Current Articles

2026, Volume 48,  Issue 9

2026, 48(9): 1-1.
Abstract:
2026, 48(9): 1-4.
Abstract:
Excellence Action Plan Leading Column
Survey on Intelligent Semantic Covert Communication
FENG Zhaoxin, XU Yifan, XING Chengwen, XU Yuhua, ZHAO Nan, WANG Jinlong
2026, 48(9): 3691-3704. doi: 10.11999/JEIT260184
Abstract:
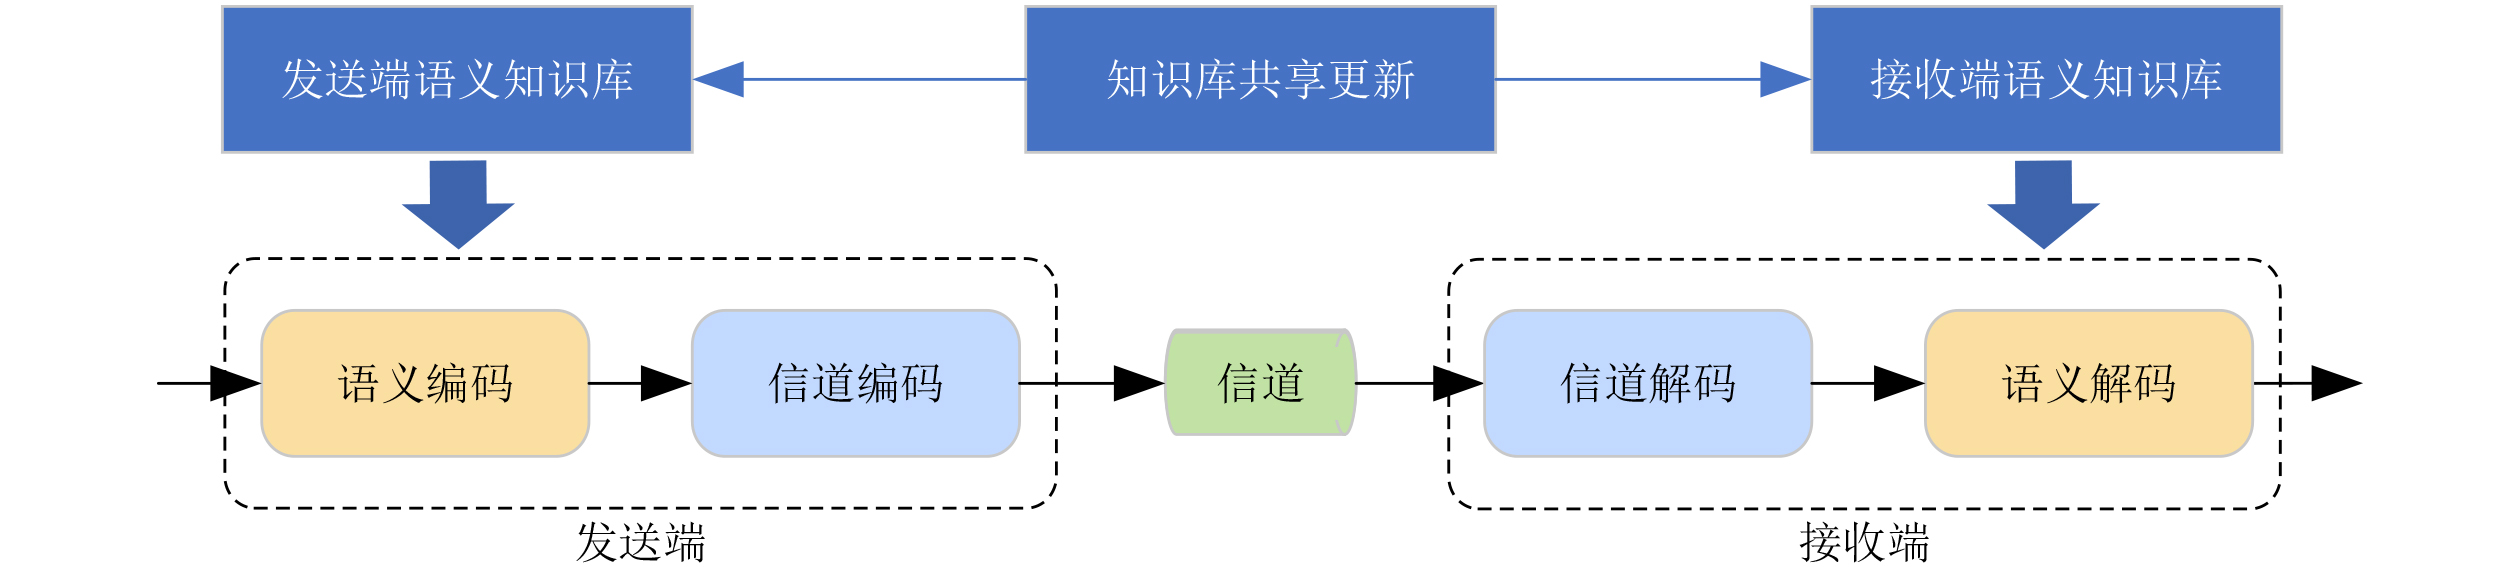
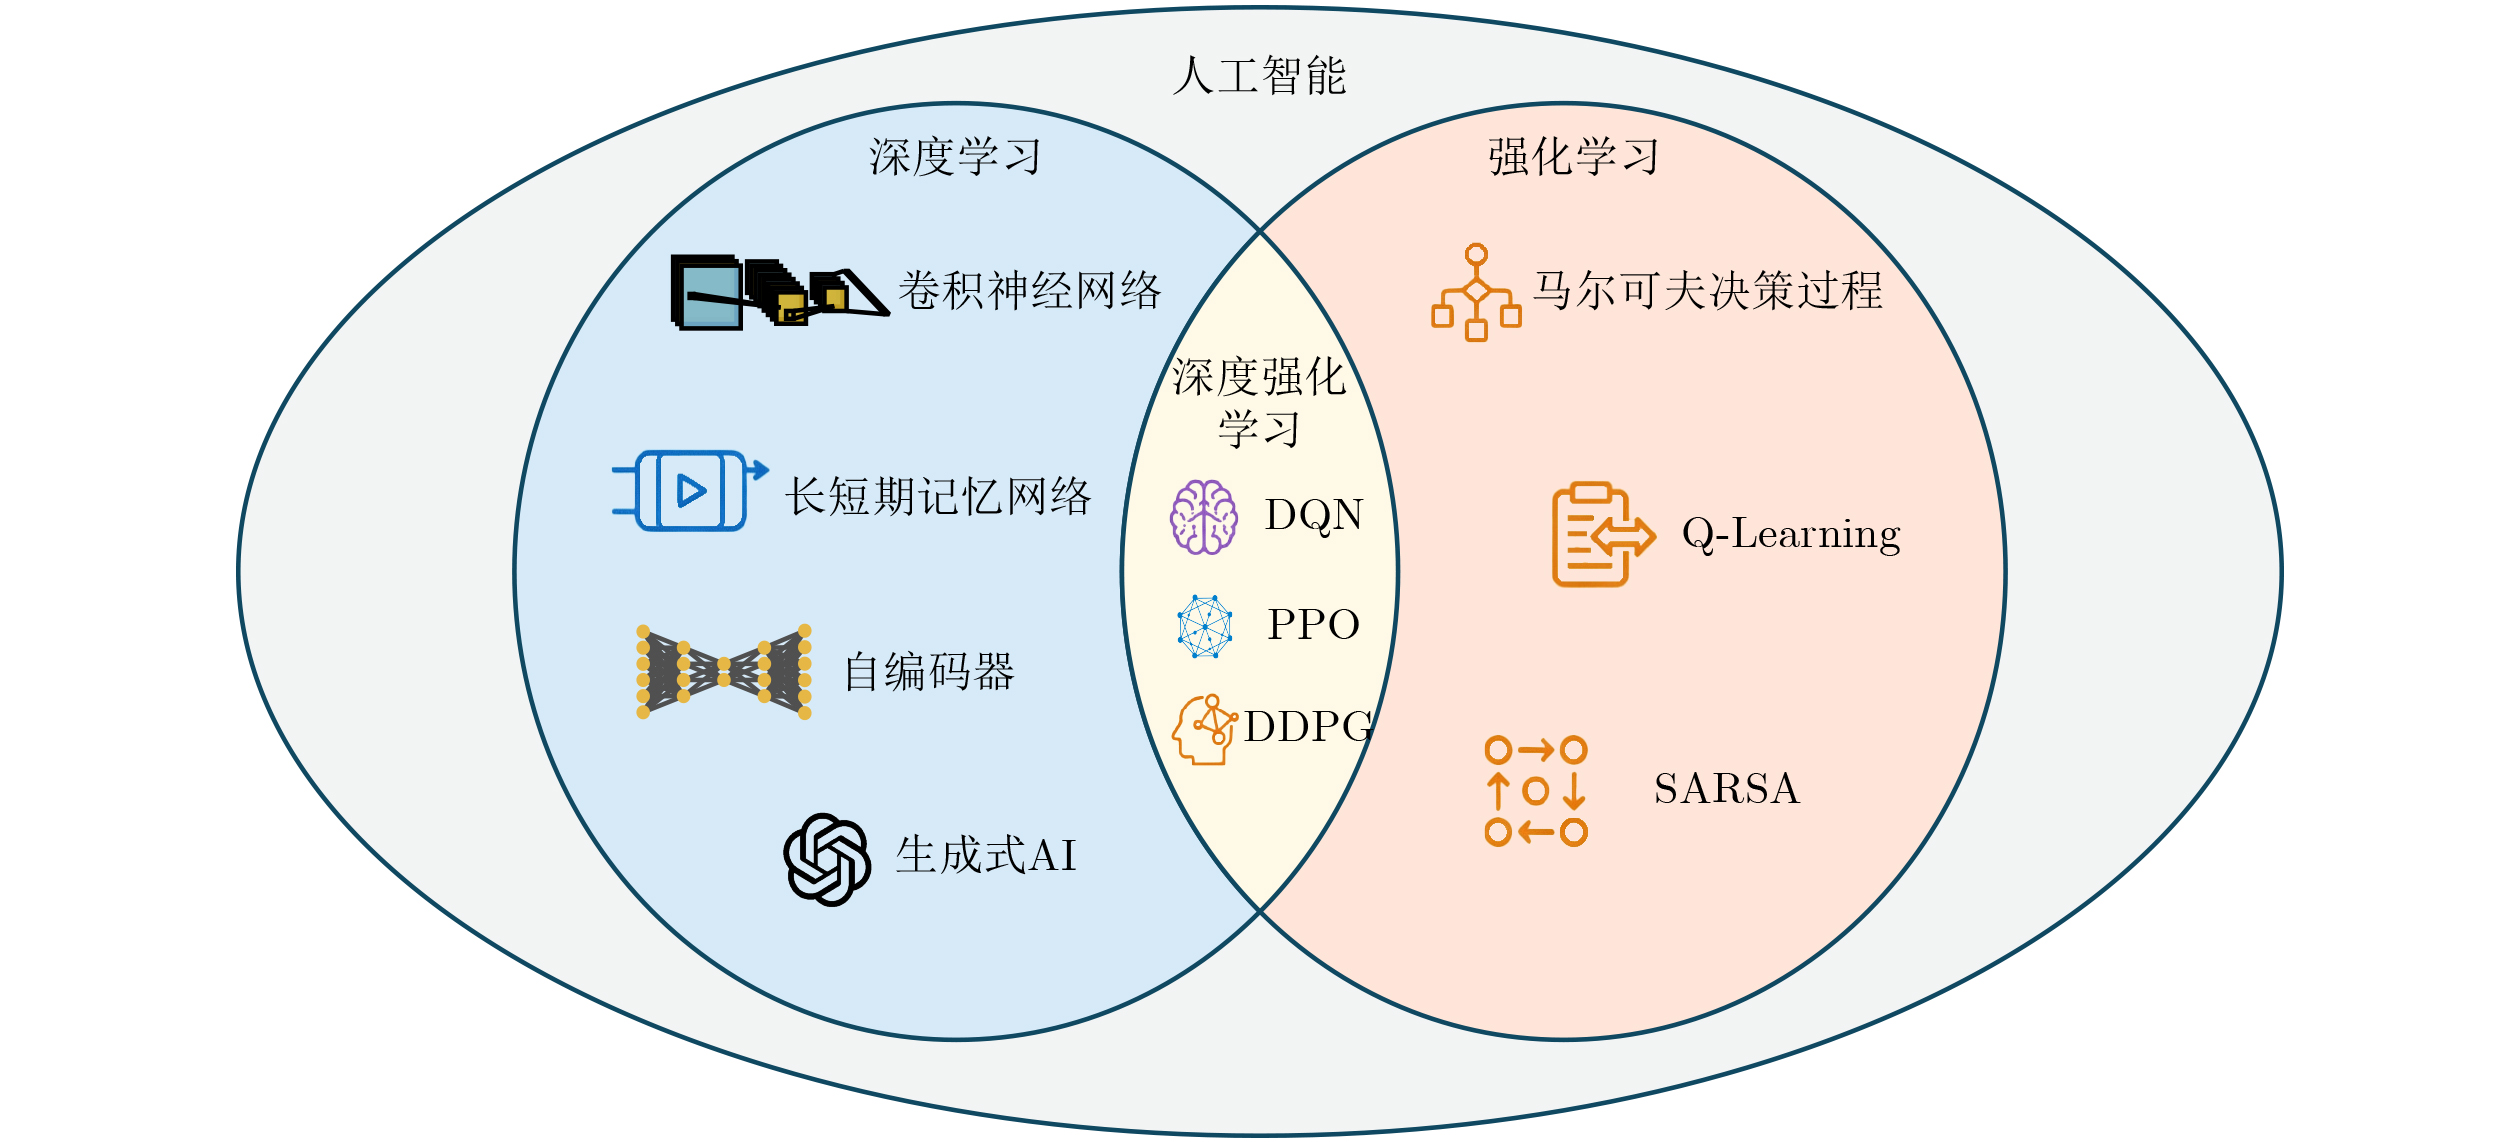
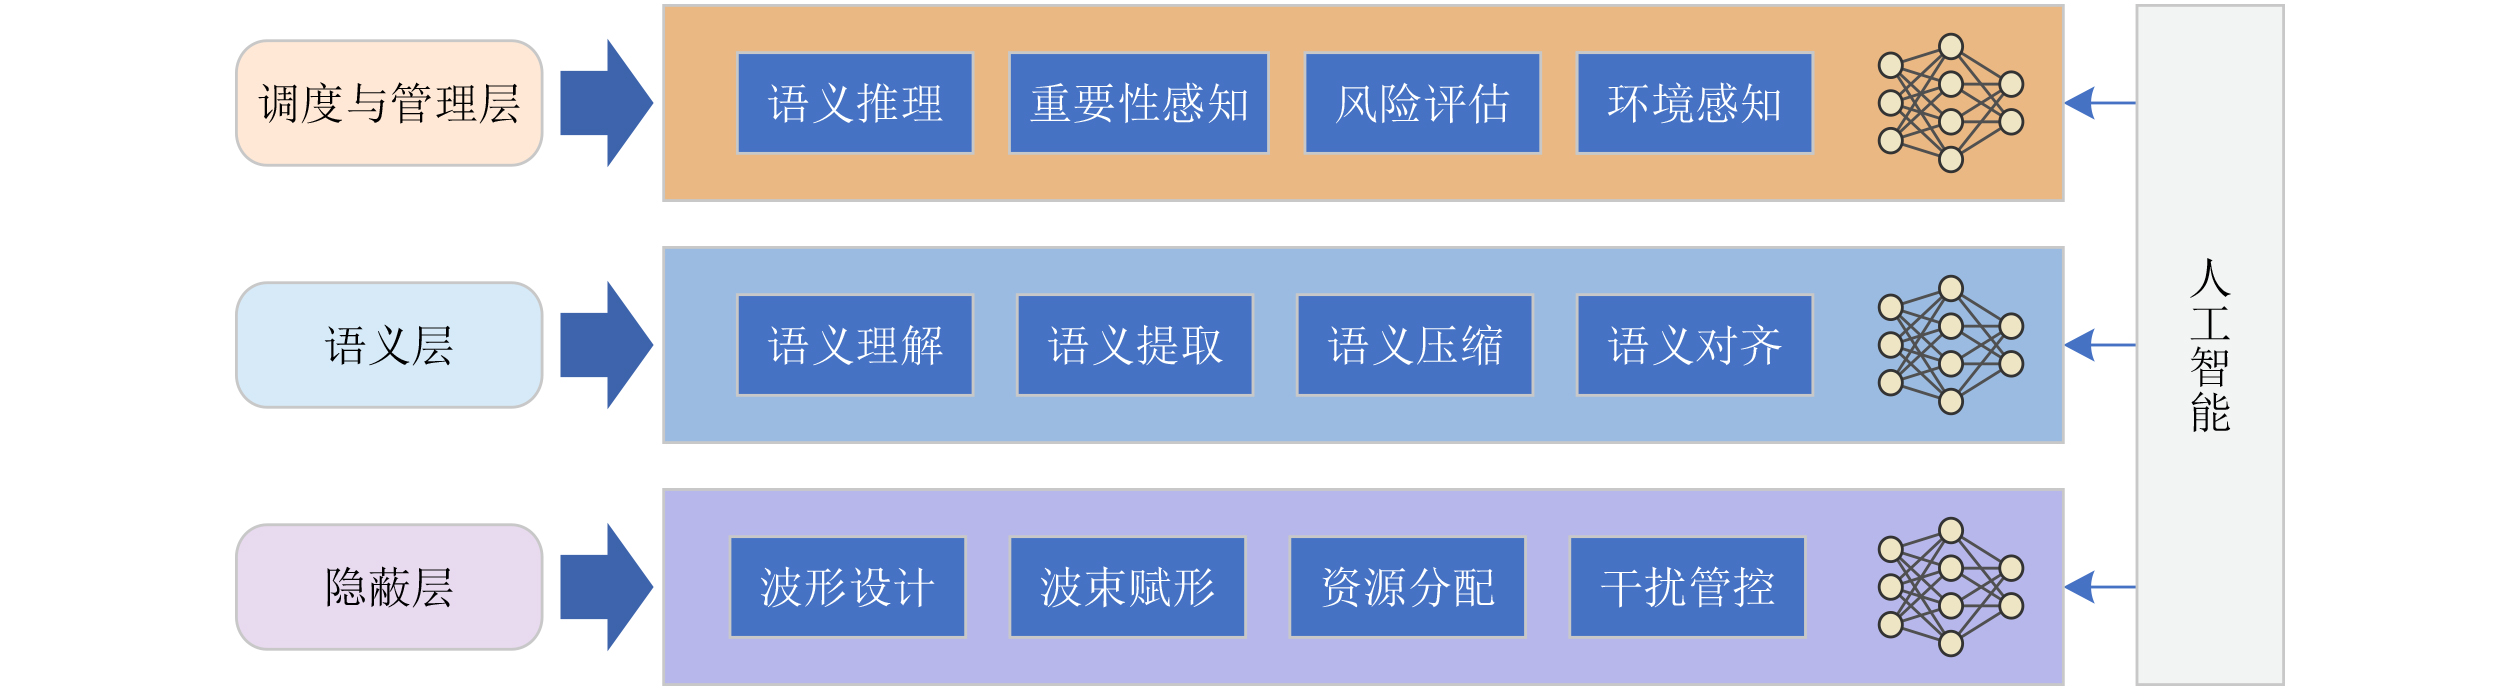
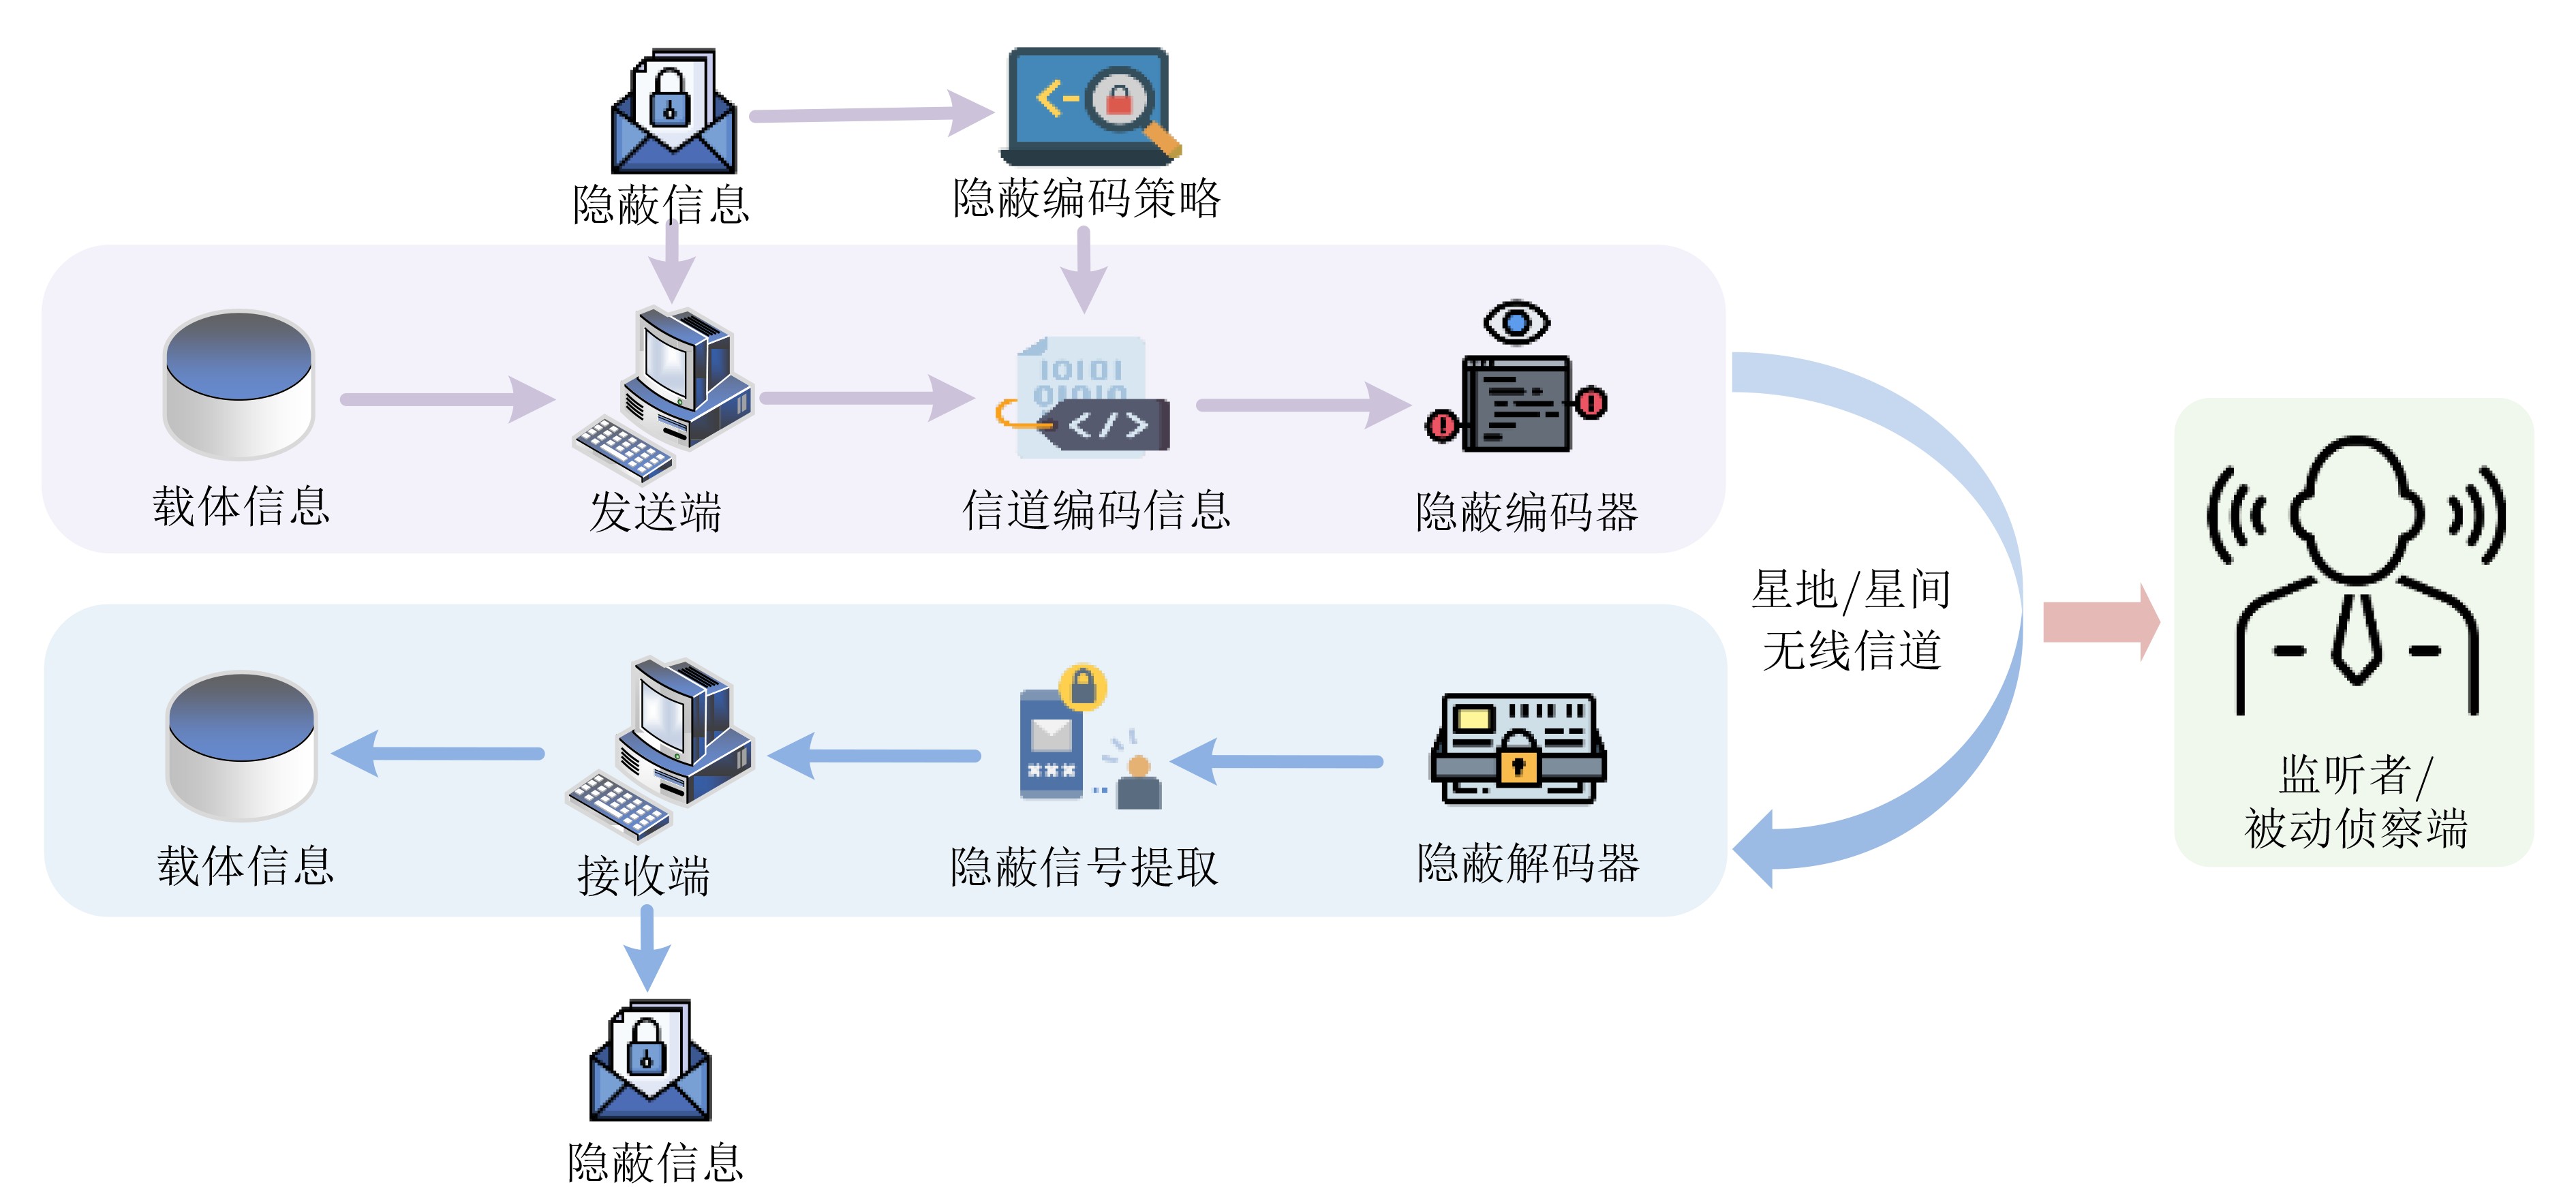
  Significance   As the Sixth-Generation mobile communication network (6G) evolves from the Internet of Everything to the Intelligent Internet of Everything, the communication paradigm is shifting from reliable bit transmission to effective semantic transmission. Semantic communication extracts and compresses task-related semantics to reduce redundancy and resource use. However, because semantic information is highly structured and task-specific, it is vulnerable to eavesdropping, inference, and attacks. Covert communication addresses this risk by hiding transmission behavior from unauthorized monitoring. With support from Artificial Intelligence (AI), covert communication can use reinforcement learning to adjust power and resource allocation in dynamic environments. Generative models can also conceal transmitted signals by learning and reproducing environmental patterns. However, strict covertness constraints limit the achievable transmission rate and make large-scale information transmission difficult. Intelligent semantic covert communication integrates semantic extraction with covert transmission, providing a reliable approach to secure and efficient 6G communications.  Progress   With the development of AI, especially deep learning for complex feature modeling, semantic communication can support efficient semantic extraction and nonlinear compression of multimodal data. Research on semantic communication has also shifted from Separate Source-Channel Coding (SSCC) to Joint Source-Channel Coding (JSCC), which supports end-to-end training and improved transmission performance. For image transmission, Convolutional Neural Networks (CNNs) use local receptive fields to capture spatial correlations. For sequential data transmission, Long Short-Term Memory (LSTM) networks use gating mechanisms to maintain temporal coherence. In covert communication, Generative Adversarial Networks (GANs) and diffusion models can learn the statistical patterns of environmental noise in the time, frequency, and spatial domains, thereby concealing transmitted signals. These methods reduce the effectiveness of unauthorized monitoring and detection, and improve system adaptability in dynamic environments. AI also improves autonomous decision-making in dynamic covert communication. By modeling covert transmission as a Markov Decision Process (MDP), Deep Reinforcement Learning (DRL) can learn resource allocation strategies through interaction with the environment. This approach reduces computational complexity compared with traditional convex optimization methods. By integrating semantic extraction and covert transmission, intelligent semantic covert communication further supports semantic-driven covert transmission. Large Language Models (LLMs) can evaluate semantic sensitivity and contextual risks, enabling selective covert transmission of sensitive semantic information.  Conclusions  Research on intelligent semantic covert communication shows the advantages of coordinated semantic perception and physical-layer covert mechanisms. AI improves semantic extraction efficiency and strengthens adaptation to dynamic and complex environments. By integrating semantic understanding with covert transmission strategies, intelligent semantic covert communication supports both efficiency and security for ubiquitous 6G services.  Prospects   Future research on intelligent semantic covert communication should address several key challenges, including AI-enabled detection, unified semantic metrics, lightweight model design, multimodal semantic alignment, system interpretability, and semantic hallucination. Active threat detection and adaptive defense strategies are needed to counter AI-driven surveillance. Causal reasoning in Large Multimodal Models (LMMs) can help mitigate semantic hallucination and improve data transmission reliability. Advances in model compression and cloud-edge collaboration are also needed to deploy high-complexity AI models on resource-limited terminals. With the rapid development of AI, intelligent semantic covert communication is expected to provide core support for intelligent connectivity of everything and help build more secure, efficient, and reliable 6G networks.
Survey of Satellite Covert Communications: Status, Key Technologies, and Future Challenges
DENG Hao, SUN Weiyuan, ZHU Zhengyu, PAN Gaofeng, SUN Gangcan
2026, 48(9): 3705-3720. doi: 10.11999/JEIT260177
Abstract:
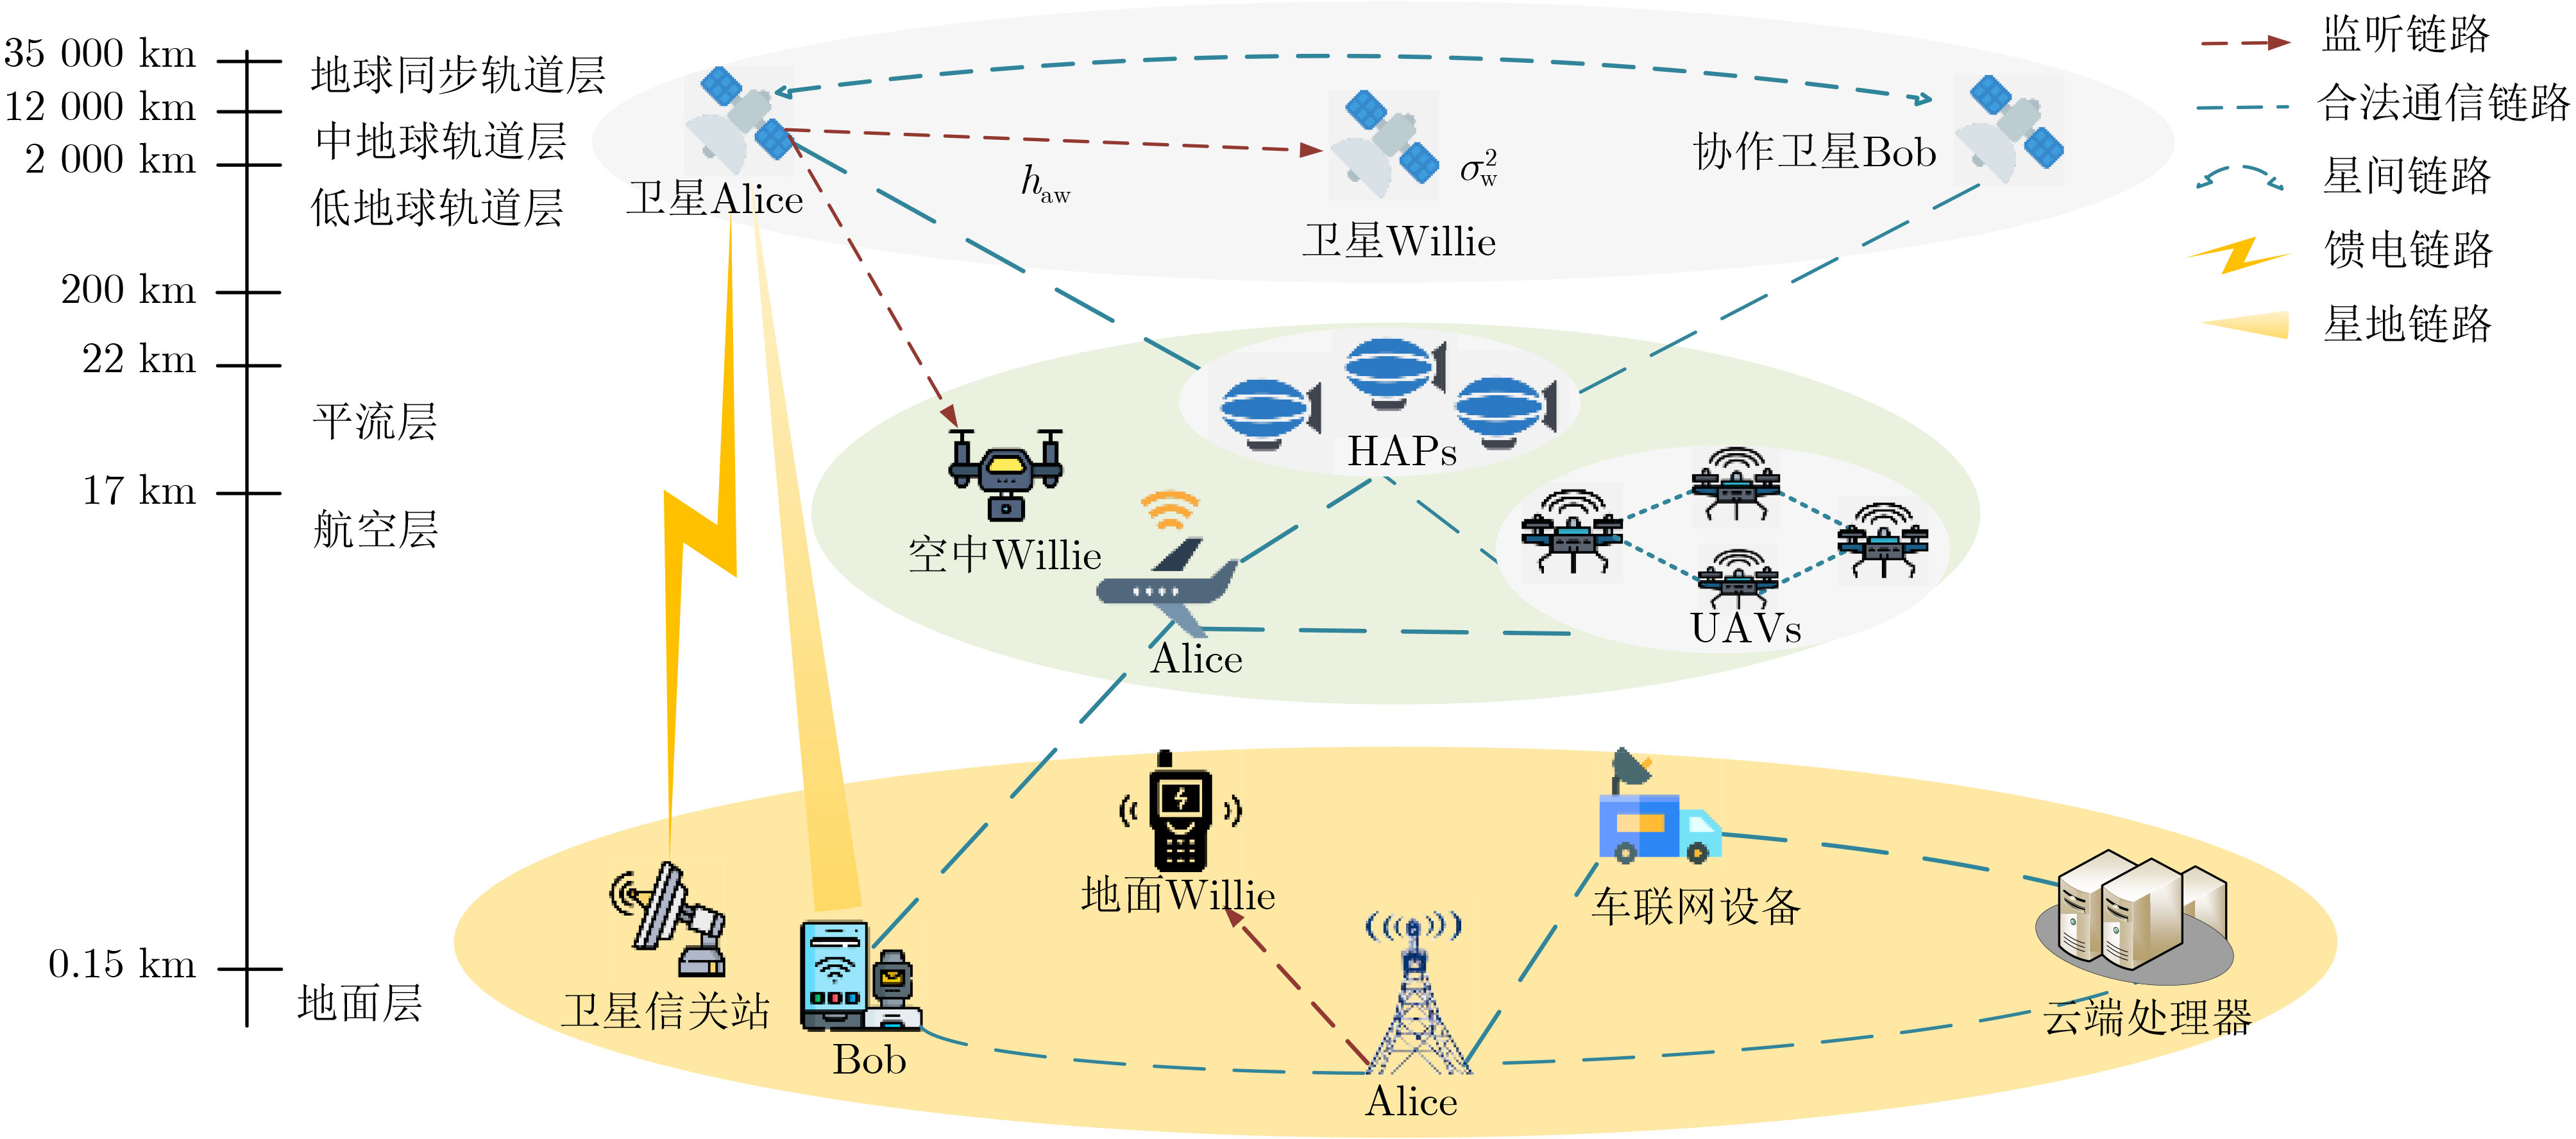
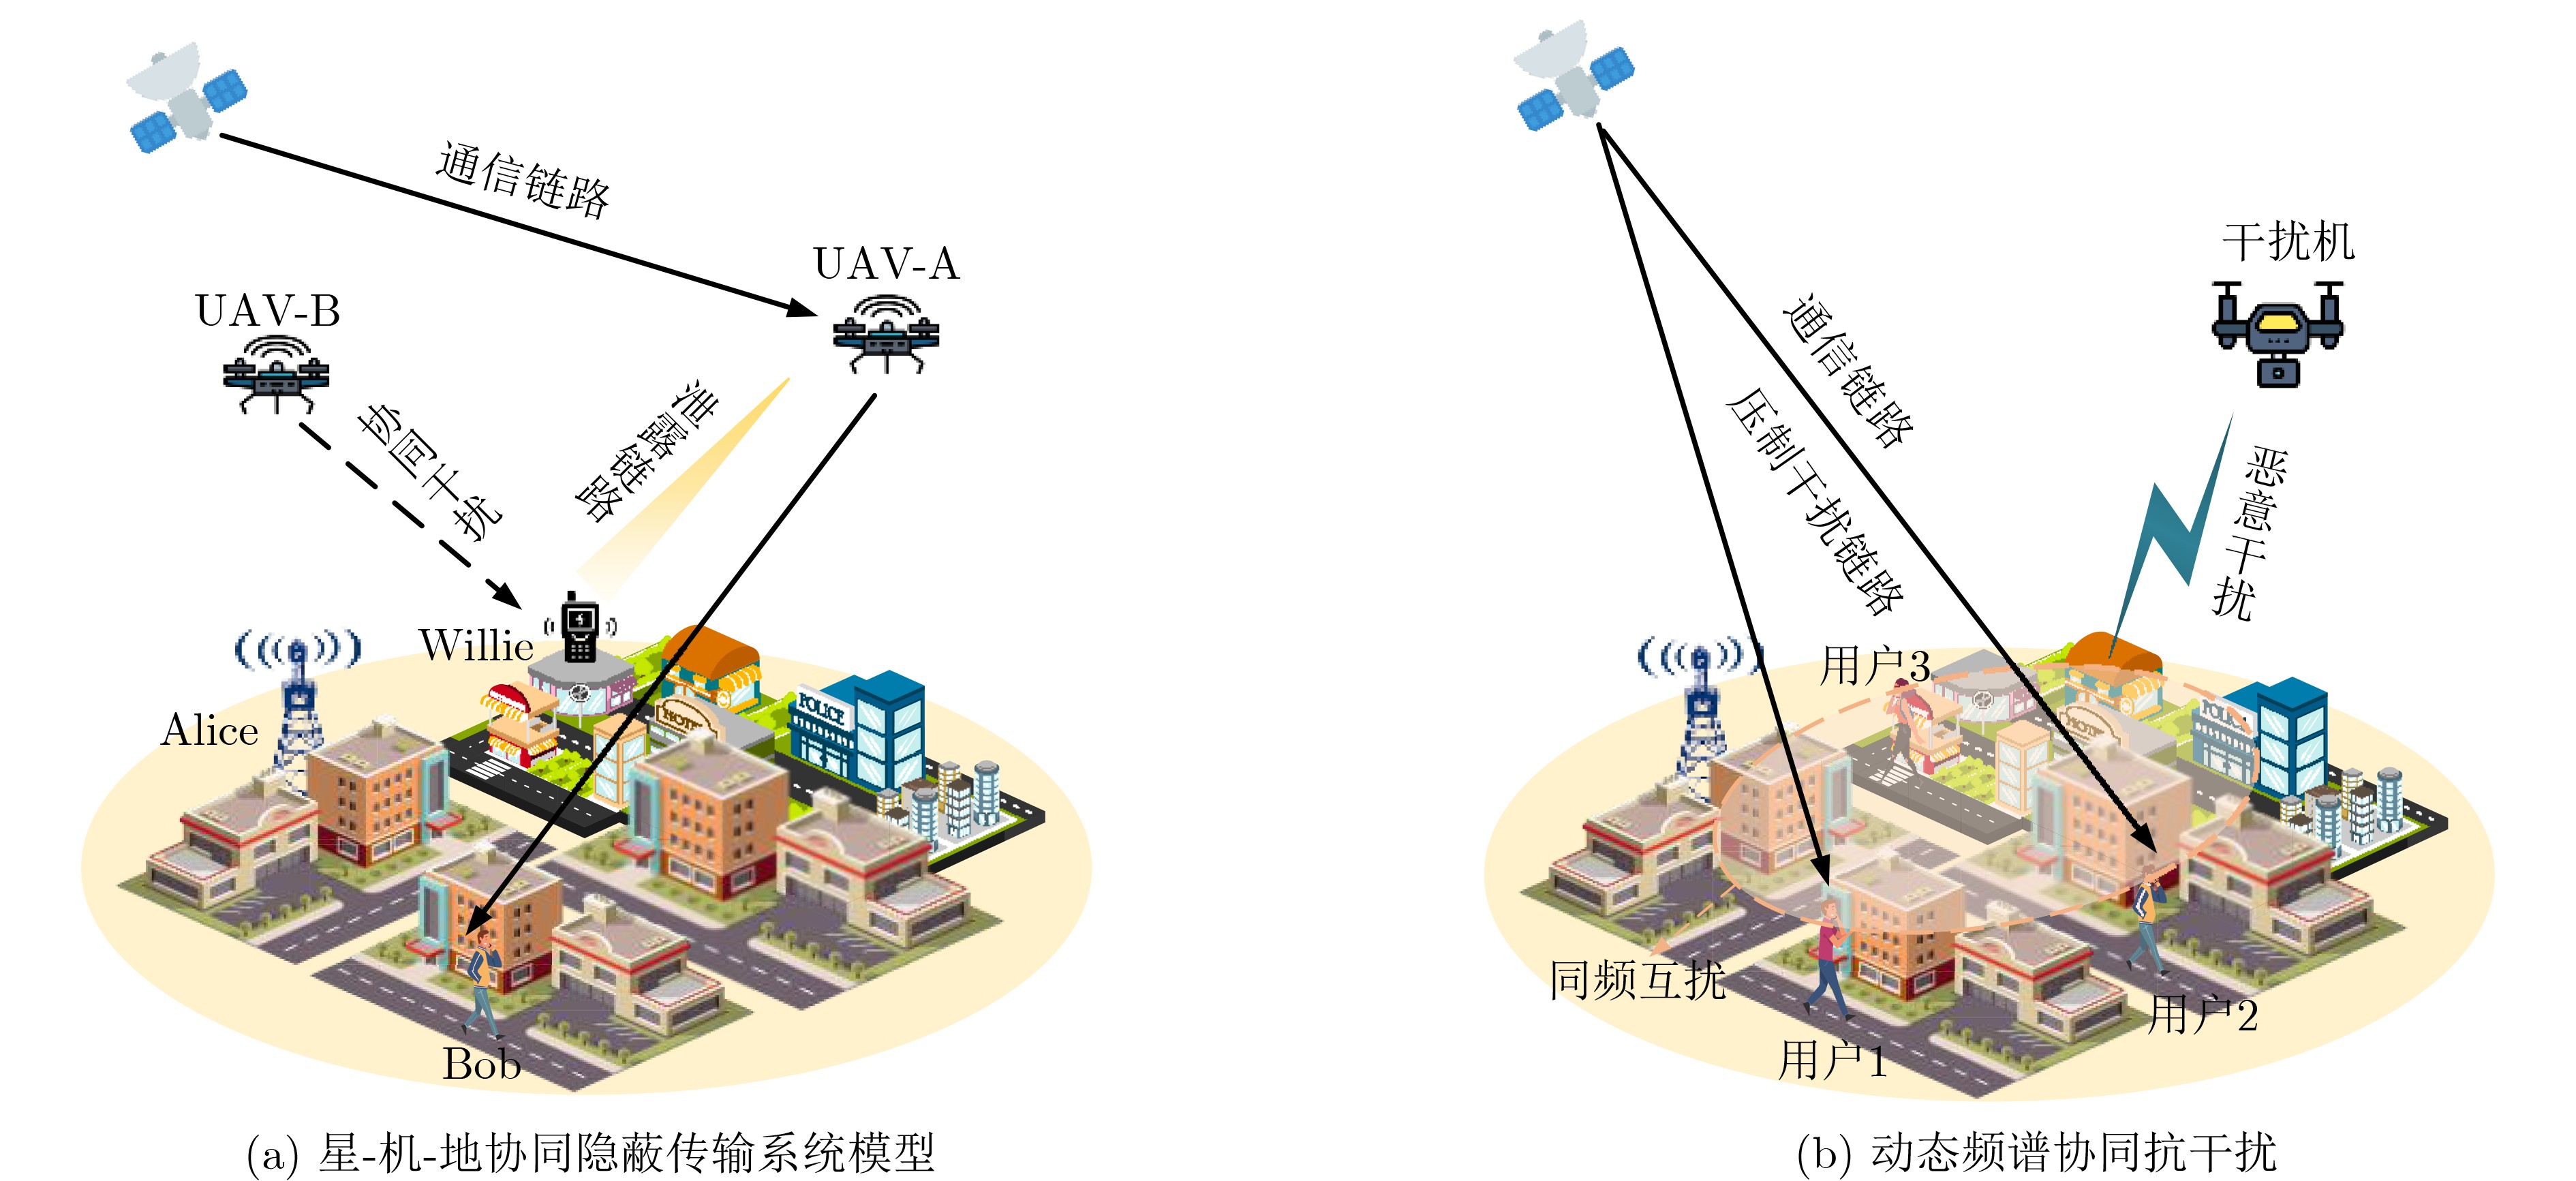
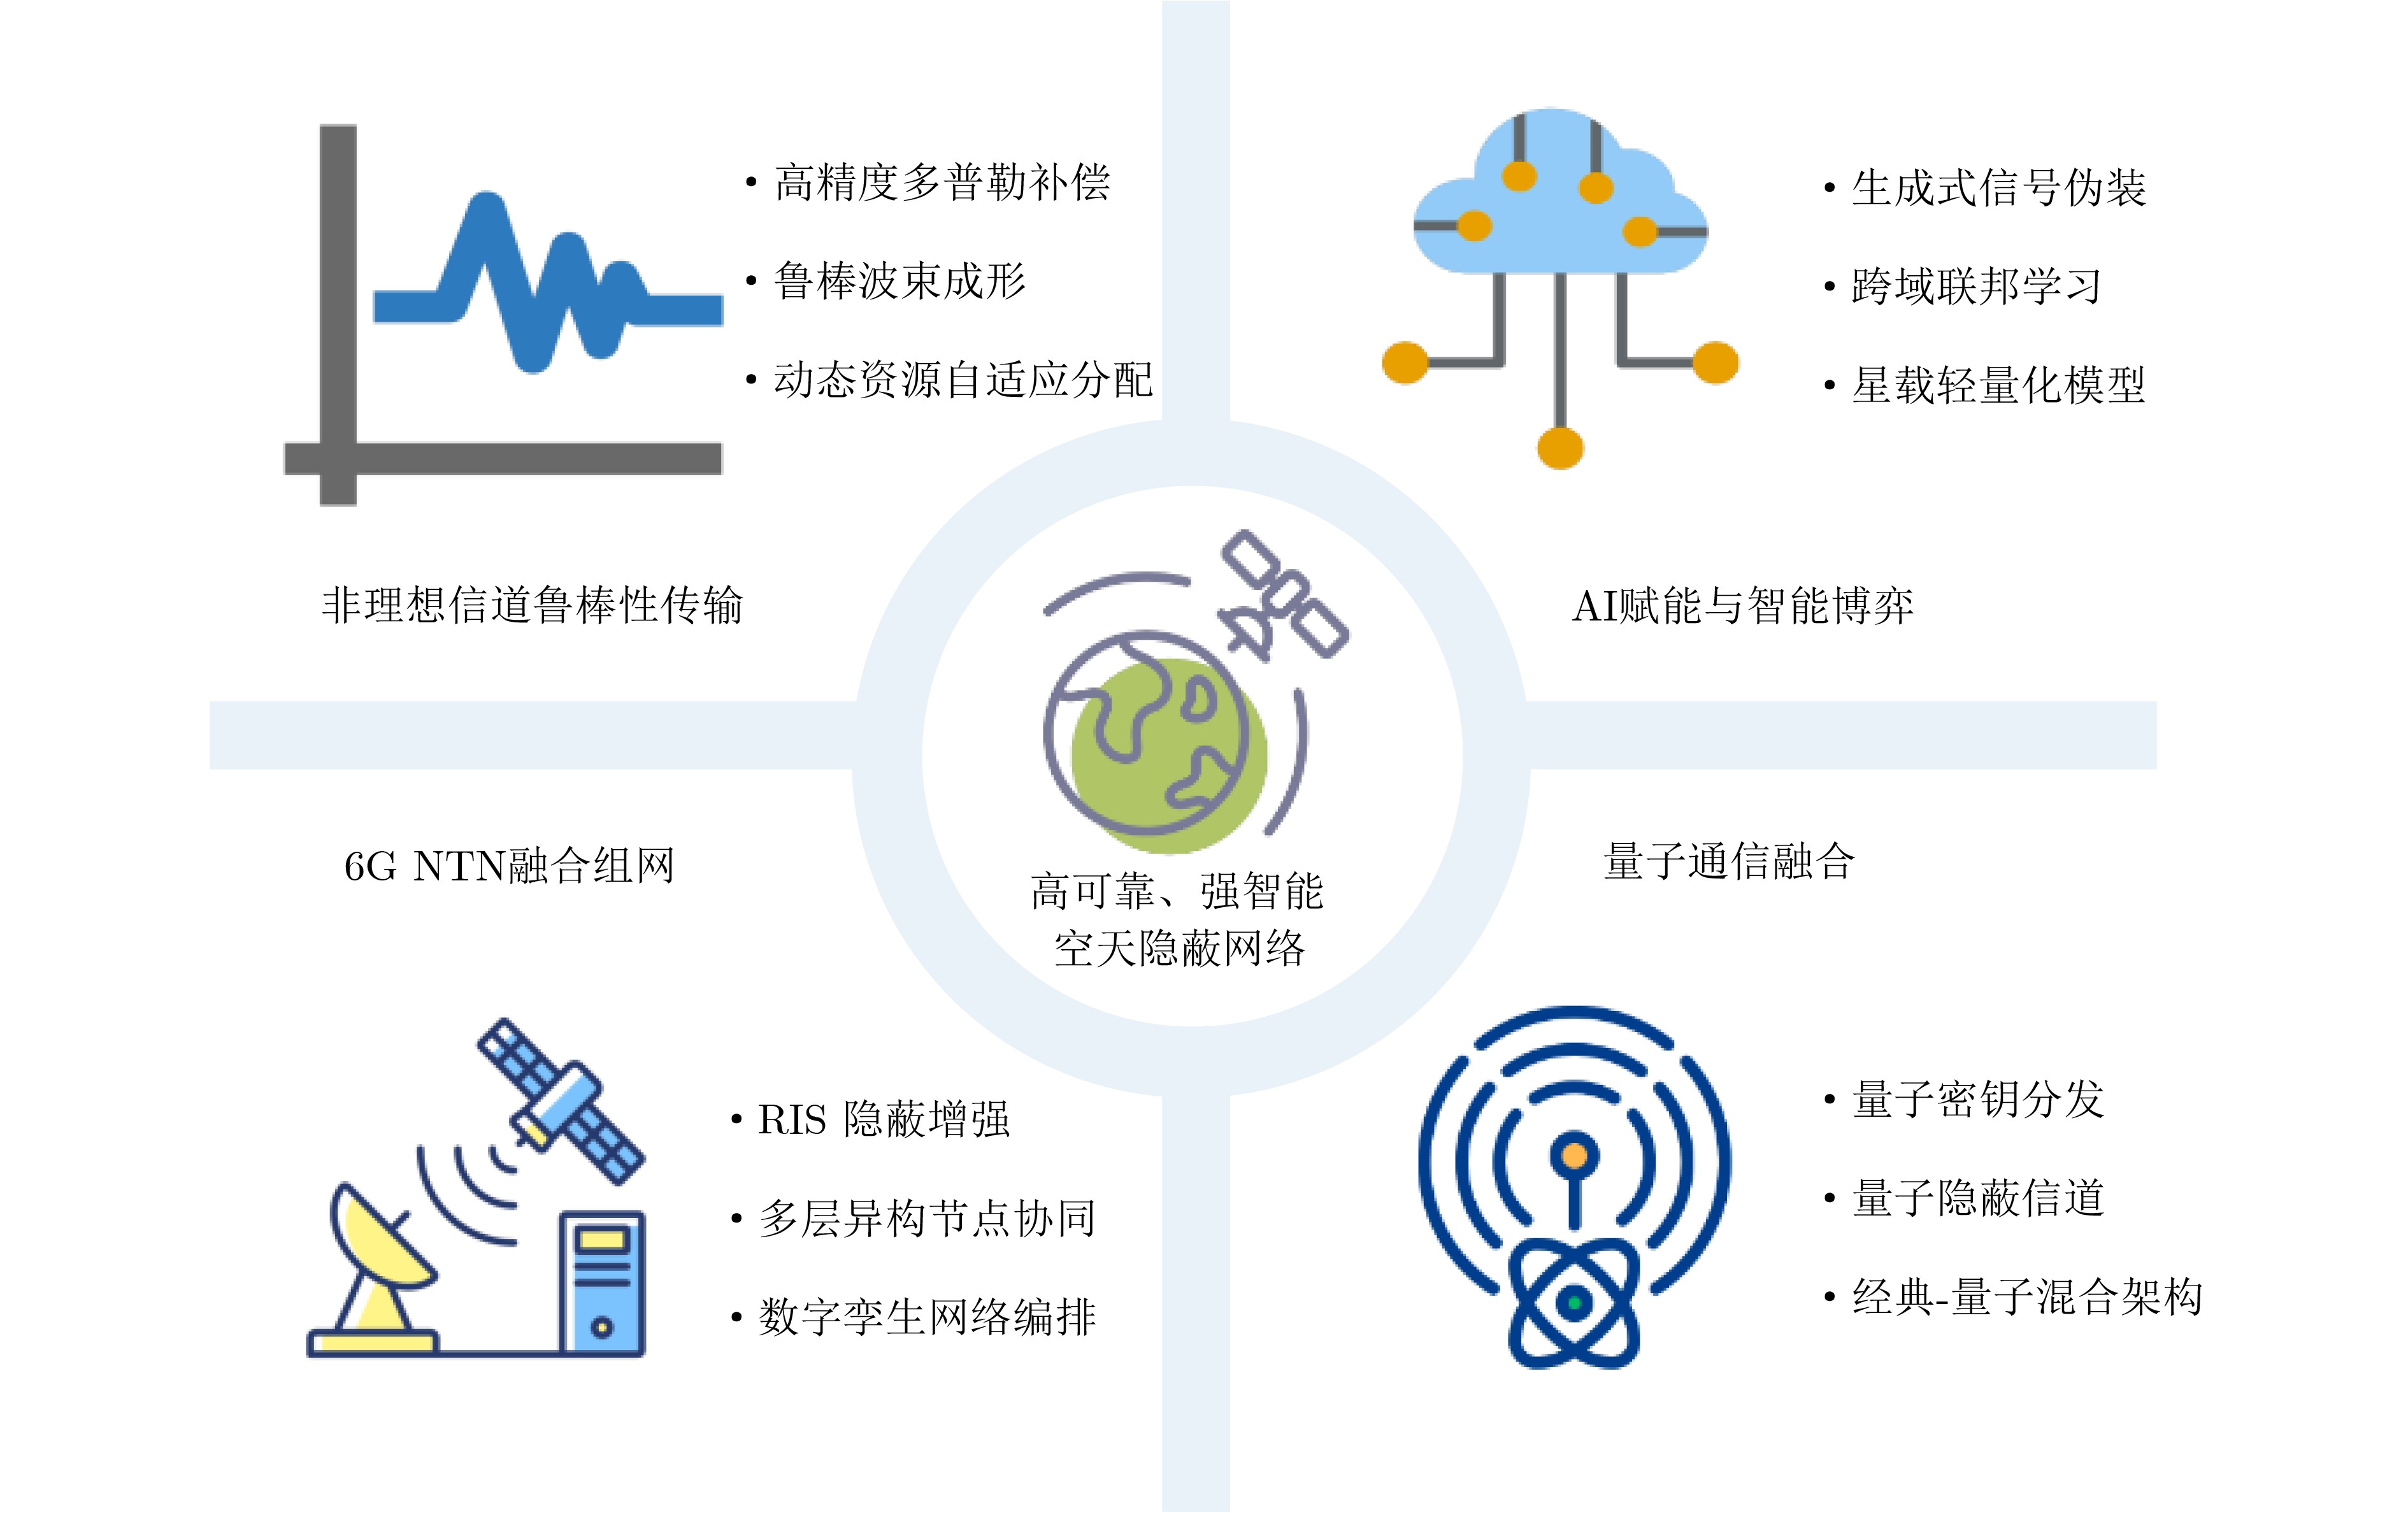
  Objective  This survey systematically reviews the theoretical foundations, key technologies, and future challenges of Satellite Covert Communications. Based on the classical Alice-Bob-Willie model, the effects of satellite channel characteristics on covert communication capacity are analyzed to establish the theoretical basis. The network architecture of Satellite Covert Communications under the space-air-ground three-layer framework (Fig. 1) is summarized. Core technologies and optimization methods, including signal camouflage coding, beamforming, spectrum agility, Quantum Key Distribution (QKD), and Artificial Intelligence (AI)-assisted techniques, are systematically reviewed. Major security threats and corresponding multi-layer defense strategies, including Physical-Layer Security (PLS) and intelligent collaborative defense, are also summarized. This survey provides a theoretical foundation and technical guidance for developing highly secure and intelligent Satellite Covert Communications systems.  Significance   The significance of this survey lies in its systematic integration of the theoretical framework and key technologies for Satellite Covert Communications. To address the threats of detection, interference, and eavesdropping in open satellite communication environments, representative space-air-ground integrated architectures reported in the literature are reviewed. These architectures overcome the limitation of conventional encryption techniques, which protect only information content, by reducing statistical distinguishability at the physical layer to achieve a low probability of detection. The constraints imposed by satellite channels on covert communication capacity are clarified through the modified Square Root Law. Enhancement strategies based on adaptive coding, beamforming, spectrum agility, and related techniques are reviewed to establish a comprehensive technical framework for Satellite Covert Communications. These advances provide theoretical support and technical guidance for constructing highly survivable and secure space-air-ground integrated communication networks, with important applications in national defense, emergency communications, and Sixth-Generation (6G) Non-Terrestrial Networks (NTNs).  Progress   Existing studies demonstrate that Doppler spread has a dual effect on covert communication capacity. It increases the missed detection probability while introducing signal distortion, making adaptive coding necessary to maintain reliable transmission. The differences in detection capability among terrestrial, aerial, and orbital wardens (Willie) are quantified (Table 1), providing a theoretical basis for hierarchical defense design. Existing studies have also proposed multi-level covertness enhancement strategies. AI-assisted dynamic camouflage combined with sparse coding exploits background noise, inter-satellite links, and dynamic beamforming to improve covert throughput. At the network level, cooperative Unmanned Aerial Vehicle (UAV)-assisted transmission and dynamic spectrum coordination are identified as representative enhancement approaches (Fig. 3). Furthermore, a hierarchical defense framework is summarized from representative studies. This framework combines Reconfigurable Intelligent Surface (RIS)-assisted signal control, Stackelberg game-based incentives for cooperative jamming, XOR network coding, and federated learning for cross-domain threat feature sharing. These advances provide effective solutions for improving the covertness and security of Satellite Covert Communications.  Conclusions  This survey systematically reviews the theoretical foundations and recent advances in Satellite Covert Communications. The integration of multi-layer satellite constellations, dynamic aerial relay platforms, and software-defined networks supported by Quantum Key Distribution (QKD) enables resilient global covert communication. Extending the Alice-Bob-Willie model to practical satellite channels with non-ideal propagation characteristics provides guidance for covert throughput optimization and secure transmission. AI-assisted coding and waveform design further enable adaptive transmission strategies that respond to dynamic channel conditions. Future research should focus on robust covert transmission in dynamic Low Earth Orbit (LEO) environments, scalable constellation management, and the deep integration of AI and quantum technologies into 6G NTNs. The convergence of programmable satellites, Reconfigurable Intelligent Surfaces (RIS), and advanced machine learning is expected to further improve secure space communications.  Prospects   Future research should focus on four major directions: robust covert transmission under non-ideal channels, AI-assisted intelligent decision-making, integrated 6G NTN networking, and the integration of quantum communication technologies (Fig. 4). High-precision Doppler compensation techniques should be developed to mitigate rapid channel variations in LEO satellite systems. Robust covert transmission schemes should also be developed for imperfect Channel State Information (CSI), with deep reinforcement learning providing real-time resource optimization. Future studies should strengthen the integration of AI and quantum technologies by combining cross-layer QKD with covert transmission protocols and exploiting Software-Defined Satellite (SDS) capabilities for adaptive strategy deployment. Additional opportunities include using RIS to enhance spatial-domain signal control and applying blockchain technology to address trust management in multi-node cooperative networks. Efficient lightweight onboard algorithms and coordinated international frameworks for spectrum and orbital resource management should also be developed to support future Satellite Covert Communications systems.
A Survey of Quantum Covert Communication Integration Schemes and Application Scenarios
SUN Yiheng, XU Yongjun, ZHANG Haibo, HUANG Zishan
2026, 48(9): 3721-3729. doi: 10.11999/JEIT260282
Abstract:
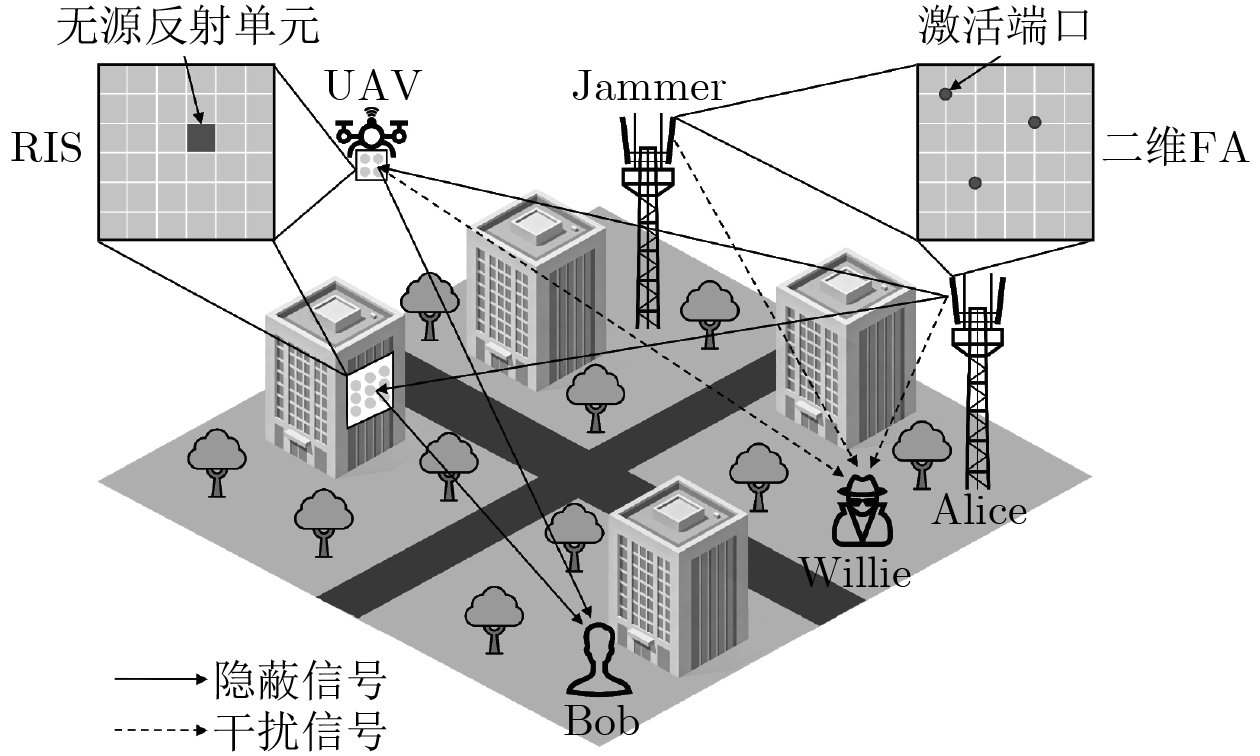
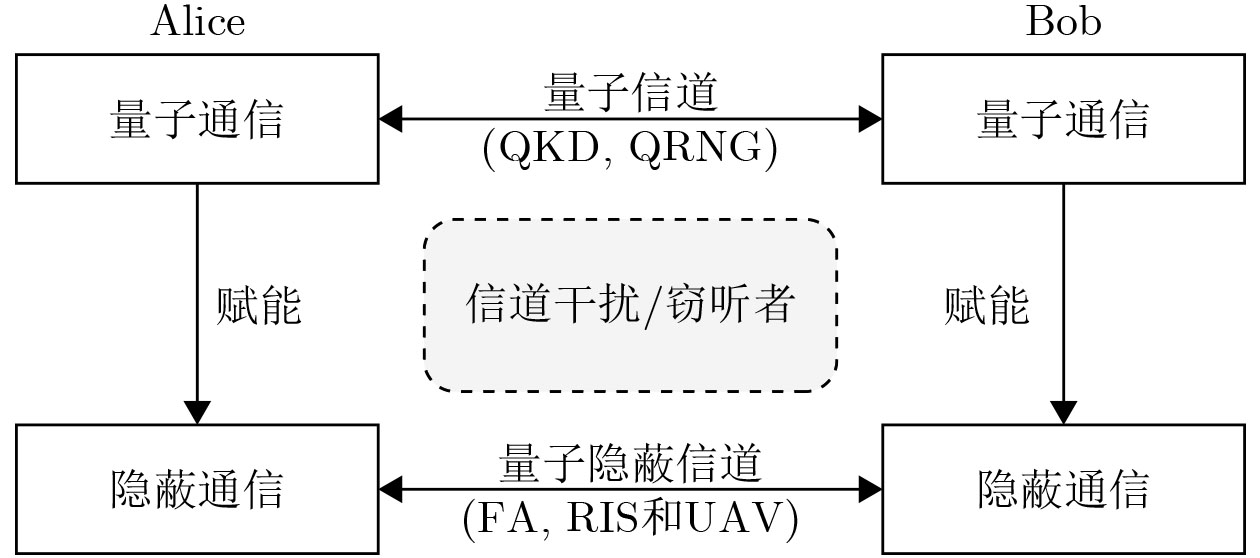
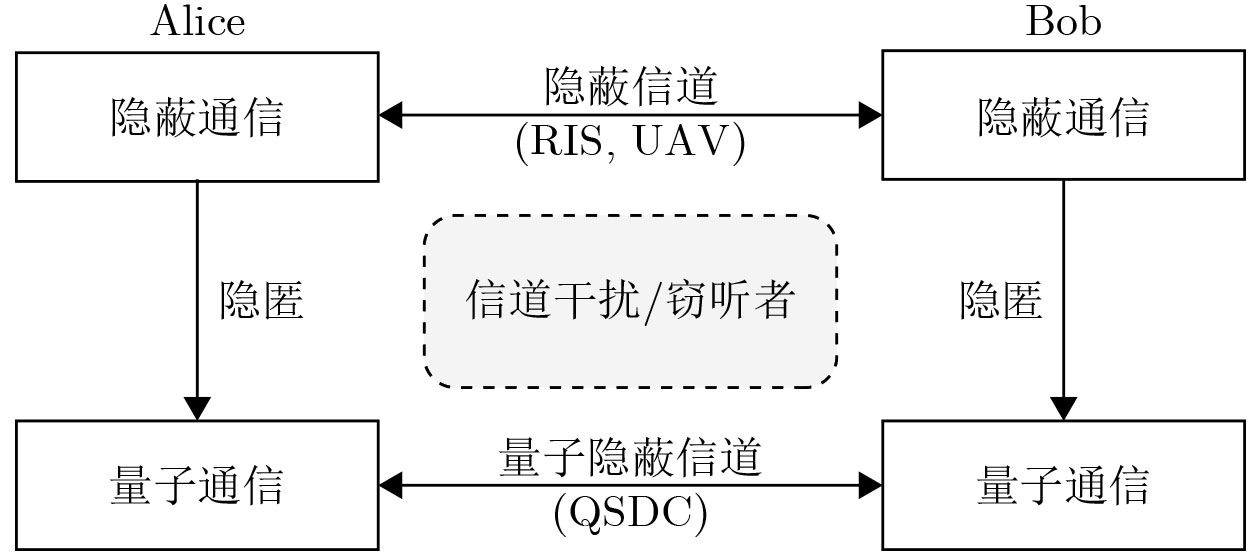
  Significance   With the growing demand for secure network communications, research on covert communication and quantum communication continues to advance. However, current covert communication still has inherent security vulnerabilities and risks of information leakage. The transmission reliability of quantum communication is also limited by eavesdropping and harmful interference, partly because the communication behavior itself is not fully hidden. Quantum covert communication has therefore attracted increasing attention, as it integrates behavior concealment with unconditional security. This paper surveys quantum covert communication integration schemes and application scenarios. It first introduces the principles of covert communication and typical enabling techniques. It then reviews quantum communication protocols and key quantum techniques. Three types of integration schemes are further summarized according to different application scenarios. This survey provides a reference for the design of secure communication networks and for the development of future quantum covert communication systems.  Progress   This paper reviews recent advances in quantum covert communication integration schemes and application scenarios. The principles of covert communication and key enabling techniques are first discussed, including Fluid Antenna (FA), Reconfigurable Intelligent Surface (RIS), and Unmanned Aerial Vehicle (UAV). FA reshapes wireless channel characteristics by dynamically adjusting antenna configuration, including shape, position, and radiation direction. This capability helps regulate the spatial correlation of multipath components and reduce information leakage. In Non-Line-of-Sight (NLOS) scenarios, RIS can dynamically change the propagation direction of incident signals. It can improve signal reception quality at the intended receiver, reduce signal leakage to monitoring users, and increase Channel State Information (CSI) uncertainty. In flexible or temporary communication networks, UAVs can adjust network topology and channel conditions through mobility. This helps create favorable channels for intended receivers while making stable monitoring more difficult. Key protocols and techniques for quantum communication are then introduced. These include BB84, B92, and E91 for Quantum Key Distribution (QKD), and BF02 and Two-Step for Quantum Secure Direct Communication (QSDC). Quantum repeaters and Quantum Random Number Generator (QRNG) are also reviewed. According to application scenarios and integration mechanisms, quantum covert communication integration schemes are classified into the Enabling Integration Scheme, the Concealment Integration Scheme, and the Symbiotic Integration Scheme. The Enabling Integration Scheme uses the unconditional security of quantum communication to compensate for security vulnerabilities in covert communication. The Concealment Integration Scheme uses covert communication enabling techniques to reduce the exposure probability of quantum communication behavior. The Symbiotic Integration Scheme integrates the advantages of covert communication and quantum communication to support mutual enhancement and deep system-level fusion. Finally, key challenges are discussed, including stringent equipment precision requirements, low resource allocation efficiency, and barriers to large-scale application. Future research directions are also identified, including high-precision communication equipment, dynamic resource management, deployment cost control, and standardized development.  Prospects   Despite the progress in preliminary applications and specific scenarios, research on quantum covert communication remains at an early stage. As application scenarios become more diverse and complex, future studies should focus on challenges that limit further development and large-scale application. Stringent equipment precision requirements are a primary challenge because they restrict reliable transmission distance and system stability. Low resource allocation efficiency is another challenge. Quantum covert communication systems that generate quantum entanglement over lossy channels remain constrained by the Square Root Law (SRL), while signal transmission is often bursty and dynamic. High deployment costs and the lack of unified standards also hinder practical implementation. To address these challenges, future research should focus on the research and development of high-precision communication equipment, dynamic resource management, deployment cost control, and standardized development. These efforts may support high-performance, large-scale, and multi-scenario quantum covert communication.  Conclusions  This paper surveys quantum covert communication, with emphasis on integration schemes and application scenarios. The fundamentals and typical enabling techniques of covert communication are first reviewed, including its Low Probability of Detection (LPD) security paradigm and channel characteristics. Typical protocols and key techniques for quantum communication are then examined, including QKD, QSDC, quantum repeaters, and QRNG. Three types of quantum covert communication integration schemes are further classified according to their integration mechanisms and application scenarios. Existing challenges are identified, including stringent equipment precision requirements, low resource allocation efficiency, and barriers to large-scale application. Future research directions include high-precision communication equipment, dynamic resource management, deployment cost control, and standardized development. These directions provide a useful reference for advancing quantum covert communication in future secure networks.
Wireless Communication and Internet of Things
Non-Terrestrial Network Architecture and Key Technologies for Civil Aviation
LIU Xiangnan, QIU Yu, HUANG Zhipeng, ZHANG Haijun
2026, 48(9): 3730-3745. doi: 10.11999/JEIT260348
Abstract:
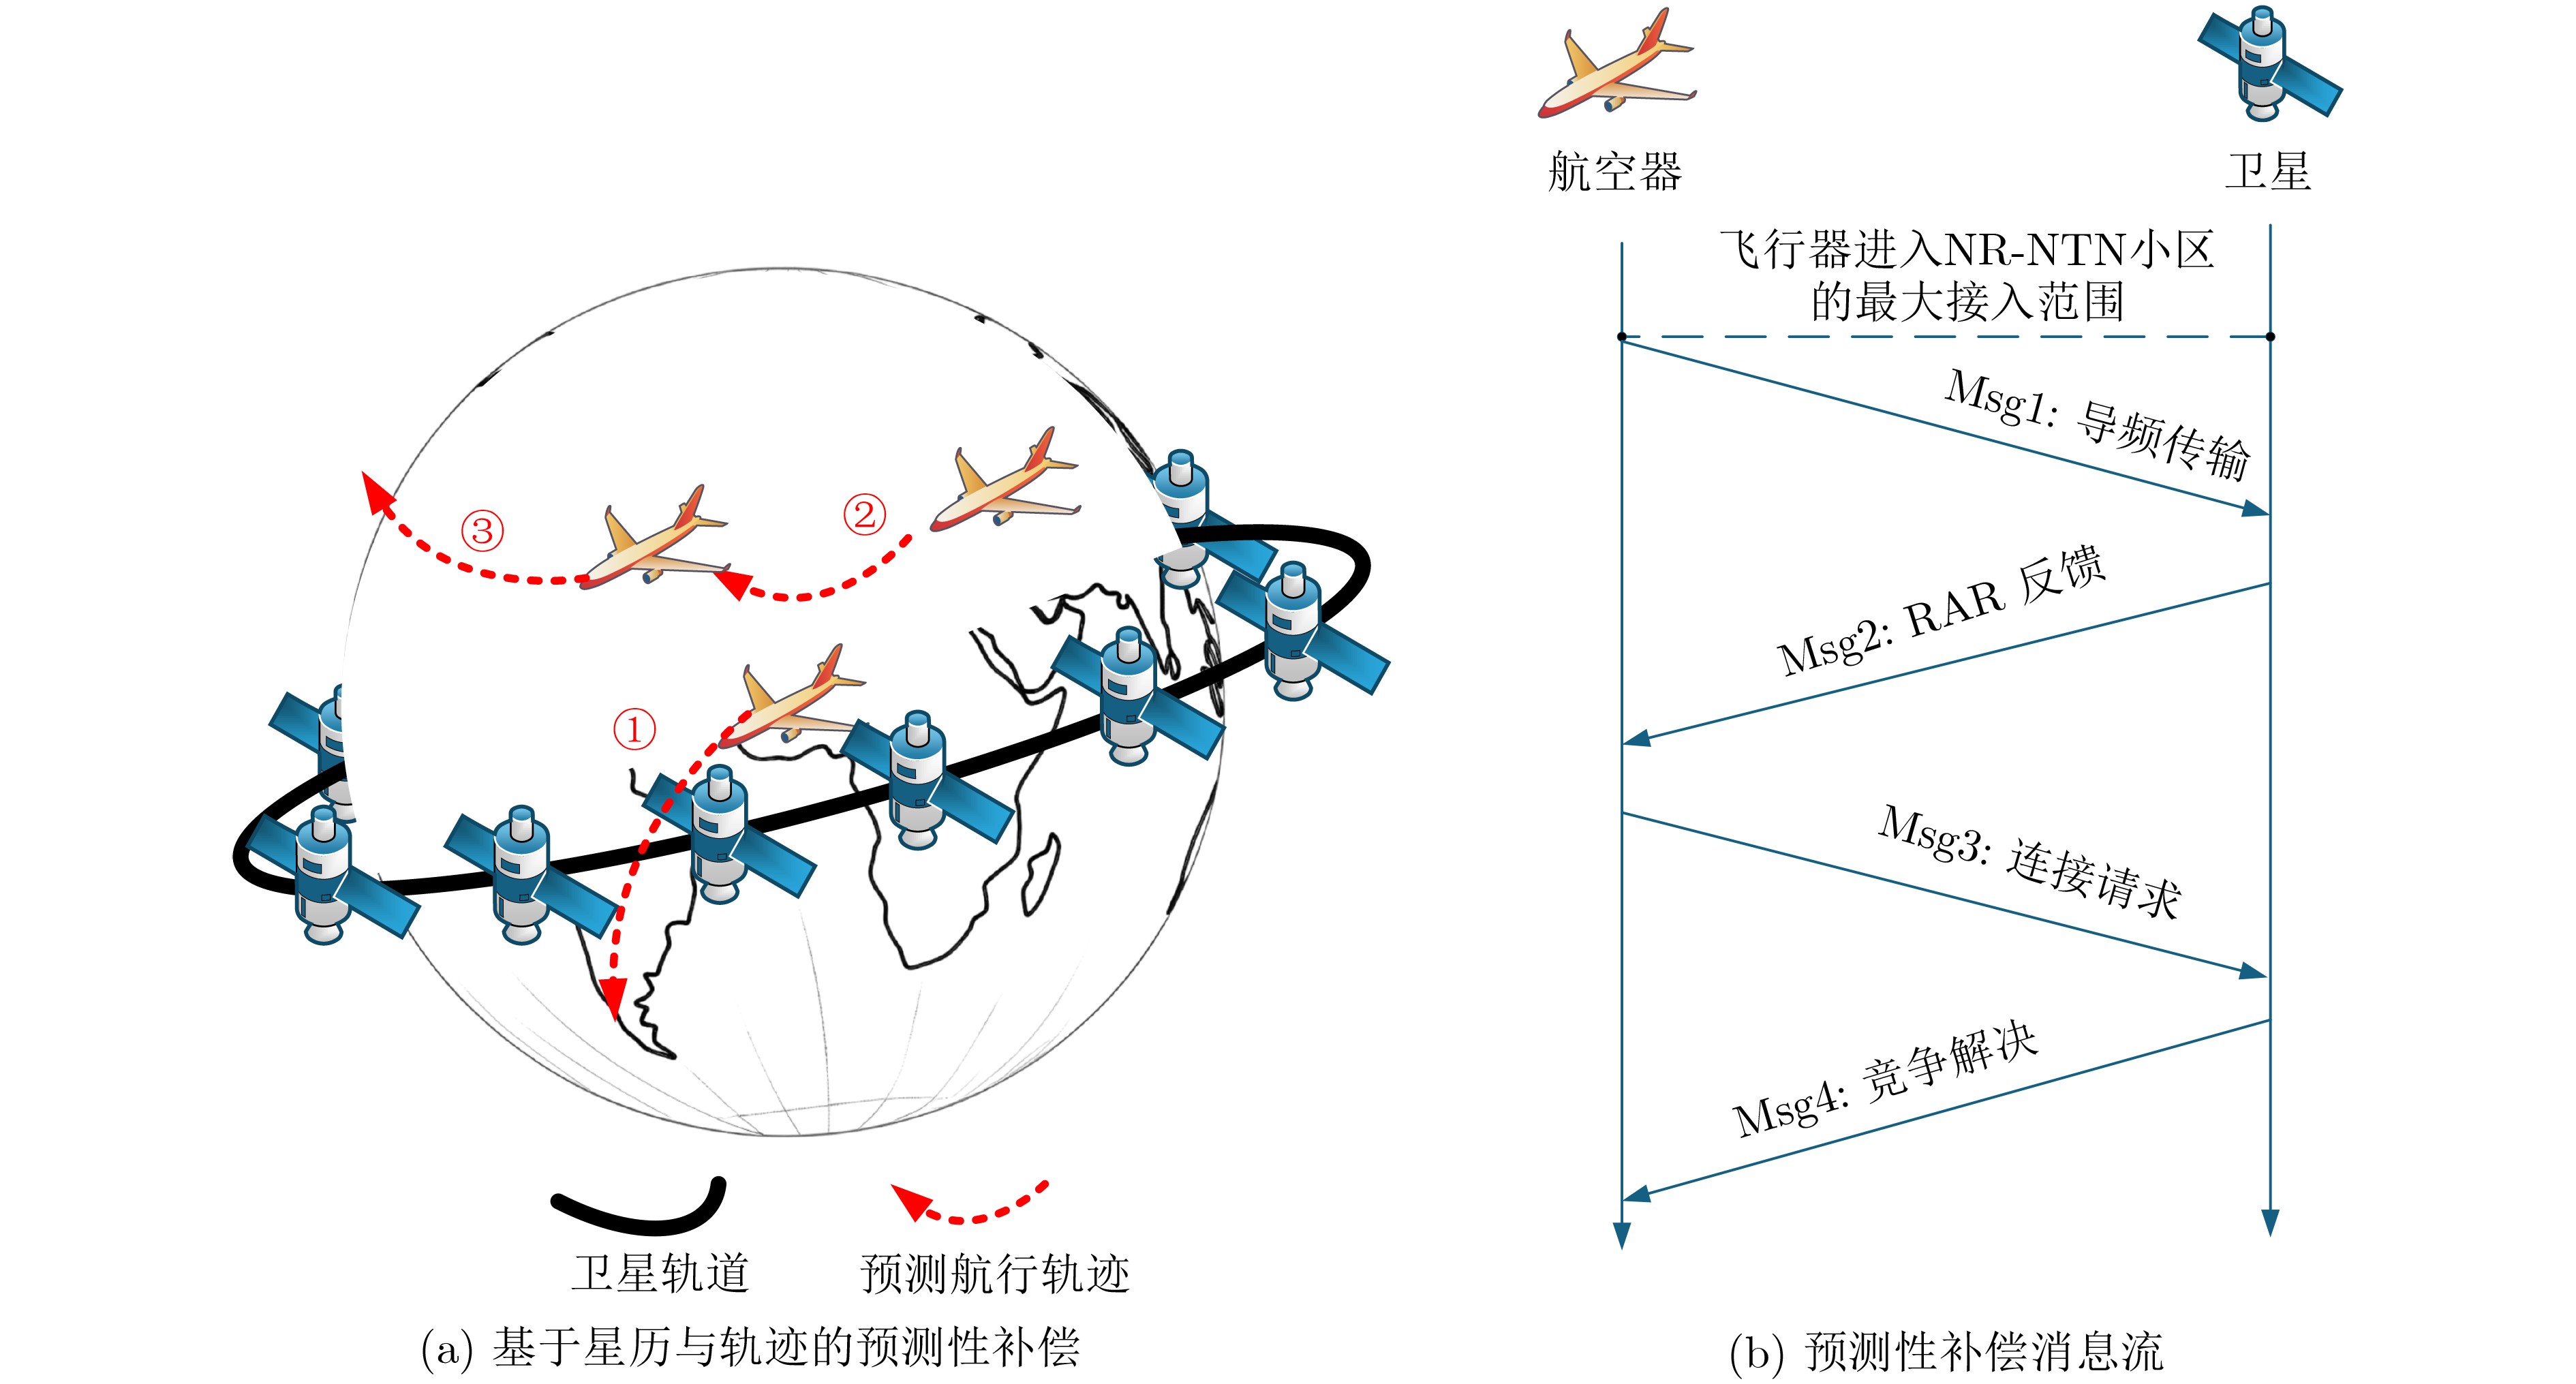
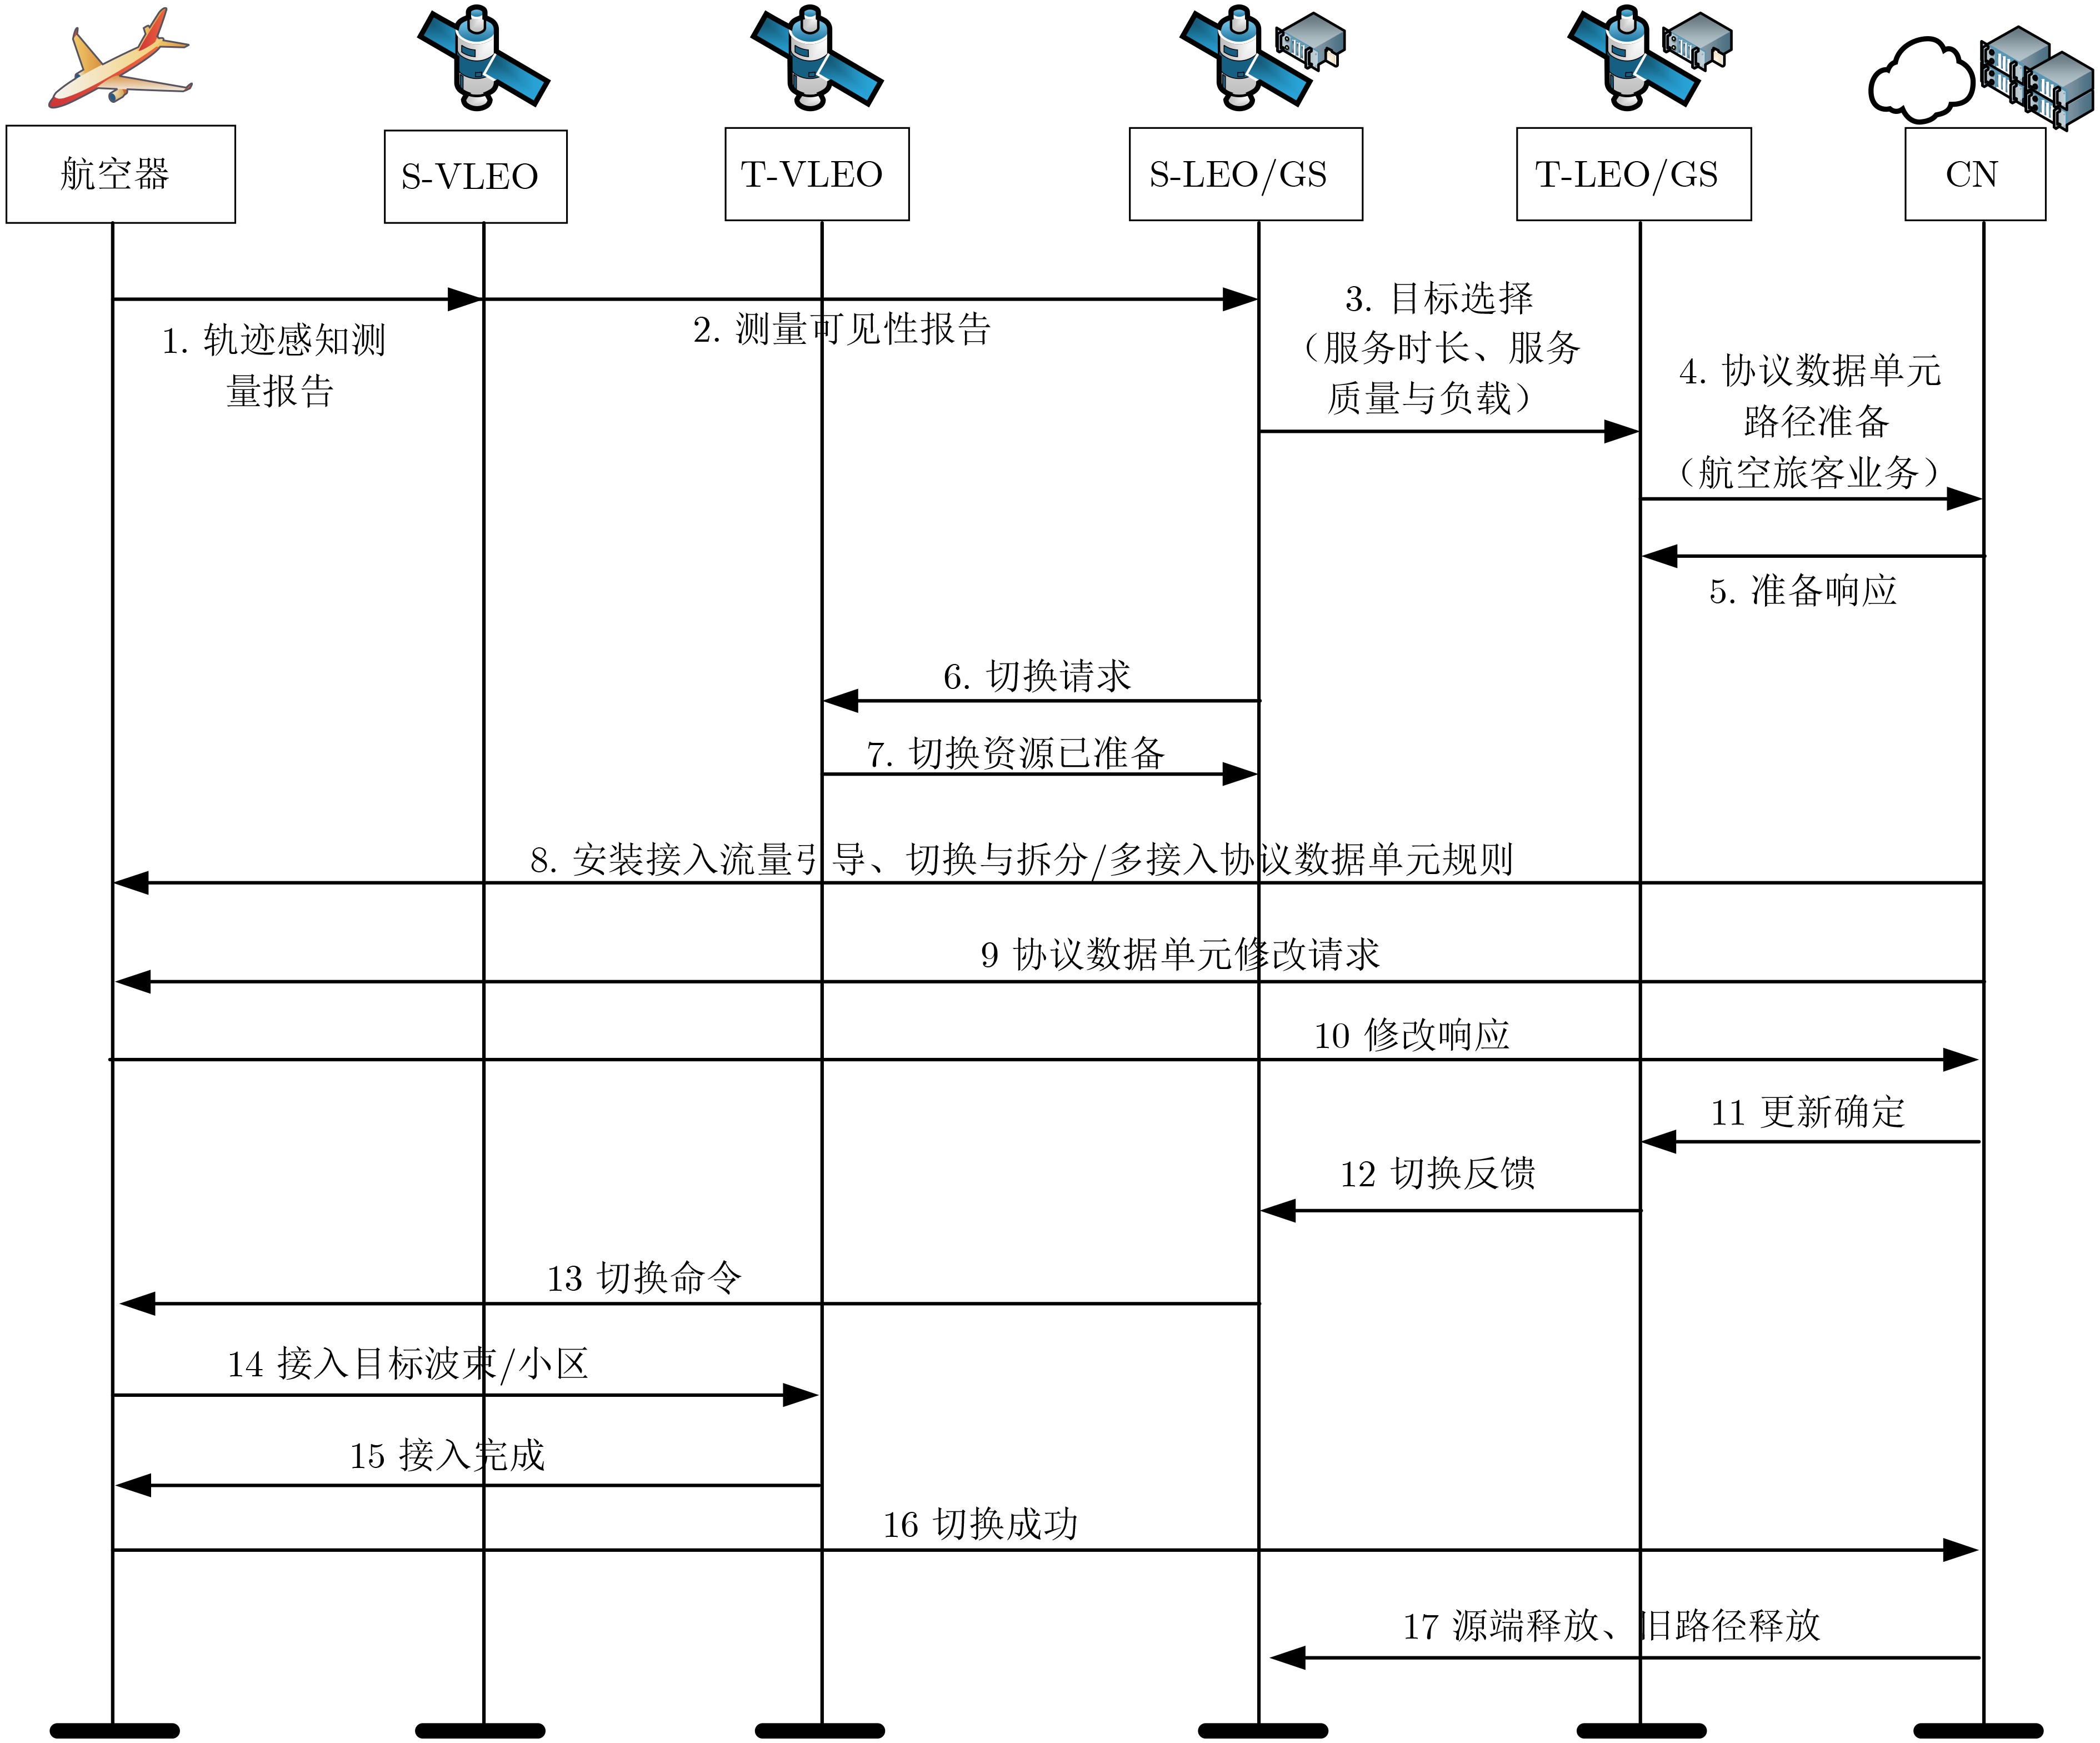
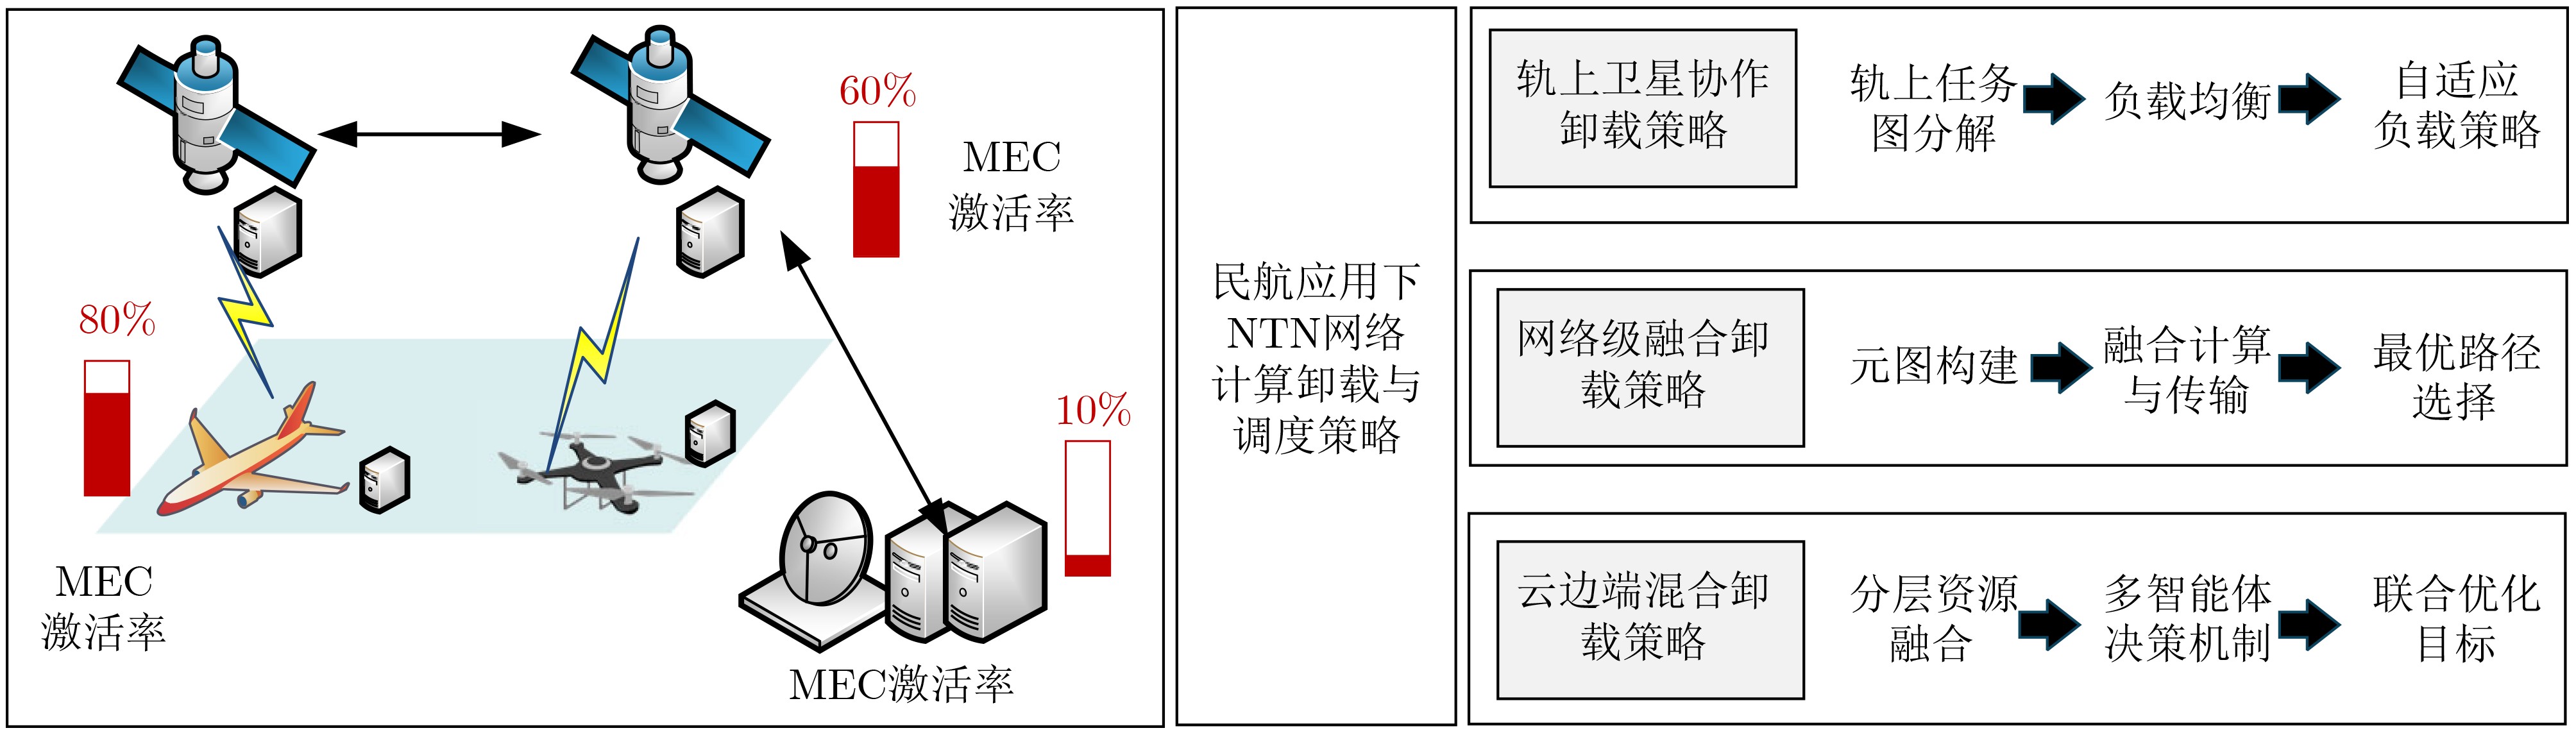
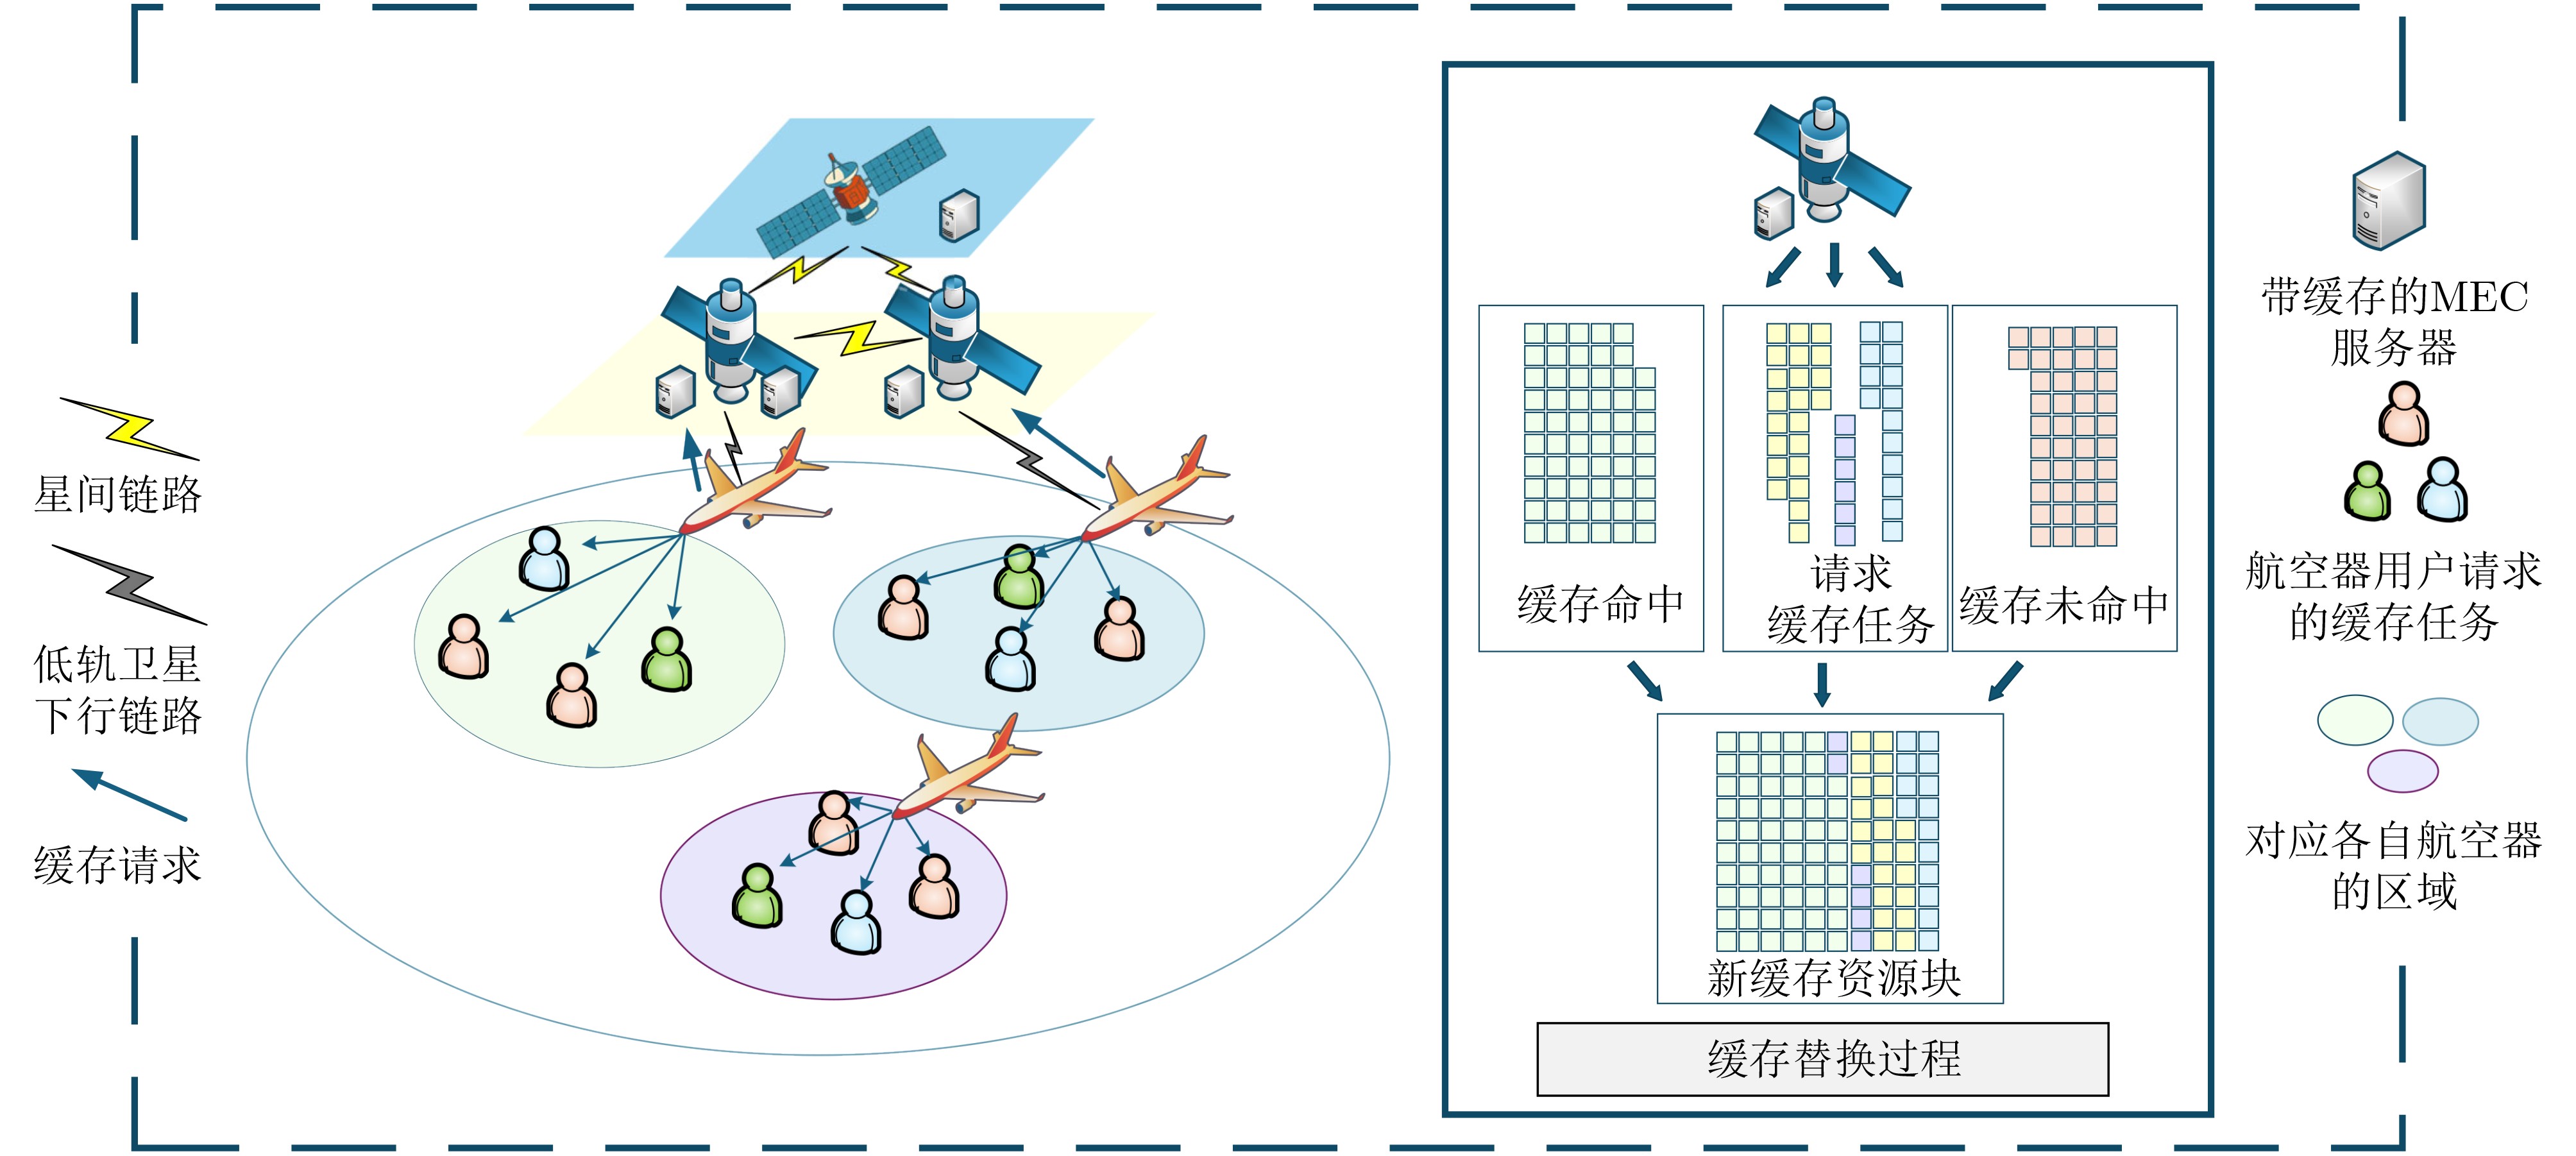
  Significance   Civil aviation communication systems are entering a new stage of development driven by the rapid growth of global air transportation, the increasing demand for intelligent air traffic management, and the continuous expansion of in-flight connectivity services. Traditional civil aviation communication systems mainly rely on high frequency radio, high frequency radio, terrestrial air-to-ground links, and conventional satellite communication systems. These technologies have supported aircraft operation, air traffic control, airline operational communication, and low-rate data transmission for a long time. However, they still face limitations when applied to future civil aviation scenarios characterized by global coverage, high-speed mobility, low latency, high reliability, and service diversification. Particularly, terrestrial networks are difficult to deploy in transoceanic routes, polar regions, deserts, mountains, and remote airspace, while traditional geostationary satellite systems suffer from large propagation delay and limited capacity. Current systems cannot fully meet the requirements of continuous aircraft access, real-time flight monitoring, engine health data transmission, aviation safety communication, and passenger broadband services. Non-Terrestrial Networks (NTNs) provide a promising technical path for overcoming these limitations. By integrating GEOstationary satellites (GEO), Medium Earth Orbit satellites (MEO), low Earth orbit satellites (LEO), Very Low Earth Orbit satellites (VLEO), High-Altitude Platform Stations (HAPS), Unmanned Aerial vehicles (UAV), electric Vertical Take Off and Landing (eVTOL), and terrestrial infrastructures, NTN can construct a multi-layer air-space-ground integrated communication system. Such a system is able to provide continuous coverage, flexible deployment, resilient connectivity, and differentiated service support for civil aviation. NTN is becoming an important enabling technology for future civil aviation communication systems and for the digital and intelligent transformation of the aviation industry.  Progress   This paper reviews the development of NTN technologies for civil aviation and summarizes key research progress from three aspects: network architecture, access and mobility management, and resource management and scheduling. (1) We propose an aviation-oriented NTN networking framework composed of three layers: the satellite edge layer, the airborne core layer, and the terrestrial assistance layer. The satellite edge layer includes GEO, MEO, LEO, and VLEO satellites connected through inter-satellite links. GEO satellites are suitable for wide-area broadcasting and non-real-time services, MEO satellites can support navigation and intermediate-delay services, LEO satellites are suitable for low-latency and high-capacity broadband access, and VLEO satellites can further reduce propagation delay for future near-real-time aviation applications. The airborne core layer includes civil aircraft, HAPS, UAVs, and eVTOL platforms. HAPS can act as a regional relay, edge computing node, or software-defined control carrier, while UAVs and eVTOL platforms can provide flexible low-altitude coverage, emergency communication, and local access support. The terrestrial assistance layer consists of terrestrial base stations and gateway stations, which support air-to-ground communication and satellite-terrestrial interconnection. Civil aviation services can be divided into air traffic control and air traffic management services, airline operational control services, and airline passenger communication or in-flight entertainment services. Through network slicing, these heterogeneous services can be logically isolated and managed over a shared air-space-ground infrastructure. In congestion, rain attenuation, or shortened visibility-window scenarios, safety slices should be protected with the highest priority, while passenger service slices can be rate-limited, buffered, or degraded. (2) We analyze the characteristics of NR-NTN access and air-to-ground direct access in civil aviation. NR-NTN can provide continuous coverage for oceanic, polar, desert, and remote flight routes through satellites or HAPS, while air-to-ground direct access can provide low-latency and high-rate links in areas where terrestrial base stations can be deployed. However, aircraft differ significantly from ordinary terrestrial terminals because their flight trajectory, altitude, speed, and route are highly predictable. Therefore, the key issue in aviation NTN access is not only how to execute random access, but how to predict the access window, timing compensation, frequency offset, and target access node before the aircraft enters the coverage area. By using satellite ephemeris, Global Navigation Satellite System information, aircraft trajectory, and velocity parameters, civil aircraft can predict satellite visibility and pre-compute timing advance, scheduling offset, and Doppler compensation before initiating access. This transforms random access from a passive response process into a proactive and predictive access process, thereby improving access certainty and synchronization stability in highly dynamic aviation scenarios. For mobility management, a signaling interaction process for aircraft handover is designed. Based on trajectory prediction and satellite visibility prediction, the network can select a target satellite or gateway with longer residence time and better service capability. Before the aircraft reaches the handover boundary, the source and target network sides can complete context preparation, user-plane path preparation, radio resource reservation, and protocol data unit session update. When the handover condition is triggered, the aircraft performs random access to the target satellite or beam and then switches the user-plane path. This “prediction-preparation-fast handover” mechanism can reduce service interruption and maintain session continuity. For safety-critical traffic, priority and isolation policies should remain consistent and auditable throughout session preparation, handover execution, and path switching. (3)We discuss computing and caching resource management in civil aviation NTN. As onboard computing capability is limited and aviation applications generate increasing computing demands, NTN can provide mobile edge computing and caching services through LEO satellites, HAPS, UAVs, and inter-satellite cooperation. The paper introduces several computing offloading modes, including on-orbit satellite collaborative offloading, network-level integrated offloading, and cloud-edge-terminal hybrid offloading. These mechanisms can support tasks such as aviation monitoring, trajectory analysis, intelligent inference, and in-flight service optimization. In addition, caching mechanisms such as onboard satellite caching, inter-satellite cooperative caching, and named-data-networking-based content caching can improve content delivery efficiency and service continuity. Cache placement should consider content popularity, regional demand prediction, visibility windows, cache prefetching, and cooperative cache sharing among different satellite layers.  Conclusions   NTN can effectively complement traditional civil aviation communication systems by filling coverage gaps in remote and oceanic airspace, enhancing service continuity, and supporting differentiated aviation services. The proposed aviation-oriented NTN architecture integrates multi-orbit satellites, HAPS, UAVs, civil aircraft, and terrestrial infrastructures into a unified framework. The on-demand isolated slicing mechanism can provide differentiated protection for ATC/ATM, AOC, and APC/IFE services. Ephemeris-map-assisted access and predictive mobility management can improve access reliability and reduce handover interruption in high-speed aviation scenarios. Computing offloading and cooperative caching further enhance the ability of NTN to support intelligent and data-intensive aviation applications.  Prospects   Future civil aviation NTN should evolve toward deeper integration of low-altitude networks, space networks, and terrestrial networks. Cross-domain topology visualization, link-state sharing, policy distribution, and programmable logical networks are essential for improving controllability and scalability. In mobility management, integrated cross-domain handover mechanisms should be developed to cope with satellite beam switching, terrestrial cell handover, and air-to-air relay reconstruction. In resource management, communication, navigation, computing, and caching resources should be jointly scheduled and transformed according to aviation service requirements. With continuous advances in NTN architecture, network slicing, predictive access, mobility management, computing offloading, and caching, NTN is expected to provide more efficient, stable, and intelligent communication support for civil aviation and to promote the digital transformation of future air transportation systems.

Research on Covert Communication Transmission Scheme Combining Relay Selection and Mode Selection over Nakagami-m Fading Channels
HUANG Haiyan, HUANG Yi, ZHANG Ning, LIANG Linlin, ZHANG Xuejun
2026, 48(9): 3746-3756. doi: 10.11999/JEIT260287
Abstract:
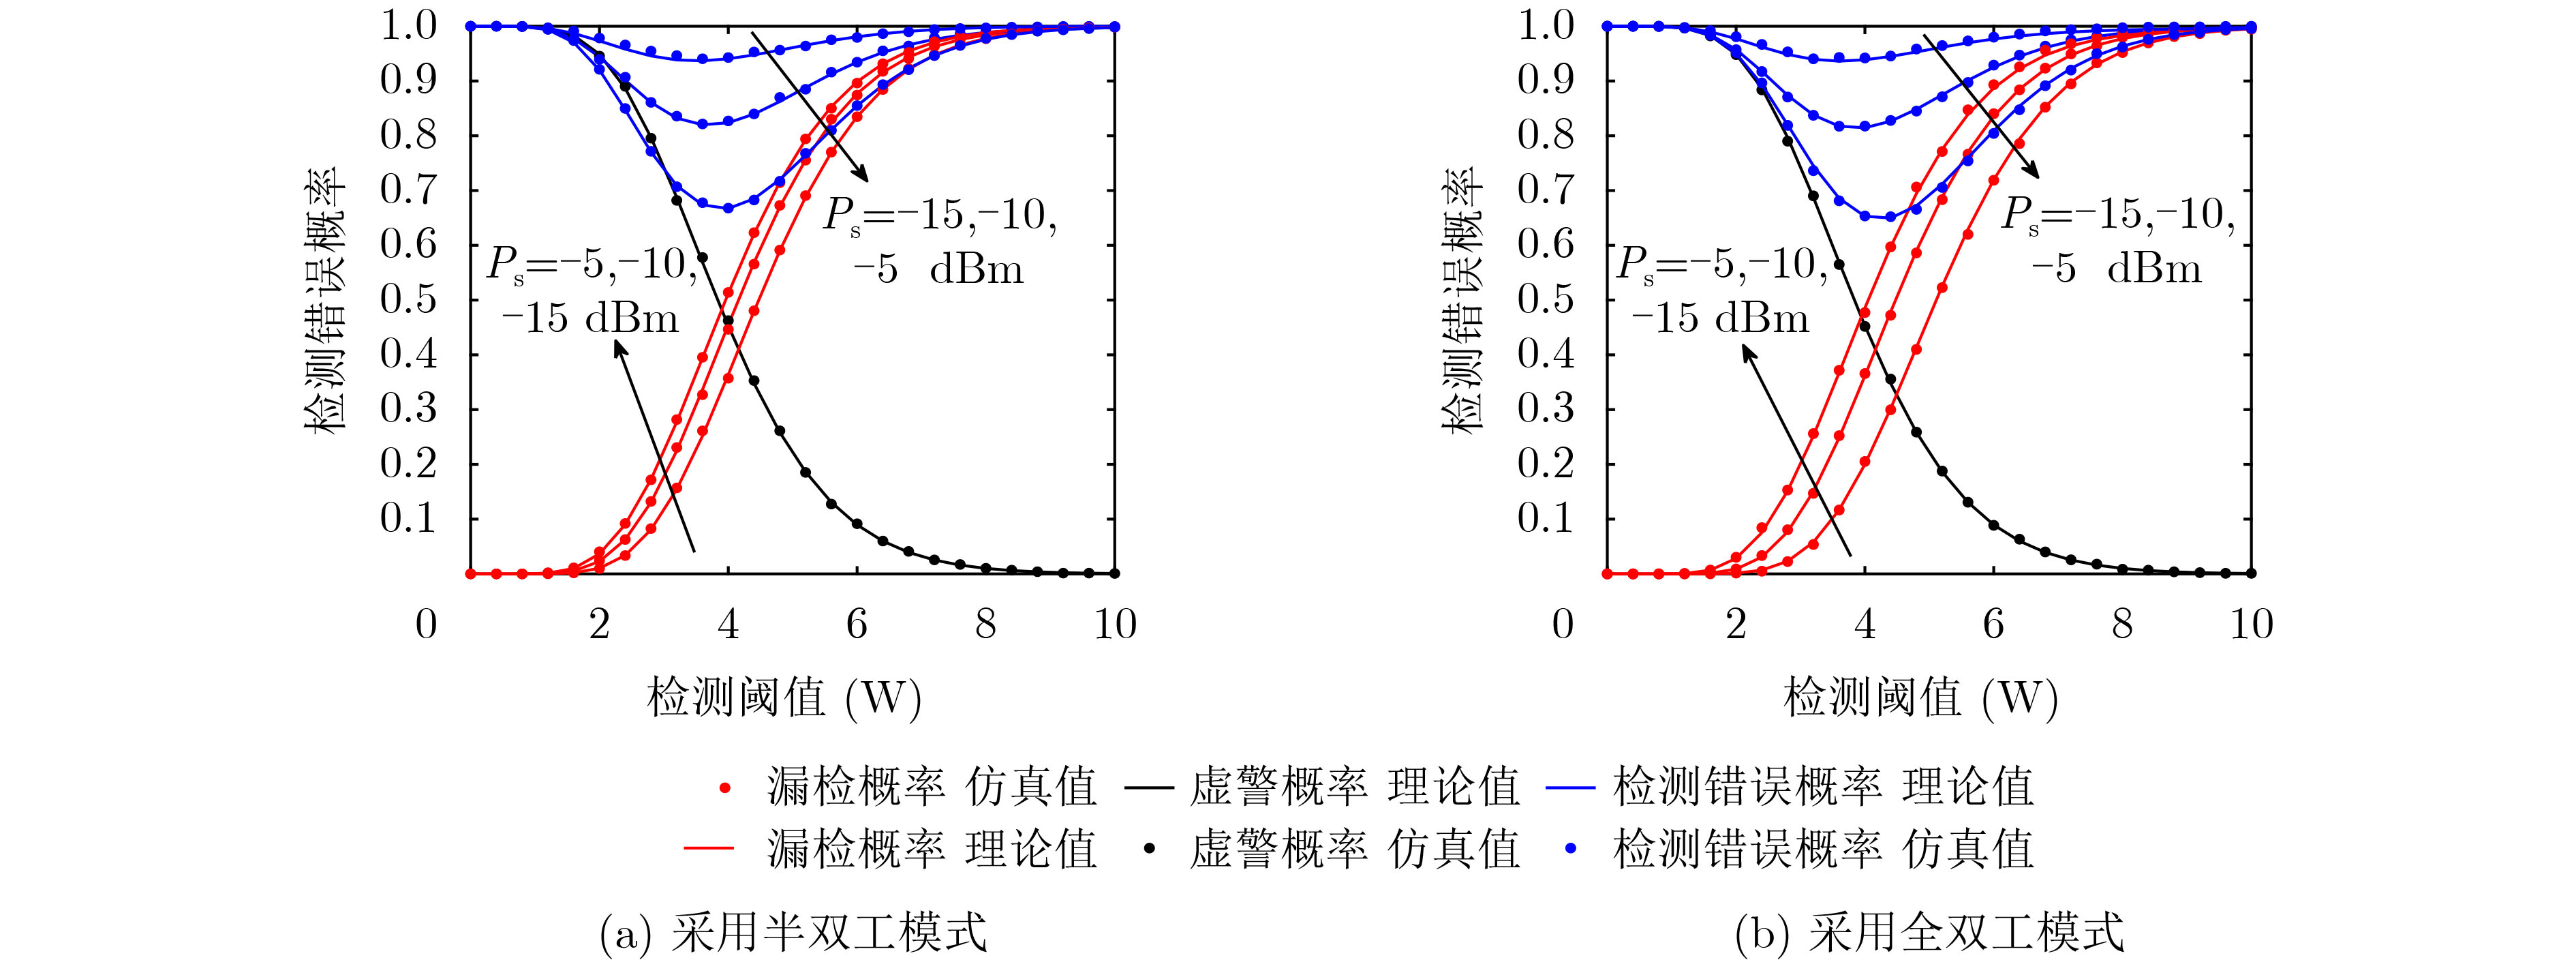
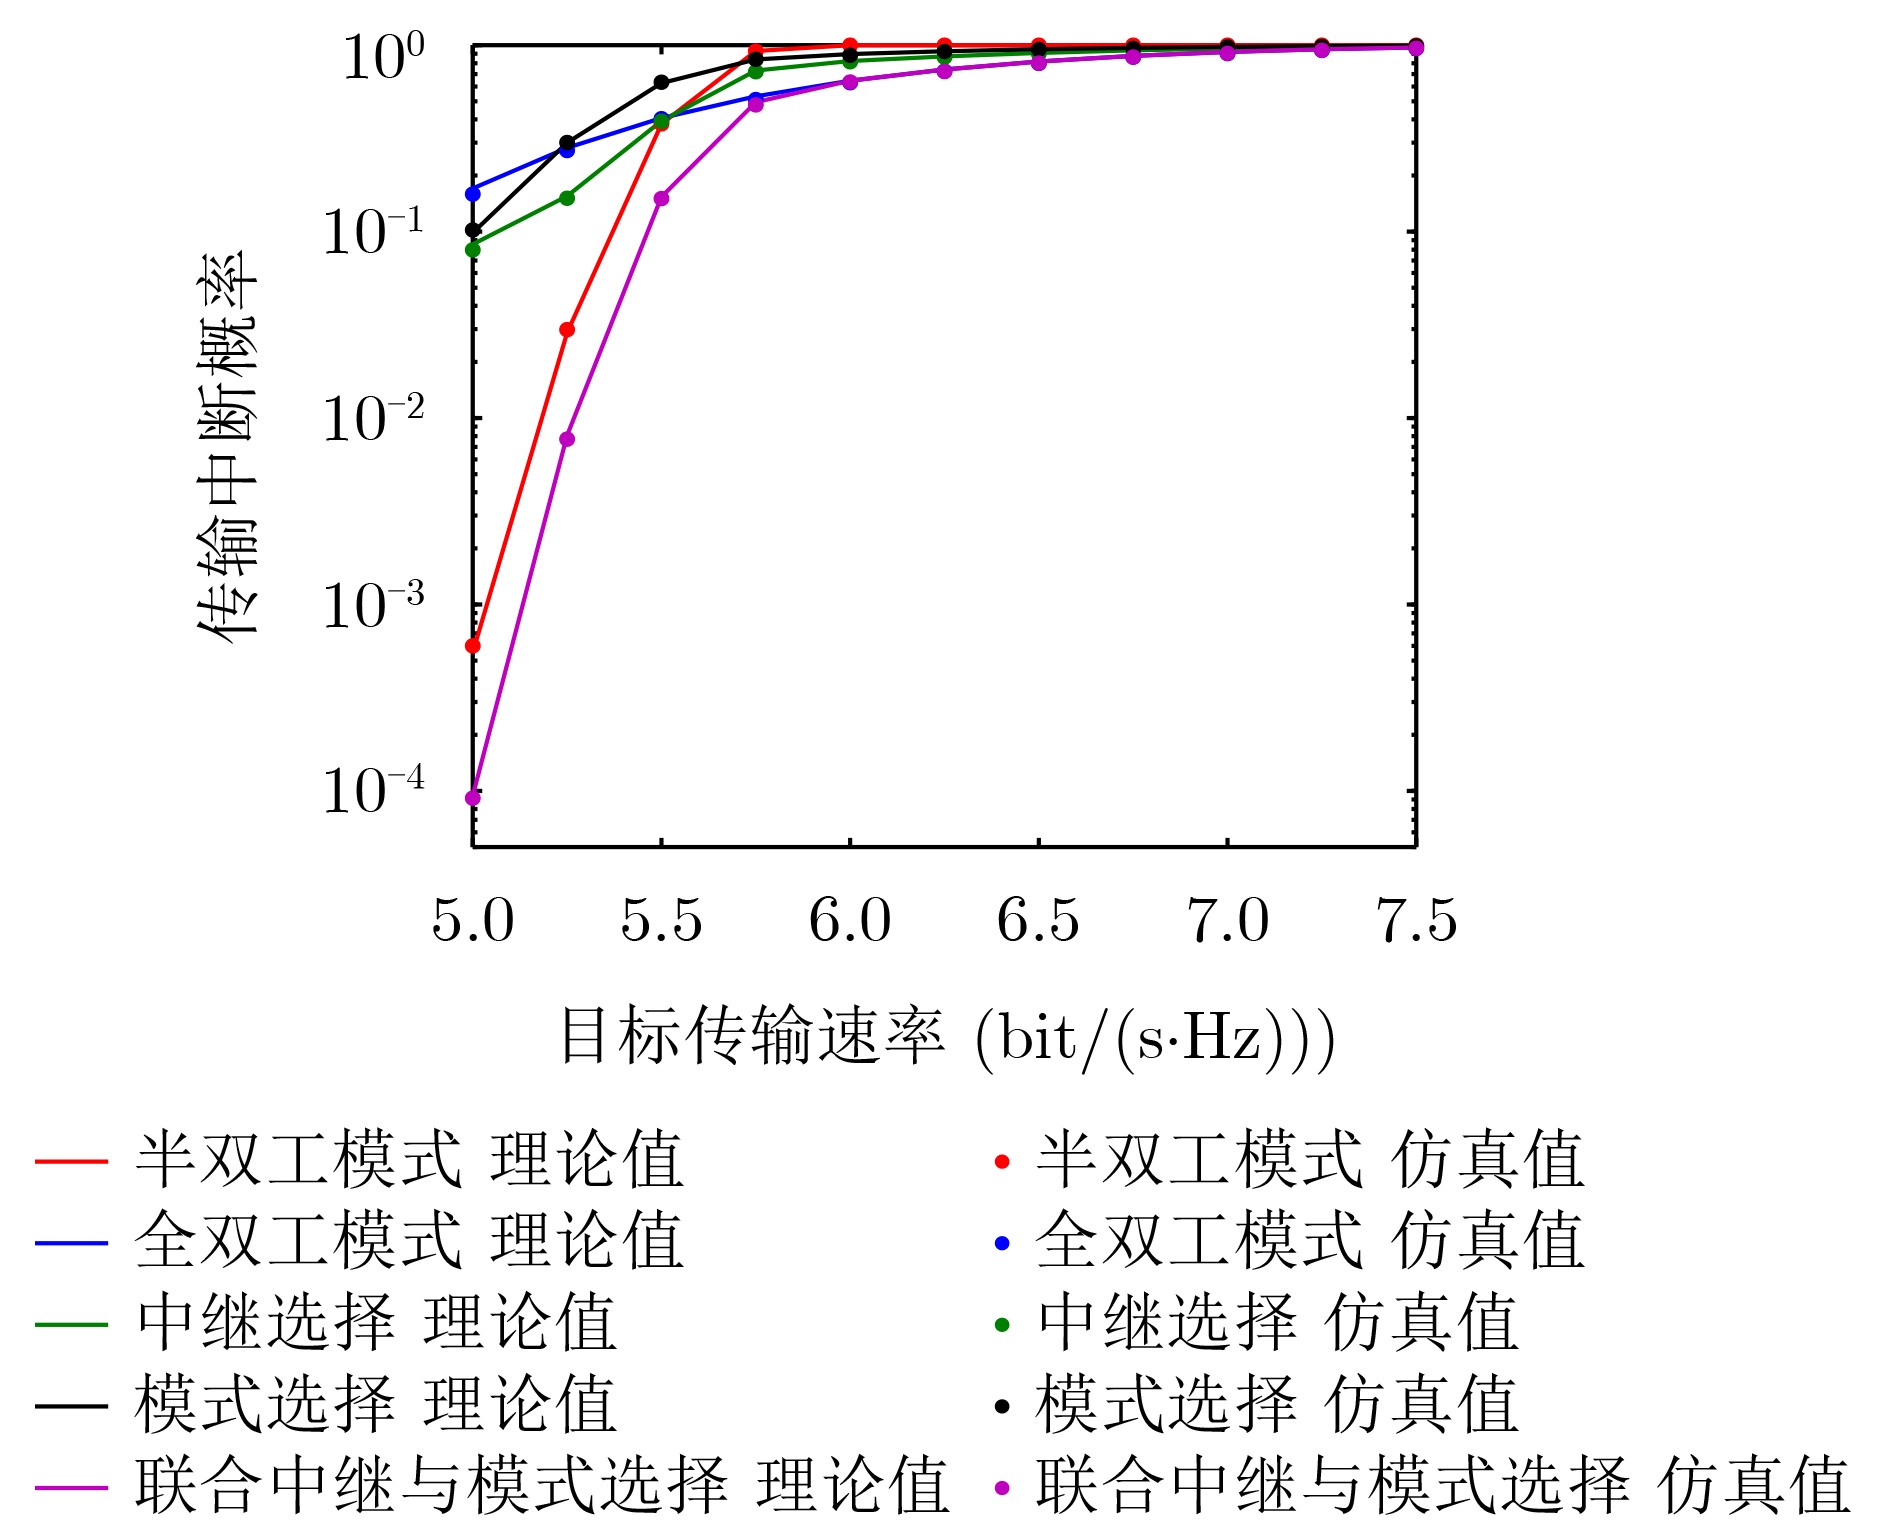
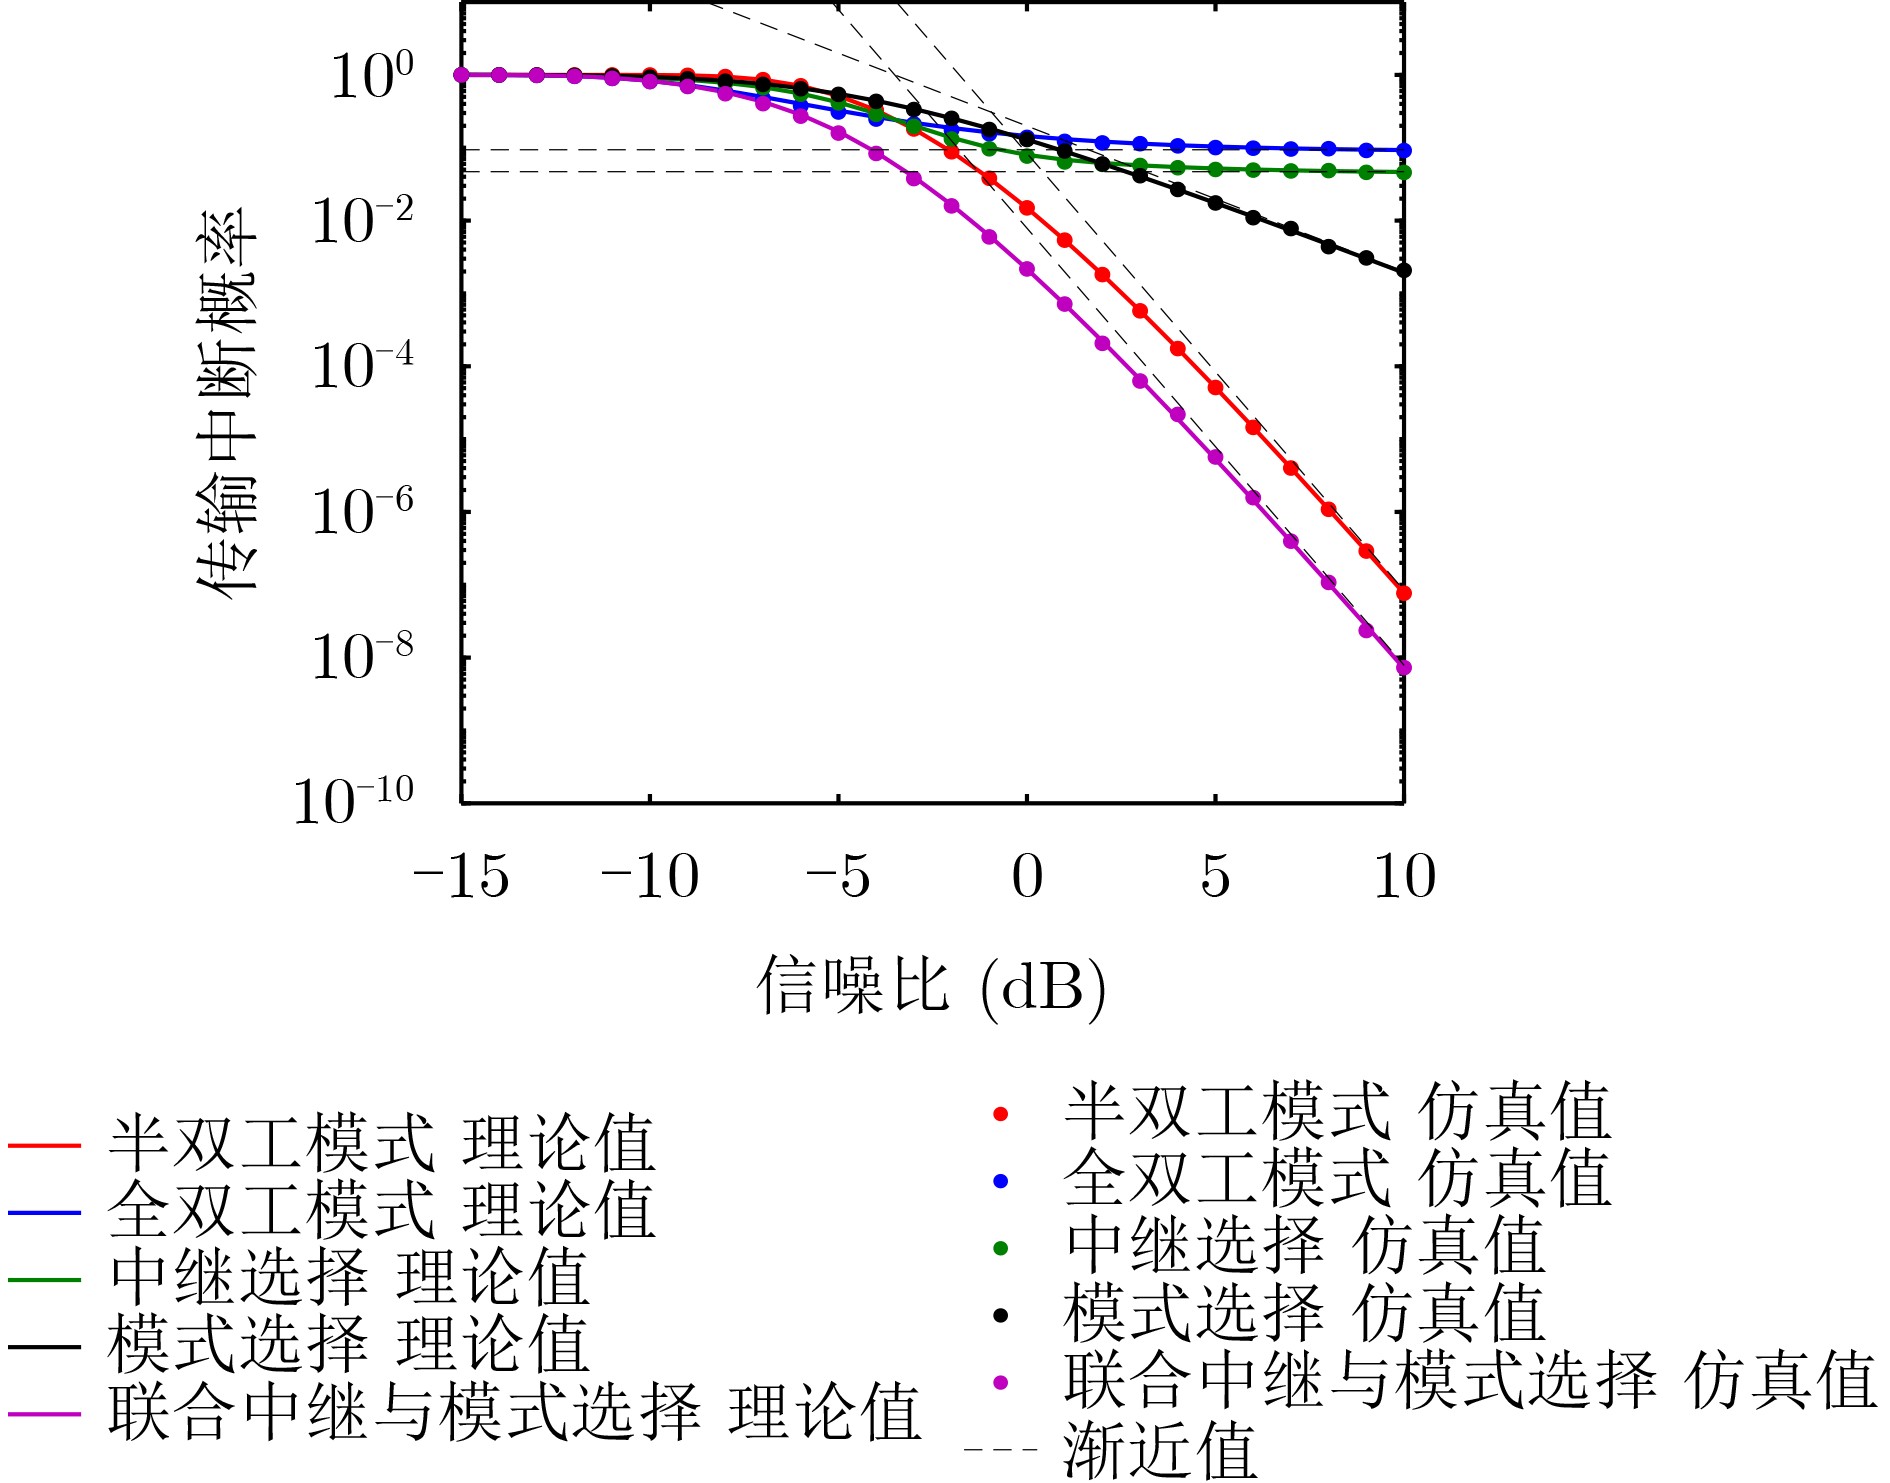
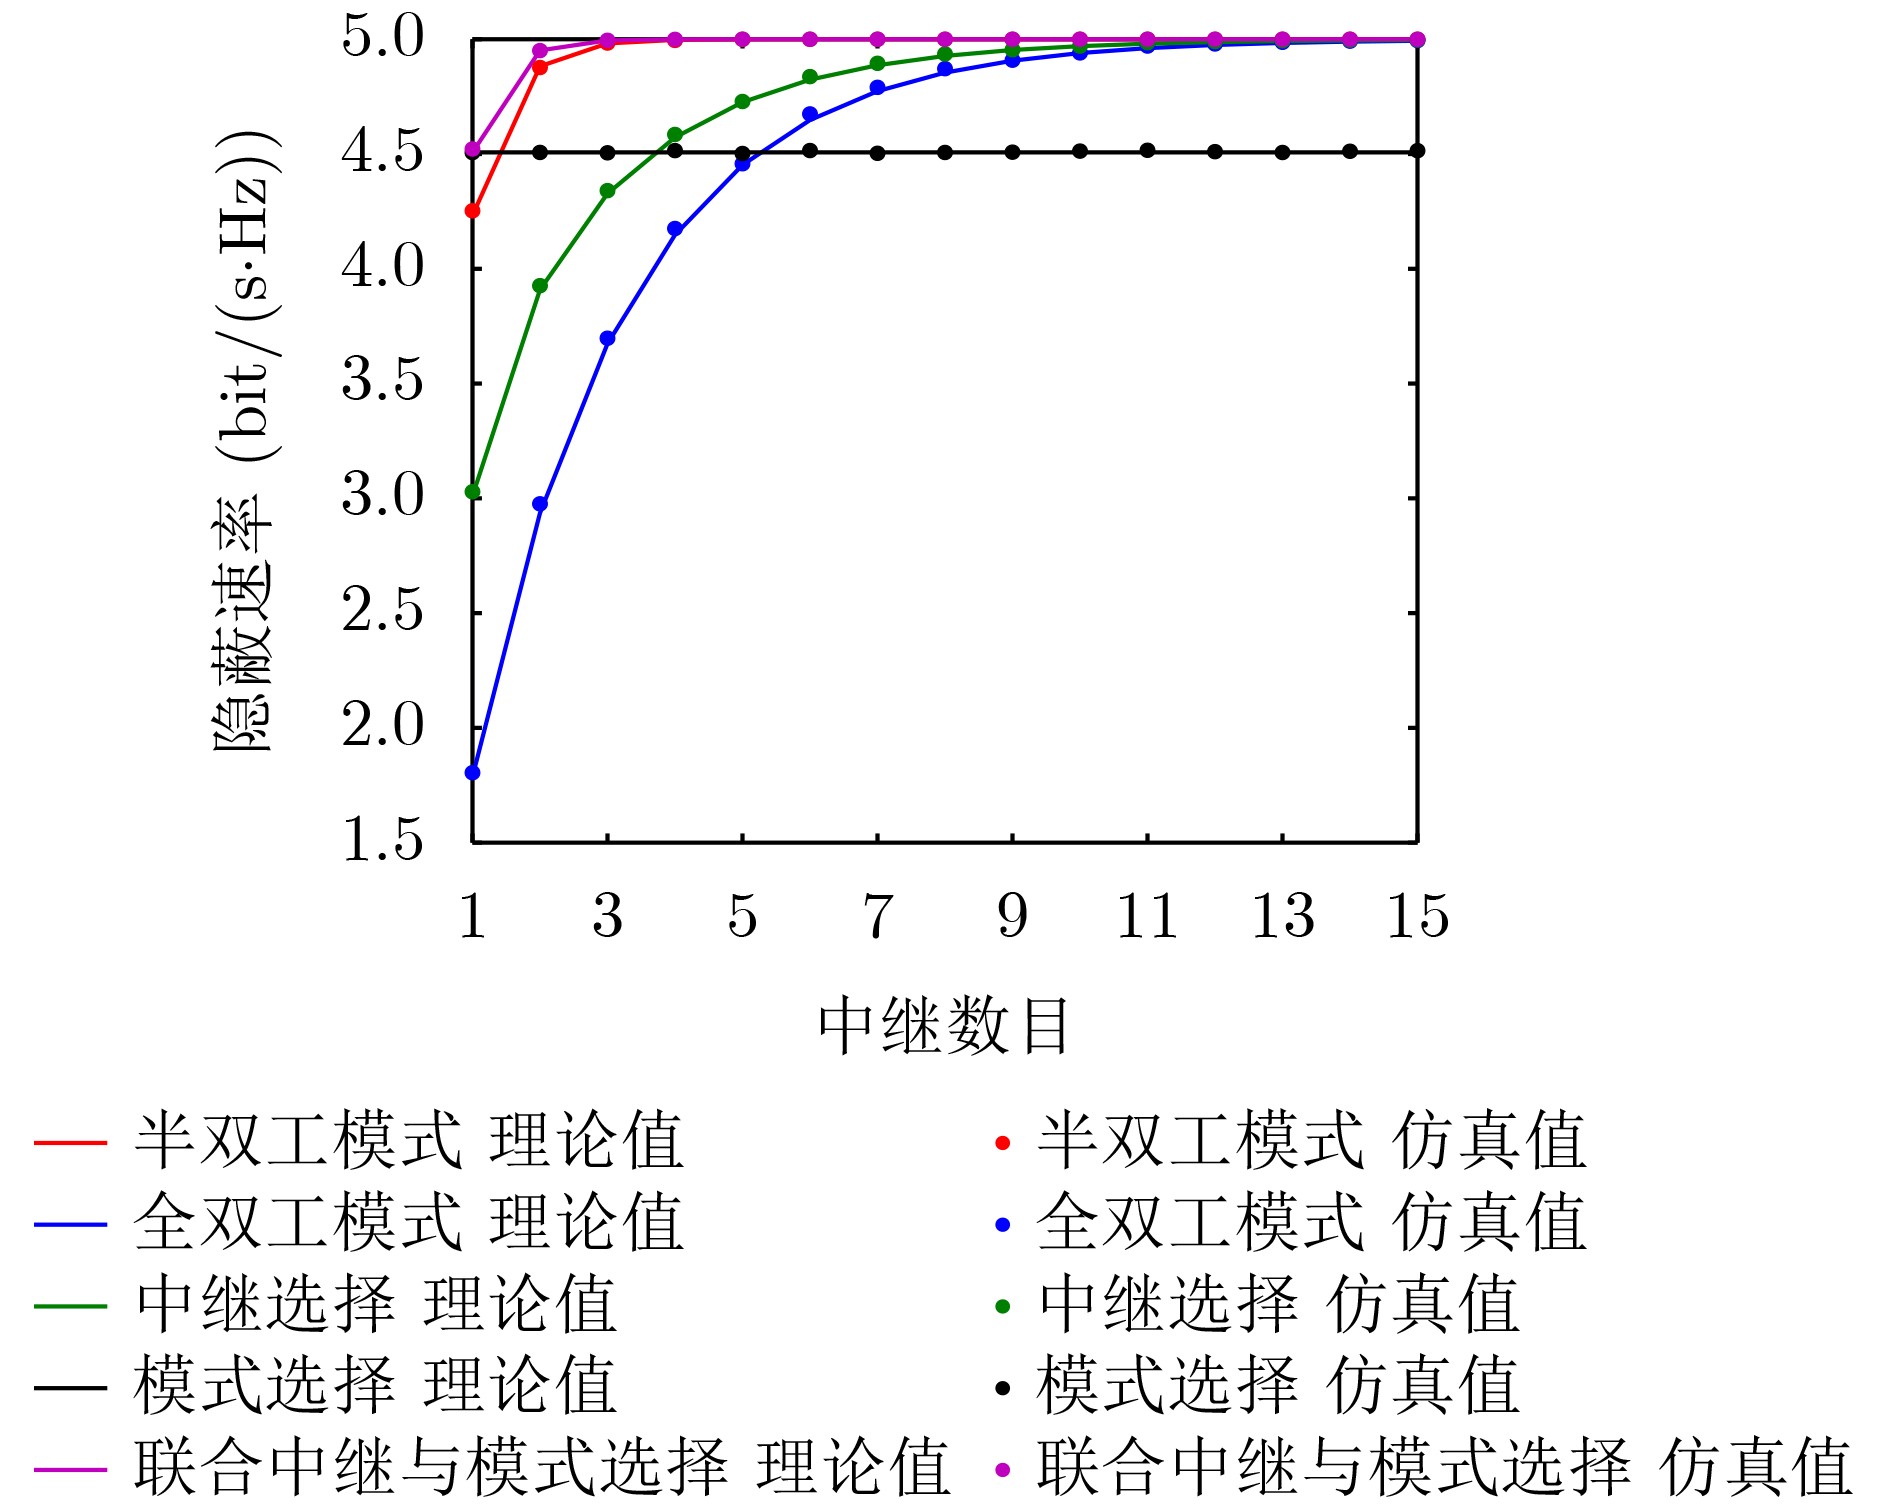
  Objective  Covert communication enhances the security of wireless communication systems by concealing both transmitted information and communication activities from unauthorized detection. However, practical wireless channels exhibit random and uncertain propagation conditions. The Nakagami-m fading channel, which can characterize a wide range of channel conditions, provides a realistic framework for evaluating the performance of covert communication. Relay-assisted transmission has attracted considerable attention because it improves transmission reliability over fading channels. Moreover, relay selection and transmission mode selection substantially affect system performance. Therefore, investigating their combined effect on covert communication over Nakagami-m fading channels is of both theoretical and practical significance for the design of next-generation secure wireless communication systems.  Methods  This paper proposes a covert communication system incorporating relay selection and transmission mode selection. The source node transmits covert information to the destination node through multiple relays, while a warden monitors transmissions from both the source and relay nodes. A friendly jammer transmits interference signals to degrade the warden’s detection capability. Four transmission schemes are considered: optimal relay selection with fixed Half-Duplex (HD) or Full-Duplex (FD) operation, optimal relay selection with random transmission mode selection, random relay selection with optimal transmission mode selection, and joint optimal relay and transmission mode selection. Closed-form expressions for the warden’s detection error probability under both HD and FD optimal relay selection are derived over Nakagami-m fading channels. Closed-form expressions for the transmission outage probability, asymptotic transmission outage probability, and covert rate are also derived for all transmission schemes. The theoretical analysis is validated through MATLAB simulations.  Results and Discussions  Simulation results demonstrate that an optimal detection threshold exists that minimizes the detection error probability (Fig. 2). As the detection threshold or jamming power increases, the warden’s ability to detect covert communication decreases, causing the detection error probability to approach one (Figs. 2 and 3). Under the same target transmission rate and high Signal-to-Noise Ratio (SNR) conditions, the joint relay and transmission mode selection scheme achieves the lowest transmission outage probability, thereby providing the highest transmission reliability (Figs. 4 and 5). At a target transmission rate of \begin{document}$ \text{6.5 bit/(s}\cdot \text{Hz)} $\end{document}, the transmission outage probability of the joint relay and transmission mode selection scheme is 6.9% lower than that of the FD transmission scheme (Fig. 4). As the transmit power and the number of relays increase, the covert rate gradually approaches a constant value. Among all transmission schemes, the joint relay and transmission mode selection scheme consistently achieves the highest covert rate (Figs. 6 and 7).  Conclusions  This paper proposes a covert communication system based on relay selection and transmission mode selection over Nakagami-m fading channels. Closed-form expressions for the warden’s detection error probability and the system’s transmission outage probability are derived under different relay selection and transmission mode selection strategies. The asymptotic transmission outage probability and covert rate are then analyzed. Simulation results show that increasing the detection threshold or jamming power weakens the warden’s ability to detect covert communication, causing the detection error probability to approach one. Under identical target transmission rates and high SNR conditions, the joint relay and transmission mode selection scheme achieves the lowest transmission outage probability. These results indicate that appropriate relay selection and transmission mode selection not only reduce the warden’s detection capability and protect covert communication, but also improve both transmission reliability and covertness. Future work will consider practical factors, including imperfect channel state information, residual self-interference, and incomplete knowledge of the warden’s channel.
Research on Secure and Covert Transmission for UAV-assisted Visible Light Communication Systems
WU Mengru, LIN Jiale, LU Weidang, LI Bo, GUO Lei
2026, 48(9): 3757-3767. doi: 10.11999/JEIT260239
Abstract:
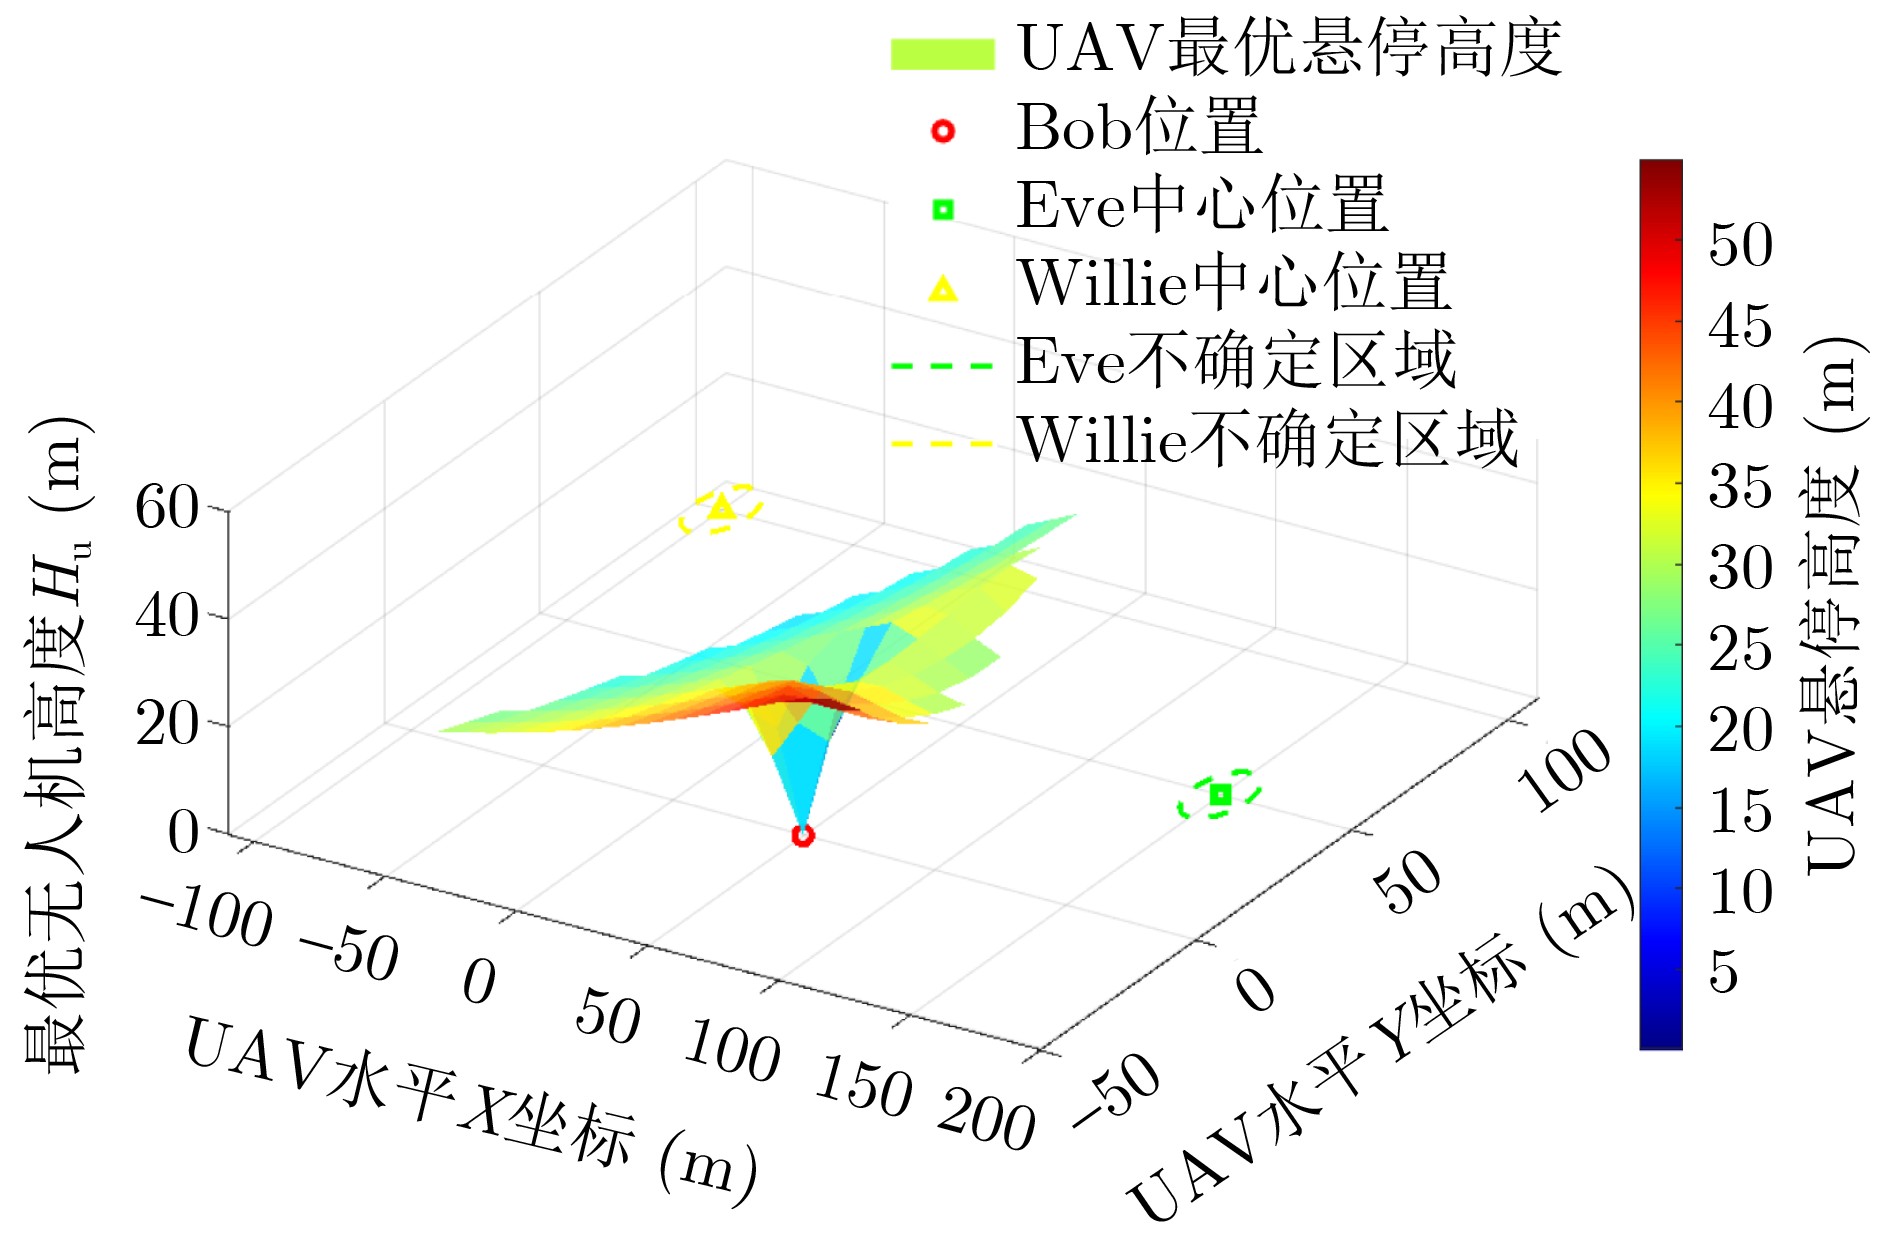
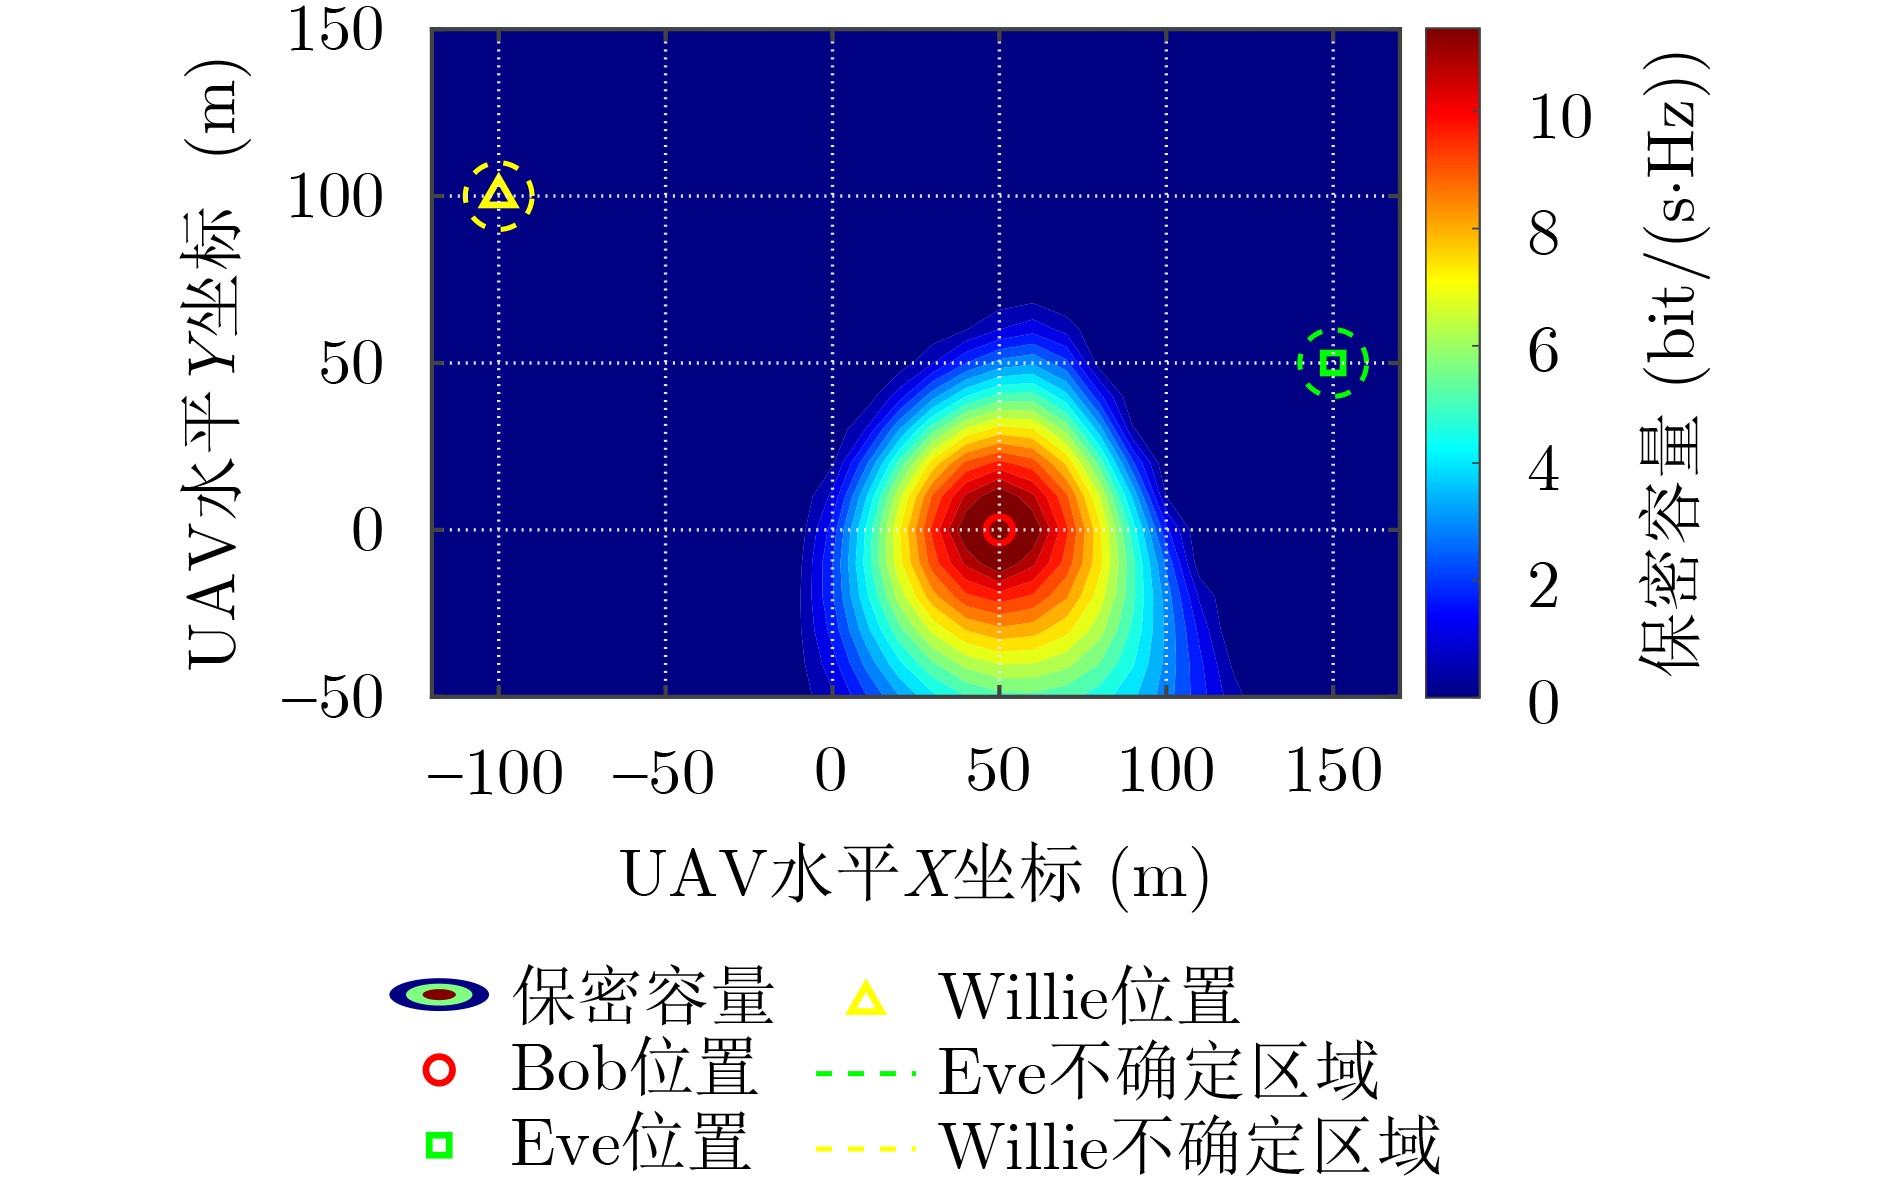
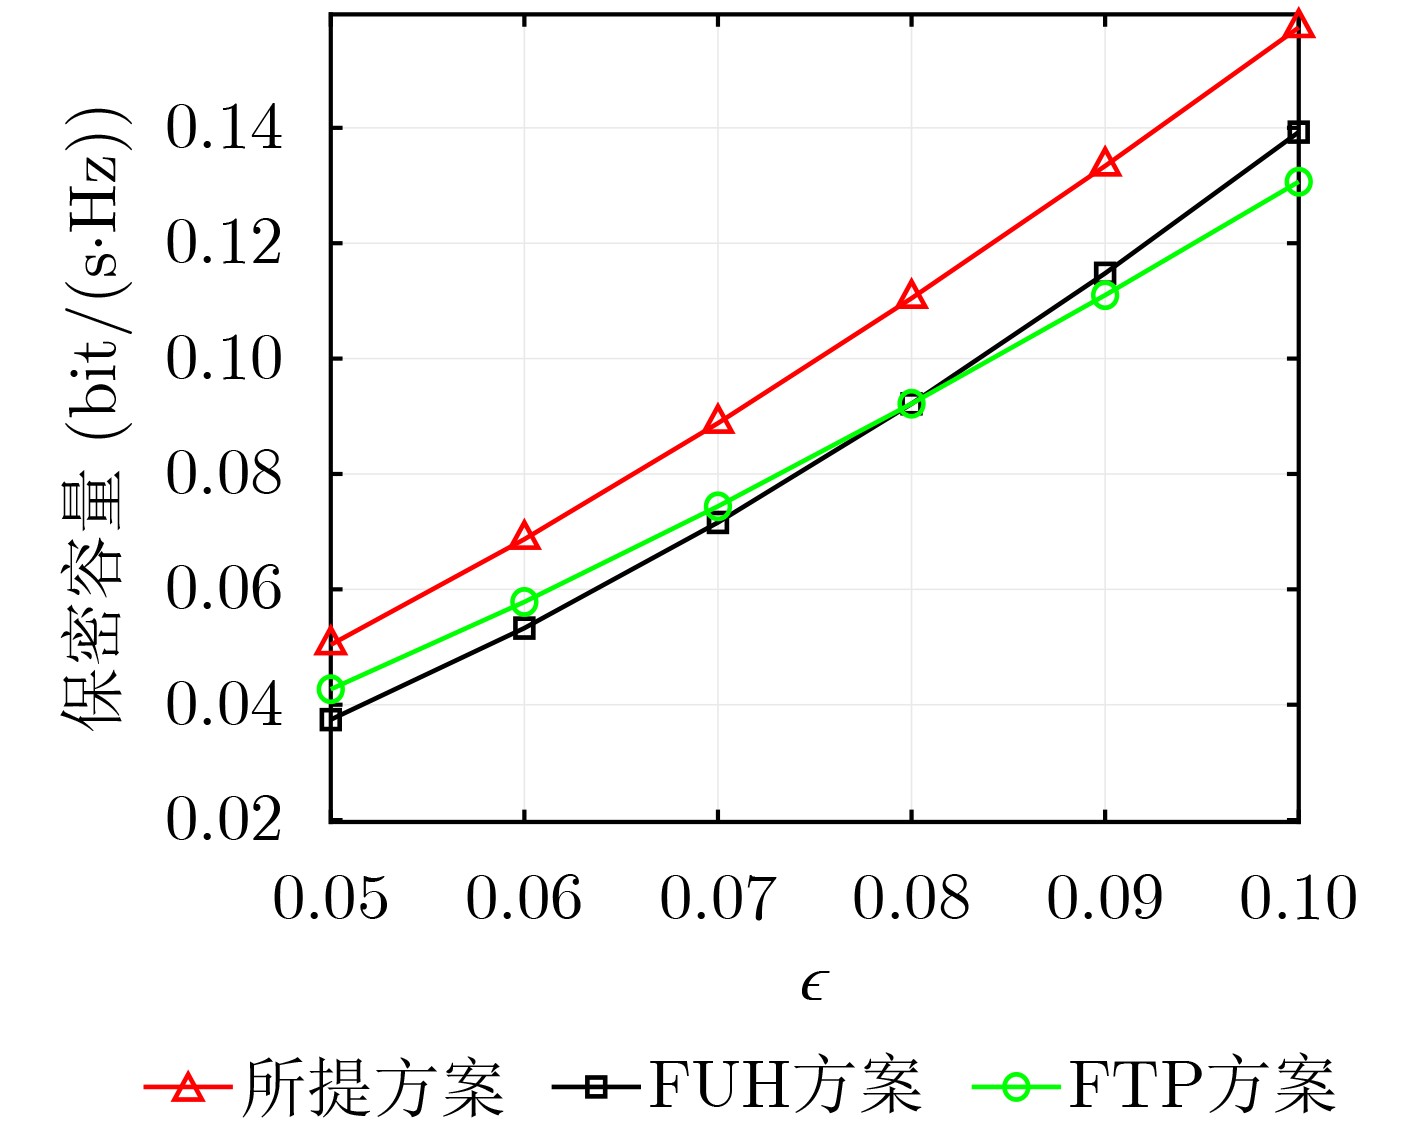
  Objective  Unmanned Aerial Vehicles (UAVs) can serve as aerial base stations for Visible Light Communication (VLC) because of their mobility and on-demand coverage capabilities. However, air-ground communication links are exposed to open environments, which makes VLC vulnerable to data eavesdropping and malicious detection. To address this issue, this paper proposes a secure and covert transmission strategy for a UAV-assisted VLC system from the perspectives of Physical Layer Security (PLS) and Covert Communication. The proposed strategy jointly optimizes UAV transmit power and hovering altitude to maximize the system secrecy capacity. The optimization is subject to covert communication requirements, illumination requirements, and operational constraints on UAV transmit power and hovering altitude.  Methods  This paper investigates secure and covert communication in a UAV-assisted VLC system. A UAV-assisted VLC system model is first established. In this model, a mobile UAV equipped with a Light-Emitting Diode (LED) is used to establish a VLC link with a legitimate ground user in the presence of an eavesdropper (Eve) and a warden (Willie). An optimization problem is then formulated to maximize the system secrecy capacity by jointly optimizing UAV transmit power and hovering altitude. To solve this problem, a Two-Layer OPtimization (TLOP) algorithm is proposed. The transformed problem is decomposed into two subproblems: an inner-layer transmit power optimization problem and an outer-layer UAV hovering altitude design problem. A closed-form expression for the optimal transmit power is derived for the inner-layer problem. A Particle Swarm Optimization (PSO) algorithm is then developed to solve the outer-layer problem.  Results and Discussions  In the simulations, the proposed optimization scheme is compared with two baseline schemes. First, the convergence of the proposed TLOP algorithm is verified (Fig. 3). The results show that the algorithm converges rapidly within a limited number of iterations. Second, the optimal UAV hovering altitude with respect to the UAV horizontal coordinates is illustrated under the spatial distribution (Fig. 4). The results indicate that the optimal hovering altitude decreases as the UAV approaches the legitimate ground user. The secrecy capacity with respect to the UAV horizontal coordinates is then presented (Fig. 5). The secrecy capacity increases as the UAV approaches the legitimate ground user. This is because the legitimate VLC channel gain increases when the UAV is closer to the user. In contrast, when the UAV approaches Eve and Willie, the security and covertness constraints become stricter. The UAV is then forced to reduce its transmit power or increase its hovering altitude, which decreases the system secrecy capacity. Furthermore, the secrecy capacity of all schemes increases as ϵ increases (Fig. 6). This is because a larger ϵ relaxes the covertness requirement. The UAV can therefore adjust its hovering altitude and transmit power more flexibly to increase the system secrecy capacity. In addition, the secrecy capacity decreases as the number of symbols increases (Fig. 7). This occurs because more symbols provide Willie with more signal samples for detection, thereby improving Willie’s detection capability. Finally, the secrecy capacity of all schemes decreases as the uncertainty-region radius of illegal nodes increases (Fig. 8). This trend occurs because greater location uncertainty forces the UAV to address potential threats over a wider area. The UAV must therefore adopt a more conservative strategy under worst-case eavesdropping and detection conditions. Overall, the simulation results confirm that the proposed scheme improves the secrecy capacity of the UAV-assisted VLC system.  Conclusions  This paper investigates secure and covert communication in a UAV-assisted VLC system. The objective is to maximize the system secrecy capacity by jointly optimizing UAV transmit power and hovering altitude under covert communication, illumination, transmit power, and hovering altitude constraints. Because the formulated problem is highly non-convex, a PSO-based TLOP algorithm is designed to solve it. The proposed algorithm decomposes the problem into an inner-layer transmit power optimization problem and an outer-layer UAV hovering altitude optimization problem. Simulation results show that the proposed algorithm converges rapidly and improves the system secrecy capacity compared with the baseline schemes.
A Task Prediction-augmented Hierarchical Offloading Method for Space-Air-Ground Integrated Networks
ZHANG Linghao, XU Bo, SUN Jinlong, LAI Haiguang, ZHAO Haitao
2026, 48(9): 3768-3778. doi: 10.11999/JEIT260217
Abstract:
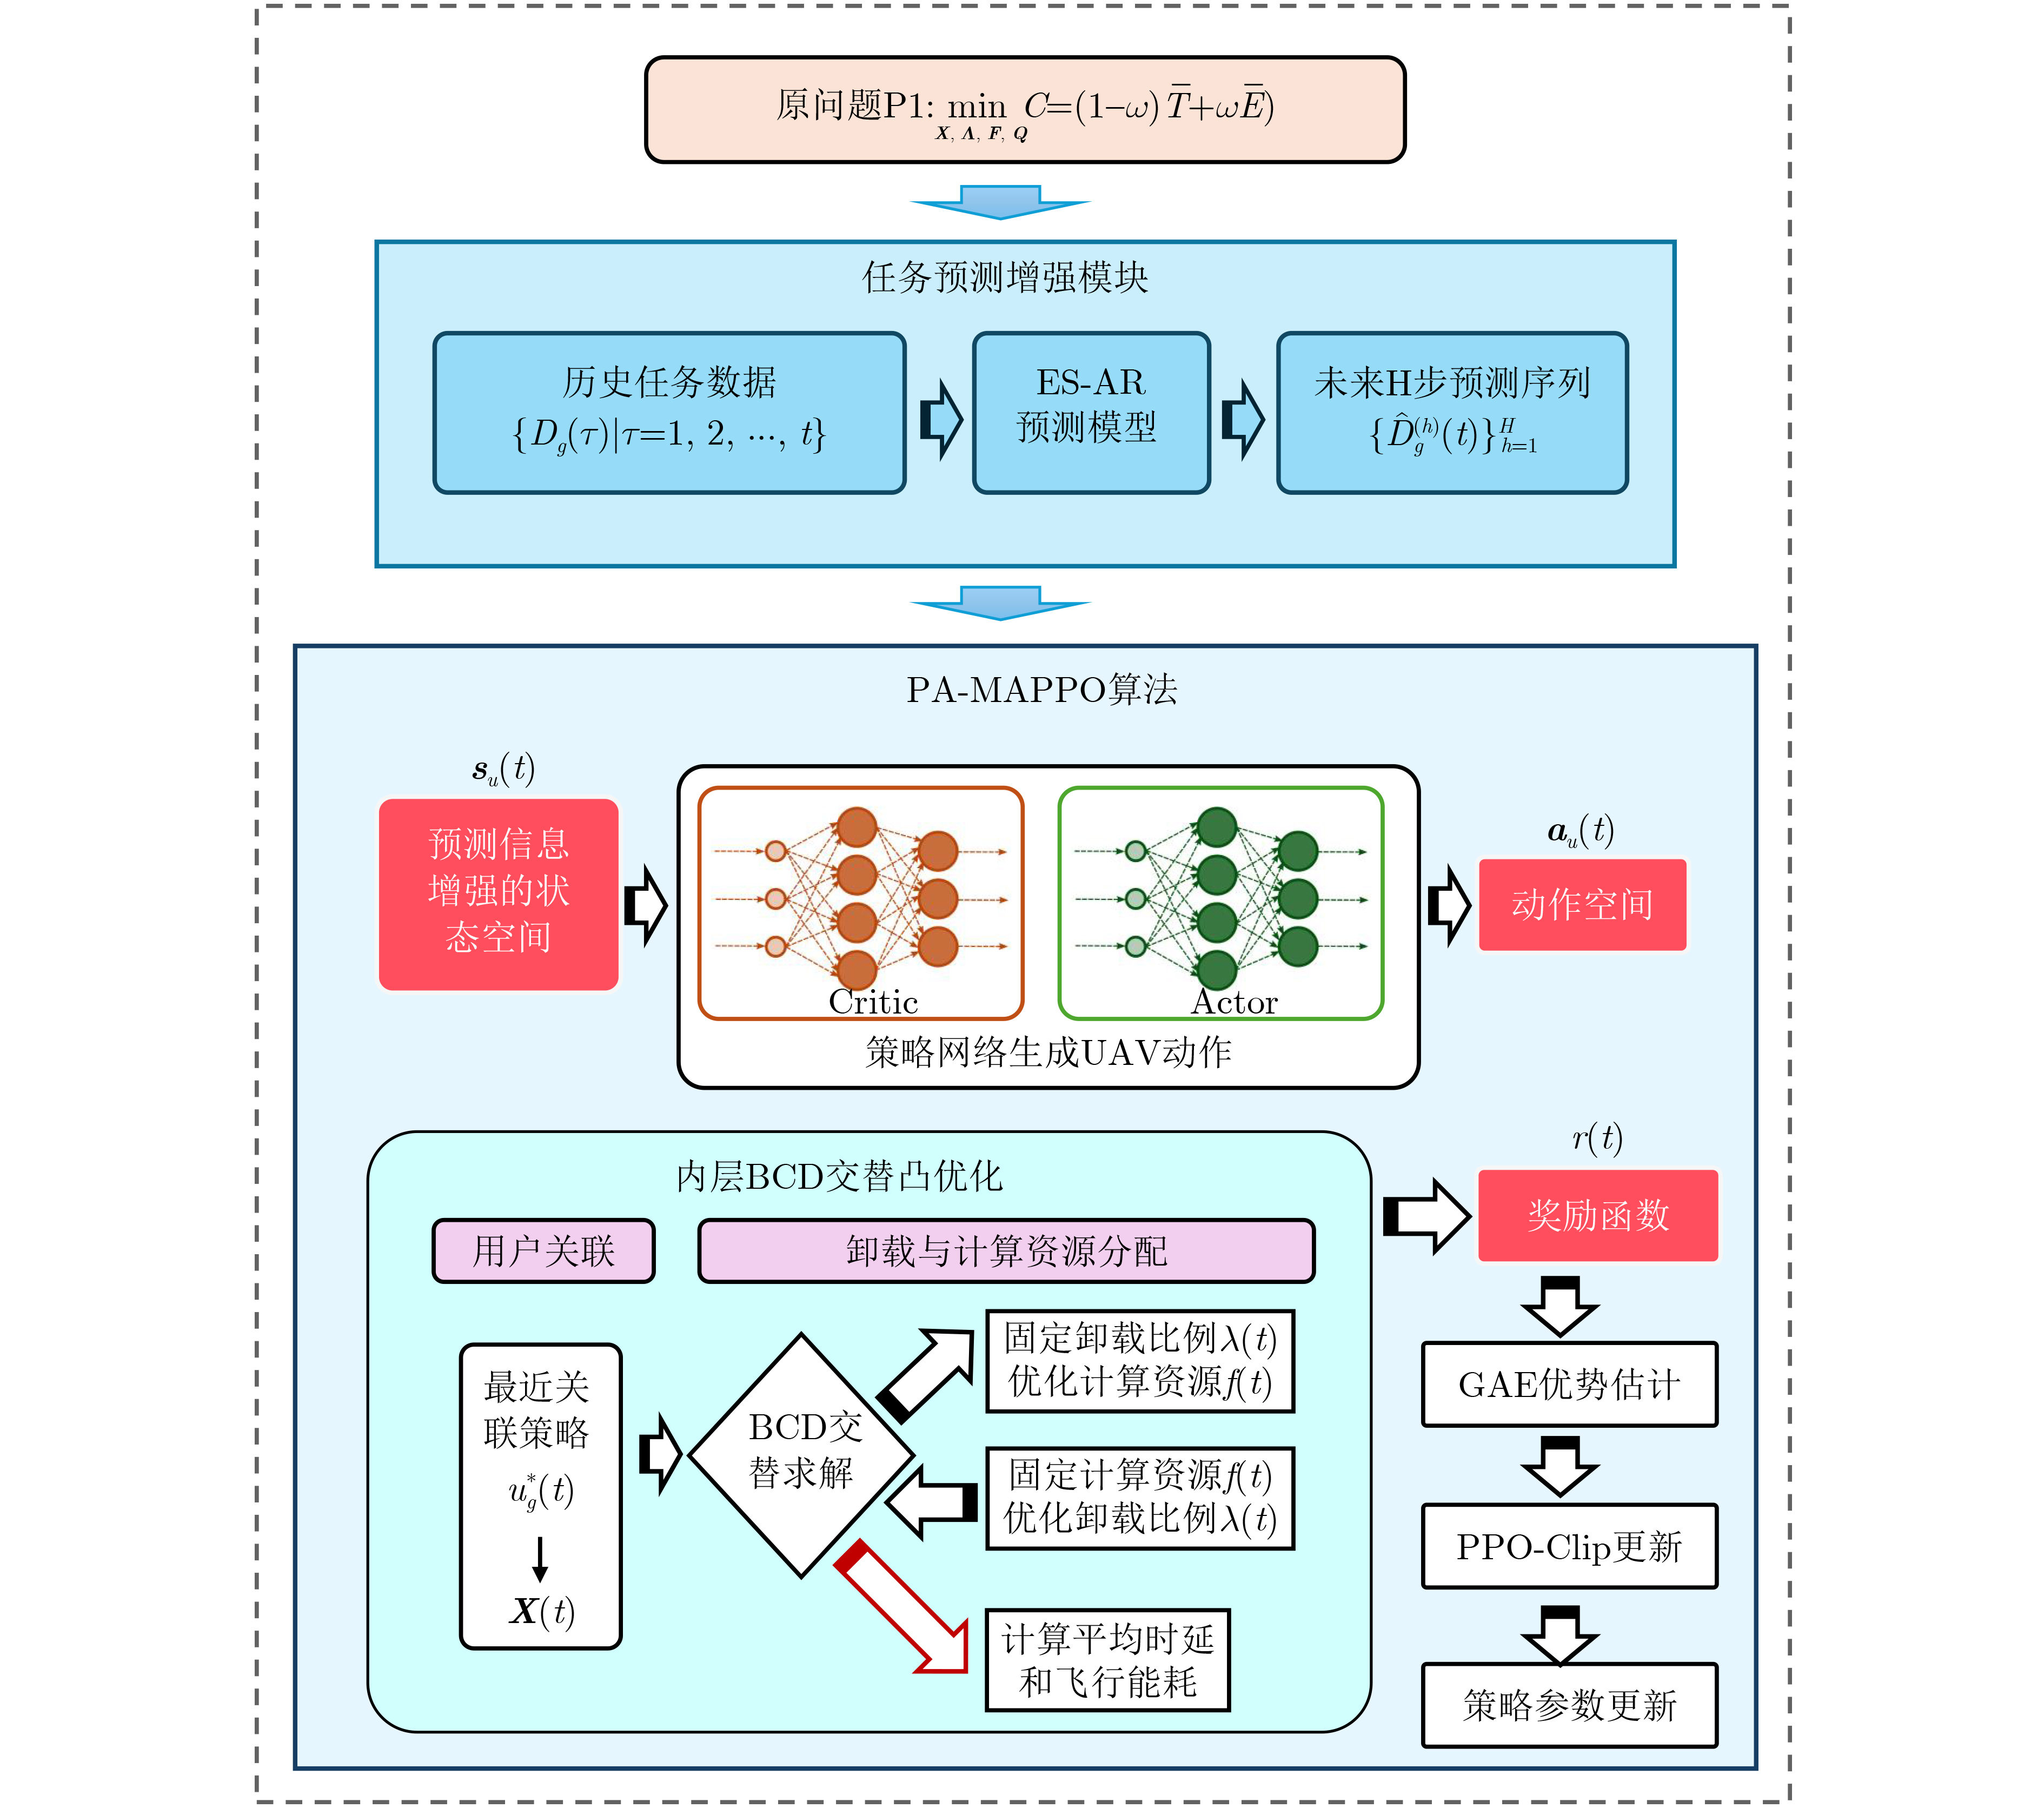
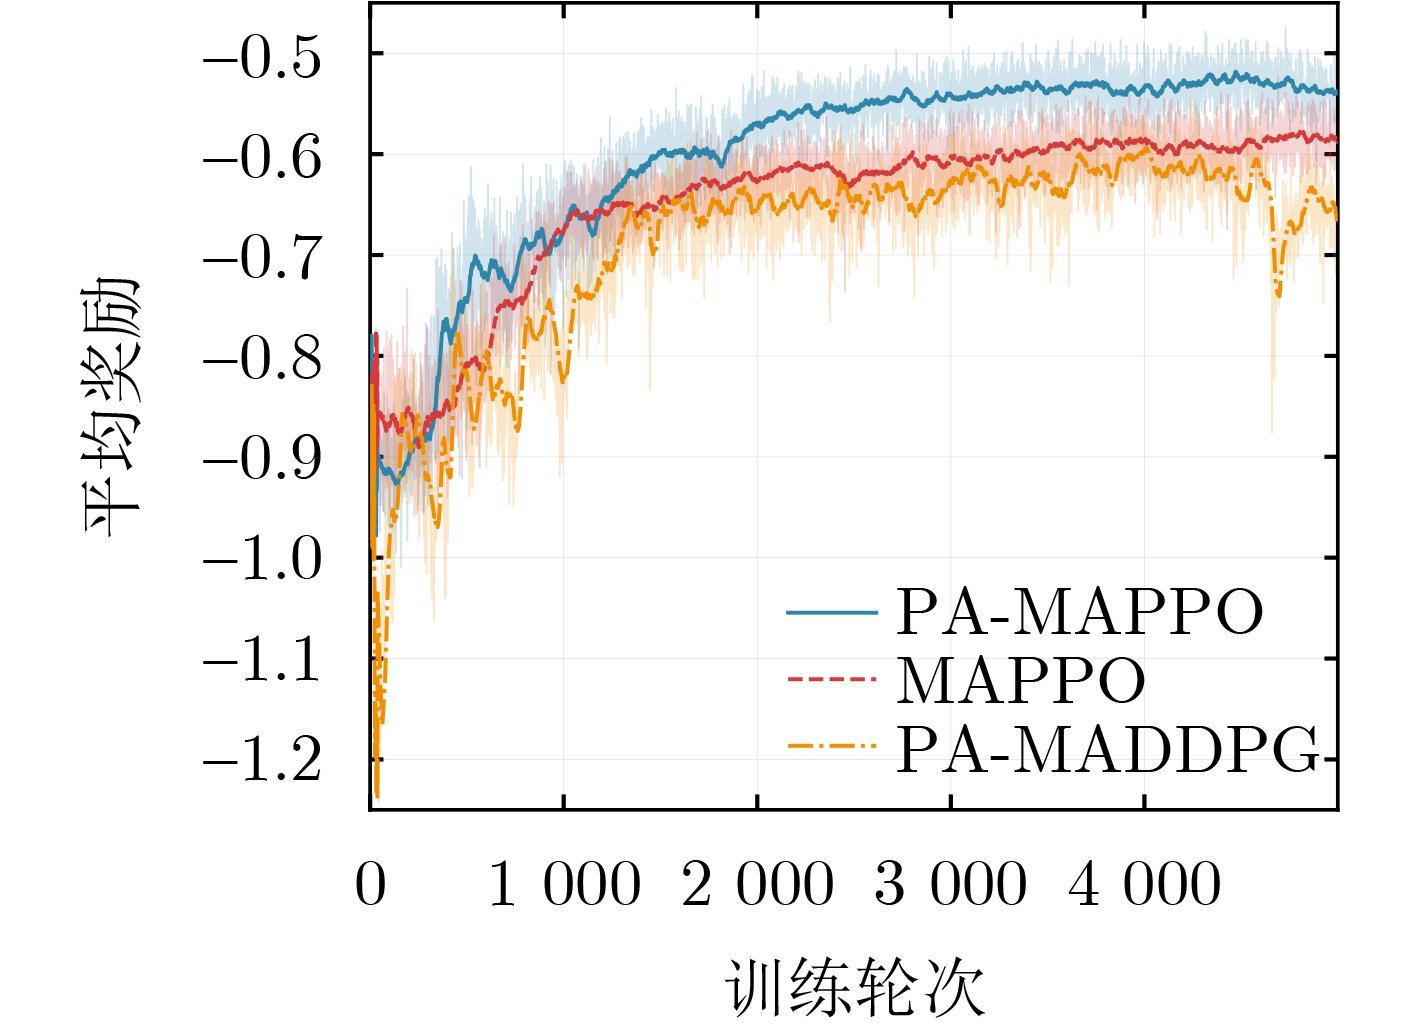
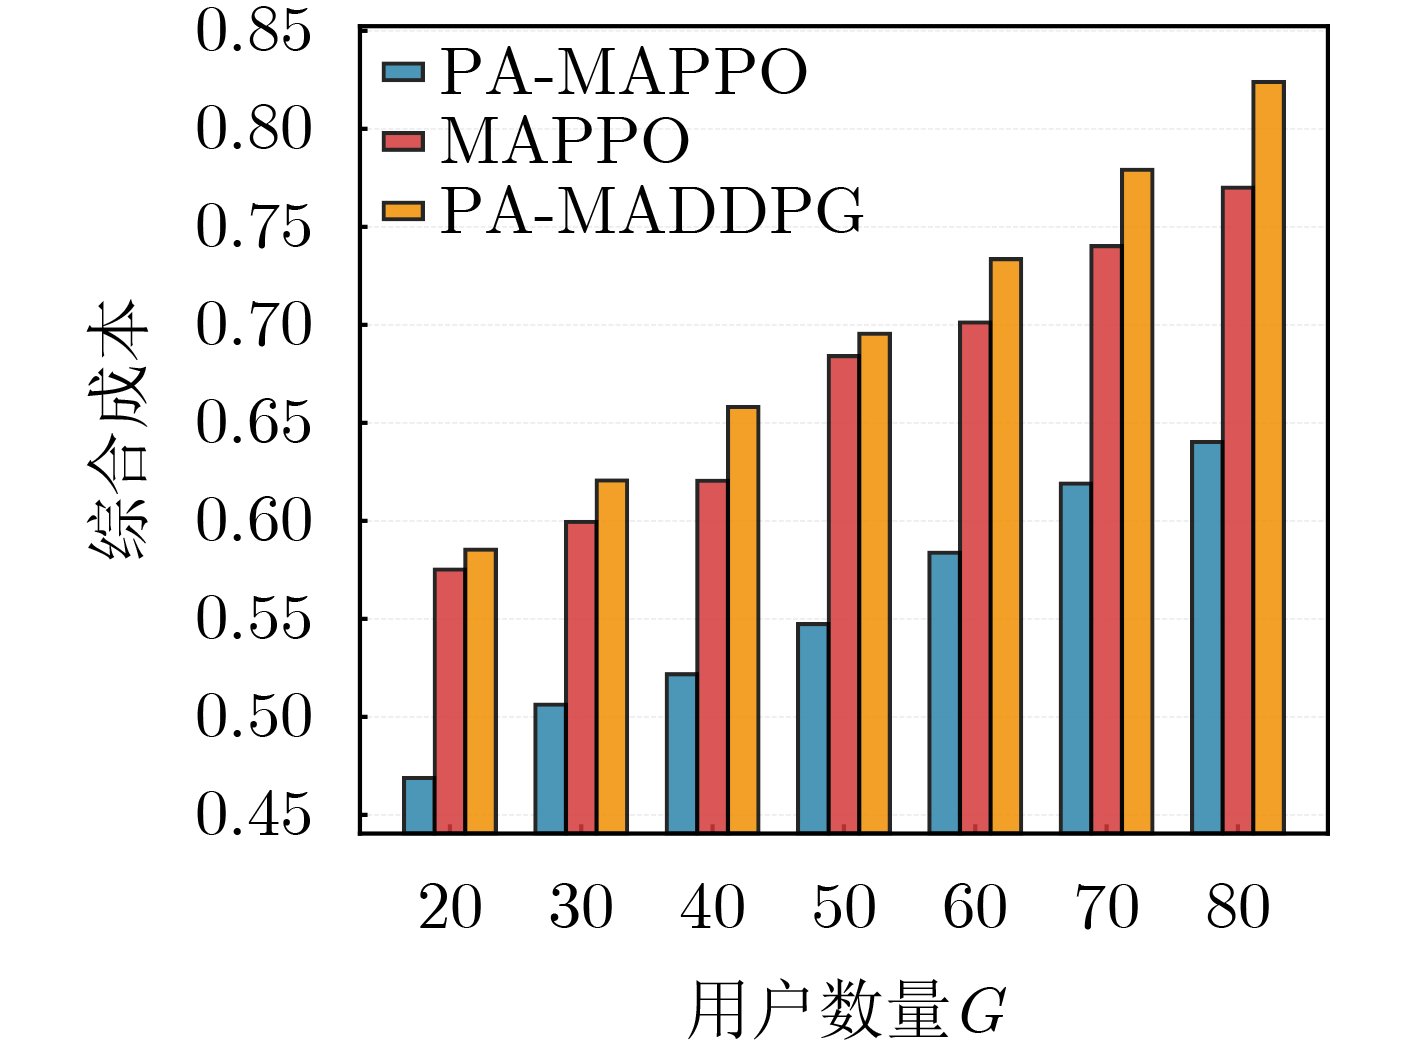
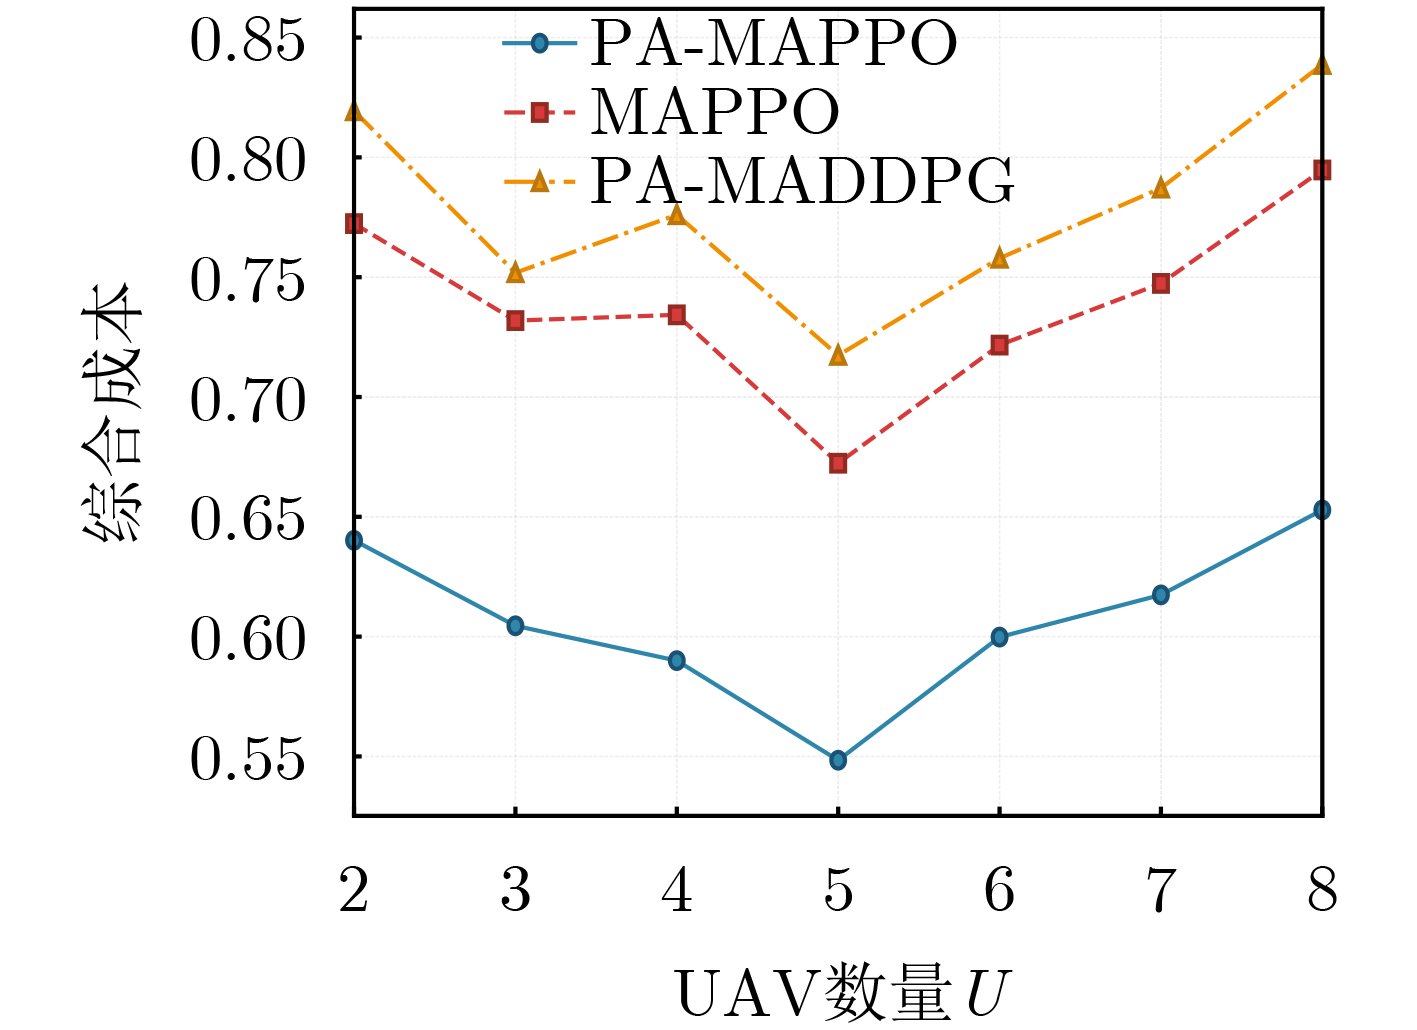
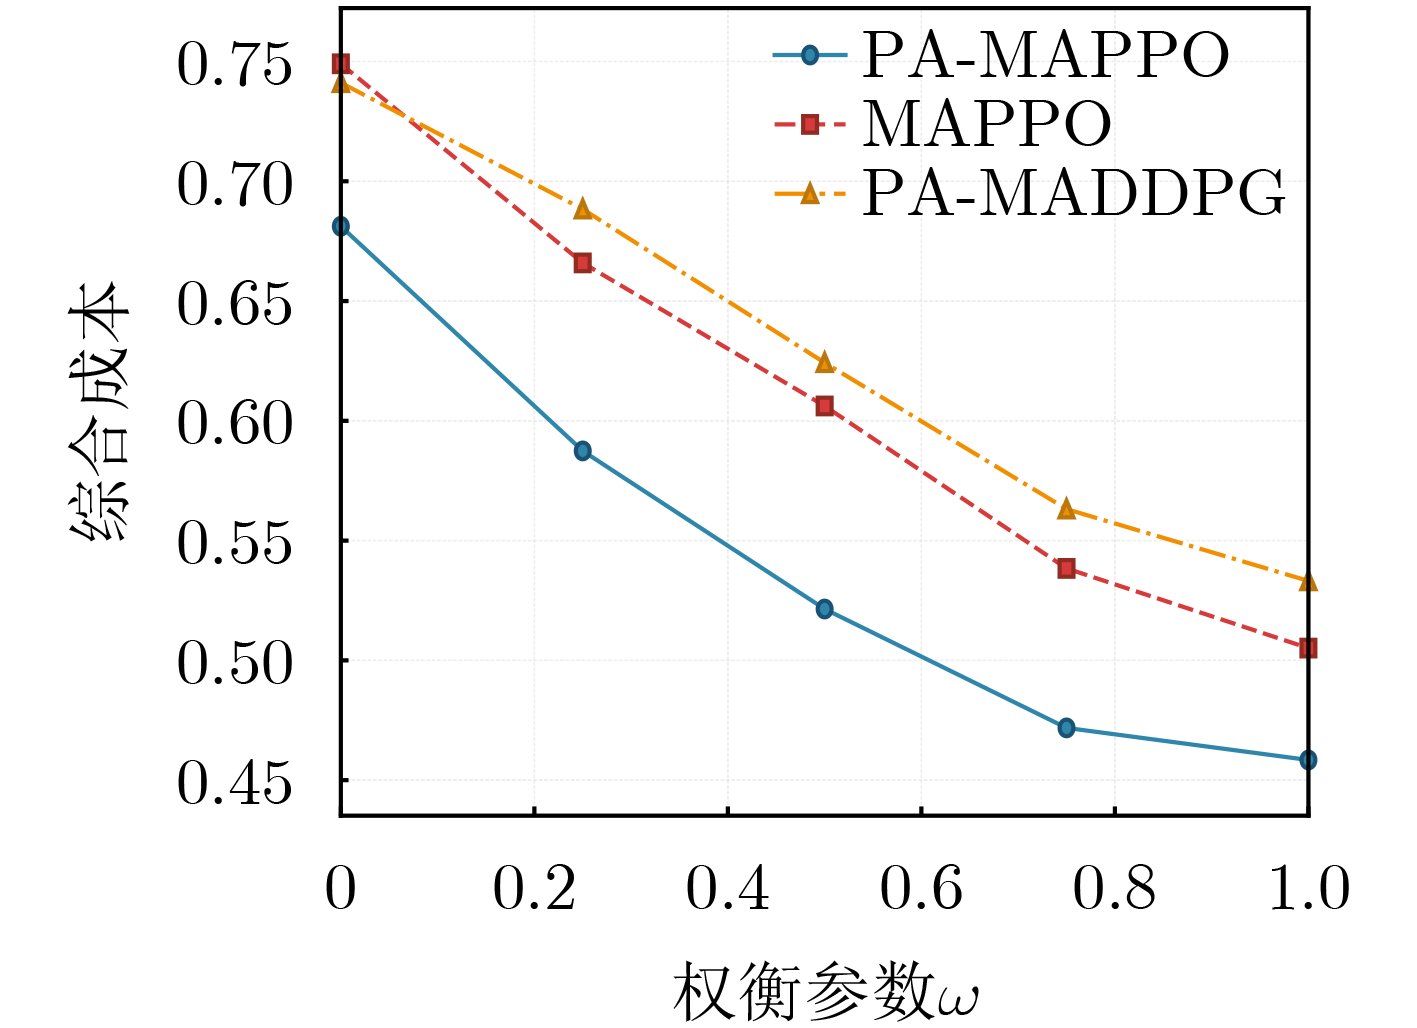
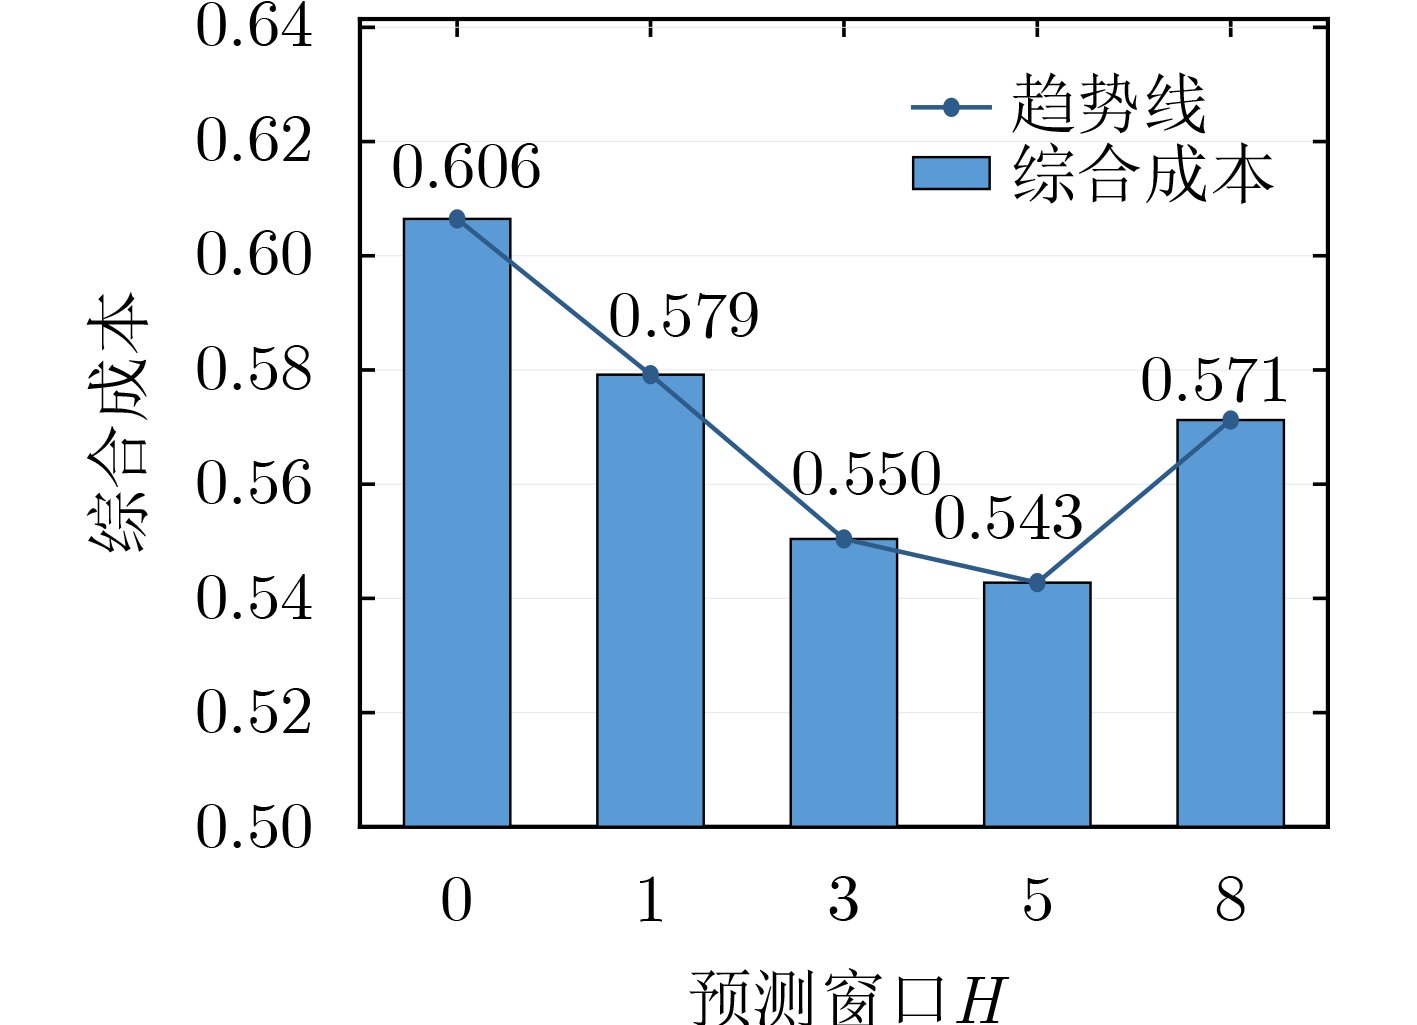
  Objective  Space-Air-Ground Integrated Networks (SAGIN) have become key infrastructure for future 6G communications. They support wide-area coverage and flexible deployment through the coordinated operation of Low Earth Orbit (LEO) satellites, Unmanned Aerial Vehicles (UAVs), and Ground Users (GUs). With the rapid growth of Internet of Things (IoT), Internet of Vehicles (IoV), and smart city applications, terminal devices generate increasingly diverse computation-intensive tasks. These tasks impose high requirements on real-time computing and resource scheduling. Mobile Edge Computing (MEC) has been integrated into SAGIN architectures to provide near-user computing services by using UAVs and satellites as edge nodes, thereby reducing task completion latency. However, efficient task offloading remains challenging when average task completion latency and UAV flight energy consumption must be jointly reduced. This difficulty is caused by the strong coupling among UAV trajectory planning, task offloading, and computational resource allocation. It is further intensified by the dynamic and partially observable nature of SAGIN environments. Existing Multi-Agent Reinforcement Learning (MARL) methods mainly rely on reactive decisions based on instantaneous observations. They lack awareness of future task workload changes, which leads to decision lag and limited adaptability under bursty traffic. To address these issues, a task prediction-augmented MARL method is proposed to support forward-looking decisions in dynamic SAGIN environments.  Methods  A three-layer SAGIN-MEC architecture is considered, including one LEO satellite, multiple UAVs, and GUs. Tasks can be processed locally, offloaded to UAVs through Ground-to-Air (G2A) links, or further relayed to the LEO satellite through Air-to-Satellite (A2S) links under a partial offloading mechanism. The joint optimization of UAV trajectory, user association, offloading ratios, and computational resource allocation is formulated as a Mixed-Integer NonLinear Programming (MINLP) problem. The objective is to minimize the weighted sum of average task completion latency and UAV flight energy consumption. Owing to the nonconvexity and high dimensionality of this problem, it is reformulated as a Decentralized Partially Observable Markov Decision Process (DEC-POMDP). A Prediction-Augmented Multi-Agent Proximal Policy Optimization (PA-MAPPO) algorithm is then developed. A lightweight Exponential Smoothing-Autoregressive (ES-AR) prediction module is used to generate multi-step workload forecasts, which are incorporated into the state space of each agent. The algorithm adopts a bilevel structure. In the outer layer, Centralized Training and Decentralized Execution (CTDE)-based PA-MAPPO generates UAV trajectory actions. In the inner layer, Block Coordinate Descent (BCD)-based convex optimization solves the resource allocation and offloading subproblems, and closed-form resource allocation solutions are obtained through Lagrangian analysis. Generalized Advantage Estimation (GAE) and the PPO-Clip objective are used to improve training stability and convergence.  Results and Discussions  Simulations are conducted with one LEO satellite, five UAVs, and 50 GUs in a 1×1 km2 area. PA-MAPPO is compared with MAPPO without prediction and Prediction-Augmented Multi-Agent Deep Deterministic Policy Gradient (PA-MADDPG). The training curves show that PA-MAPPO converges within 2500 episodes, with the highest average reward and the smallest variance, indicating better stability (Fig. 3). As the number of GUs increases from 20 to 80, PA-MAPPO consistently achieves the lowest system cost. Compared with MAPPO and PA-MADDPG, it reduces the average cost by approximately 12.4% and 18.7%, respectively (Fig. 4). Experiments with different UAV numbers show a U-shaped cost curve for all algorithms. The best configuration is obtained when U=5, where PA-MAPPO achieves the minimum cost (Fig. 5). Sensitivity analysis of the latency-energy tradeoff weight ω confirms that PA-MAPPO remains robust under different optimization preferences (Fig. 6). The prediction horizon H has a nonmonotonic effect on performance. When H=5, PA-MAPPO obtains the best result and reduces the cost by approximately 10.5% compared with the no-prediction case. Longer horizons degrade performance because prediction errors accumulate (Fig. 7).  Conclusions  The PA-MAPPO algorithm is proposed to solve the joint optimization of UAV trajectory planning, user association, task offloading, and computational resource allocation in dynamic SAGIN environments. By integrating a lightweight ES-AR task workload prediction module into the MARL process, PA-MAPPO enables UAV agents to account for future task dynamics. This design reduces the decision lag caused by purely reactive methods. The inner BCD-based convex optimization converges to a Karush-Kuhn-Tucker (KKT)-stationary point, while the outer CTDE-based PPO mechanism improves training stability and scalability. Simulation results show that PA-MAPPO consistently achieves a lower overall system cost than the baseline methods across different system scales and parameter settings, achieving a better balance between task latency and UAV flight energy consumption. It also maintains strong scalability and robustness under different system configurations. Future work will study online prediction and decision co-optimization in multi-satellite cooperative scenarios and examine the effect of dynamic network topology changes on algorithm performance.
Queue Stability-Constrained Robust Secure Beamforming for Low-Altitude UAV-ISAC Systems
OUYANG Jian, REN Wei, XU Ba, LIU Xiaoyu, JIANG Wanmu
2026, 48(9): 3779-3789. doi: 10.11999/JEIT260275
Abstract:
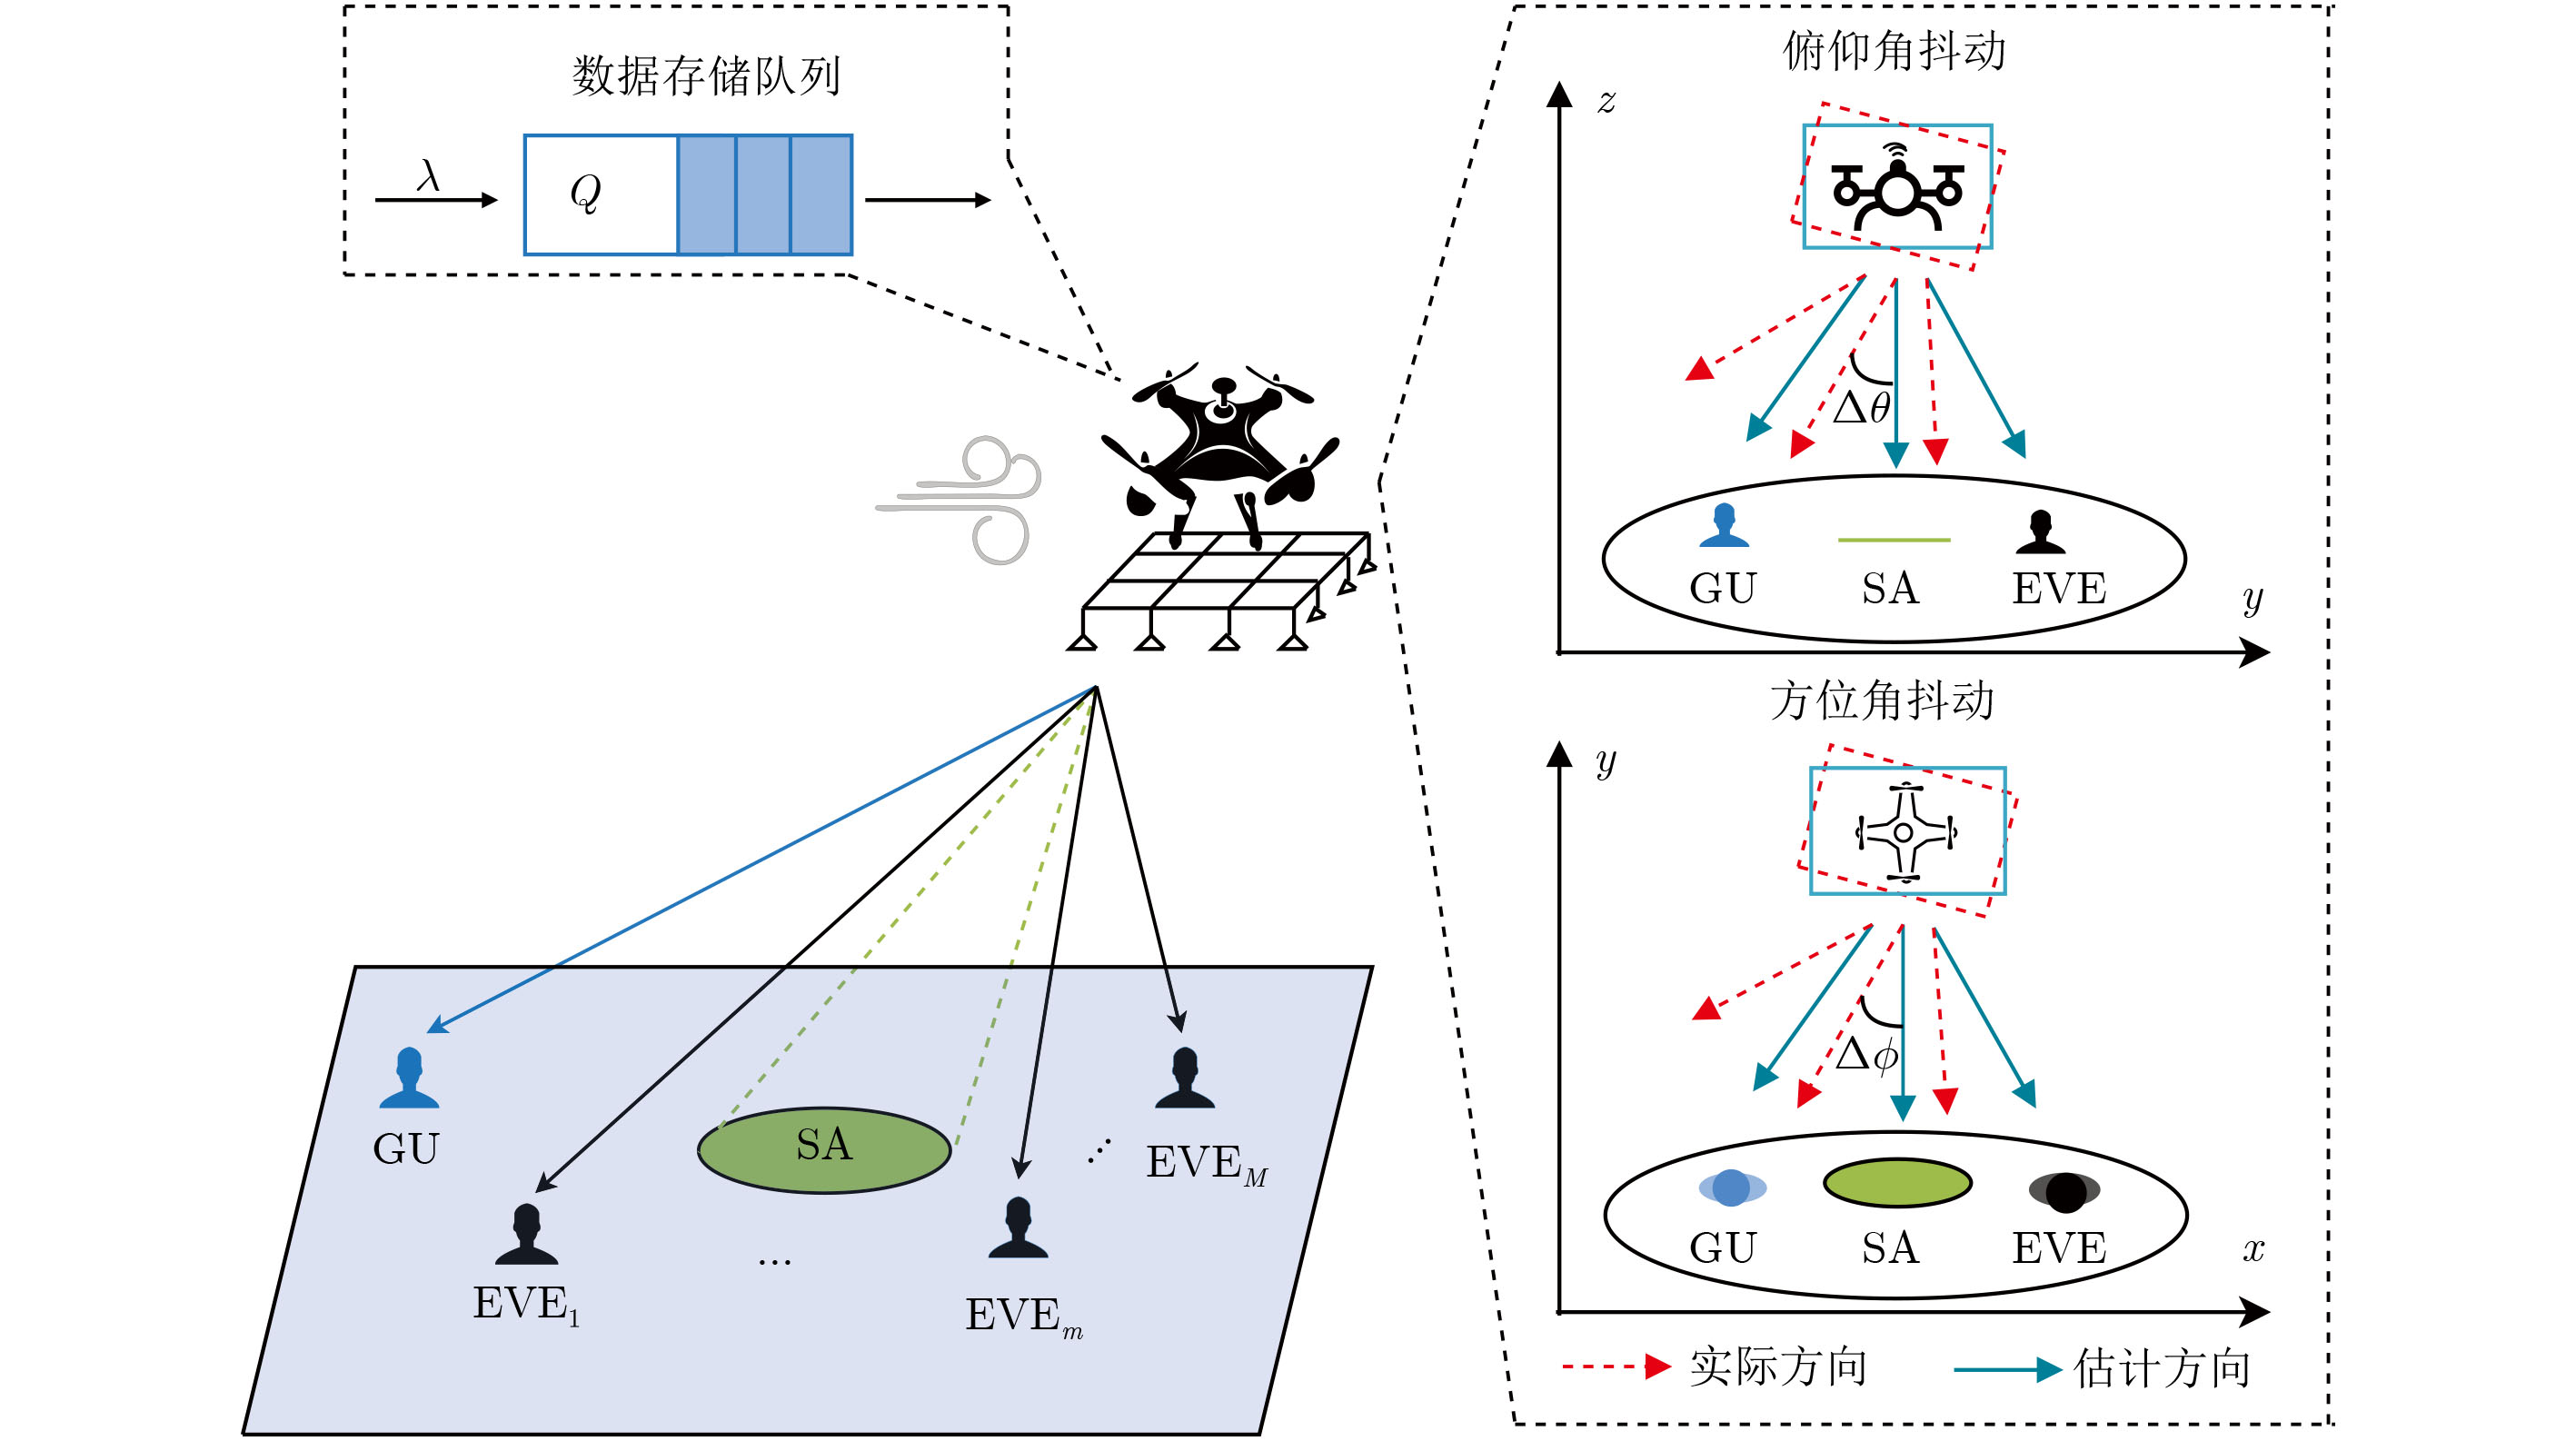
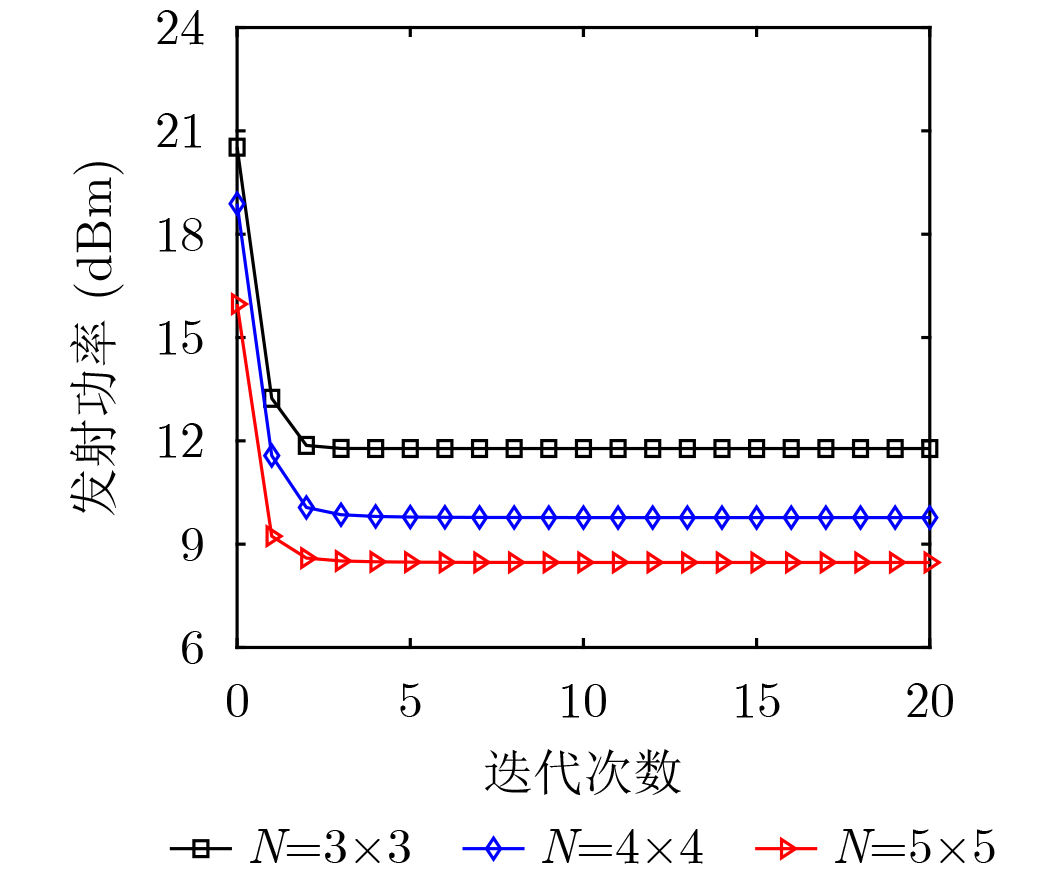
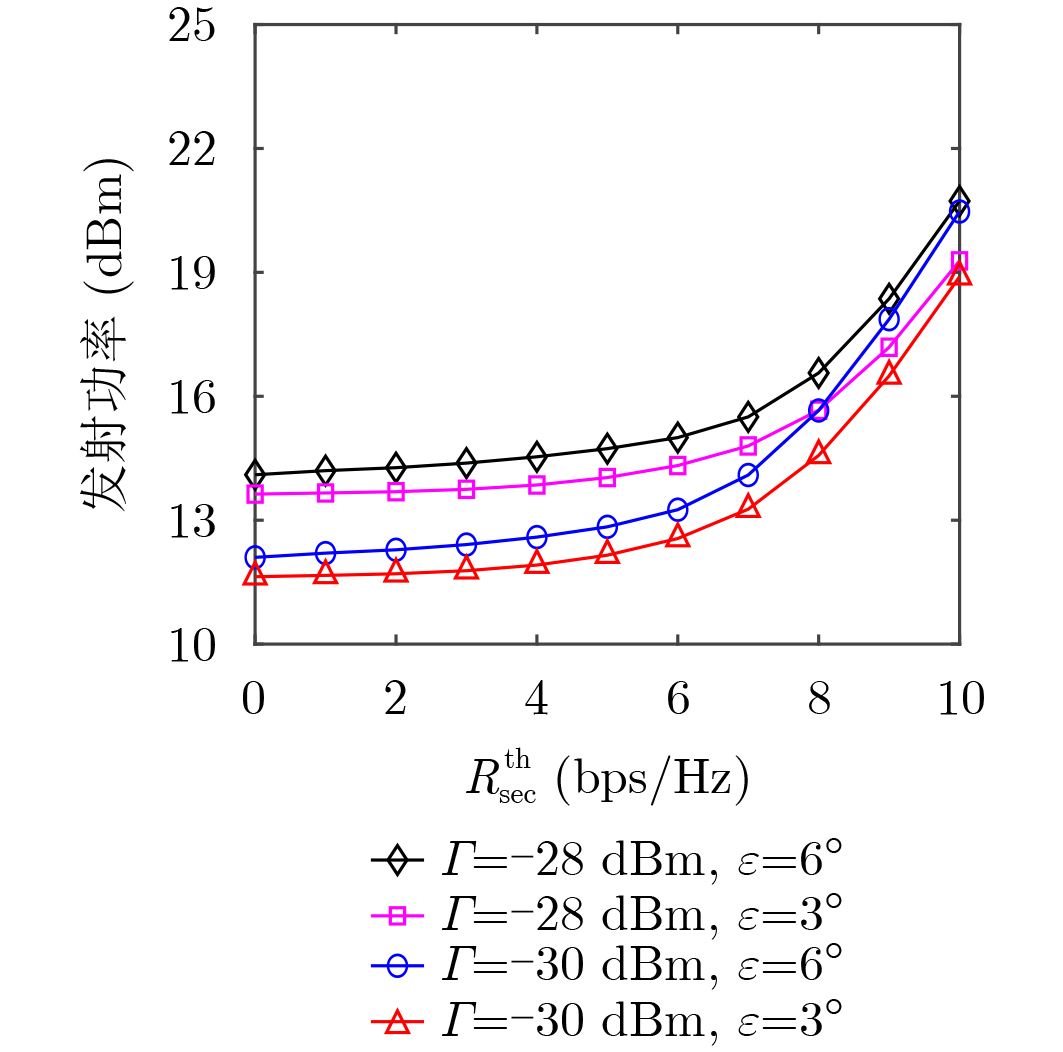
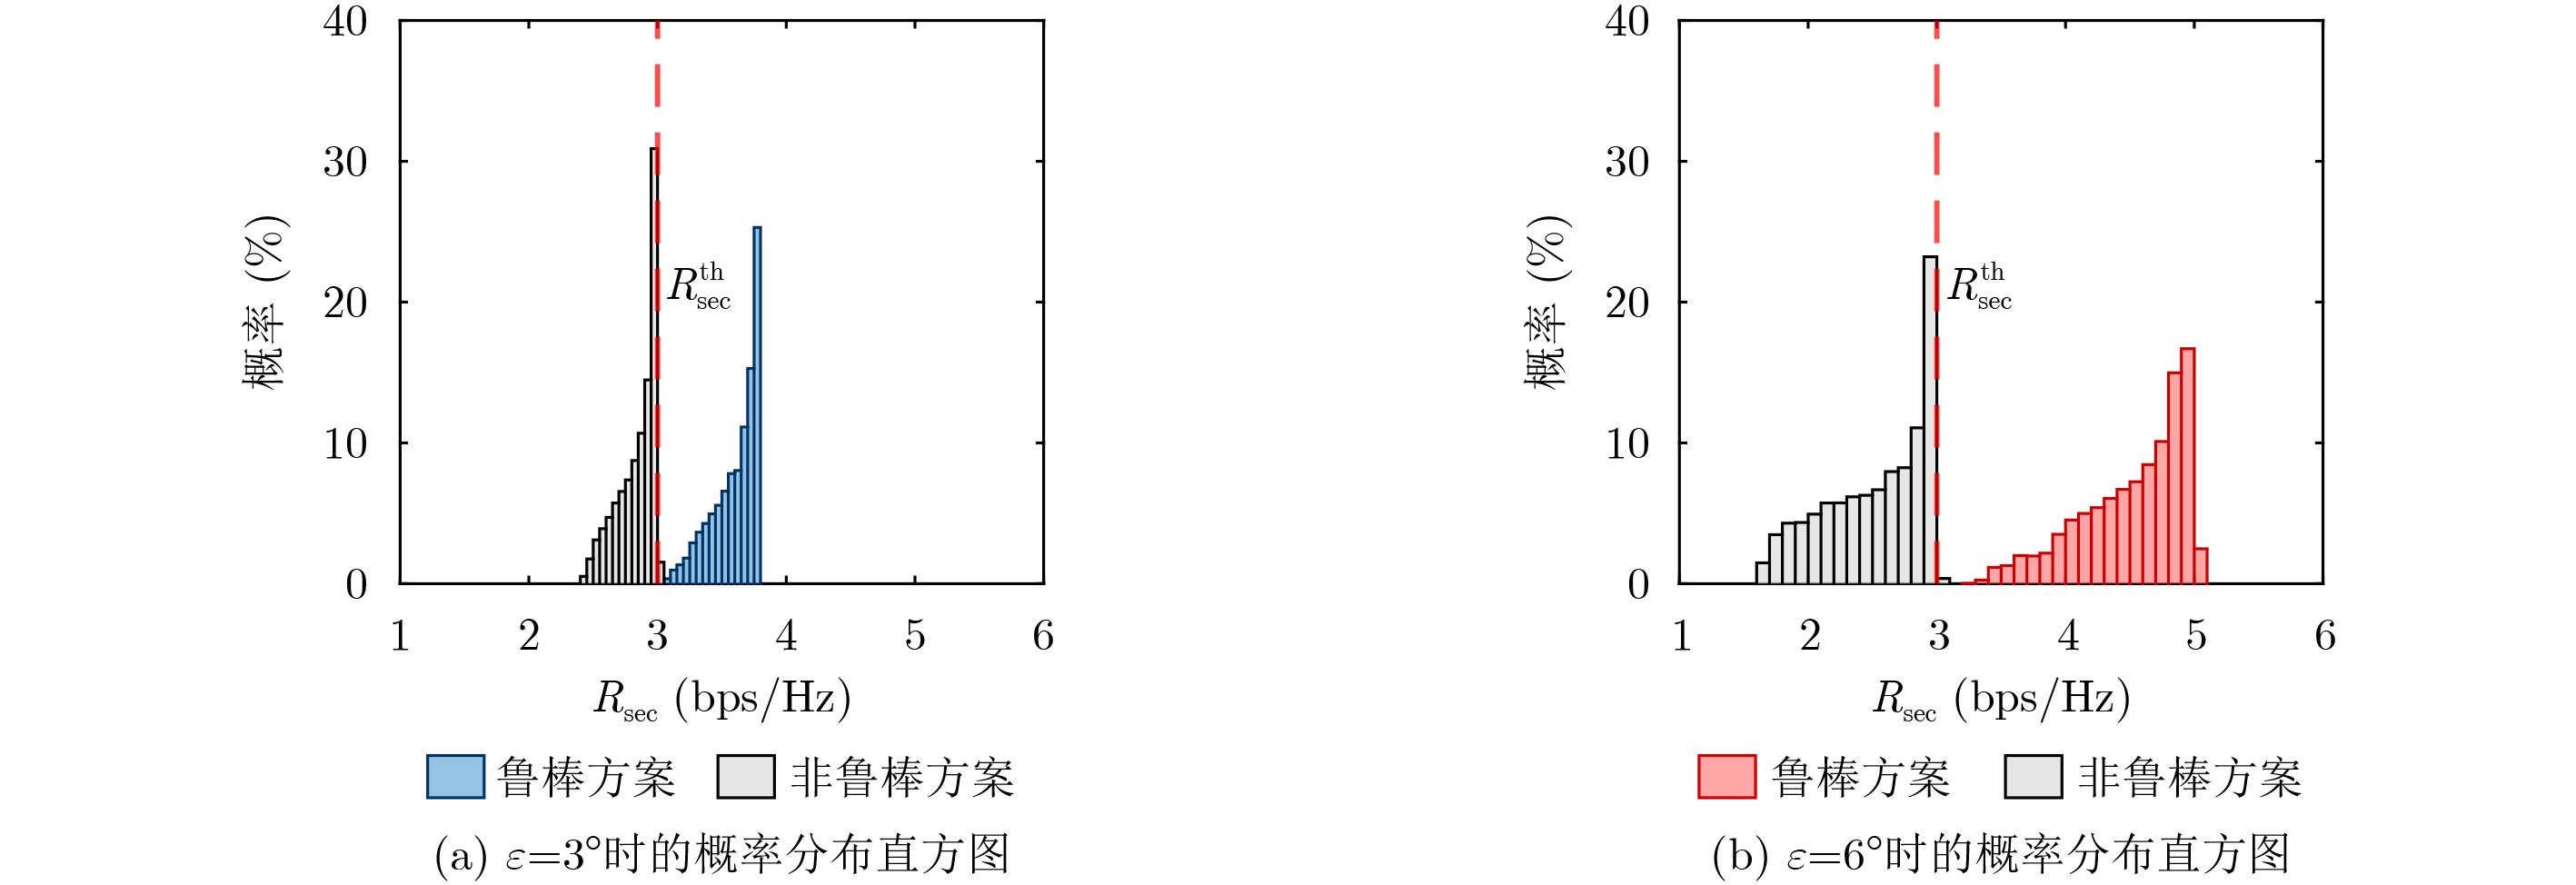
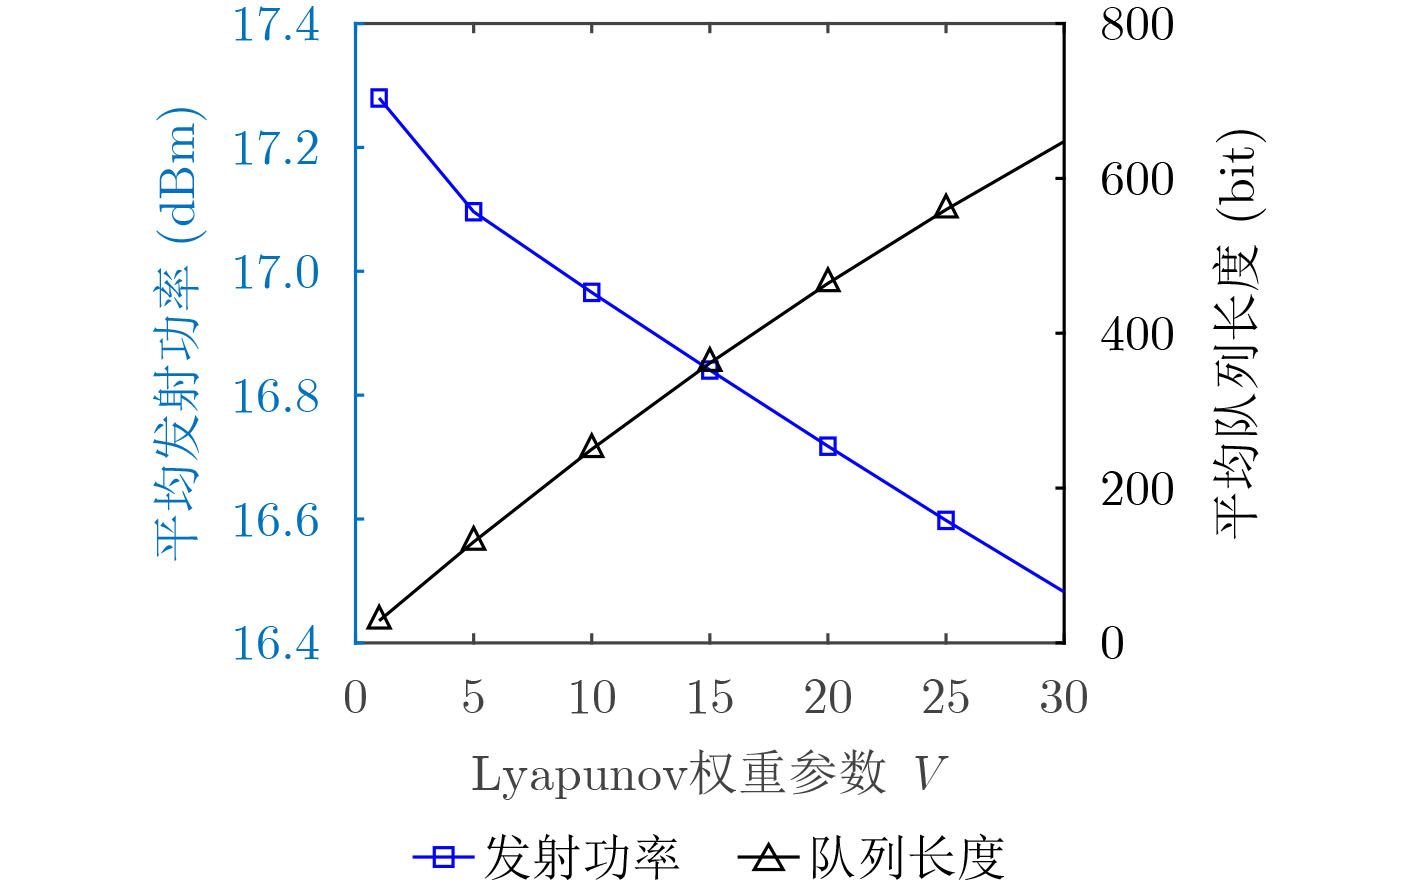
  Objective  To address antenna array angle errors caused by Unmanned Aerial Vehicle (UAV) jitter, transmission instability resulting from random data arrivals, and secure transmission in multi-eavesdropper scenarios for low-altitude Integrated Sensing and Communication (ISAC) systems, a robust secure beamforming algorithm subject to queue stability constraints is proposed. The proposed algorithm minimizes the long-term average transmit power while maintaining data queue stability and enhancing beamforming robustness against UAV jitter.  Methods  An optimization problem is formulated to minimize the long-term average transmit power subject to constraints on data queue stability, minimum secrecy rate, sensing performance, and maximum transmit power. Because the long-term stochastic optimization problem is difficult to solve directly, the Lyapunov optimization framework is employed to transform it into a sequence of short-term optimization subproblems. To address antenna array angle errors caused by UAV jitter within each time slot, the Second-Order Taylor Series Expansion (STSE) and the S-Procedure are jointly employed to approximate the non-convex problem with a tractable convex formulation. A robust secure beamforming algorithm based on penalty-based successive convex approximation is then developed.  Results and Discussions  Simulation results demonstrate the effects of the number of antennas, minimum secrecy rate threshold, sensing beam gain threshold, UAV jitter error, and Lyapunov weight factor on the system transmit power. As shown in Fig. 3, the communication beamformer provides additional sensing gain for the sensing area, whereas the sensing beamformer enhances communication security by directing interference toward potential eavesdroppers. These results verify the effectiveness of the proposed algorithm in jointly improving sensing and secure communication performance. Furthermore, by exploiting the dual-function characteristics of the communication and sensing beamformers, the proposed ISAC scheme achieves higher resource utilization efficiency than the separated sensing-and-communication scheme, as shown in Fig. 5. Figure 6 further shows that, compared with the non-robust scheme, the proposed robust scheme consistently satisfies the minimum secrecy rate requirement under various angle errors. In addition, Fig. 8 demonstrates that the proposed queue-aware scheme effectively suppresses transmit power fluctuations caused by random data arrivals, providing better transmission stability than the scheme without queue constraints.  Conclusions  A robust secure beamforming method for UAV-ISAC systems subject to queue stability constraints is investigated. The Lyapunov optimization framework transforms the long-term stochastic optimization problem into a sequence of short-term optimization subproblems. The STSE and the S-Procedure are jointly employed to convert the non-convex constraints caused by UAV jitter into tractable convex forms. A robust secure beamforming algorithm based on penalty-based successive convex approximation is then developed to efficiently solve the resulting deterministic short-term optimization subproblems. Simulation results demonstrate that the proposed scheme effectively addresses random data arrivals, UAV jitter, and eavesdropping threats, thereby ensuring the stability and security of downlink data transmission in low-altitude UAV-ISAC systems.
Research on Energy Efficiency Optimization for Rotatable Hybrid Reconfigurable Intelligent Surface-aided Communication
ZHANG Guangchi, GUO Xuan, WANG Luyao, CUI Miao, FU Hao
2026, 48(9): 3790-3799. doi: 10.11999/JEIT260119
Abstract:
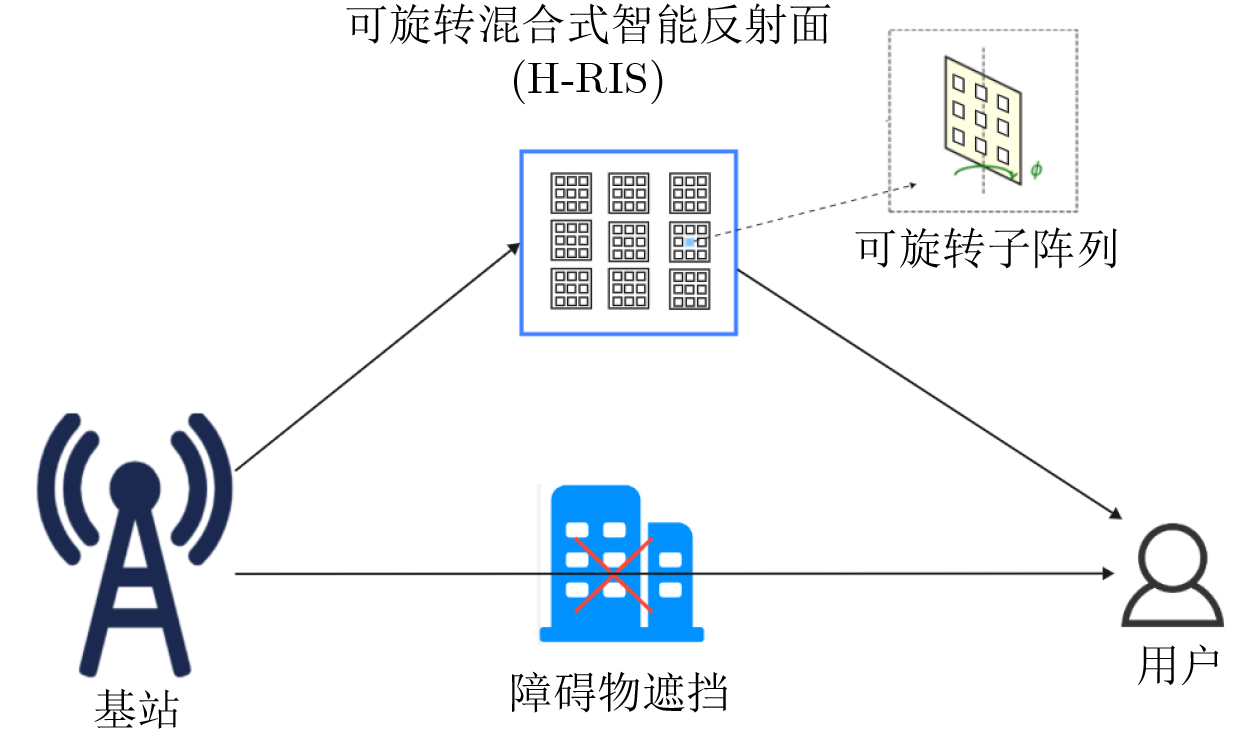
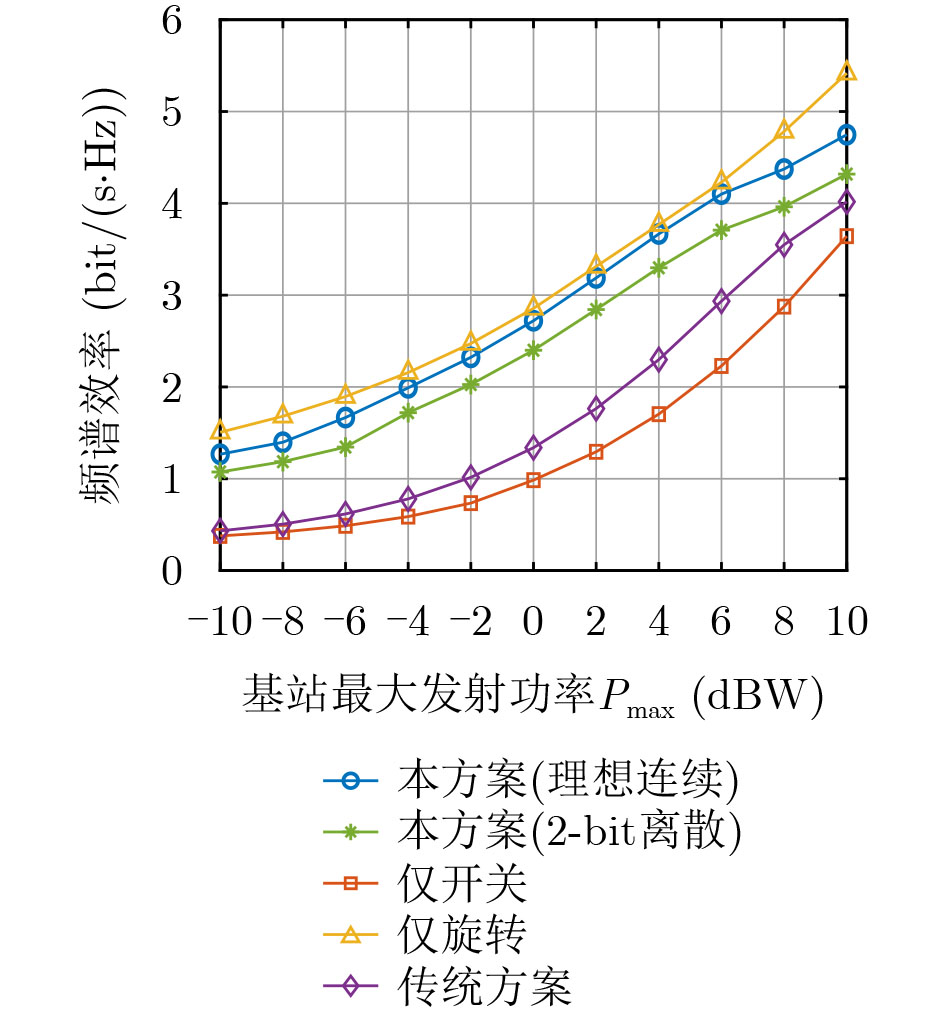
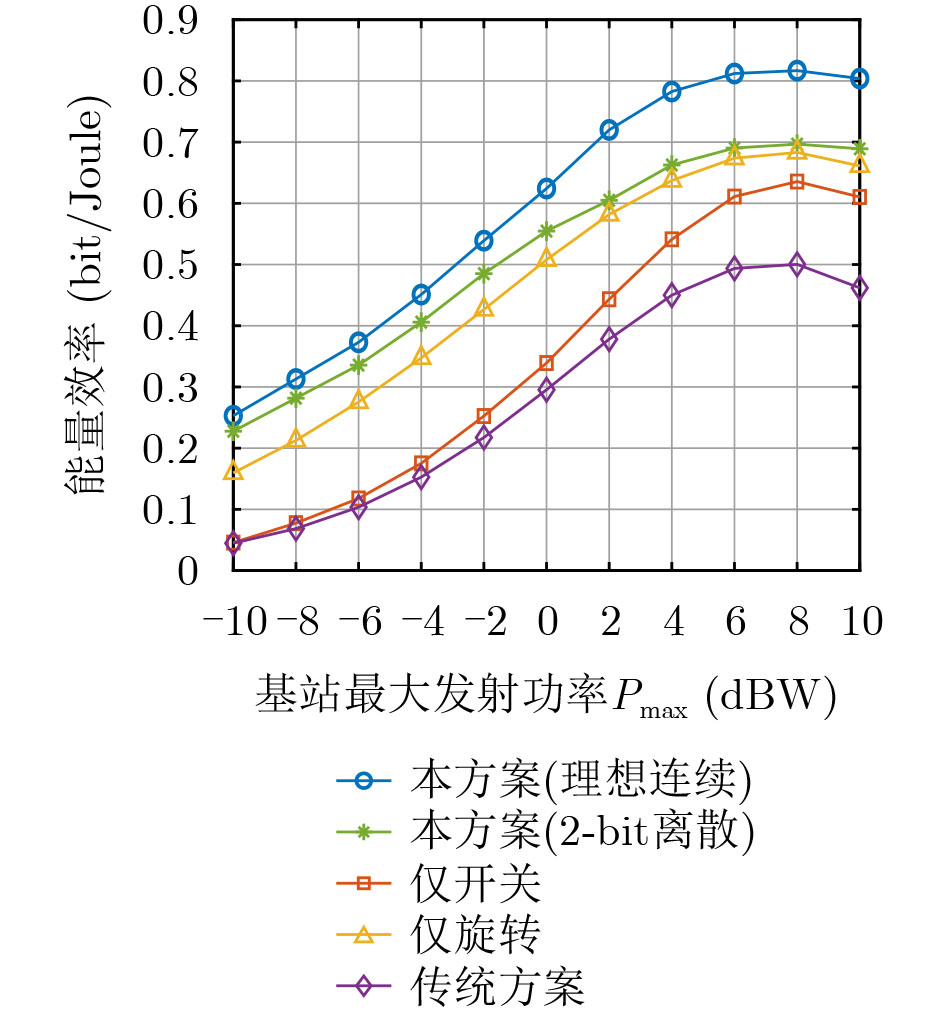
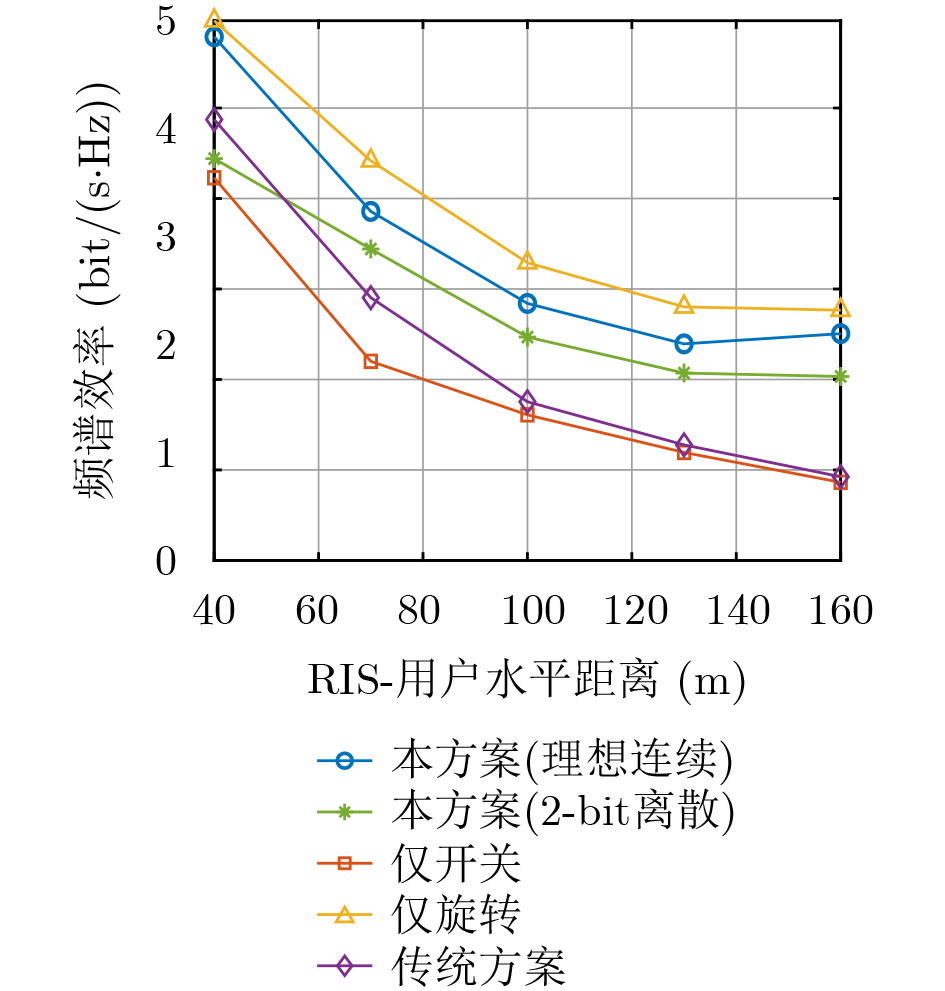
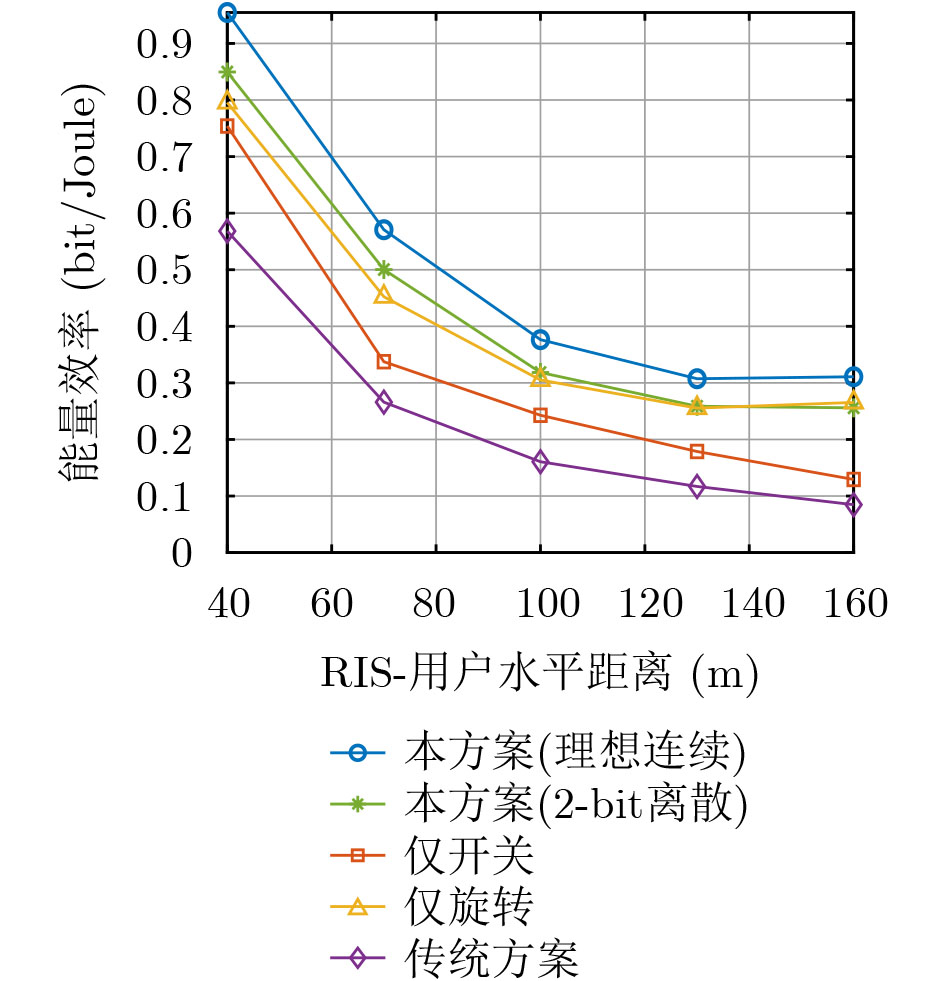
  Objective  With the evolution of sixth-generation (6G) communication networks, Reconfigurable Intelligent Surfaces (RISs) have become a promising technology for reshaping wireless propagation environments and improving spectral efficiency. However, conventional fixed RIS architectures face two main deployment challenges. The first is angle-mismatch loss, in which the effective aperture is reduced when users are located at large angles from the RIS normal. The second is the energy-consumption bottleneck caused by the cumulative power consumption of Radio Frequency (RF) circuits and static control elements in large-scale arrays. Existing studies often consider mechanical rotation and element switching separately. A unified framework is still needed to balance mechanical and circuit energy consumption with communication gain. To address these limitations, this paper investigates a Rotatable and Switchable Hybrid RIS (H-RIS)-aided downlink communication system. The objective is to maximize system Energy Efficiency (EE) by jointly optimizing the base-station transmit power, subarray activation states, physical rotation angles, and electronic phase shifts. Mechanical rotation degrees of freedom are used to compensate for path loss, whereas dynamic switching is used to reduce redundant power consumption and support green communication.  Methods  A joint optimization framework is established for an H-RIS-aided single-user Multiple-Input Single-Output (MISO) system. The system model accounts for the dynamic power consumption induced by mechanical rotation and the static power consumption of active subarrays. The optimization problem is formulated as a non-convex Mixed-Integer Nonlinear Programming (MINLP) problem with coupled binary variables for subarray activation states and continuous variables for transmit power, rotation angles, and phase shifts. To solve this problem, a Block Coordinate Descent (BCD)-based Alternating Optimization (AO) algorithm is proposed to decouple the variables into three subproblems. First, a channel-contribution-based ranking strategy is developed to address the exponential complexity caused by binary switching variables. Eigenvalue decomposition is performed on the cascaded channel correlation matrix to quantify the priority of each subarray, reducing the search space from exponential to linear complexity. Second, for the power-allocation subproblem, the non-convex fractional objective function is transformed into a parametric subtractive form by using the Dinkelbach algorithm and is then solved by the interior-point method. Third, for physical-rotation and electronic-phase optimization, the problem is decomposed into single-variable subproblems. A Golden Section Search algorithm is used to iteratively obtain the optimal rotation angle and phase shift of each subarray within bounded constraints, which ensures monotonic convergence of the objective function.  Results and Discussions  Extensive simulations are conducted to evaluate the proposed H-RIS scheme against benchmark schemes, including “Only-Rotation” (always on), “Only-Switching” (fixed angle), and “Conventional” (fixed and always on). The simulation results under the maximum transmit power Pmax (Fig. 2 and Fig. 3) show that the proposed method achieves the highest EE across the full power range. In the low-power regime, the proposed algorithm turns off redundant subarrays when the rate gain cannot offset the circuit power cost. This strategy yields higher EE than the “Only-Rotation” scheme, which suffers from high static power consumption. The effect of user distance is also analyzed (Fig. 4 and Fig. 5). The results show that the proposed scheme maintains high spectral efficiency comparable to that of the “Only-Rotation” scheme by dynamically adjusting the rotation angles to align with the Line-of-Sight (LoS) path. This adjustment effectively compensates for the angle-mismatch loss observed in the “Only-Switching” and “Conventional” schemes. In addition, the subarray activation pattern varies in a “U” shape with distance (Table 1), enabling flexible adjustment of array size and orientation according to the user-RIS geometry.  Conclusions  This paper proposes an energy-efficient transmission scheme for H-RIS-aided communication systems by integrating mechanical rotation with dynamic switching. A low-complexity BCD-based algorithm is developed to jointly optimize the transceiver design. The results confirm that mechanical rotation mitigates angle-mismatch loss, whereas the proposed channel-contribution-based switching strategy reduces redundant energy consumption. Compared with conventional fixed RIS architectures, the proposed H-RIS architecture provides a better trade-off between spectral efficiency and EE, offering a feasible solution for future green 6G networks.
A Multi-Dimensional Scenario-Based Evaluation Method for Deep Learning Side-Channel Analysis Using a Multi-Attribute Decision Model
GU Zepeng, CHEN Lin, CAI Juesong, YAN Yingjian
2026, 48(9): 3800-3810. doi: 10.11999/JEIT260198
Abstract:
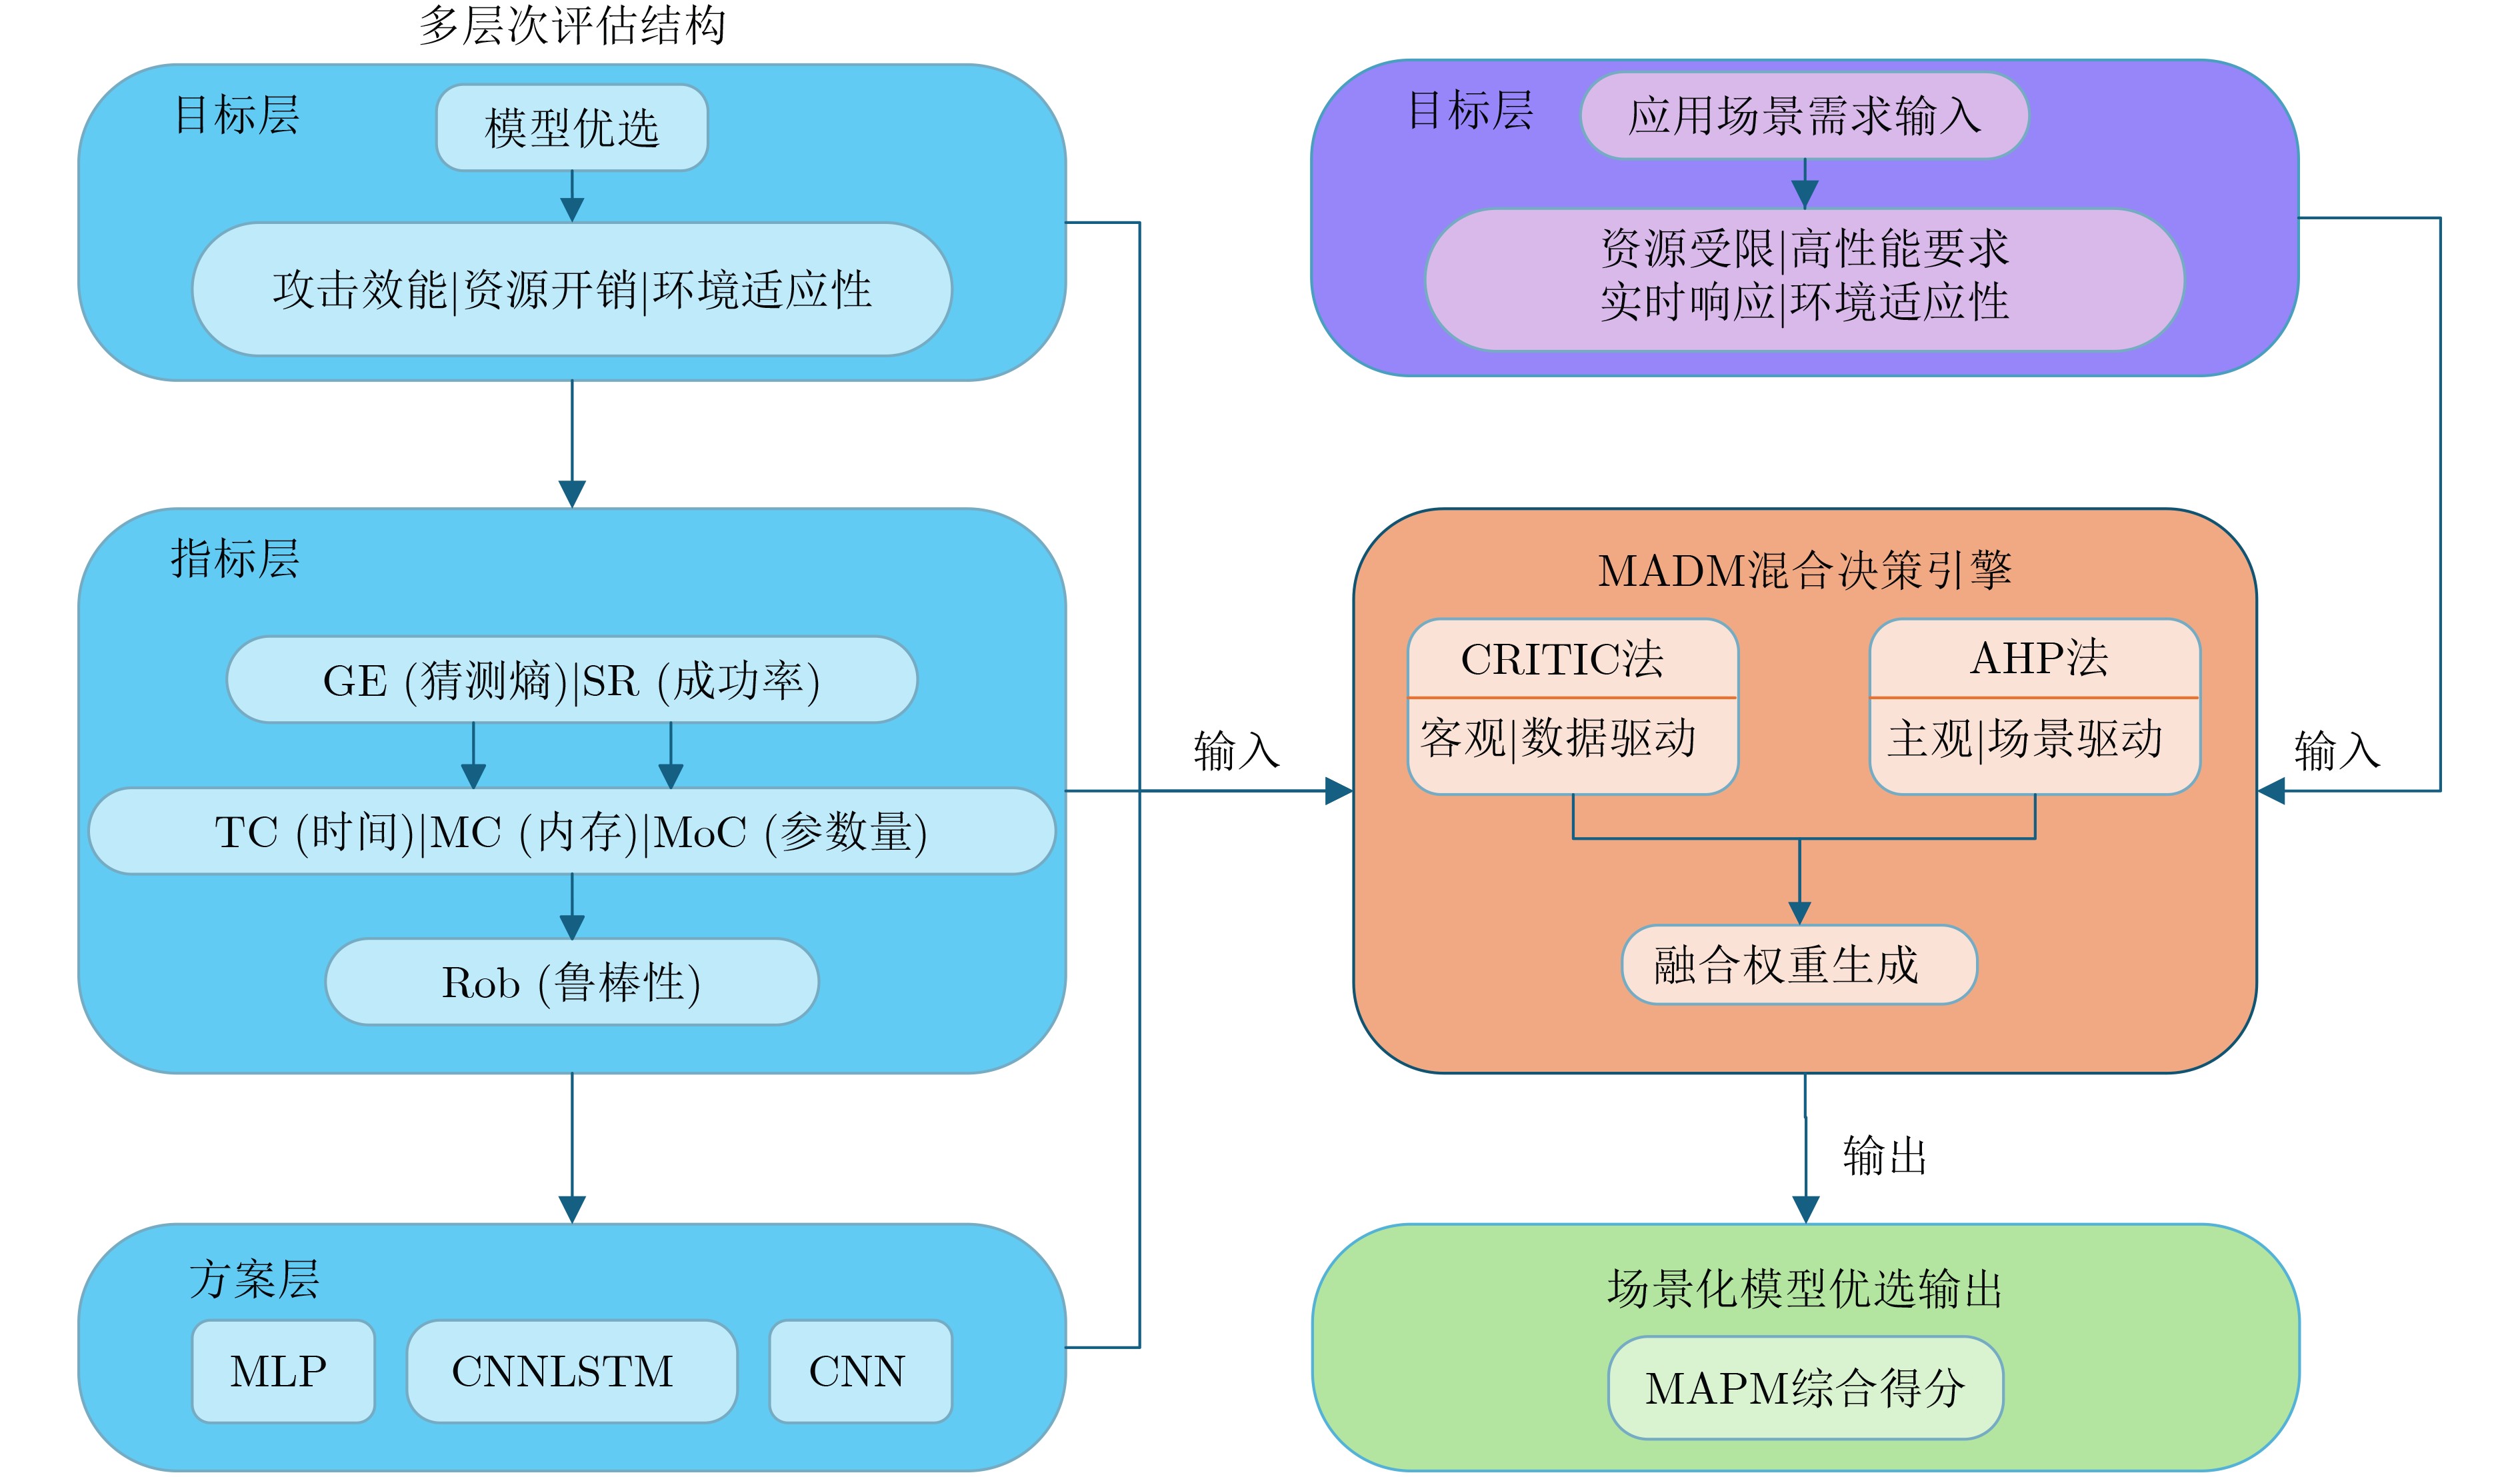
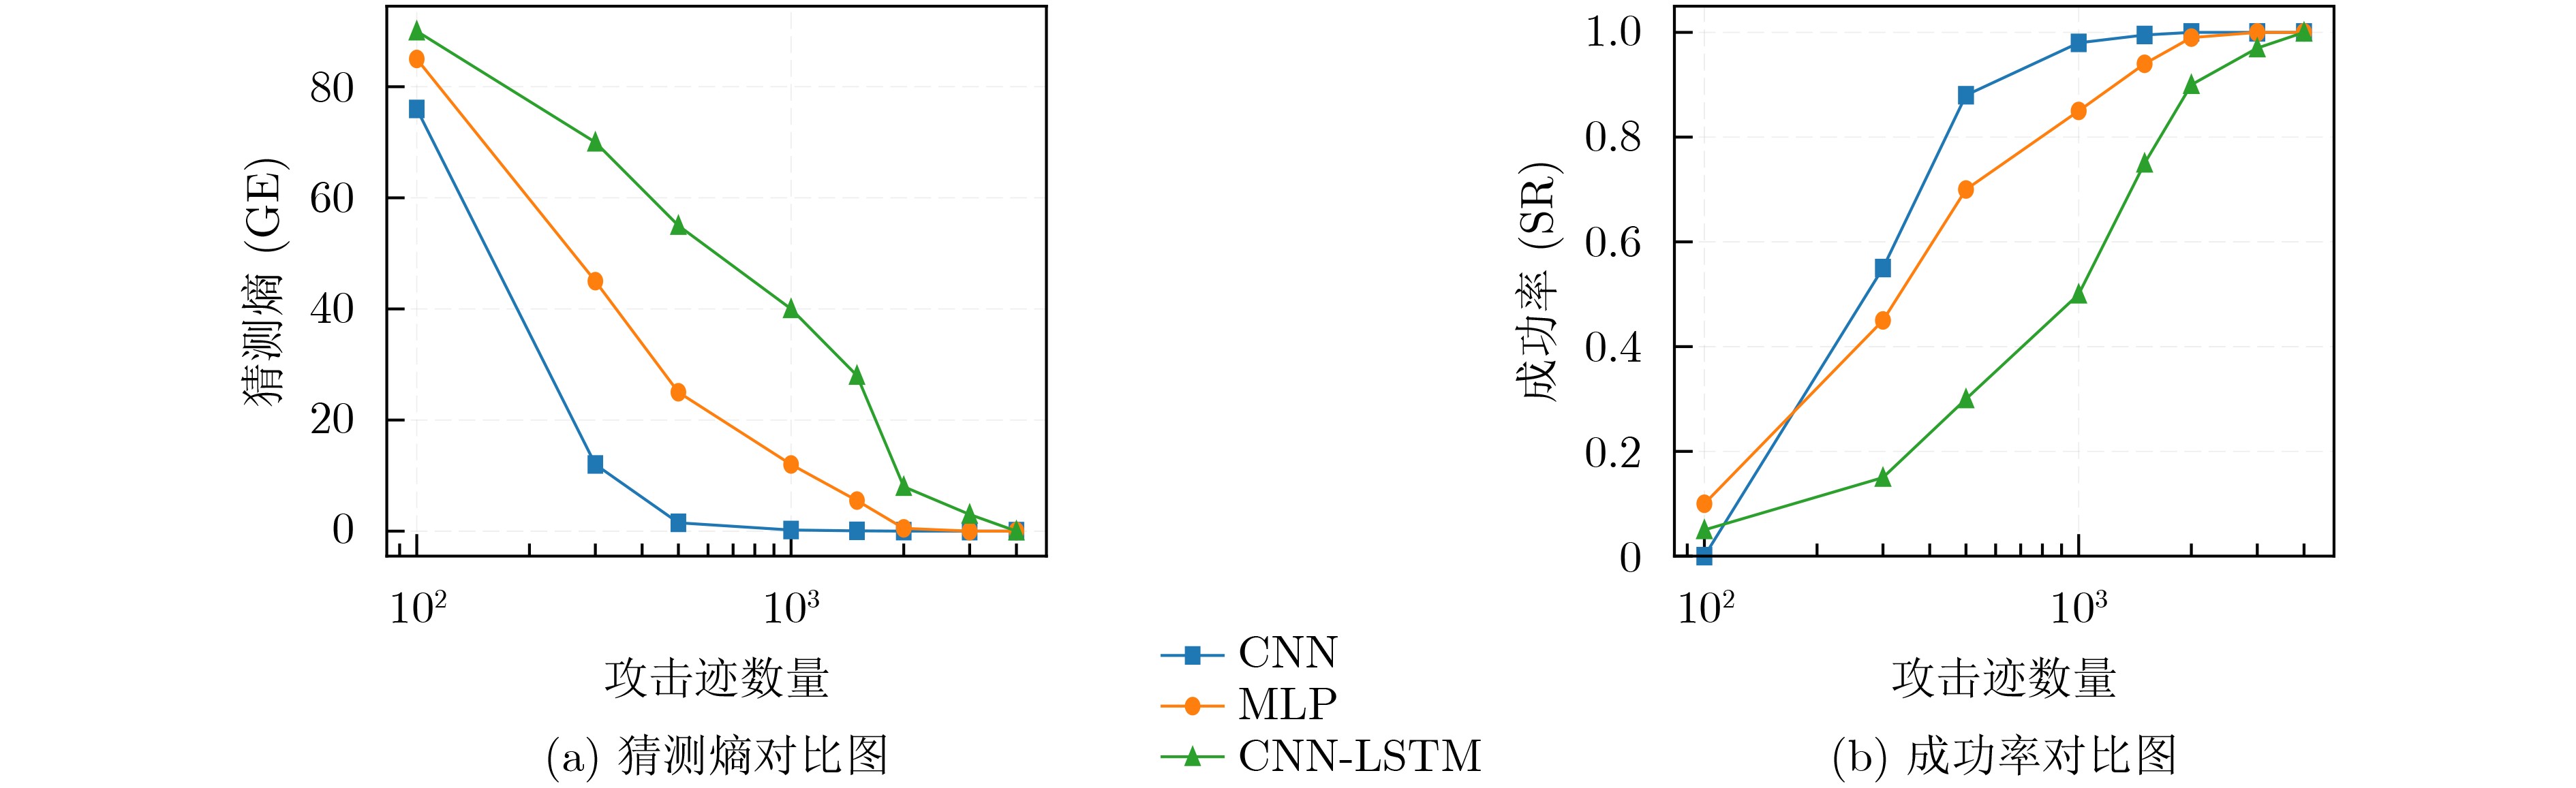
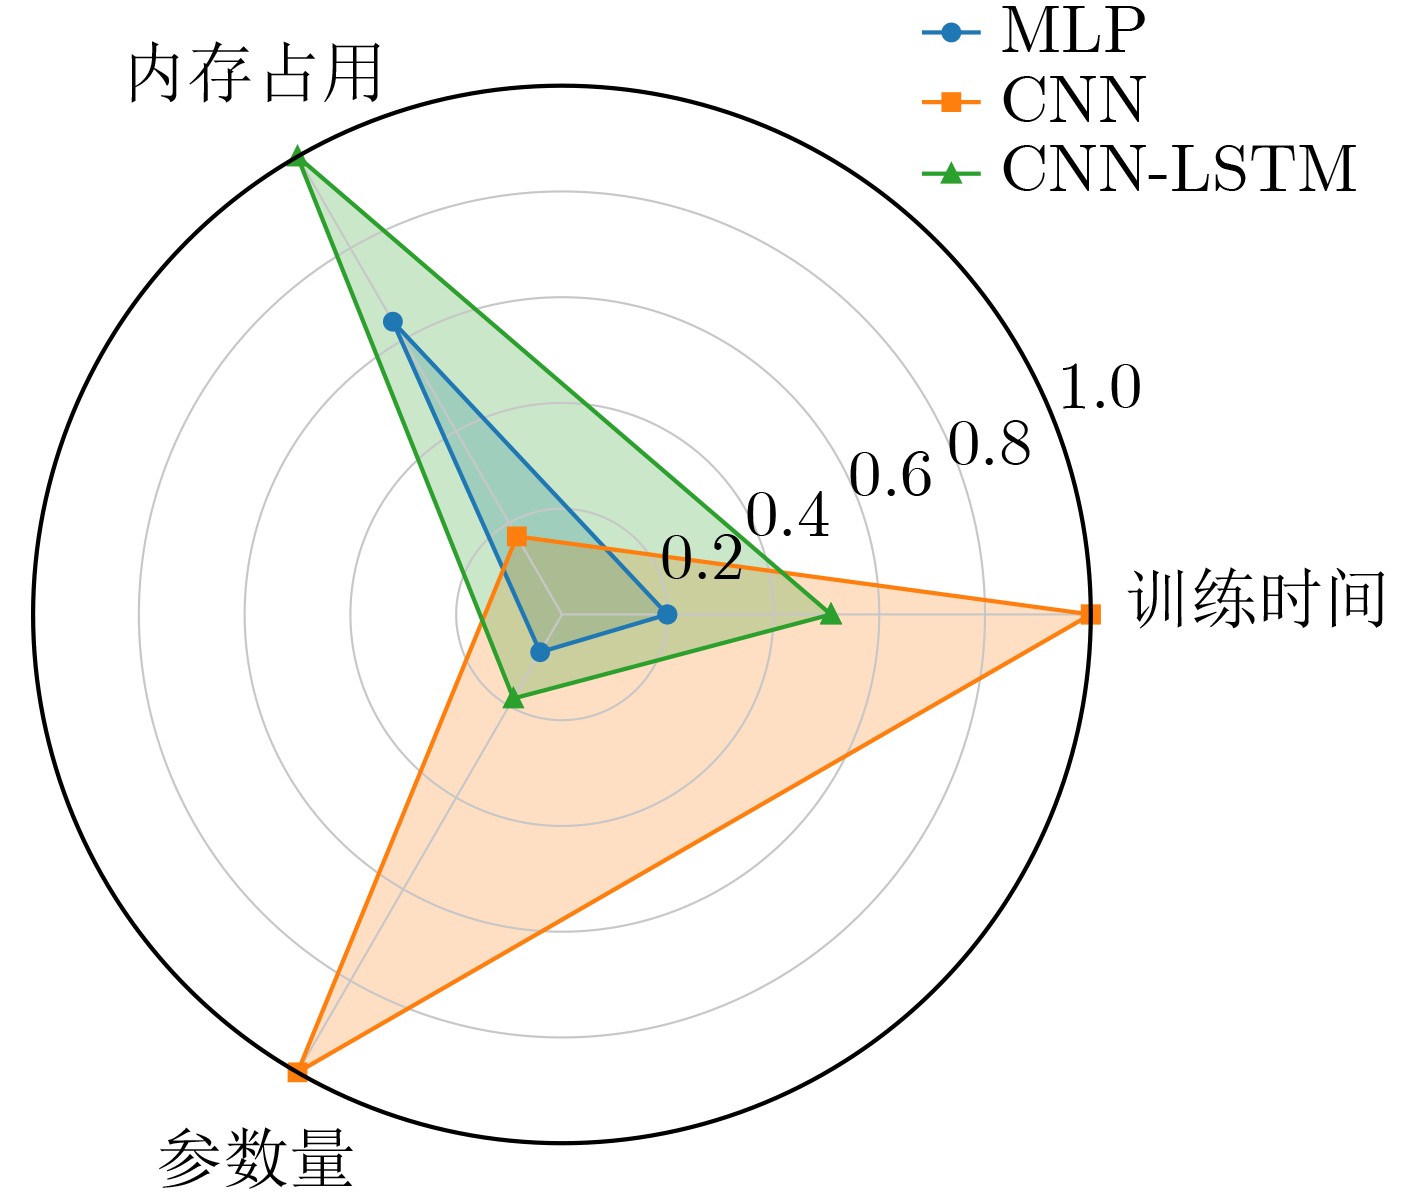
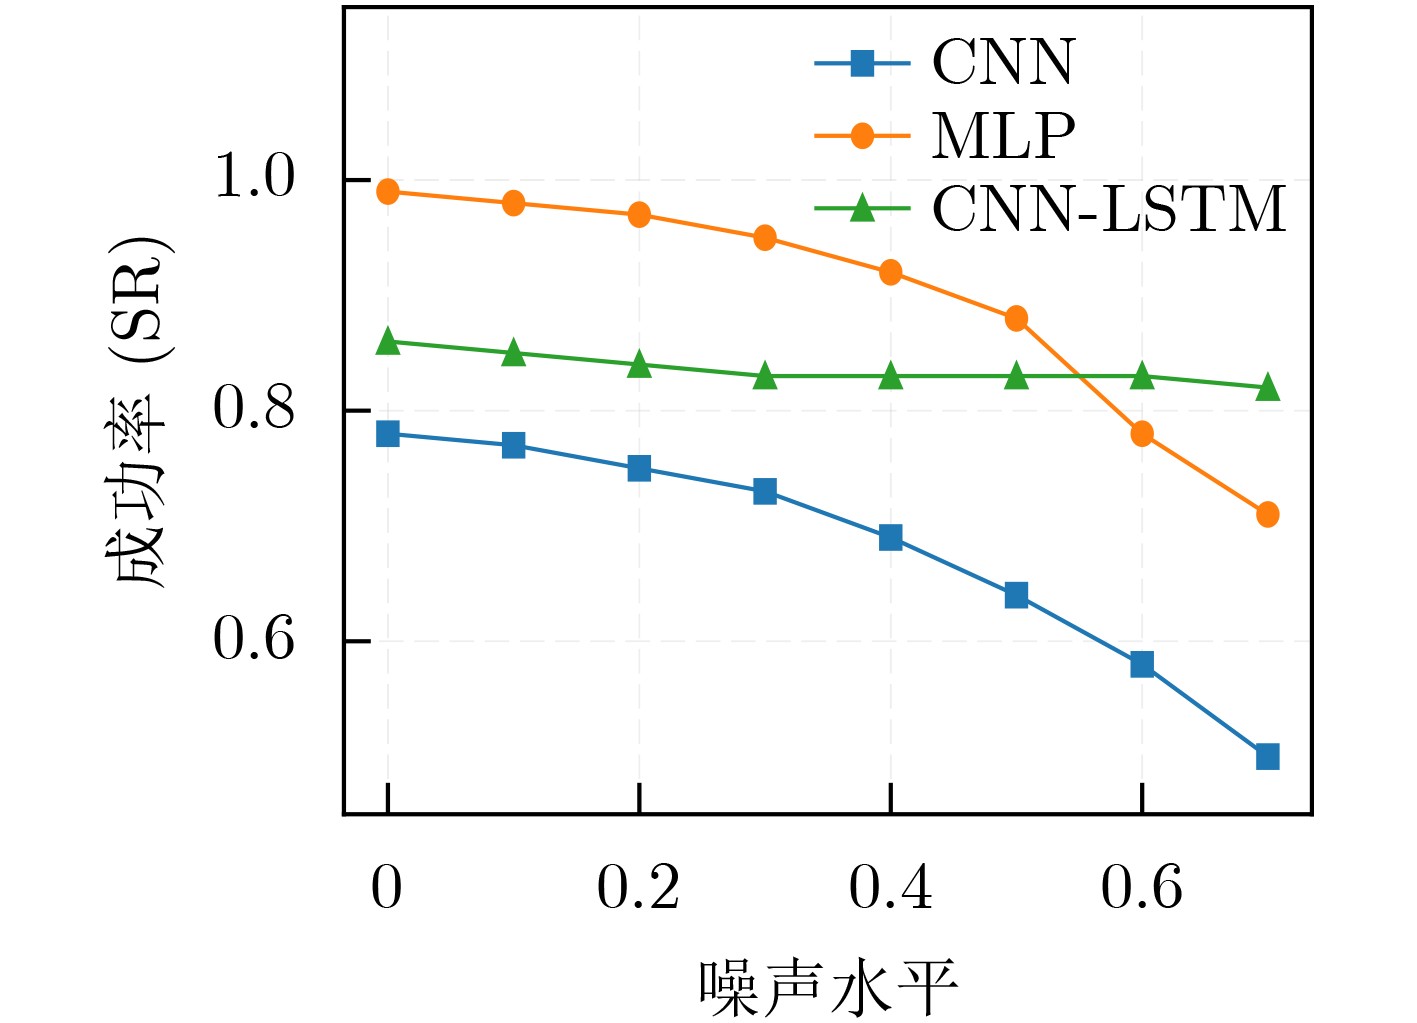
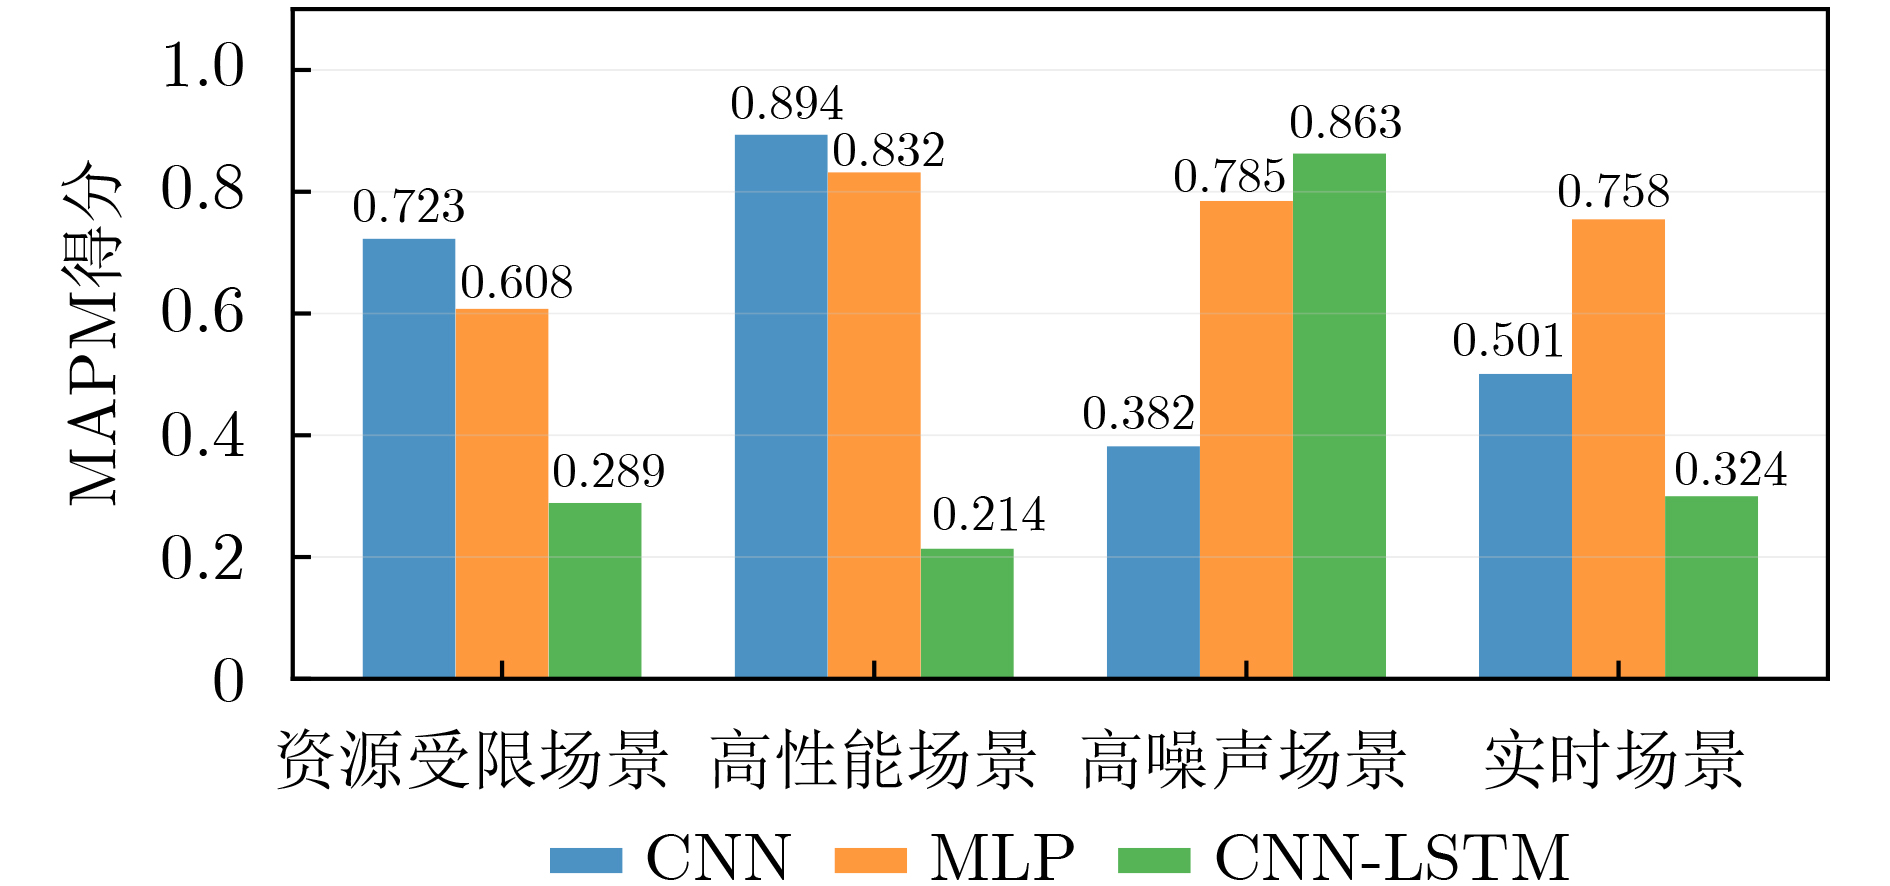
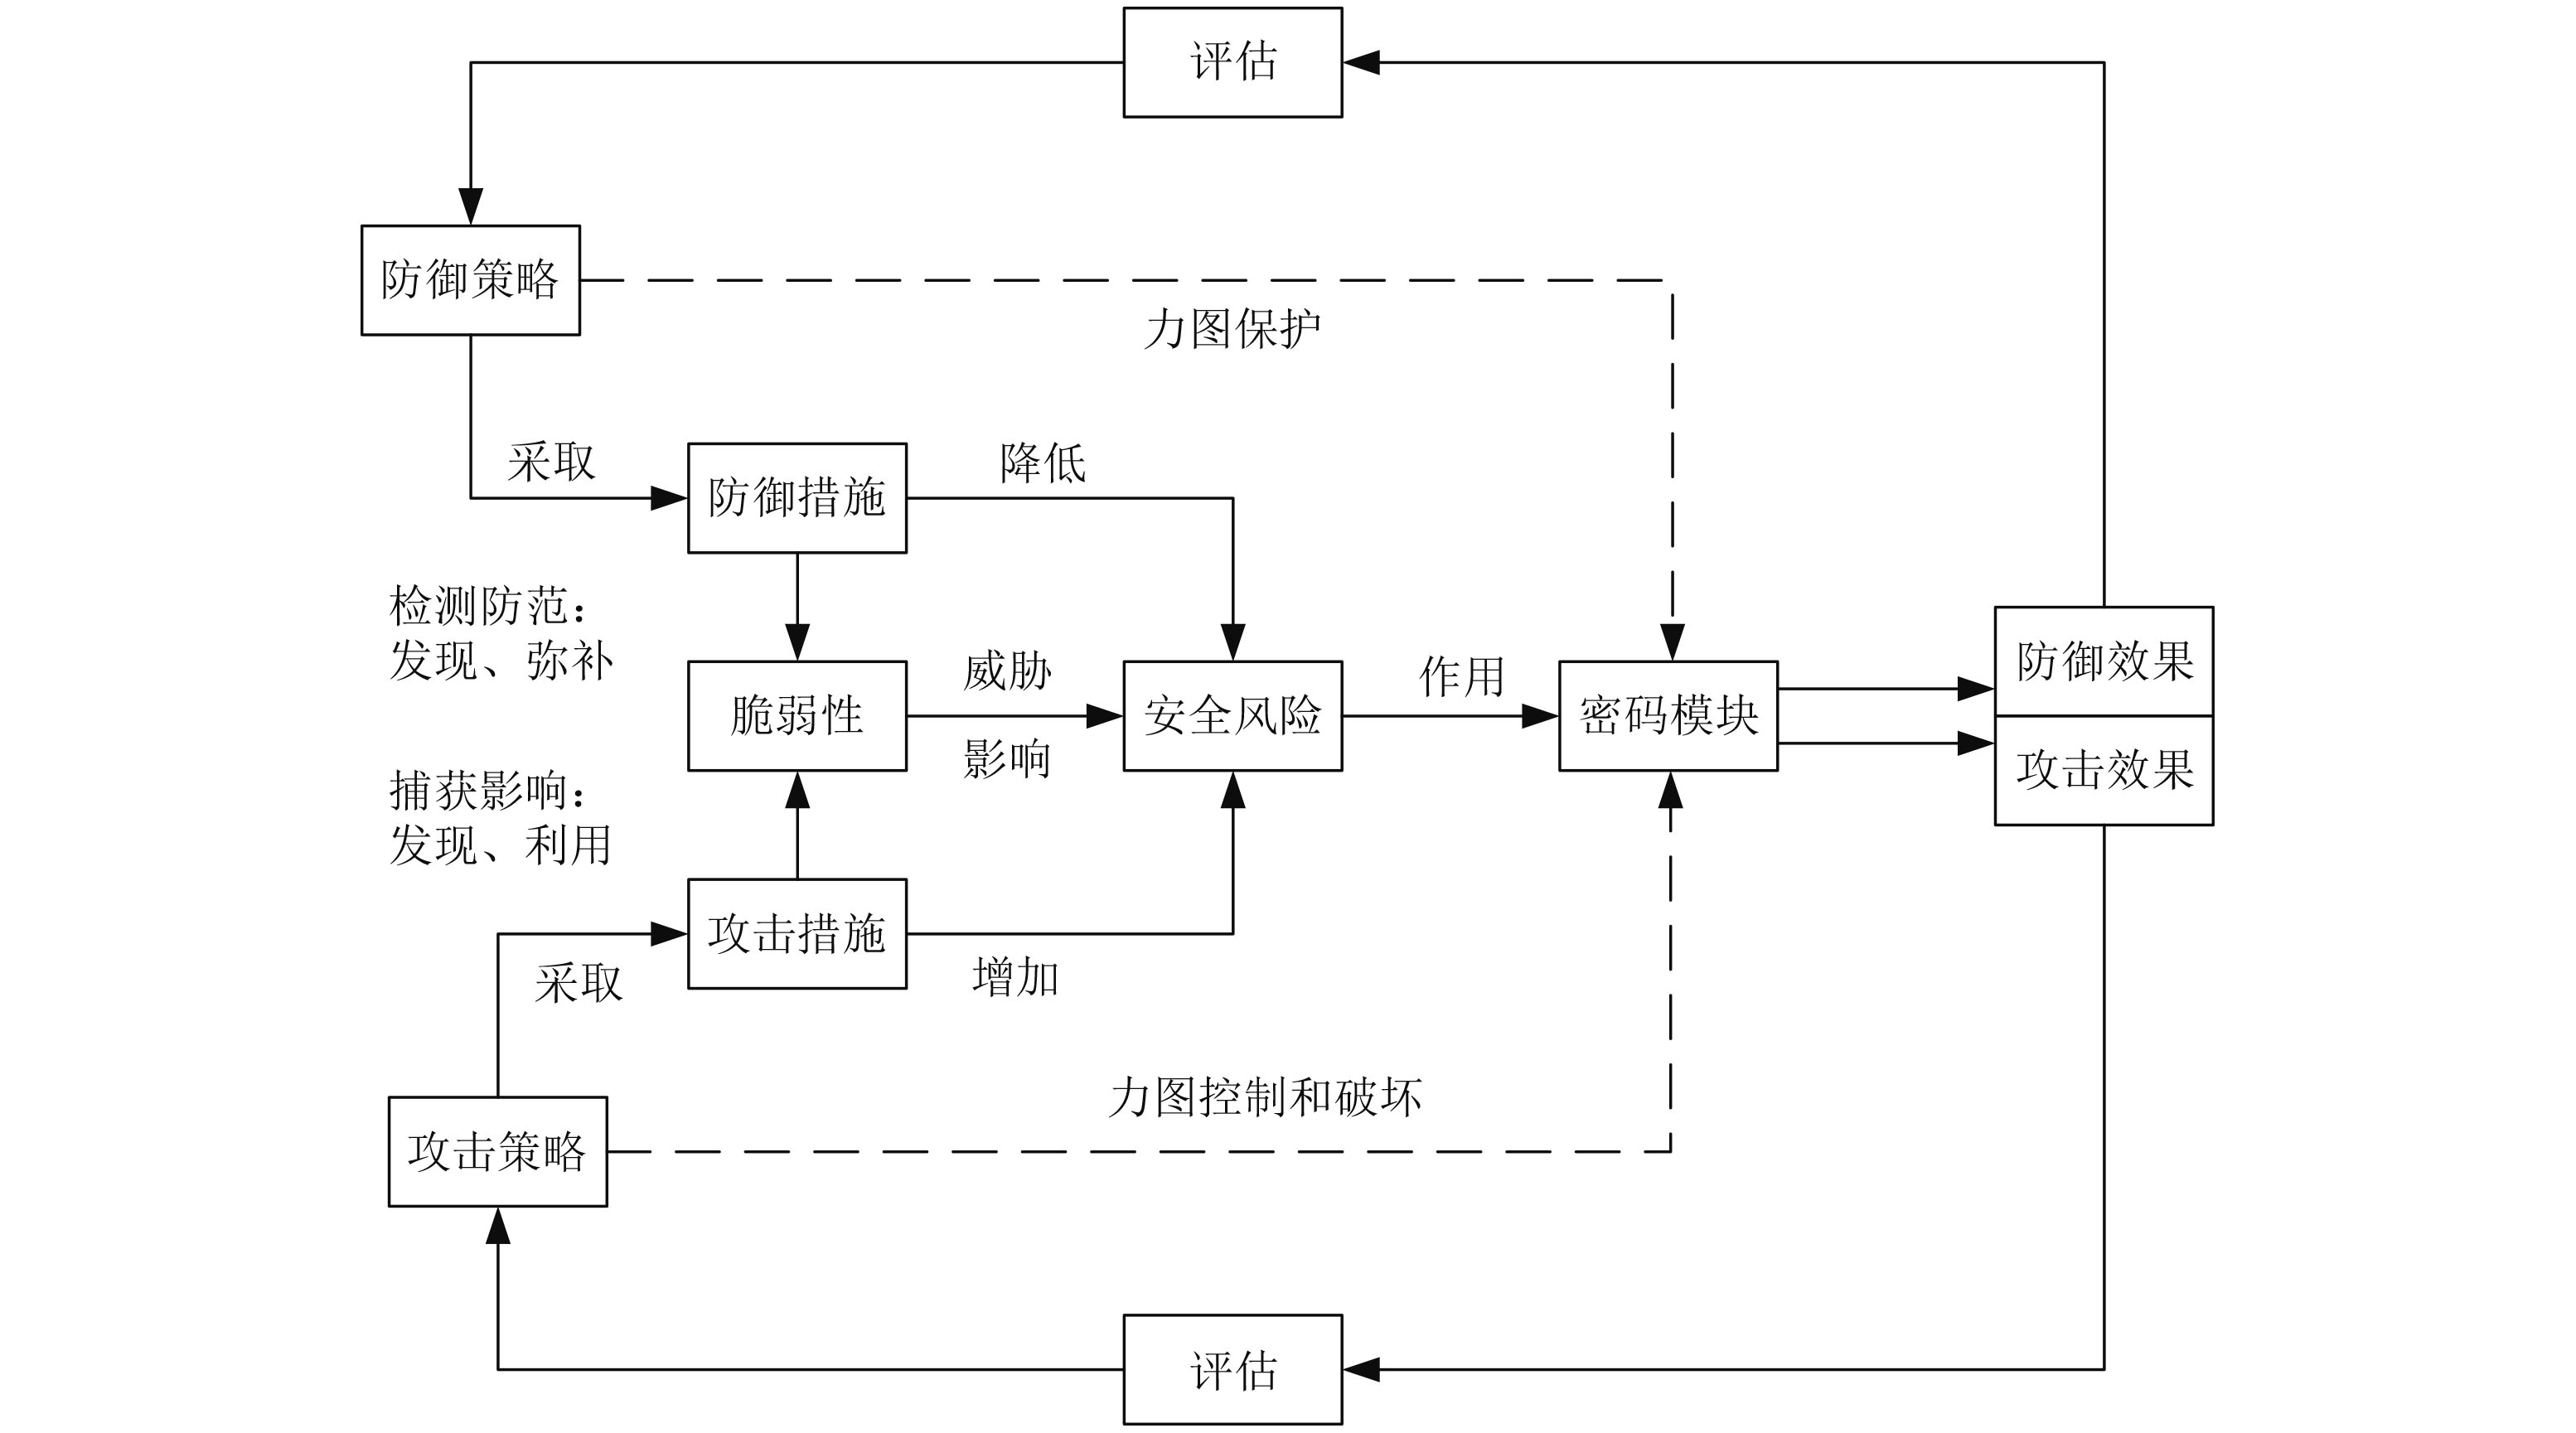
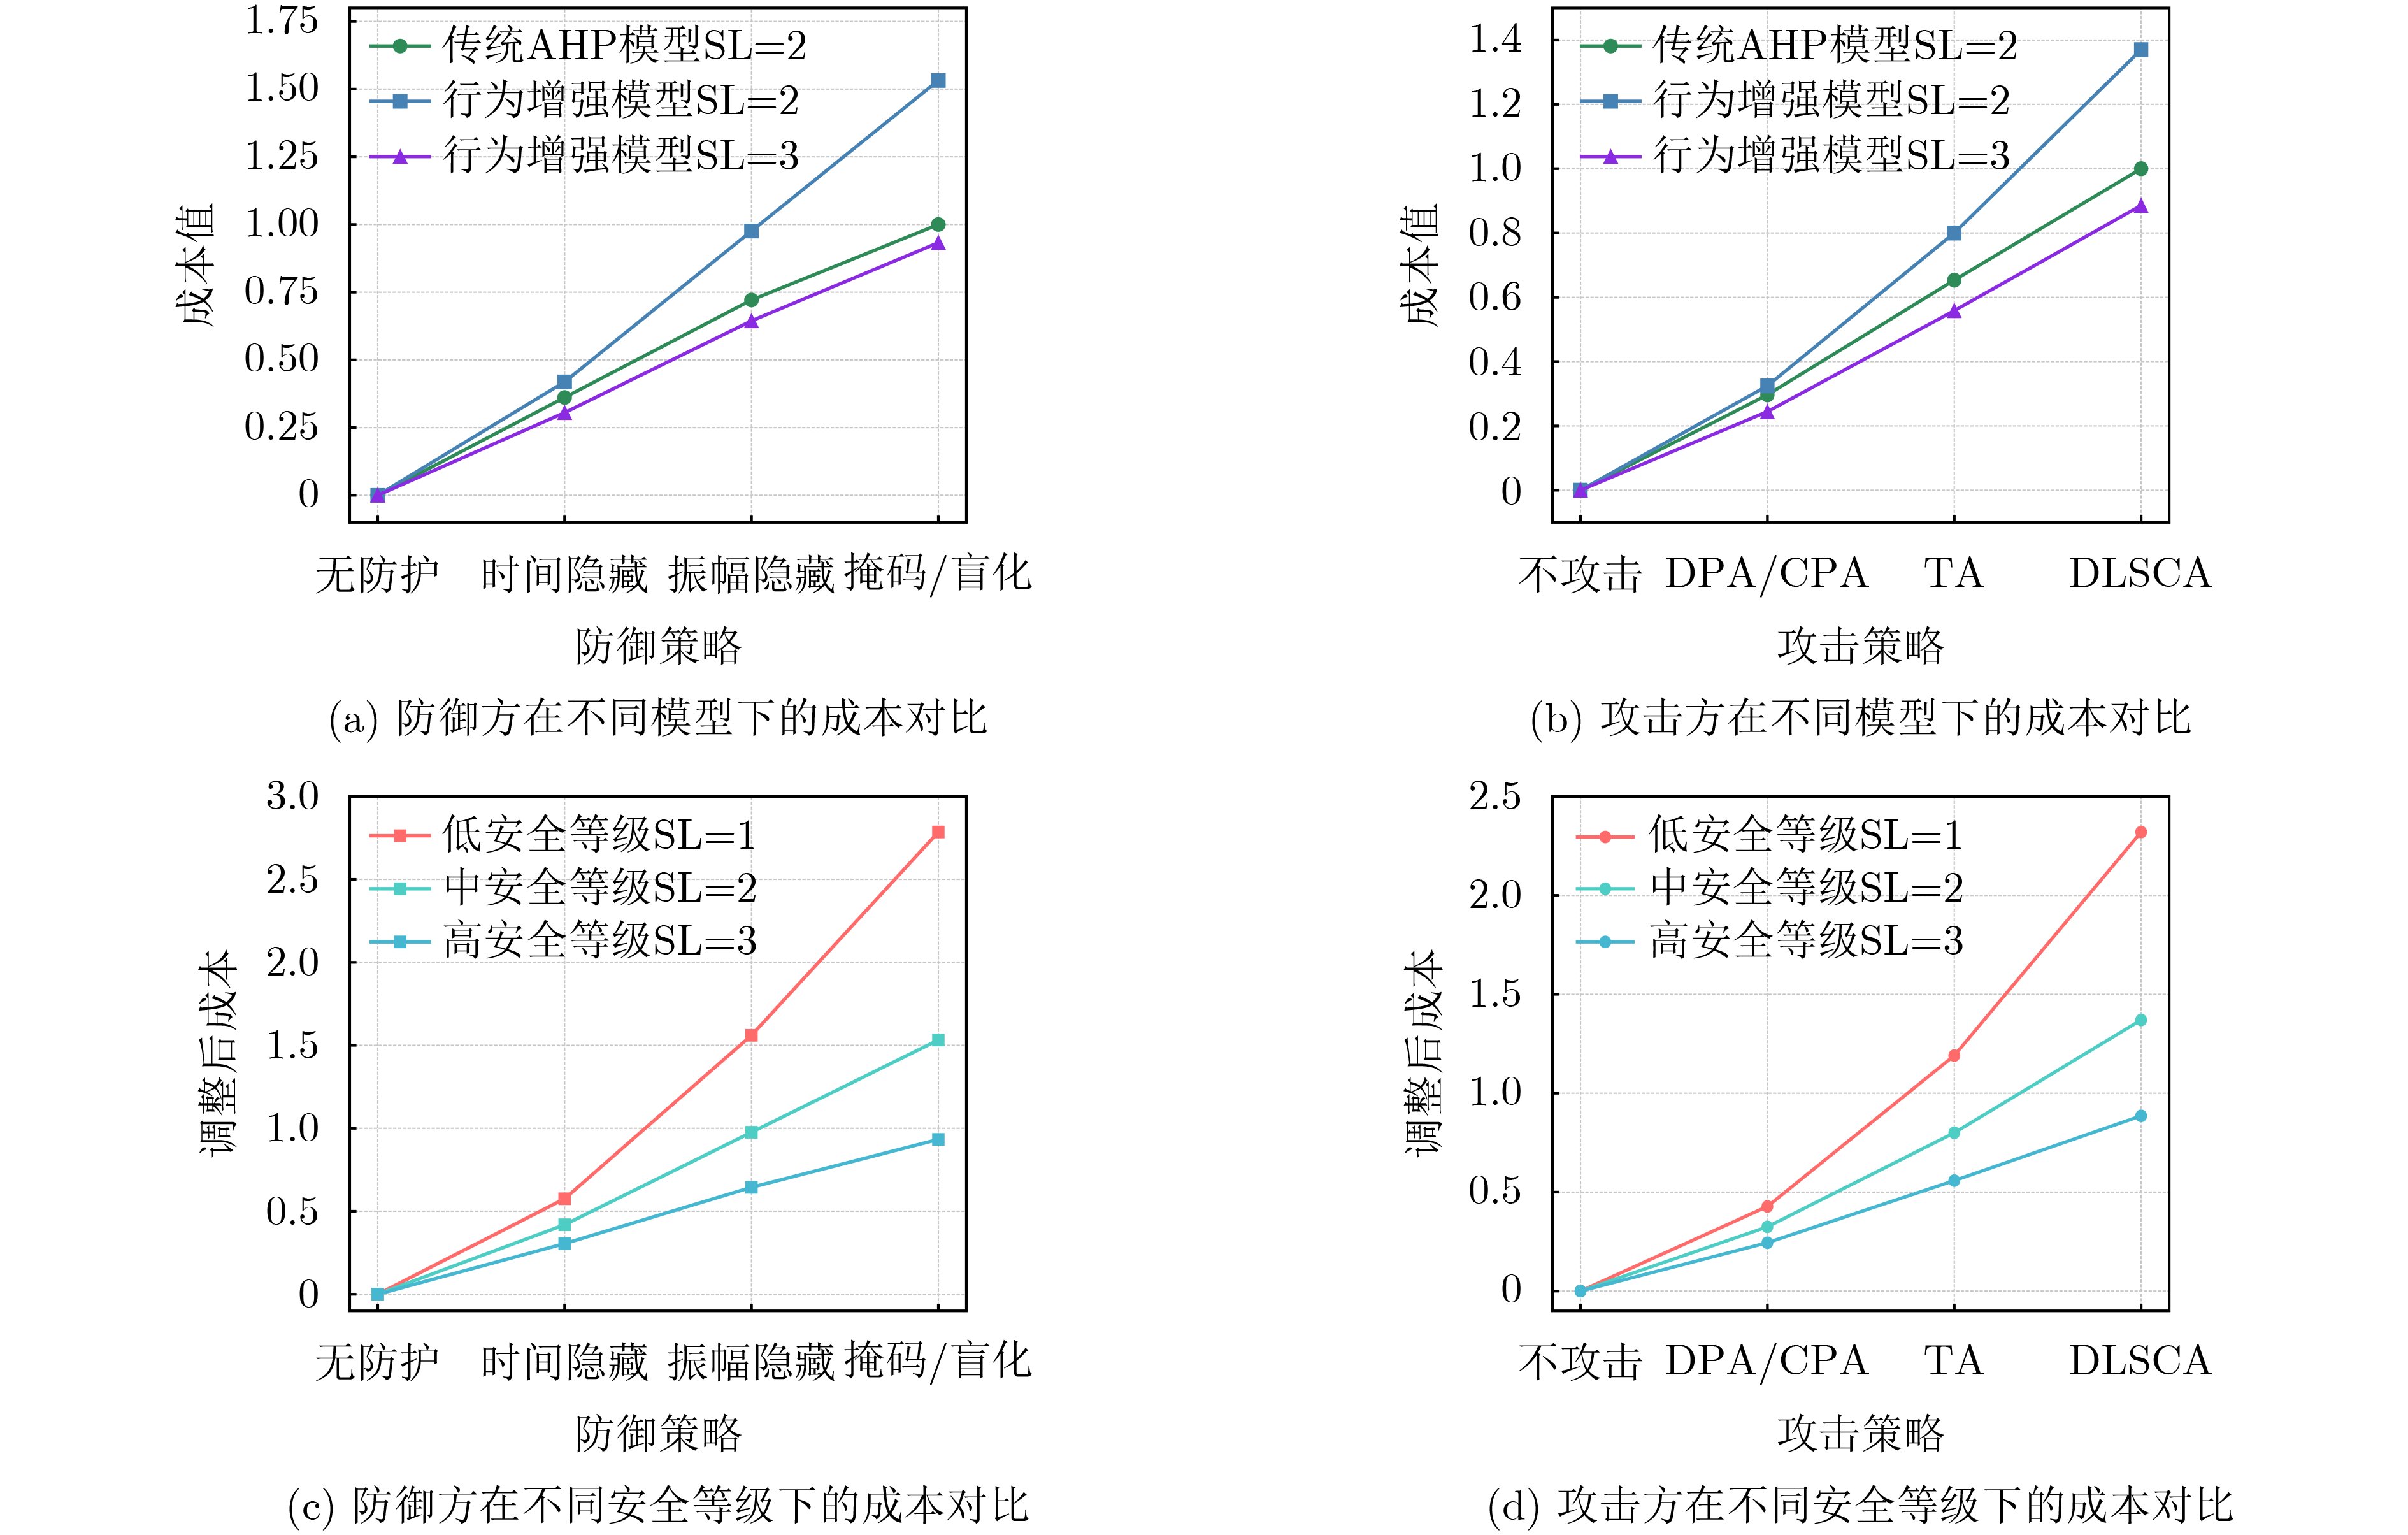
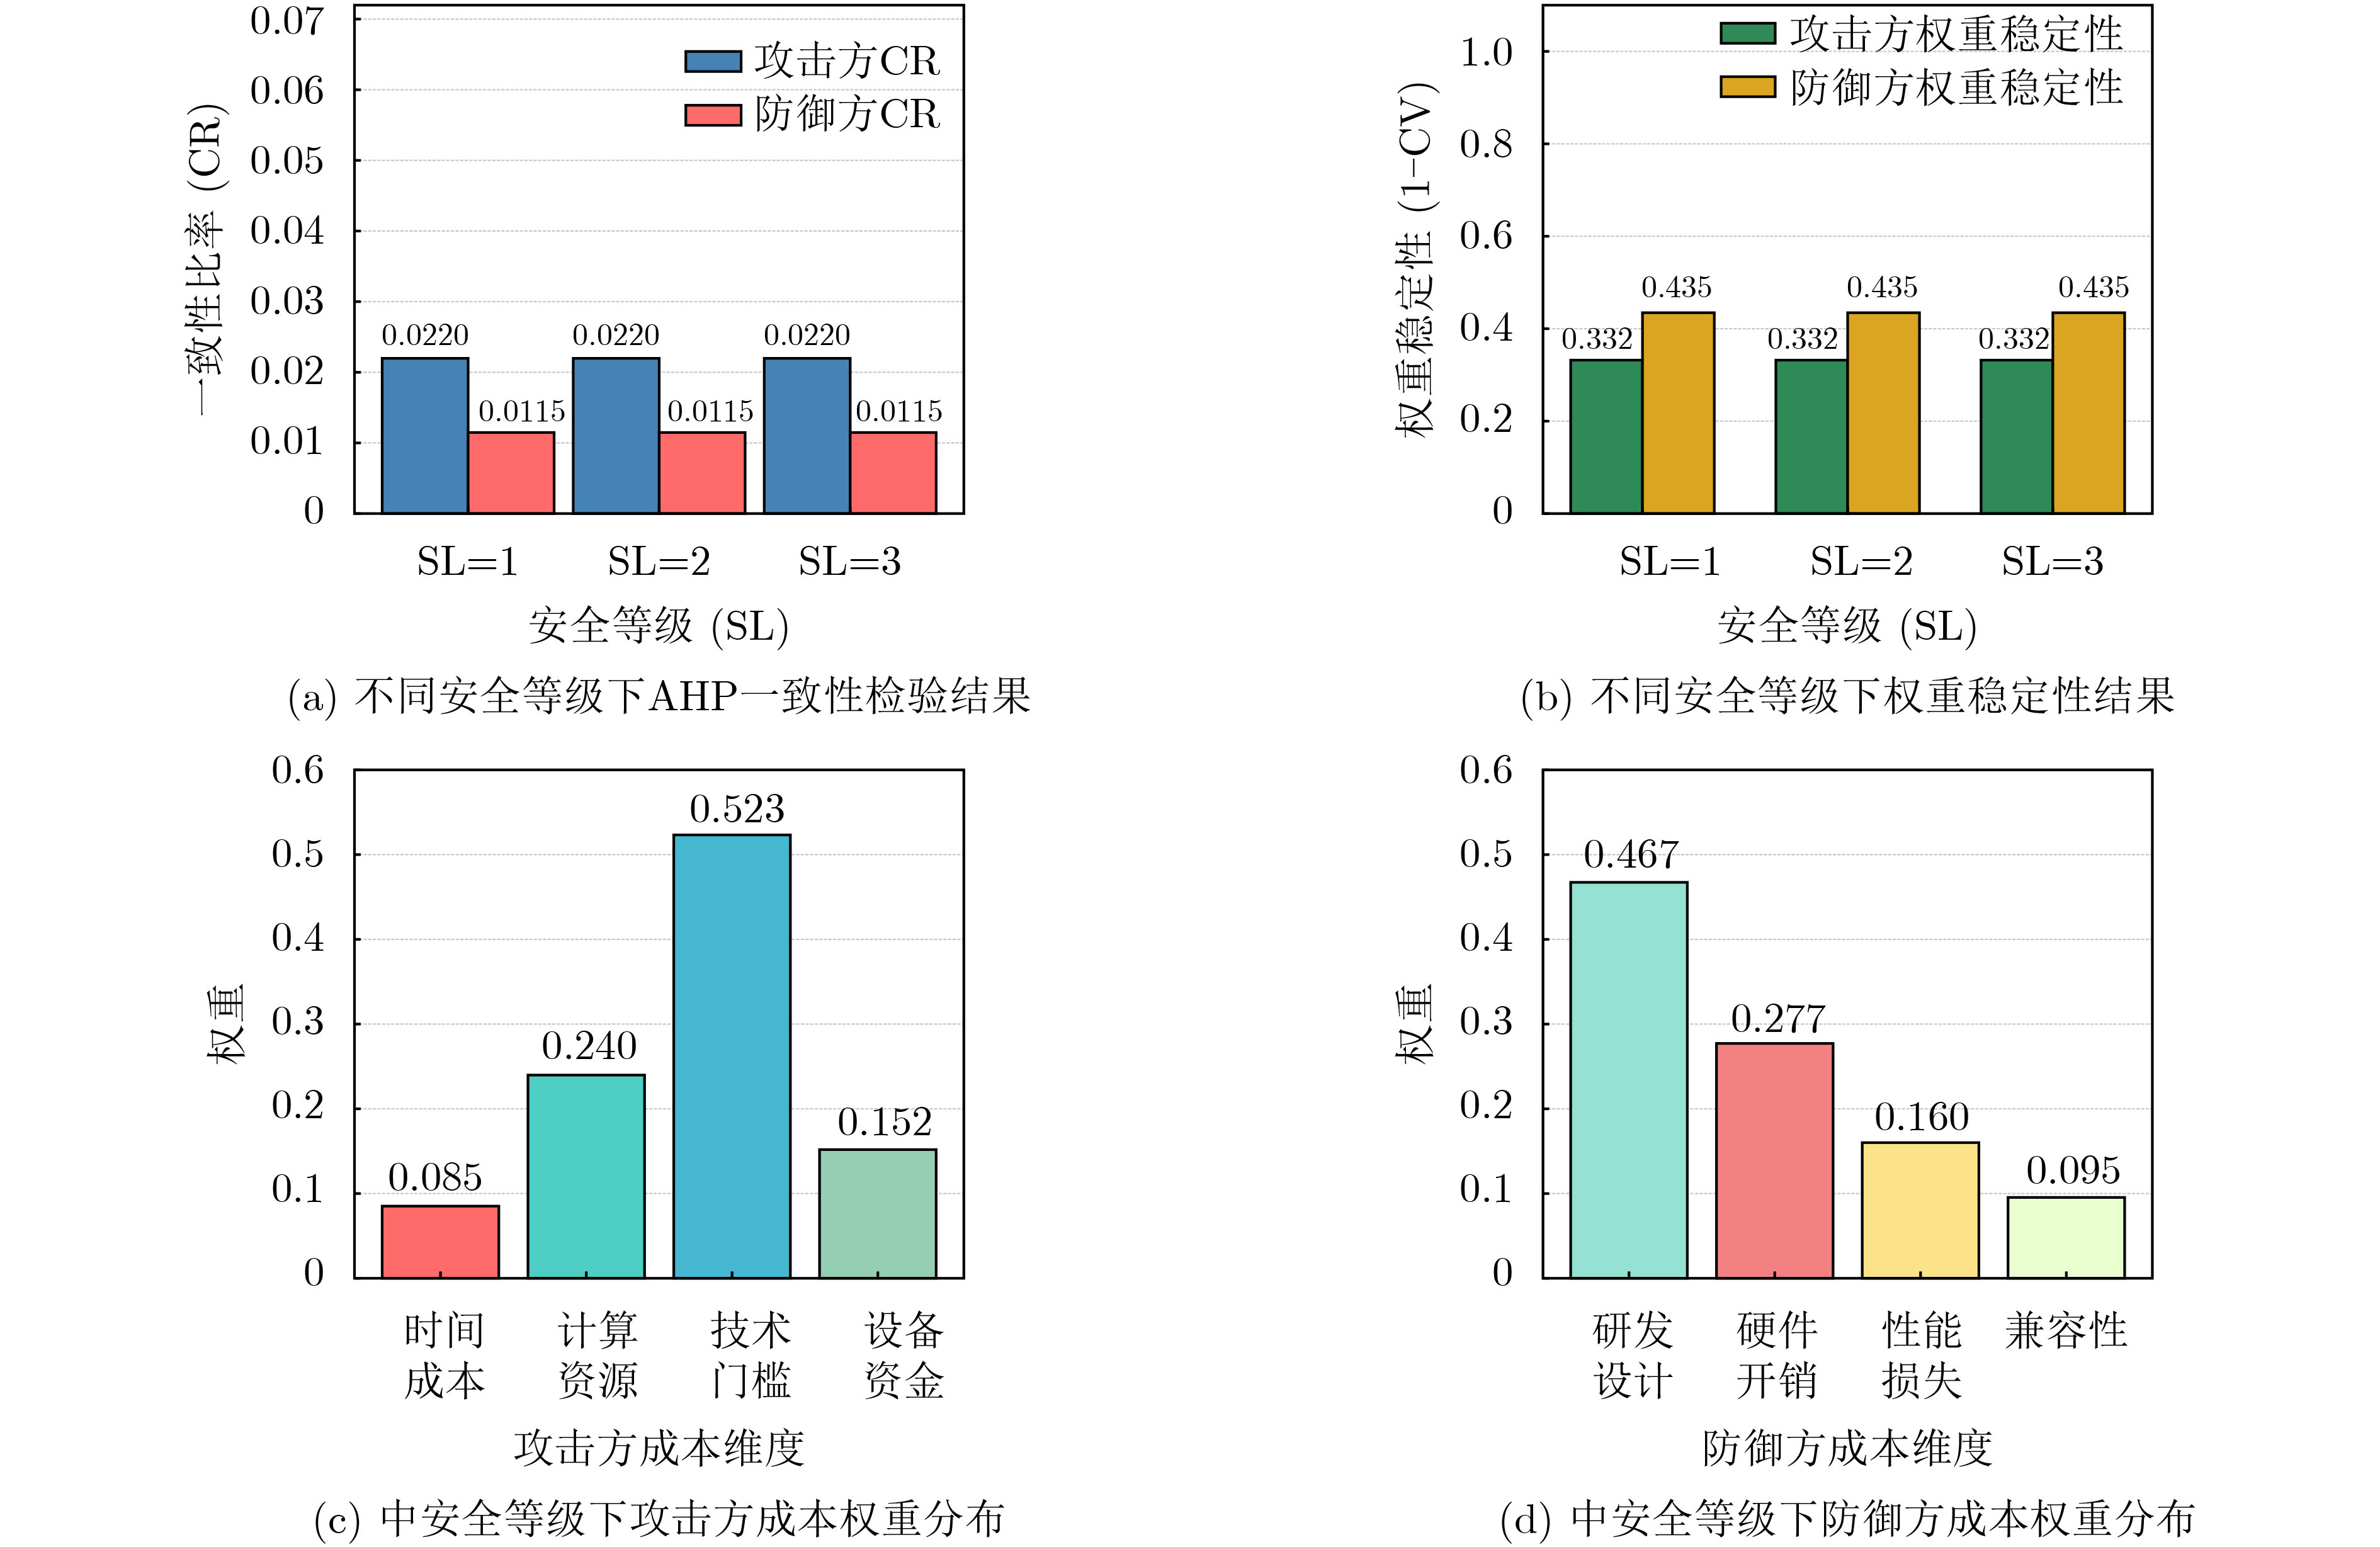
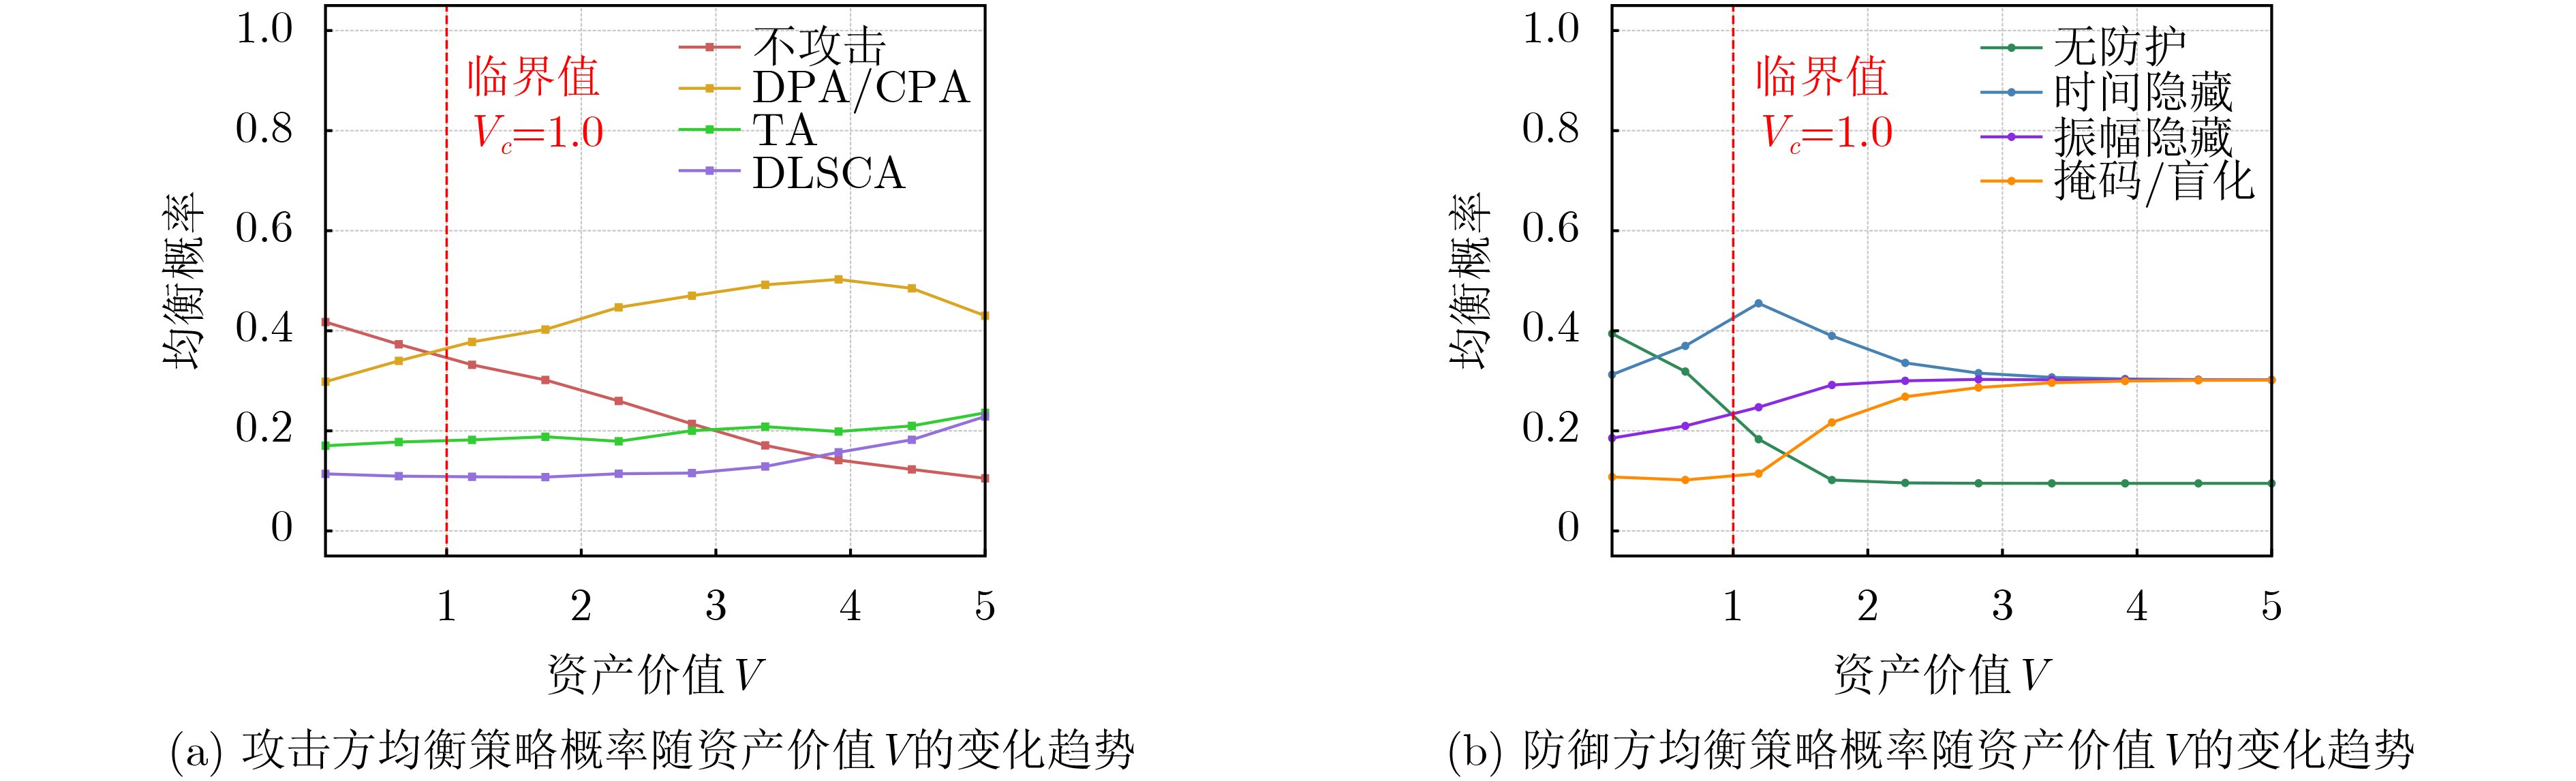
  Objective  Deep Learning Side-Channel Analysis (DL-SCA) has substantially improved the effectiveness of attacks against protected cryptographic implementations. However, the transition of DL-SCA models from research to practical deployment is limited by the lack of systematic, fair, and scenario-specific evaluation methods. Existing evaluations mainly rely on Guessing Entropy (GE) and Success Rate (SR), while overlooking practical factors such as resource overhead and environmental adaptability. Moreover, inconsistent hyperparameter optimization leads to unfair model comparisons and provides limited quantitative guidance for model selection under different deployment constraints, including resource-constrained devices, high-noise environments, and real-time applications. This paper proposes a systems engineering-based evaluation framework that enables comprehensive, quantitative, and scenario-specific assessment of DL-SCA models.  Methods  A multi-dimensional, scenario-based evaluation framework is developed using systems engineering principles. First, a hierarchical evaluation index system is established, comprising three criteria—attack effectiveness, resource overhead, and environmental adaptability—and six evaluation metrics: GE, SR, training time (TC), peak memory consumption (MC), model complexity (MoC), and noise robustness (Rob). Second, a standardized evaluation process based on the V-model is designed to ensure fair comparison. Each candidate model, including a Multi-Layer Perceptron (MLP), Convolutional Neural Network (CNN), and CNN-LSTM hybrid model, undergoes independent hyperparameter optimization using grid search before multi-dimensional performance evaluation. Third, a hybrid Criteria Importance Through Intercriteria Correlation-Analytic Hierarchy Process (CRITIC-AHP) Multi-Attribute Decision-Making (MADM) framework is developed. The CRITIC method derives objective weights from the statistical characteristics of the evaluation data, whereas the AHP method incorporates scenario-specific preferences through pairwise comparison matrices. The objective and subjective weights are fused to generate scenario-specific weights. Finally, a Multi-dimensional Attack Performance Metric (MAPM) is defined as the weighted sum of normalized evaluation metrics using the fused weights, providing a composite score for each model under a specific deployment scenario.  Results and Discussions  The proposed framework is validated using the ASCAD fixed-key dataset. After independent hyperparameter optimization, the three model architectures are evaluated using all six metrics. The CRITIC method produces the objective weight vector W critic = [0.17, 0.19, 0.15, 0.21, 0.14, 0.14]. Four representative deployment scenarios—Resource-Constrained, High-Performance, High-Noise, and Real-Time—are then defined, and the corresponding AHP preference weights are fused with the objective weights to generate the final scenario-specific weights. For example, MC receives the highest weight (0.52) in the Resource-Constrained scenario, whereas Rob dominates the High-Noise scenario with a weight of 0.57. The resulting MAPM scores (Table 9, Fig. 9) clearly differentiate the strengths of the evaluated models and demonstrate the scenario-specific decision capability of the proposed framework. CNN achieves the highest score in the High-Performance scenario (0.894), MLP ranks first in the Real-Time scenario (0.758) because of its shortest training time, and the CNN-LSTM hybrid model performs best in the High-Noise scenario (0.863) because of its superior noise robustness despite higher resource overhead. These results demonstrate that no single model is optimal across all deployment scenarios and that MAPM provides a clear and quantitative basis for model selection under specific deployment constraints.  Conclusions  This paper proposes a systems engineering-based, multi-dimensional evaluation framework to address the major limitations of current DL-SCA model assessment. By integrating a hierarchical evaluation index system, a standardized V-model evaluation process, and a hybrid CRITIC-AHP Multi-Attribute Decision-Making (MADM) framework, the proposed method quantitatively balances the trade-offs among attack effectiveness, resource overhead, and environmental adaptability. Experimental results obtained using the ASCAD benchmark demonstrate that the framework provides clear, quantitative, and scenario-specific guidance for model selection. The proposed Multi-dimensional Attack Performance Metric (MAPM) provides a practical decision basis for selecting DL-SCA models under diverse deployment constraints, narrowing the gap between academic attack development and practical model deployment. Future work will extend the framework to additional model architectures and datasets, improve evaluation automation, and validate its effectiveness in practical deployment environments.
Intelligent Resource Allocation Algorithm Based on Outdated CSI for Multi-Node URLLC
ZHAO Yizhen, GAO Wei, HU Yulin, ZHU Yao
2026, 48(9): 3811-3821. doi: 10.11999/JEIT260216
Abstract:
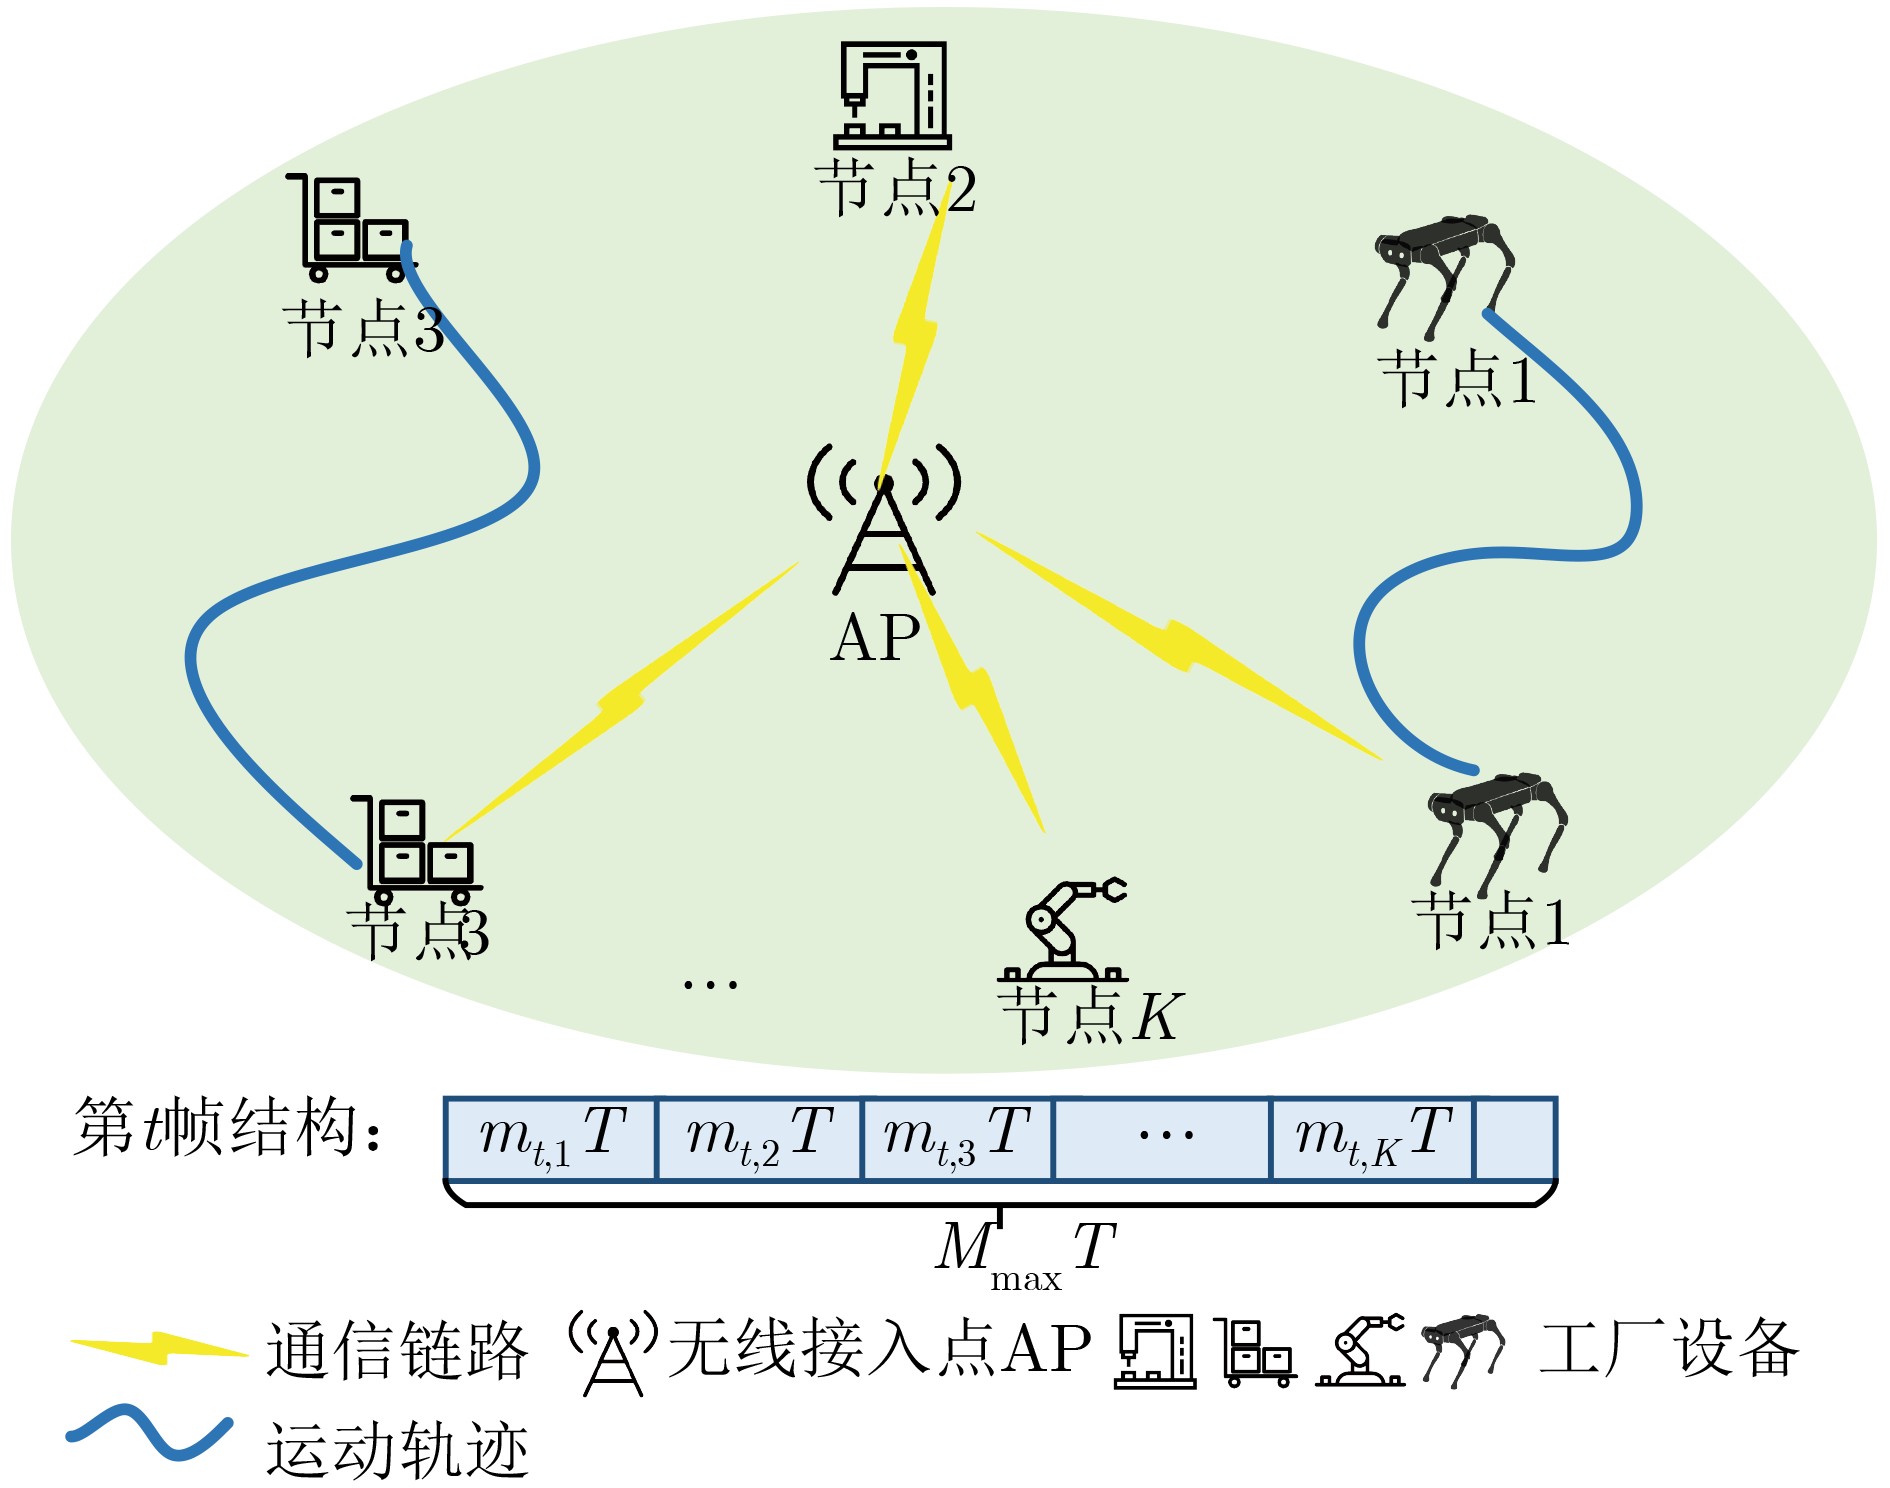
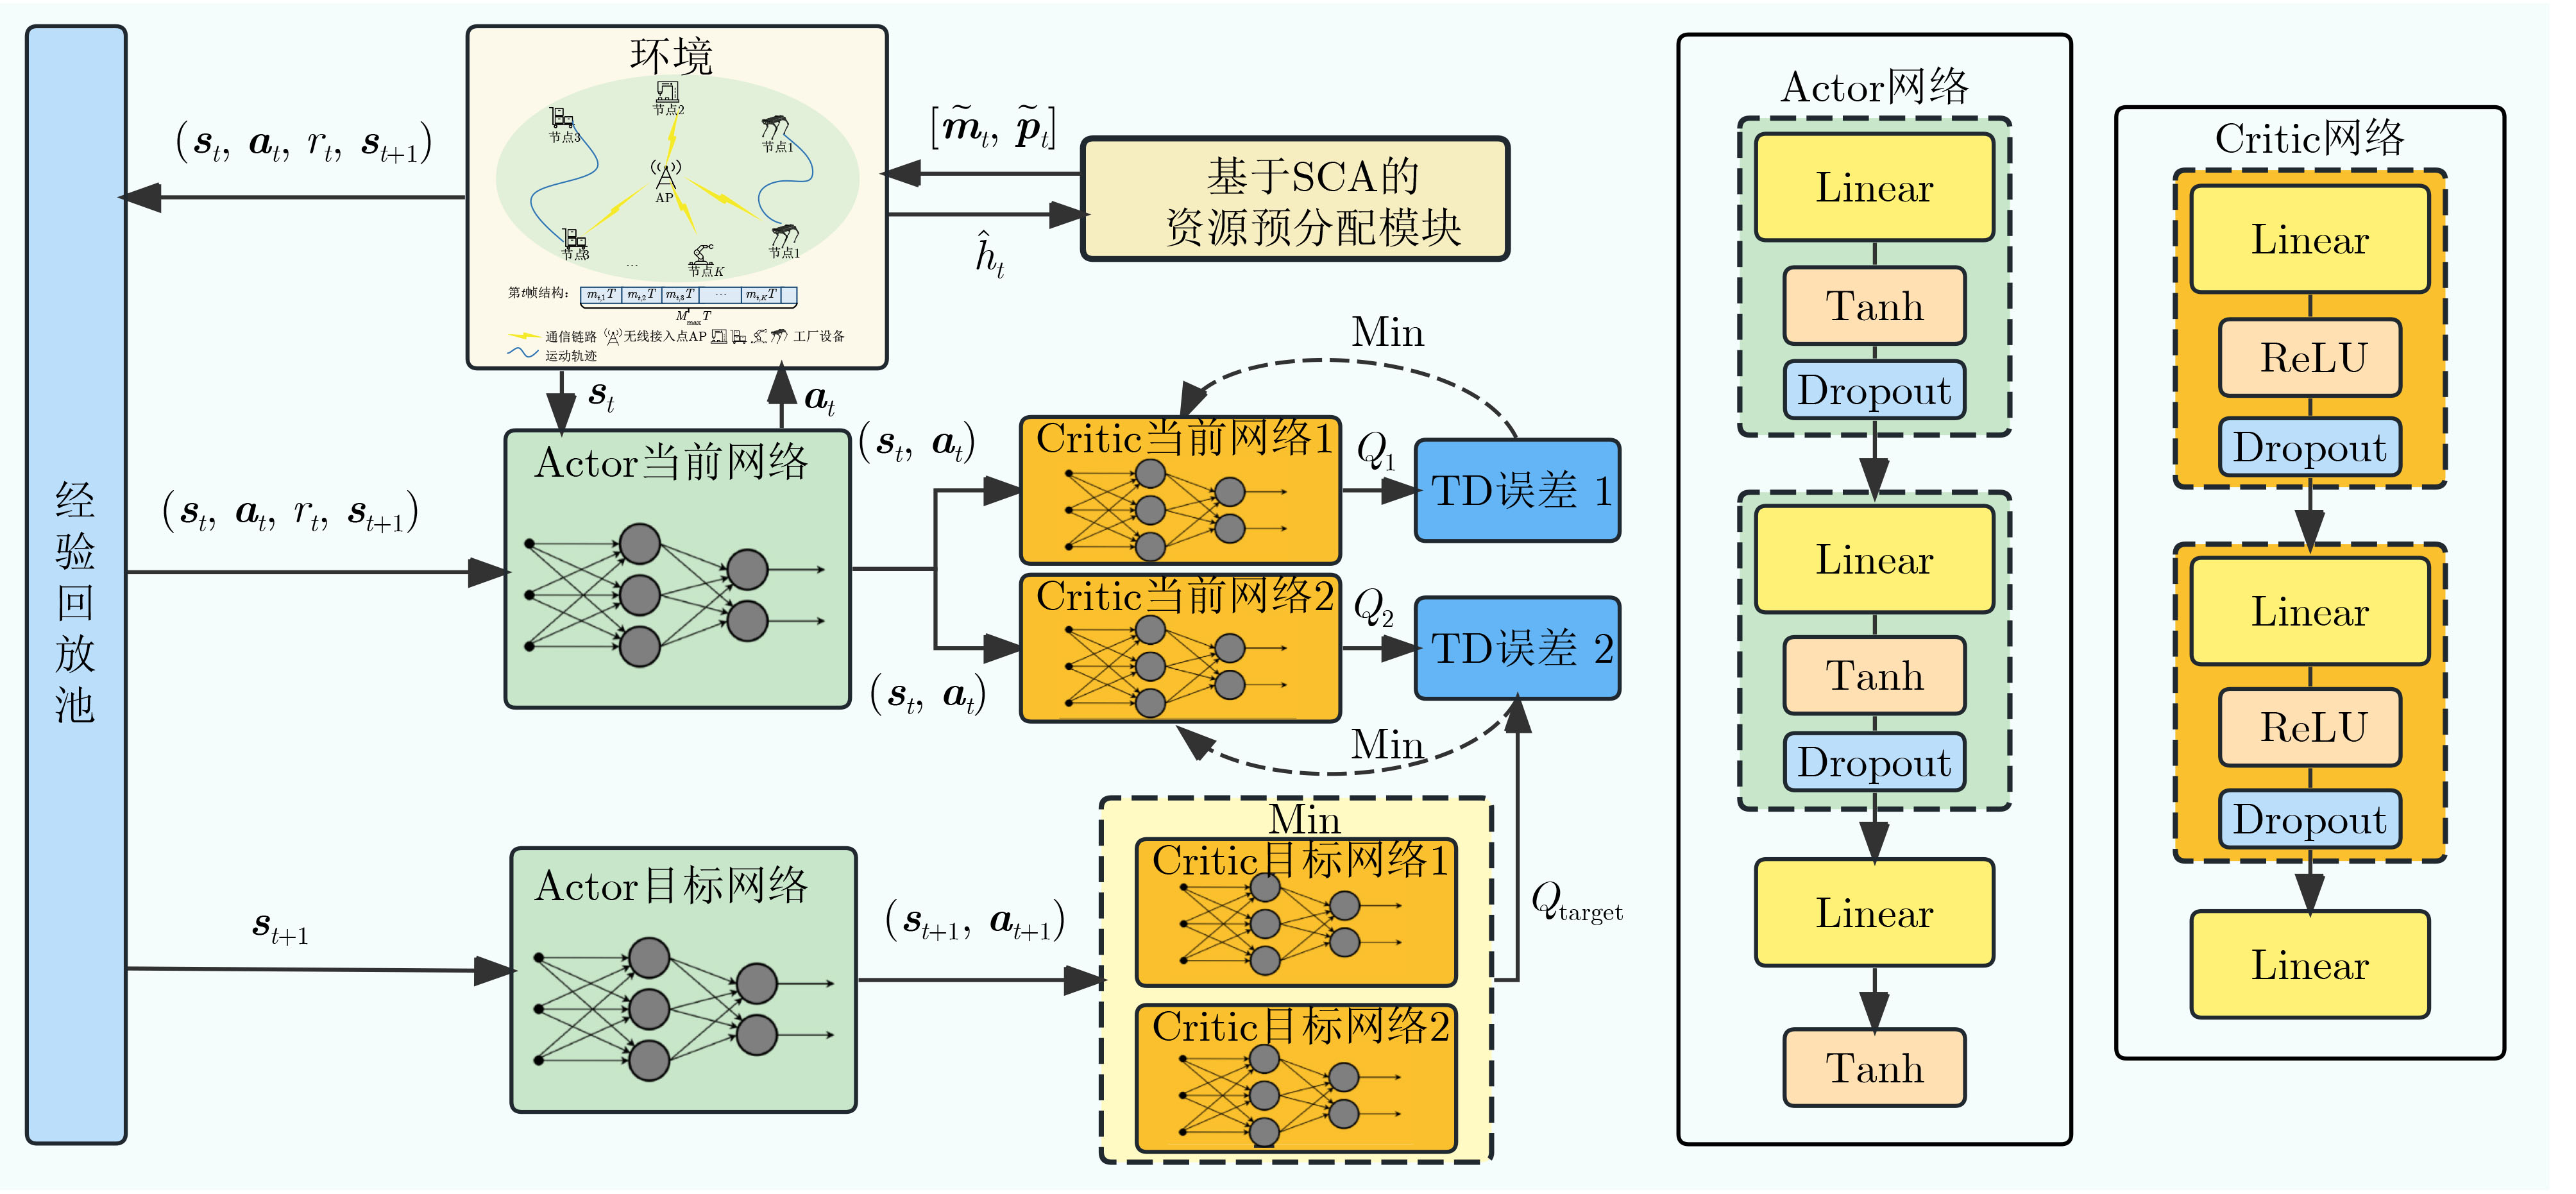
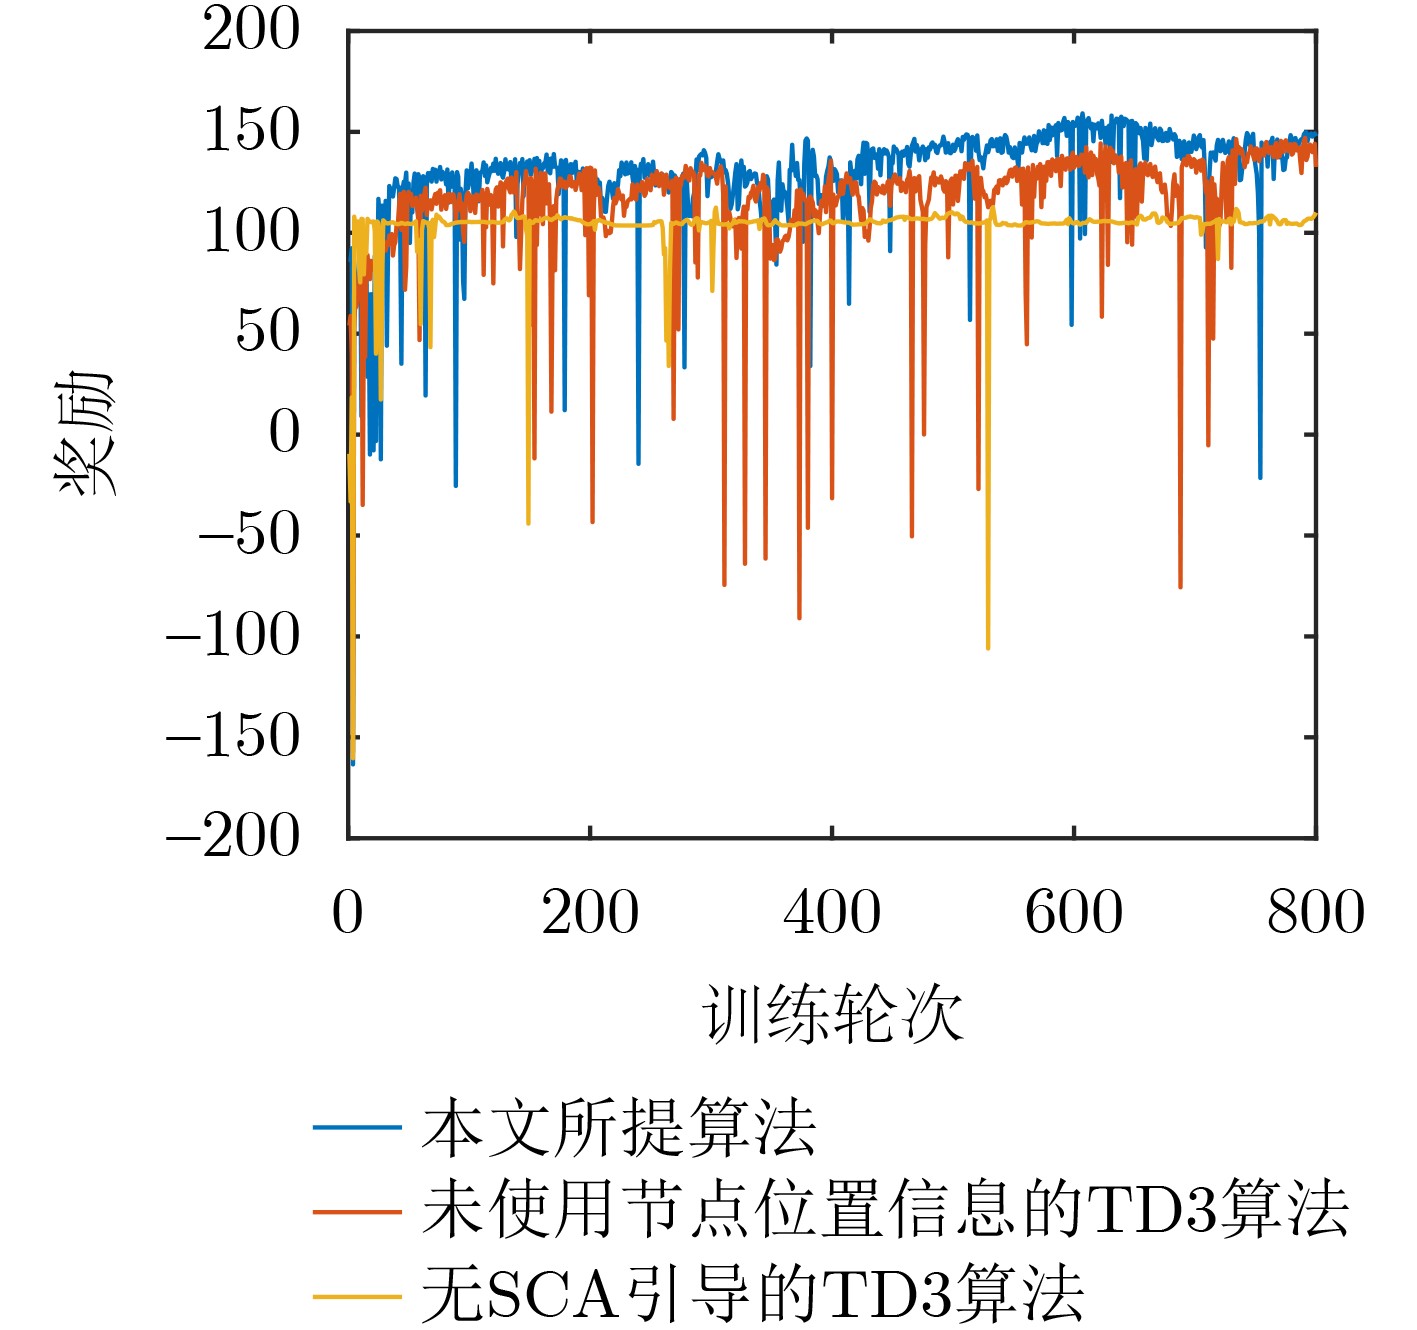
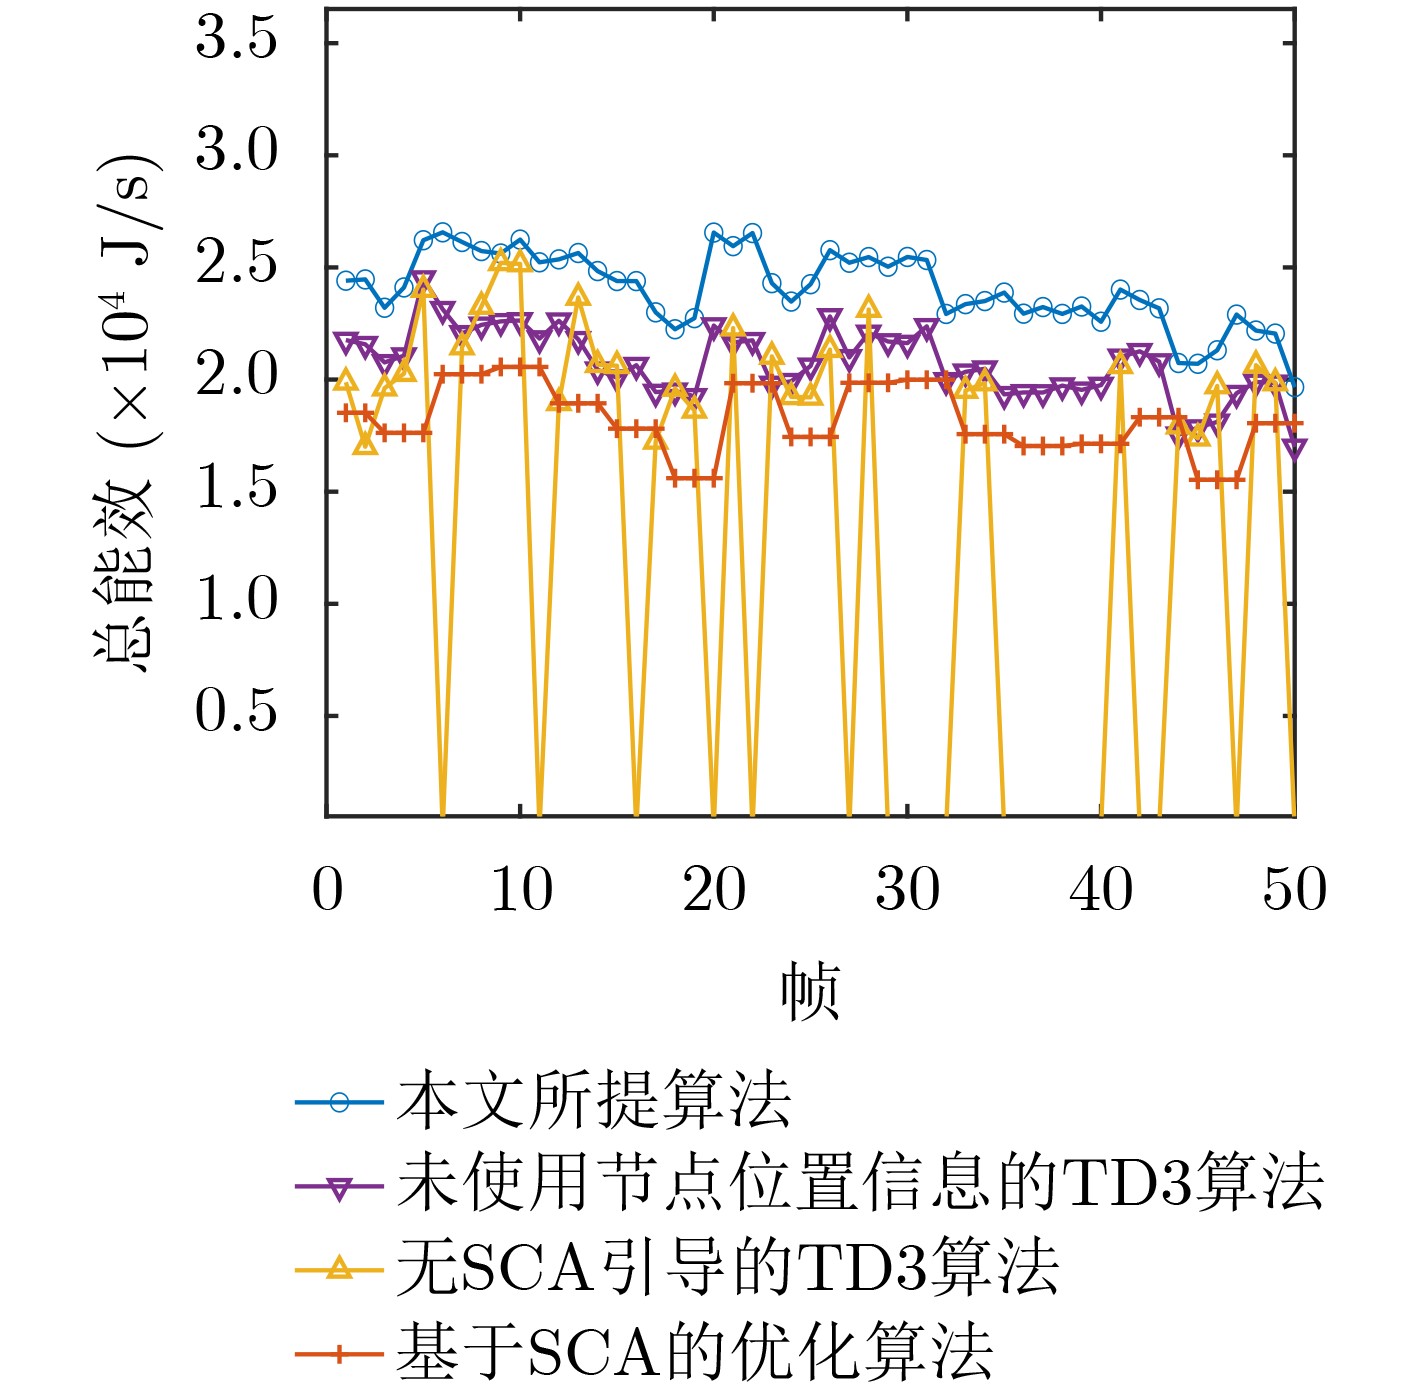
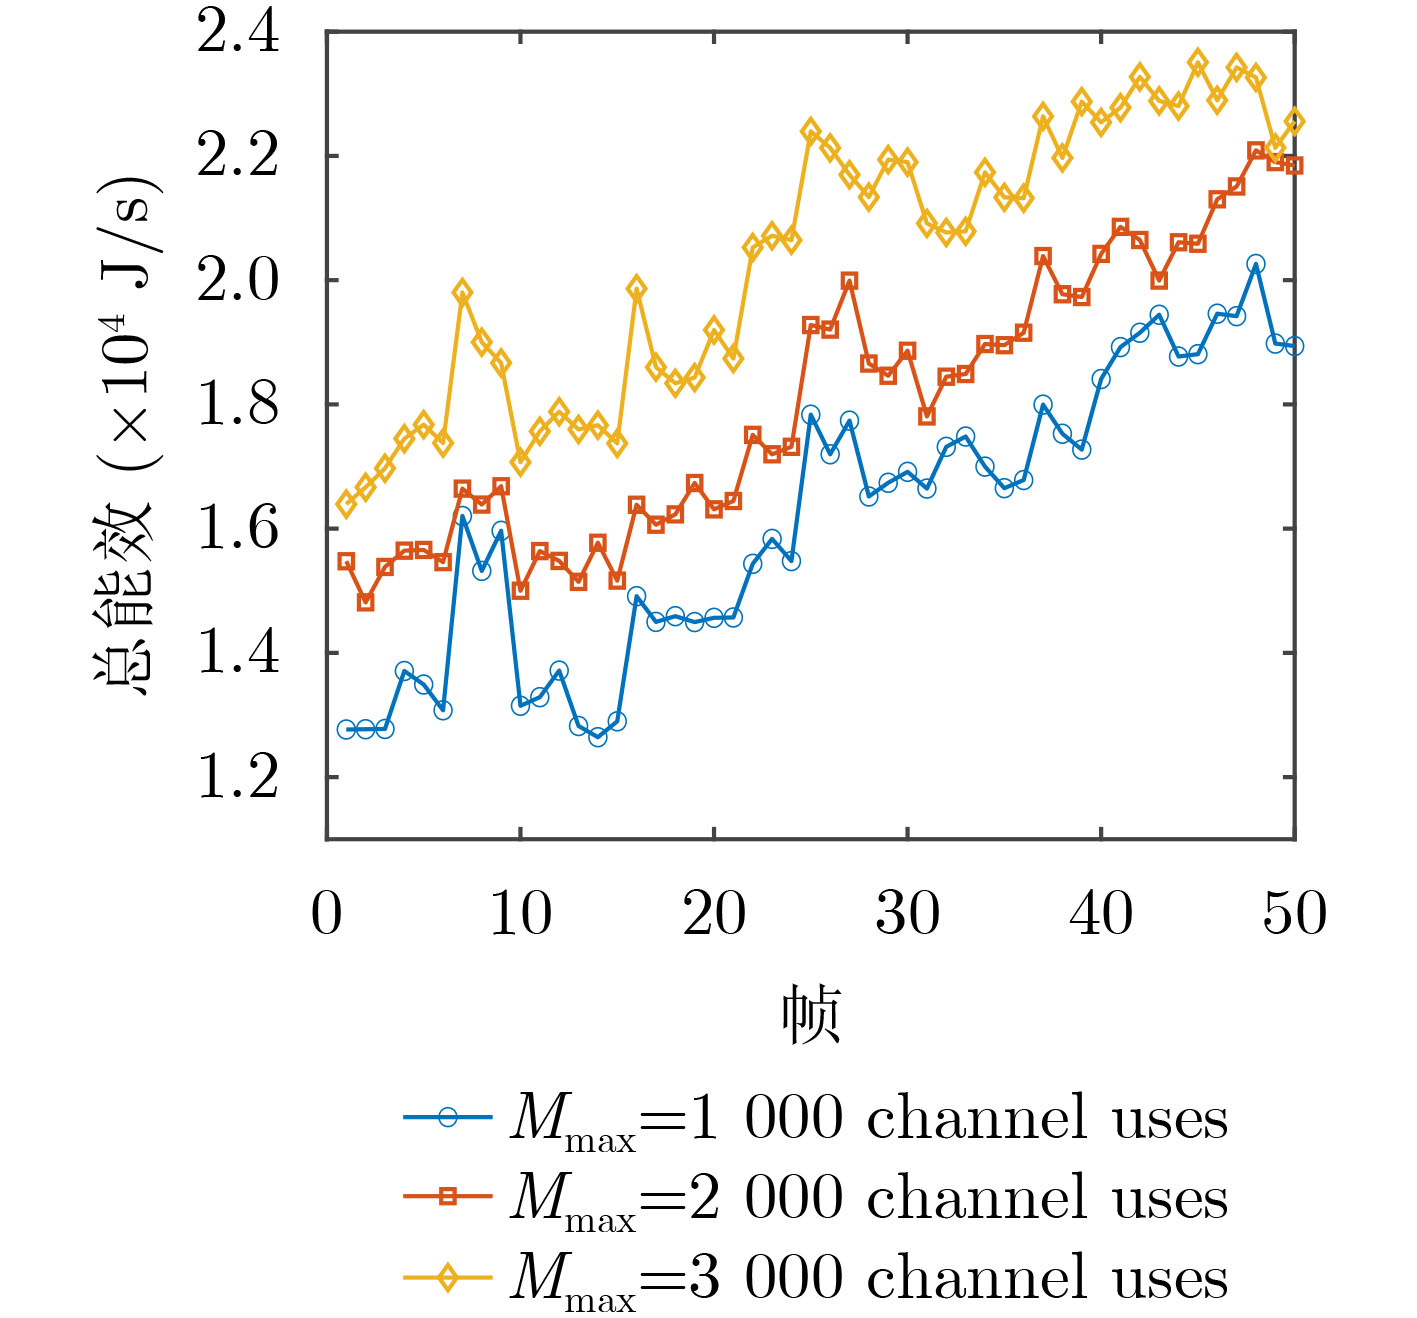
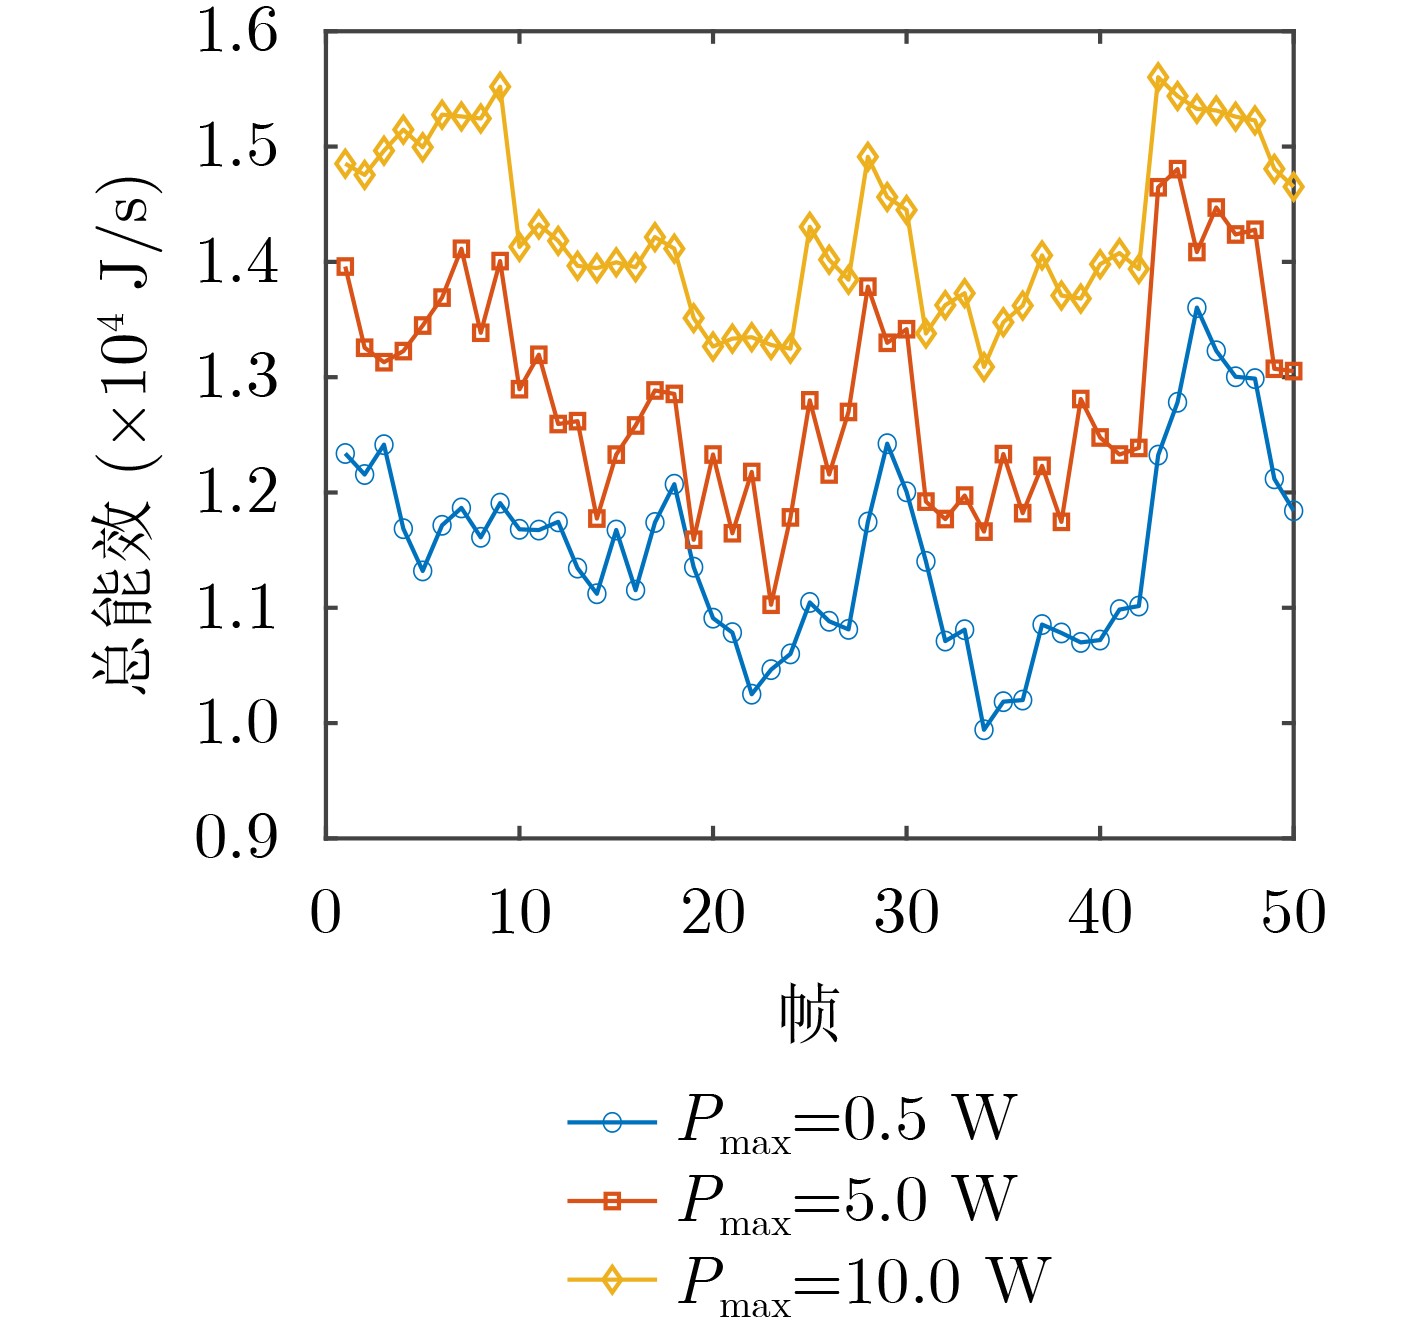
  Objective  Ultra-Reliable and Low-Latency Communications (URLLC) is widely used in Industrial Internet of Things (IIoT) systems. However, in mobile industrial scenarios such as transportation and inspection, instantaneous Channel State Information (CSI) is difficult to obtain because of feedback overhead. Resource allocation decisions therefore need to be made using outdated CSI. This mismatch restricts system energy efficiency. Traditional convex optimization methods have difficulty addressing this problem. Classical Deep Reinforcement Learning (DRL) algorithms also have limited convergence stability and policy performance under the stringent latency and reliability constraints of URLLC. To address these challenges, this paper considers a multi-node URLLC system under outdated CSI in dynamic scenarios. An energy-efficiency maximization problem is formulated under the Finite BlockLength (FBL) regime, with communication latency and reliability constraints. An efficient and stable algorithm is then designed for joint power and blocklength allocation.  Methods  A Successive Convex Approximation (SCA)-assisted DRL framework is proposed to maximize energy efficiency under outdated CSI. First, an SCA-based algorithm is developed to obtain a pre-allocation solution for transmit power and blocklength. This solution is feasible and physically interpretable, but relatively conservative. Based on this baseline, a Twin Delayed Deep Deterministic policy gradient (TD3) algorithm is used for incremental refinement through interaction with the dynamic environment. This process reduces the conservatism of SCA. The SCA solution is used as prior knowledge in the state representation. Node location information is also incorporated into the state space. These designs narrow the policy search space and enable the DRL agent to better capture large-scale channel characteristics and system dynamics under outdated CSI. Learning efficiency and stability are therefore improved.  Results and Discussions  The proposed algorithm is evaluated through simulations and compared with three benchmark algorithms: an SCA-based optimization algorithm, a TD3 algorithm without SCA guidance, and a TD3 algorithm without node location information. The results show that the proposed method outperforms all benchmarks in convergence stability and system energy efficiency. In the training phase (Fig. 3), the average reward of the proposed algorithm increases steadily and converges stably. By contrast, removing node location information leads to lower rewards and stronger fluctuations. Removing SCA guidance causes the algorithm to converge to a much lower reward level. These results confirm the roles of SCA-based prior guidance and location-aware state representation in improving training stability. In the actual operation stage (Fig. 4), the proposed algorithm achieves high and stable energy efficiency and outperforms all comparison algorithms. Under outdated CSI, DRL-based methods can obtain higher energy efficiency than conservative optimization methods when transmission succeeds. However, removing node location information reduces energy efficiency, and removing SCA guidance increases transmission failures. These results verify the effectiveness of both designs in improving energy efficiency and maintaining policy feasibility. The effects of key system parameters are also examined. For basic resource parameters, a moderate increase in the blocklength budget (Fig. 5) or power budget (Fig. 6) improves system energy efficiency. For reliability constraints (Fig. 7), the reliability requirement should be set according to service requirements to avoid resource waste. Finally, the average energy efficiency under different numbers of nodes and different numbers of neurons in the TD3 network is analyzed (Fig. 8). The results provide guidance for algorithm configuration and network-scale design.  Conclusions  This paper addresses energy-efficient resource allocation for multi-node URLLC systems with outdated CSI by integrating SCA and DRL. In the proposed framework, a TD3-based DRL algorithm is guided by an SCA reference solution, and node location information is incorporated into the state representation. This optimization-learning dual-driven framework combines the interpretability and feasibility of model-based optimization with the adaptivity of data-driven learning. Simulation results show that the proposed method achieves higher energy efficiency than SCA-based optimization and conventional TD3 while satisfying URLLC latency and reliability constraints. The SCA reference solution improves policy stability and effectiveness under outdated CSI. Node location information further supports efficient decision-making. This work focuses on a single-cell multi-node scenario under Time Division Multiple Access (TDMA). Practical issues such as multi-cell interference, cooperative scheduling among multiple base stations, and more complex mobility patterns are not considered. Future work will extend the proposed framework to multi-cell and multi-agent scenarios and test its applicability under more severe CSI imperfections.
Millimeter-Wave Air-to-Ground Channel Prediction Assisted by Visual Information of the Propagation Environment
CHENG Yuanxun, HU Qingsong, ZHANG Xiaomin, WANG Xuesong
2026, 48(9): 3822-3832. doi: 10.11999/JEIT260274
Abstract:
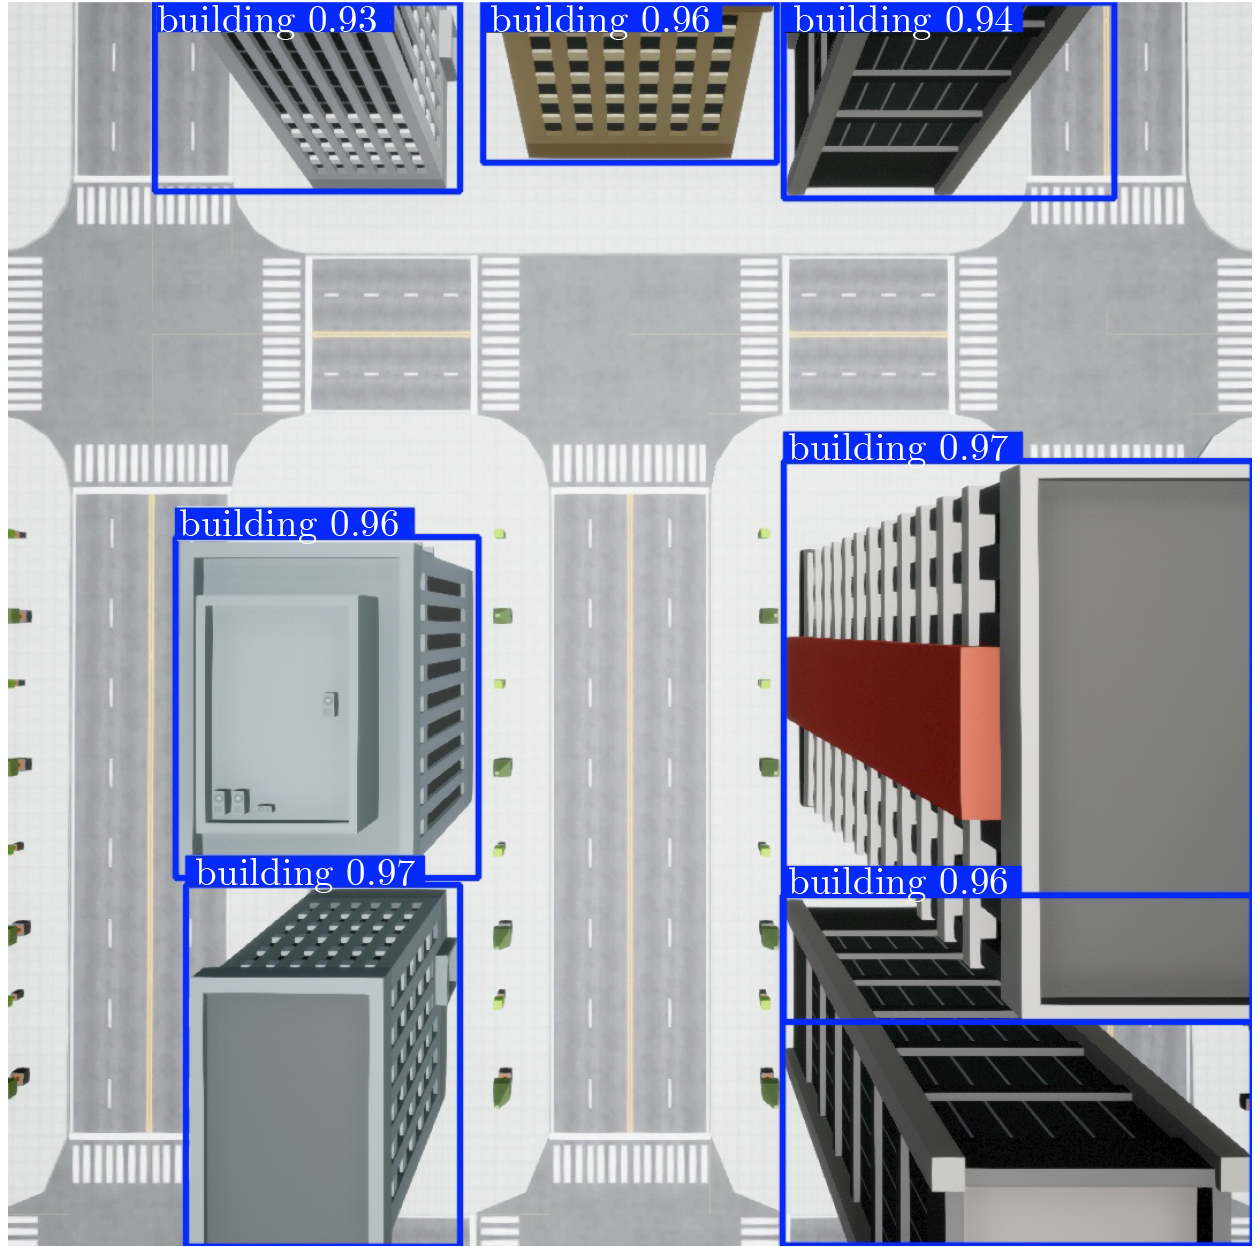
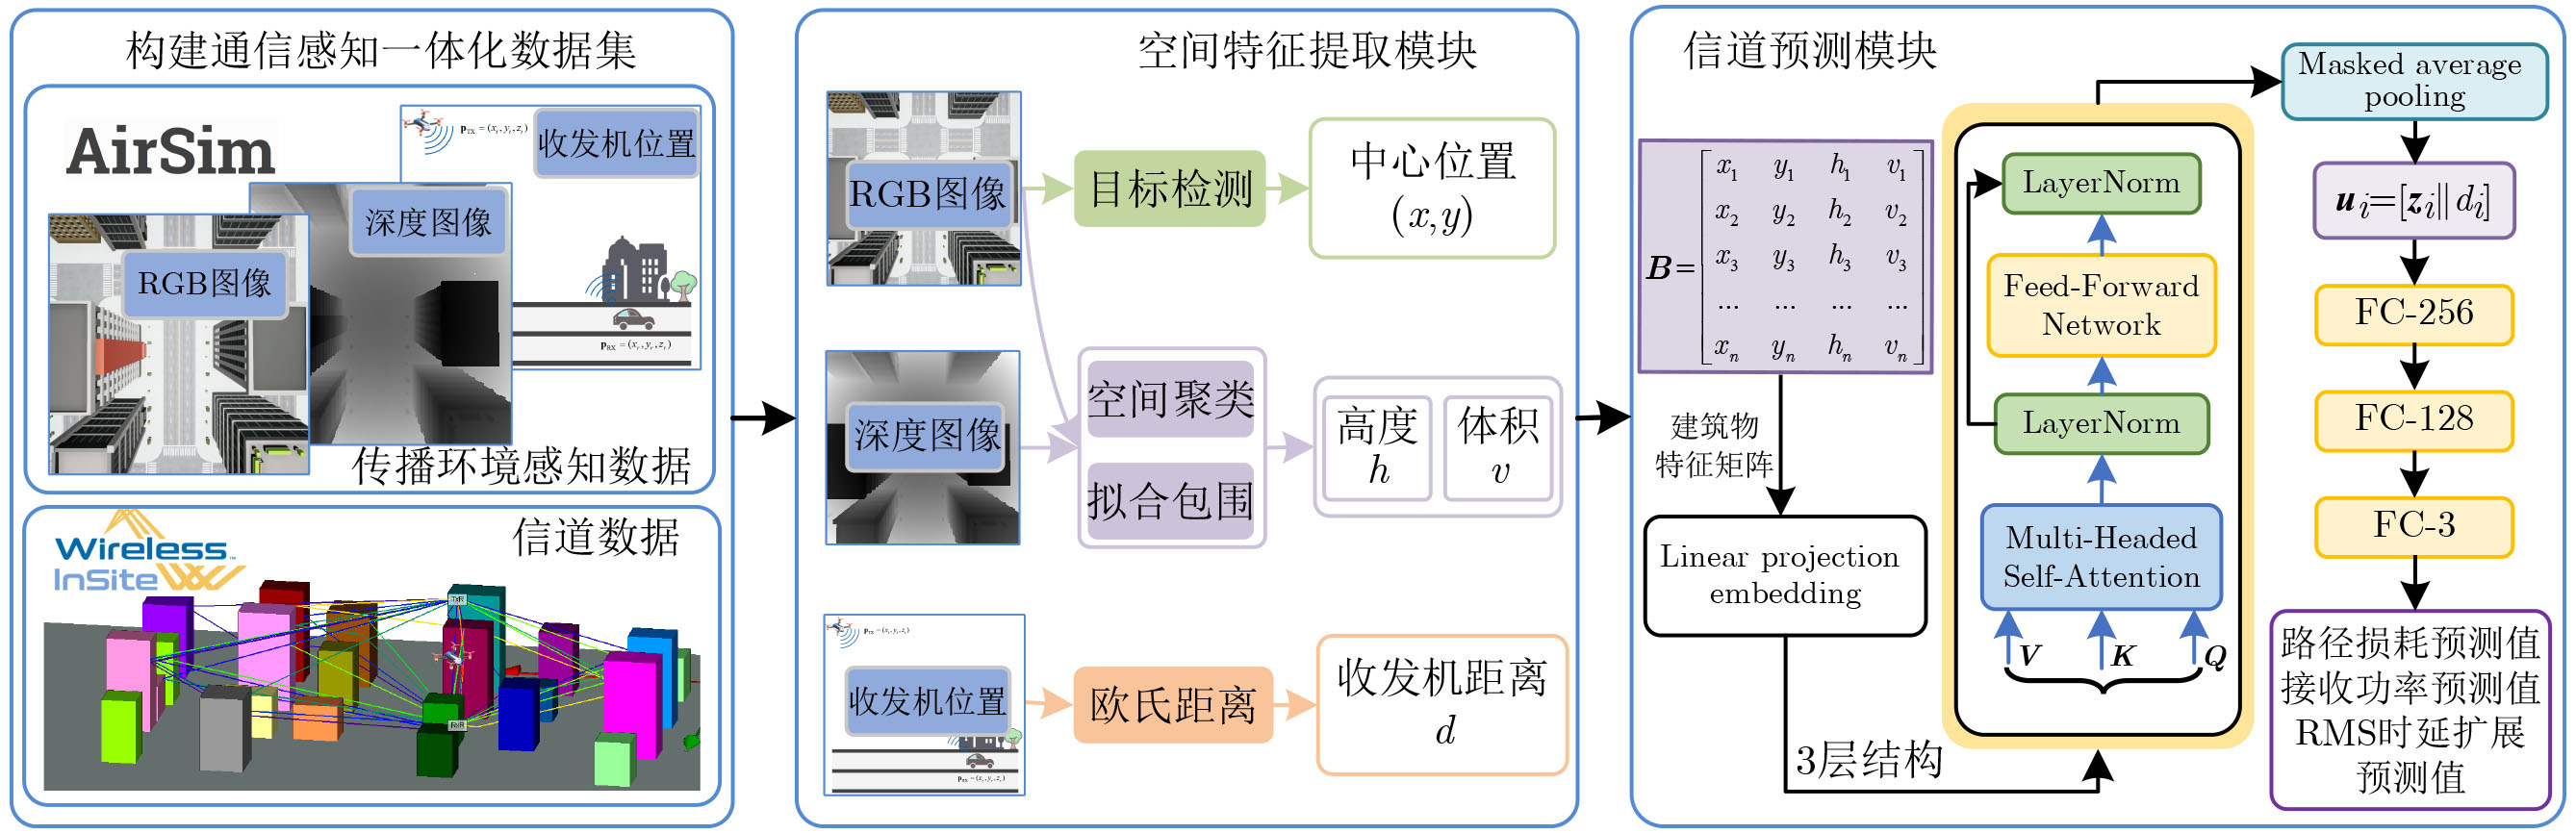
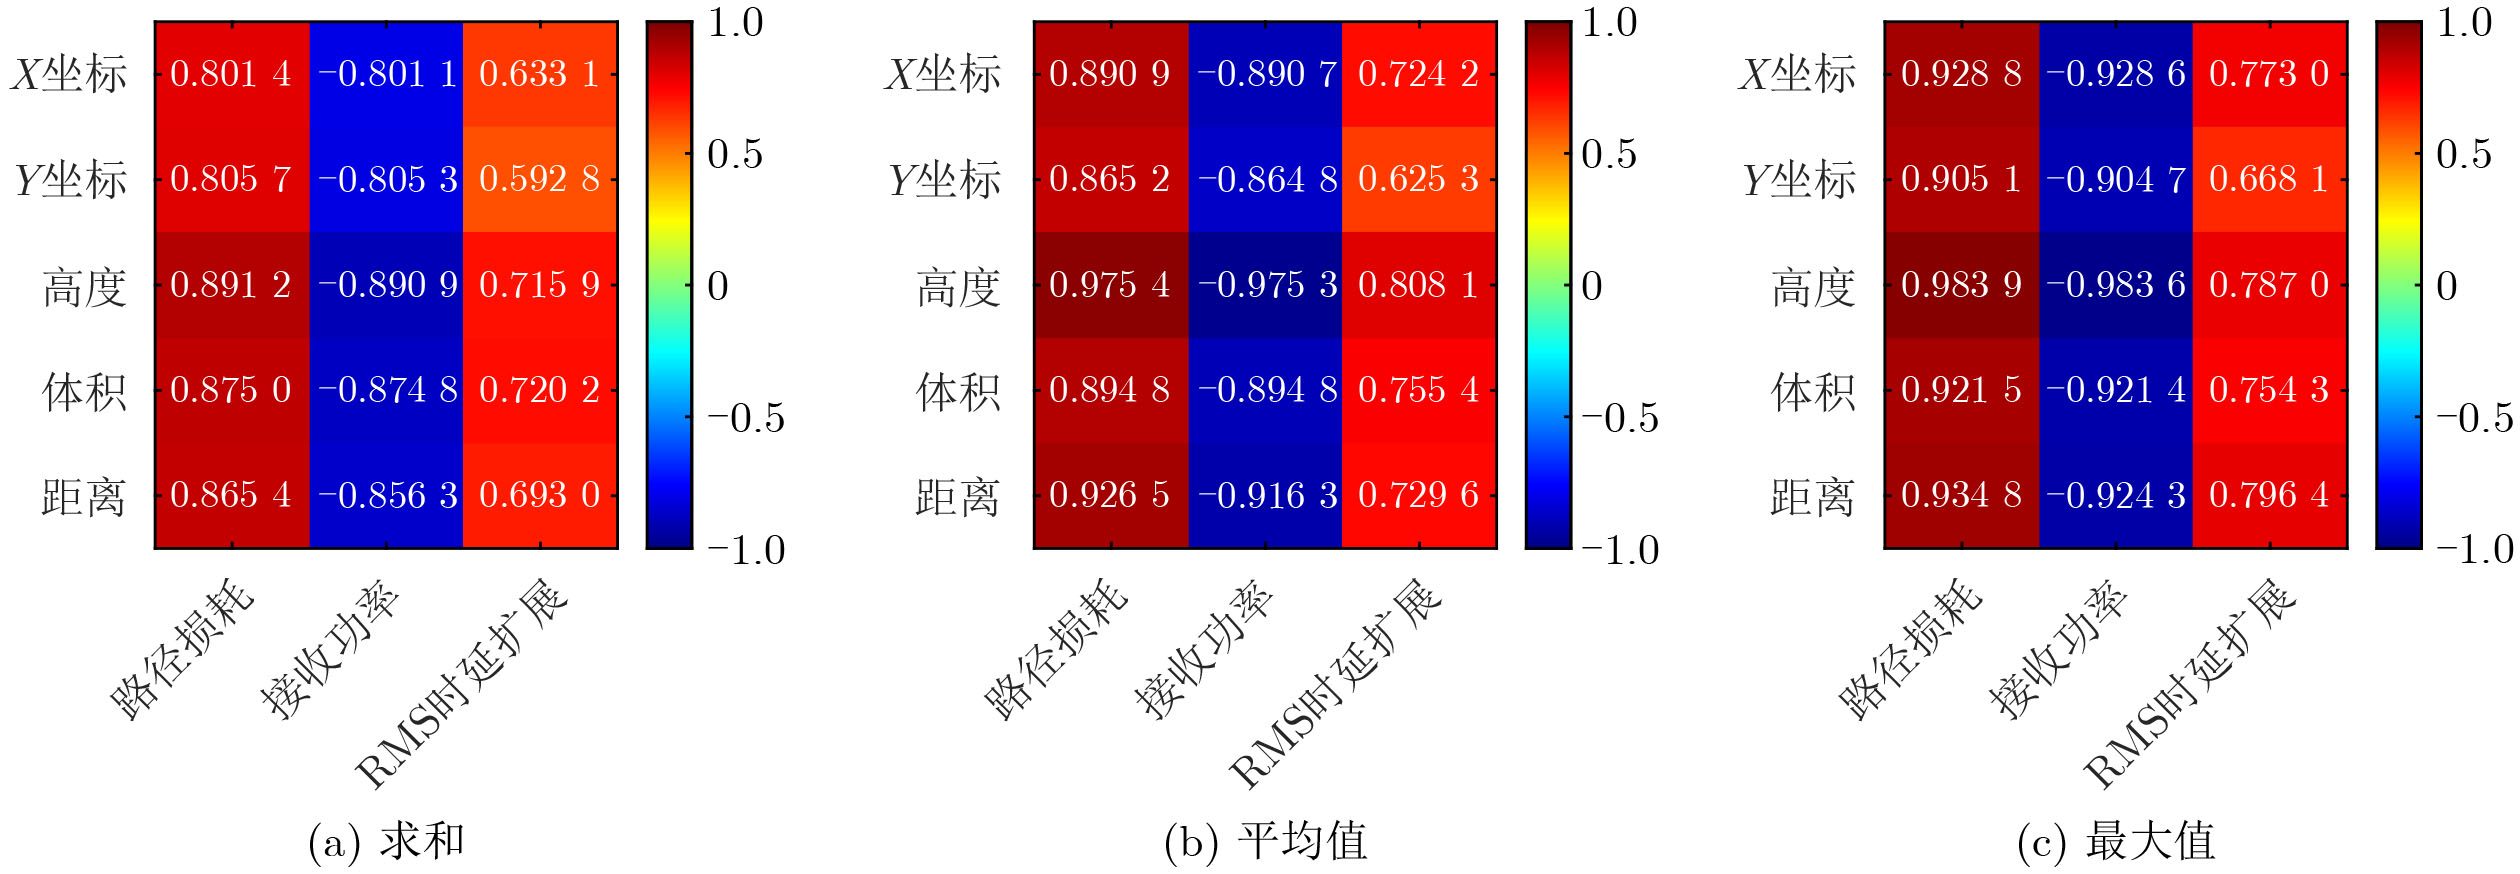
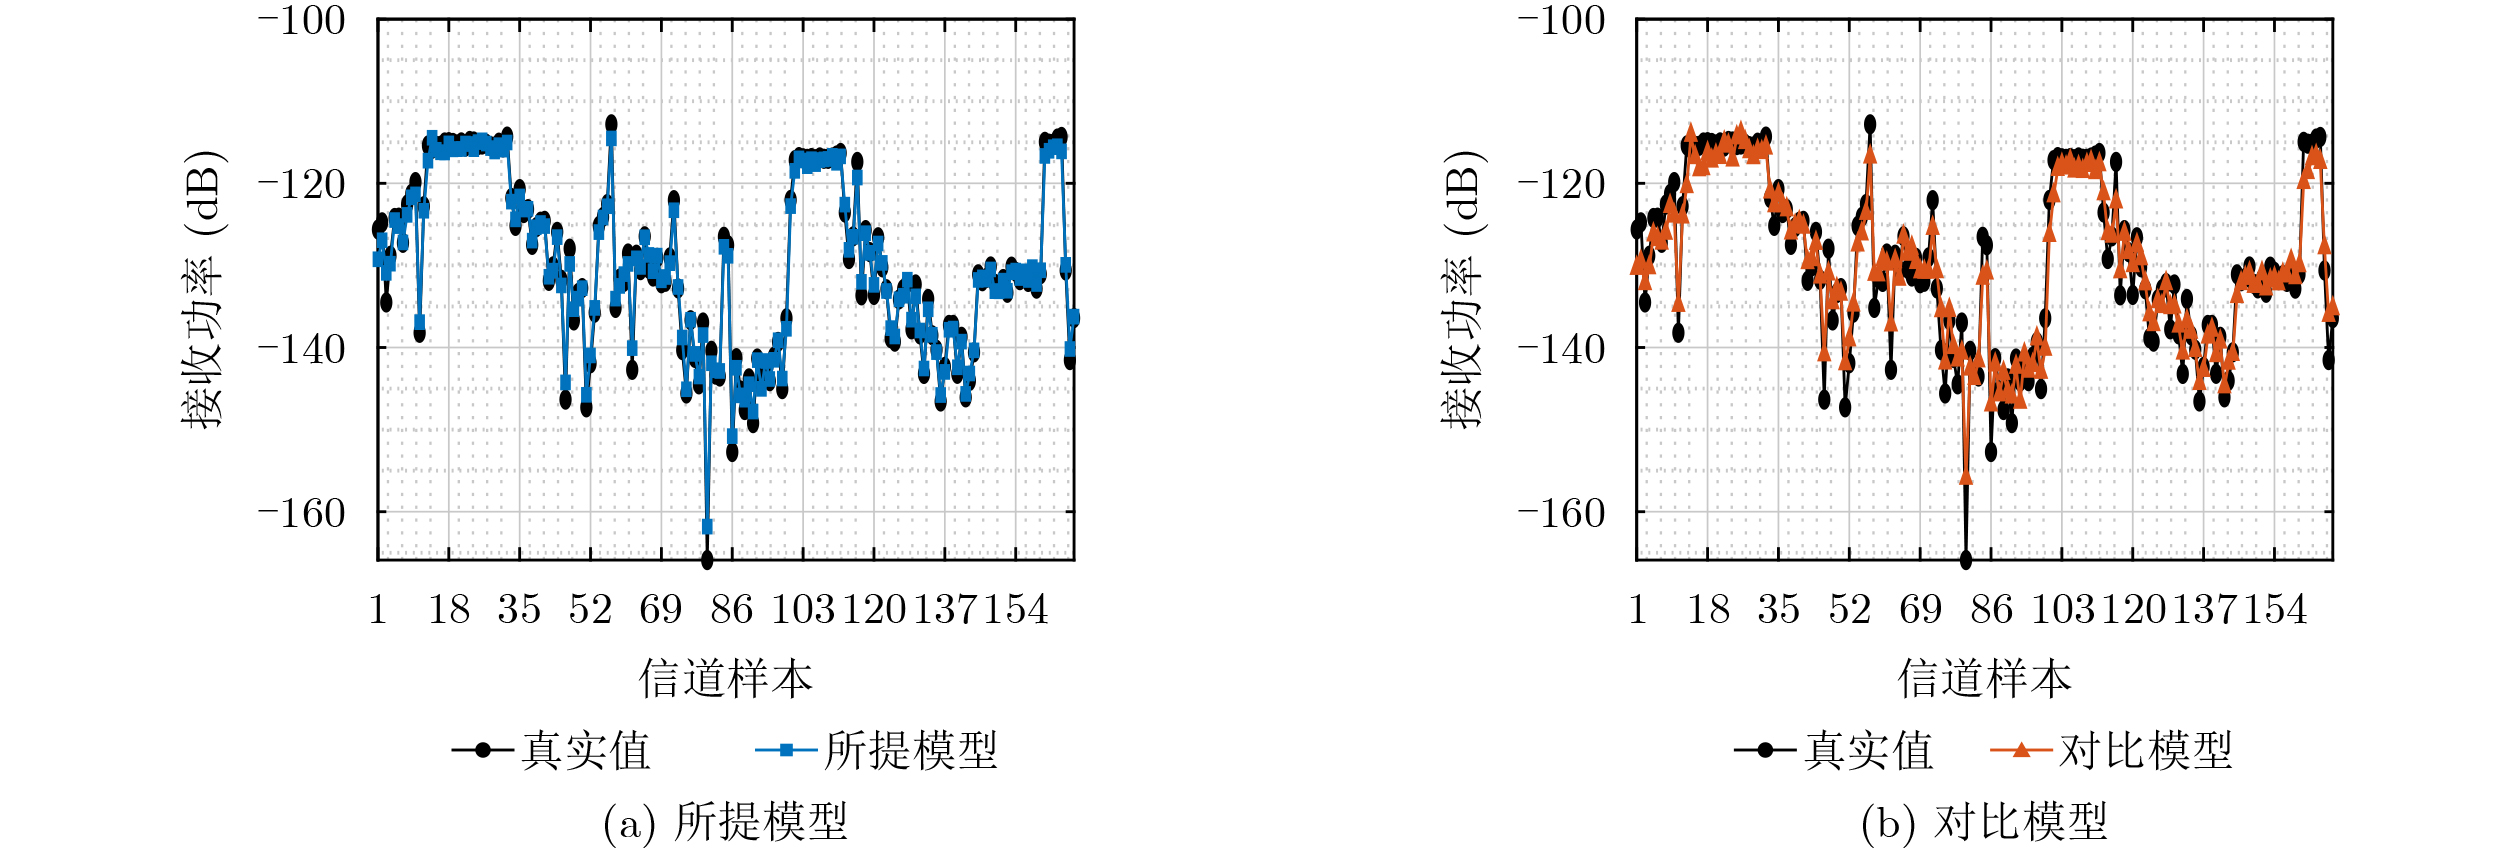
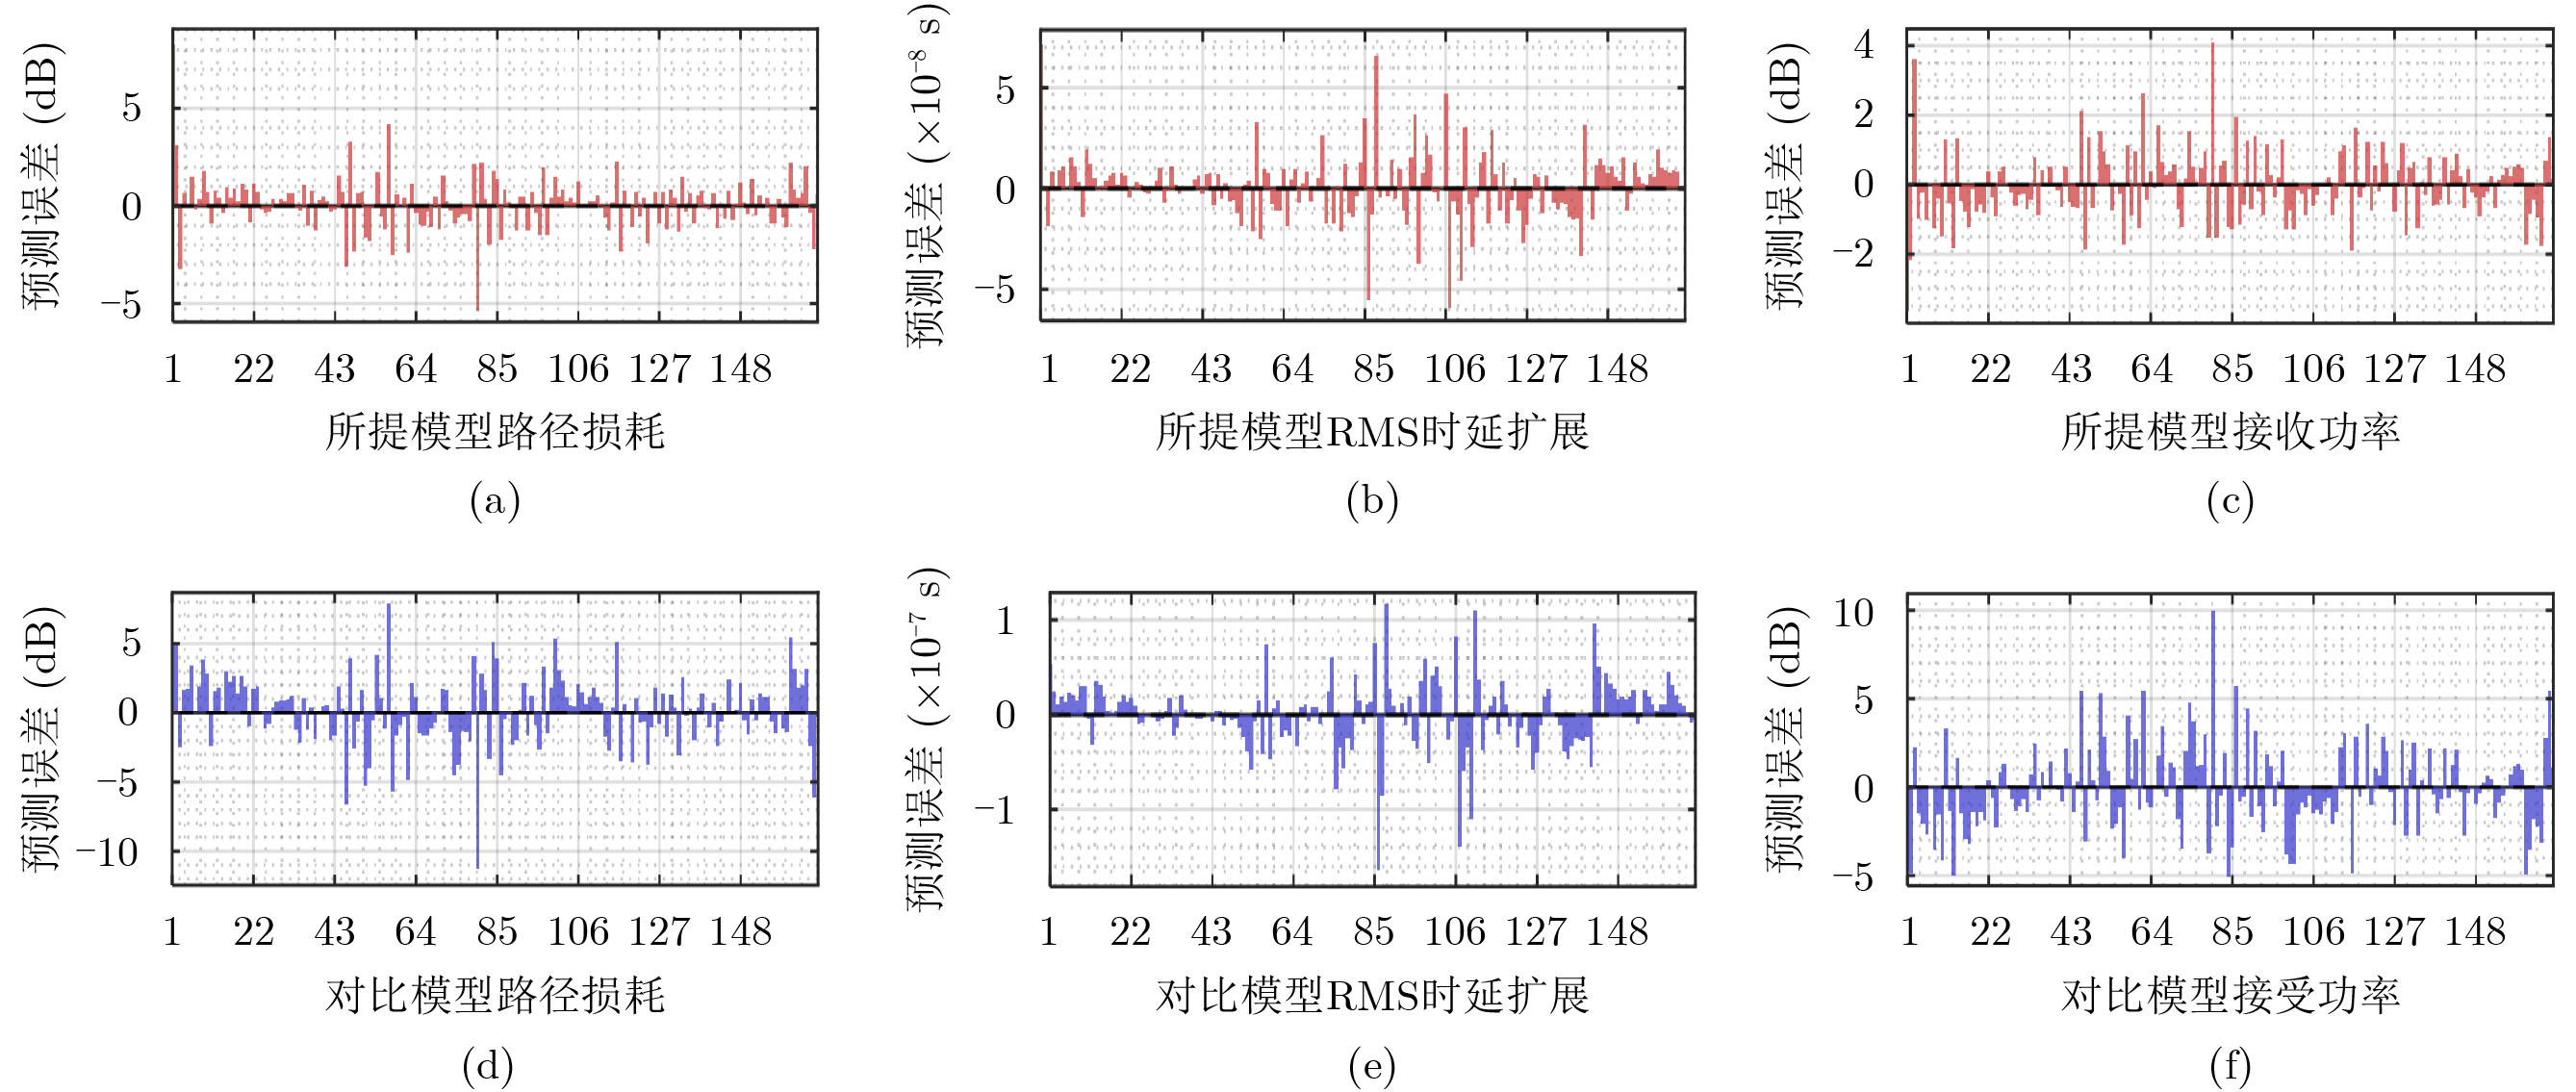
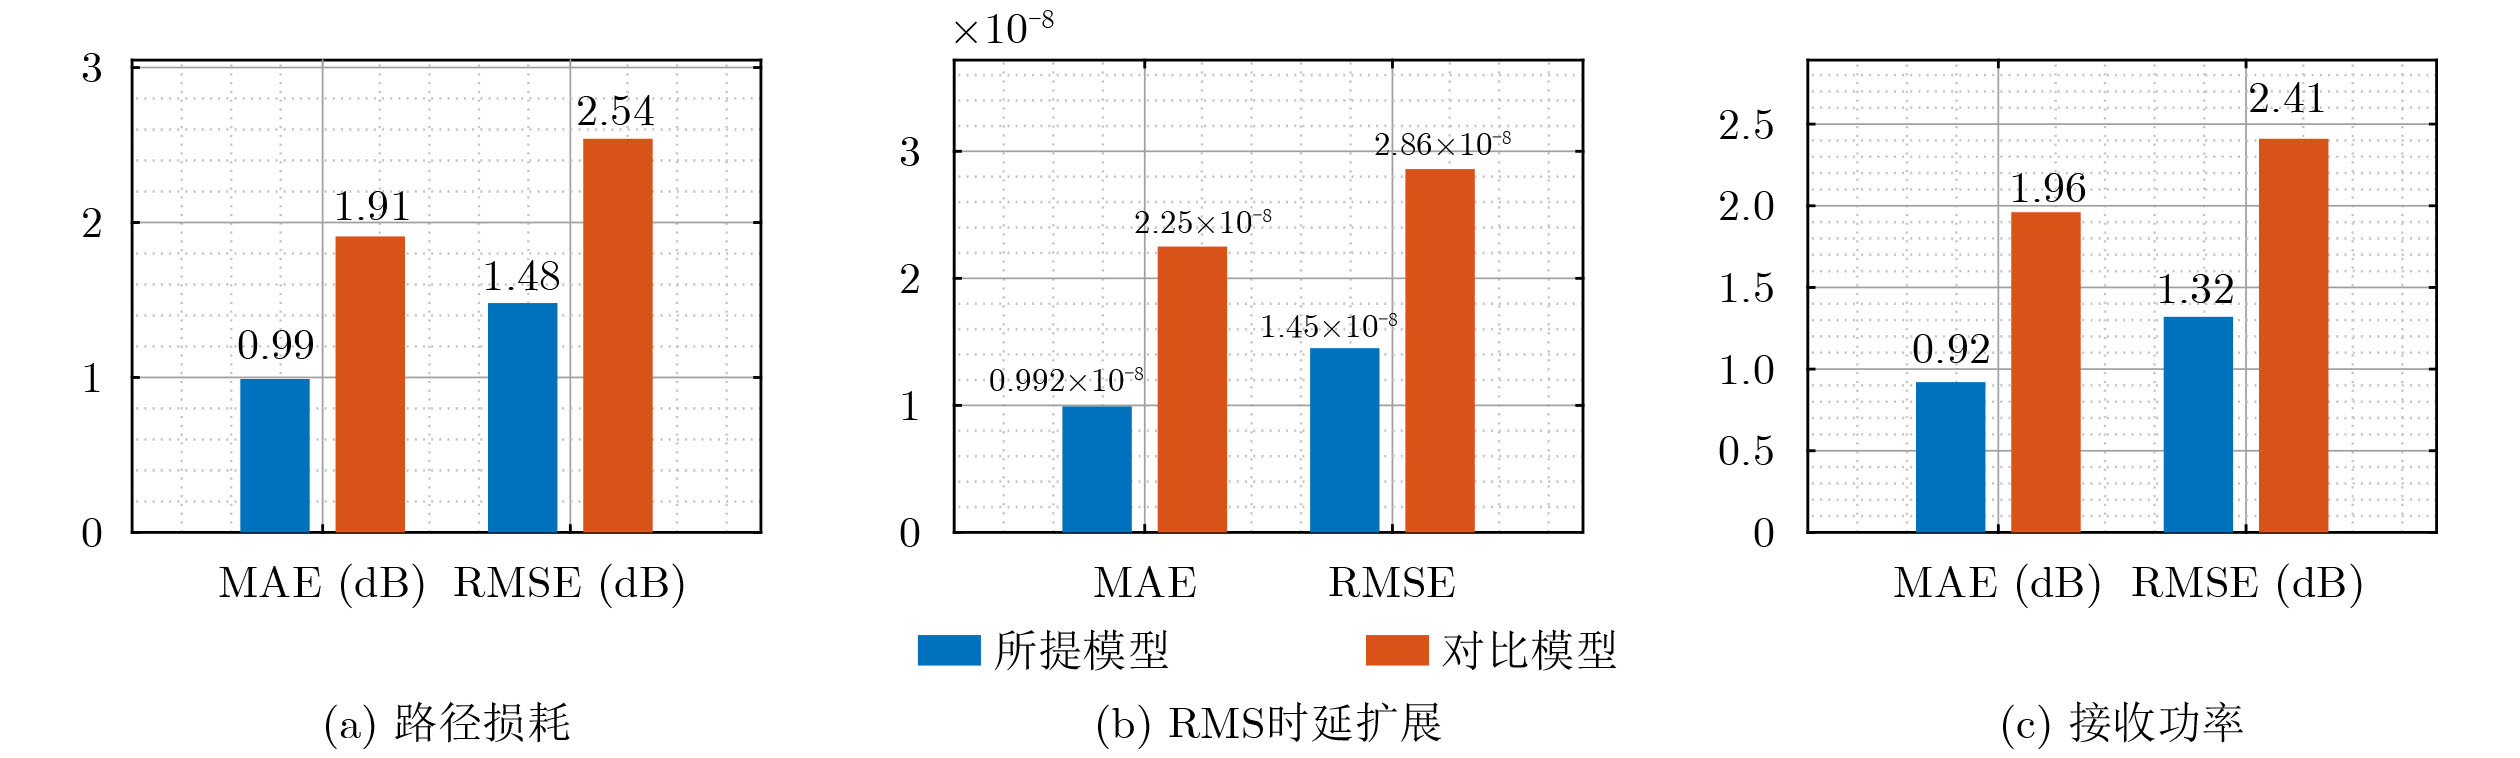
  Objective  Accurate prediction of Air-to-Ground (A2G) channel parameters is essential for adaptive transmission and resource optimization in Unmanned Aerial Vehicle (UAV) communications. In urban Millimeter-Wave (mmWave) scenarios, A2G links are highly sensitive to blockage, reflection, scattering, and rapidly changing geometry among the transmitter, receiver, and surrounding buildings. The channel therefore shows strong spatial and temporal nonstationarity. Conventional pilot- or feedback-based methods can become ineffective because channel estimates are rapidly outdated. Recent data-driven approaches have shown potential. However, many rely heavily on historical channel observations or directly use raw images as network inputs, which may introduce redundant visual information and reduce physical interpretability. To address these limitations, this paper proposes a vision-assisted mmWave A2G channel prediction method. Low-dimensional geometric features are extracted from the propagation environment instead of using raw visual data directly. The method preserves key structural information governing channel evolution, reduces irrelevant redundancy, and improves the accuracy of channel prediction.  Methods  An Integrated Sensing and Communication (ISAC) dataset with strict spatial and temporal alignment is established for mmWave UAV A2G channel prediction. On the sensing side, a high-fidelity Three-Dimensional (3D) urban scenario containing 23 buildings, roads, and intersections is constructed in Unreal Engine 4.27. Synchronized RGB and depth images are collected in AirSim using a multirotor UAV equipped with RGB and depth cameras. The UAV flies along 10 preset trajectories at a height of 55 m with a spatial sampling interval of 1 m, yielding 2 160 valid visual samples (Fig. 1, Fig. 2). On the communication side, the same scene is reconstructed in Wireless InSite. The transmitter-receiver positions are updated synchronously along the same trajectories to ensure frame-level alignment between visual and channel data (Fig. 3). A cross-modal spatial feature extraction scheme is developed to obtain compact and physically meaningful environmental representations. Buildings are first detected from RGB images using YOLOv8 (Fig. 4). The detected regions are then registered with depth images to reconstruct 3D point clouds. After Euclidean clustering and axis-aligned bounding-box fitting, key geometric attributes are extracted, including planar position, height, and volume. These features are combined with the transmitter-receiver distance to form the spatial feature vector for each frame. Their relevance to path loss, received power, and Root Mean Square (RMS) delay spread is evaluated through cosine-similarity-based correlation analysis (Fig. 6). Based on the extracted features, a hybrid Transformer-Multilayer Perceptron (MLP) network is designed for channel prediction (Fig. 5). Building features are first projected into a latent space. A stacked Transformer encoder is then used to capture global interactions among buildings through masked multi-head self-attention. Masked average pooling aggregates building-level representations into a scene-level environmental descriptor. This descriptor is concatenated with the link-distance feature and fed into an MLP regressor to predict the three target channel parameters.  Results and Discussions  The results confirm the effectiveness of the proposed spatial feature representation. Correlation analysis shows that the extracted geometric features are consistently related to path loss, received power, and RMS delay spread under different aggregation strategies (Fig. 6). This result indicates that compact building descriptors can effectively characterize the propagation environment. Among these descriptors, building height shows the strongest correlation with all three channel parameters. This finding confirms the key role of building height in blockage, attenuation, and multipath propagation in urban mmWave A2G channels. In prediction experiments, the proposed method accurately tracks the variation trends of all three targets. It remains effective in deep-fading and sharp-fluctuation regions for path loss prediction (Fig. 7), achieves high consistency with the ground truth for RMS delay spread (Fig. 8), and follows rapid local fluctuations in received power with high fidelity (Fig. 9). By contrast, the benchmark model captures only the overall trend and shows larger deviations at peaks, valleys, and abrupt-change intervals. Residual analysis further demonstrates the superiority of the proposed method. Across all three tasks, its errors are more concentrated around zero and fluctuate within narrower ranges than those of the benchmark model (Fig. 10). Quantitatively, both Mean Absolute Error (MAE) and Root Mean Square Error (RMSE) are reduced (Fig. 11). Compared with the benchmark model, the proposed method improves MAE by 48.2%, 55.9%, and 53.1% for path loss, RMS delay spread, and received power, respectively. The corresponding RMSE improvements are 41.7%, 49.3%, and 45.2% (Table 3). The model also maintains acceptable complexity, with about 5.5 M parameters and a single-frame inference delay of about 3.4 ms. These results indicate its potential for real-time deployment.  Conclusions  A vision-assisted mmWave A2G channel prediction method is proposed for UAV communications. A strictly aligned ISAC dataset is constructed, and low-dimensional spatial features with clear physical meaning are extracted from RGB-depth visual data. The method establishes an effective mapping from environmental geometry to channel parameters. The proposed Transformer-MLP framework accurately predicts path loss, received power, and RMS delay spread. It also provides better interpretability, robustness, and efficiency than the benchmark model.
An Inverse-hybrid-modeling Digital Twin System for Natural Gas Energy Metrology
LIU Bin, ZHONG Lu, FENG Quanyuan, CHEN Yihong
2026, 48(9): 3833-3847. doi: 10.11999/JEIT260289
Abstract:
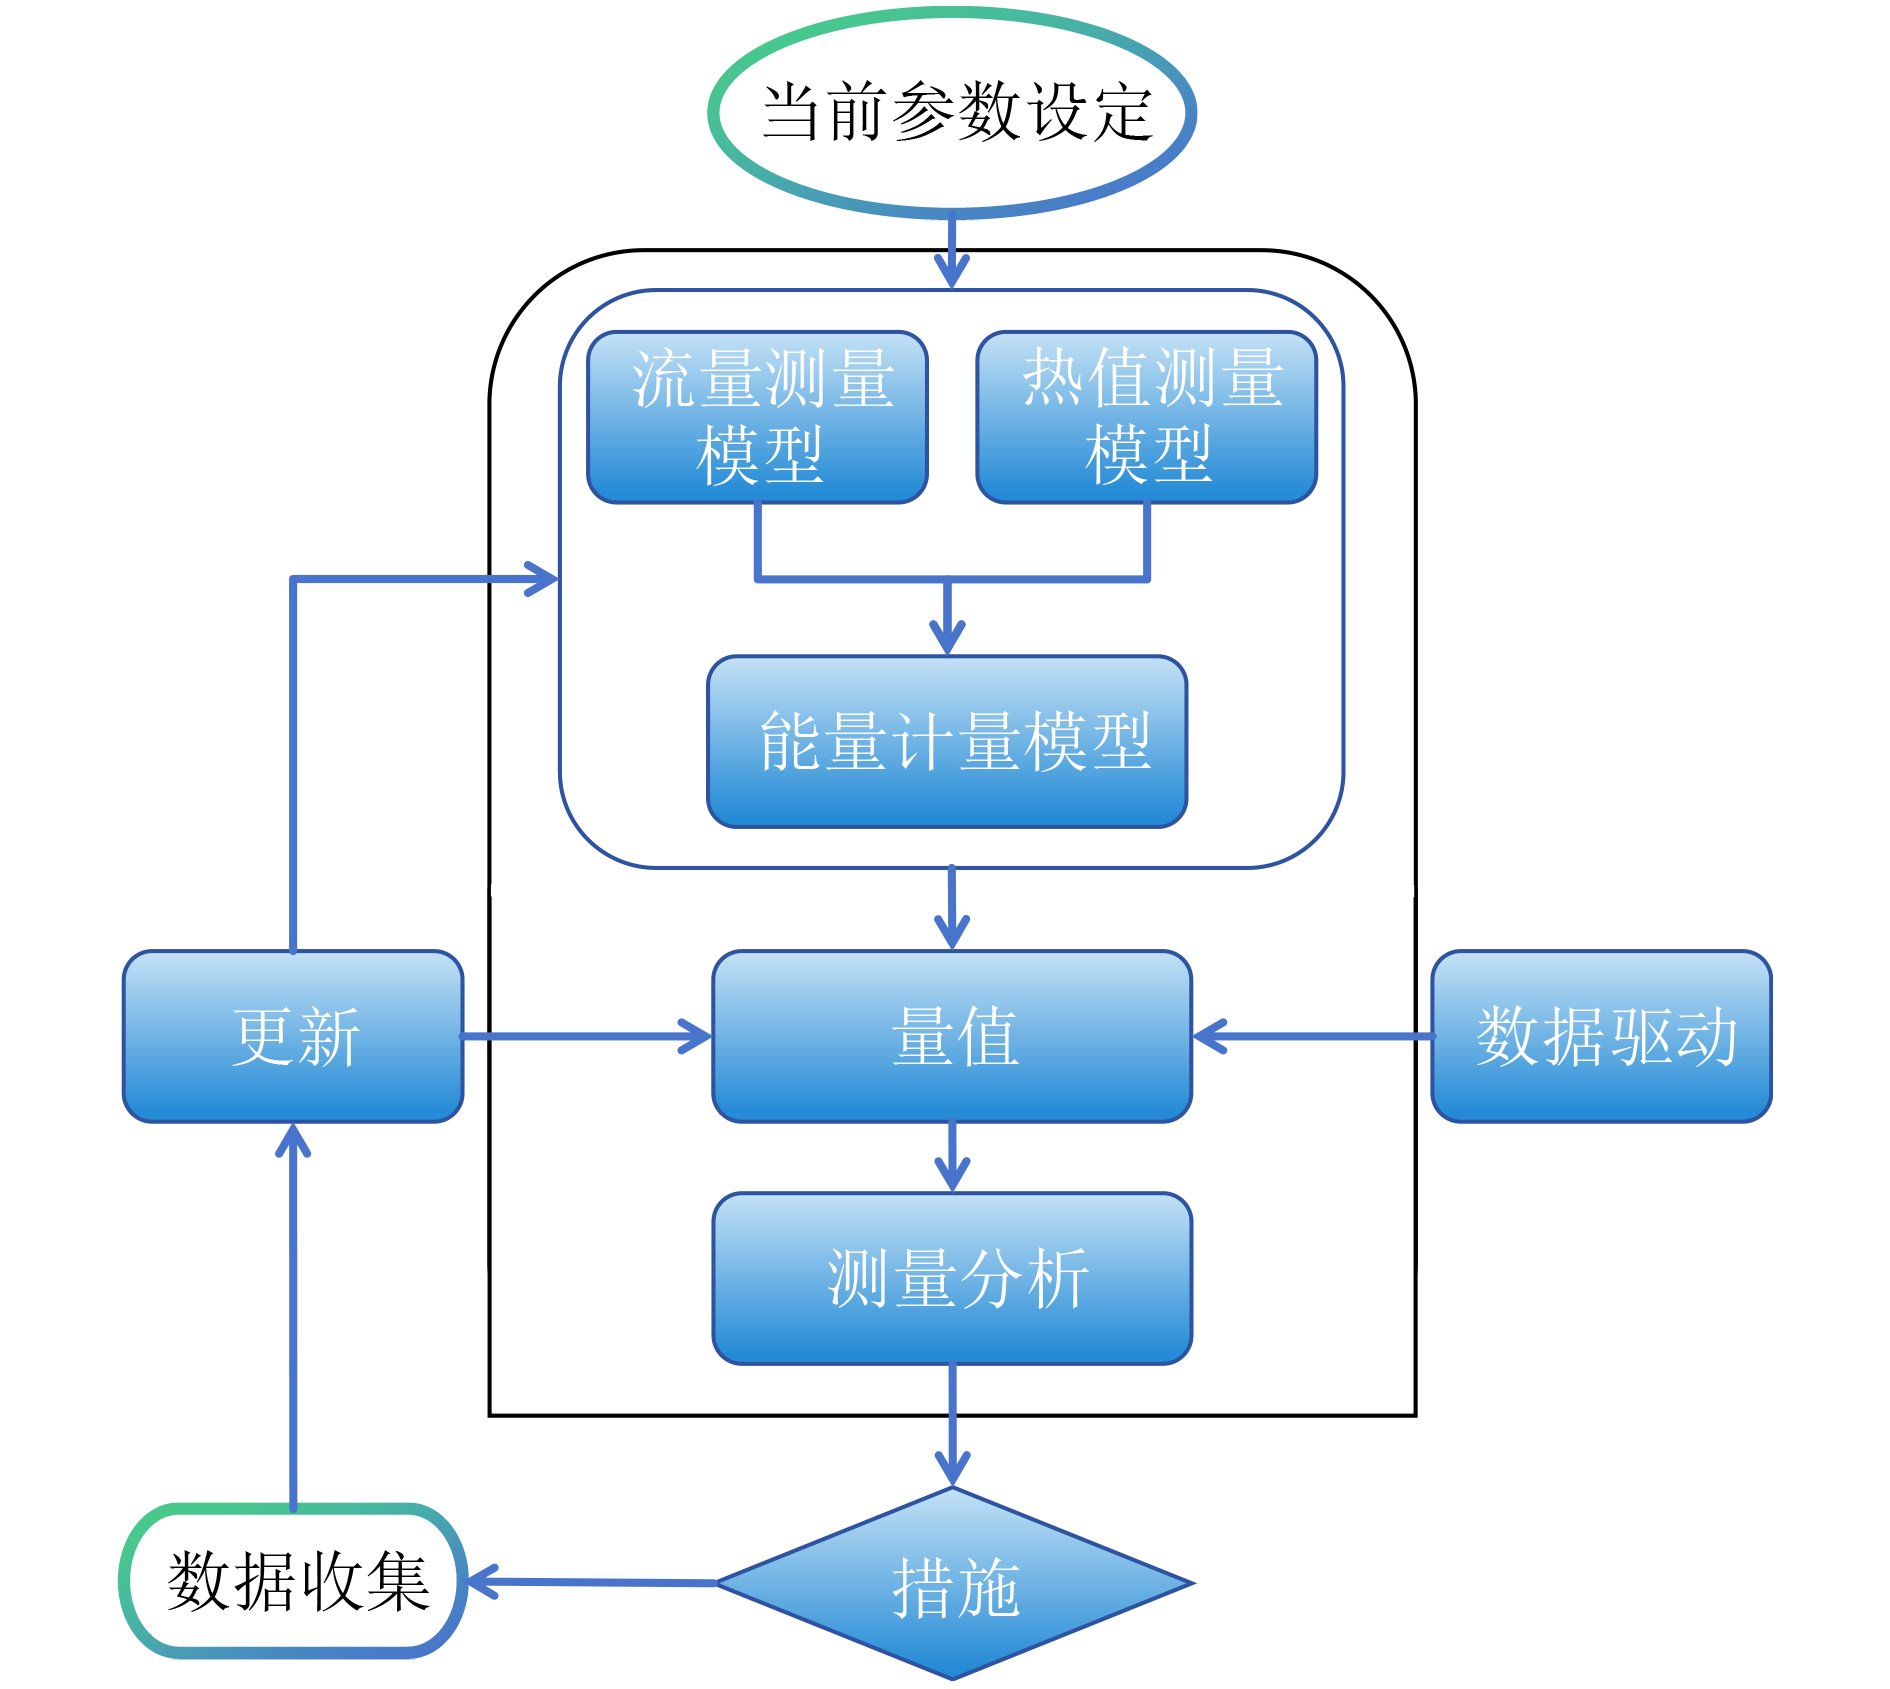
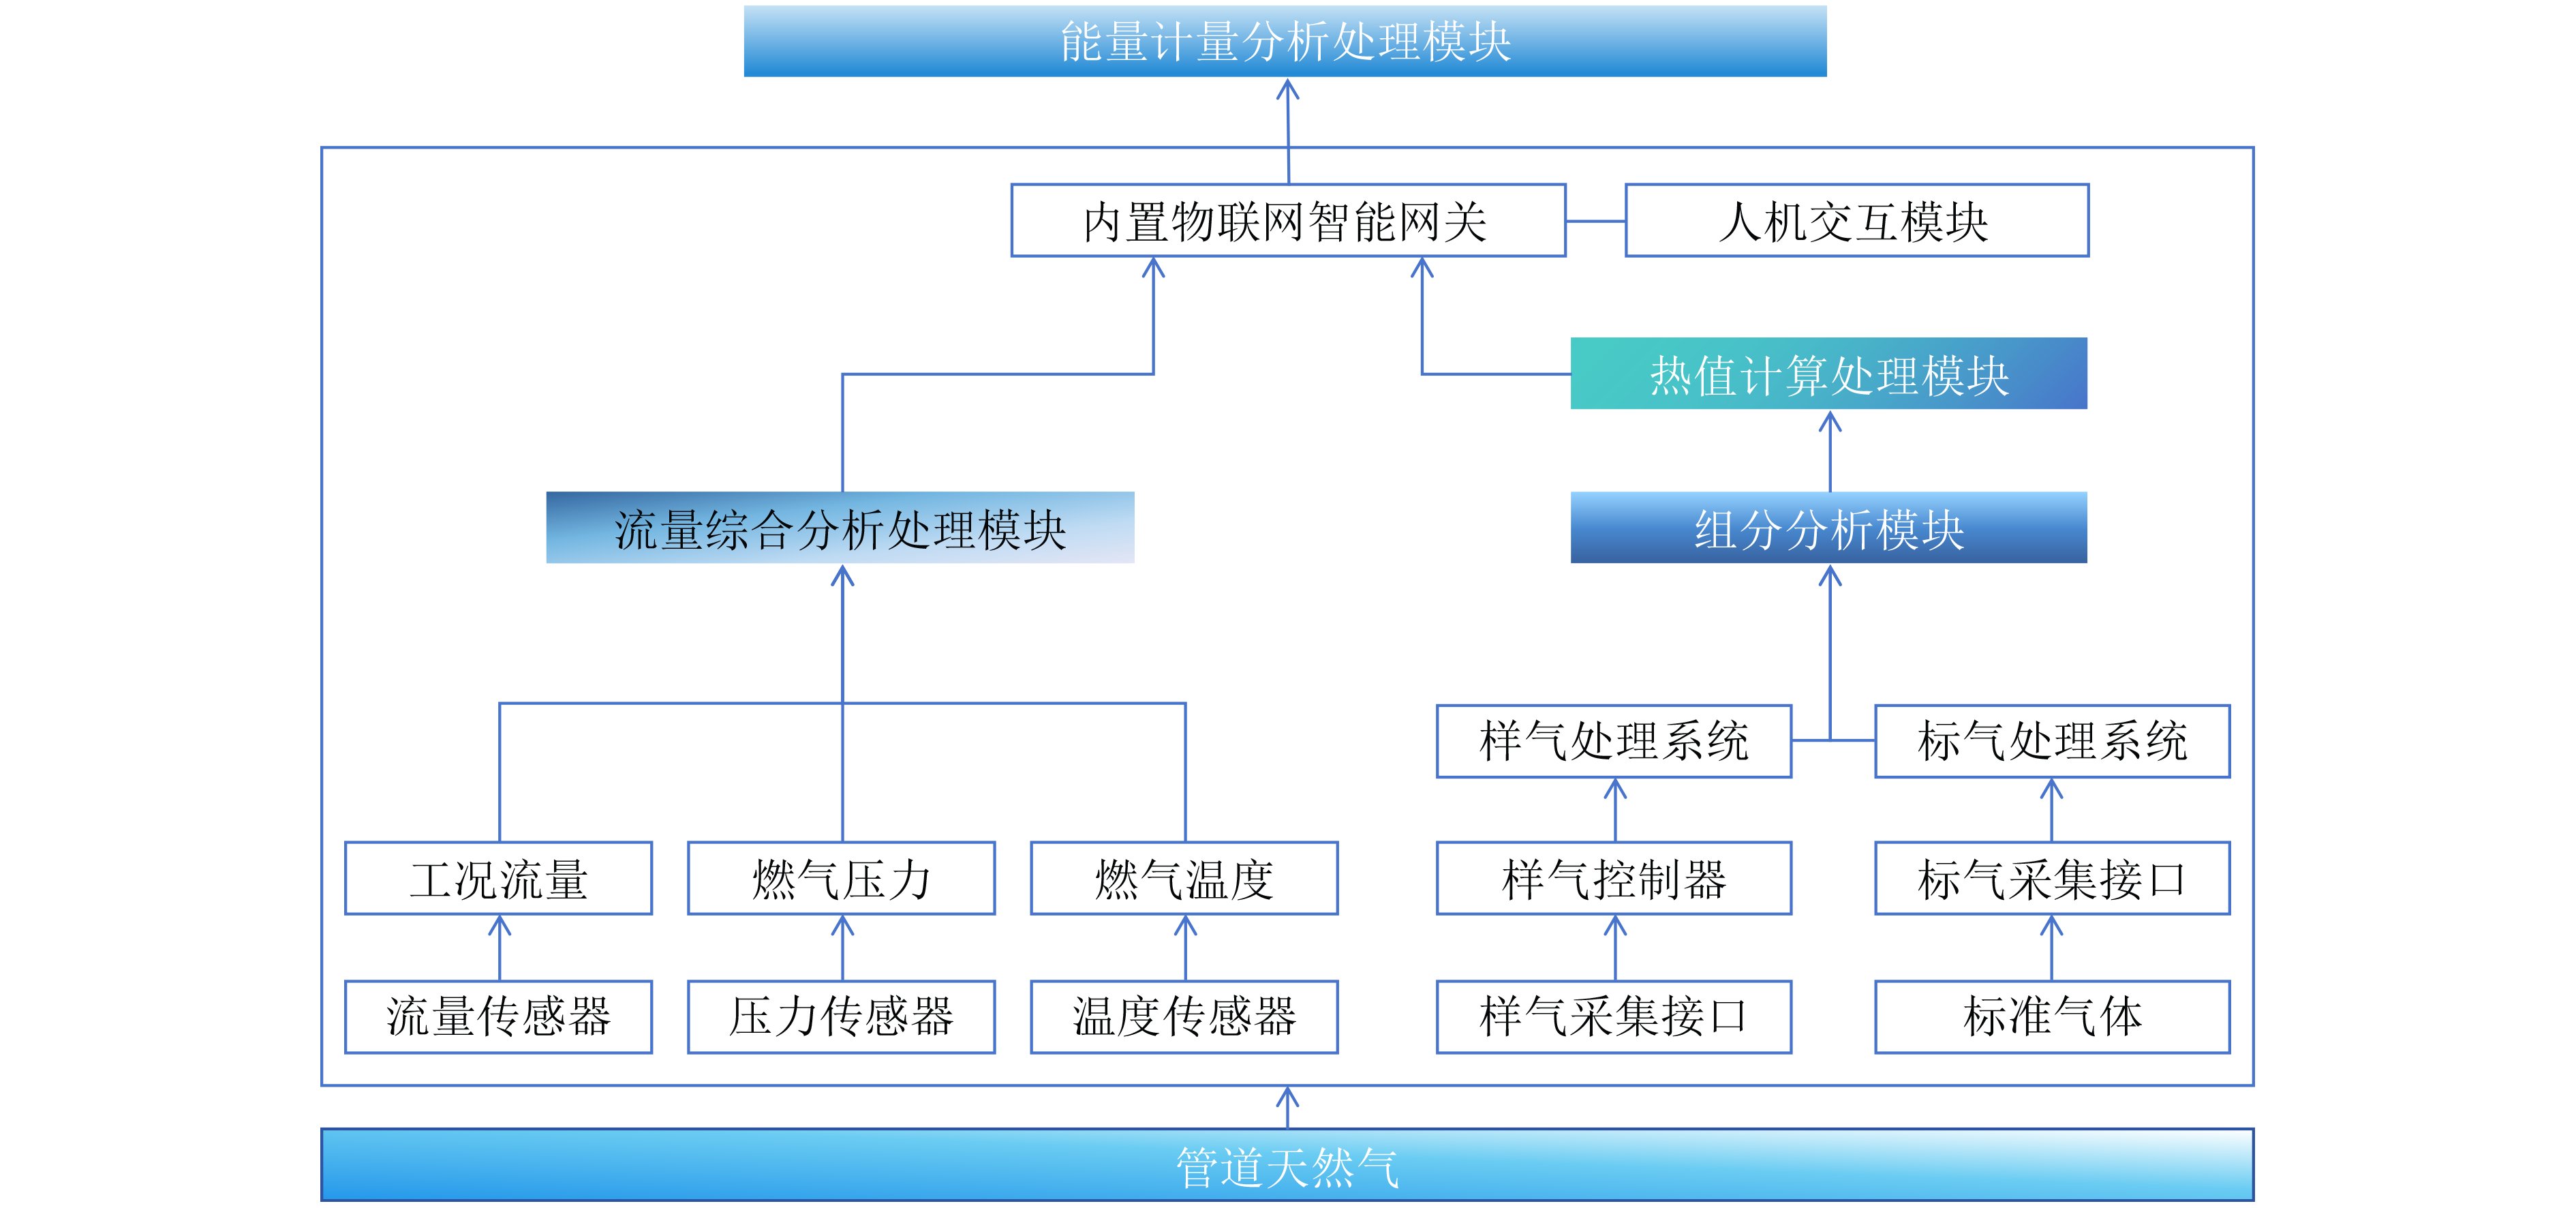
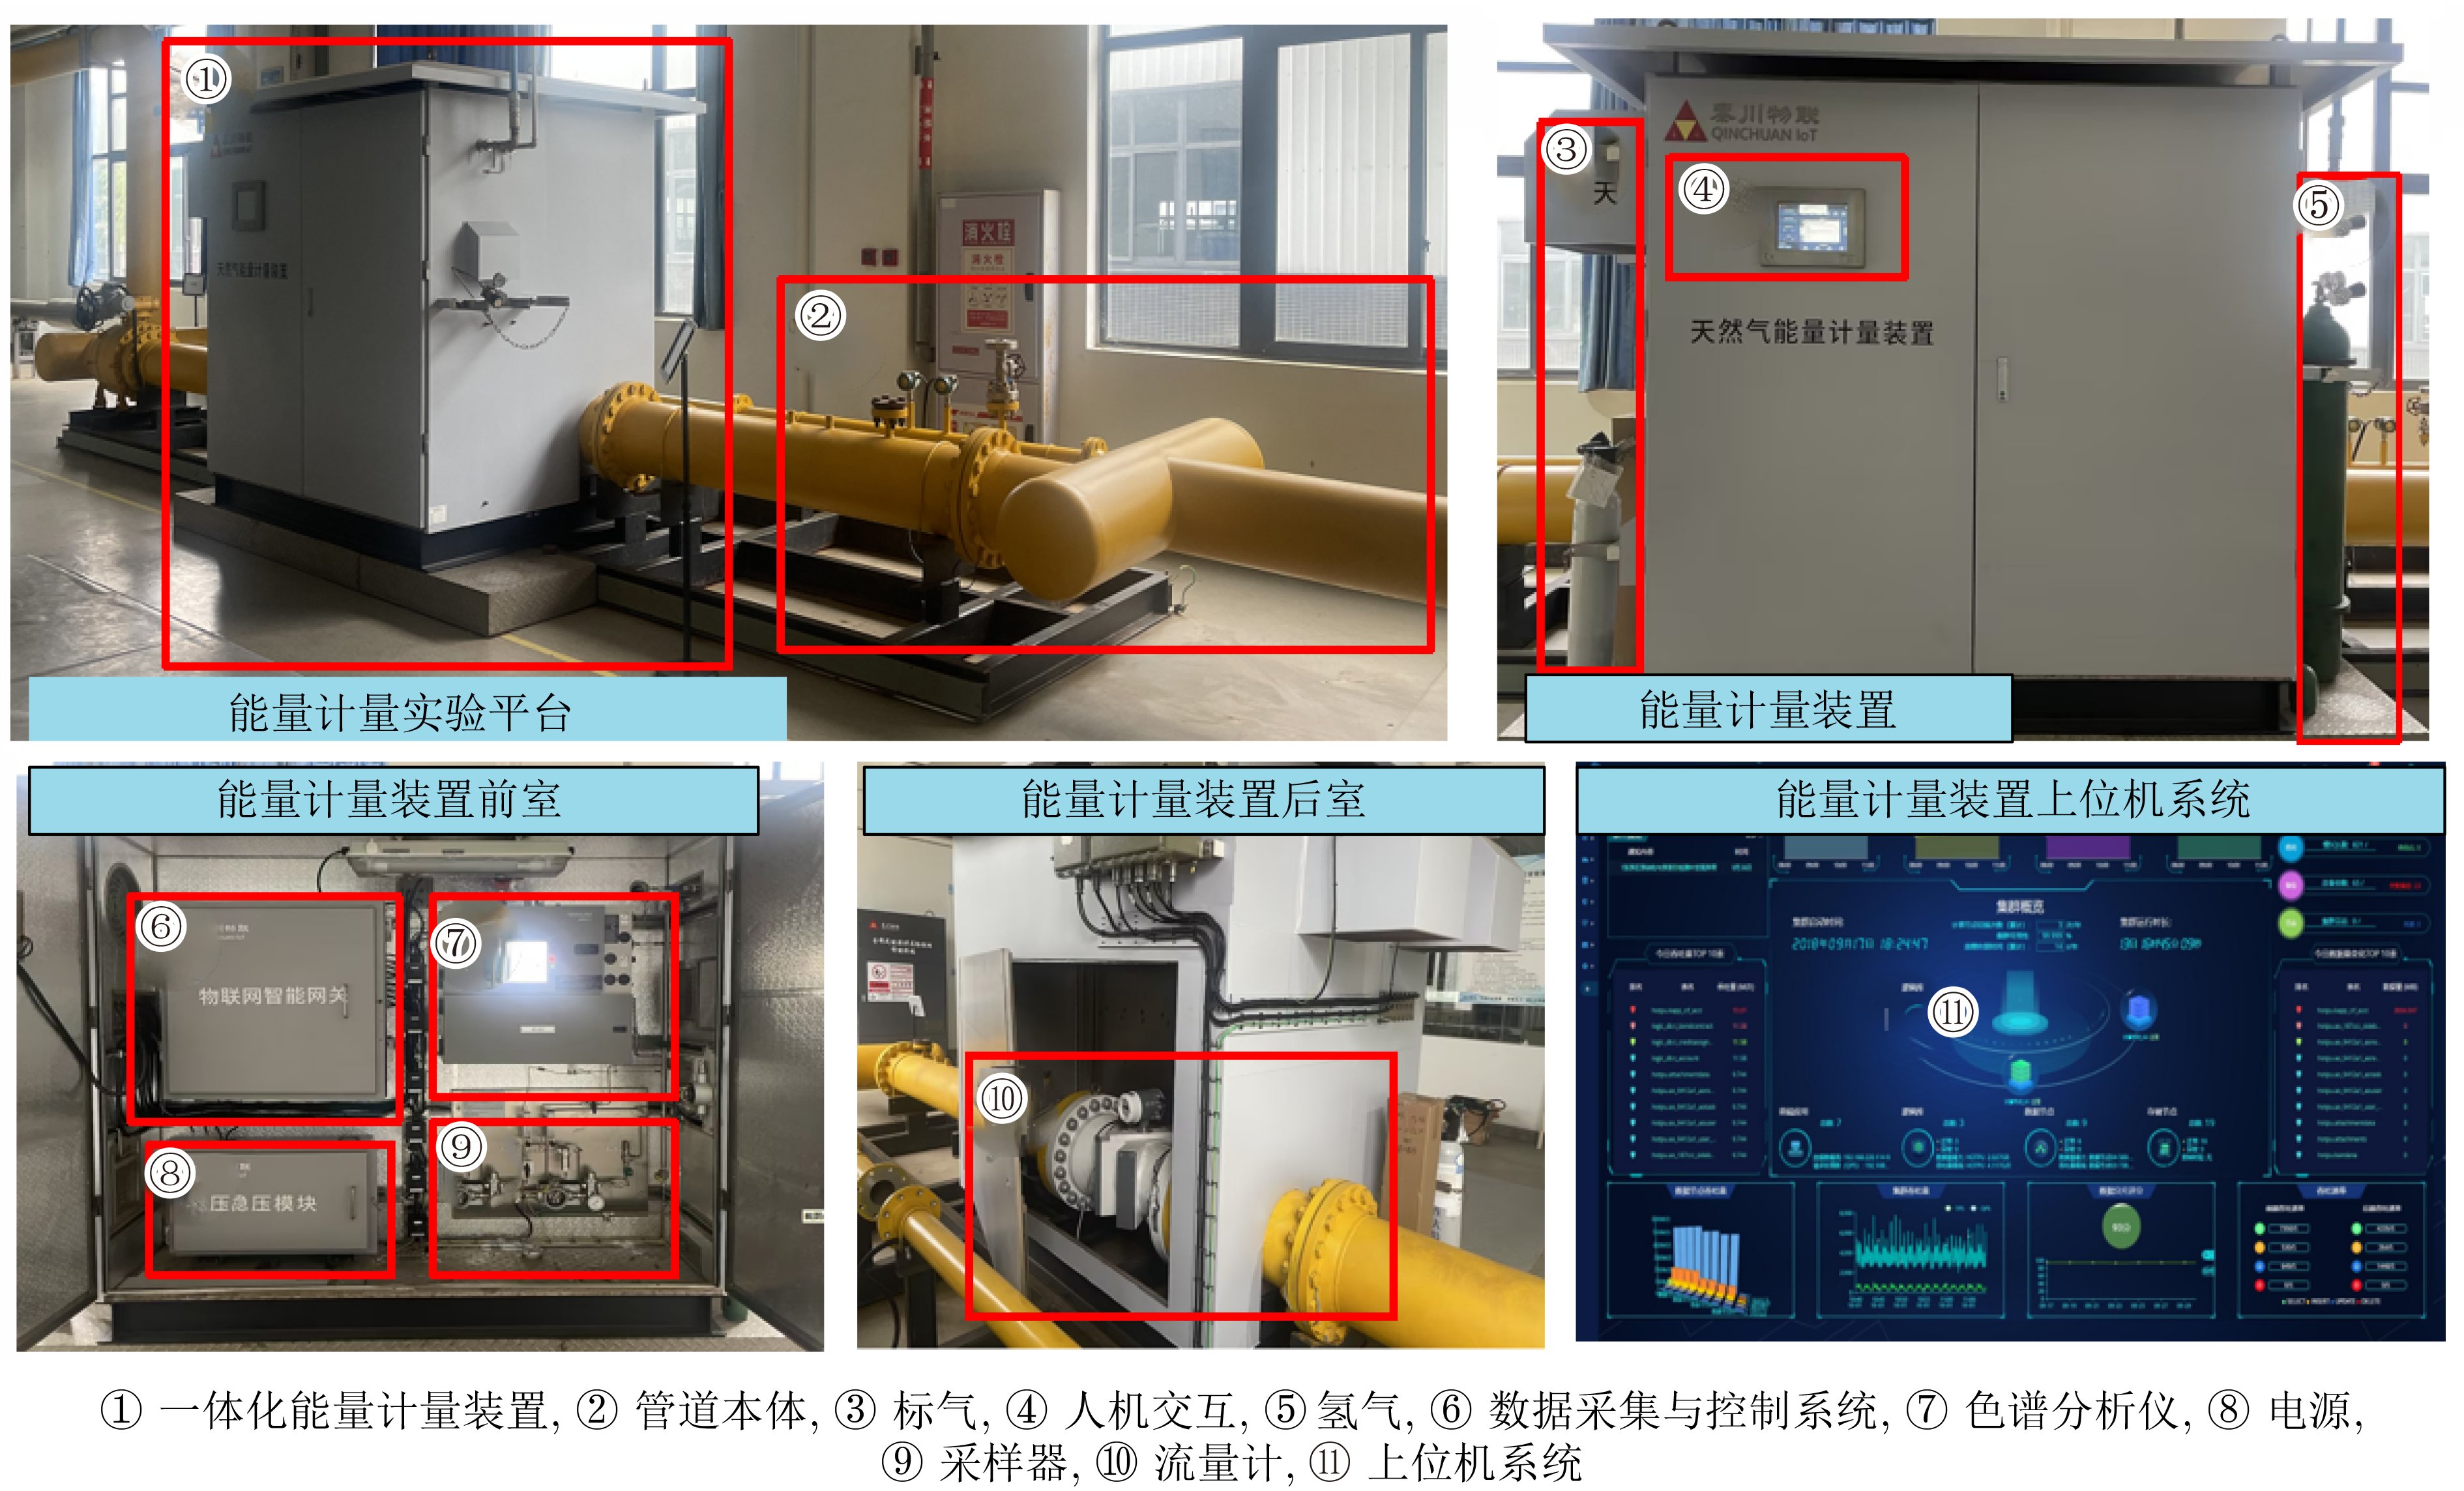
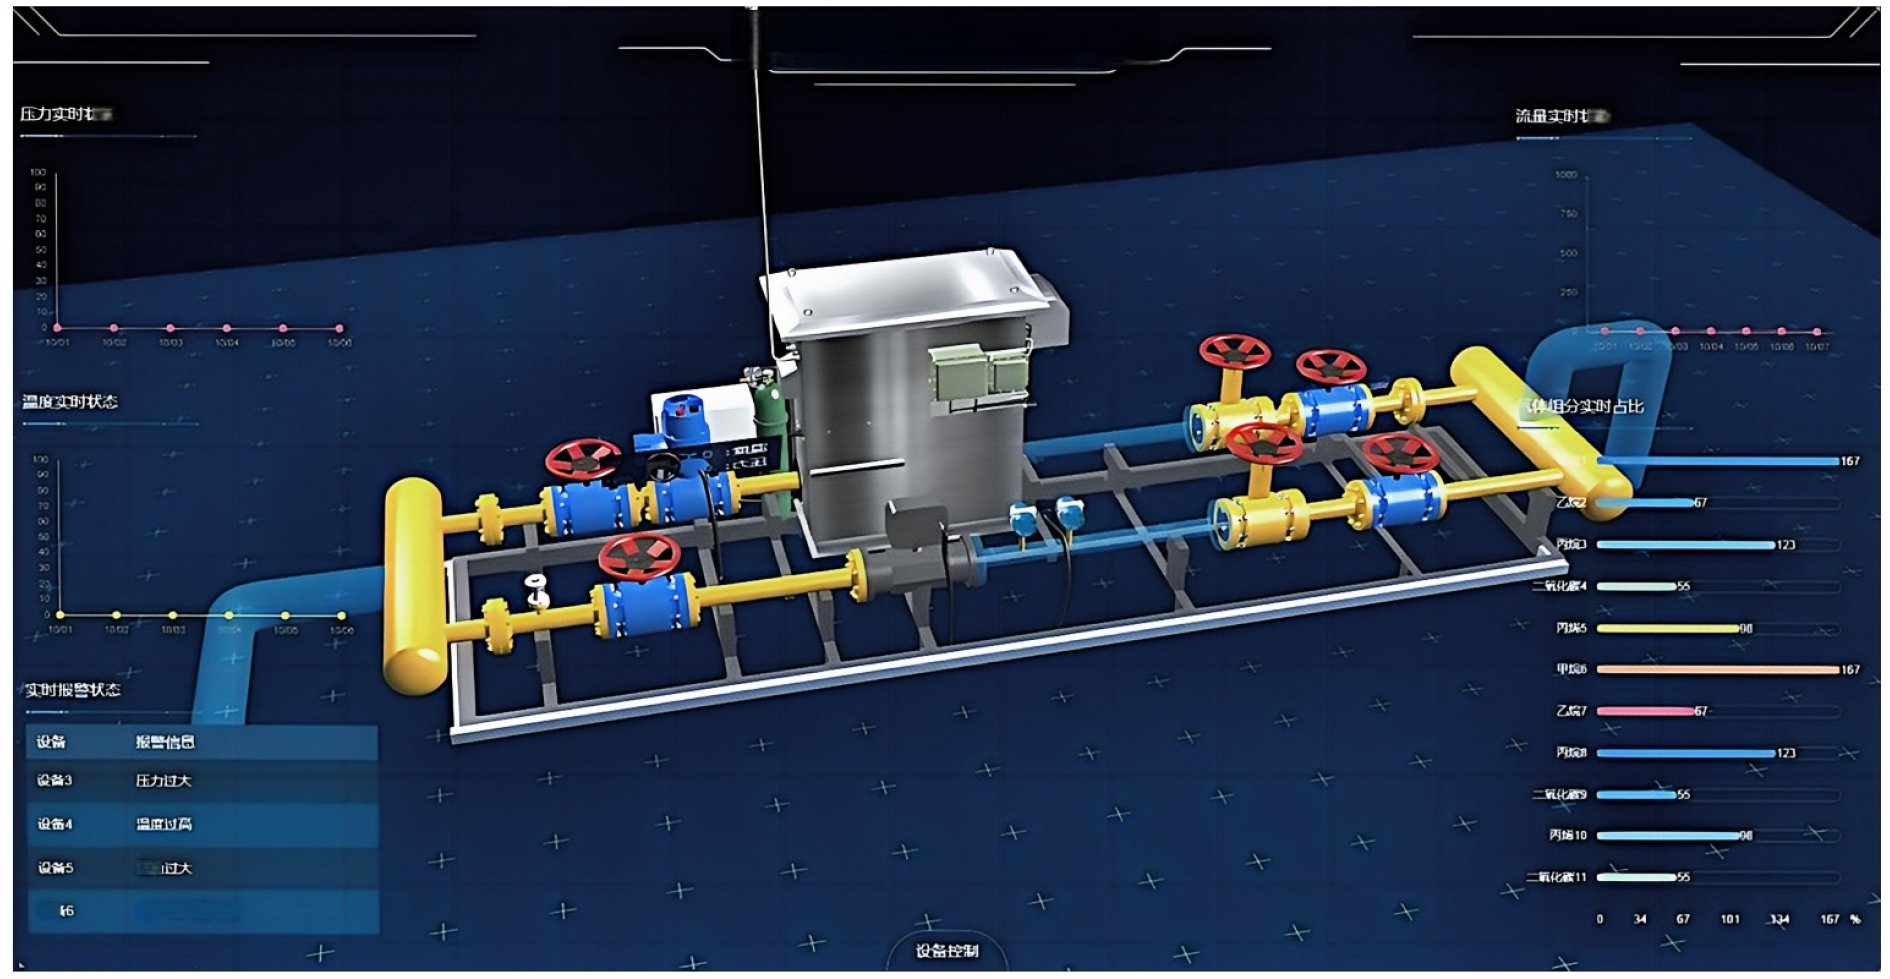
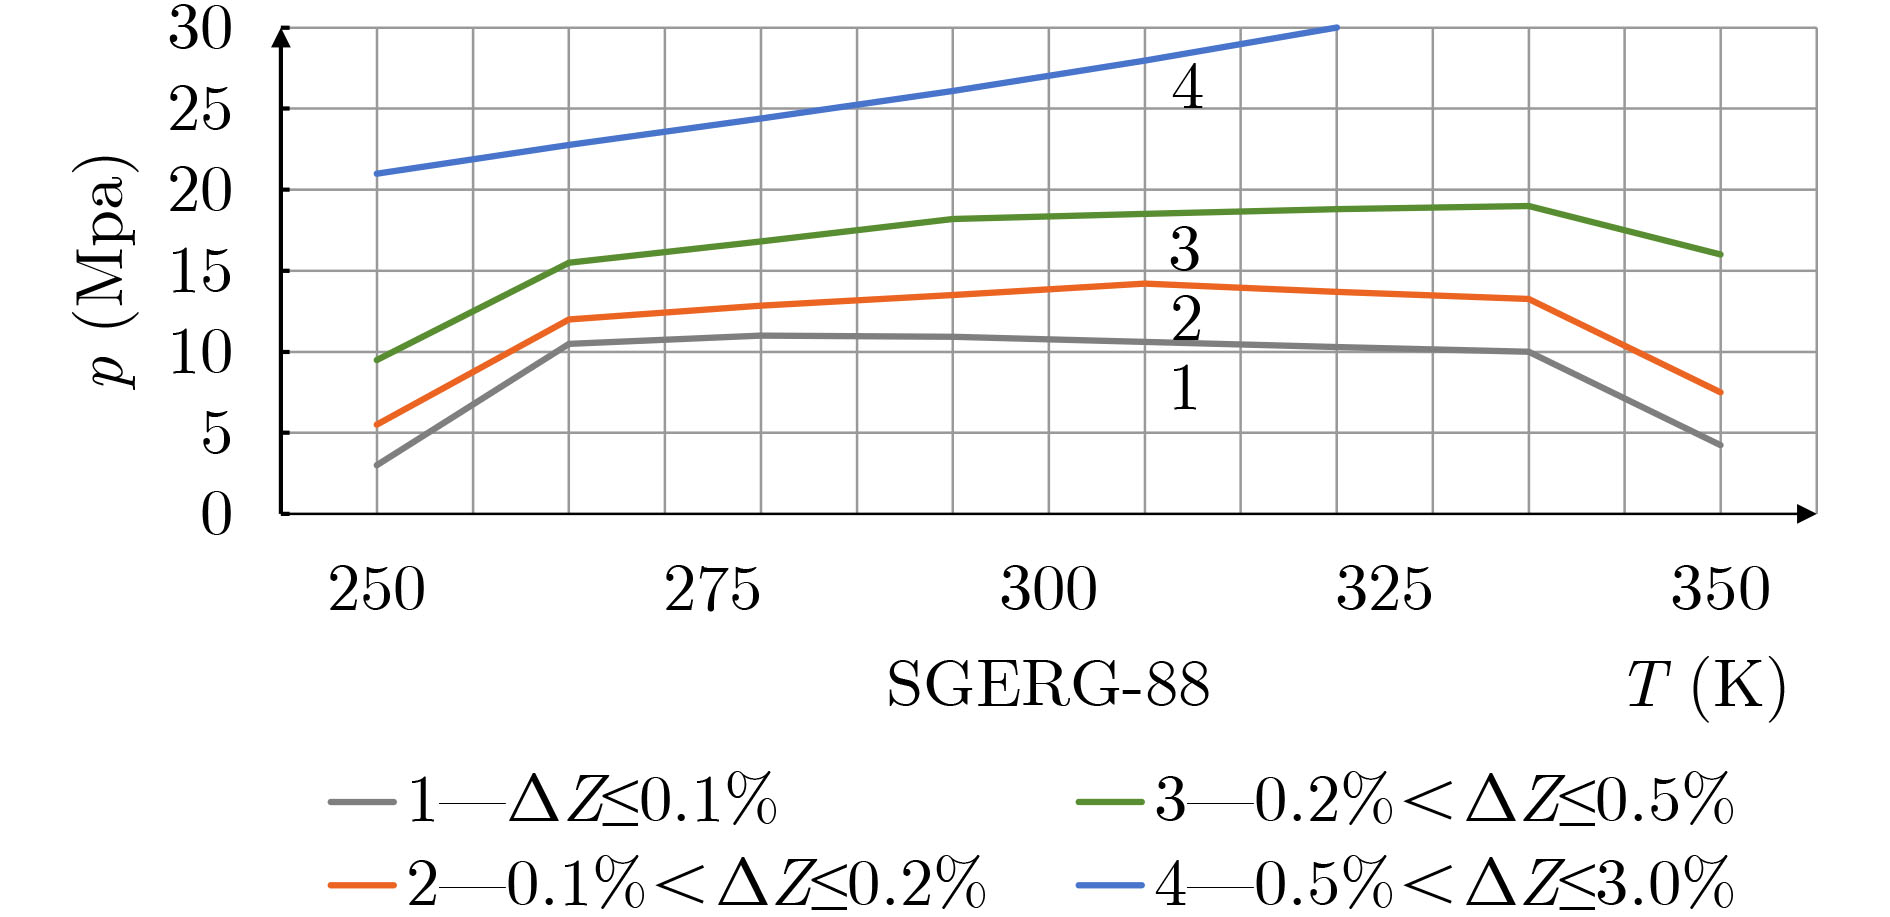
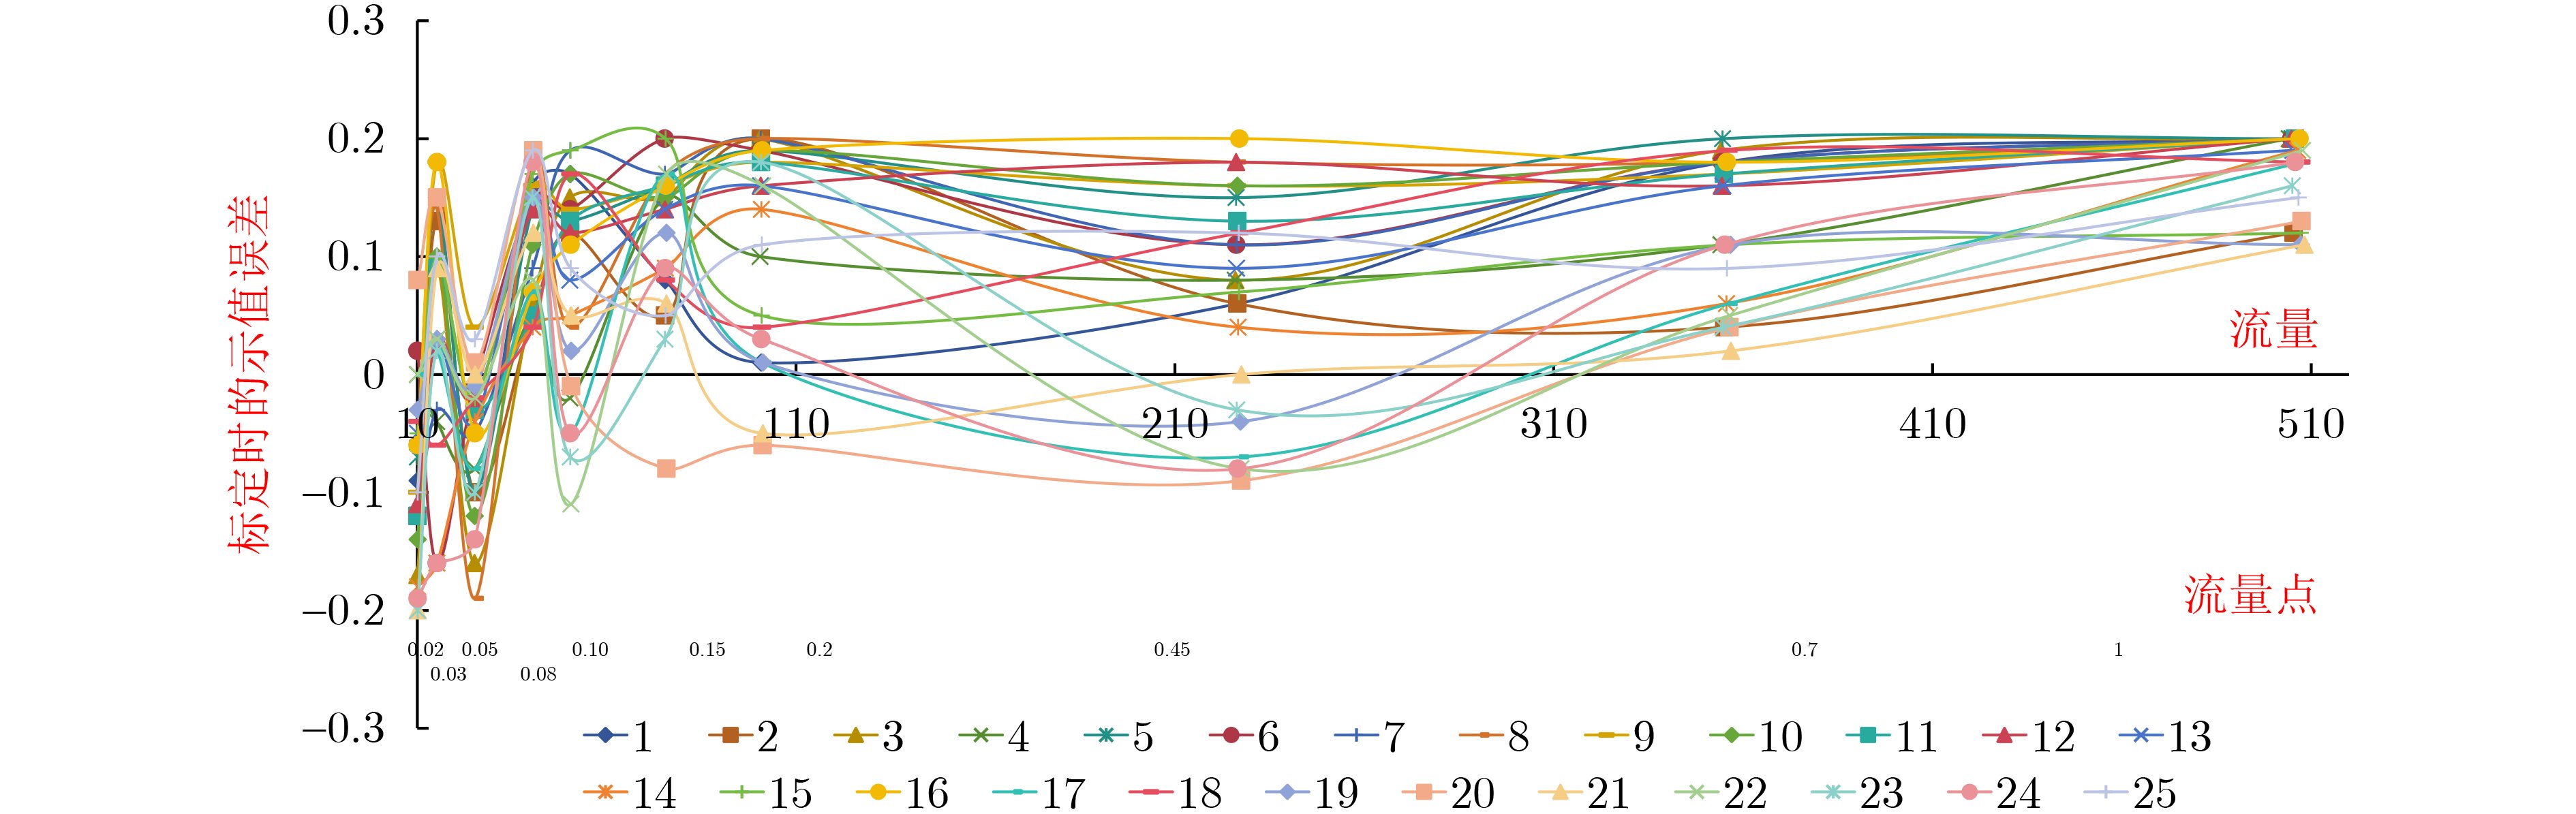
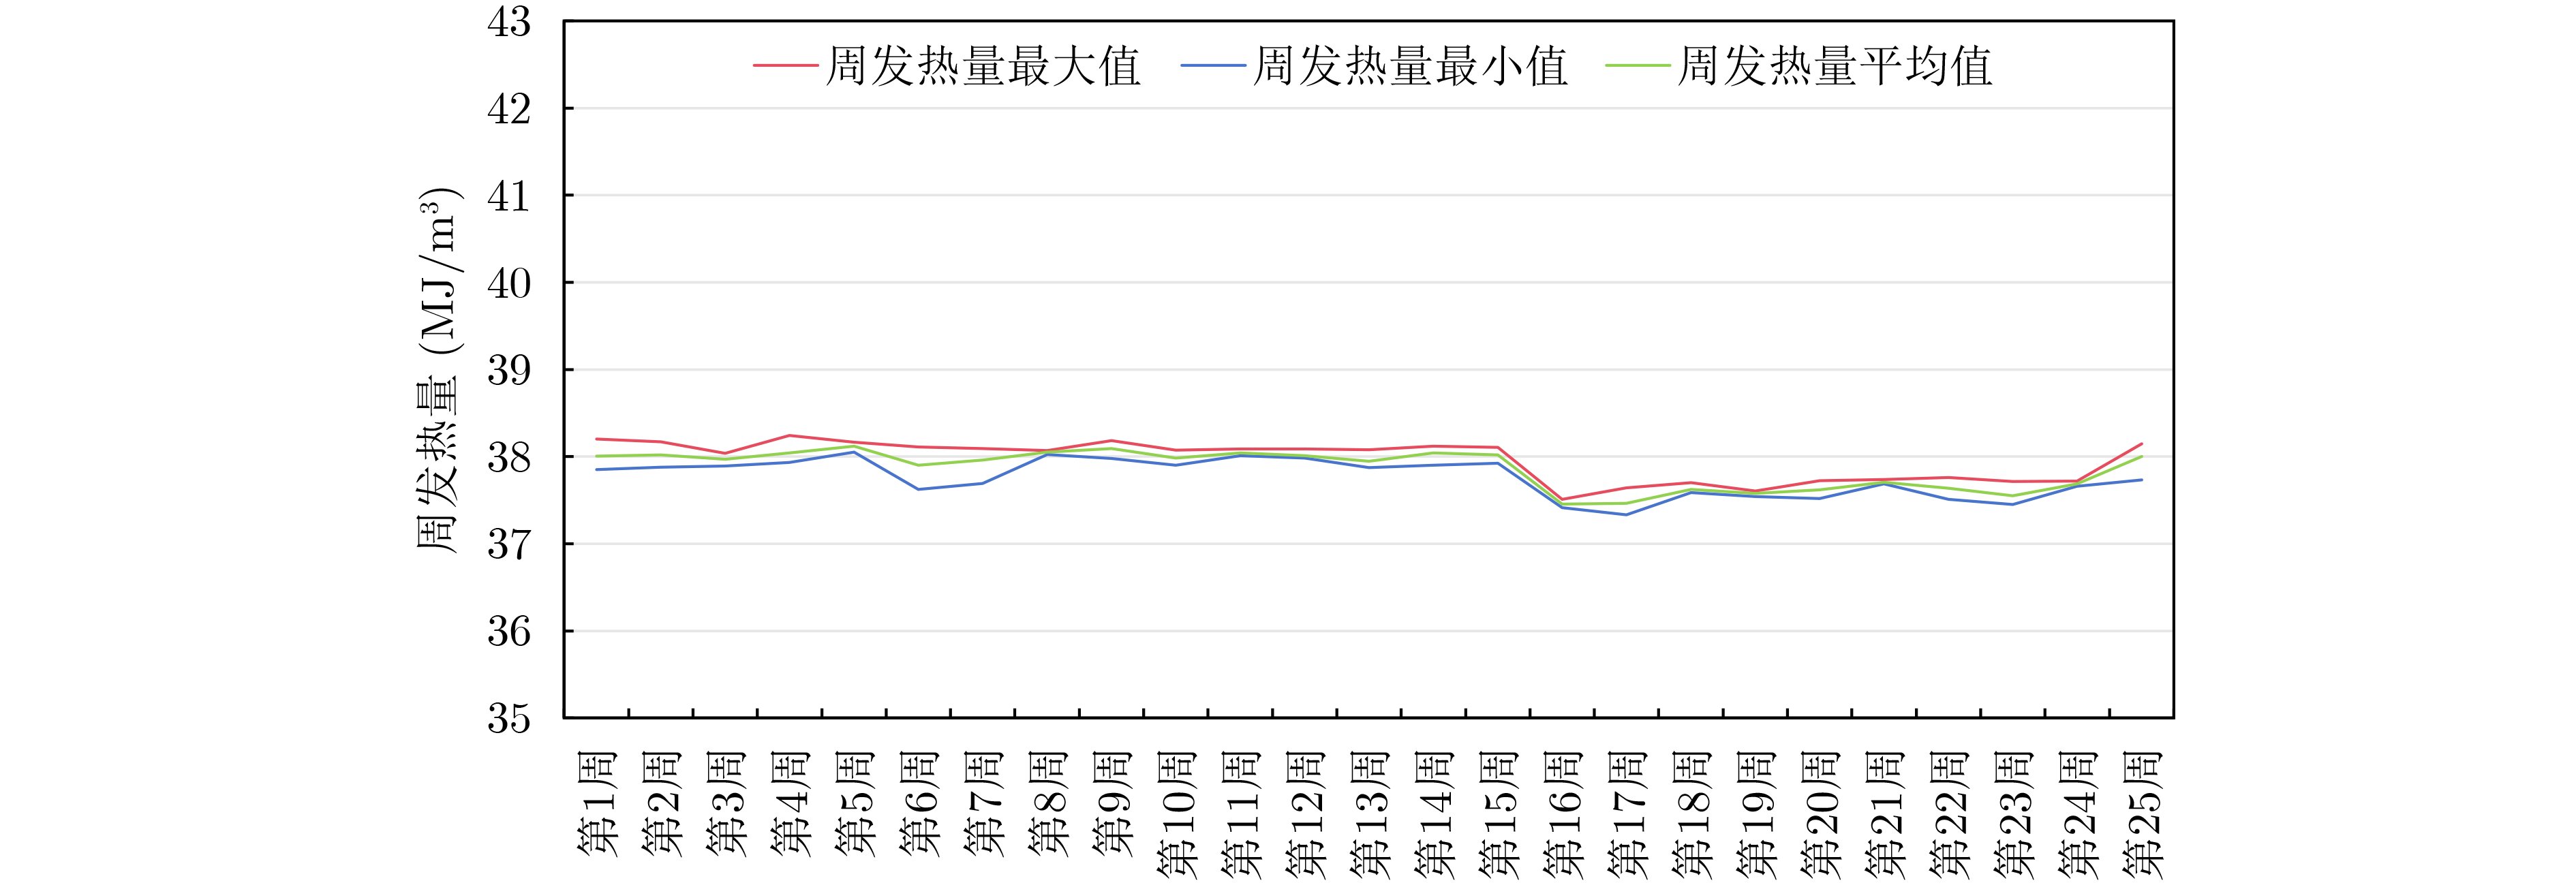
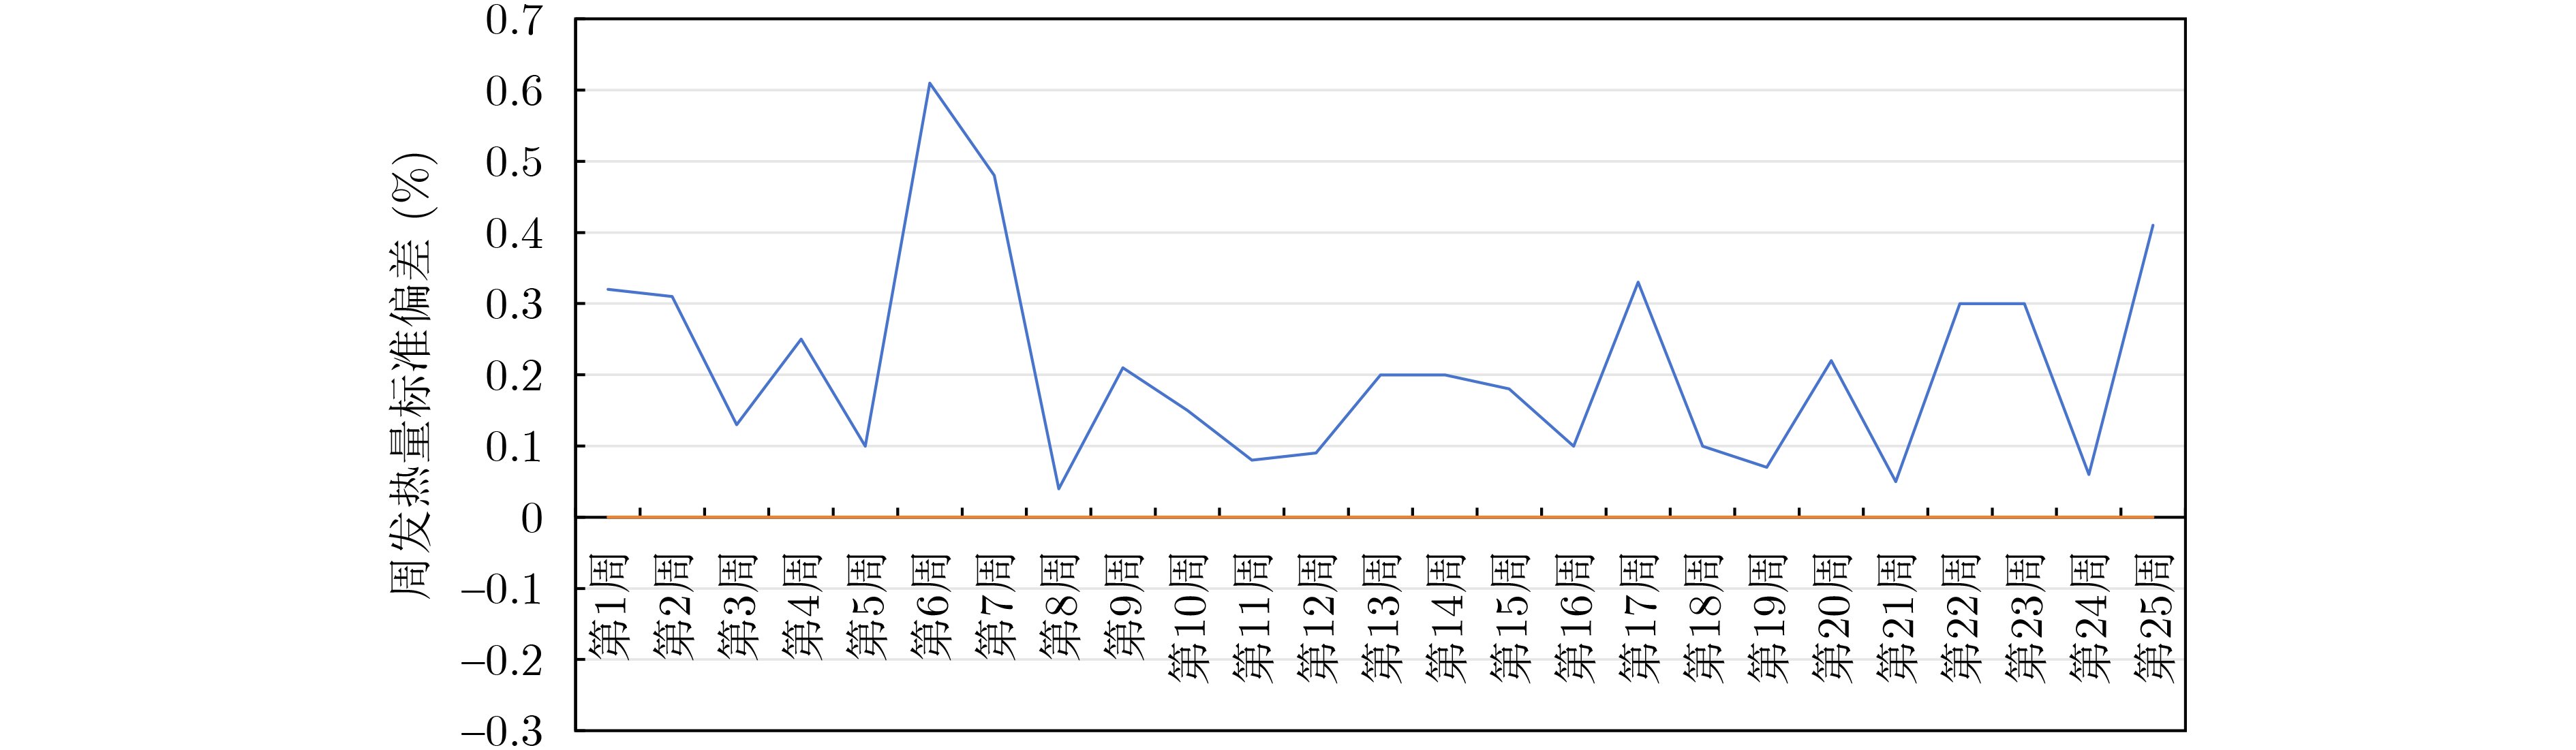
  Objective  Global natural gas consumption continues to increase at an average annual rate of 3.2%. A 0.1% reduction in energy measurement error can reduce trade disputes by approximately $750 million per year. Traditional studies mainly use indirect methods for energy measurement. Among these methods, chromatographic analysis and acoustic velocity correlation are the most widely used, but both have clear application limits. Chromatographic analysis has a low interference error, but it shows delayed dynamic response at high flow rates and limited dynamic calibration capability. It also has poor adaptability to multi-gas-source switching, requires manual calibration, and has high operation and maintenance costs. The lack of interoperability standards for energy networks further increases the difficulty of system integration. Acoustic velocity correlation provides a low-latency dynamic response for flow measurement, but it has a high interference error. This error may increase when the content of a single component changes, such as when the hydrogen content increases from 5% to 10%. The method may even fail under complex operating conditions, such as multi-gas-source mixing and dynamic pressure fluctuations. To address these issues, new mechanism-modeling-oriented methods have been developed. The two most representative directions are mechanism-modeling-driven methods and hybrid-modeling methods. Both methods combine multi-source data fusion with virtual-physical interaction to establish mechanism models that link flow rate, other parameters, and energy. These methods provide a new approach for accurate energy measurement, but new challenges remain. Mechanism-modeling-driven methods are usually based on static flow modeling using Computational Fluid Dynamics (CFD). However, their dynamic parameter updates are slow. They also have difficulty adapting to real-time operating-condition changes, rely on large labeled datasets, and have limited interpretability. Hybrid-modeling methods still face unresolved problems in collaborative optimization across multiple modules. In addition, existing studies lack support from industrial-grade verification platforms. These limits restrict their ability to solve the dynamic response delay, parameter identification difficulty, excessive physical simplification, and weak interference resistance of traditional natural gas energy metrology methods under complex conditions. Based on recent progress in mechanism-modeling-driven and hybrid-modeling methods, this study proposes an inverse-hybrid-modeling-driven digital twin system. The system introduces a Variational AutoEncoder (VAE)-based operating-condition feature extraction algorithm and a Dynamic Bayesian Network (DBN)-based parameter calibration mechanism. It also uses a Variational Expectation-Maximization (VEM) algorithm for offline calibration. The proposed system aims to improve the accuracy, adaptability, and interference resistance of natural gas energy metrology under complex operating conditions.  Methods   A natural gas energy metrology digital twin system based on inverse hybrid modeling is proposed. The system is built on a three-tier “algorithm-system-scenario” architecture. It integrates calorific value, flow, and energy mechanism models with multi-source real-time data streams. The VAE is used for unsupervised mining of operating-condition features. A parameter self-correction loop is then constructed by combining the DBN with VEM-based system calibration. Industrial-grade devices, including ultrasonic flowmeters and gas chromatographs, are integrated to ensure real-time data transmission and closed-loop control. The system covers key operating conditions, including dynamic pressure fluctuations, hydrogen-blended gas mixtures, and multi-gas-source switching. This design ensures strong adaptability between the model and practical applications. The system was continuously verified for 25 weeks on a full-scale industrial-grade experimental platform. The results show the Mean Time Between Failures (MTBF) of ≥4 100 h, energy measurement error of ≤0.25%, calorific value error of ≤0.12%, and flow indication error of ≤0.2%. The system also meets security requirements through industrial Ethernet encryption and hierarchical access control. It provides engineering support for intelligent pipeline-network optimization and standardized integration.  Results and Discussions  First, a multi-level hybrid modeling framework is established. Modular hybrid modeling is achieved through the algorithm-system-scenario three-tier architecture. Numerical methods combined with data are more flexible than purely analytical models and can represent complex multiphysics systems with fewer lumped physical parameters. These parameters may change during energy measurement under mechanical, energy, and hydrodynamic effects. The VAE and DBN are used to deeply integrate mechanism models with real-time data. This reduces the parameter synchronization delay to 3.8 s and supports fluid-acoustic co-simulation and rapid response under complex operating conditions, such as hydrogen-blended natural gas. Second, an integrated algorithm for inverse hybrid modeling and system calibration is proposed. By incorporating the VAE, DBN, and VEM algorithm, the inverse hybrid modeling algorithm forms a self-supervised, adaptive intelligent system with an internal closed-loop operation. The VAE encoder compresses high-dimensional operating-condition data into low-dimensional feature vectors. This enables unsupervised feature extraction without large labeled datasets. Based on the learned internal data distribution, the VAE can also generate perturbed data similar to the input data. These data are used to simulate abnormal operating conditions and verify interference resistance. The DBN constructs a continuous “prior-evidence-posterior” iterative cycle to support system self-correction and adaptive response to operating-condition changes. The VEM algorithm compensates for systematic errors that are difficult for the DBN to capture, thereby overcoming the limits of traditional static models.  Conclusions  This study describes and validates a hybrid digital twin system that combines experimental data-driven methods with physical models. The system successfully simulates the physical characteristics of natural gas energy metrology. A full-scale test platform was constructed, and the main system parameters were validated using experimental measurement data and compared with industry benchmarks. Each independent module in the algorithm-system-scenario three-tier hybrid modeling architecture, including calorific value measurement, flow calculation, and energy conversion, was continuously verified for 25 weeks. The results confirm strong consistency between model predictions and actual measurements. On the natural gas energy metrology digital twin experimental platform, systematic validation was performed for three core functions: flow measurement under dynamic conditions, multi-component calorific value determination, and energy accumulation. The results show that the output of the digital twin model matches the physical device measurement data with an accuracy of more than 99.5%. Under complex operating conditions, such as pressure pulsations and hydrogen-blended gas mixtures, the system maintains the measurement error within 0.5%. This performance is better than that of traditional methods and meets the Class A accuracy requirements for natural gas measurement. By introducing a multi-tier hybrid modeling framework, this study addresses the parameter identification difficulty and excessive physical simplification of traditional natural gas energy metrology methods. The integration of the VAE, DBN, and VEM algorithm enables unsupervised feature extraction under complex operating conditions and adaptive calibration of model parameters. This reduces dependence on prior physical knowledge and large labeled datasets. The experimental results show that the proposed method maintains high precision and strong stability under complex scenarios, including pressure pulsations and hydrogen-blended gas mixtures, where traditional models have difficulty providing accurate descriptions.
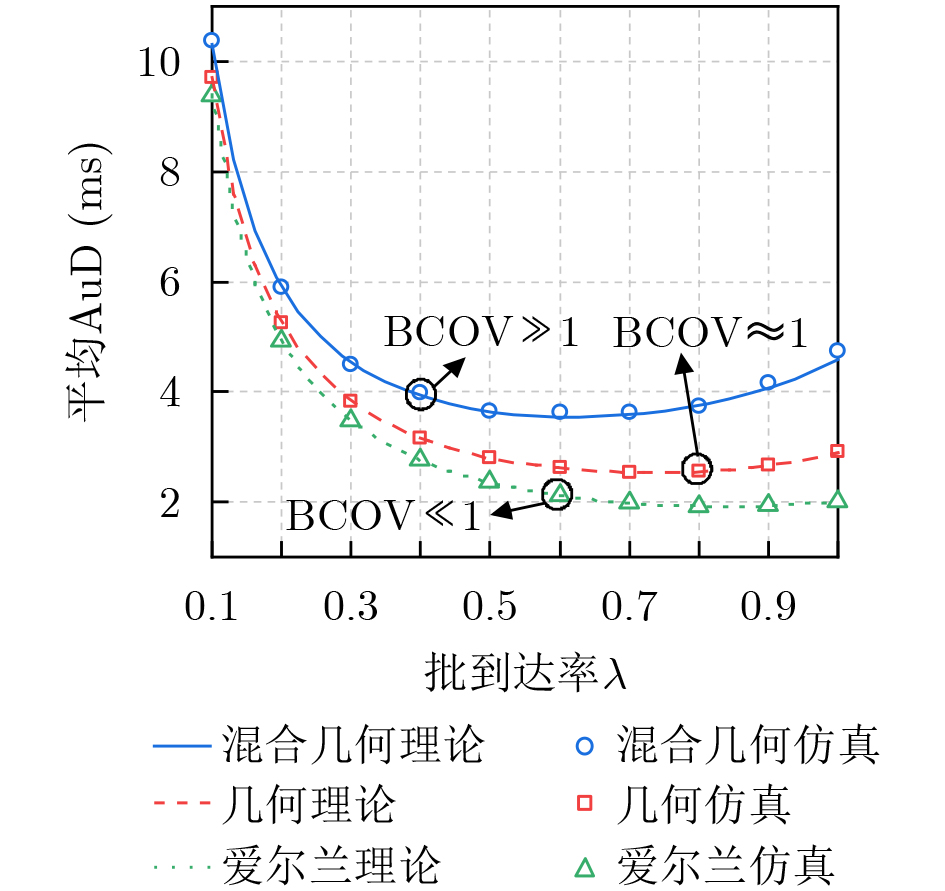
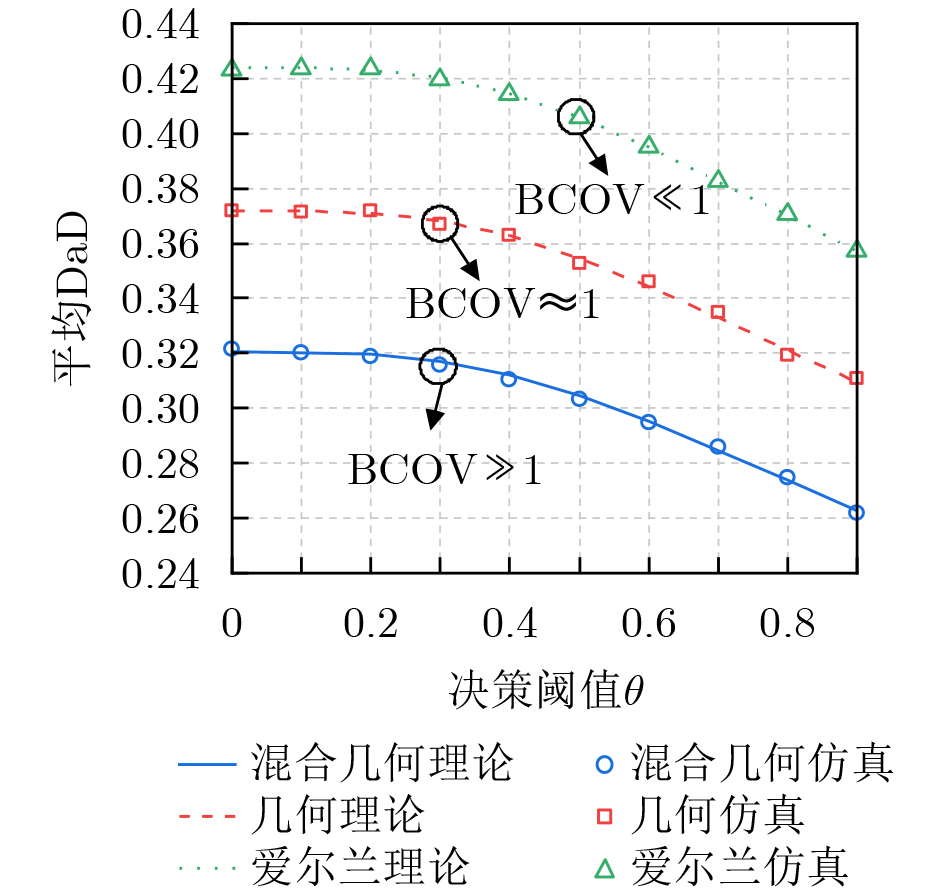
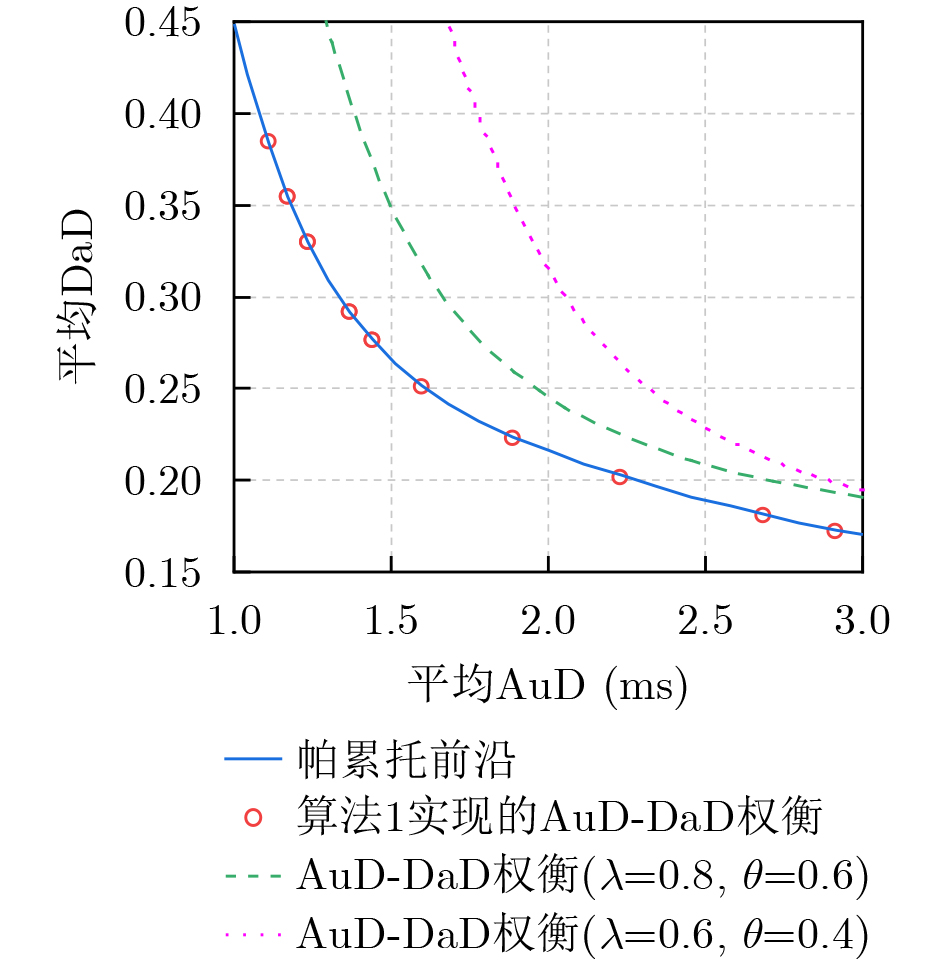
Analysis of Age upon Decisions and Distortion at Decisions in IoT Status Update Systems with Batch Arrivals
LIU Lei, JIN Wenkai, ZHANG Qingqing, LI Yuzhou, JIANG Fan
2026, 48(9): 3848-3857. doi: 10.11999/JEIT260359
Abstract:
  Objective  The rapid development of the Internet of Things (IoT) makes the timely transmission and processing of status updates essential for modern systems, where information freshness at decision epochs plays a critical role. In many IoT applications, such as smart grid fault detection and Industrial Internet of Things (IIoT) cluster monitoring, status updates typically arrive in batches rather than individually. However, most existing studies on Age of Information (AoI) assume single-update arrivals and therefore cannot accurately characterize the queueing dynamics caused by batch arrivals. Besides information freshness, distortion at decision epochs is another key factor because it directly affects decision quality. A fundamental tradeoff therefore exists between information freshness and distortion. Waiting for more complete status update information allows more completed status updates to be incorporated into joint estimation, but increases queueing and transmission delays, thereby reducing information freshness. In contrast, triggering decisions earlier reduces delay but increases distortion because fewer completed status updates are available for joint estimation. To address this problem, this paper investigates the tradeoff between information freshness and distortion in an IoT status update system with batch arrivals by adopting Age upon Decisions (AuD) and Distortion at Decisions (DaD) as performance metrics. Analytical expressions for the average AuD and average DaD are derived under a general batch-size distribution. Furthermore, for the typical case of geometrically distributed batch sizes, an alternating iterative optimization algorithm is developed to jointly optimize the batch arrival rate, average batch size, and decision threshold, thereby minimizing the weighted sum of the average AuD and average DaD. The results provide theoretical insight and practical guidance for the design of IoT status update systems with batch arrivals.  Methods  Information freshness and distortion at decision epochs are analyzed for an IoT status update system with batch arrivals. AuD and DaD are adopted to quantify information freshness and distortion, respectively. Based on queueing theory, analytical expressions for the average AuD and average DaD are derived under a general batch-size distribution. A typical case with geometrically distributed batch sizes is then investigated. An alternating iterative optimization algorithm is further developed to jointly optimize the batch arrival rate, average batch size, and decision threshold to minimize the weighted sum of the average AuD and average DaD.  Results and Discussions  Simulation results validate the theoretical analysis. The average AuD exhibits a nonmonotonic trend as the batch arrival rate increases, first decreasing and then increasing. In addition, the Batch-size Coefficient Of Variation (BCOV) has a significant effect on the average AuD, with a smaller BCOV providing better information freshness performance. Under high-load conditions, queue backlogs become more severe, and stochastic fluctuations in batch arrivals have a greater effect on the queueing process. This increases service-time variability and amplifies the effect of BCOV on the average AuD (Fig. 2). As the average batch size increases, the system queue length and queueing delay increase, leading to a larger average AuD. At the same time, the decision control unit can utilize more completed status updates for joint estimation, thereby reducing the average DaD (Fig. 3). Moreover, the average DaD decreases as the decision threshold increases because more completed status updates are incorporated into the joint estimation process, improving estimation accuracy. A larger BCOV also increases the number of completed status updates available for joint estimation and therefore further reduces the average DaD (Fig. 4). The optimization results show that the solutions obtained by the proposed algorithm lie on the Pareto frontier, demonstrating its effectiveness. By comparison, fixed batch arrival rates and decision thresholds produce performance that is considerably farther from the Pareto frontier, demonstrating the advantage of jointly optimizing system parameters (Fig. 5).  Conclusions  This paper investigates an IoT status update system with batch arrivals by adopting AuD and DaD to quantify information freshness and distortion, respectively. Analytical expressions for the average AuD and average DaD are derived under a general batch-size distribution. For the typical case of geometrically distributed batch sizes, an alternating iterative optimization algorithm is developed to jointly optimize the batch arrival rate, average batch size, and decision threshold, thereby minimizing the weighted sum of the average AuD and average DaD. Simulation results verify the theoretical analysis and reveal the effects of the batch arrival rate, average batch size, and decision threshold on the average AuD and average DaD. The results also demonstrate that the proposed low-complexity algorithm effectively identifies Pareto-optimal solutions for the AuD-DaD tradeoff. This study considers only the batch arrival characteristics of status updates. Future work will incorporate batch service mechanisms to further examine their effects on the tradeoff between AuD and DaD. Flexible decision mechanisms can also be developed to achieve adaptive AuD-DaD tradeoffs according to the heterogeneous requirements for information freshness and distortion across applications with different batch characteristics.
Co-Frequency Interference Analysis and Dynamic Simulation Validation of Satellite-Direct-to-Device Systems Against Terrestrial IMT Networks in Cross-Border Scenarios
LIU Quan, ZHAO Weisong, XIAO Na, SONG Yanjun, ZHOU Meng, ZHANG Zhili, WANG Jinhai, WANG Lichong
2026, 48(9): 3858-3870. doi: 10.11999/JEIT260263
Abstract:
  Objective   Satellite-Direct-to-Device (SD2D) systems that reuse terrestrial IMT spectrum may generate harmful downlink interference to incumbent IMT networks in neighboring administrations, particularly in cross-border deployments where SD2D downlinks overlap the receive bands of both IMT user equipment (UE) and IMT Base Stations (BSs). A practical coexistence methodology is therefore required to (1) translate IMT receiver protection criteria into explicit Power Flux Density (PFD) and Equivalent Power Flux Density (EPFD) constraints and (2) validate these constraints using a dynamic simulation framework so that they can be converted into enforceable geographic coordination measures, such as minimum isolation distances. This study focuses on the dominant interference path, namely SD2D downlink interference to IMT receivers, and establishes a traceable workflow from deterministic protection limits to dynamic simulation validation and the corresponding minimum isolation distances.  Methods  A cross-border scenario is modeled in which Country A deploys an SD2D system and Country B operates a terrestrial IMT network. Two representative downlink frequencies, 1 995 MHz and 2 190 MHz, are evaluated for two representative Starlink configurations, Starlink-1 and Starlink-2. The IMT network is modeled using ITU-R- and 3GPP-compliant parameters, with an I/N protection threshold of –6 dB and a target percentile κ (baseline κ=99.5%) for both IMT UEs and BSs. Satellite transmit antennas follow the ITU-R S.1528 reference pattern, IMT BS receive antennas follow the ITU-R F.1336 sector pattern, and IMT UEs are modeled with omnidirectional antennas. A back-lobe blockage model is incorporated into both satellite and BS antenna patterns to account for rear-side shielding. Signal propagation follows the ITU-R P.619 model, using free-space path loss as the conservative baseline, while an optional clutter-loss term is incorporated through a clutter-occurrence probability. Deterministic protection limits are derived by calculating the maximum permissible aggregate PFD for IMT UE protection and the maximum permissible aggregate EPFD for IMT BS protection. A dynamic simulation framework then validates these limits and searches for the required minimum isolation distances (Fig. 4). Co-channel beam isolation angles are optimized using the C/I Complementary Cumulative Distribution Function (CCDF), and a segmented search algorithm determines the minimum UE- and BS-side isolation distances together with the corresponding κ-percentile PFD/EPFD statistics.  Results and Discussions  The deterministic analysis yields a maximum permissible aggregate PFD of –102.72 dBW/m2/MHz at 2 190 MHz for IMT UEs and a maximum permissible aggregate EPFD of –129.53 dBW/m2/MHz at 1 995 MHz for IMT BSs (Fig. 3). For Starlink-1, the C/I design criterion yields a minimum co-channel beam isolation angle pair of (12°, 12°) (Fig. 5). Dynamic simulation shows that, under the representative baseline configuration with an I/N threshold of –6 dB and κ=99.5%, the minimum isolation distances are 195 km for UE protection and 290 km for BS protection (Fig. 6, Fig. 7, and Table 4). The resulting coordination isolation distance is therefore 290 km, and the simulated κ-percentile PFD and EPFD agree with the deterministic protection limits, with a residual margin below 0.5 dB. For Starlink-2, the optimized co-channel beam isolation angles increase to (15°, 15°), and the corresponding minimum isolation distances increase to 272 km for UEs and 420 km for BSs under the same baseline configuration (Table 5). These baseline distances should be interpreted as representative values for the specified simulation configuration rather than unique, strictly converged results. Stability verification shows that, under different sampling intervals, simulation durations, and random seeds, the UE- and BS-side minimum isolation distances remain within 195~210 km and 290~300 km, respectively, for Starlink-1, and within 266~290 km and 370~420 km, respectively, for Starlink-2 (Table 7). Sensitivity analysis for Starlink-1 further indicates that the required minimum isolation distance is governed by the upper tail of the aggregate I/N distribution (Table 6). Increasing κ from 99.5% to 100% increases the UE- and BS-side minimum isolation distances from 195/290 km to 304/560 km. Clutter attenuation substantially reduces the UE-side minimum isolation distance, decreasing it to 173 km when the clutter-occurrence probability is 0.5, while producing little change in BS protection. Polarization reuse increases the UE- and BS-side minimum isolation distances to 222 km and 360 km, respectively, whereas increasing the number of co-channel beams to 16 increases the BS-side minimum isolation distance to 330 km. The minimum service elevation angle and the link establishment strategy are identified as the dominant operational factors. Changing the minimum service elevation angle from 10° to 35° changes the required UE- and BS-side minimum isolation distances from 340/460 km to 101/150 km, whereas replacing the Sat-MaxElevation strategy with the UE-MaxElevation strategy reduces them to 80/180 km.  Conclusions   The proposed workflow converts IMT receiver protection criteria into deterministic protection limits expressed as PFD and EPFD constraints and validates them using a dynamic simulation framework. Under an I/N threshold of –6 dB and κ=99.5%, the baseline and stability analyses jointly indicate representative UE- and BS-side minimum isolation-distance ranges of 195~210 km and 290~300 km for Starlink-1 and 266~290 km and 370~420 km for Starlink-2, rather than unique, strictly converged values. Sensitivity analysis further shows that κ only changes the statistical criterion used to extract tail events from the sample set, whereas clutter attenuation primarily benefits IMT UEs. In contrast, the minimum service elevation angle, polarization reuse, the number of co-channel beams, and the link establishment strategy reshape the worst-case interference geometry and can produce substantial, and sometimes non-monotonic, changes in the required minimum isolation distances. The proposed framework establishes a traceable link between IMT receiver protection criteria and enforceable border coordination measures.
Radar, Sonar,Navigation and Array Signal Processing
An Incremental Density-Based Clustering Method with TDOA Prior for Mobile Multi-Station Radar Signal Sorting
CHEN Jinli, FAN Yu, WANG Yanjie, ZHANG Jindong
2026, 48(9): 3871-3883. doi: 10.11999/JEIT260151
Abstract:
  Objective  Radar signal sorting is a core technology in electronic reconnaissance that aims to deinterleave and classify pulses from multiple radar emitters within dense, overlapping pulse streams. In practical reconnaissance missions, especially those employing mobile platforms such as aircraft, observation stations continuously change position, whereas radar emitters are typically stationary. The resulting variation in the relative geometry causes the Time Difference of Arrival (TDOA) of intercepted signals to evolve over time. Conventional multi-station radar signal sorting methods are generally developed under a static TDOA assumption and cannot effectively characterize this temporal evolution. Therefore, pulses from the same radar emitter are easily split into multiple clusters, resulting in cluster proliferation and degraded sorting performance. To address this problem, an Incremental Density-based Clustering (ICDC) method with TDOA prior information is proposed for mobile multi-station radar signal sorting. The proposed method exploits the temporal evolution of TDOA to improve sorting stability and accuracy in mobile multi-station scenarios.  Methods  The temporal evolution of TDOA in mobile multi-station scenarios is first analyzed, and the TDOA trajectory is approximated as a linear function of time to establish a linear prior state model. Online micro-clusters are then constructed from multi-station TDOA observations and aggregated into macro-clusters according to their spatiotemporal intersection relationships. For each macro-cluster, an independent Kalman Filter (KF) model is established for each TDOA dimension. The state vector consists of the TDOA value and its rate of change, and recursive state estimation is performed to provide dynamic TDOA priors for newly arriving samples. During incremental clustering, a spatiotemporal joint scoring function is developed by incorporating KF prediction residuals as dynamic constraints. The matching criterion therefore evolves from a conventional density-based rule into a joint spatiotemporal consistency criterion, enabling more accurate assignment of newly arriving TDOA observations. To suppress cluster proliferation caused by TDOA evolution, a concept drift detection strategy based on macro-cluster center evolution is further employed. When concept drift is detected, posterior state estimates and covariance matrices generated by the KF are used to construct a dual Mahalanobis distance criterion that jointly evaluates state-distribution overlap and predicted TDOA overlap. Radar clusters produced by erroneous splitting are then adaptively merged under a 95% confidence threshold, effectively suppressing cluster proliferation caused by concept drift.  Results and Discussions  Simulation data are generated according to the radar parameters listed in Table 1. The multi-station TDOA corresponding to the same radar emitter exhibits an approximately linear evolution with respect to the Time of Arrival (TOA) at the observation station (Fig. 5), consistent with the proposed linear prior model. The ability of the proposed method to suppress radar cluster proliferation is first evaluated (Fig. 6). Radar emitters E4 and E9 are selected from the nine simulated emitters as representative cases because their TDOA trajectories are closely spaced and difficult to separate. Compared with Density-Based Spatial Clustering of Applications with Noise (DBSCAN), ICDC, cloud model-based sorting, and PointNet++ sorting, the proposed method more effectively suppresses radar cluster proliferation and maintains greater cluster stability. The overall sorting performance is further compared with the histogram method, grid-based clustering, DBSCAN, ICDC, cloud model-based sorting, and PointNet++ sorting. When the TOA measurement error ranges from 50 to 300 ns (Fig. 7), the proposed method consistently achieves a sorting accuracy above 96%, demonstrating strong robustness to measurement errors. Under different pulse interference rates (Fig. 8), the sorting accuracy also remains above 96%, indicating excellent interference robustness. The performance under different observation station velocities is further evaluated (Fig. 9). The proposed method maintains high sorting accuracy over the entire velocity range and still achieves approximately 94% accuracy at relatively high observation station velocities, demonstrating strong robustness under dynamic observation conditions. Radar cluster proliferation probability, missed-cluster probability (Fig. 10), and computational complexity (Table 2) are also analyzed. The results demonstrate that the proposed method achieves a favorable balance among sorting accuracy, cluster proliferation suppression, missed-cluster control, and computational complexity.  Conclusions  An ICDC method with TDOA prior information is proposed to address the degradation of radar signal sorting performance caused by TDOA evolution in mobile multi-station scenarios. By incorporating observation station motion into a dynamic TDOA state model and applying KF-based recursive prediction, the proposed method effectively suppresses radar cluster proliferation and erroneous cluster splitting caused by concept drift. The spatiotemporal joint criterion and the adaptive cluster merging strategy further improve robustness in complex dynamic environments. Simulation results demonstrate the effectiveness and stability of the proposed method for mobile multi-station cooperative reconnaissance. Future work will focus on real-time multi-parameter fusion-based sorting in complex electromagnetic environments. Furthermore, adaptive estimation and adjustment of the micro-cluster spatial intersection threshold, process noise covariance matrix, and measurement noise variance will be investigated to further improve performance in complex scenarios.
Heterogeneous Task Cooperative Scheduling Architecture for Networked Radar in Saturation Attack Air Defense Early Warning
YE Juhang, FANG Yuyuan, WEI Shaopeng, DUAN Jia, ZHANG Lei
2026, 48(9): 3884-3899. doi: 10.11999/JEIT260373
Abstract:
  Objective  To address the severe challenges posed by Unmanned Aerial Vehicle (UAV) swarms and intelligent loitering munitions, which generate massive, sudden, and heterogeneous early warning tasks during saturation attacks, a scalable networked-radar cooperative scheduling architecture is proposed. Existing architectures suffer from rigid dynamic coordination and insufficient capability for heterogeneous task scheduling. The non-convex cooperative scheduling problem is therefore decoupled into a multi-stage decision process consisting of multidimensional dynamic resource coordination and adaptive heterogeneous task scheduling. By incorporating a dispatch mechanism and Hierarchical Reinforcement Learning (HRL), a hybrid architecture integrating network-level centralized dynamic target allocation with node-level distributed heterogeneous task scheduling is developed. The architecture is implemented through an execution-redispatch cognitive closed loop, together with a Target Dispatch Algorithm (TDA) and a hierarchical command-and-scheduling method, to address multi-radar, multi-target, and multi-task scheduling in saturation attack scenarios.  Methods  The cooperative scheduling problem is first decoupled into dispatch-oriented network-level multidimensional resource coordination and hierarchical-command-based node-level adaptive heterogeneous task scheduling. An environment perception layer establishes a dynamic uncertainty model based on the Bayesian Cramér-Rao Lower Bound (BCRLB) and radar detection probability to jointly characterize target threat levels and radar operating states. The network coordination layer then adopts an adaptive weighted dispatch model based on comprehensive combat effectiveness to achieve dynamic target allocation while constructing a scalable execution-redispatch cognitive closed loop. To solve the resulting large-scale, nonlinear, multi-constraint generalized bipartite graph matching problem, the proposed TDA, an MMAS-based algorithm incorporating feasibility-rule-based constraint handling, is developed as a constructive solution. At the node level, Hierarchical Q-Learning (HQL) is implemented through a serial dual-Q-table implementation for distributed heterogeneous task scheduling. Using task proportion control as the hierarchical subgoal, the proposed method transforms upper-level operational intent into lower-level beam dwell scheduling, enabling adaptive, long-term, and interpretable execution of heterogeneous tasks with complex dependency relationships.  Results and Discussions  A simulated point-defense scenario against UAV swarm and loitering munition saturation attacks is established using three networked homogeneous S-band medium-range phased-array radars to counter 200 high-speed maneuvering targets. For network-level coordination, the proposed TDA replaces conventional penalty functions with a hierarchical solution framework based on feasibility-rule constraint handling. By exploiting prior model information, TDA achieves higher solution quality and faster convergence than the Max-Min Ant System (MMAS), Artificial Bee Colony (ABC), and Genetic Algorithm (GA) (Fig. 3). Although computational complexity increases, the execution time remains well within the dispatch cycle, improving solution quality with only millisecond-level computational overhead while satisfying real-time operational requirements (Fig. 4). For node-level scheduling, HQL employs hierarchical macro- and micro-level decisions to ensure policy consistency. Supported by an internal dense transfer-reward mechanism, HQL achieves higher learning efficiency and better long-term policy quality than Q-Learning (QL) and the Priority-Based Method (PBM) (Fig. 5). The hierarchical serial dual-Q-table framework maintains balanced task proportions, maximizes comprehensive combat effectiveness, and improves resource utilization (Fig. 6). Furthermore, comparisons of the target track-loss rate and mean tracking error show that HQL achieves the lowest mean tracking error by prioritizing high-quality tracking tasks, despite a moderately higher target track-loss rate, demonstrating superior long-term scheduling capability (Fig. 7).  Conclusions  The proposed hybrid architecture integrating network-level centralized dynamic target allocation with node-level distributed heterogeneous task scheduling effectively addresses the limitations of rigid dynamic coordination and insufficient heterogeneous task scheduling capability in existing networked radar systems. The proposed framework enables real-time cooperative scheduling of search, confirmation, and tracking tasks during large-scale, high-speed saturation attacks, thereby improving the operational capability of the air defense early warning system. Simulation results demonstrate improvements in applicable processing scale, environmental adaptability, long-term scheduling capability, scalability, and interpretability. Future work will explore online learning to reduce the discrepancy between offline training and online deployment and will further extend the architecture by integrating weapon-target assignment to support unified early warning and fire-control systems.
Decision Learning Correction Network: Fusion Classification of Hyperspectral Images and LiDAR Data
WANG Haoyu, LIU Nuofei, CHENG Yuhu, LIU Xiaomin, WANG Xuesong
2026, 48(9): 3900-3911. doi: 10.11999/JEIT260362
Abstract:
  Objective  HyperSpectral Images (HSI) and Light Detection And Ranging (LiDAR) provide complementary information for land-cover classification. HSI captures rich spectral information for material discrimination, while LiDAR provides elevation and structural information for spatial characterization. However, most existing fusion methods treat multimodal fusion as a one-shot static aggregation process, implicitly assuming that a fixed fusion strategy is applicable to all pixels and regions. This assumption is difficult to satisfy in complex remote sensing scenes, where class-boundary and cross-modal heterogeneous regions exhibit high information density but account for only a small proportion of samples (Fig. 1). To address this limitation, this paper proposes a Decision Learning Correction Network (DLCN) that reformulates static HSI-LiDAR fusion as a context-dependent sequential decision-making process.  Methods  The proposed DLCN consists of feature extraction, fusion decision learning, and classification. First, HSI and LiDAR are processed through two parallel branches to extract spectral and spatial features and elevation and structural features, respectively. The extracted features are then concatenated to form the current state and are fed into an Actor-Critic framework. The Actor network generates fusion actions to adaptively adjust modality contributions, while the Critic network evaluates the long-term value of each action for classification. To improve learning from difficult samples, a key-sample-oriented sampling module assigns higher sampling probabilities to samples with larger modal fidelity loss. Meanwhile, a modal fidelity constraint mechanism evaluates spectral fidelity, feature consistency, structural preservation, and resolution matching, and corrects destructive actions during fusion. Through this closed-loop framework, DLCN performs dynamic generation, evaluation, and correction of fusion actions, thereby producing high-quality fusion features for classification (Fig. 2).  Results and Discussions  Experiments are conducted on the Houston2013, Trento, and MUUFL datasets. DLCN achieves the highest Overall Accuracy (OA) of 97.85%, 99.58%, and 94.38% on the three datasets, respectively, outperforming CHNet, DSymFuser, mPMCL, MEDFN, S3F2Net, and MSAF. The classification maps demonstrate that DLCN effectively reduces misclassification in class-boundary, mixed land-cover, and structurally complex regions, producing results that more closely match the ground-truth maps across all three datasets (Figs. 3~5). Ablation studies further demonstrate that the value-guided policy optimization mechanism, key-sample-oriented sampling module, and modal fidelity constraint mechanism each improve classification performance. Compared with the baseline models, the complete DLCN consistently increases OA on Houston2013, Trento, and MUUFL, validating the effectiveness of the proposed decision-learning-correction framework. Time-step analysis shows that DLCN progressively improves classification accuracy while maintaining stable spectral-angle variation during sequential decision making (Fig. 6). Furthermore, DLCN achieves inference times of 1.32 s, 0.86 s, and 2.23 s on the three datasets, respectively, ranking first among the compared methods. These results indicate that the additional computation introduced by the Actor-Critic decision framework and modal fidelity constraint mechanism is effectively translated into improved classification performance without imposing excessive computational cost.  Conclusions  This paper proposes a DLCN for HSI and LiDAR fusion classification. Unlike conventional static fusion methods, DLCN formulates multimodal fusion as a sequential decision-making process and adaptively adjusts fusion strategies according to the local context. Its closed-loop framework enables fusion actions to be generated, evaluated, and corrected throughout the decision process, thereby producing high-quality fusion features for classification. Experimental results demonstrate that DLCN produces more accurate classification maps in heterogeneous remote sensing scenes, and the time-step analysis further confirms the stability of the sequential decision-making process. Future work will focus on more fine-grained feature representation and more robust policy optimization to improve model generalization in complex remote sensing scenes.
VT2R: Video- and Text-driven Method for Large-scale Millimeter-wave Radar Data Generation
DENG Kaikai, LING Yue, XING Ling, WU Honghai, ZHAO Dong, MA Huahong
2026, 48(9): 3912-3924. doi: 10.11999/JEIT260240
Abstract:
  Objective  Large-scale training data are essential for developing robust and generalizable deep learning models. However, existing Millimeter-Wave (mmWave) Radar data generation methods remain limited by the availability of training data. To address this limitation, this paper proposes VT2R, a video- and text-driven radar data generation method that generates large-scale, realistic radar point cloud data from video or text inputs. The proposed method addresses the key challenge of constructing accurate mappings from video and text to radar point cloud data.  Methods  VT2R consists of four components: a video feature encoding network, a text feature encoding network, a radar feature encoding network, and a data fitting and decoding network. The video and text feature encoding networks extract temporally consistent visual representations and semantically aligned textual features, respectively, whereas the radar feature encoding network learns the structural and dynamic characteristics of radar point clouds through hierarchical spatiotemporal modeling. In the data fitting and decoding network based on a Variational Autoencoder (VAE), multimodal features are mapped into a unified latent distribution space and decoded into radar point cloud sequences through reparameterization. During training, reconstruction loss, Kullback-Leibler (KL) divergence loss, and cross-modal similarity loss are jointly optimized.  Results and Discussions  The first radar point cloud dataset for reclining gesture recognition is constructed (Figs. 6 and 7). It contains five gesture categories collected from 32 participants, yielding a total of 14 400 samples. Experimental results demonstrate that VT2R achieves a recognition accuracy of 89.2% when trained using only generated radar point cloud data, representing a 33.88% improvement over RFGen (Figs. 10 and 11). When a small amount of real radar data is incorporated for joint training, the recognition accuracy further increases to 97.62%, exceeding RFGen by 21.48% (Figs. 10 and 12). Under different scenarios and experimental settings, VT2R achieves average recognition accuracies of 89.35% and 97.21% (Figs. 16~18). Additional experiments on different user postures show average recognition accuracies of 89.98% and 97.55% under the first and third experimental settings, respectively (Fig. 20). These results are consistent with those obtained in the reclining scenario, demonstrating strong robustness and cross-posture generalization.  Conclusions  This paper proposes VT2R, a radar data generation system that addresses the severe shortage of real radar training data for gesture recognition in reclining scenarios. The system integrates a video feature encoding network built on a vision-language pre-trained model, a text feature encoding network incorporating structured prompt templates, a hierarchical radar feature encoding network for sparse radar point clouds, and a VAE-based data fitting and decoding network to collaboratively generate large-scale, realistic radar point cloud data. The proposed framework also supports data augmentation using limited real radar data, providing effective data support for radar perception tasks. Future work will extend the framework to more complex gesture scenarios and multimodal data generation, providing higher-quality training data for emerging large-scale models.
Non-Orthogonal PSWFs Signal Detection Method Based on Adaptive Temporal-Spatial Feature Fusion
CHEN Wenhua, MAO Zhongyang, LU Faping, SUN Ye, GAO Yixuan
2026, 48(9): 3925-3934. doi: 10.11999/JEIT260024
Abstract:
  Objective   To address the demands of B5G/6G systems for high spectral efficiency and transmission reliability, Prolate Spheroidal Wave Functions (PSWFs)-based non-orthogonal modulation has attracted extensive research interest because of its strong time-frequency energy concentration. However, severe mutual interference among multiplexed PSWF signals degrades the performance of conventional detection methods in complex channel environments. Existing methods are limited by ideal channel assumptions or single-modal feature extraction and therefore cannot fully exploit the temporal and spatial information of PSWF signals or adapt to dynamic interference. An Adaptive Temporal-Spatial Feature Fusion (ATSFF) architecture is proposed for accurate and robust detection of non-orthogonal PSWF signals.  Method   A dual-path parallel framework is constructed to extract complementary temporal and spatial features. A Gated Recurrent Unit (GRU) network extracts deep temporal features and captures long-term dependencies from one-dimensional received signals. In the other path, one-dimensional signals are transformed into two-dimensional representations using the Gramian Angular Difference Field (GADF), and hierarchical spatial features are extracted using ResNet50. An adaptive probability-weighted fusion mechanism dynamically adjusts the contributions of the two feature branches according to their prediction uncertainty, thereby integrating complementary temporal and spatial information and improving detection robustness.  Results and Discussion   Simulations on a 32-class non-orthogonal PSWF signal dataset (Fig. 6) show that the proposed ATSFF method outperforms coherent detection, cross-term detection, Approximate Message Passing-Interleave Division Multiple Access (AMP-IDMA), and Temporal Multiple Sparse Bayesian Learning-Least Squares (TMSBL-LS) over the full Signal-to-Noise Ratio (SNR) range. t-SNE visualization (Fig. 4) shows that the fused features achieve better inter-class separation and greater intra-class compactness. At a bit error rate of 4 × 10⁻⁵, the proposed method achieves a gain of approximately 0.2 dB over cross-term detection (Fig. 6). Although ATSFF has higher computational overhead and lower real-time performance than conventional methods, its single-sample inference cost remains fixed after the network architecture is established, and GPU-based batch processing is supported. The method is therefore suitable for communication scenarios with high detection-accuracy requirements.  Conclusions   An adaptive temporal-spatial feature fusion method is proposed for non-orthogonal PSWF signal detection under severe mutual interference. Dual-path feature extraction is achieved using GRU and ResNet50, and a prediction-uncertainty-based adaptive probability-weighted fusion mechanism is used to integrate complementary temporal and spatial features. The simulation results demonstrate improved detection accuracy and robustness under complex channel conditions. The proposed method provides a feasible approach for high-accuracy detection of non-orthogonal PSWF signals.
Accelerated Broadband Electromagnetic Scattering Analysis via ACA-Driven Measurement Matrix Interpolation
WANG Zhonggen, WU Chenggang, NIE Wenyan, SUN Yufa
2026, 48(9): 3935-3942. doi: 10.11999/JEIT260392
Abstract:
  Objective  Broadband electromagnetic scattering analysis is widely used in radar target recognition, stealth technology, and microwave imaging. Although the Method of Moments (MoM) provides high computational accuracy, it incurs substantial computational and memory costs for electrically large or geometrically complex targets because full impedance matrices must be constructed and solved. Existing acceleration techniques, including the MultiLevel Fast Multipole Method (MLFMM) and Adaptive Cross Approximation (ACA), reduce the computational burden but still require repeated matrix construction and equation solving at every frequency during wideband analysis. Methods such as Asymptotic Waveform Evaluation (AWE), Model-Based Parameter Estimation (MBPE), and impedance matrix interpolation have been proposed to reduce this redundancy. However, AWE is prone to error accumulation over wide frequency bands, MBPE requires expensive initial sampling, and conventional impedance matrix interpolation still requires the computation of full high-dimensional impedance matrices at the sampling frequencies. More recently, Compressive Sensing Method of Moments (CS-MoM) and its extension, CS-HBFM, have improved wideband analysis by employing Hyper-Basis Functions (HBFs). By constructing Characteristic Mode Basis Functions (CMBFs) only once at the highest frequency, CS-HBFM eliminates repeated basis-function generation. Nevertheless, existing CS-HBFM methods rely on nondeterministic random or uniform sampling, require expensive large-scale matrix-vector products, and repeatedly reconstruct and solve impedance equations throughout the frequency sweep.  Methods  A CS-ACA-MMI framework is proposed for broadband electromagnetic scattering analysis by combining dual ACA decomposition with Measurement Matrix Interpolation (MMI). First, CMBFs are constructed at the highest frequency, and dominant HBFs are selected according to the Modal Significance (MS) criterion. ACA is then applied to the full impedance matrix to extract deterministic row indices corresponding to the dominant Rao-Wilton-Glisson (RWG) basis functions. These indices are reused throughout the frequency band, eliminating nondeterministic sampling and repeated index extraction. Second, four sampling frequencies are selected using Chebyshev-Lobatto nodes. Low-dimensional measurement matrices are constructed directly from the extracted row indices, avoiding the generation of full high-dimensional impedance matrices. The measurement impedance elements at the sampling frequencies are corrected according to the geometric distance, interpolated to the target frequency, and then restored to the actual measurement impedance elements, thereby eliminating repeated construction of measurement matrices during frequency sweeping. Third, ACA is applied to the far-field component of the interpolated measurement matrix, converting large-scale matrix-vector products into low-dimensional matrix multiplications. The near-field sensing matrix is obtained directly by multiplying the measurement matrix by the basis functions, enabling rapid construction of the complete sensing matrix. Finally, the dense linear system is transformed into an overdetermined system under the compressive sensing framework, and the least-squares method is used to reconstruct the current coefficients, from which the broadband Radar Cross Section (RCS) is calculated. The Root Mean Square Error (RMSE) is used to evaluate numerical accuracy. Three representative targets, namely a cylinder, a slotted cone, and an almond, are analyzed. Broadband RCS, numerical accuracy, total computation time, and single-frequency measurement-matrix memory consumption are compared with those obtained using MoM and CS-HBFM to validate the proposed framework.  Results and Discussions  Three numerical examples, including a perfect electric conductor cylinder, a slotted cone, and an almond, are used to validate the proposed CS-ACA-MMI framework. The ACA-extracted row indices are concentrated near geometric boundaries and structural junctions, demonstrating the physical validity of the deterministic sampling strategy (Fig. 2). Parametric studies show that appropriate ACA thresholds and four sampling frequencies provide the best balance between computational efficiency and numerical accuracy (Figs. 3~5). The broadband RCS predicted by the proposed framework agrees closely with the MoM results over the entire frequency band (Figs. 6~8), and the RMSE remains low, demonstrating high numerical accuracy. Compared with CS-HBFM, the proposed framework reduces the total computation time by 93.4% for the cylinder, 96.7% for the slotted cone, and 80.9% for the almond (Table 2). These improvements result from deterministic index reuse, MMI, and dual ACA acceleration, which substantially reduce the computational cost of broadband frequency-sweeping analysis.  Conclusions  A CS-ACA-MMI framework is proposed by integrating ACA with MMI for efficient broadband electromagnetic scattering analysis. The proposed framework eliminates repeated matrix construction and equation solving during frequency sweeping while overcoming the nondeterministic sampling strategy and the high computational and memory costs of conventional CS-HBFM. Dominant row indices extracted by ACA at the highest frequency provide a deterministic measurement-matrix construction strategy and a stable physical basis for broadband interpolation. By shifting the interpolation target from full impedance matrices to low-dimensional measurement matrices, the computational complexity and redundant matrix construction are substantially reduced. A second ACA decomposition further accelerates sensing-matrix construction by converting large-scale matrix-vector products into low-dimensional matrix multiplications. Numerical results demonstrate that the proposed framework achieves numerical accuracy comparable to that of MoM while reducing total computation time by more than 80% and decreasing single-frequency measurement-matrix memory consumption by up to 65%. Because only the measurement matrices at four sampling frequencies need to be stored, the overall memory requirement is further reduced.
A Noise Reduction Strategy via Coprime-Spacing Subarrays for Biodiversity Acoustic Indices
CHEN Lei, XU Zhiyong, ZHAO Zhao
2026, 48(9): 3943-3953. doi: 10.11999/JEIT260237
Abstract:
  Objective  Acoustic indices are widely used for rapid biodiversity assessment and have received increasing attention in soundscape ecology. However, most commonly used acoustic indices are sensitive to background noise. Traditional single-channel noise reduction methods, such as spectral subtraction, high-pass filtering, and threshold detection, are often used as preprocessing steps to improve acoustic index calculation. However, when anthropogenic interference overlaps with biological sound signals in both the time and frequency domains, the denoising performance of these methods decreases sharply. Microphone-array-based spatio-temporal adaptive whitening filtering provides a feasible approach for suppressing directional interference. However, its non-uniform two-dimensional spatio-temporal amplitude response and target self-cancellation during unconstrained interference cancellation can distort the time-frequency distribution of biological sound signals. This distortion causes acoustic index values to deviate from their noise-free ideal values. To address this problem, this study proposes a noise reduction strategy via coprime-spacing subarrays for biodiversity acoustic indices. The proposed method suppresses directional anthropogenic interference while preserving the time-frequency distribution structure of biological sound signals as completely as possible.  Methods  A microphone-array-based spatio-temporal adaptive whitening filtering strategy is proposed. It is combined with the Frequency-dependent Acoustic Diversity Index (FADI), which is insensitive to fluctuations in the two-dimensional spatio-temporal amplitude response of the array. A noise-robust acoustic index, termed Adaptive Interference Cancellation-FADI (AIC-FADI), is then developed. Specifically, a non-uniform linear array is constructed using three microphones to form two dual-element subarrays with coprime spacing. This design uses the high spatial resolution of wide-spacing arrays to narrow the null width in the interference direction. It also reduces the physical implementation difficulty and mutual coupling effects associated with small-spacing arrays, which arise from the ultra-wideband characteristics of biological sound signals. Spatio-temporal adaptive whitening filtering is then applied separately to each coprime-spacing subarray. Two-dimensional nulls are adaptively formed within the interference support region, thereby suppressing directional anthropogenic interference in the analysis data before index calculation. A frequency-dependent adaptive thresholding scheme is then used to obtain the binary time-frequency spectrum of each subarray output. This scheme reduces the effect of gain differences along the frequency axis for a given direction. The high spatial resolution of wide-spacing arrays and the interleaved spatial aliasing nulls in the spatio-temporal frequency responses of the two coprime-spacing subarrays are then used for pointwise maximum fusion of the two binary time-frequency spectra. This process reconstructs the binary time-frequency distribution structure of biological sound signals outside the interference support region. A single binary time-frequency spectrum is obtained, in which biological sound signals are largely preserved and anthropogenic interference is substantially suppressed. Finally, the proportions of time-frequency bins assigned a value of 1 in each frequency band are calculated and input into the entropy function following the Acoustic Diversity Index (ADI) framework, yielding the final AIC-FADI value.  Results and Discussions  Simulation results show that AIC-FADI maintains numerical robustness down to –15 dB Signal-to-Interference-plus-Noise Ratio (SINR) (yellow line in Fig. 5). It substantially outperforms the single-channel FADI baseline and the ADI-based variants without coprime-subarray fusion evaluated in this paper, including AIC-FADI-s, AIC-FADI1, and AIC-FADI2. Field experiments further confirm that the proposed spatio-temporal adaptive whitening filtering effectively suppresses wideband interference in complex soundscapes and improves the SINR of the analyzed recordings. This improvement allows some weaker biological sound signals to exceed their corresponding frequency-dependent adaptive thresholds, thereby reducing missed detections of target signals. In addition, pointwise maximum fusion of the binary time-frequency spectra from the two coprime-spacing subarray outputs further reduces missed detections in AIC-FADI (Fig. 8). However, the field experiments also show that the interference suppression performance of AIC-FADI decreases for highly time-varying interference components.  Conclusions  This study addresses the reliable calculation of acoustic indices in complex soundscapes where directional anthropogenic interference overlaps with biological sound signals in both the time and frequency domains. A noise reduction strategy via coprime-spacing subarrays is proposed, and the noise-robust AIC-FADI method is developed. Simulation and field recording results show that spatio-temporal adaptive whitening filtering on each coprime-spacing subarray, followed by pointwise maximum fusion, provides both wideband interference suppression and target information fidelity in complex soundscapes with strong interference. AIC-FADI maintains numerical robustness down to –15 dB SINR and outperforms the single-channel FADI baseline and ADI-based variants without coprime-subarray fusion. The proposed method provides a feasible technical solution for extending the practical application scenarios and spatio-temporal coverage of biodiversity acoustic indices in human-dominated areas. However, this study considers only directional interference that is relatively stable or slowly time-varying. Its suppression performance decreases for highly time-varying or uncorrelated noise components. These issues should be addressed in future work using more targeted signal processing techniques to further improve acoustic index robustness in highly complex acoustic environments.
Image and Intelligent Information Processing
A General Evaluation Framework for Mission Planning Algorithms for Remote Sensing Satellite Constellations
LI Jinfei, YU Xiaogang, TIAN Jing, HE Haochen, XING Xiangwei, ZHANG Xiaohan
2026, 48(9): 3954-3965. doi: 10.11999/JEIT260335
Abstract:
  Objective  The rapid growth in remote sensing satellite constellations has shifted mission planning from single-satellite static scheduling to large-scale dynamic coordination across heterogeneous constellations. However, evaluation methods have not kept pace with algorithm development. Existing studies often rely on private datasets, simplified metrics centered on Completion Rate, and idealized simulations that ignore realistic constraints, such as attitude maneuvers, illumination conditions, and dynamic task insertion. These limitations prevent fair cross-paper comparison and slow engineering application. To address this gap, this paper proposes the Remote Sensing Constellation Mission Planning Benchmark (RSCMP-Bench), a general, open, and reproducible evaluation framework. It is designed as a unified benchmark for the community, similar to ImageNet in computer vision and General Language Understanding Evaluation (GLUE) in Natural Language Processing (NLP).  Methods  RSCMP-Bench consists of three components. First, the multi-scenario standard task library contains 300 standardized scenarios at three difficulty levels: Low, Medium, and High, with 100 scenarios per level. Satellite numbers range from 30 to 200, and task demands range from 56 to 560. All scenarios are generated from public Two-Line Element (TLE) data and explicitly model realistic constraints. Optical satellites require a minimum solar elevation angle, and Synthetic Aperture Radar (SAR) satellites require incidence angles within specified ranges. General constraints, such as per-orbit maximum on-time, minimum single-operation on-time, attitude maneuver time, and valid execution windows, are also modeled. The scenarios include point tasks, area tasks, static tasks, and dynamically inserted tasks. Second, the multi-dimensional effectiveness evaluation system includes a Basic Performance layer and a Dynamic Adaptability layer. The Basic Performance layer uses Completion Rate, Weighted Completion Rate, Average Response Delay, and Time Utilization. The Dynamic Adaptability layer uses multi-stage rolling evaluation with random dynamic task insertion. The Dynamic Adaptability Score measures the post-insertion Completion Rate relative to the baseline, and Dynamic Response Efficiency measures the performance gain per unit replanning time. A composite RSCMP-Bench Score is also provided. Third, the simulation and evaluation platform uses a client-server architecture. It integrates a Simplified General Perturbations 4 (SGP4) propagator, algorithm adapters, two-stage constraint verification, an intelligent scenario generator, and visualization tools. The platform has been deployed at https://www.tianzhibei.com and has supported a national competition with more than 80 research teams.  Results and Discussions  Baseline experiments comparing Random Scheduler and Priority Greedy validate the feasibility, reproducibility, and discriminative capacity of RSCMP-Bench. Random Scheduler yields very low Completion Rates of 7.3%, 3.8%, and 1.9% on the Low, Medium, and High levels, respectively. These results confirm the extreme sparsity of the feasible solution space. Priority Greedy achieves higher Completion Rates but still degrades as scenario difficulty increases, decreasing from 76.1% at the Low level to 63.7% at the Medium level and 49.2% at the High level. These findings indicate that high-difficulty scenarios remain challenging even for reasonable heuristic methods. They also show considerable room for more advanced algorithms. The dynamic adaptability protocol quantifies algorithm robustness under unexpected dynamic task insertion, which is not captured by static evaluations. The two-stage constraint verification module rejects infeasible plans and generates detailed error reports to support debugging.  Conclusions   RSCMP-Bench provides a unified, fair, and reproducible benchmark for remote sensing constellation mission planning. By combining a public library of 300 standardized scenarios, a multi-dimensional effectiveness evaluation system based on Basic Performance and Dynamic Adaptability, and a simulation and evaluation platform with realistic constraints and automated scenario generation, the framework addresses the long-standing lack of standardized evaluation in this field. Baseline results confirm its discriminative capacity and reveal clear performance bottlenecks in large-scale dynamic scenarios. Inspired by ImageNet and GLUE, RSCMP-Bench can support systematic community evaluation and fair competition. The framework has been deployed at https://www.tianzhibei.com, and its adoption can accelerate progress in intelligent mission planning for next-generation remote sensing constellations.
Cross-Domain Collaborative Enhancement for Tiny Object Detection in Remote Sensing Images
ZHANG Tianyang, ZHANG Xiangrong, WANG Guanchun, TANG Xu
2026, 48(9): 3966-3976. doi: 10.11999/JEIT260317
Abstract:
  Objective  Deep learning has substantially advanced object detection in Remote Sensing Images (RSIs). However, because of imaging conditions and the inherently small size of many objects, a large proportion of targets in RSIs occupy fewer than 16 × 16 pixels. Therefore, current object detection methods achieve substantially lower detection accuracy for tiny objects than for normal-scale objects. This limitation primarily arises from two critical factors: insufficient positive sample assignment and weak feature representation. To address these challenges, a Cross-Domain Collaborative Enhancement Detector (CDCEDet) is proposed. CDCEDet jointly optimizes label assignment in the spatial domain and enhances feature representation in the frequency domain, thereby improving the accuracy and robustness of tiny object detection in RSIs.  Methods  The overall framework of CDCEDet is illustrated in Fig. 2 and consists of three major components. First, a Scale-Adaptive Anchor Generator (SAAG) is designed to dynamically generate anchors that match the scales of ground-truth (GT) objects, thereby effectively alleviating the scale mismatch between anchors and tiny objects that has been largely overlooked in previous studies. Compared with conventional uniformly distributed anchor generators, SAAG substantially increases the number of positive samples assigned to tiny objects, even under Intersection over Union (IoU)-based label assignment. Second, a Quantile-based Adaptive Label Assignment (QALA) mechanism is developed to replace the conventional fixed IoU threshold-based label assignment. QALA models the IoU distribution between each GT object and its matched anchors to generate an adaptive label assignment threshold for each object, thereby further increasing the number of positive samples assigned to tiny objects. Third, a Frequency-Adaptive Fusion (FAF) module is developed to enhance feature representation from a frequency-domain perspective. An adaptive high-pass filter is used to strengthen high-frequency details and compensate for information loss caused by channel compression, whereas an adaptive low-pass filter preserves semantic consistency during feature upsampling, thereby reducing semantic inconsistency within upsampled objects.  Results and Discussions  Extensive experiments are conducted on two public remote sensing tiny object detection datasets, AI-TODv2 and AI-TOD-R. The proposed method is compared with several state-of-the-art methods, including RFLA, DCNet, and DCFL. On the AI-TODv2 dataset (Table 1), CDCEDet improves AP50 and AP50–95 by 1.8% and 0.7%, respectively, compared with the best existing method. On the AI-TOD-R dataset (Table 2), AP50 and AP50–95 are improved by 2.6% and 0.7%, respectively. These results demonstrate that CDCEDet achieves superior detection performance and strong generalization capability for tiny object detection in RSIs. Ablation studies and parameter analyses of the proposed modules (Tables 3~6) further verify the effectiveness of each component and their complementary contributions. Qualitative results on both datasets (Fig. 3) show that the proposed method accurately detects tiny objects in both sparse and dense scenes. As illustrated in Fig. 4, SAAG generates scale-matched anchors for individual objects and assigns substantially more positive samples to tiny objects than the conventional uniformly distributed anchor generator. Furthermore, visual comparisons with RFLA and DCNet (Fig. 5) demonstrate that CDCEDet achieves higher detection accuracy while substantially reducing missed detections.  Conclusions  A CDCEDet is proposed to address insufficient positive sample assignment and weak feature representation in remote sensing tiny object detection. Specifically, SAAG dynamically generates anchors that match the scales of GT objects, substantially increasing the number of positive samples assigned to tiny objects. QALA further improves label assignment by modeling the IoU distribution between GT objects and their matched anchors to adaptively determine the label assignment threshold, thereby effectively reducing the scale bias introduced by fixed IoU thresholds. In addition, FAF enhances feature representation from a frequency-domain perspective through an adaptive high-pass filter and an adaptive low-pass filter. Experimental results on two benchmark datasets demonstrate the superior detection performance and strong generalization capability of CDCEDet. Future work will focus on improving model efficiency and real-time performance to facilitate practical deployment in remote sensing applications.
A Phase Transition Obstacle Avoidance Method for UAV Swarms Driven by Multistable Potential Fields
HE Ming, CHEN QiYang, HAN Wei, PAN Fan, MA YiSong
2026, 48(9): 3977-3986. doi: 10.11999/JEIT260357
Abstract:
  Objective  Unmanned Aerial Vehicle (UAV) swarms have demonstrated considerable potential for complex missions, such as search, surveillance, and disaster response, because of their distributed coordination and robustness. However, in dynamic environments with dense obstacles and rapidly changing risks, conventional swarm control methods often exhibit discontinuous behavior switching and control chattering, which reduce system stability and coordination efficiency. Existing approaches, including threshold-based switching and Artificial Potential Field (APF) methods with fixed potential weights, rely on abrupt transitions between behavioral modes, leading to oscillatory responses. To address these limitations, a phase transition obstacle avoidance method for UAV swarms driven by multistable potential fields is proposed. Swarm behavior evolution is modeled as a continuous phase transition process within a unified potential field framework, enabling smooth and adaptive transitions between formation flight and obstacle avoidance.  Methods  An environmental risk assessment model is first established by integrating static obstacle risk, dynamic obstacle risk, and inter-agent proximity risk. A distributed consensus protocol is then employed to establish global risk consensus. Subsequently, a morphology factor is generated through nonlinear mapping of the global risk consensus and is used as an order parameter to characterize the macroscopic swarm state. A unified time-varying potential field, comprising formation, obstacle avoidance, and navigation potentials, is constructed, and the relative weights of these potentials are continuously adjusted by the morphology factor. When the risk level is low, the system exhibits a monostable structure dominated by the formation and navigation potentials. As the risk increases, the potential field continuously evolves into a multistable structure dominated by the obstacle avoidance potential, thereby enabling distributed obstacle avoidance. A distributed consensus control law based on the negative gradient of the unified potential field is further developed. A damping term is incorporated to dissipate system energy and improve stability, while a dynamic compensation term addresses nonlinear dynamics. The control law depends only on local information, ensuring good scalability. The global uniform ultimate boundedness of the closed-loop system is established using Lyapunov theory.  Results and Discussions  Simulation results demonstrate that the proposed method enables the swarm to maintain a compact solid-phase swarm formation in low-risk regions and to transition smoothly to a dispersed liquid-phase swarm configuration when obstacles are encountered, followed by rapid formation recovery after obstacle avoidance. The pitch and roll angles of each UAV vary smoothly without abrupt changes, and both the UAV-to-obstacle distance and the inter-UAV separation remain above the prescribed safety threshold throughout the flight, ensuring collision-free operation. Statistical results obtained from 20 independent simulation runs show that, compared with the threshold-switching method, the proposed method reduces the rate of control input variation by approximately 26% and decreases the peak control input by approximately 18%. Compared with the bio-inspired diversion method, the average formation recovery time after obstacle avoidance is reduced by approximately 16%. Ablation experiments further demonstrate that removing the morphology-driven phase transition mechanism significantly increases trajectory oscillation and control oscillation, confirming the critical role of the multistable continuous phase transition mechanism in maintaining smooth swarm motion. In complex narrow-channel environments, the proposed method effectively avoids the local minimum problem encountered by conventional APF methods and generates smoother flight trajectories with substantially reduced oscillation.  Conclusions  A phase transition obstacle avoidance method for UAV swarms driven by multistable potential fields is proposed. By introducing a morphology factor and constructing a unified potential field framework, swarm behavior evolution is represented as a continuous phase transition process. The distributed control law enables smooth behavioral transitions while maintaining system stability and scalability. Simulation results demonstrate that the proposed method achieves better safety, smoother control, and higher coordination efficiency than conventional methods.
A State Prediction Method for Long-Endurance Fixed-Wing UAV Propulsion Systems
LI Sicheng, WANG Lianqing, LI Zhiyong, WANG Guochang, GE Kaihua, CHEN Junfeng, TAN Rongqing
2026, 48(9): 3987-3998. doi: 10.11999/JEIT260188
Abstract:
  Objective  Accurate single-step prediction of key propulsion-system states is essential for early fault warning and autonomous health management of long-endurance fixed-wing Unmanned Aerial Vehicles (UAVs). During high-altitude missions exceeding 24 h, electrical and thermal variables in the propulsion system exhibit strong coupling, multi-time-constant dynamics, and pronounced day-night operating-condition changes. These characteristics cause short-term fluctuations and long-term trends to coexist, making adaptive feature weighting difficult under time-varying variable sensitivities. Therefore, general-purpose time-series forecasting models often fail to satisfy the accuracy and robustness requirements of multivariate propulsion-system state prediction. To address these challenges, a Grouped Squeeze-and-Excitation Multi-scale Temporal Convolutional Network (GEMS-TCN) is proposed by enhancing a modern convolution-based forecasting backbone with Multi-scale Embedding (MsE) and Grouped Channel Attention. The proposed model performs accurate 10 s-ahead single-step prediction of 16 key propulsion-system states from 72-dimensional flight telemetry while satisfying the real-time inference requirement of the 1 Hz telemetry cycle.  Methods  Real-flight telemetry collected from a representative long-endurance fixed-wing UAV is used for model development and evaluation. The dataset is sampled at 1 Hz over nine consecutive days and contains 806 629 time steps and 72 variables (Fig. 2). Sixteen propulsion-system states, including the bus voltage, control-unit temperature, winding temperature, and power-device temperature of four motors, are selected as prediction targets, whereas all 72 variables are used as model inputs (Table 1). The raw data are processed through time indexing, interquartile range (IQR)-based anomaly detection, and interpolation, and are then chronologically divided into training, validation, and test sets at a ratio of 8:1:1 to prevent information leakage (Figs. 4 and 5). GEMS-TCN employs an MsE layer with parallel one-dimensional convolutions to extract temporal features at multiple receptive-field scales. Stacked GEMS-TCN blocks integrate Depthwise Convolution (DWConv), Convolutional Feed-Forward Networks (ConvFFNs), and Grouped Squeeze-and-Excitation (GroupSE) modules to hierarchically recalibrate intra-variable and cross-variable channel responses (Fig. 1). The models are trained using the Adam optimizer with the Mean Squared Error (MSE) loss function. Performance is evaluated using the Mean Absolute Error (MAE), MSE, and Symmetric Mean Absolute Percentage Error (SMAPE). PatchTST, ModernTCN, FEDformer, DLinear, and TimesNet are used as benchmark models. Ablation and robustness experiments are conducted for further validation.  Results and Discussions  On the complete 16-dimensional prediction task, GEMS-TCN achieves a test-set MAE of 0.171 and an MSE of 0.069 (Table 4). Compared with TimesNet, the strongest baseline for trend tracking, GEMS-TCN reduces the MSE by 28.1% while maintaining comparable MAE and SMAPE, demonstrating improved suppression of large prediction errors (Table 4). Stable prediction accuracy is maintained under both daytime and nighttime operating conditions, with MAE/MSE values of 0.189/0.085 and 0.150/0.051, respectively, demonstrating robustness to operating-condition changes (Table 4). The predicted trajectories exhibit more accurate alignment at thrust-transition points, reduced overshoot, and fewer spurious spikes, while maintaining low-bias tracking of slowly varying nighttime temperature profiles (Fig. 7). Ablation experiments show that MsE and GroupSE each improve prediction performance, and their combination achieves the best overall performance, confirming that the two modules provide complementary benefits (Table 6). Under 1% and 5% random data dropouts and 60 s continuous data loss, the MSE remains below 0.07, demonstrating robustness to practical data-loss scenarios (Table 5). Furthermore, GEMS-TCN contains 27.88 M parameters and achieves an inference latency of 0.90 ms per sample, which is substantially shorter than the 1 s telemetry sampling interval.  Conclusions  GEMS-TCN provides an effective convolution-based framework for multivariate propulsion-system state prediction in long-endurance fixed-wing UAVs. By integrating MsE with hierarchical channel recalibration implemented through GroupSE, the proposed method simultaneously represents rapid fluctuations and slow temporal evolution, thereby improving the representation of multi-time-constant dynamics and multivariate coupling in propulsion-system telemetry. Real-flight experiments demonstrate stable prediction performance across daytime and nighttime operating conditions, different state categories, and data-loss scenarios. Ablation experiments further verify the effectiveness and complementarity of MsE and GroupSE. These results indicate that the proposed structure-aware modeling strategy provides effective support for propulsion-system health monitoring, early fault warning, and autonomous health management of long-endurance fixed-wing UAVs.
A WiFi Multi-link Collaborative Human Tracking Method for Smart Home
PAN Houcheng, CAI Yushuang, YAO Junmei, ZHANG Tingting
2026, 48(9): 3999-4009. doi: 10.11999/JEIT260267
Abstract:
  Objective  WiFi-based indoor passive human tracking has attracted increasing attention for smart home applications because Internet of Things (IoT) devices are widely interconnected through existing WiFi infrastructures. Existing approaches estimate the Angle of Arrival (AoA) or Time of Flight (ToF) of the target-reflected path to achieve tracking. However, these methods are fundamentally limited by the difficulty of separating weak target-reflected signals from dense multipath propagation when commercial WiFi devices provide only a small antenna array and limited bandwidth under existing communication protocols. Therefore, Doppler Frequency Shift (DFS)-based approaches that exploit multiple links have become more practical. Dead Reckoning (DR) is widely adopted in these methods, but dynamic link selection for signal fusion remains challenging. Furthermore, the performance of DR-based methods degrades substantially when device-location errors are present. Existing methods also generally employ a single-transmitter-multi-receiver architecture, in which Access Point (AP) broadcasts downlink WiFi signals to STAtions (STA). It complicates data aggregation and limits the use of multiple receive antennas of AP’s. To address the challenges of multi-link signal fusion and device-location uncertainty, a Particle Filter (PF)-based method is proposed. Furthermore, a multi-transmitter-single-receiver architecture is adopted, in which multiple STAs transmit uplink packets to a single AP. This architecture simplifies data aggregation while exploiting the AP’s multi-antenna capability.  Methods  In the IEEE 802.11 standard, the wireless channel is estimated at the receiver using pilot signals embedded in WiFi packets, and Channel State Information (CSI) is continuously obtained. Human motion perturbs multipath propagation and produces time-varying changes in CSI. Therefore, CSI serves as the primary sensing signal because it implicitly captures target motion. In practice, raw CSI is affected by amplitude and phase impairments. Accordingly, signal preprocessing is first performed before Doppler extraction. Subsequently, multi-link DFS measurements are fused using PF, in which the target state is sequentially propagated and updated according to likelihoods derived from DFS measurements. This probabilistic framework naturally enables dynamic multi-link fusion because unreliable links receive lower weights rather than being deterministically discarded. Moreover, the effects of device-location errors are incorporated into the measurement-noise model, improving robustness to device-location uncertainty. When prior knowledge of device locations is unavailable, device self-localization is first performed by jointly estimating the Line-of-Sight (LoS) AoA and ToF between the AP and each STA. Preliminary device self-localization experiments (Fig. 5) demonstrate a median STA localization error of approximately 0.56 m (Table 1), providing reliable initialization for the subsequent tracking algorithm.  Results and Discussions  A prototype system is implemented using a multi-transmitter-single-receiver architecture with commercial Intel AX200/AX201 WiFi cards. CSI is collected over a 20 MHz channel centered at 5.24 GHz using PicoScenes, with IEEE 802.11ac packets transmitted at 100 or 200 Hz. Each CSI sample contains measurements from 57 subcarriers. Meanwhile, Fine Time Measurement (FTM) is performed on Channel 11 at 2.4 GHz using iw and hostapd. In the prototype system, each STA transmitter is equipped with a single antenna, while the AP receiver employs two antennas. Experiments are conducted using one AP and three or four STAs (Fig. 7). WiTraj and PITrack, both based on DR, are used as baseline methods. When device self-localization is required, the proposed method achieves a median tracking error of 0.47 m, compared with 1.78 m for WiTraj and 1.77 m for PITrack (Fig. 9), representing an accuracy improvement of approximately 70% over conventional DR-based methods. Error-injection experiments with random device-location perturbations show that, unlike conventional DR-based methods, which are highly sensitive to device-location errors, the proposed method remains robust to device-location uncertainty (Fig. 10). Additionally, computational complexity analysis shows that, although execution time increases with the particle count (Table 3), tracking performance reaches a stable level beyond a moderate particle count (Fig. 11). Therefore, real-time operation can be achieved by selecting an appropriate particle count. Finally, experiments in complex environments demonstrate that the proposed method consistently achieves higher tracking accuracy than the baseline methods (Fig. 12).  Conclusions  A PF-based method is proposed for multi-link collaborative passive human tracking using commercial WiFi devices. By probabilistically fusing measurements from multiple links, robust tracking is achieved even when device-location errors are present. When device locations are unavailable, device self-localization is achieved by combining CSI-based estimation with FTM measurements, providing the geometric information required for tracking. A prototype system based on a multi-transmitter-single-receiver architecture is developed to simplify data aggregation while exploiting the AP’s multi-antenna capability. Experimental results demonstrate that the proposed method achieves sub-0.5 m median tracking error when device-location errors are present, representing an improvement of approximately 70% over conventional DR-based methods. The proposed method also exhibits strong robustness to device-location uncertainty and supports real-time implementation when an appropriate particle count is selected. Future work will extend the framework to multi-person tracking and evaluate its performance under more realistic deployment conditions.
Decoupled Learning for Long-tailed Oracle Bone Character Recognition Based on Adaptive Difficulty Sampling
SUN Junwei, GUAN Suyan, CHEN Xinyu, WANG Kun, CAI Yuanqiang
2026, 48(9): 4010-4021. doi: 10.11999/JEIT260327
Abstract:
  Objective  Oracle Bone Character (OBC) recognition is challenged by an extreme long-tailed distribution and substantial intra-class variation. Conventional deep learning methods are often dominated by head classes, whereas existing approaches tend to overfit tail classes or fail to account for differences in learning difficulty across classes. To address these limitations, a two-stage decoupled learning framework is proposed to improve the recognition of tail and difficult classes while preserving the discriminative capability of head classes.  Methods  The proposed framework decouples feature representation learning from classifier optimization. In the first stage, the backbone network is trained using a mixed data augmentation strategy that combines CutMix and RandAugment with Label-Distribution-Aware Margin (LDAM) loss to learn robust feature representations and alleviate the effect of intra-class variation. In the second stage, the backbone network is frozen, and only the classifier is optimized. An adaptive difficulty sampling strategy is proposed to dynamically assign sampling weights according to historical and current class-level training difficulty. The classifier is further optimized using a Class-Balanced LDAM (CBL) loss, which combines class-balanced weighting with LDAM to refine decision boundaries for long-tailed classification.  Results and Discussions  Experiments on the highly imbalanced OBC306 dataset demonstrate that the proposed method achieves an overall accuracy of 94.34% and an average class accuracy of 89.89%. Compared with the Inception-v4 baseline, the proposed method improves the average class accuracy by 19.61%. Comparisons with representative long-tailed OBC recognition methods further demonstrate superior overall performance. Comprehensive ablation studies verify the effectiveness of the mixed data augmentation strategy and the adaptive difficulty sampling strategy in improving the recognition of rare and difficult characters. Parameter sensitivity analysis and qualitative error analysis further confirm the robustness and effectiveness of the proposed framework.  Conclusions  The proposed two-stage decoupled learning framework effectively addresses long-tailed OBC recognition by balancing the learning priorities of head, tail, and difficult classes. The mixed data augmentation strategy improves feature robustness, whereas the adaptive difficulty sampling strategy and the Class-Balanced LDAM loss jointly optimize classifier learning and refine decision boundaries without degrading head-class recognition performance. The proposed framework provides an effective solution for the digital recognition of Oracle Bone Characters and offers technical support for low-resource ancient character recognition.
Multi-task Lightning Nowcasting with Spatio-temporal Focal Perception and Synergistic Weighted Loss
TANG Zhihao, HAN Yuanpeng, ZHANG Hui, SONG Lin, ZHANG Qilin, LIU Yi
2026, 48(9): 4022-4034. doi: 10.11999/JEIT260234
Abstract:
  Objective  Lightning nowcasting is essential for early warning systems and for protecting critical infrastructure, including aviation, power grids, and transportation systems. Traditional numerical weather prediction models depend strongly on parameterization schemes and require high computational costs, which limits their use in rapid-update nowcasting. Although deep learning methods have advanced, they still have difficulty handling extreme data sparsity, suffer from serial-computation bottlenecks in recurrent architectures, and mainly focus on binary occurrence prediction rather than the joint optimization of lightning-frequency prediction and regional localization. Moreover, conventional loss functions are easily dominated by extensive non-lightning areas, which biases predictions toward zero or causes excessive false alarms. To address these limitations, a Spatio-Temporal Focal perception and synergistic weighted loss Network (STF-Net) is proposed as a multi-task lightning nowcasting model that jointly predicts lightning frequency and occurrence regions. It integrates three key components: a Lightning Adaptive Attention Module (LAAM) for explicit spatio-temporal dependency modeling, a Spatio-Temporally Weighted Hybrid Loss for data sparsity and imbalance, and a spatio-temporal dual-branch Generative Adversarial Network (GAN) to improve prediction fidelity and temporal coherence.  Methods  STF-Net is built on the SimVP video prediction architecture and adopts an encoder-translator-decoder paradigm. LAAM uses a three-dimensional decoupled attention mechanism along the height, width, and channel dimensions, enabling adaptive focus on convectively sensitive regions while maintaining computational efficiency. The Spatio-Temporally Weighted Hybrid Loss combines Temporally Weighted Mean Squared Error (TW-MSE) for frequency regression and Dual-Weighted Cross-Entropy loss (DWCE) for regional localization. Time-increasing weights are incorporated to improve medium- to long-term forecast robustness (Fig. 5). DWCE integrates static class weights with dynamic grid weights, thereby balancing global class proportions and local lightning-frequency heterogeneity. A spatio-temporal dual-branch GAN, consisting of a spatial PatchGAN discriminator and a temporal three-dimensional convolutional discriminator, is used to improve the textural fidelity and temporal coherence of predicted lightning-frequency fields. The model uses six consecutive historical lightning-frequency frames at 256×256 resolution and 10-min intervals to predict the next six frames, corresponding to a 1-h forecast window. Experiments are conducted on a high-resolution Very Low Frequency Lightning Location Network (VLF-LLN) dataset containing 11 748 images that cover different seasonal and weather conditions. The dataset is split at a ratio of 7:3 for training and testing.  Results and Discussions  Comprehensive evaluation metrics are used, including Mean Squared Error (MSE) and Mean Absolute Error (MAE), which are computed only on lightning pixels; Peak Signal-to-Noise Ratio (PSNR) and Structural Similarity Index Measure (SSIM) for image fidelity; and Probability Of Detection (POD), False Alarm Rate (FAR), and Critical Success Index (CSI) for regional detection. STF-Net achieves a CSI of 0.663 within the 1-h forecast window, representing a 14.5% improvement over the SimVP baseline (0.579). It also reduces FAR from 0.351 to 0.216, corresponding to a relative reduction of 38.5% (Table 1). Ablation studies validate each component. Adding GAN improves CSI to 0.624 and reduces MSE to 0.109. Further incorporation of LAAM increases CSI to 0.629 and yields the highest POD of 0.894. The complete STF-Net with the hybrid loss achieves the best performance, with a CSI of 0.663 and an MSE of 0.105 (Table 1, Fig. 5). The joint prediction of frequency and region is supported by simultaneous improvements in regression metrics (MSE and MAE) and detection metrics (CSI and FAR). Time-step analysis shows that LAAM reduces long-term performance degradation, with STF-Net maintaining the highest CSI compared with SimVP+GAN and SimVP (Fig. 6). Comparative experiments with ConvLSTM and PredRNN further demonstrate the superiority of STF-Net across all lead times. STF-Net consistently achieves highest CSI and lowest MSE, and its advantage becomes more evident as the forecast horizon increases (Fig. 8). Its consistent gains in PSNR and SSIM further indicate that the spatio-temporal GAN helps generate coherent, detail-rich predictions. Visualization results show that STF-Net produces structurally clear and continuous lightning-activity regions centered on high-frequency areas. It accurately tracks dynamic evolution patterns, including movement, merging, and splitting, while generating minimal noise in non-lightning regions. These results demonstrate effective collaborative prediction of both frequency magnitude and spatial distribution.  Conclusions  STF-Net is presented as a deep learning model for joint lightning-frequency prediction and regional localization. It explicitly models long-range spatio-temporal dependencies, focuses on critical convective zones, addresses extreme data sparsity and class imbalance, and jointly optimizes frequency regression and regional localization while suppressing false alarms. Its spatio-temporal dual-branch GAN further improves the spatial structural consistency and temporal coherence of predictions. Experimental results show that STF-Net outperforms baseline and state-of-the-art models, achieving a CSI of 0.663, an FAR of 0.216, and the best MSE and MAE values within a 1-h forecast window. The model effectively reduces long-term performance degradation, captures the evolution trends of lightning regions, and generates physically plausible predictions with minimal background noise. This study provides an efficient end-to-end solution for operational lightning nowcasting systems and offers guidance for model design in sparse meteorological spatio-temporal sequence prediction.
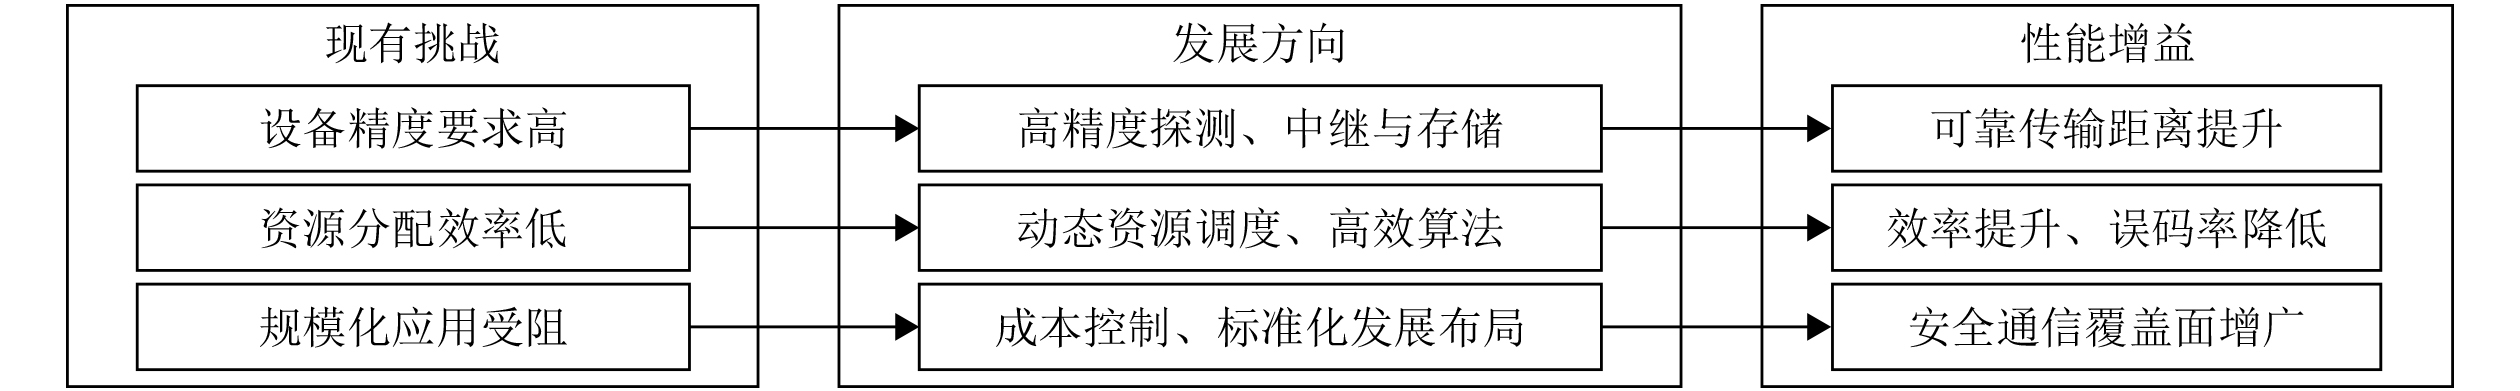
A Radio Frequency Fingerprint Open-set Identification MethodCombining Multi-scale Wavelet Front-end and Hyperspherical Metric Learning
TIAN Xinyu, LI Zirui, ZHENG Qinghe, ZHOU Fuhui, YU Lisu, HUANG Chongwen, JIANG Weiwei, SHU Feng, ZHAO Yizhe
2026, 48(9): 4035-4047. doi: 10.11999/JEIT260214
Abstract:
  Objective  Open-set Radio Frequency Fingerprint (RFF) identification under low Signal-to-Noise Ratio (SNR) conditions is challenging because fingerprint features are easily masked by noise, multipath effects induce nonlinear distortions, and existing methods struggle with feature extraction and unknown device detection. This study proposes a deep learning framework that integrates a multi-scale wavelet front-end with hyperspherical metric learning to achieve robust open-set RFF identification.  Methods  The proposed method, MS-RANet, comprises three key components. First, a multi-scale wavelet front-end based on one-dimensional stationary wavelet transform performs full-resolution, multi-scale decomposition of I/Q signals, preserving discriminative fingerprint information while suppressing noise. Second, a multi-scale residual attention network incorporates deep residual learning, global self-attention, and Bidirectional LSTM (BiLSTM) to enhance sensitivity to subtle fingerprint features and capture long-range temporal dependencies. Third, hyperspherical metric learning constrains the feature space onto a unit hypersphere, optimizing angular margins to produce compact intra-class and separable inter-class feature distributions. Unknown devices are subsequently detected using cosine similarity.  Results and Discussions  Experiments on a high-fidelity IEEE 802.11 simulation dataset demonstrate the effectiveness of MS-RANet. The method achieves an average classification accuracy of 65.34% across SNR levels from –5 dB to 20 dB, and an Area Under the Curve (AUC) of 0.81 at –5 dB SNR, outperforming DNN, GRU, CNN-LSTM, ResNet50, and DRSN-CA. Confusion matrices and Receiver Operating Characteristic (ROC) curves confirm robustness under extreme channel conditions. t-SNE visualization shows well-separated, compact clusters for known devices, while unknown samples are effectively isolated from known class regions. Ablation studies verify the contributions of the multi-scale wavelet front-end, global attention, BiLSTM, and hyperspherical metric learning modules.  Conclusions  This study presents a robust open-set RFF identification method combining a multi-scale wavelet front-end with hyperspherical metric learning. The framework exhibits strong noise resilience, enhanced feature discrimination, and reliable detection of unknown devices under low-SNR and multipath fading conditions. Future work will focus on reducing computational complexity, improving inference speed, evaluating generalization across diverse scenarios and protocols, and integrating the method with complementary physical-layer security mechanisms for collaborative authentication.
Reynolds Decomposition Motion-Guided Texture Learning for Scarred Myocardium Phenotyping
RUAN Dongsheng, YANG Daiguo, ZHANG Xiaolin, MA Jianhua, JIANG Mingfeng, WANG Yaming
2026, 48(9): 4048-4058. doi: 10.11999/JEIT260330
Abstract:
  Objective  Scarred myocardium is a key imaging marker of multiple cardiovascular diseases, and accurate phenotyping is clinically valuable for treatment planning and prognosis. Cine-MRI noninvasively provides both cardiac motion and anatomical texture information. However, existing classification methods have two major limitations. First, motion representation is often overly discretized and insensitive to subtle abnormalities. Second, multimodal fusion commonly relies on simple feature concatenation, which limits the ability to capture the deep pathological association between motion impairment and texture alteration. A motion-guided texture learning framework is therefore developed to improve the accuracy of non-invasive scarred myocardium classification.  Methods  A Motion-Guided Texture fusion Network (MGTNet) is proposed to enable deep interaction between motion and texture features. First, inspired by Reynolds decomposition in fluid dynamics, a Reynolds Decomposition Motion Network (RDMNet) is designed within a diffeomorphic registration framework to decompose the myocardial motion field into a regular mean motion component and an abnormal pulsatile motion component. This decomposition provides a refined motion representation that is sensitive to subtle abnormalities. Second, a Motion-Guided Cross-Attention (MGCA) module is designed, in which refined motion features serve as query features to dynamically modulate texture features and enhance the perception of suspected lesion regions. In addition, an inter-frame motion interaction module is used to capture temporal dependencies across cardiac frames, while an intra-frame texture extraction module learns multi-scale spatial texture patterns within each frame. Through a serial pipeline of motion field estimation, motion-guided texture enhancement, and feature fusion, end-to-end scarred myocardium classification is achieved.  Results and Discussions  Experiments on the CMRD and ACDC datasets show that MGTNet consistently outperforms existing single-modality and multimodal methods (Tables 1 and 2). It achieves accuracies of 95.6% on CMRD and 97.3% on ACDC, with AUC values of 96.6% and 96.0%, respectively. Compared with the baseline MTNet, MGTNet improves accuracy by up to 1.4 percentage points and the F1-score by up to 2.3 percentage points. Further comparisons with different motion field estimation methods (Tables 3 and 4) show that RDMNet provides more discriminative motion priors and achieves the best overall performance on both datasets. These results indicate that fine-grained motion modeling and motion-guided texture enhancement effectively capture complementary pathological information from Cine-MRI. The ROC curves of the nine methods on both datasets further support the superior classification performance of the proposed method.  Conclusions  A scarred myocardium classification method based on motion-guided texture learning is presented. Reynolds decomposition is incorporated into motion field estimation to separate regular mean motion from abnormal pulsatile motion, and cross-attention is used to guide texture extraction with motion priors. This strategy addresses the limitations of discrete motion representation and shallow multimodal fusion. The results confirm that deep motion-texture interaction improves the accuracy and robustness of non-invasive scarred myocardium classification and provides an effective approach for Cine-MRI-based myocardial phenotyping.
Cryption and Network Information Security
A Behavioral Economics-Based Game Model for Side-Channel Security Attack and Defense Strategies
CAI Juesong, YAN Yingjian, WANG Jindong
2026, 48(9): 4059-4070. doi: 10.11999/JEIT260121
Abstract:
  Objective  The field of side-channel security lacks a systematic, quantifiable, and reproducible model for selecting attack and defense strategies, particularly in engineering applications where limited resources require informed cost-benefit trade-offs. The absence of such a framework hinders the practical implementation of the principle of appropriate security and often leads to either excessive or insufficient protection of cryptographic modules. Conventional approaches to attack and defense cost evaluation rely heavily on subjective expert judgment, making the results difficult to reproduce and compare systematically. This study proposes an interdisciplinary framework that integrates game theory, behavioral economics, and the Analytic Hierarchy Process (AHP) to establish a structured decision framework. The proposed framework performs structured cost quantification for side-channel attack and defense strategies while incorporating behavioral factors into decision-making under uncertainty, thereby supporting adaptive strategy selection according to asset value and security level.  Methods  A multilayer modeling framework is developed based on a static game with incomplete information. The side-channel analyst and defense designer are modeled as rational players with finite strategy sets. The attacker selects from Differential Power Analysis/Correlation Power Analysis (DPA/CPA), Template Attack (TA), and Deep Learning-Based Side-Channel Analysis (DLSCA), whereas the defender selects time hiding, amplitude hiding, or masking/blinding countermeasures. An AHP-based structured cost quantification framework is established to quantify strategy costs. Pairwise comparison matrices are used to decompose costs into multiple criteria, including time, data storage, computational resources, expertise, and hardware overhead, and to calculate objective criterion weights, replacing subjective cost assignment with a reproducible hierarchical evaluation framework. To capture realistic decision-making behavior, Prospect Theory and risk-aversion theory are incorporated into the utility function. Behavioral parameters are parameterized by security level, enabling adaptive strategy selection under different security requirements. The resulting behaviorally enhanced Bayesian game is solved using Bayesian Nash Equilibrium (BNE), in which each player’s optimal mixed strategy is determined according to its private type and prior beliefs about the opponent. To satisfy engineering requirements, the As Low As Reasonably Practicable (ALARP) principle is incorporated as an engineering cost-effectiveness constraint, ensuring that selected defense strategies achieve appropriate risk reduction at acceptable cost. Numerical optimization is performed using a customized sequential quadratic programming algorithm implemented in Python.  Results and Discussions  Comprehensive experiments are conducted to evaluate the consistency, sensitivity, and practical applicability of the proposed framework. The AHP-based structured cost quantification framework demonstrates good internal consistency, with all consistency ratios below the threshold of 0.1, confirming the reliability of the judgment matrices. The resulting weight distributions indicate that attackers assign greater importance to technical barriers and computational resources, whereas defenders place greater emphasis on design complexity and performance overhead. The behavioral adjustment mechanism effectively modifies subjective cost according to security level. Under low-security conditions, stronger risk aversion increases perceived cost and promotes conservative strategy selection. Under high-security conditions, decision-making becomes more consistent with objectively quantified costs. Equilibrium analysis under different asset values and security levels produces interpretable strategy distributions. For low-value assets, both players tend to select low-cost or no-action strategies that satisfy the lower boundary of the ALARP acceptable region. As asset value increases, a clear threshold effect drives both players toward higher-cost, higher-effectiveness strategies, including DLSCA and masking/blinding techniques. Sensitivity analysis further demonstrates that the probability of adopting stronger defense strategies increases monotonically with asset value, confirming the framework’s ability to characterize the nonlinear relationship between protection intensity and asset value. These results demonstrate that the proposed framework supports adaptive, context-aware security decision-making by jointly considering structured cost, risk, and behavioral factors.  Conclusions  This study proposes a behaviorally informed game-theoretic framework for selecting side-channel attack and defense strategies, addressing the lack of a systematic approach to structured cost quantification in existing studies. By integrating AHP-based structured cost quantification, behaviorally adjusted subjective cost, and ALARP-based engineering cost-effectiveness constraints, the proposed framework provides a reproducible, multidimensional, and context-dependent approach to analyzing attack and defense strategies. The framework explicitly associates security level with behavioral parameters, enabling dynamic strategy selection according to both asset value and decision-makers’ risk preferences. Although the current implementation relies partly on expert-defined parameters and adopts a static game framework, it establishes a quantitative foundation for replacing heuristic security decisions with interdisciplinary, data-driven analysis. Future work will focus on calibrating model parameters using practical side-channel attack and defense datasets, extending the framework to multistage dynamic games to characterize long-term strategic evolution, and validating the framework in practical cryptographic security evaluation scenarios. The proposed framework provides the first systematic methodology for cost-aware and behaviorally informed optimization of side-channel attack and defense strategies, offering both theoretical support and practical guidance for achieving appropriate security in cryptographic engineering.
Construction and Performance Analysis of Optimal Low-Hit-Zone Frequency Hopping Sequence Sets
TIAN Xinyu, CHEN Xiaoyu, ZHANG Jitao
2026, 48(9): 4071-4080. doi: 10.11999/JEIT260343
Abstract:
  Objective  ElectroMagnetic Interference (EMI) is a critical factor limiting the reliability of synchronization systems. Existing Fifth-Generation (5G) synchronization schemes extensively employ Zadoff-Chu (ZC) sequences to distinguish users through cyclic shifts. However, finite sequence lengths and limited orthogonal resources create substantial capacity bottlenecks in high-density access scenarios. To address these challenges, this paper investigates the problem from two perspectives. At the system level, a synchronization framework is developed by integrating Frequency Hopping (FH) with ZC sequences. By jointly exploiting code, time, and frequency-domain resources, the proposed framework improves concurrent access capability for local clusters while enhancing robustness against complex EMI through frequency diversity. At the sequence-design level, a class of multi-subset Low-Hit-Zone (LHZ) Frequency Hopping Sequence (FHS) sets is constructed to provide an efficient sequence allocation scheme for local-cluster synchronization.  Methods  Based on the theoretical framework proposed by Cai et al., the sequence mapping mechanism is reconstructed, and a disjoint Cyclic Perfect Mendelsohn Difference Family (CPMDF) is introduced to construct FHS sets that are optimal with respect to the Peng-Fan bound. The generating units are further expanded through Cartesian products, and a column-incoherent partitioning strategy is proposed to construct multi-subset LHZ FHS sets. It is proved that every nonempty subset satisfies the Peng-Fan-Lee bound with equality. Compared with Global-LHZ-FH-ZC, Clustered-LHZ-FH-ZC provides higher synchronization detection robustness by better matching the local-cluster competition structure. At the system level, an FH-ZC synchronization architecture is developed by combining predefined FH patterns with the frequency-domain correlation properties of ZC sequences for subband signal detection. A Peak-to-SideLobe Ratio (PSLR) decision metric and an early-termination strategy are adopted to evaluate synchronization preamble detection under interference. Furthermore, a multi-user simulation model is established to evaluate synchronization detection performance under accumulated co-channel collisions and EMI.  Results and Discussions  The proposed construction generates an FHS set that is optimal with respect to the Peng-Fan bound and a class of multi-subset LHZ FHS sets in which every nonempty subset is optimal with respect to the Peng-Fan-Lee bound. Example 2 demonstrates the construction procedure and the intra-subset and inter-subset Hamming correlation properties of the proposed multi-subset LHZ FHS sets. Table 1 shows that, under the same frequency-resource constraints, the proposed construction generates more sequences than existing methods under the compared parameter settings, indicating higher sequence-resource utilization. Table 2 compares the parameters of the proposed sequence sets with representative constructions reported previously and demonstrates that the proposed multi-subset optimal sequence family provides a new parameter combination. To the best of our knowledge, an optimal sequence family with a multi-subset structure has not been reported previously. Figs. 2 and 3 demonstrate that the proposed FH-ZC synchronization architecture achieves a higher synchronization detection probability than the conventional full-band Fixed-ZC baseline under subband-selective blocking interference caused by EMI. Figure 4 shows that the synchronization detection probability decreases as the number of active users increases because accumulated co-channel collisions degrade synchronization performance. Compared with Global-LHZ-FH-ZC, Clustered-LHZ-FH-ZC provides higher synchronization detection robustness by better matching the local-cluster competition structure characterized by strong intra-cluster competition and weak inter-cluster coupling.  Conclusions  To satisfy the sequence-capacity requirements of massive-access scenarios, this paper proposes a class of multi-subset LHZ FHS sets. By expanding the generating sequence sets through Cartesian products and partitioning subsets using a column-incoherent strategy, the proposed construction achieves both a large family size and optimal LHZ performance. The proposed multi-subset structure is well suited to local-cluster synchronization and substantially improves sequence family size and sequence-resource utilization, thereby providing a richer sequence resource pool for high-density multi-user systems. Simulation results under the considered physical-layer model demonstrate that the proposed LHZ FHS subsets reduce the effect of frequency collisions during multi-user synchronization detection. Furthermore, the FH-ZC synchronization scheme achieves a higher synchronization preamble detection probability than the conventional full-band Fixed-ZC baseline under subband-selective blocking interference caused by EMI.
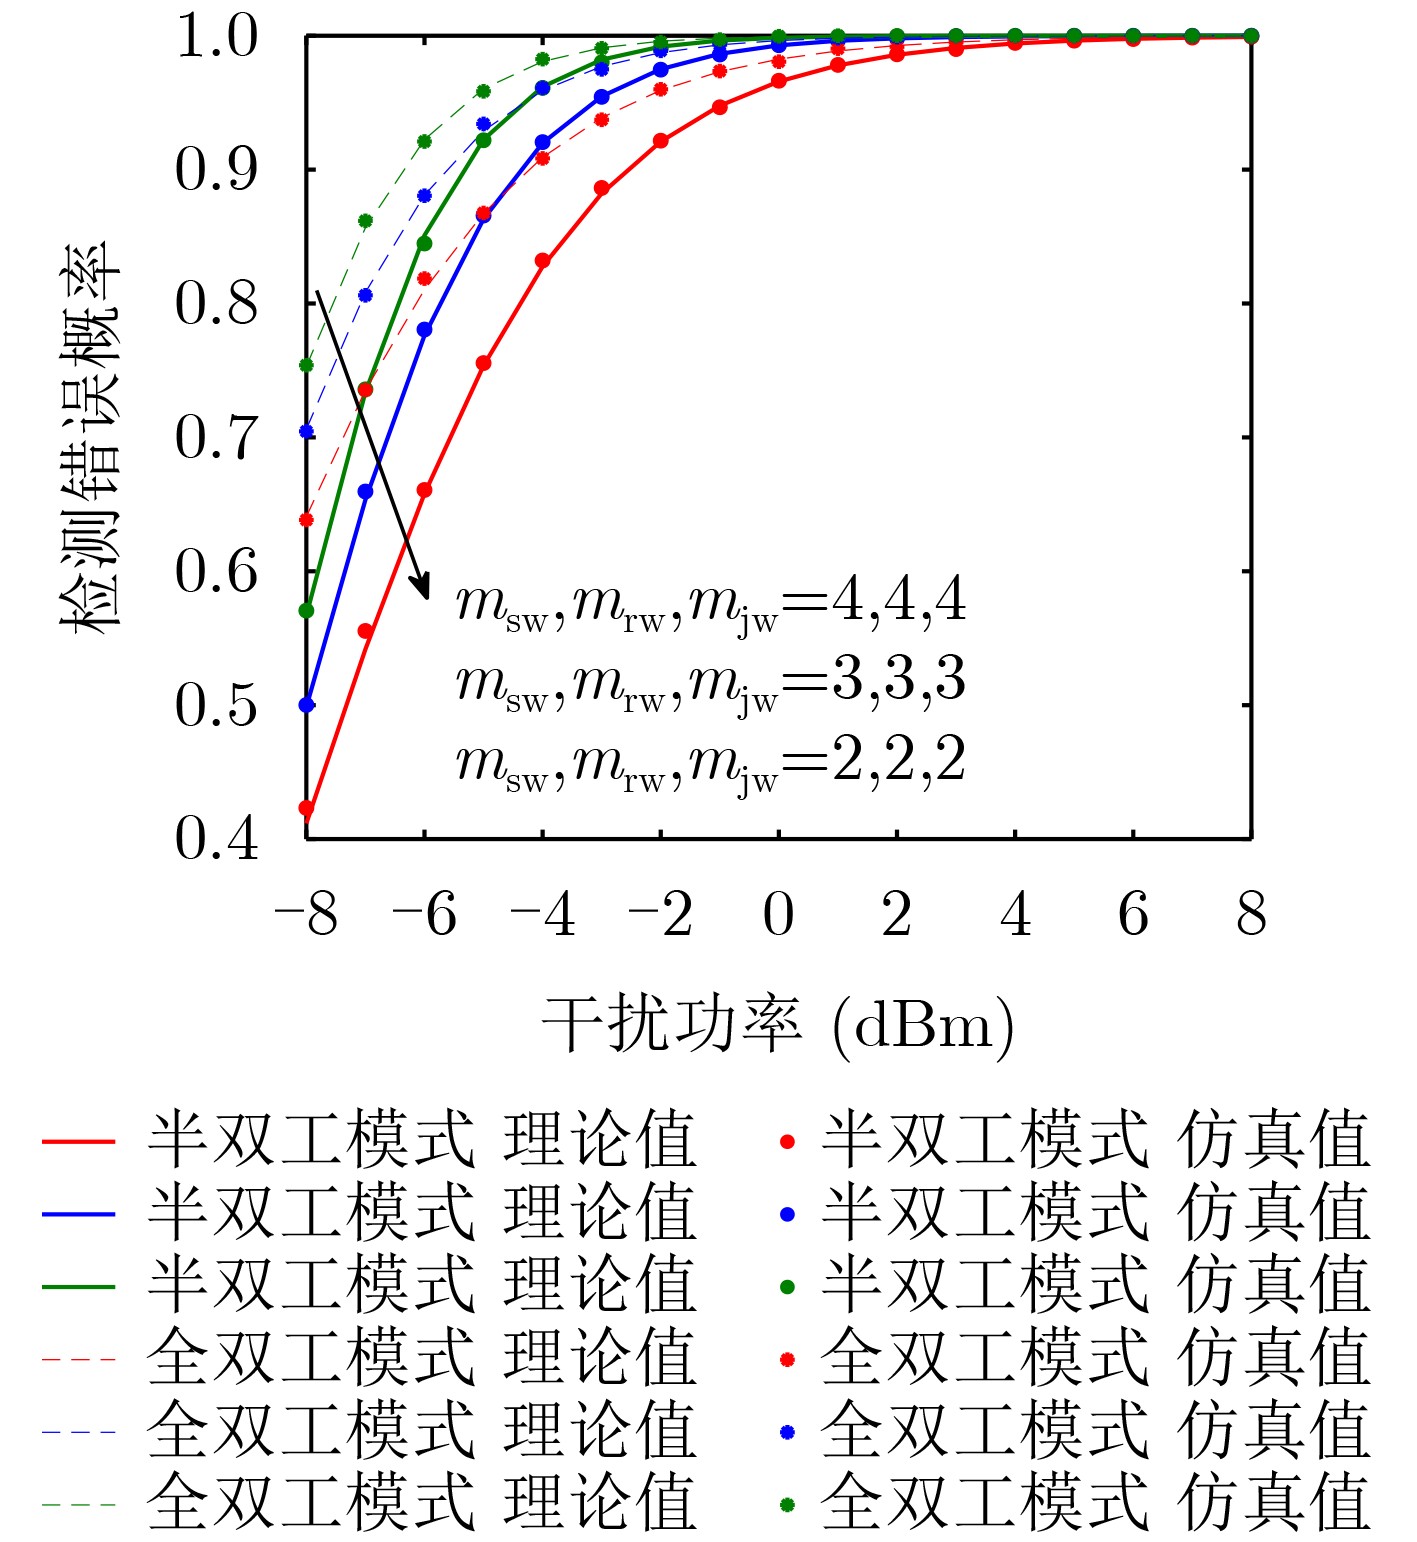
Circuit and System Design
Design of Lightweight Gated Recurrent Unit Network Model Based on Memristor
HUA Honghu, XU Jia, ZHANG Bohao, WANG Wei, LI Zhiwei, LIU Haijun
2026, 48(9): 4081-4090. doi: 10.11999/JEIT260152
Abstract:
  Objective  With the slowdown of Complementary Metal-Oxide-Semiconductor (CMOS) technology scaling and the inherent memory-computation separation of von Neumann architectures, conventional computing systems face increasing challenges in processing large-scale sequential data. Memristors provide a promising solution because of their high integration density, fast switching speed, and synaptic plasticity. Memristor crossbar arrays naturally support Vector-Matrix Multiplication (VMM) in the analog domain, enabling energy-efficient in-memory computing. As a representative recurrent neural network, the Gated Recurrent Unit (GRU) has achieved excellent performance in sequential tasks such as trajectory prediction and urban sound classification. However, conventional hardware implementations of GRU networks require frequent data transfer between memory and processing units, resulting in high energy consumption and limited throughput. Although memristor-based GRU implementations improve computational efficiency, their large parameter size and high weight precision require substantial hardware resources and reduce deployment reliability on resource-constrained memristor arrays. In addition, device non-idealities, such as conductance fluctuations, further reduce inference accuracy. Existing memristor-based GRU methods generally treat weights and activations using the same quantization strategy without considering their different hardware implementation characteristics, and they provide limited robustness against device variations. This paper addresses these issues through a hardware-algorithm co-design strategy.  Methods  This paper proposes a lightweight memristor-based GRU network model. A 1T1R (one-transistor-one-resistor) memristor crossbar array is adopted for weight mapping and analog Multiply-ACcumulate (MAC) operations. Signed weights are represented by differential pairs of positive and negative conductance matrices because memristor conductance values are inherently non-negative. A linear transformation is used to map trained network weights to memristor conductance values. To account for the different hardware implementation paths of weights and activations, a device-aware fusion quantization method based on performance analysis is proposed. Symmetric quantization is applied to weights stored in the memristor array because the zero-centered quantization range eliminates zero-point storage and simplifies write-driver circuit design. In contrast, asymmetric quantization is applied to activation values computed in peripheral circuits, thereby preserving the dynamic range and reducing quantization error. To improve robustness against memristor conductance fluctuations, weight noise training is incorporated into Quantization-Aware Training (QAT). Gaussian noise with an intensity determined by the device variation parameter is injected into quantized weights during each forward pass. This strategy acts as a regularizer that guides the model toward flatter loss minima and improves tolerance to weight perturbations. During backpropagation, the straight-through estimator updates the full-precision floating-point weights, whereas noise is dynamically resampled in every forward pass.  Results and Discussions  On the public UrbanSound8K dataset, the proposed full-precision lightweight memristor-based GRU network model achieves a classification accuracy of 93.94%. After applying the device-aware fusion quantization method, the 6-bit quantized model achieves 92.68% accuracy, corresponding to only a 1.26% decrease while reducing weight precision by 81.25% (Table 1). The proposed model outperforms Dilated Convolution (78.00%), LM-MFCC+GRU (92.00%), TFFS-DNN (88.74%), TFCNN (93.10%), and CL-Transformer (92.95%) under their full-precision settings (Table 2). Under noisy input conditions with Signal-to-Noise Ratios (SNRs) ranging from –10 dB to 10 dB, the 6-bit quantized model exhibits robustness comparable to or better than that of the full-precision model, demonstrating the effectiveness of the proposed device-aware fusion quantization strategy (Table 3). From the perspectives of storage, hardware resources, and device feasibility, 6-bit quantization reduces weight storage from 5.6 MB to 1.05 MB, corresponding to a compression ratio of 81.2%, while requiring only 2.8 million memristor cells under the 1T1R mapping scheme. Weight noise training also substantially improves robustness against device non-idealities. When the conductance variation reaches 14%, the classification accuracy increases from 82.97% to 91.14%. At the maximum simulated variation of 28%, the accuracy increases from 54.23% to 87.01% (Fig. 7), demonstrating improved tolerance to memristor device variations. On a self-constructed true-false trajectory dataset, the lightweight memristor-based GRU network model achieves 97.35% accuracy at full precision and 96.51% after 6-bit quantization, with only a 0.84% decrease, outperforming the Dilated Convolution baseline (Table 4). To further verify its applicability to different sequential tasks, the lightweight memristor-based GRU network model is evaluated on lithium-ion battery State-of-Charge (SOC) estimation using a public dataset. The 6-bit quantized model achieves Root Mean Square Errors (RMSEs) of 1.48%, 0.79%, and 0.74% at 0 °C, 25 °C, and 45 °C, respectively, outperforming the existing memristor-based GRU implementation. The proposed model also achieves lower RMSEs than the comparison method at all evaluated quantization precisions of 6 bit and above (Table 5).  Conclusions  This paper presents a lightweight memristor-based GRU network model for hardware deployment. By combining device-aware fusion quantization with weight noise training integrated into Quantization-Aware Training (QAT), the model achieves substantial memory compression while maintaining high classification accuracy and improving robustness to memristor device non-idealities. Experimental results on multiple datasets and sequential tasks demonstrate that the 6-bit quantized model preserves competitive accuracy and stable performance, providing an effective solution for deploying GRU networks on resource-constrained memristor-based edge computing platforms.
A Reconfigurable Parallelized Coprocessor Design for the RISC-V-based Grain Cryptographic Algorithm
NAN Longmei, WANG Haoyu, DU Yiran, LI Wei, CHEN Tao
2026, 48(9): 4091-4104. doi: 10.11999/JEIT260391
Abstract:
  Objective  To address the performance limitations of Grain cryptographic algorithms on General-Purpose Processors (GPPs), as well as the inflexibility and high hardware overhead of Application-Specific Integrated Circuit (ASIC) implementations, a dedicated cryptographic hardware accelerator is integrated into an RISC-V coprocessor through a custom instruction extension mechanism. A reconfigurable parallelized architecture is proposed for the Grain algorithm family based on the RISC-V coprocessor interface. Corresponding custom instructions are designed to support the flexible and efficient execution of Grain-80, Grain-128, Grain-128a, and Grain-128AEAD on a unified hardware platform. The proposed architecture provides a favorable balance between processing efficiency, design flexibility, and hardware resource overhead, making it suitable for resource-constrained embedded systems.  Methods  A unified shift-register architecture is adopted to support flexible switching among Grain-80, Grain-128, Grain-128a, and Grain-128AEAD, with a configurable parallelization degree of 1 to 8. To implement the custom instructions for the Grain cryptographic algorithms, the software and hardware functions are analyzed, and the cryptographic process is divided between the processor and coprocessor to achieve efficient execution. The proposed coprocessor uses a streamlined architecture that reuses common hardware resources across the four algorithms. Combined with a configurable feedback tap selection network and feedback logic tailored to a predefined set of algorithms, the architecture enables reconfigurable parallel execution with limited additional hardware resource overhead.  Results and Discussions  The proposed custom instructions enable flexible implementation of four Grain cryptographic algorithms on the same hardware platform. Compared with implementations without instruction extensions, the proposed custom instructions reduce the number of clock cycles and instructions required for cryptographic processing while improving throughput (Table 5). On the Hummingbird E203 platform with a parallelization degree of 4, the proposed implementation requires 105, 129, and 183 clock cycles for Grain-80, Grain-128/Grain-128a, and Grain-128AEAD, respectively, with corresponding throughputs of 220.67, 179.74, and 126.70 Mbit/(s·Hz). Compared with purely software-based implementations, the proposed approach substantially reduces both the number of executed instructions and the number of clock cycles (Table 5). Synthesis results further demonstrate that the coprocessor occupies 7 252.55 μm² in a 65 nm process and achieves a throughput of 1.56 Gbit/(s·Hz) at a parallelization degree of 4. Although the reconfigurable architecture requires slightly more area than a dedicated single-algorithm implementation, it supports four Grain algorithms on a unified hardware platform and provides improved hardware resource reuse and design flexibility.  Conclusions  A hardware-software cooperative reconfigurable parallelization scheme is designed to accelerate the Grain cryptographic algorithm family in lightweight embedded systems. The scheme exploits the RISC-V custom instruction extension mechanism and combines a unified shift-register architecture, a configurable feedback tap selection network, and feedback logic tailored to a predefined set of algorithms. Four algorithms, namely Grain-80, Grain-128, Grain-128a, and Grain-128AEAD, can therefore be flexibly selected and processed in parallel on a single hardware platform. This design improves processing efficiency while maintaining design flexibility and limiting hardware resource overhead. The present work focuses on reconfigurable parallelization for the Grain algorithm family. Future research will investigate more general reconfigurable architectures for nonlinear Boolean functions by incorporating configurable units, such as LookUp Tables (LUTs) or programmable logic arrays. Such architectures may further improve compatibility with multiple stream cipher algorithms while maintaining high throughput and low hardware resource overhead.
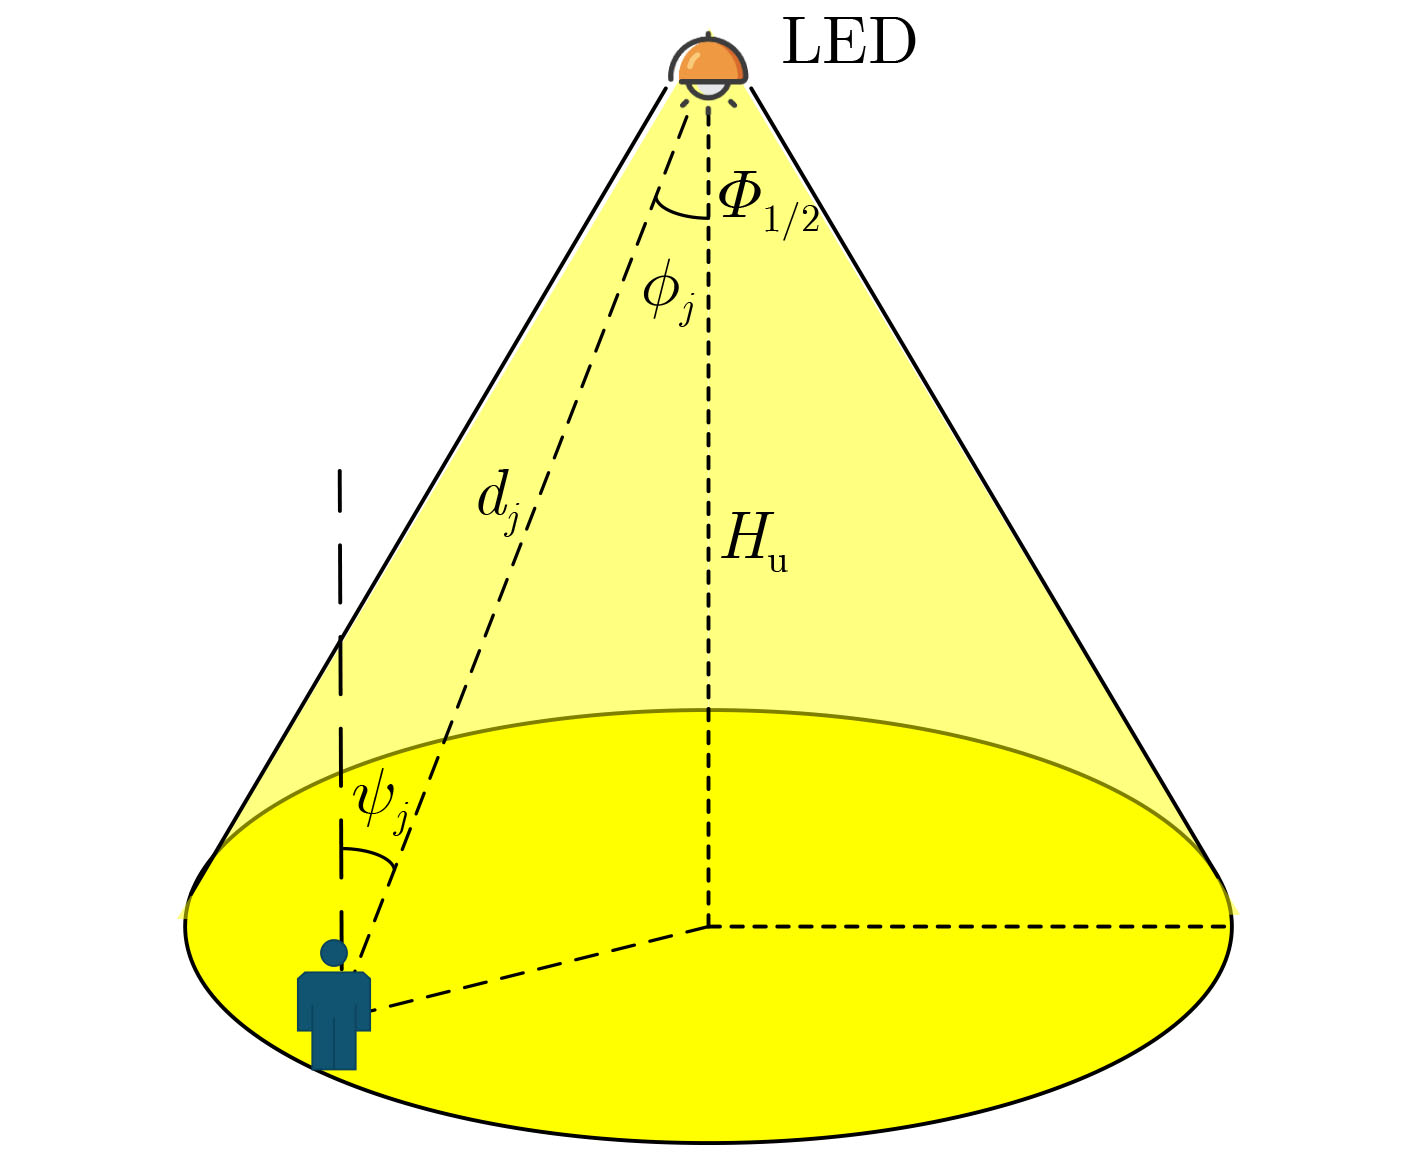
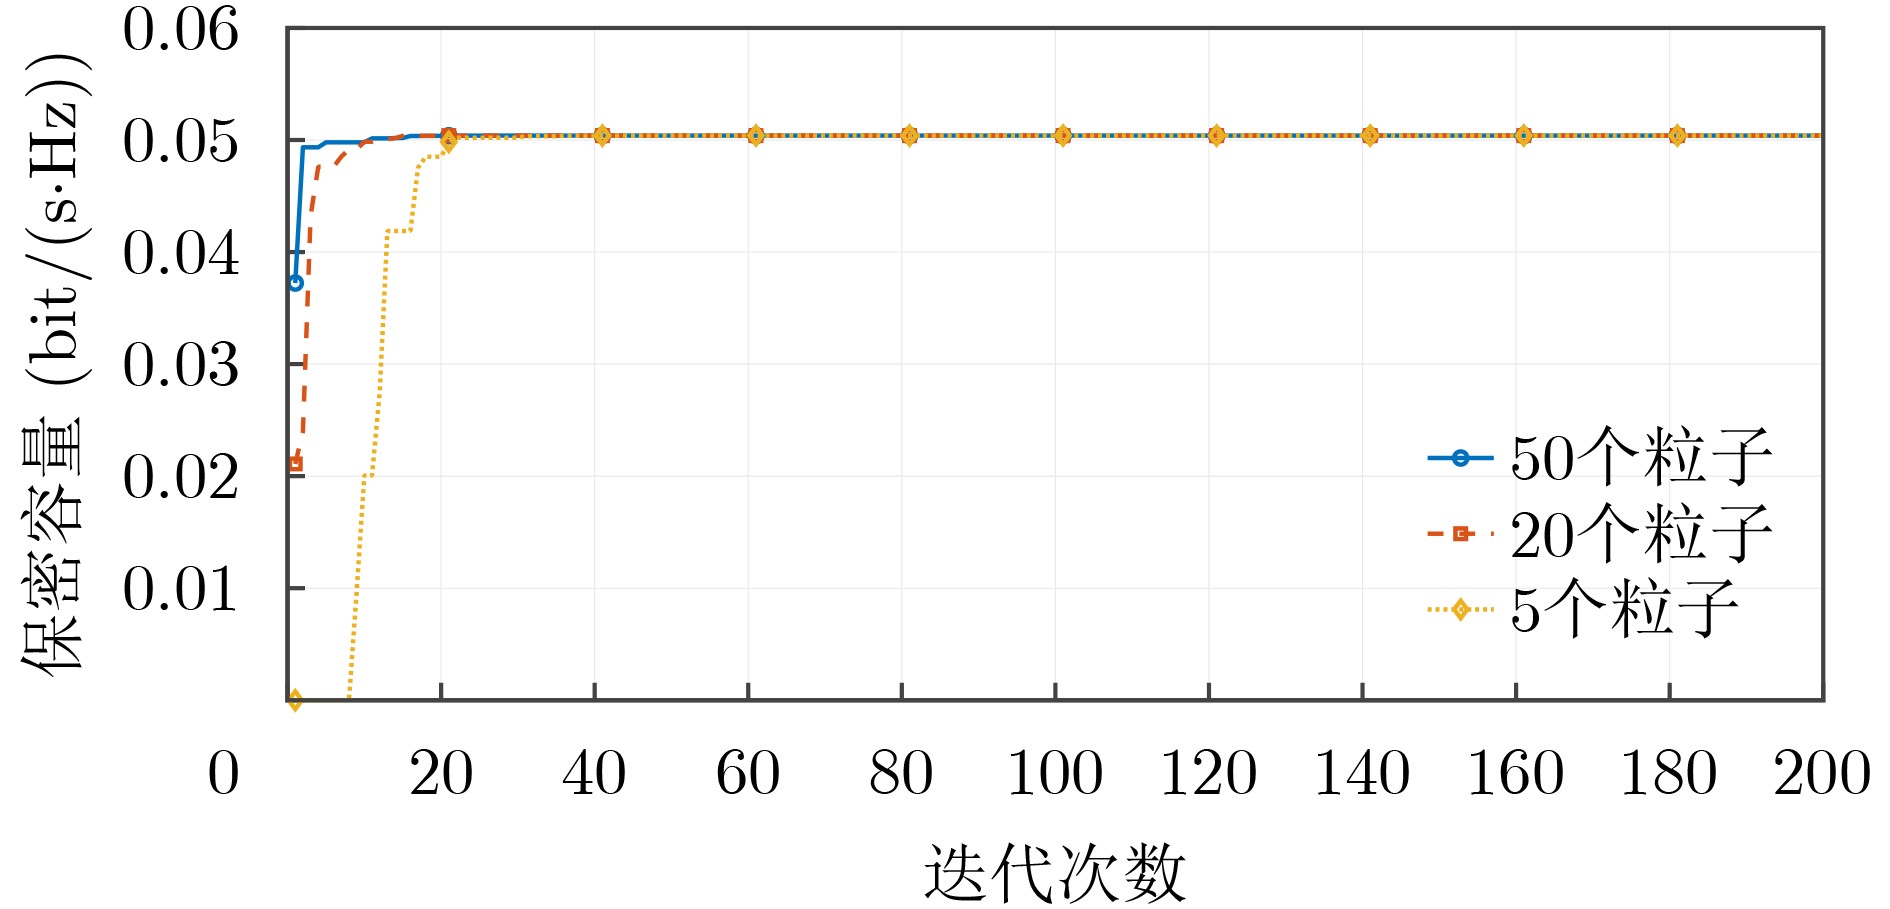
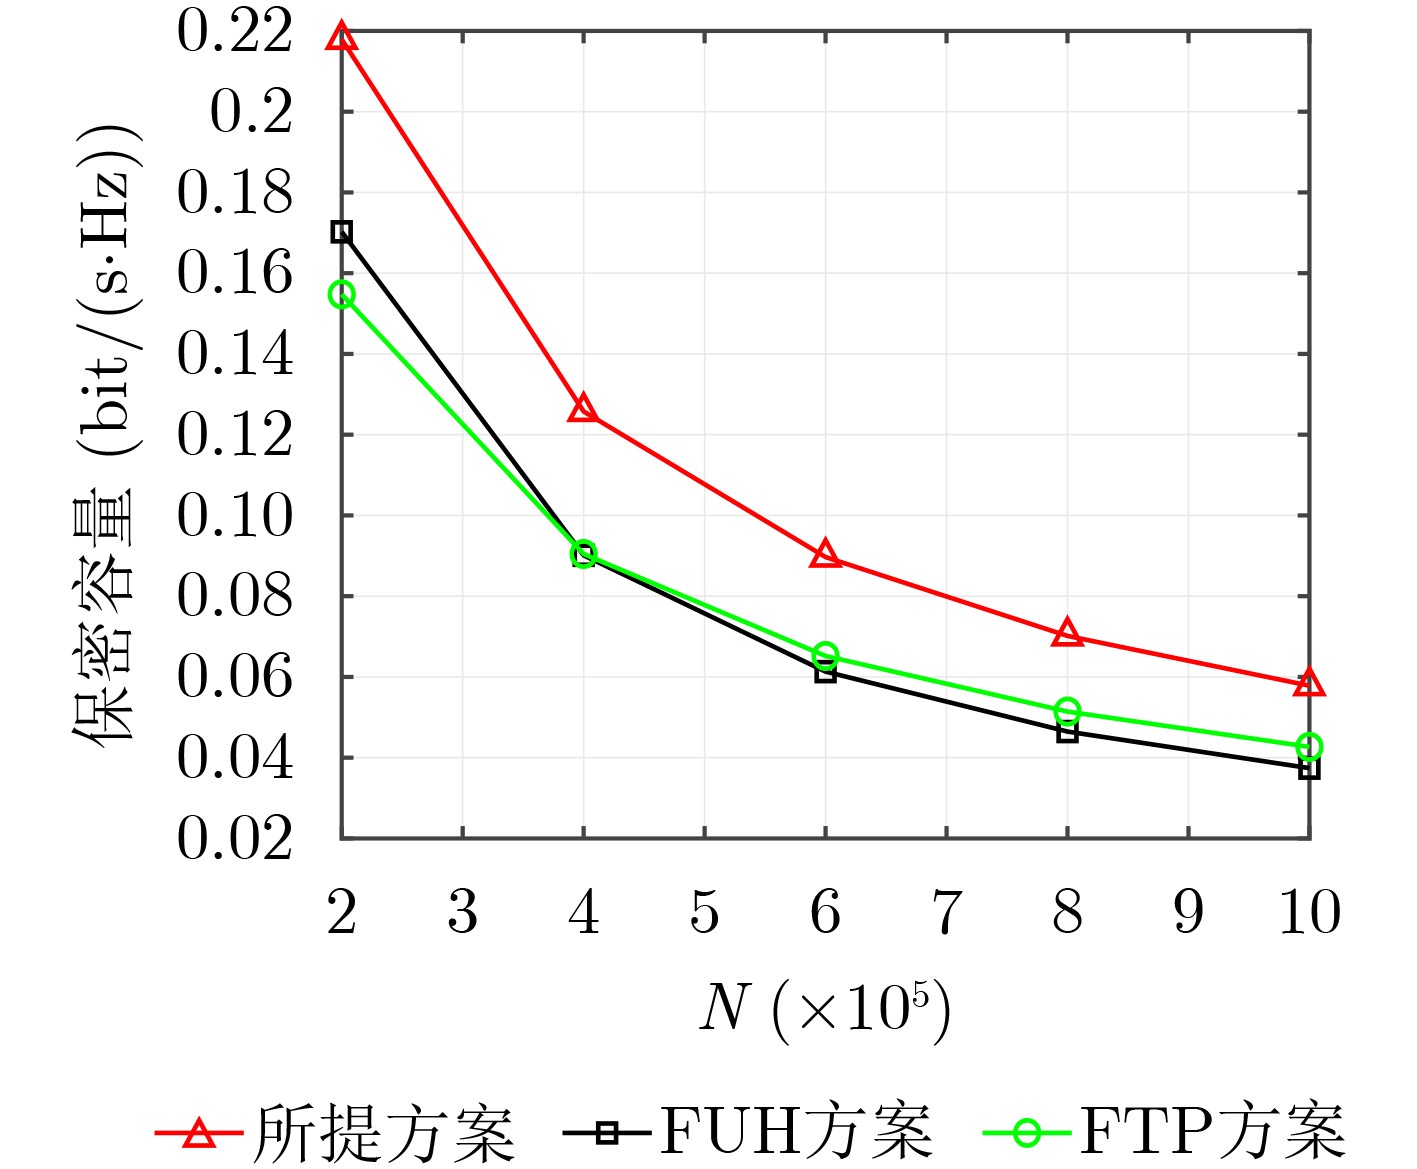
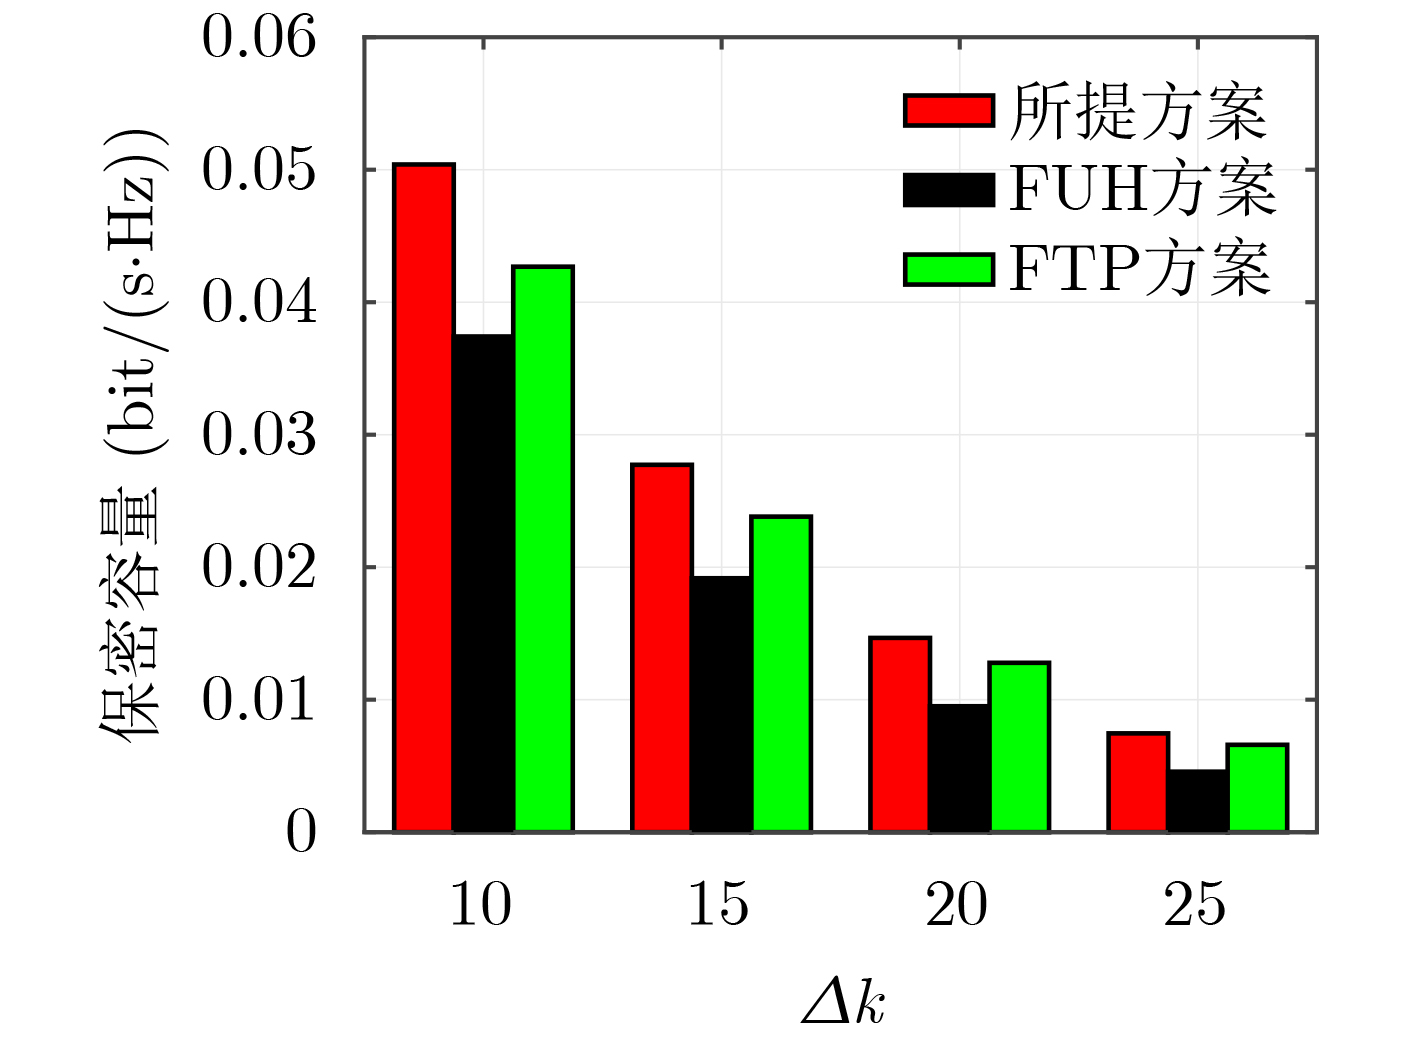
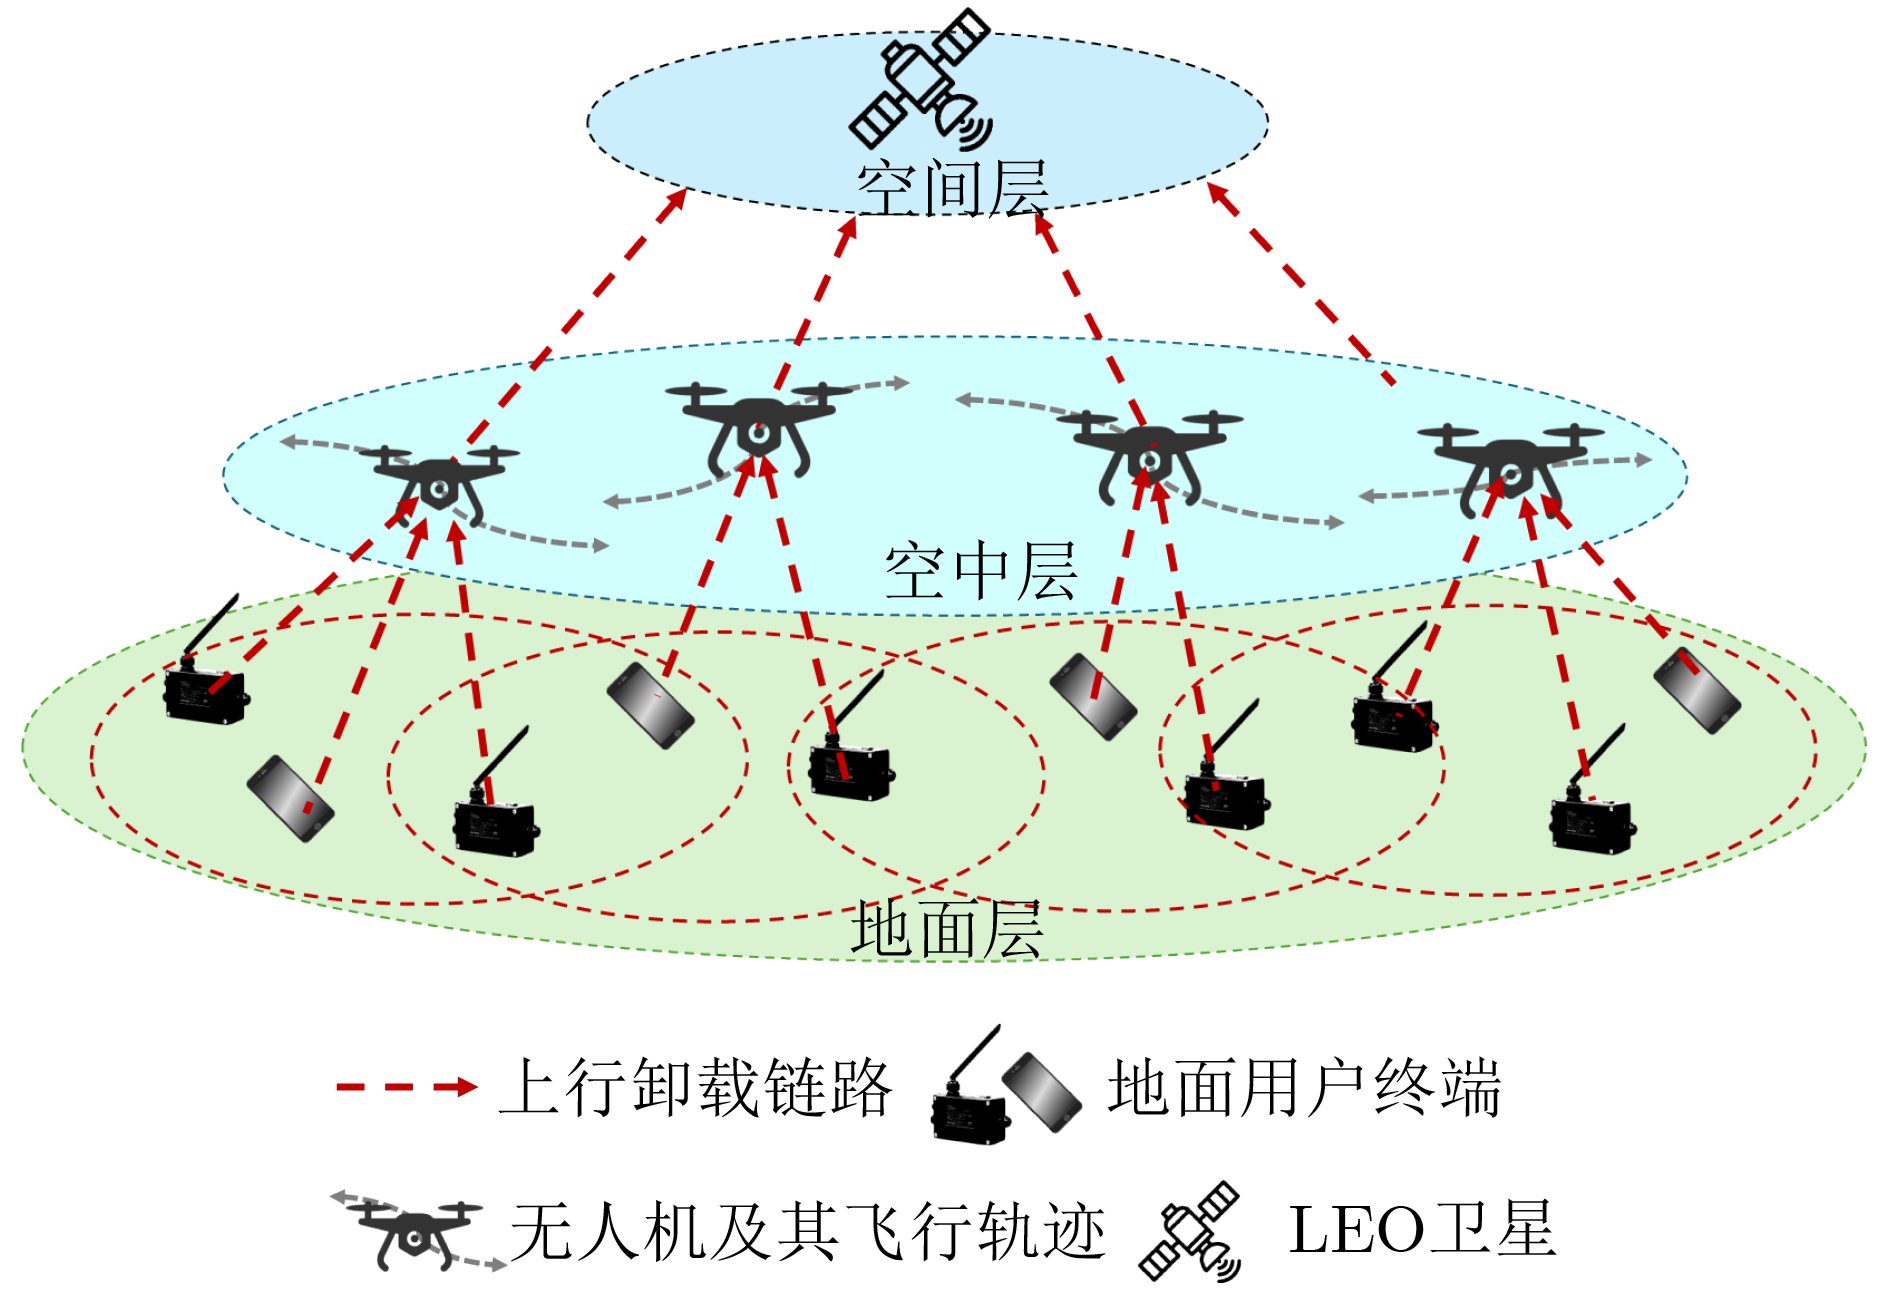
Intelligent Privacy-Aware Computation Offloading Method against Multi-server Joint Inference Attacks
MIN Minghui, LIU Mingcheng, ZHANG Peng, DUAN Jincheng, LI Shiyin, ZHANG Hongliang
2026, 48(9): 4105-4116. doi: 10.11999/JEIT260249
Abstract:
  Objective  With the rapid development of the low-altitude economy, services such as intelligent transportation, smart healthcare, and low-altitude logistics have become increasingly common. Their efficient operation depends on the real-time processing of massive sensing data. Mobile Edge Computing (MEC) improves task execution efficiency and reduces device computational burdens by offloading tasks to nearby servers. However, user privacy and security risks have become increasingly severe. In dynamic scenarios where multiple MEC servers jointly process tasks, information sharing can enable multi-server joint inference attacks and greatly increase the risk of user location privacy leakage. Although existing studies have used Differential Privacy (DP) to protect user location privacy, current DP-based solutions remain limited. These methods inject noise into offloading decisions, but unconstrained noise may reduce task allocation accuracy. In addition, user mobility causes continuous changes in channel states during dynamic computation offloading. Privacy leakage risks and attacker behaviors are also uncertain. Traditional optimization methods based on static system models are therefore unsuitable for such dynamic environments. To address these challenges, this paper proposes an Asynchronous Advantage Actor-Critic (A3C)-based Intelligent Privacy-Aware Computation Offloading (AIPCO) scheme against multi-server joint inference attacks. The proposed scheme protects user location privacy while maximizing the overall utility of the MEC system.  Methods  This paper proposes a DP-based task offloading rate perturbation mechanism. By adding controlled noise, the mechanism increases the randomness of user task offloading toward multiple MEC servers. A truncated Laplace mechanism is used to constrain the perturbed offloading rates within valid boundaries. This design satisfies the mathematical guarantees of DP and reduces the accuracy of multi-server joint inference attacks on sensitive user locations. Privacy entropy is then introduced to dynamically evaluate the real-time privacy protection level. Finally, the AIPCO scheme is constructed. Through a multi-threaded asynchronous training mechanism, the scheme interacts with the environment through iterative trial and error and efficiently learns the optimal real-time offloading policy online. The proposed scheme dynamically protects user privacy, reduces computational cost, and maximizes comprehensive system utility.  Results and Discussions  The AIPCO scheme jointly optimizes user privacy and task offloading cost by incorporating multidimensional performance variables into the reinforcement learning reward function. A comprehensive performance analysis (Fig. 4) shows that, when the number of continuous learning iterations reaches 200, the privacy protection level of AIPCO increases by 2.52%, 3.56%, and 22.90% compared with RCLM, JODRL, and DODA-DT, respectively. This advantage is mainly attributed to the DP-based task offloading rate perturbation method, which uses the truncated Laplace mechanism to increase data randomness while strictly constraining the perturbation range. By contrast, RCLM perturbs the task offloading rate through range-limited DP without using the truncated Laplace mechanism. JODRL increases randomness only through network policy optimization, resulting in a lower privacy protection level. DODA-DT focuses on balancing energy consumption and system latency without optimizing user privacy. For the privacy weight parameter (Fig. 5), increasing ω improves privacy protection. For example, the privacy protection level increases by 5.64% when ω rises from 0.2 to 0.7, with a clear performance gain at 0.7. As the system agent reduces its focus on computational cost, user utility remains optimal despite increased cost. When the physical distance between users and the MEC server is adjusted (Fig. 6), AIPCO shows stronger privacy protection in long-distance scenarios. A greater distance reduces the number of tasks offloaded to the server. Therefore, attackers obtain less information, and privacy protection improves. Although computational cost increases with distance, AIPCO consistently outperforms competing schemes. These results confirm that AIPCO achieves optimal MEC system utility while protecting user privacy.  Conclusions  To mitigate multi-server joint inference attacks caused by information sharing among collaborative MEC servers, this paper proposes an AIPCO method. A DP-based task offloading rate perturbation scheme is designed to increase randomness, and a truncated Laplace mechanism is used to constrain perturbed rates within reasonable boundaries. The scheme is proven to satisfy strict DP mathematical guarantees, and privacy entropy is introduced to quantitatively evaluate the privacy protection level. In addition, the AIPCO scheme uses a multi-threaded asynchronous training mode, enabling the agent to efficiently learn the optimal perturbed offloading policy in a continuous space and maximize overall system utility. Simulation results show that the proposed scheme outperforms the baselines in both dynamic and average performance. It achieves optimal system utility while protecting user privacy.
A Novel TDMOSFET and Its Neural Network Modeling for Ternary Logic Applications
LU Bin, LU Haoran, ZHAO Xiaohong, DI Jiayu, XING Linlin
2026, 48(9): 4117-4128. doi: 10.11999/JEIT260413
Abstract:
  Objective  Complementary Metal-Oxide-Semiconductor (CMOS) technology continues to advance toward smaller device dimensions and higher integration. As circuit integration increases, short-channel effects and other phenomena increase leakage current in MOSFET devices, resulting in higher static power consumption. With the rapid development of artificial intelligence, traditional binary logic faces limitations in processing and storing massive amounts of data. Ternary logic has therefore attracted increasing attention because it provides higher information density and lower system complexity than binary logic. However, current ternary logic circuits still face challenges, including the use of multiple components, passive elements, and poor compatibility with conventional CMOS processes.  Methods  A novel Tunneling-Drift-Diffusion Metal-Oxide-Semiconductor Field-Effect Transistor (TDMOSFET) that combines quantum tunneling and drift-diffusion mechanisms is proposed. The device exhibits a constant off-state current characteristic, making it suitable for ternary logic applications. Its operating principle is analyzed, and an Artificial Neural Network (ANN) is used to model its electrical characteristics. The ANN model is trained using Technology Computer-Aided Design (TCAD) simulation data to predict the current-voltage (I-V) and capacitance-voltage (C-V) characteristics. The trained ANN model is further converted into a Verilog-A model and integrated into HSPICE to simulate basic ternary logic circuits, including the Standard Ternary Inverter (STI), Negative Ternary Inverter (NTI), Positive Ternary Inverter (PTI), Ternary NOT-AND gate (T-NAND), and Ternary NOT-OR gate (T-NOR).  Results and Discussions  The trained ANN model accurately predicts the I-V and C-V characteristics of the TDMOSFET. Compared with the TCAD results, the maximum relative errors for the drain current (IDS), gate-drain capacitance (CGD), and gate-source capacitance (CGS) are 39.43%, 5.05%, and 14.19%, respectively, whereas the corresponding average relative errors are 0.46%, 0.69%, and 0.51%. The ANN model is successfully converted into a Verilog-A model and integrated into HSPICE for circuit-level simulation. The STI, NTI, PTI, T-NAND, and T-NOR circuits are successfully simulated. The TDMOSFET-based ternary logic circuits do not require passive elements and are compatible with conventional CMOS processes.  Conclusions  A novel TDMOSFET with dual conduction mechanisms is proposed. When the gate-source voltage is below the turning voltage (Vturn), band-to-band tunneling is the dominant conduction mechanism, and the device operates similarly to a reverse-biased tunneling diode. When the gate-source voltage exceeds Vturn, the drift-diffusion mechanism becomes dominant, and the device exhibits characteristics similar to those of a conventional MOSFET. The proposed device maintains compatibility with conventional CMOS processes, simplifying the manufacturing process and reducing cost and integration complexity. TDMOSFET-based ternary logic circuits realize ternary operation without increasing the number of transistors, using passive elements, or requiring multivalued supply voltages. The proposed TCAD simulation → ANN modeling → Verilog-A modeling → HSPICE simulation framework can also be applied to the study of other emerging semiconductor devices.
MG-MoE: Routed Multi-Granularity Expert Ensemble
XIAN Fengyu, JIAN Haifang, XIE Zihui, DU Jun, ZHANG Yuanyuan, NING Xin, DONG Miaomiao, WANG Hongchang
2026, 48(9): 4129-4138. doi: 10.11999/JEIT260219
Abstract:
  Objective  Fine-Grained Image Recognition (FGIR) aims to distinguish visually similar subcategories that differ only in subtle local patterns. It must also remain robust to large intra-class variations caused by pose changes, occlusion, illumination shifts, and complex backgrounds. In real-world scenarios, these challenges are further intensified by long-tailed category distributions. Rare or difficult classes are more likely to overfit spurious contextual cues and suffer from unstable decision boundaries. Therefore, a conditional computation paradigm is needed, in which complementary inductive biases are separated into specialized expert branches and adaptively combined for each sample. This work aims to develop a routed multi-granularity mixture-of-experts framework that improves discriminative performance under controllable inference cost. It also enhances robustness for difficult samples and long-tailed categories through adaptive sparse expert activation.  Methods  A Multi-Granularity Mixture-of-Experts (MG-MoE) model is proposed. It is a routed ensemble architecture composed of a shared backbone, four heterogeneous experts, and a learnable router that predicts input-conditioned expert weights (Fig. 2). The experts are designed with complementary inductive biases to address key factors in FGIR. MPSA emphasizes global structure and contour-level semantics. PMG captures fine local details through multi-granularity part modeling. TransFG focuses on pose and deformation modeling. PIM improves robustness in cluttered backgrounds through background suppression. To limit interference and reduce unnecessary computation, MG-MoE adopts sparse fusion. Only the Top-K experts, with K=2 by default, contribute to the final prediction during inference. To improve routing stability and generalization, a two-stage optimization strategy is designed. In the first stage, dynamic cluster-level training is performed. A cluster-level soft teacher distribution is constructed from validation-set statistics and imposed through Kullback-Leibler (KL) divergence regularization. This process stabilizes routing behavior and promotes effective expert specialization. In the second stage, residual fine-tuning is conducted. The feature-driven routing mechanism is kept unchanged, while the classification heads of the Top-2 experts associated with each cluster are selectively unfrozen. The router and expert heads are then jointly optimized with grouped learning rates. This design reduces fusion bias and strengthens discrimination for difficult samples and long-tailed categories.  Results and Discussions  MG-MoE achieves strong performance on standard FGIR benchmarks. On CUB-200-2011, it obtains 92.89% Top-1 accuracy. This result is higher than those of representative expert backbones used individually, including MPSA (91.23%), PIM (91.17%), and TransFG (90.49%). It also outperforms the multi-granularity baseline PMG (88.32%) (Table 1). On the Bird-1445 sampled set, MG-MoE achieves 96.80% Top-1 accuracy and consistently improves over strong baselines (Table 2). These results indicate that routed multi-expert specialization remains effective in data-limited and highly similar fine-grained scenarios. The efficiency-accuracy trade-off is summarized in Table 3. With Top-2 sparse routing, MG-MoE reaches 92.89% accuracy with a compute budget of 143.9 GFLOPs. It avoids dense expert activation during inference by selecting only the Top-2 experts for each sample, thereby achieving a favorable balance between accuracy and efficiency. Ablation experiments show that increasing K beyond 2 does not yield consistent gains, which suggests that indiscriminate fusion can dilute discriminative evidence. Top-2 fusion produces the best performance, whereas Top-1 fusion is more sensitive to routing errors and larger K values may introduce noise and reduce accuracy (Table 4). The role of expert diversity and composition is also analyzed. Two- and three-expert variants generally underperform the full four-expert configuration, indicating that each inductive bias contributes to different fine-grained difficulty factors. In contrast, adding homogeneous experts without new functional diversity brings diminishing or negative gains, which is consistent with increased routing ambiguity and limited expert complementarity (Table 5). These results support the use of a compact set of heterogeneous experts combined with sparse routing. To interpret the learned specialization, category-wise routing statistics are visualized. The expert-category heatmap shows that MPSA receives dominant routing weights across many categories, reflecting the central role of global structure in fine-grained discrimination. PIM and TransFG show higher activation for specific difficult categories, which is consistent with their roles in background suppression and pose and deformation modeling (Fig. 3). Finally, t-SNE visualizations illustrate the qualitative effect of expert fusion on class separability. Shared backbone features show stronger inter-class entanglement among visually similar subcategories. In contrast, fused outputs form clearer clusters with better between-class separation and within-class compactness, indicating a more reliable decision space shaped by routed expert aggregation (Fig. 4).  Conclusions  MG-MoE is a multi-granularity routed mixture-of-experts framework for fine-grained recognition. By combining four complementary experts, Top-2 sparse fusion, and a two-stage optimization strategy for stable routing and calibrated fusion, MG-MoE improves recognition accuracy on CUB-200-2011 and the Bird-1445 sampled set. It also provides interpretable evidence of expert specialization (Table 1, Table 2, Fig. 3, Fig. 4). Ablation results confirm that controlled Top-2 fusion and heterogeneous expert design are key to the observed performance gains. Overly dense fusion or homogeneous expert expansion provides limited benefit (Table 4, Table 5).
A Low-latency Synchronization Header Detection Algorithm and Circuit for the JESD204C Interface
YIN Peng, ZHANG Chao, LEI Changan, HOU Weizhou, SHU Zhou, LIU Shubin, ZHU Zhangming
2026, 48(9): 4139-4149. doi: 10.11999/JEIT260163
Abstract:
  Objective  With rapid advances in high-speed electronics, front-end Analog-to-Digital Converters and Digital-to-Analog Converters (ADCs/DACs) continue to increase in sampling rate and resolution. Back-end Field-Programmable Gate Arrays and Application-Specific Integrated Circuits (FPGAs/ASICs) also provide stronger computing capability. These trends impose strict requirements on high-speed data interfaces, including high bandwidth, low latency, low power consumption, and reliable synchronization. As a mainstream high-speed Serializer/Deserializer (SerDes) interface, the JESD204C interface still suffers from long link initialization latency and high synchronization power consumption. These limitations restrict system real-time performance and energy efficiency. To address these issues, this study optimizes the link-layer design of the JESD204C receiver and proposes an efficient Synchronization Header (SH) detection method. The method implements exponential compression of the search set through global observation and iterative convergence. Detection efficiency is improved, fast and accurate SH positioning is achieved, link synchronization latency is reduced, and synchronization stability and energy efficiency are enhanced.  Methods  A typical JESD204C interface uses serial sliding detection for SH detection, which causes high link initialization latency and large delay jitter. To solve these problems, an Iterative Set Screening (ISS)-based SH detection algorithm is proposed. The SH detection task is modeled as the rapid localization of a deterministic pattern in a binary random sequence. A theoretical model based on information theory and stochastic processes is constructed. Expected space utilization and Bit Error Rate (BER) are introduced to support quantitative performance evaluation. In this model, SH candidate positions are defined as a dynamic set. Based on the inherent polarity inversion characteristic of the SH and global observations in each clock cycle, multilevel XOR logic is used to verify all candidate hypotheses in parallel. Non-inverting candidate positions are eliminated, and the search space is dynamically compressed. This design improves synchronization speed and position robustness, providing a low-latency and reliable initialization solution for high-speed SerDes links.  Results and Discussions  The proposed ISS-based SH detection algorithm is validated under harsh conditions, including SH crossing block boundaries and loss of lock caused by burst errors. The results demonstrate strong robustness, with rapid SH locking and link resynchronization under all test conditions (Figs. 11~16). To evaluate performance, four representative schemes are reproduced: a single-bit serial locking circuit, a 66-bit serial locking architecture, a register-intensive block synchronization method, and a parallel search circuit. A systematic comparison is then conducted between these schemes and the proposed design. The results show that the normalized locking time of the single-bit serial locking circuit, 66-bit serial locking architecture, and register-intensive block synchronization method varies substantially with SH position (Fig. 17(a)), especially at block boundari0es (Fig. 17(b)). When the SH is located at the Most Significant Bit (MSB), typical sliding detection requires about 1.8 times the time needed at the Least Significant Bit (LSB), indicating strong sensitivity to the starting position and search path. In contrast, the proposed ISS scheme maintains a stable normalized locking time within 1.0 ± 0.05 across all positions, with the standard deviation reduced by more than 70%. By evaluating all candidate positions equally through parallel filtering, the scheme eliminates position dependence. Synchronization can be completed within tens of clock cycles whether the SH is located at the LSB, the MSB, or any other position in the block. The experimental results verify that the ISS algorithm improves synchronization robustness and predictability while accelerating link initialization. Table 3 summarizes the performance metrics. The average locking time is only 24.4 clock cycles, representing an overall improvement of more than 70% compared with the single-bit serial locking circuit, 66-bit serial locking architecture, and register-intensive block synchronization method. The standard deviation of locking time is only 4.7, indicating a more stable synchronization process. In terms of resource utilization, the design consumes 509 Look-Up Tables (LUTs) and only 2.0 mW, much lower than the 3 503 LUTs and 94.1 mW required by the register-intensive scheme. Its energy efficiency reaches 0.03 mW/bit, which is better than those of the three conventional methods. Compared with the parallel search circuit, the average locking time is reduced by 6.87%, power consumption is reduced by 53.5%, and energy efficiency is improved by 53.8%. Therefore, the proposed JESD204C receiver link shows advantages in SH detection speed, stability, power consumption, and energy efficiency.  Conclusions  An ISS-based SH detection algorithm is proposed for the JESD204C receiver. By screening the data stream in parallel through multilevel XOR logic, dynamically compressing the search space, and efficiently eliminating non-inverting candidate positions, the algorithm converges to the true SH position. This approach improves the conventional serial detection mechanism. The design is verified on the Xilinx KC705 FPGA platform. A Pseudorandom Binary Sequence 31 (PRBS31) is used to emulate the random distribution of polarity transitions, and a high-speed SubMiniature version A (SMA) cable is used for data loopback transmission. The results show that the algorithm achieves an average locking time of only 24.4 clock cycles, with a standard deviation as low as 4.7. High robustness is maintained for the SH at any position within the 66-bit block, and the energy efficiency reaches 0.03 mW/bit. The algorithm is superior to existing typical schemes in locking speed, delay stability, and energy efficiency. It provides a low-latency, reliable, and energy-efficient synchronization initialization approach for high-speed SerDes links.
Construction of a DNA Strand Displacement Memristor and Its Filter Circuit Characteristics
WANG Yanfeng, CHEN Guanzhou, SUN Ce, SUN Junwei
2026, 48(9): 4150-4162. doi: 10.11999/JEIT260283
Abstract:
  Objective  Filter circuits are widely used in modern control and signal-processing systems for noise suppression and signal integrity enhancement. Conventional Resistor-Capacitor (RC) filters are widely applied, but their fixed parameters limit adaptability and miniaturization in emerging molecular and nanoscale computing platforms. To address these limitations, DNA Strand Displacement (DSD) technology is integrated with memristor theory to develop tunable multistable molecular filter circuits. This study aims to design and validate first- and second-order low-pass filter circuits based on the dynamic response and state-dependent behavior of a DSD-based memristor. The proposed filters are designed to improve frequency selectivity, parameter adaptability, and system stability compared with traditional filter architectures. This approach is intended for molecular signal processing, integrated biocircuits, and adaptive filtering systems that require compact size and reconfigurability.  Methods  The method consists of four stages. First, core DSD reaction modules, including sine, cosine, integration, addition, and multiplication modules, are designed to construct a programmable multistable memristor model. Second, square-wave and sinusoidal input signals are generated through DSD reactions to evaluate the memristor response under different frequencies and amplitudes. Third, the memristor is embedded into low-pass filter structures to construct first- and second-order DSD-based memristor filter circuits. Fourth, simulations are performed using Visual DSD for molecular dynamics analysis and MATLAB for circuit-level analysis. Circuit performance is evaluated using transfer functions, Nyquist plots, Bode diagrams, and time-domain comparisons with classical RC filters. This combined simulation strategy verifies both molecular feasibility and circuit functionality.  Results and Discussions  The DSD-based memristor exhibits multistable behavior and converges to six stable equilibrium points under different initial conditions (Fig. 8). Its hysteresis characteristics further confirm the state-dependent memory behavior of the designed molecular memristor (Fig. 7). The first-order DSD-based memristor filter circuit provides stable attenuation for square-wave and sinusoidal input signals. Its output amplitudes are consistently higher than those of the traditional RC filter across the tested frequencies (Table 3). The second-order DSD-based memristor filter circuit further reduces signal delay and improves stability, especially under high-frequency inputs (Table 4). Frequency-response analyses show that the cutoff frequency can be dynamically tuned by adjusting DSD reaction rates and initial concentrations (Figs. 9 and 11). Time-domain simulations further confirm the filtering performance of the first- and second-order circuits (Figs. 10 and 12). Reliability analysis indicates that lower initial copy numbers increase stochastic molecular noise, whereas higher initial copy numbers make the output distribution closer to the deterministic response and improve the probability of successful filtering. These results verify the feasibility of DSD-memristor integration for adaptive molecular filtering.  Conclusions  A DSD-based memristor with multistable characteristics and its corresponding first- and second-order low-pass filter circuits are designed and validated. Compared with traditional RC architectures, the proposed filters show improved output stability, parameter tunability, and frequency adaptability. By combining DSD technology with memristor theory, this study provides a reconfigurable molecular-scale filtering framework for signal-processing applications. The results provide a basis for future work on adaptive molecular circuits, intelligent filtering, and nanoelectronic system design. Further studies should focus on experimental validation, real-time tuning strategies, sequence optimization, anti-interference design, signal amplification, and circuit integration.