| Citation: | LIU Peng, LUO Jihao, WANG Xinyi, FEI Zesong. Communication, Sensing, and Computation in Low-Altitude Embodied Intelligence: From Functional Integration to Closed-Loop Coordination[J]. Journal of Electronics & Information Technology. doi: 10.11999/JEIT261177

|

| [1] |
国务院. 政府工作报告[EB/OL]. https://www.gov.cn/gongbao/2024/issue_11246/202403/content_6941846.html, 2024.
State Council of the People’s Republic of China. Report on the work of the government[EB/OL]. https://www.gov.cn/gongbao/2024/issue_11246/202403/content_6941846.html, 2024. (查阅网上资料,未找到对应的英文翻译,请确认).
|
| [2] |
中共中央. 中共中央关于进一步全面深化改革、推进中国式现代化的决定[R]. 2024. (查阅网上资料, 未找到本条文献信息, 请确认).
Central Committee of the Communist Party of China. Resolution of the central committee of the communist party of china on further deepening reform comprehensively to advance Chinese modernization[R]. 2024.
|
| [3] |
国务院. 政府工作报告[EB/OL]. https://www.gov.cn/yaowen/liebiao/202503/content_7013163.htm, 2025.
State Council of the People’s Republic of China. Report on the work of the government[EB/OL]. https://www.gov.cn/yaowen/liebiao/202503/content_7013163.htm, 2025. (查阅网上资料,未找到对应的英文翻译,请确认).
|
| [4] |
国务院. 政府工作报告[EB/OL]. https://www.gov.cn/gongbao/2026/issue_12646/202603/content_7064134.html, 2026.
State Council of the People’s Republic of China. Report on the work of the government[EB/OL]. https://www.gov.cn/gongbao/2026/issue_12646/202603/content_7064134.html, 2026. (查阅网上资料,未找到对应的英文翻译,请确认).
|
| [5] |
工业和信息化部, 科学技术部, 财政部, 等. 工业和信息化部 科学技术部 财政部 中国民用航空局关于印发《通用航空装备创新应用实施方案(2024-2030年)》的通知[EB/OL]. https://www.gov.cn/zhengce/zhengceku/202403/content_6942115.htm, 2024.
Ministry of Industry and Information Technology, Ministry of Science and Technology, Ministry of Finance, et al. Implementation plan for innovative applications of general aviation equipment (2024–2030)[EB/OL]. https://www.gov.cn/zhengce/zhengceku/202403/content_6942115.htm, 2024. (查阅网上资料,未找到对应的英文翻译,请确认).
|
| [6] |
中华人民共和国中央人民政府. 中华人民共和国国民经济和社会发展第十五个五年规划纲要[EB/OL]. https://www.gov.cn/yaowen/liebiao/202603/content_7062633.htm, 2026.
The Central People’s Government of the People's Republic of China. Outline of the 15th five-year plan for national economic and social development of the People’s Republic of China[EB/OL]. https://www.gov.cn/yaowen/liebiao/202603/content_7062633.htm, 2026.
|
| [7] |
FEI Zesong, WANG Xinyi, WU Nan, et al. Air-ground integrated sensing and communications: Opportunities and challenges[J]. IEEE Communications Magazine, 2023, 61(5): 55–61. doi: 10.1109/MCOM.007.2200459.
|
| [8] |
MU Junsheng, ZHANG Ronghui, CUI Yuanhao, et al. UAV meets integrated sensing and communication: Challenges and future directions[J]. IEEE Communications Magazine, 2023, 61(5): 62–67. doi: 10.1109/MCOM.008.2200510.
|
| [9] |
DUAN Jiafei, YU S, TAN Huili, et al. A survey of embodied AI: From simulators to research tasks[J]. IEEE Transactions on Emerging Topics in Computational Intelligence, 2022, 6(2): 230–244. doi: 10.1109/TETCI.2022.3141105.
|
| [10] |
LUO Jihao, FEI Zesong, WANG Xinyi, et al. Toward low-altitude embodied intelligence: A sensing-communication-computation-control closed-loop perspective[J]. IEEE Communications Magazine, 2026, 64(9): 110–117. doi: 10.1109/MCOM.001.2600091.
|
| [11] |
WEN Dingzhu, ZHOU Yong, LI Xiaoyang, et al. A survey on integrated sensing, communication, and computation[J]. IEEE Communications Surveys & Tutorials, 2025, 27(5): 3058–3098. doi: 10.1109/COMST.2024.3521498.
|
| [12] |
LIU Fan, CUI Yuanhao, MASOUROS C, et al. Integrated sensing and communications: Toward dual-functional wireless networks for 6G and beyond[J]. IEEE Journal on Selected Areas in Communications, 2022, 40(6): 1728–1767. doi: 10.1109/JSAC.2022.3156632.
|
| [13] |
吴子君, 张海君, 马旭, 等. 6G通感算一体化体系架构与关键技术[J]. 电子与信息学报, 2025, 47(4): 876–887. doi: 10.11999/JEIT241151.
WU Zijun, ZHANG Haijun, MA Xu, et al. System architecture and key technologies of 6G integrated sensing, communication, and computing[J]. Journal of Electronics & Information Technology, 2025, 47(4): 876–887. doi: 10.11999/JEIT241151.
|
| [14] |
武燕燕, 吴松, 邓伟. 6G天地一体通感算智能协同网络资源管理技术综述[J]. 电子与信息学报, 2025, 47(8): 2448–2472. doi: 10.11999/JEIT250140.
WU Yanyan, WU Song, and DENG Wei. An overview of resource management technology of 6G integrated communication, sensing, and computation enabled satellite-terrestrial intelligent network[J]. Journal of Electronics & Information Technology, 2025, 47(8): 2448–2472. doi: 10.11999/JEIT250140.
|
| [15] |
朱政宇, 殷梦琳, 姚信威, 等. AI赋能的通感算一体化关键技术研究综述[J]. 电子与信息学报, 2025, 47(10): 3426–3438. doi: 10.11999/JEIT250242.
ZHU Zhengyu, YIN Menglin, YAO Xinwei, et al. Overview of the research on key technologies for AI-powered integrated sensing, communication and computing[J]. Journal of Electronics & Information Technology, 2025, 47(10): 3426–3438. doi: 10.11999/JEIT250242.
|
| [16] |
GU Xiaohui and ZHANG Guoan. A survey on UAV-assisted wireless communications: Recent advances and future trends[J]. Computer Communications, 2023, 208: 44–78. doi: 10.1016/j.comcom.2023.05.013.
|
| [17] |
MARSHALL J A, SUN Wei, and L’AFFLITTO A. A survey of guidance, navigation, and control systems for autonomous multi-rotor small unmanned aerial systems[J]. Annual Reviews in Control, 2021, 52: 390–427. doi: 10.1016/j.arcontrol.2021.10.013.
|
| [18] |
CHIRIYATH A R, PAUL B, and BLISS D W. Radar-communications convergence: Coexistence, cooperation, and co-design[J]. IEEE Transactions on Cognitive Communications and Networking, 2017, 3(1): 1–12. doi: 10.1109/TCCN.2017.2666266.
|
| [19] |
HASSANIEN A, AMIN M G, ABOUTANIOS E, et al. Dual-function radar communication systems: A solution to the spectrum congestion problem[J]. IEEE Signal Processing Magazine, 2019, 36(5): 115–126. doi: 10.1109/MSP.2019.2900571.
|
| [20] |
DONG Fuwang, LIU Fan, LU Shihang, et al. Communication-assisted sensing in 6G networks[J]. IEEE Journal on Selected Areas in Communications, 2025, 43(4): 1371–1386. doi: 10.1109/JSAC.2025.3531548.
|
| [21] |
NISHIO T, KODA Y, PARK J, et al. When wireless communications meet computer vision in beyond 5G[J]. IEEE Communications Standards Magazine, 2021, 5(2): 76–83. doi: 10.1109/MCOMSTD.001.2000047.
|
| [22] |
ALKHATEEB A, CHARAN G, OSMAN T, et al. DeepSense 6G: A large-scale real-world multi-modal sensing and communication dataset[J]. IEEE Communications Magazine, 2023, 61(9): 122–128. doi: 10.1109/MCOM.006.2200730.
|
| [23] |
CUI Yue, DING Haichuan, ZHAO Lian, et al. Integrated sensing and communication: A network level perspective[J]. IEEE Wireless Communications, 2024, 31(1): 103–109. doi: 10.1109/MWC.015.2200275.
|
| [24] |
OSORIO D P M, BARUA B, BESSER K L, et al. The rise of networked ISAC: Emerging aspects and challenges[J]. IEEE Open Journal of the Communications Society, 2025, 6: 5072–5091. doi: 10.1109/OJCOMS.2025.3575729.
|
| [25] |
KENNEY R H, MERLO J M, MGHABGHAB S R, et al. Wireless distributed frequency and phase synchronization for coherent distributed arrays[J]. IEEE Transactions on Microwave Theory and Techniques, 2024, 72(8): 4723–4736. doi: 10.1109/TMTT.2024.3367017.
|
| [26] |
CAMAJORI TEDESCHINI B, BRAMBILLA M, BARBIERI L, et al. Cooperative LiDAR sensing for pedestrian detection: Data association based on message passing neural networks[J]. IEEE Transactions on Signal Processing, 2023, 71: 3028–3042. doi: 10.1109/TSP.2023.3304002.
|
| [27] |
YANG Xiaoyu, WEI Zhiqing, XU Jie, et al. Coordinated transmit beamforming for networked ISAC with imperfect CSI and time synchronization[J]. IEEE Transactions on Wireless Communications, 2024, 23(12): 18019–18035. doi: 10.1109/TWC.2024.3459036.
|
| [28] |
NIU Yangyang, WEI Zhiqing, WANG Lin, et al. Interference management for integrated sensing and communication systems: A survey[J]. IEEE Internet of Things Journal, 2025, 12(7): 8110–8134. doi: 10.1109/JIOT.2024.3506162.
|
| [29] |
HU Yue, FANG Shaoheng, LEI Zixing, et al. Where2comm: Communication-efficient collaborative perception via spatial confidence maps[C]. Proceedings of the 36th Conference on Neural Information Processing Systems, New Orleans, USA, 2022: 4874–4886.
|
| [30] |
MAO Yuyi, ZHANG Jun, and LETAIEF K B. Dynamic computation offloading for mobile-edge computing with energy harvesting devices[J]. IEEE Journal on Selected Areas in Communications, 2016, 34(12): 3590–3605. doi: 10.1109/JSAC.2016.2611964.
|
| [31] |
TRAN T X and POMPILI D. Joint task offloading and resource allocation for multi-server mobile-edge computing networks[J]. IEEE Transactions on Vehicular Technology, 2019, 68(1): 856–868. doi: 10.1109/TVT.2018.2881191.
|
| [32] |
CHEN Min, HAO Yixue, LI Yong, et al. On the computation offloading at ad hoc cloudlet: Architecture and service modes[J]. IEEE Communications Magazine, 2015, 53(6): 18–24. doi: 10.1109/MCOM.2015.7120041.
|
| [33] |
ZHU Guangxu and HUANG Kaibin. MIMO over-the-air computation for high-mobility multimodal sensing[J]. IEEE Internet of Things Journal, 2019, 6(4): 6089–6103. doi: 10.1109/JIOT.2018.2871070.
|
| [34] |
YOU Lizhao, ZHAO Xinbo, CAO Rui, et al. Broadband digital over-the-air computation for wireless federated edge learning[J]. IEEE Transactions on Mobile Computing, 2024, 23(5): 5212–5228. doi: 10.1109/TMC.2023.3304652.
|
| [35] |
ZHANG Deyou, XIAO Ming, PANG Zhibo, et al. IRS assisted federated learning: A broadband over-the-air aggregation approach[J]. IEEE Transactions on Wireless Communications, 2024, 23(5): 4069–4082. doi: 10.1109/TWC.2023.3313968.
|
| [36] |
MO Xiaopeng and XU Jie. Energy-efficient federated edge learning with joint communication and computation design[J]. Journal of Communications and Information Networks, 2021, 6(2): 110–124. doi: 10.23919/JCIN.2021.9475121.
|
| [37] |
WANG Sihua, CHEN Mingzhe, SHEN Cong, et al. Digital over-the-air federated learning in multi-antenna systems[J]. IEEE Transactions on Wireless Communications, 2024, 23(10): 15125–15141. doi: 10.1109/TWC.2024.3425732.
|
| [38] |
AZIMI-ABARGHOUYI S M and FODOR V. Scalable hierarchical over-the-air federated learning[J]. IEEE Transactions on Wireless Communications, 2024, 23(8): 8480–8496. doi: 10.1109/TWC.2024.3350923.
|
| [39] |
QAISAR S, BILAL R M, IQBAL W, et al. Compressive sensing: From theory to applications, a survey[J]. Journal of Communications and Networks, 2013, 15(5): 443–456. doi: 10.1109/JCN.2013.000083.
|
| [40] |
BALTRUŠAITIS T, AHUJA C, and MORENCY L P. Multimodal machine learning: A survey and taxonomy[J]. IEEE Transactions on Pattern Analysis and Machine Intelligence, 2019, 41(2): 423–443. doi: 10.1109/TPAMI.2018.2798607.
|
| [41] |
LIU Peixi, ZHU Guangxu, WANG Shuai, et al. Toward ambient intelligence: Federated edge learning with task-oriented sensing, computation, and communication integration[J]. IEEE Journal of Selected Topics in Signal Processing, 2023, 17(1): 158–172. doi: 10.1109/JSTSP.2022.3226836.
|
| [42] |
QIAO Donghao and ZULKERNINE F. Adaptive feature fusion for cooperative perception using LiDAR point clouds[C]. 2023 IEEE/CVF Winter Conference on Applications of Computer Vision, Waikoloa, USA, 2023: 1186–1195. doi: 10.1109/WACV56688.2023.00124.
|
| [43] |
MAN Yunze, GUI Liangyan, and WANG Yuxiong. BEV-guided multi-modality fusion for driving perception[C]. 2023 IEEE/CVF Conference on Computer Vision and Pattern Recognition, Vancouver, Canada, 2023: 21960–21969. doi: 10.1109/CVPR52729.2023.02103.
|
| [44] |
王新奕, 费泽松, 周一青, 等. 面向物联网的通感算智融合: 关键技术与未来展望[J]. 电子与信息学报, 2025, 47(4): 888–908. doi: 10.11999/JEIT240806.
WANG Xinyi, FEI Zesong, ZHOU Yiqing, et al. Integrated sensing, communication, computation, and intelligence towards IoT: Key technologies and future directions[J]. Journal of Electronics & Information Technology, 2025, 47(4): 888–908. doi: 10.11999/JEIT240806.
|
| [45] |
ZHUANG Zeming, WEN Dingzhu, SHI Yuanming, et al. Integrated sensing-communication-computation for over-the-air edge AI inference[J]. IEEE Transactions on Wireless Communications, 2024, 23(4): 3205–3220. doi: 10.1109/TWC.2023.3306465.
|
| [46] |
WANG Diao, WEN Dingzhu, HE Yinghui, et al. Joint device scheduling and resource allocation for ISCC-based multiview–multitask inference[J]. IEEE Internet of Things Journal, 2024, 11(24): 40814–40830. doi: 10.1109/JIOT.2024.3456569.
|
| [47] |
LIU Shuai, WEN Dingzhu, LI Da, et al. Energy-efficient optimal mode selection for edge AI inference via integrated sensing-communication-computation[J]. IEEE Transactions on Mobile Computing, 2024, 23(12): 14248–14262. doi: 10.1109/TMC.2024.3440581.
|
| [48] |
ZHAO Junhui, REN Ruixing, ZOU Dan, et al. IoV-oriented integrated sensing, computation, and communication: System design and resource allocation[J]. IEEE Transactions on Vehicular Technology, 2024, 73(11): 16283–16294. doi: 10.1109/TVT.2024.3422270.
|
| [49] |
DENG Cailian, FANG Xuming, and WANG Xianbin. Integrated sensing, communication, and computation with adaptive DNN splitting in multi-UAV networks[J]. IEEE Transactions on Wireless Communications, 2024, 23(11): 17429–17445. doi: 10.1109/TWC.2024.3453650.
|
| [50] |
HOU Peng, HUANG Yi, ZHU Hongbin, et al. Distributed DRL-based integrated sensing, communication, and computation in cooperative UAV-enabled intelligent transportation systems[J]. IEEE Internet of Things Journal, 2025, 12(5): 5792–5806. doi: 10.1109/JIOT.2024.3489655.
|
| [51] |
LI Guoliang, WANG Shuai, YE Kejiang, et al. Multi-point integrated sensing and communication: Fusion model and functionality selection[J]. IEEE Wireless Communications Letters, 2022, 11(12): 2660–2664. doi: 10.1109/LWC.2022.3213883.
|
| [52] |
ZHOU Longyu, LENG Supeng, WANG Qing, et al. Integrated sensing and communication in UAV swarms for cooperative multiple targets tracking[J]. IEEE Transactions on Mobile Computing, 2023, 22(11): 6526–6542. doi: 10.1109/TMC.2022.3193499.
|
| [53] |
WANG Binglu, ZHANG Lei, WANG Zhaozhong, et al. Core: Cooperative reconstruction for multi-agent perception[C]. 2023 IEEE/CVF International Conference on Computer Vision, Paris, France, 2023: 8676–8686. doi: 10.1109/ICCV51070.2023.00800.
|
| [54] |
HONG Shixin, LIU Yu, LI Zhi, et al. Multi-agent collaborative perception via motion-aware robust communication network[C]. 2024 IEEE/CVF Conference on Computer Vision and Pattern Recognition, Seattle, USA, 2024: 15301–15310. doi: 10.1109/CVPR52733.2024.01449.
|
| [55] |
RASHID M and NANZER J A. Frequency and phase synchronization in distributed antenna arrays based on consensus averaging and Kalman filtering[J]. IEEE Transactions on Wireless Communications, 2023, 22(4): 2789–2803. doi: 10.1109/TWC.2022.3213788.
|
| [56] |
SONG Zhiying, YANG Lei, WEN Fuxi, et al. TraF-Align: Trajectory-aware feature alignment for asynchronous multi-agent perception[C]. 2025 IEEE/CVF Conference on Computer Vision and Pattern Recognition, Nashville, USA, 2025: 12048–12057. doi: 10.1109/CVPR52734.2025.01125.
|
| [57] |
LIU Sifan, LIU Rang, LU Zhiping, et al. Cooperative cell-free ISAC networks: Joint BS mode selection and beamforming design[C]. 2024 IEEE Wireless Communications and Networking Conference, Dubai, United Arab Emirates, 2024: 1–6. doi: 10.1109/WCNC57260.2024.10571110.
|
| [58] |
WANG Yi, ZU Keke, XIANG Luping, et al. ISAC enabled cooperative detection for cellular-connected UAV network[J]. IEEE Transactions on Wireless Communications, 2025, 24(2): 1541–1554. doi: 10.1109/TWC.2024.3509978.
|
| [59] |
MENG Kaitao, MASOUROS C, CHEN Guangji, et al. Network-level integrated sensing and communication: Interference management and BS coordination using stochastic geometry[J]. IEEE Transactions on Wireless Communications, 2024, 23(12): 19365–19381. doi: 10.1109/TWC.2024.3483031.
|
| [60] |
DING Changfeng, WANG Junbo, ZHANG Hua, et al. Joint MIMO precoding and computation resource allocation for dual-function radar and communication systems with mobile edge computing[J]. IEEE Journal on Selected Areas in Communications, 2022, 40(7): 2085–2102. doi: 10.1109/JSAC.2022.3157389.
|
| [61] |
HUANG Ning, DOU Chenglong, WU Yuan, et al. Unmanned-aerial-vehicle-aided integrated sensing and computation with mobile-edge computing[J]. IEEE Internet of Things Journal, 2023, 10(19): 16830–16844. doi: 10.1109/JIOT.2023.3270332.
|
| [62] |
LIU Peng, FEI Zesong, WANG Xinyi, et al. Joint beamforming and offloading design for integrated sensing, communication, and computation system[J]. IEEE Transactions on Vehicular Technology, 2025, 74(9): 14933–14937. doi: 10.1109/TVT.2025.3561430.
|
| [63] |
LIU Peng, FEI Zesong, WANG Xinyi, et al. Joint offloading and beamforming design in integrating sensing, communication, and computing systems: A distributed approach[J]. IEEE Transactions on Communications, 2025, 73(7): 4697–4712. doi: 10.1109/TCOMM.2024.3516488.
|
| [64] |
LIU Peng, FEI Zesong, WANG Xinyi, et al. Toward intelligent edge sensing for ISCC network: Joint multi-tier DNN partitioning and beamforming design[J]. IEEE Transactions on Wireless Communications, 2026, 25: 6774–6789. doi: 10.1109/TWC.2025.3626555.
|
| [65] |
LIU Peng, TANG Shuntian, LIN Ke, et al. Joint split inference design and bandwidth allocation for intelligent edge perception network[C]. 2025 IEEE/CIC International Conference on Communications in China, Shanghai, China, 2025: 388–393. doi: 10.1109/ICCCWorkshops67136.2025.11148170.
|
| [66] |
WANG Zhaolin, MU Xidong, LIU Yuanwei, et al. NOMA-aided joint communication, sensing, and multi-tier computing systems[J]. IEEE Journal on Selected Areas in Communications, 2023, 41(3): 574–588. doi: 10.1109/JSAC.2022.3229447.
|
| [67] |
HUANG Ning, DOU Chenglong, WU Yuan, et al. Mobile edge computing aided integrated sensing and communication with short-packet transmissions[J]. IEEE Transactions on Wireless Communications, 2024, 23(7): 7759–7774. doi: 10.1109/TWC.2023.3344479.
|
| [68] |
CHENG Kaijun, FANG Xuming, and WANG Xianbin. Optimized resource allocation and time partitioning for integrated communication, sensing, and edge computing network[J]. Computer Communications, 2022, 194: 240–249. doi: 10.1016/j.comcom.2022.07.030.
|
| [69] |
ZHAO Lindong, WU Dan, ZHOU Liang, et al. Radio resource allocation for integrated sensing, communication, and computation networks[J]. IEEE Transactions on Wireless Communications, 2022, 21(10): 8675–8687. doi: 10.1109/TWC.2022.3168348.
|
| [70] |
LI Zhenyu, FU Yuchuan, TIAN Mengqiu, et al. Cooperative sensing, communication and computation resource allocation in mobile edge computing-enabled vehicular networks[J]. Journal of Information and Intelligence, 2024, 2(4): 339–354. doi: 10.1016/j.jiixd.2024.02.006.
|
| [71] |
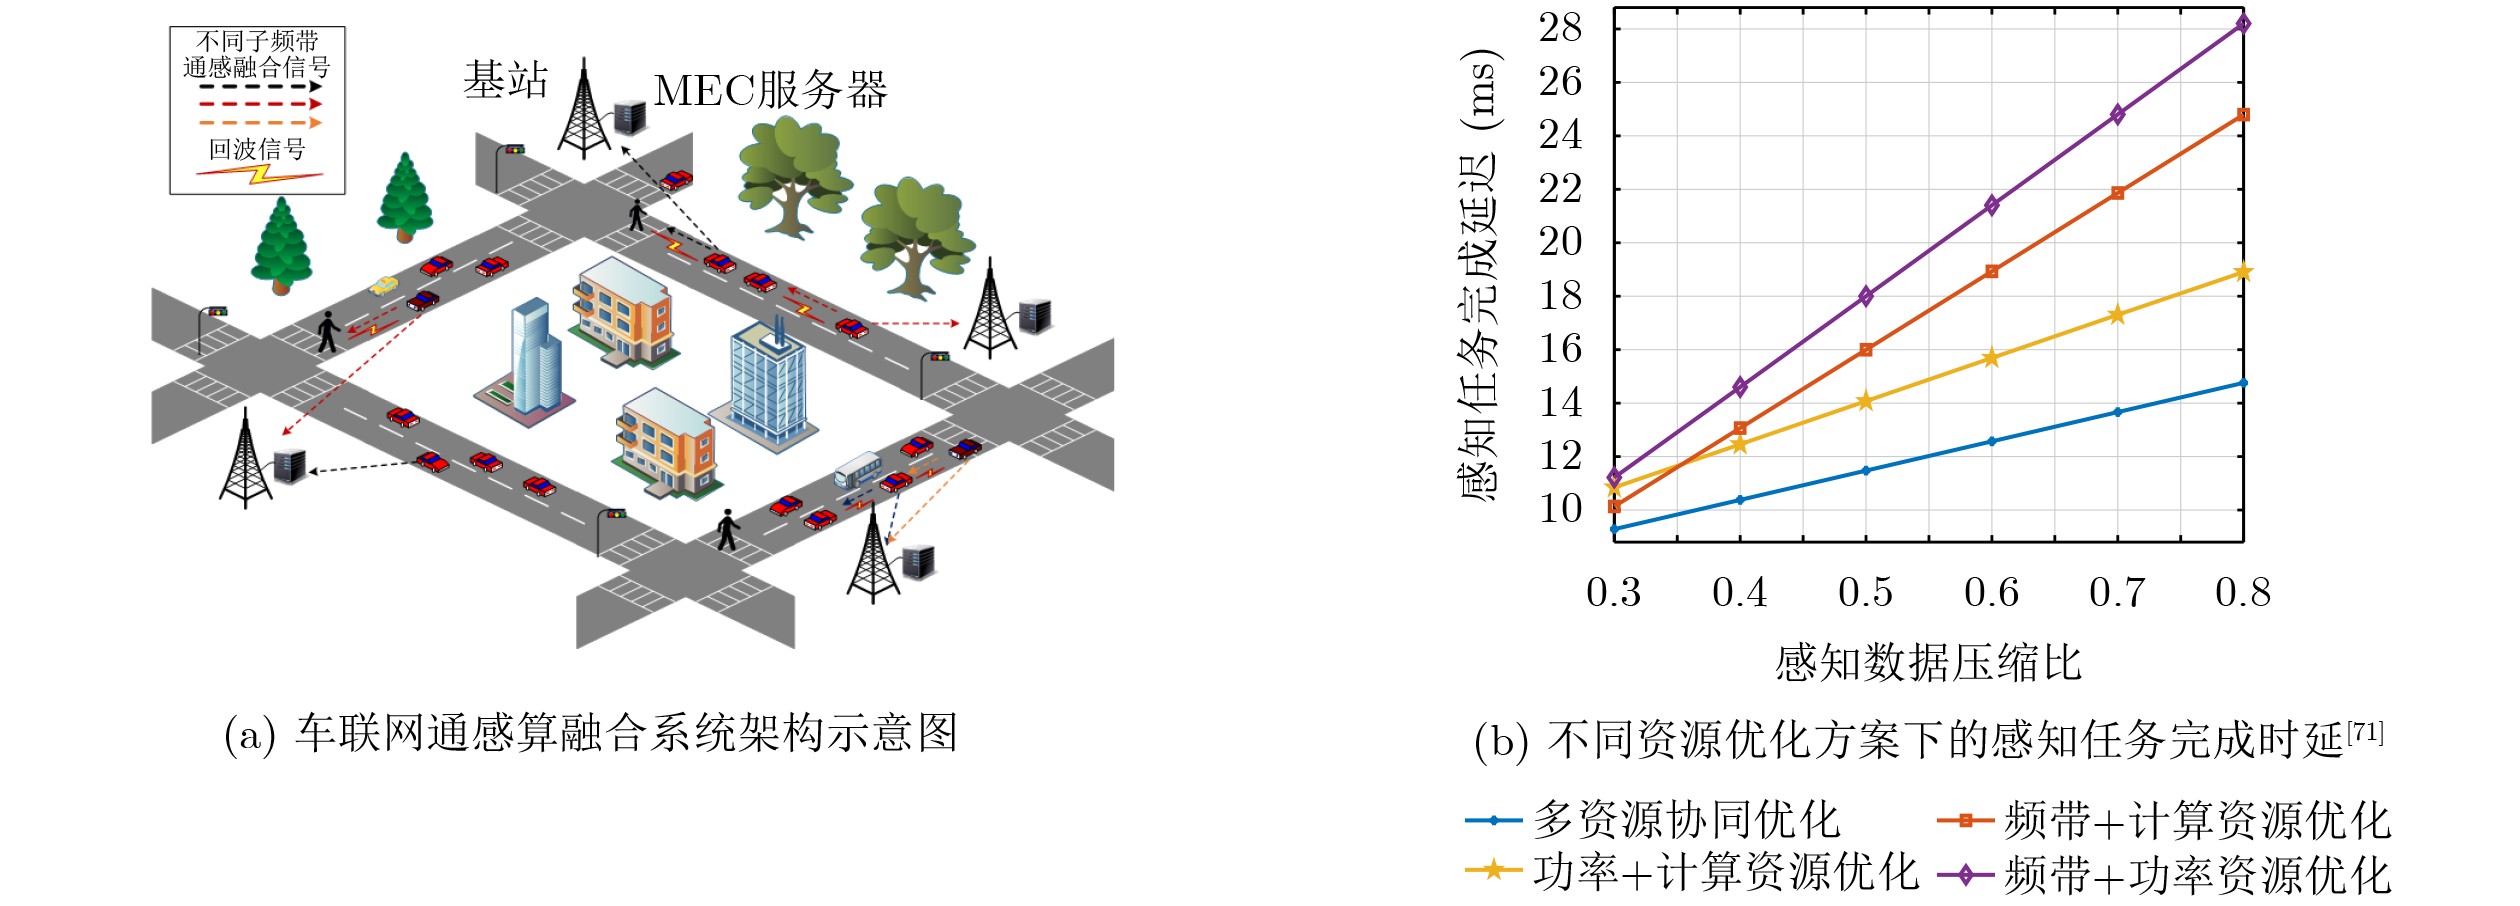
LIU Peng, WANG Xinyi, FEI Zesong, et al. Latency minimization oriented radio and computation resource allocations for 6G V2X networks with ISCC[J]. IEEE Transactions on Communications, 2025, 73(12): 15851–15865. doi: 10.1109/TCOMM.2025.3616242.
|
| [72] |
ZHOU Yige, LIU Xin, ZHAI Xiangping, et al. UAV-enabled integrated sensing, computing, and communication for Internet of Things: Joint resource allocation and trajectory design[J]. IEEE Internet of Things Journal, 2024, 11(7): 12717–12727. doi: 10.1109/JIOT.2023.3335937.
|
| [73] |
PENG Sicong, LI Bin, LIU Lei, et al. Trajectory design and resource allocation for multi-UAV-assisted sensing, communication, and edge computing integration[J]. IEEE Transactions on Communications, 2025, 73(4): 2847–2861. doi: 10.1109/TCOMM.2024.3478115.
|
| [74] |
CHANG Bo, TANG Wei, YAN Xiaoyu, et al. Integrated scheduling of sensing, communication, and control for mmWave/THz communications in cellular connected UAV networks[J]. IEEE Journal on Selected Areas in Communications, 2022, 40(7): 2103–2113. doi: 10.1109/JSAC.2022.3157366.
|
| [75] |
LI Qingliang, LI Bin, HE Zhenqing, et al. Joint design of communication sensing and control with a UAV platform[J]. IEEE Transactions on Wireless Communications, 2024, 23(12): 19231–19244. doi: 10.1109/TWC.2024.3480705.
|
| [76] |
JIN Haijia, WU Jun, YUAN Weijie, et al. Co-design of sensing, communications, and control for low-altitude wireless networks[J]. IEEE Transactions on Mobile Computing, 2025, 24(11): 12035–12048. doi: 10.1109/TMC.2025.3581616.
|
| [77] |
MAO Sun, YUEN C, LIU Lei, et al. RIS-enhanced semantic-aware sensing, communication, computation, and control for internet of things[J]. IEEE Transactions on Wireless Communications, 2026, 25: 2231–2246. doi: 10.1109/TWC.2025.3595550.
|
| [78] |
FANG Xinran, LEI Chengleyang, FENG Wei, et al. Sensing-communication-computing-control closed-loop optimization for 6G digital twin-empowered robotic systems[J]. IEEE Journal on Selected Areas in Communications, 2025, 43(10): 3330–3346. doi: 10.1109/JSAC.2025.3574601.
|
| [79] |
KHAN M A, KUMAR N, ALSAMHI S H, et al. Security and privacy issues and solutions for UAVs in B5G networks: A review[J]. IEEE Transactions on Network and Service Management, 2025, 22(1): 892–912. doi: 10.1109/TNSM.2024.3487265.
|
Figures(6)




 DownLoad: