Advanced Search
Turn off MathJax
Article Contents
YANG Hui, LI Bin, CHEN Hongbin. A Cooperative Control Method for Multi-UAV Encirclement of a High-Speed Evader under Perception Constraints[J]. Journal of Electronics & Information Technology. doi: 10.11999/JEIT260956
Citation: YANG Hui, LI Bin, CHEN Hongbin. A Cooperative Control Method for Multi-UAV Encirclement of a High-Speed Evader under Perception Constraints[J]. Journal of Electronics & Information Technology. doi: 10.11999/JEIT260956

A Cooperative Control Method for Multi-UAV Encirclement of a High-Speed Evader under Perception Constraints

doi: 10.11999/JEIT260956 cstr: 32379.14.JEIT260956
Funds:  Guangxi Key Research and Development Program (AB25069510)
  • Received Date: 2026-07-13
  • Accepted Date: 2026-10-20
  • Rev Recd Date: 2026-09-07
  • Available Online: 2026-10-28
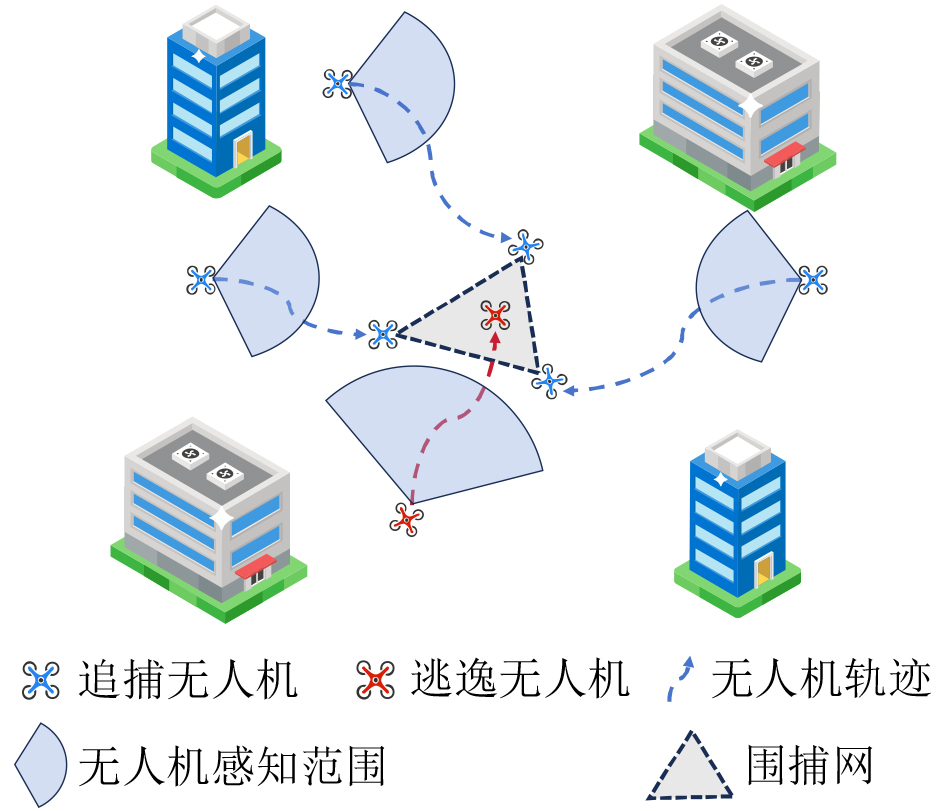
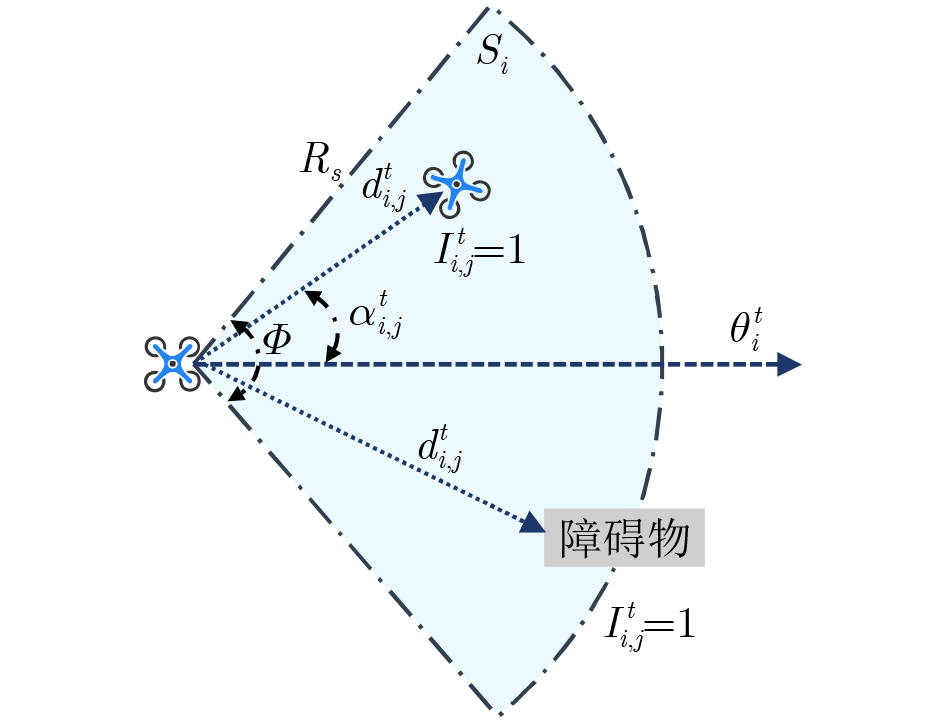
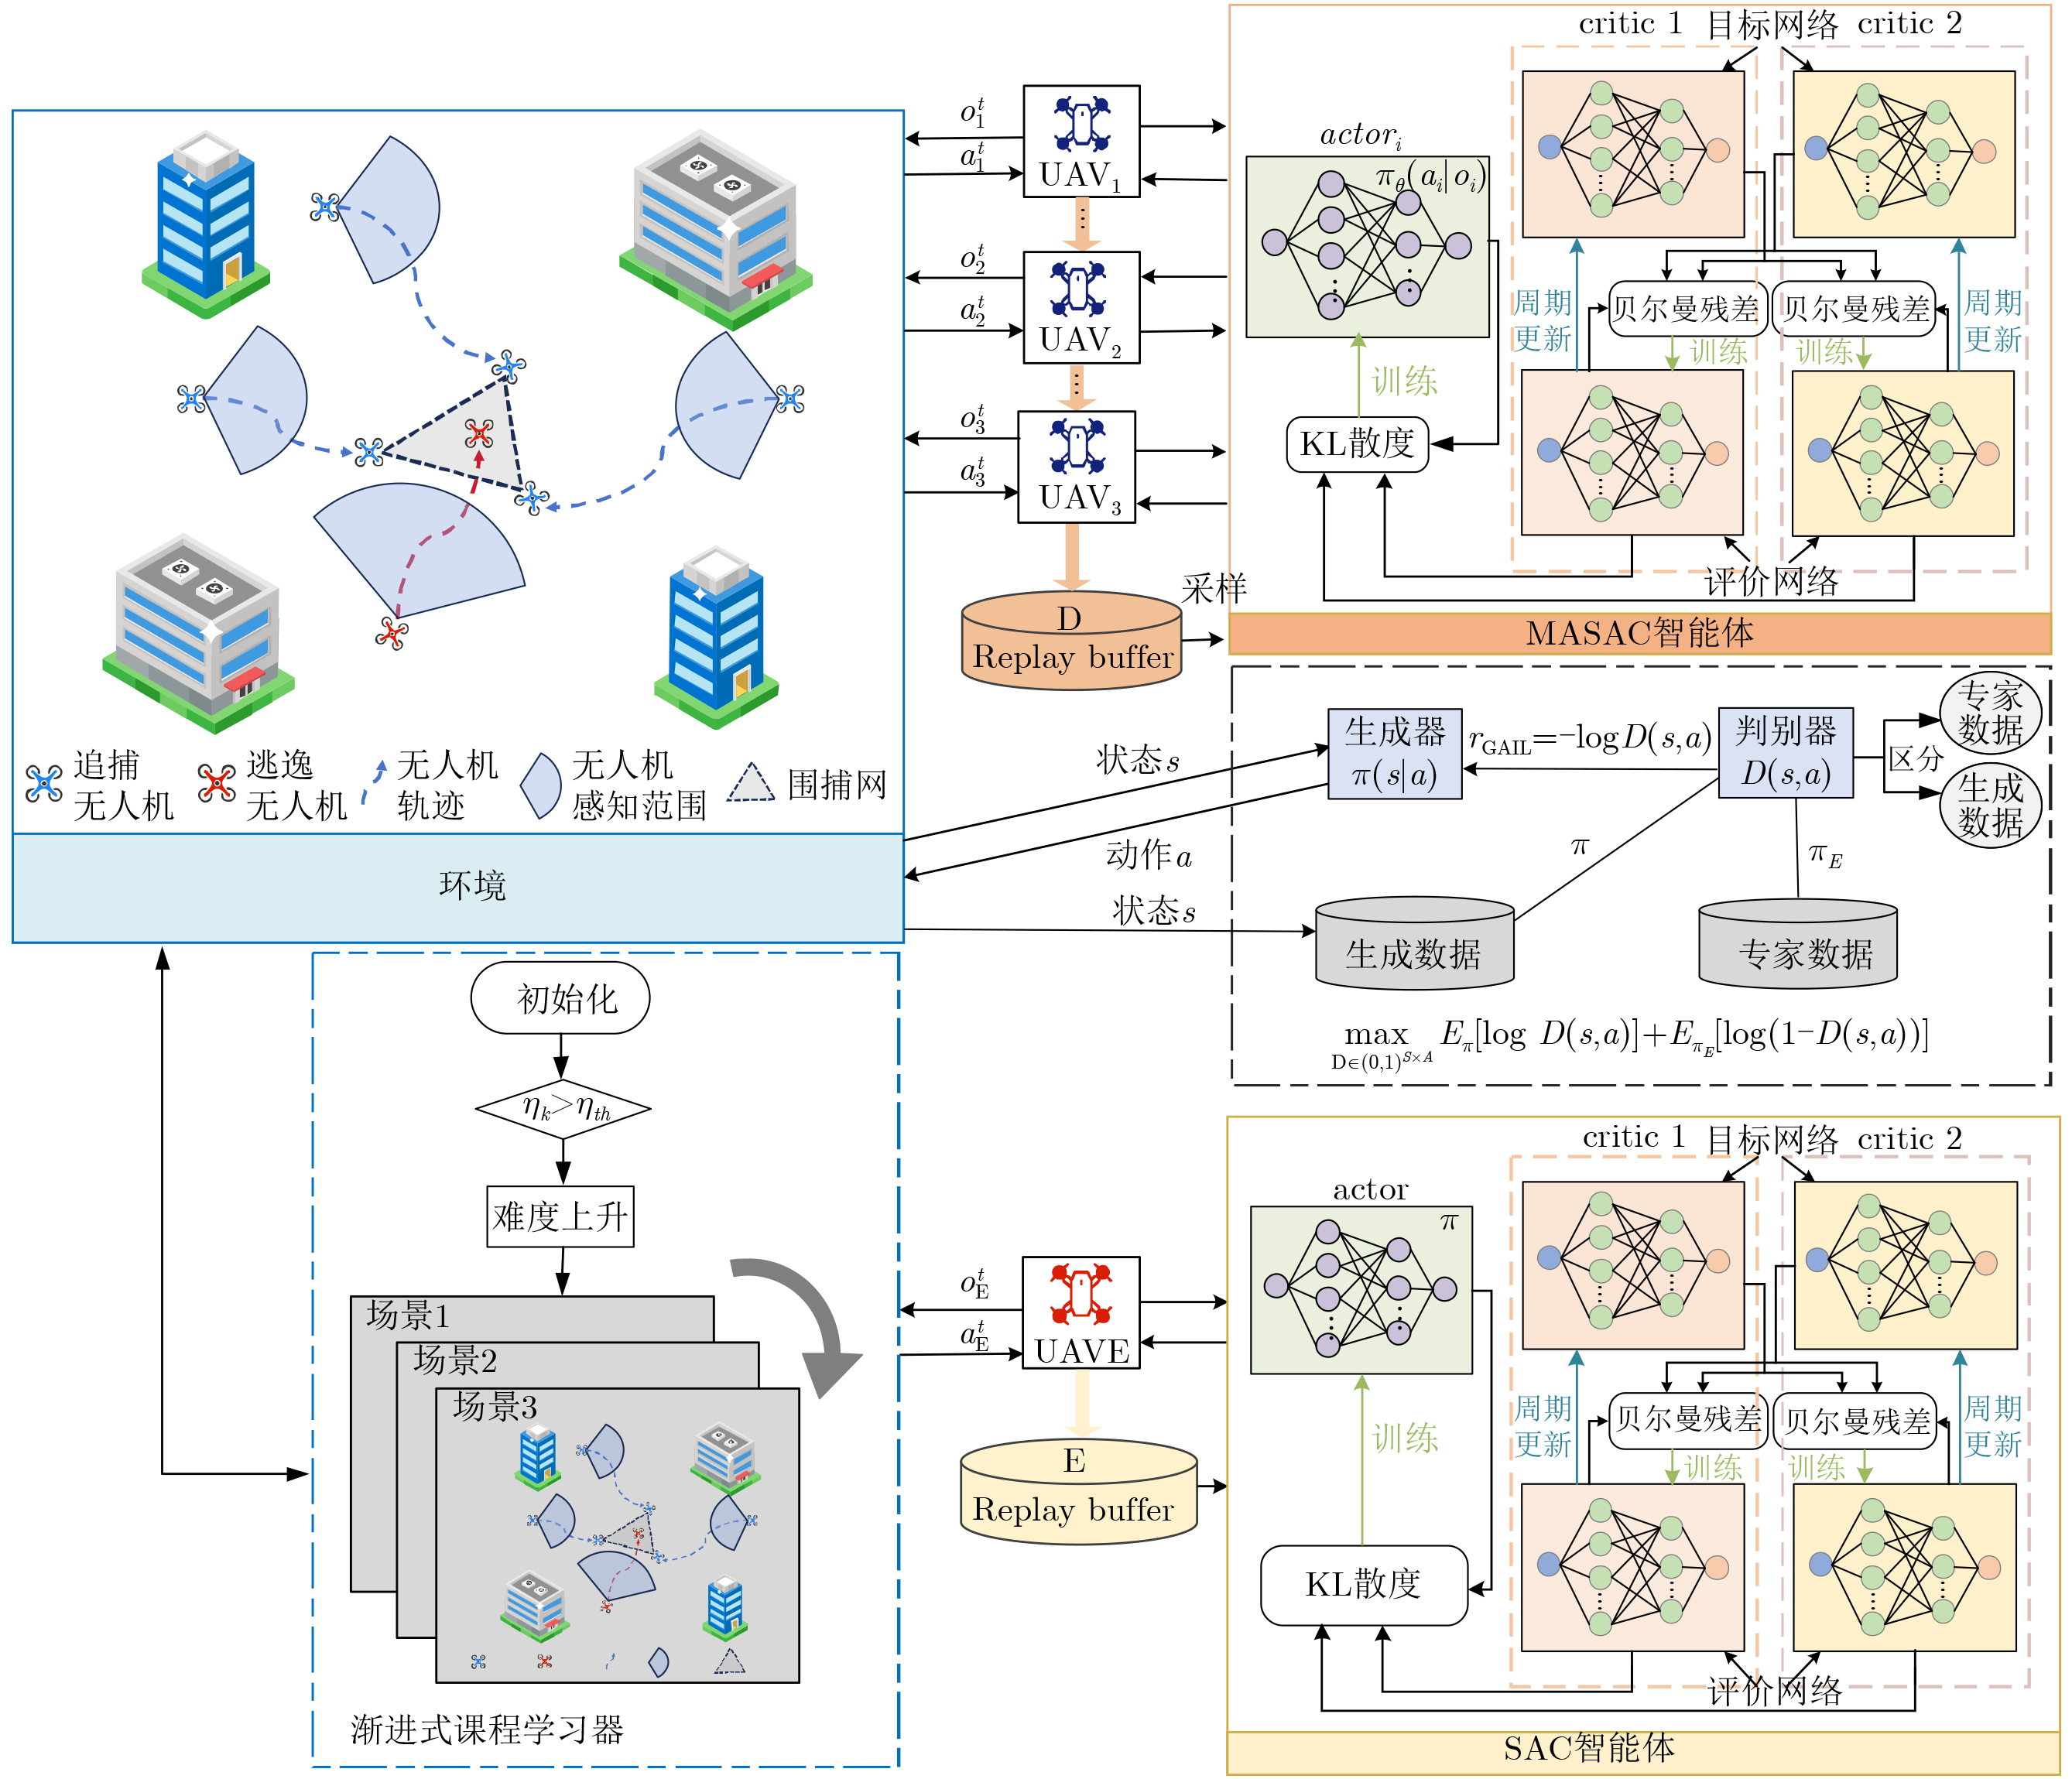
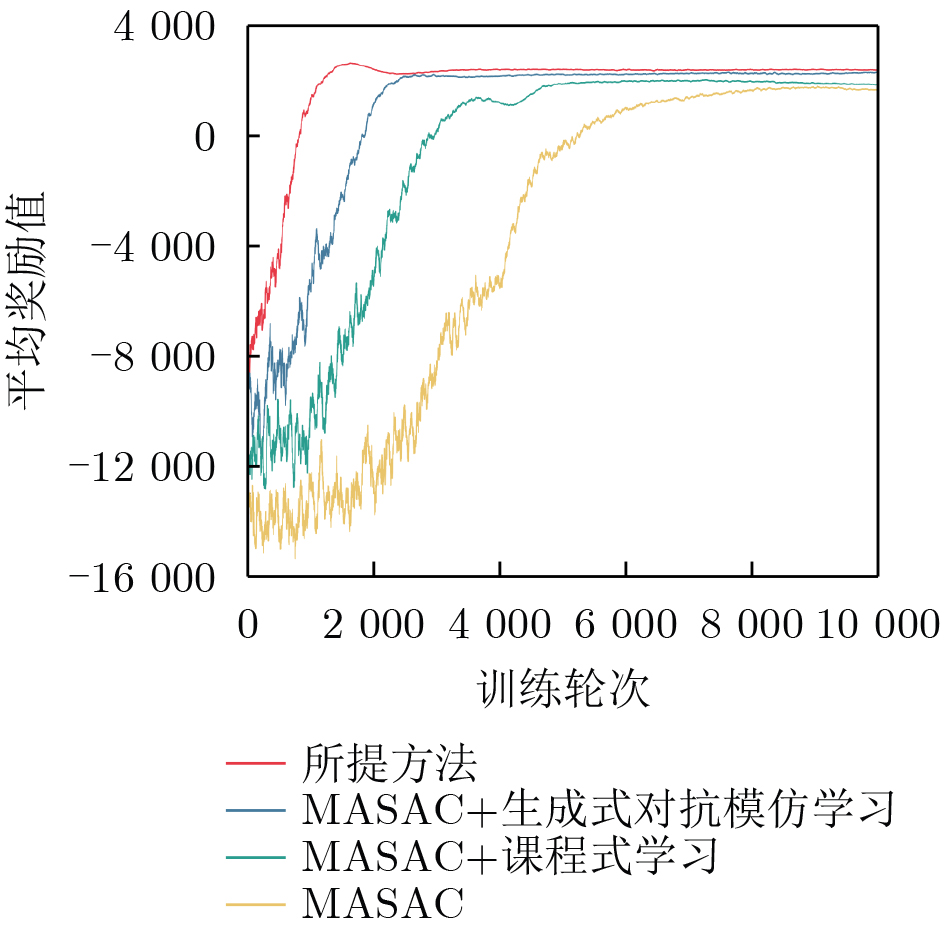
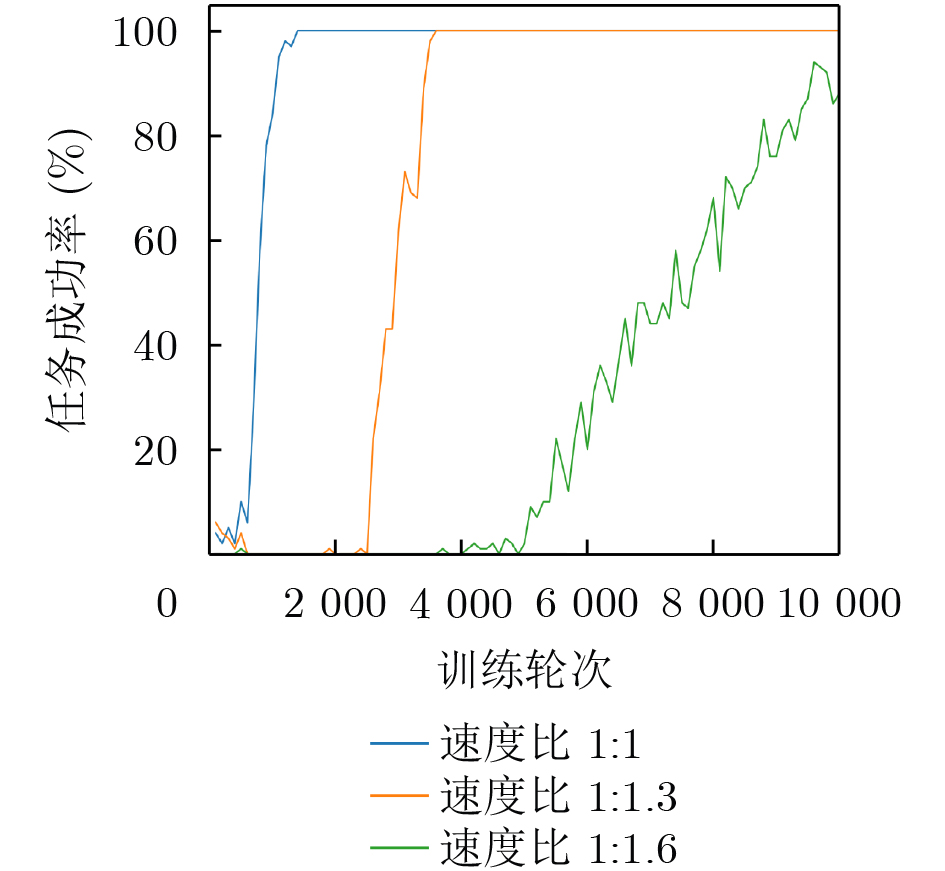
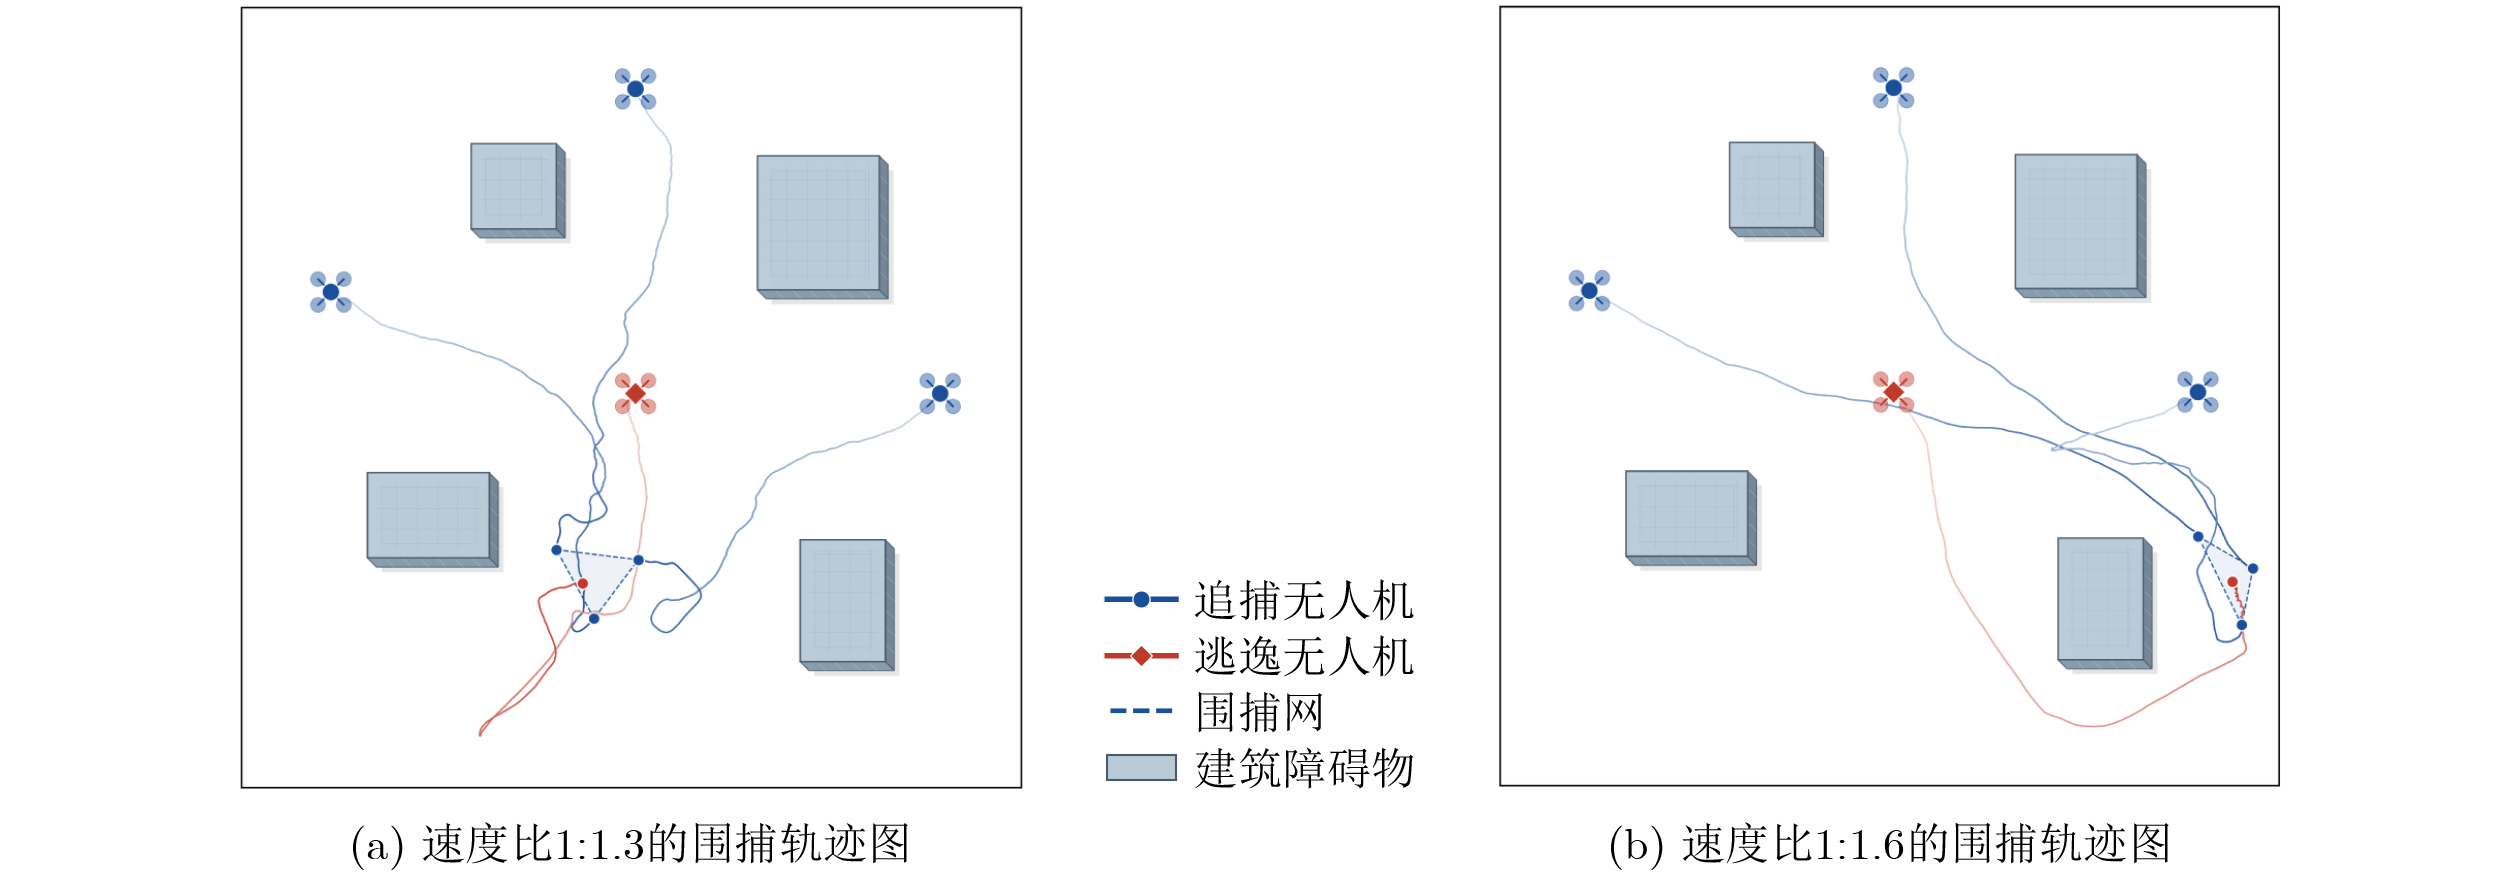
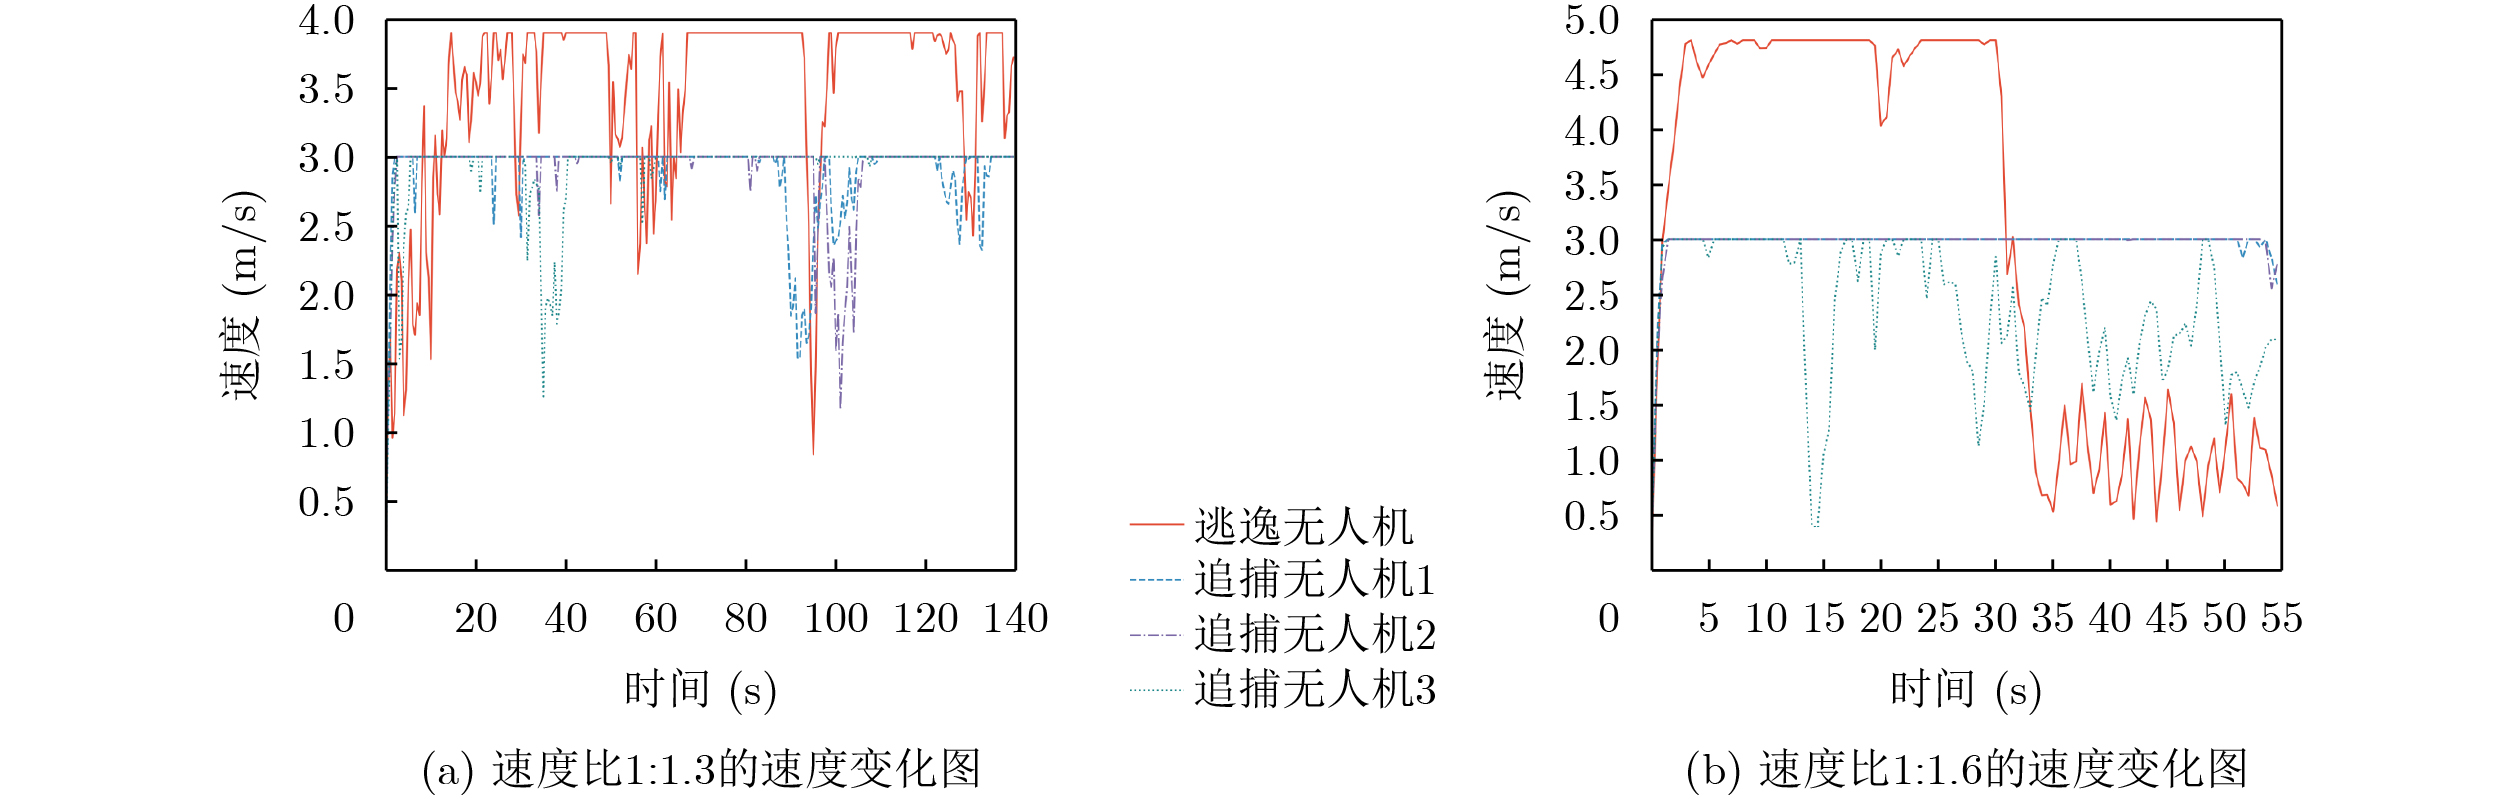
  •   Objective  This paper investigates the cooperative pursuit-evasion problem of multiple unmanned aerial vehicles (UAVs) against a highly maneuverable evader in low-altitude urban environments. With the rapid growth of low-altitude UAV applications, unauthorized UAVs pose increasing threats to airspace security. Compared with conventional counter-UAV measures, cooperative pursuit by multiple UAVs offers a more flexible solution; however, when the evader outperforms each pursuer in maneuverability, capture can only be achieved through coordinated decision-making that restricts the evader's escape space. The objective is therefore to develop an efficient multi-UAV cooperative pursuit strategy achieving robust capture under dynamics constraints, obstacle interference, and speed disadvantage.  Methods  To address this problem, a cooperative pursuit-evasion scenario is constructed in a bounded urban area with static rectangular obstacles, where the motion of all UAVs is described by a damped double-integrator model that captures the inertia and velocity-attenuation characteristics of UAV dynamics. The pursuit problem is then formulated as a Markov decision process in which each UAV acts on local observations. The pursuers are trained with the Multi-Agent Soft Actor-Critic (MASAC) algorithm under the centralized training and decentralized execution framework, while the evader is trained simultaneously with Soft Actor-Critic (SAC), forming an adversarial learning process. To improve exploration efficiency, a progressive adversarial imitation learning framework is introduced: expert demonstrations are generated offline via Apollonius-circle analysis under speed disadvantage, Generative Adversarial Imitation Learning provides intrinsic imitation rewards in early training, and an exponential decay mechanism gradually shifts the pursuer policy from imitation-driven to autonomous reinforcement learning. Furthermore, a velocity-ratio-based curriculum progressively increases the evader's maximum speed, enhancing policy adaptability against highly maneuverable targets.  Results and Discussions  Simulation experiments are conducted on a Python-based multi-UAV pursuit-evasion platform, where the urban airspace contains static rectangular buildings, three pursuer UAVs (maximum speed 3 m/s), and one evader UAV (3.9 m/s). Results show that the proposed framework outperforms baseline reinforcement learning methods and converges to a stable reward level after approximately 2000 episodes. Ablation studies demonstrate that Apollonius-circle based expert demonstrations significantly accelerate early-stage learning, while velocity-ratio curriculum learning enhances final pursuit performance; their combination yields a synergistic improvement in both convergence speed and policy quality. Experiments under speed ratios of 1:1, 1:1.3, and 1:1.6 further verify robustness: the capture success rate approaches 100% without a speed disadvantage and remains high as the evader's speed advantage increases.  Conclusions  This paper proposes a progressive adversarial imitation learning framework for multi-UAV cooperative pursuit of a highly maneuverable evader. By integrating MASAC-based cooperative decision-making, adversarial evader training, Apollonius-circle expert demonstrations with GAIL imitation rewards, and velocity-ratio curriculum learning, the framework significantly improves learning efficiency and capture performance. Simulation results verify faster convergence, higher capture success rates, and stronger adaptability across different evader speeds, providing an effective learning-based solution for low-altitude cooperative interception of highly maneuverable targets.
  • loading
  • [1]
    许越越, 杜华军, 郭尚伟. 低空无人机具身导航研究进展[J]. 航天控制, 2025, 43(4): 7–14. doi: 10.16804/j.cnki.issn1006-3242.2025.04.004.

    XU Yueyue, DU Huajun, and GUO Shangwei. Research progress on embodied navigation of low-altitude UAV[J]. Aerospace Control, 2025, 43(4): 7–14. doi: 10.16804/j.cnki.issn1006-3242.2025.04.004.
    [2]
    王云涛, 苏洲, 高源, 等. 低空智联网架构、安全与优化关键技术[J]. 电子与信息学报, 2026, 48(3): 889–913. doi: 10.11999/JEIT250947.

    WANG Yuntao, SU Zhou, GAO Yuan, et al. Key technologies for low-altitude intelligent networks: Architecture, security, and optimization[J]. Journal of Electronics & Information Technology, 2026, 48(3): 889–913. doi: 10.11999/JEIT250947.
    [3]
    CHENG Nan, WU Shen, WANG Xiucheng, et al. AI for UAV-assisted IoT applications: A comprehensive review[J]. IEEE Internet of Things Journal, 2023, 10(16): 14438–14461. doi: 10.1109/JIOT.2023.3268316.
    [4]
    CHAUHAN D, KAGATHARA H, MEWADA H, et al. Nation’s defense: A comprehensive review of anti-drone systems and strategies[J]. IEEE Access, 2025, 13: 53476–53505. doi: 10.1109/ACCESS.2025.3550338.
    [5]
    CHEN Jinchao, WANG Yang, ZHANG Ying, et al. Extrinsic-and-intrinsic reward-based multi-agent reinforcement learning for multi-UAV cooperative target encirclement[J]. IEEE Transactions on Intelligent Transportation Systems, 2025, 26(10): 17653–17665. doi: 10.1109/TITS.2024.3524562.
    [6]
    CHEN Nuo, LI Linjing, and MAO Wenji. Equilibrium strategy of the pursuit-evasion game in three-dimensional space[J]. IEEE/CAA Journal of Automatica Sinica, 2024, 11(2): 446–458. doi: 10.1109/JAS.2023.123996.
    [7]
    FANG Xu, WANG Chen, XIE Lihua, et al. Cooperative pursuit with multi-pursuer and one faster free-moving evader[J]. IEEE Transactions on Cybernetics, 2022, 52(3): 1405–1414. doi: 10.1109/TCYB.2019.2958548.
    [8]
    ZHOU Meng, WANG Zihao, WANG Jing, et al. Multi-robot collaborative hunting in cluttered environments with obstacle-avoiding Voronoi cells[J]. IEEE/CAA Journal of Automatica Sinica, 2024, 11(7): 1643–1655. doi: 10.1109/JAS.2023.124041.
    [9]
    唐伦, 李质萱, 蒲昊, 等. 基于多智能体深度强化学习的无人机动态预部署策略[J]. 电子与信息学报, 2023, 45(6): 2007–2015. doi: 10.11999/JEIT220513.

    TANG Lun, LI Zhixuan, PU Hao, et al. A dynamic pre-deployment strategy of UAVs based on multi-agent deep reinforcement learning[J]. Journal of Electronics & Information Technology, 2023, 45(6): 2007–2015. doi: 10.11999/JEIT220513.
    [10]
    冯斯梦, 张云弈, 刘凯, 等. 低空混合障碍下无人机协同多智能体航迹规划[J]. 电子与信息学报, 2025, 47(5): 1291–1300. doi: 10.11999/JEIT250012.

    FENG Simeng, ZHANG Yunyi, LIU Kai, et al. Collaborative multi-agent trajectory optimization for unmanned aerial vehicles under low-altitude mixed-obstacle airspace[J]. Journal of Electronics & Information Technology, 2025, 47(5): 1291–1300. doi: 10.11999/JEIT250012.
    [11]
    ZHANG Yaozhong, DING Meiyan, ZHANG Jiandong, et al. Multi-UAV pursuit-evasion gaming based on PSO-M3DDPG schemes[J]. Complex & Intelligent Systems, 2024, 10(5): 6867–6883. doi: 10.1007/s40747-024-01504-1.
    [12]
    YANG Zhengzhi, CUI Yuanhao, DU Wenbo, et al. Cooperative pursuit-evasion with low altitude wireless network: A hierarchical reinforcement learning approach[J]. IEEE Transactions on Mobile Computing, 2026, 25(4): 5716–5729. doi: 10.1109/TMC.2025.3632863.
    [13]
    薛健, 赵琳, 向贤财, 等. 非完全信息下无人机集群对抗研究综述[J]. 电子与信息学报, 2024, 46(4): 1157–1172. doi: 10.11999/JEIT230544.

    XUE Jian, ZHAO Lin, XIANG Xiancai, et al. A review of the research on UAV swarm confrontation under incomplete information[J]. Journal of Electronics & Information Technology, 2024, 46(4): 1157–1172. doi: 10.11999/JEIT230544.
    [14]
    XIANG Yuming, LI Sizhao, LI Rongpeng, et al. Decentralized consensus inference-based hierarchical reinforcement learning for multiconstrained UAV pursuit-evasion game[J]. IEEE Transactions on Neural Networks and Learning Systems, 2025, 36(10): 18229–18243. doi: 10.1109/TNNLS.2025.3582909.
    [15]
    CHEN Jiayu, YU Chao, LI Guosheng, et al. Online planning for multi-UAV pursuit-evasion in unknown environments using deep reinforcement learning[J]. IEEE Robotics and Automation Letters, 2025, 10(8): 8196–8203. doi: 10.1109/LRA.2025.3583620.
  • 加载中

Catalog

    通讯作者: 陈斌, bchen63@163.com
    • 1. 

      沈阳化工大学材料科学与工程学院 沈阳 110142

    1. 本站搜索
    2. 百度学术搜索
    3. 万方数据库搜索
    4. CNKI搜索

    Figures(8)

    Article Metrics

    Article views (50) PDF downloads(8) Cited by()
    Proportional views
    Related

    /

    DownLoad:  Full-Size Img  PowerPoint
    Return
    Return