Advanced Search
Turn off MathJax
Article Contents
ZHAO Yicheng, WANG Hai, QIN Zhen, SUN Weihao. Resource Allocation and Node Deployment for Multi-UAV Integrated Localization and Communication with Differentiated Requirements[J]. Journal of Electronics & Information Technology. doi: 10.11999/JEIT260819
Citation: ZHAO Yicheng, WANG Hai, QIN Zhen, SUN Weihao. Resource Allocation and Node Deployment for Multi-UAV Integrated Localization and Communication with Differentiated Requirements[J]. Journal of Electronics & Information Technology. doi: 10.11999/JEIT260819

Resource Allocation and Node Deployment for Multi-UAV Integrated Localization and Communication with Differentiated Requirements

doi: 10.11999/JEIT260819 cstr: 32379.14.JEIT260819
  • Received Date: 2026-06-18
  • Accepted Date: 2026-08-17
  • Rev Recd Date: 2026-08-13
  • Available Online: 2026-08-25
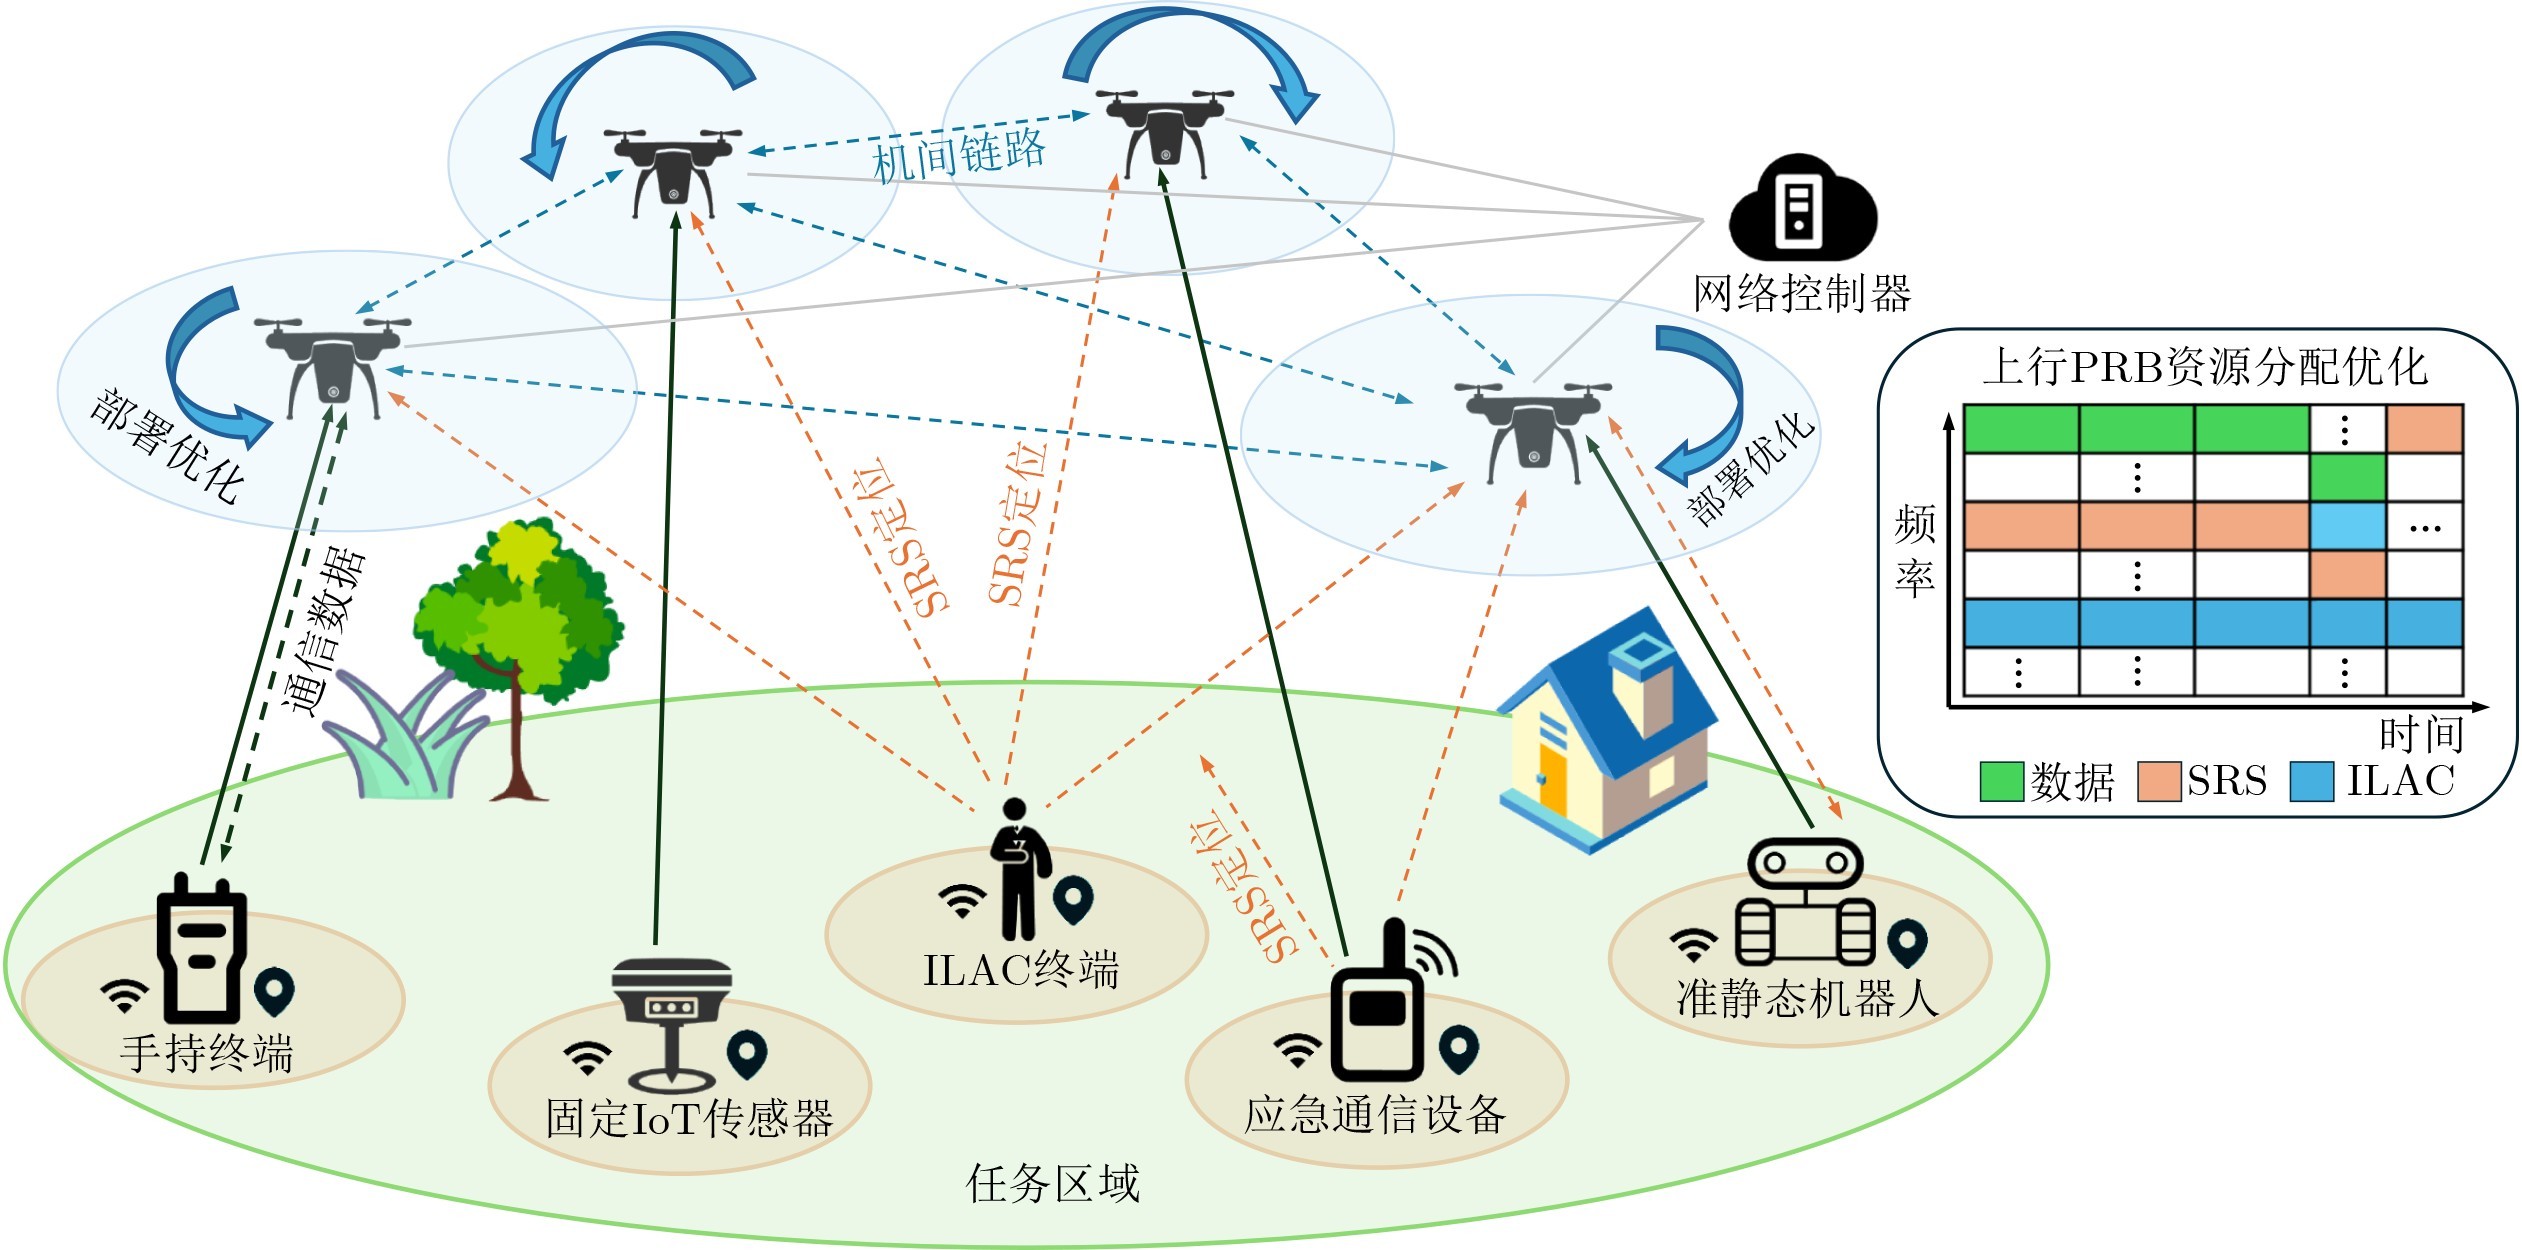
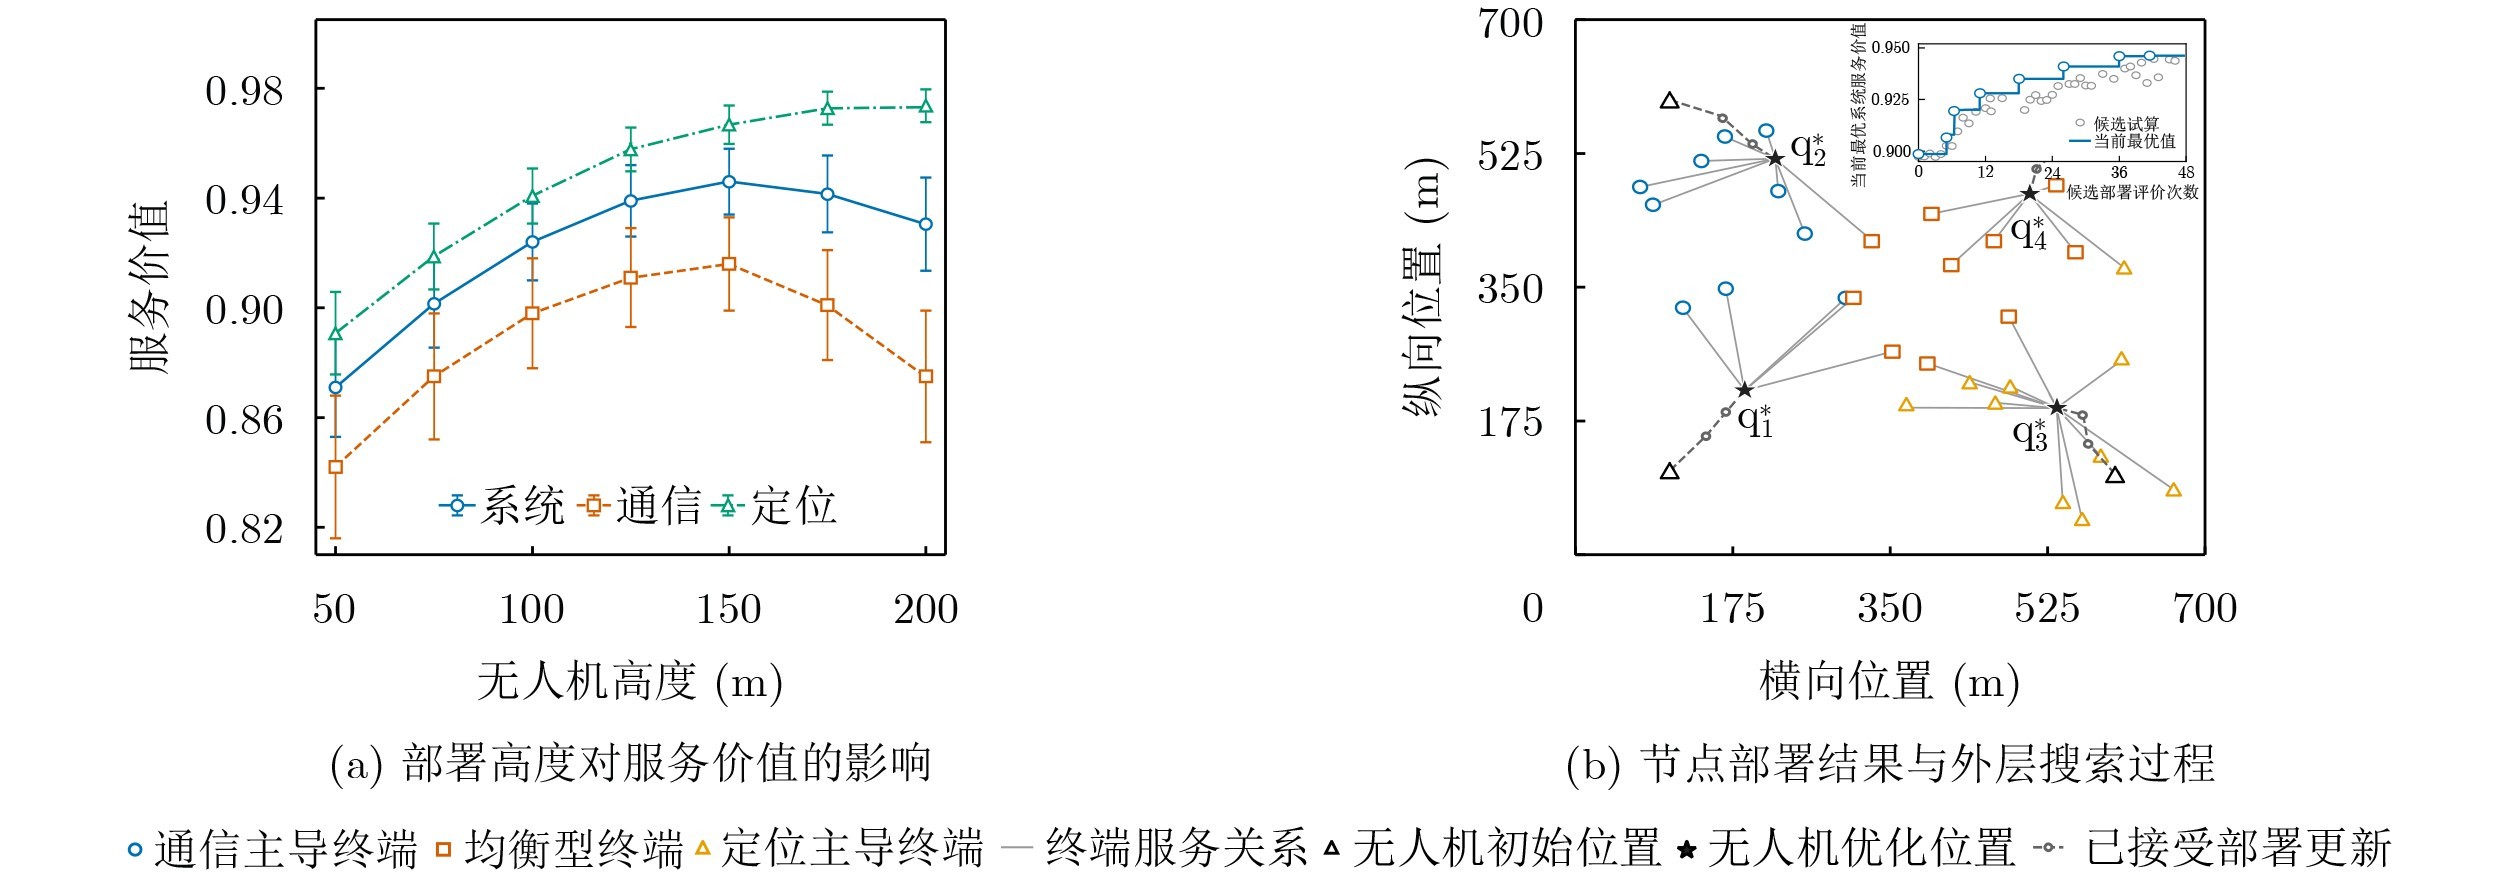
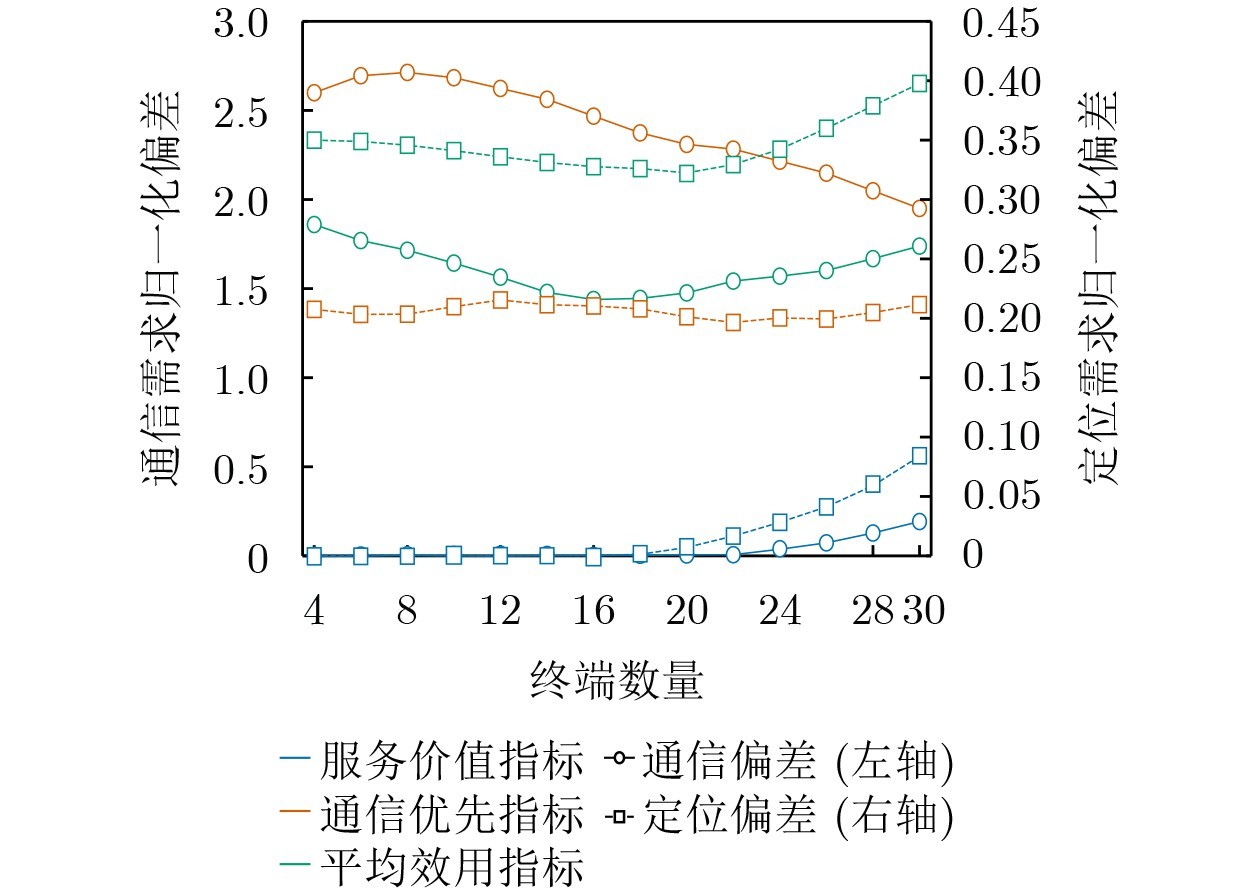
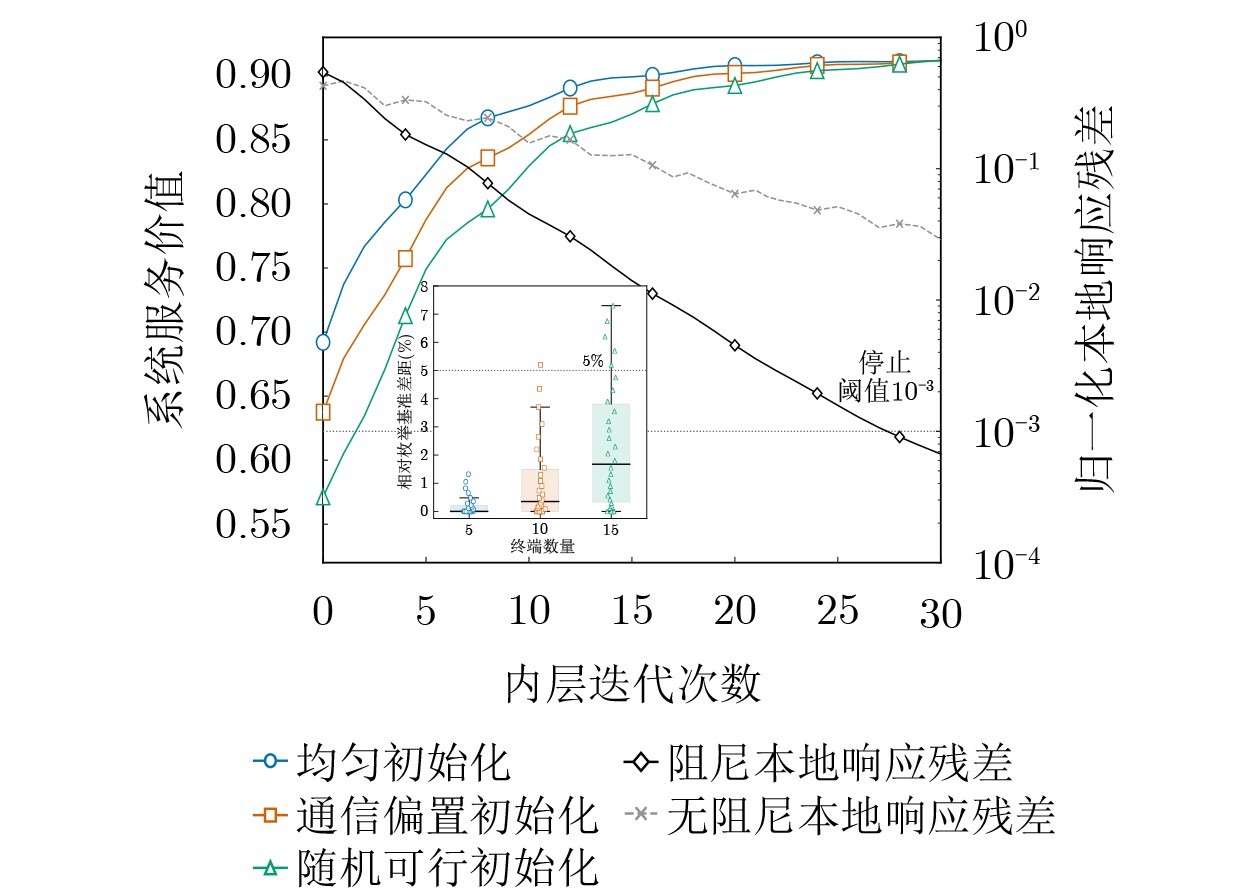
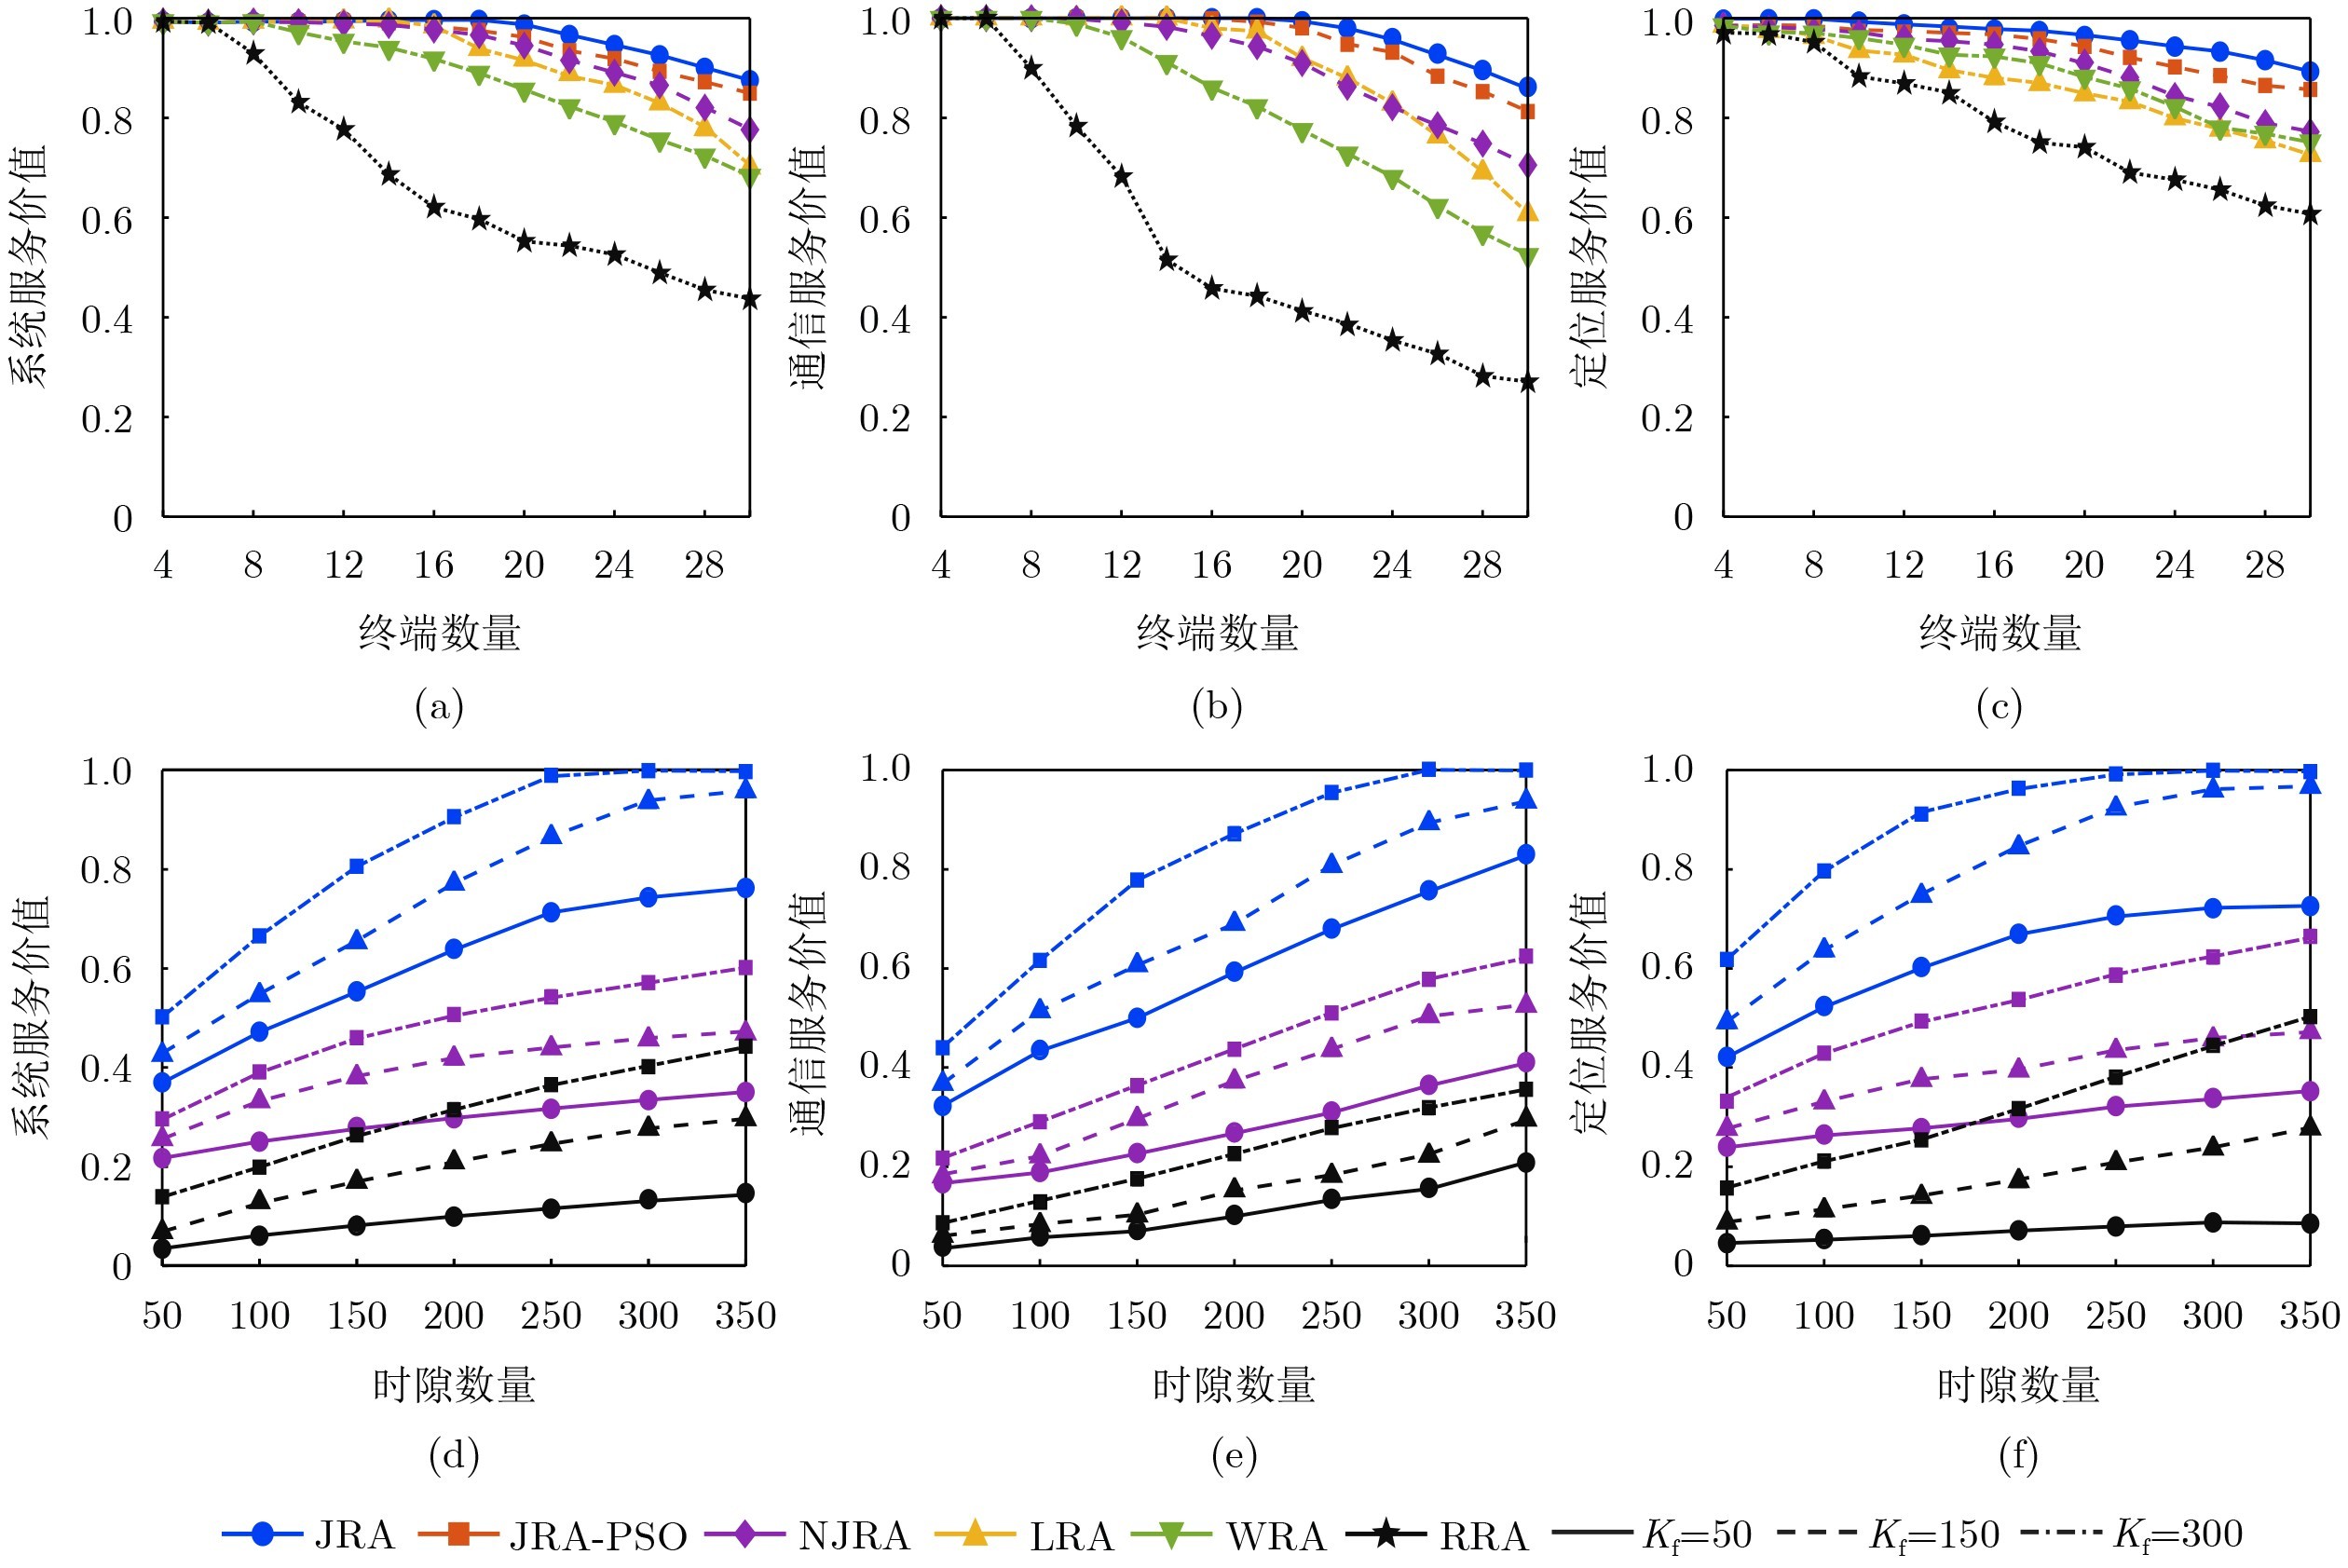
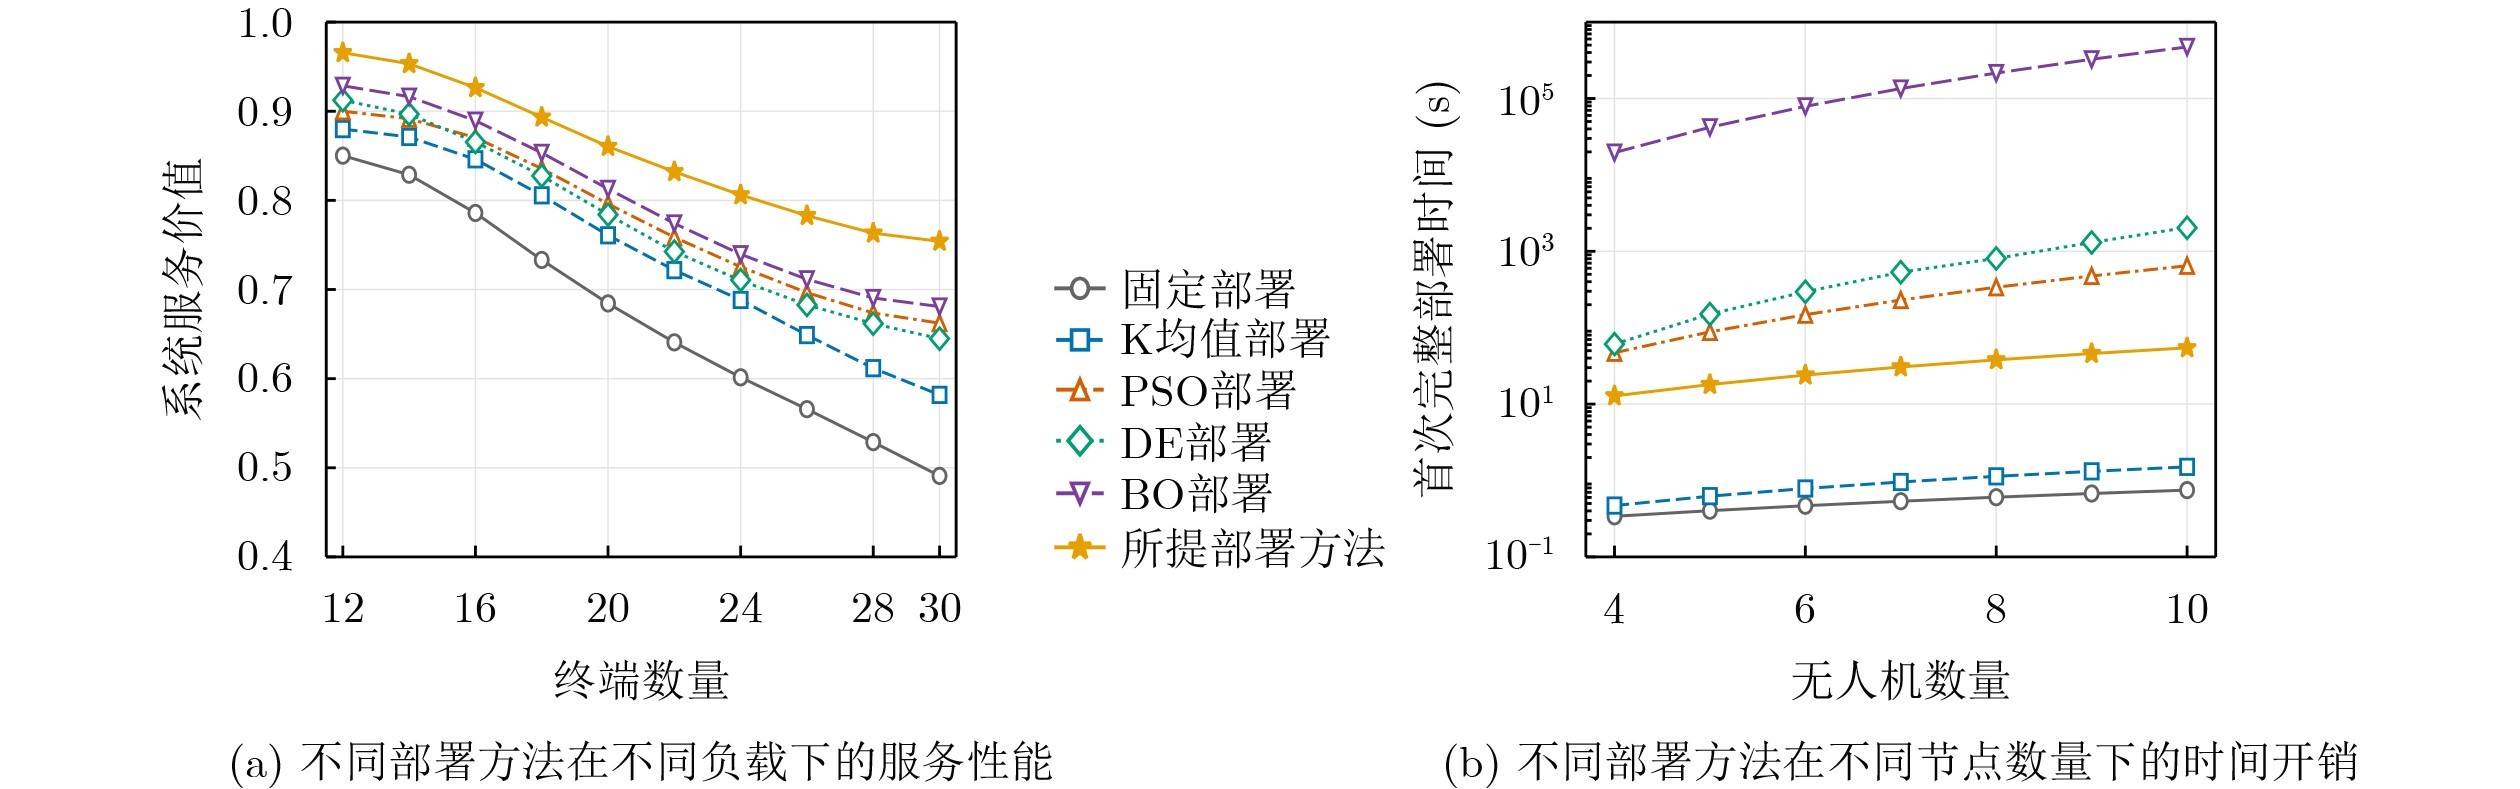
  •   Objective  In areas with weak ground-network coverage or limited Global Navigation Satellite System (GNSS) availability, multiple dual-functional Unmanned Aerial Vehicles (UAVs) can provide uplink communication and cooperative localization services. Ground terminals have different requirements for data volume, minimum communication rate, localization-accuracy threshold, service priority, and communication and localization service weights. Maximizing communication rate, localization accuracy, or a weighted sum of the two cannot directly reflect these differentiated requirements. A service below its activation threshold may be unusable, whereas resources allocated after demand saturation provide little additional value. A quasi-static service period with prior terminal positions is therefore considered. A topology-dependent Value of Service (VoS) is formulated, and Physical Resource Block (PRB) scheduling and UAV positions are jointly optimized.  Methods  Data or Sounding Reference Signals (SRSs) are transmitted by terminals over assigned PRBs. Time Difference of Arrival (TDoA) measurements are formed by synchronized UAVs, and a probabilistic air-to-ground channel model determines communication access and valid localization anchors. Communication VoS combines a sigmoidal rate utility with data completeness. Position Error Bound (PEB), derived from the accumulated Fisher Information Matrix (FIM), is mapped to an exponential utility to quantify localization VoS. Terminal priorities and communication and localization service weights are used to aggregate the two service values. The resulting problem P0 couples binary scheduling, non-concave utilities, time-frequency resources, service relationships, localization geometry, and UAV positions. For a fixed topology, the average number of allocated PRBs and active slots are used to construct a continuous service-level resource profile. This profile approximates the original schedule but does not provide an upper bound. Bandwidth responses are obtained by deterministic one-dimensional branch-and-bound search with damped Newton refinement and shadow-price bisection. Slot responses are obtained by deterministic comparison of a finite set of service-boundary, integer-slot, and feasible-domain-boundary candidates. Adjacent-integer recovery and deterministic slot packing are then used to construct a feasible integer schedule under resource-capacity and terminal-power constraints. If packing fails, the upward-rounded component with the smallest unit VoS loss is rolled back, and the schedule is repacked. VoS is then recomputed from the recovered integer schedule. Thus, the reported schedules remain feasible for P0 without any claim of global optimality. The fixed-topology resource-allocation procedure produces a complete resource response, including the recovered feasible schedule and its VoS, which is subsequently used to drive deployment. Coverage-repair, localization-geometry-improvement, and resource-saving candidates are generated according to service deficits, service relationships, and resource consumption. Normalized proxy scores, per-UAV candidate truncation, and beam search reduce the number of complete resource-response evaluations. For each retained deployment, service relationships are rebuilt, including communication access and localization anchors, and the FIM and resource allocation are recomputed. A candidate is accepted only when the VoS gain obtained from its complete resource response exceeds the preset threshold. The resulting outer sequence is monotonic and bounded and converges to a stable point within the generated candidate set. Resource allocation and node deployment remain coupled throughout the procedure. For each retained topology, communication access, localization anchors, the FIM, and the feasible integer schedule are recomputed before VoS is evaluated. Proxy scores are used only to rank candidates, whereas final acceptance is always based on the complete resource response. The next topology is therefore not selected from distance or localization geometry alone. The accepted update reflects terminal demand, resource scarcity, and localization geometry under the same feasible scheduling constraints used in the objective. This design keeps the optimization objective consistent with the final deployment decision and avoids a geometry-only selection rule.  Results and Discussions  Simulations are conducted in a 700 m × 700 m area with four UAVs at a baseline deployment height of 150 m. Communication-dominant, localization-dominant, and balanced terminals are included in equal proportions. At each load, all methods share 30 independent scenarios and identical random seeds. The deployment-height experiment reports a 95% confidence interval based on 1,000 scenario-level bootstrap resamples. For fair comparisons, all resource-allocation methods use the same topology, resource pool, and random scenarios. All deployment methods use the same proposed joint resource-allocation response, are evaluated from a cold start, and are subject to the same cap on complete resource-response evaluations, with initialization and training costs included. VoS-driven allocation yields smaller communication-rate and localization-accuracy demand deviations than the communication-priority and average-utility metrics because service saturation redirects resources from overprovisioned requests to insufficiently served requests (Fig. 2). In the convergence test, three feasible initializations converge to similar system VoS values. Damping suppresses oscillations near transitions between non-concave segments, and the small-scale benchmark indicates limited empirical loss from the continuous response and integer recovery (Fig. 3). With increasing terminal load, the proposed joint allocator outperforms a Particle Swarm Optimization (PSO)-based slot-response variant, as well as non-joint, learning-based, weight-driven, and random allocation methods (Fig. 4). Communication service is more sensitive to terminal load because both communication rate and data completeness must be maintained, whereas localization service accumulates information across anchors and slots. Resource-pool tests further show that additional bandwidth provides little benefit when slots are scarce, whereas increasing SRS bandwidth more directly improves localization. The structured deployment search achieves higher VoS with shorter end-to-end deployment time than PSO, Differential Evolution (DE), and Bayesian Optimization (BO) by focusing complete resource-response evaluations on service-aware candidates (Fig. 5). VoS first increases and then decreases with UAV deployment height because improved line-of-sight probability and multi-anchor visibility compete with increased propagation distance and path loss. Horizontal deployment updates balance communication-link quality and localization geometry according to terminal requirements (Fig. 6).  Conclusions  The proposed framework evaluates communication and localization services according to demand satisfaction and coordinates time-frequency resource allocation with iterative UAV deployment updates through complete resource responses and structured candidate search. It improves demand matching, system VoS, deployment efficiency, and interpretability while preserving feasibility under the original scheduling constraints. Prior terminal positions and a quasi-static service period are assumed. Future work will address dynamic terminal movement and changing demands over longer service periods through dynamic resource allocation and continuous UAV trajectory optimization.
  • loading
  • [1]
    新华社. 中华人民共和国国民经济和社会发展第十五个五年规划纲要[EB/OL]. https://www.gov.cn/yaowen/liebiao/202603/content_7062633.htm, 2026. (查阅网上资料,未找到本条文献英文翻译信息,请确认).
    [2]
    PAN Yu, LI Ruoguang, DA Xinyu, et al. Cooperative trajectory planning and resource allocation for UAV-enabled integrated sensing and communication systems[J]. IEEE Transactions on Vehicular Technology, 2024, 73(5): 6502–6516. doi: 10.1109/TVT.2023.3337106.
    [3]
    孙伟皓, 王海, 秦蓁, 等. 机会无人机辅助数据收集的组网和资源分配方法[J]. 电子与信息学报, 2025, 47(5): 1381–1391. doi: 10.11999/JEIT241053.

    SUN Weihao, WANG Hai, QIN Zhen, et al. Networking and resource allocation methods for opportunistic UAV-assisted data collection[J]. Journal of Electronics & Information Technology, 2025, 47(5): 1381–1391. doi: 10.11999/JEIT241053.
    [4]
    YANG Yang, CHEN Mingzhe, BLANKENSHIP Y, et al. Positioning using wireless networks: Applications, recent progress, and future challenges[J]. IEEE Journal on Selected Areas in Communications, 2024, 42(9): 2149–2178. doi: 10.1109/JSAC.2024.3423629.
    [5]
    YANG Zheyuan, BI Suzhi, and ZHANG Y J A. Deployment optimization of dual-functional UAVs for integrated localization and communication[J]. IEEE Transactions on Wireless Communications, 2023, 22(12): 9672–9687. doi: 10.1109/TWC.2023.3273159.
    [6]
    JIANG Yifan, WU Qingqing, CHEN Wen, et al. UAV-enabled integrated sensing and communication: Tracking design and optimization[J]. IEEE Communications Letters, 2024, 28(5): 1024–1028. doi: 10.1109/LCOMM.2024.3379504.
    [7]
    WU Jun, YUAN Weijie, and BAI Lin. On the interplay between sensing and communications for UAV trajectory design[J]. IEEE Internet of Things Journal, 2023, 10(23): 20383–20395. doi: 10.1109/JIOT.2023.3287991.
    [8]
    LI Biwei, WANG Xianbin, XIN Yan, et al. Value of service maximization in integrated localization and communication system through joint resource allocation[J]. IEEE Transactions on Communications, 2023, 71(8): 4957–4971. doi: 10.1109/TCOMM.2023.3280212.
    [9]
    3GPP. TS 38.211 V17.0. 0-2022 NR Physical channels and modulation[S]. Sophia Antipolis, European Telecommunications Standards Institute (ETSI), 2022.
    [10]
    SHEN Yuan and WIN M Z. Fundamental limits of wideband localization—part I: A general framework[J]. IEEE Transactions on Information Theory, 2010, 56(10): 4956–4980. doi: 10.1109/TIT.2010.2060110.
    [11]
    KELLY F P, MAULLOO A K, and TAN D K H. Rate control for communication networks: Shadow prices, proportional fairness and stability[J]. Journal of the Operational Research Society, 1998, 49(3): 237–252. doi: 10.1057/palgrave.jors.2600523.
    [12]
    KWON G, CONTI A, PARK H, et al. Joint communication and localization in millimeter wave networks[J]. IEEE Journal of Selected Topics in Signal Processing, 2021, 15(6): 1439–1454. doi: 10.1109/JSTSP.2021.3113115.
    [13]
    YANG Liu, WEI Yifei, FENG Zhiyong, et al. Deep reinforcement learning-based resource allocation for integrated sensing, communication, and computation in vehicular network[J]. IEEE Transactions on Wireless Communications, 2024, 23(12): 18608–18622. doi: 10.1109/TWC.2024.3470873.
    [14]
    金飞鸿, 张静, 谢亚琴. 用户需求差异化场景下信息年龄优先的多无人机部署及资源分配方法[J]. 电子与信息学报, 2026, 48(1): 253–263. doi: 10.11999/JEIT251062.

    JIN Feihong, ZHANG Jing, and XIE Yaqin. AoI-prioritized multi-UAV deployment and resource allocation method in scenarios with differentiated user requirements[J]. Journal of Electronics & Information Technology, 2026, 48(1): 253–263. doi: 10.11999/JEIT251062.
    [15]
    XU Renjie, HUANG Zhaoke, WANG Chenwei, et al. Evolving collaborative differential evolution for dynamic multi-objective UAV path planning[J]. IEEE Transactions on Vehicular Technology, 2026, 75(5): 7456–7468. doi: 10.1109/TVT.2025.3632847.
    [16]
    BENZAGHTA M, GERACI G, LÓPEZ-PÉREZ D, et al. Cellular network design for UAV corridors via data-driven high-dimensional Bayesian optimization[J]. IEEE Transactions on Wireless Communications, 2025, 24(9): 7530–7545. doi: 10.1109/TWC.2025.3561066.
  • 加载中

Catalog

    通讯作者: 陈斌, bchen63@163.com
    • 1. 

      沈阳化工大学材料科学与工程学院 沈阳 110142

    1. 本站搜索
    2. 百度学术搜索
    3. 万方数据库搜索
    4. CNKI搜索

    Figures(6)  / Tables(2)

    Article Metrics

    Article views (91) PDF downloads(11) Cited by()
    Proportional views
    Related

    /

    DownLoad:  Full-Size Img  PowerPoint
    Return
    Return