Advanced Search
Volume 48 Issue 9
Sep.  2026
Turn off MathJax
Article Contents
CHENG Yuanxun, HU Qingsong, ZHANG Xiaomin, WANG Xuesong. Millimeter-Wave Air-to-Ground Channel Prediction Assisted by Visual Information of the Propagation Environment[J]. Journal of Electronics & Information Technology, 2026, 48(9): 3822-3832. doi: 10.11999/JEIT260274
Citation: CHENG Yuanxun, HU Qingsong, ZHANG Xiaomin, WANG Xuesong. Millimeter-Wave Air-to-Ground Channel Prediction Assisted by Visual Information of the Propagation Environment[J]. Journal of Electronics & Information Technology, 2026, 48(9): 3822-3832. doi: 10.11999/JEIT260274

Millimeter-Wave Air-to-Ground Channel Prediction Assisted by Visual Information of the Propagation Environment

doi: 10.11999/JEIT260274 cstr: 32379.14.JEIT260274
Funds:  The National Natural Science Foundation of China (52474185)
  • Received Date: 2026-03-16
  • Accepted Date: 2026-05-15
  • Rev Recd Date: 2026-05-15
  • Available Online: 2026-06-02
  • Publish Date: 2026-09-18
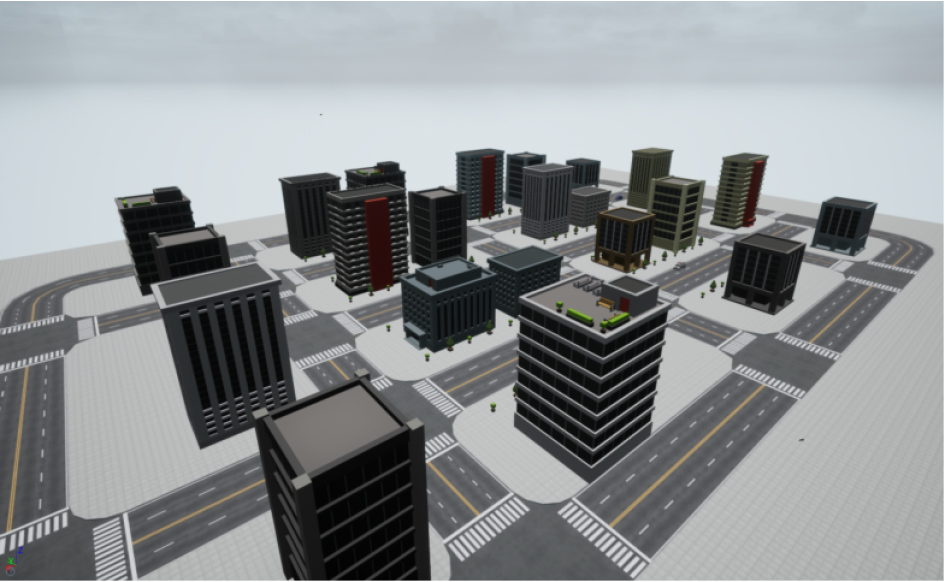
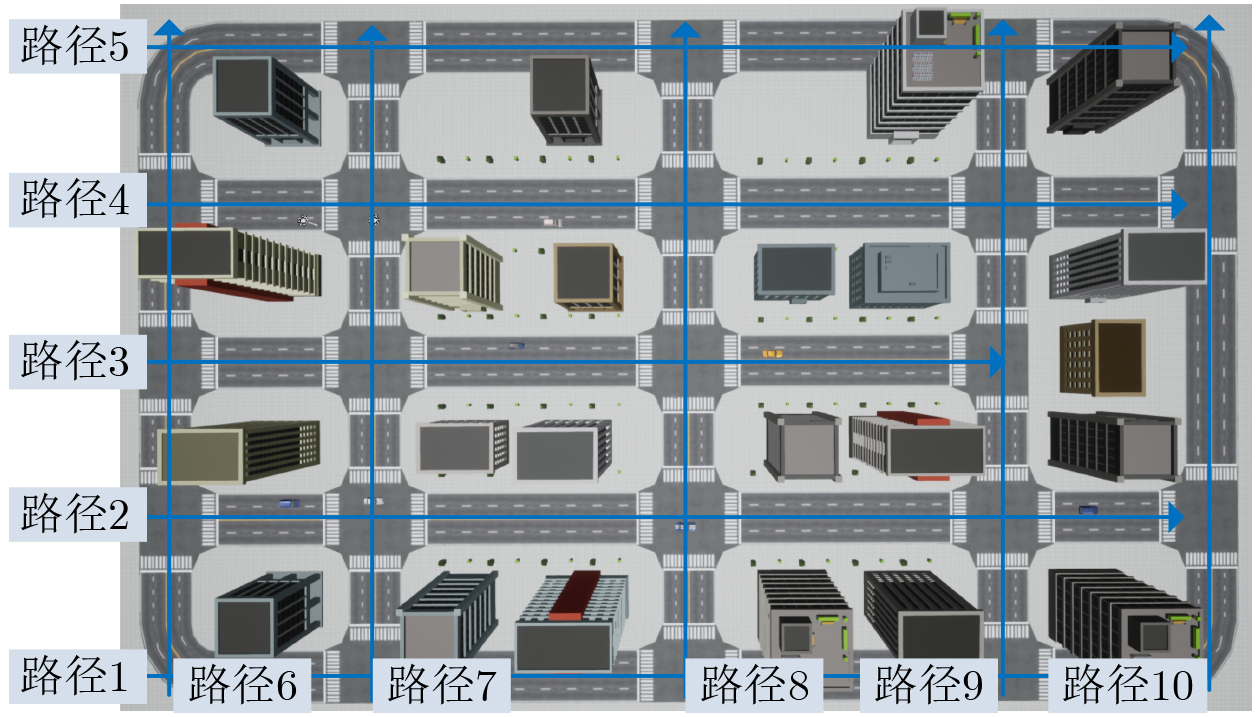
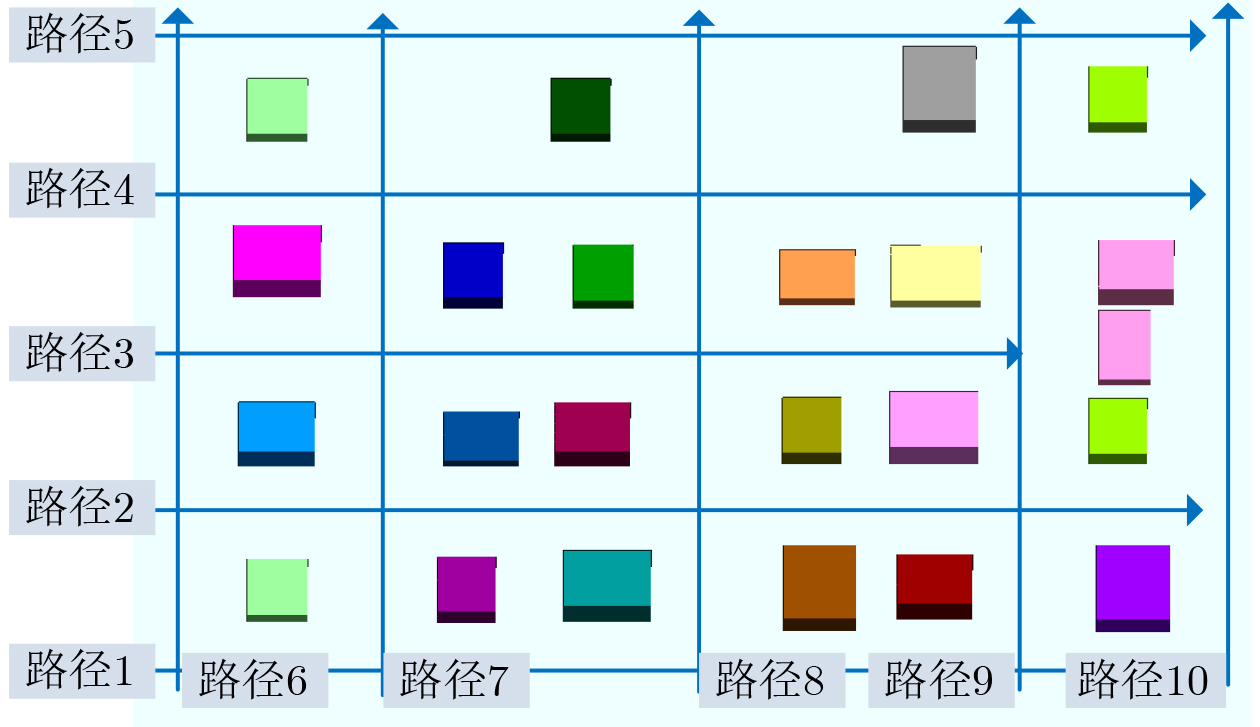
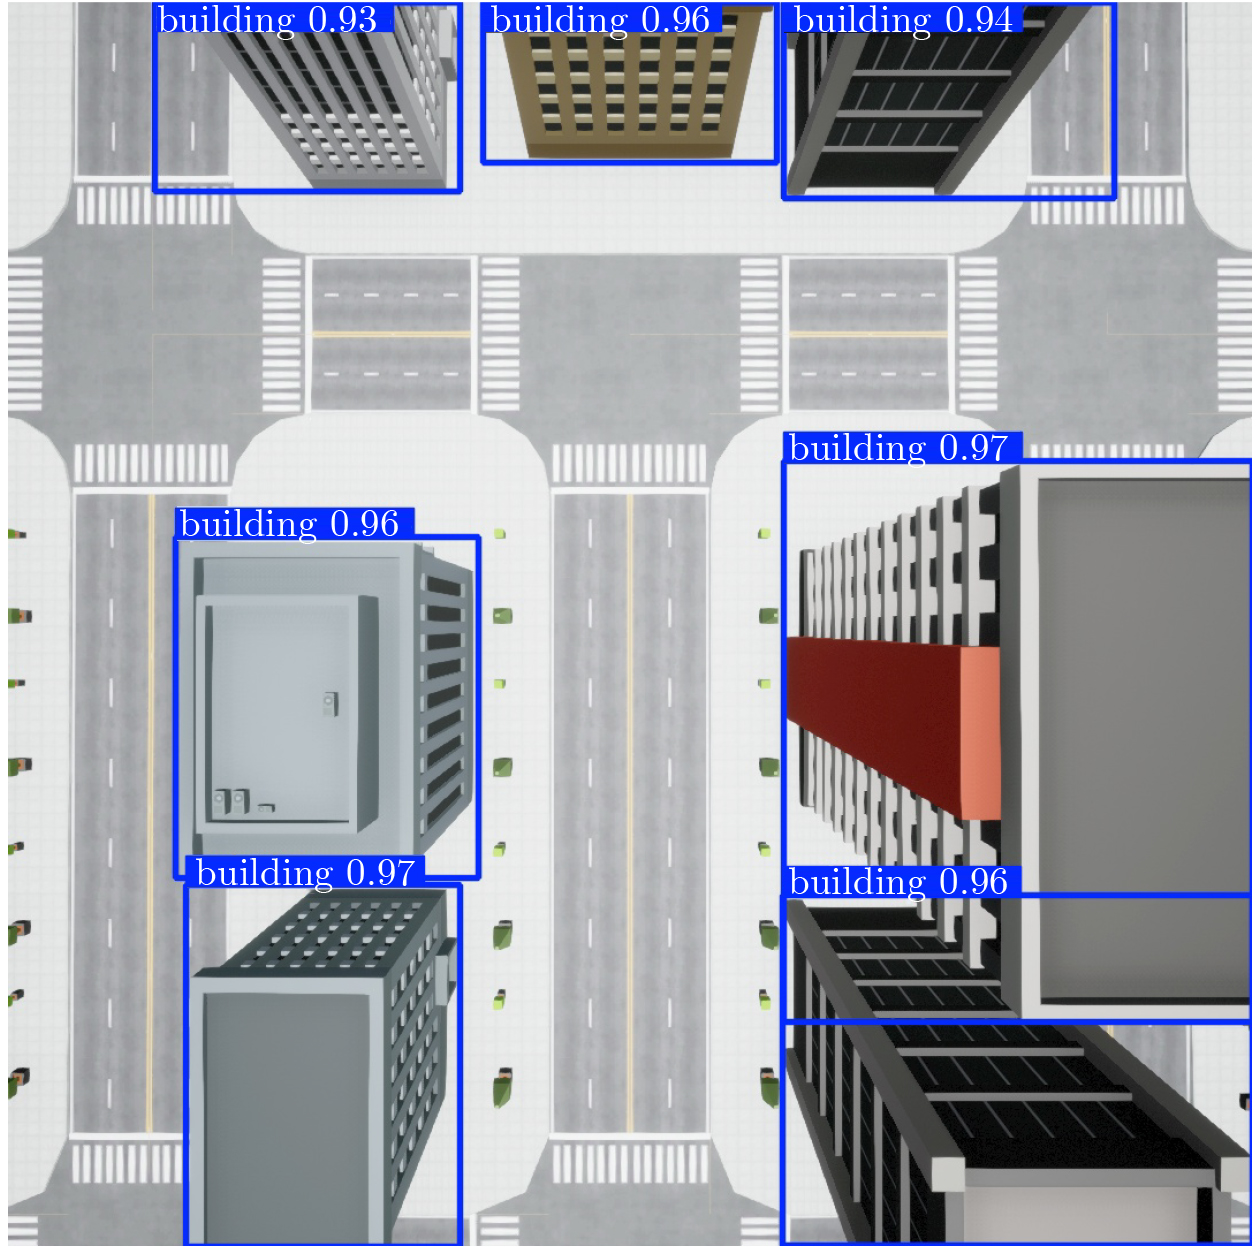
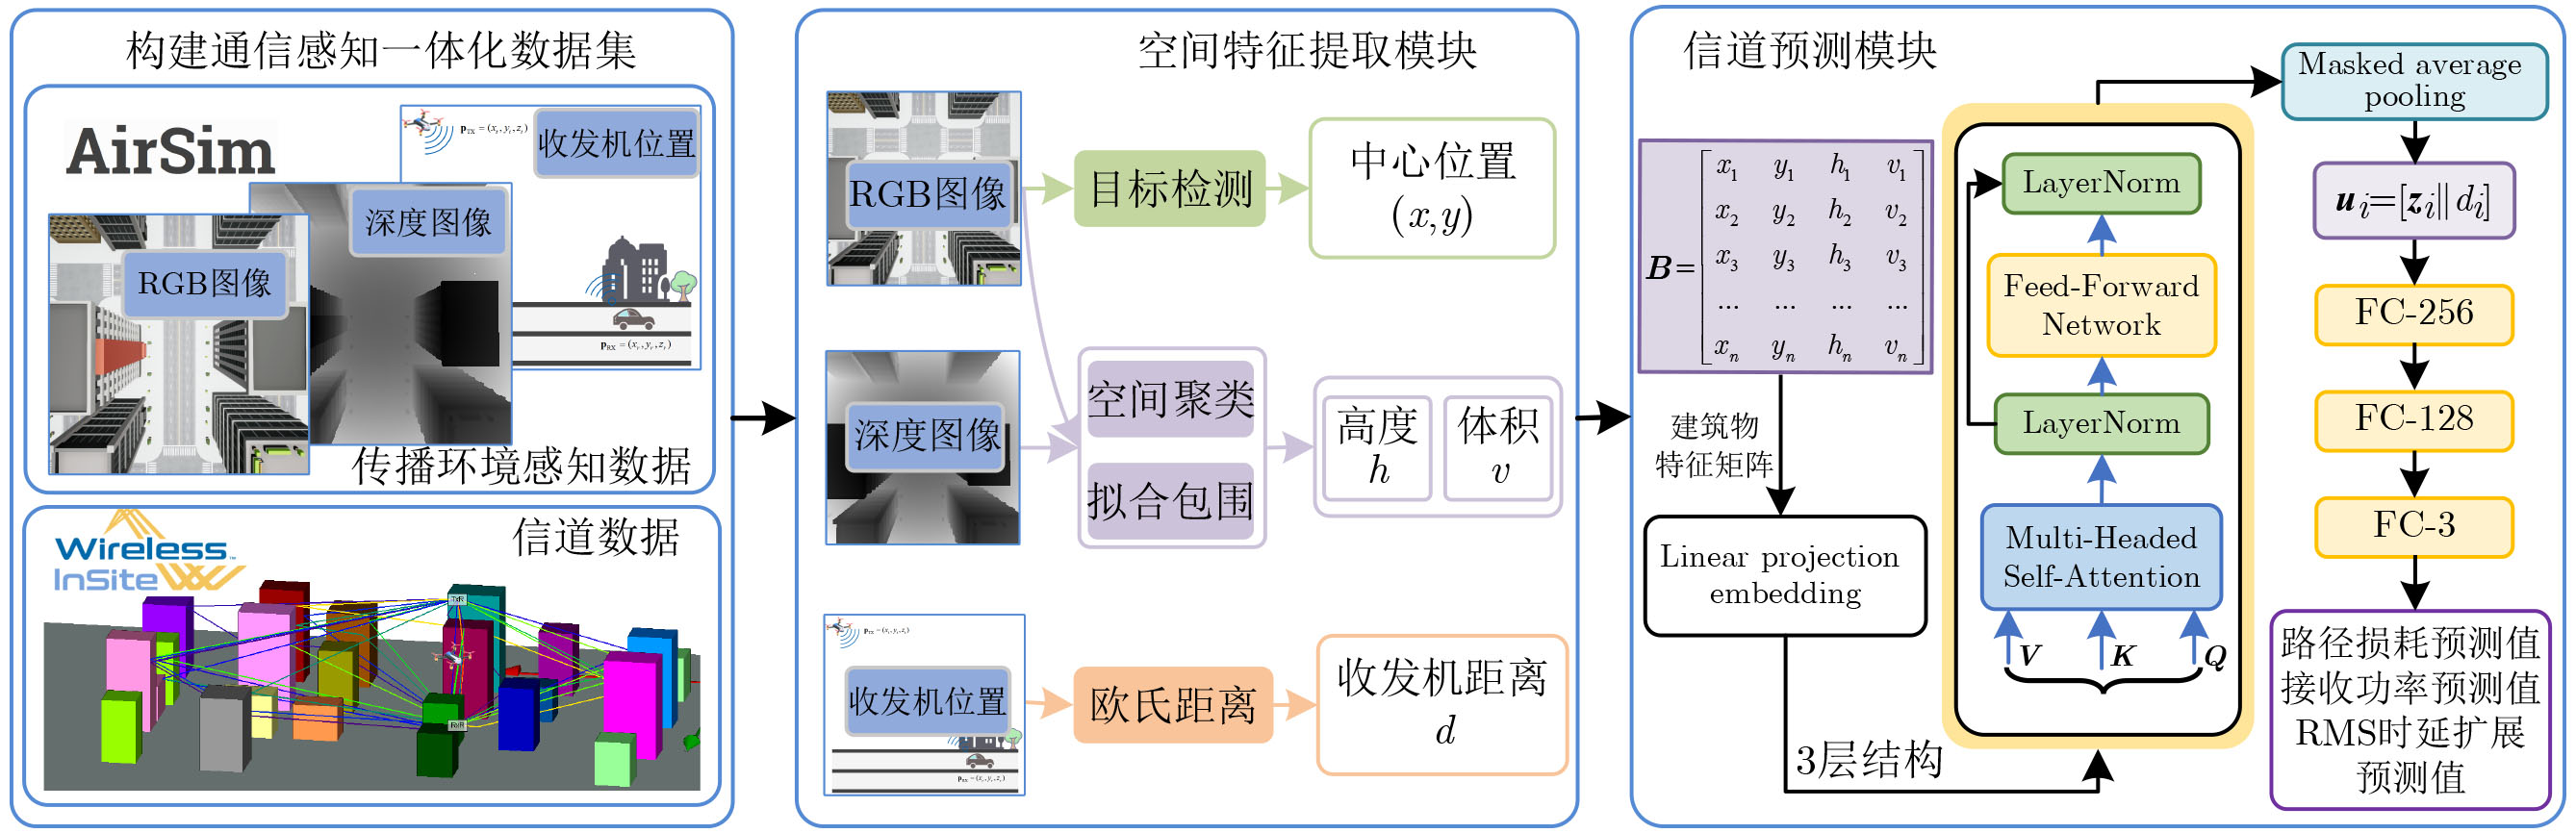
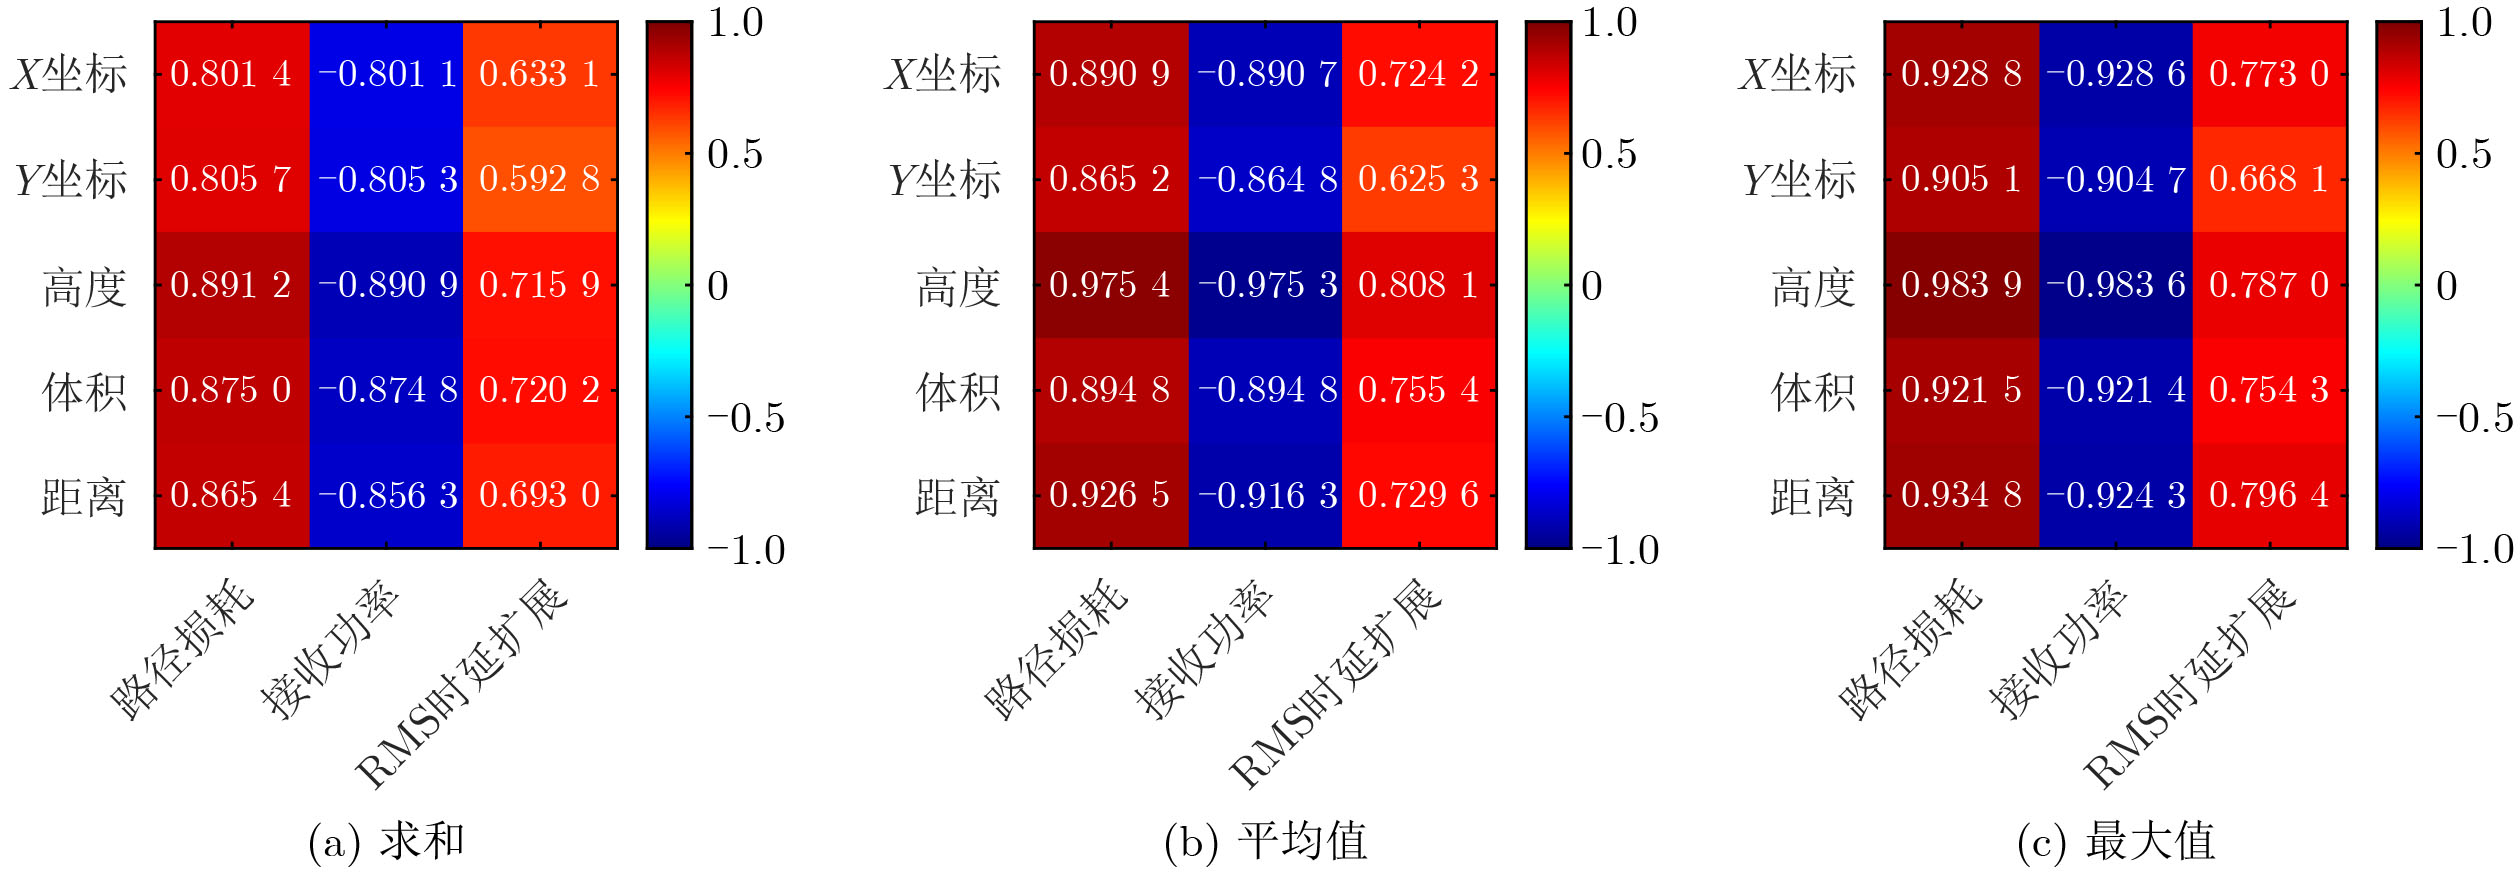
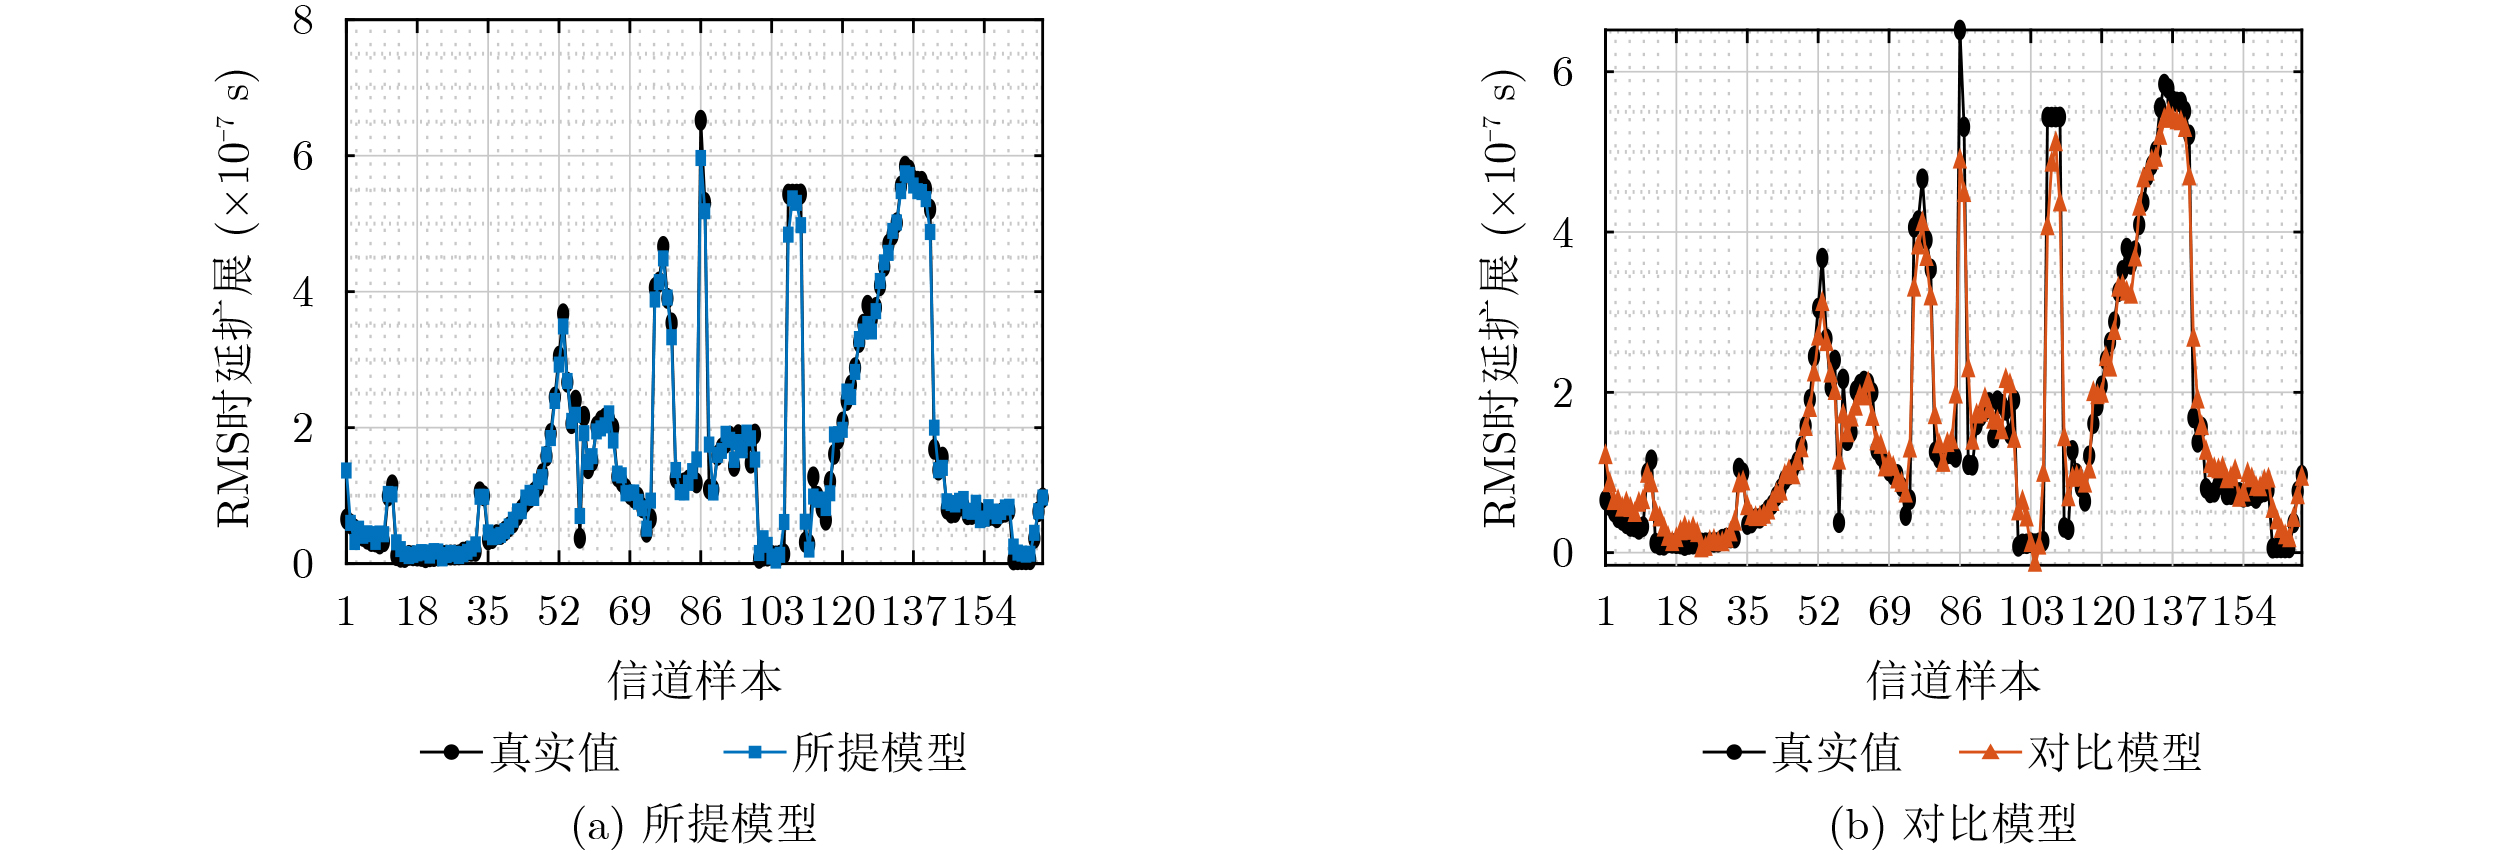
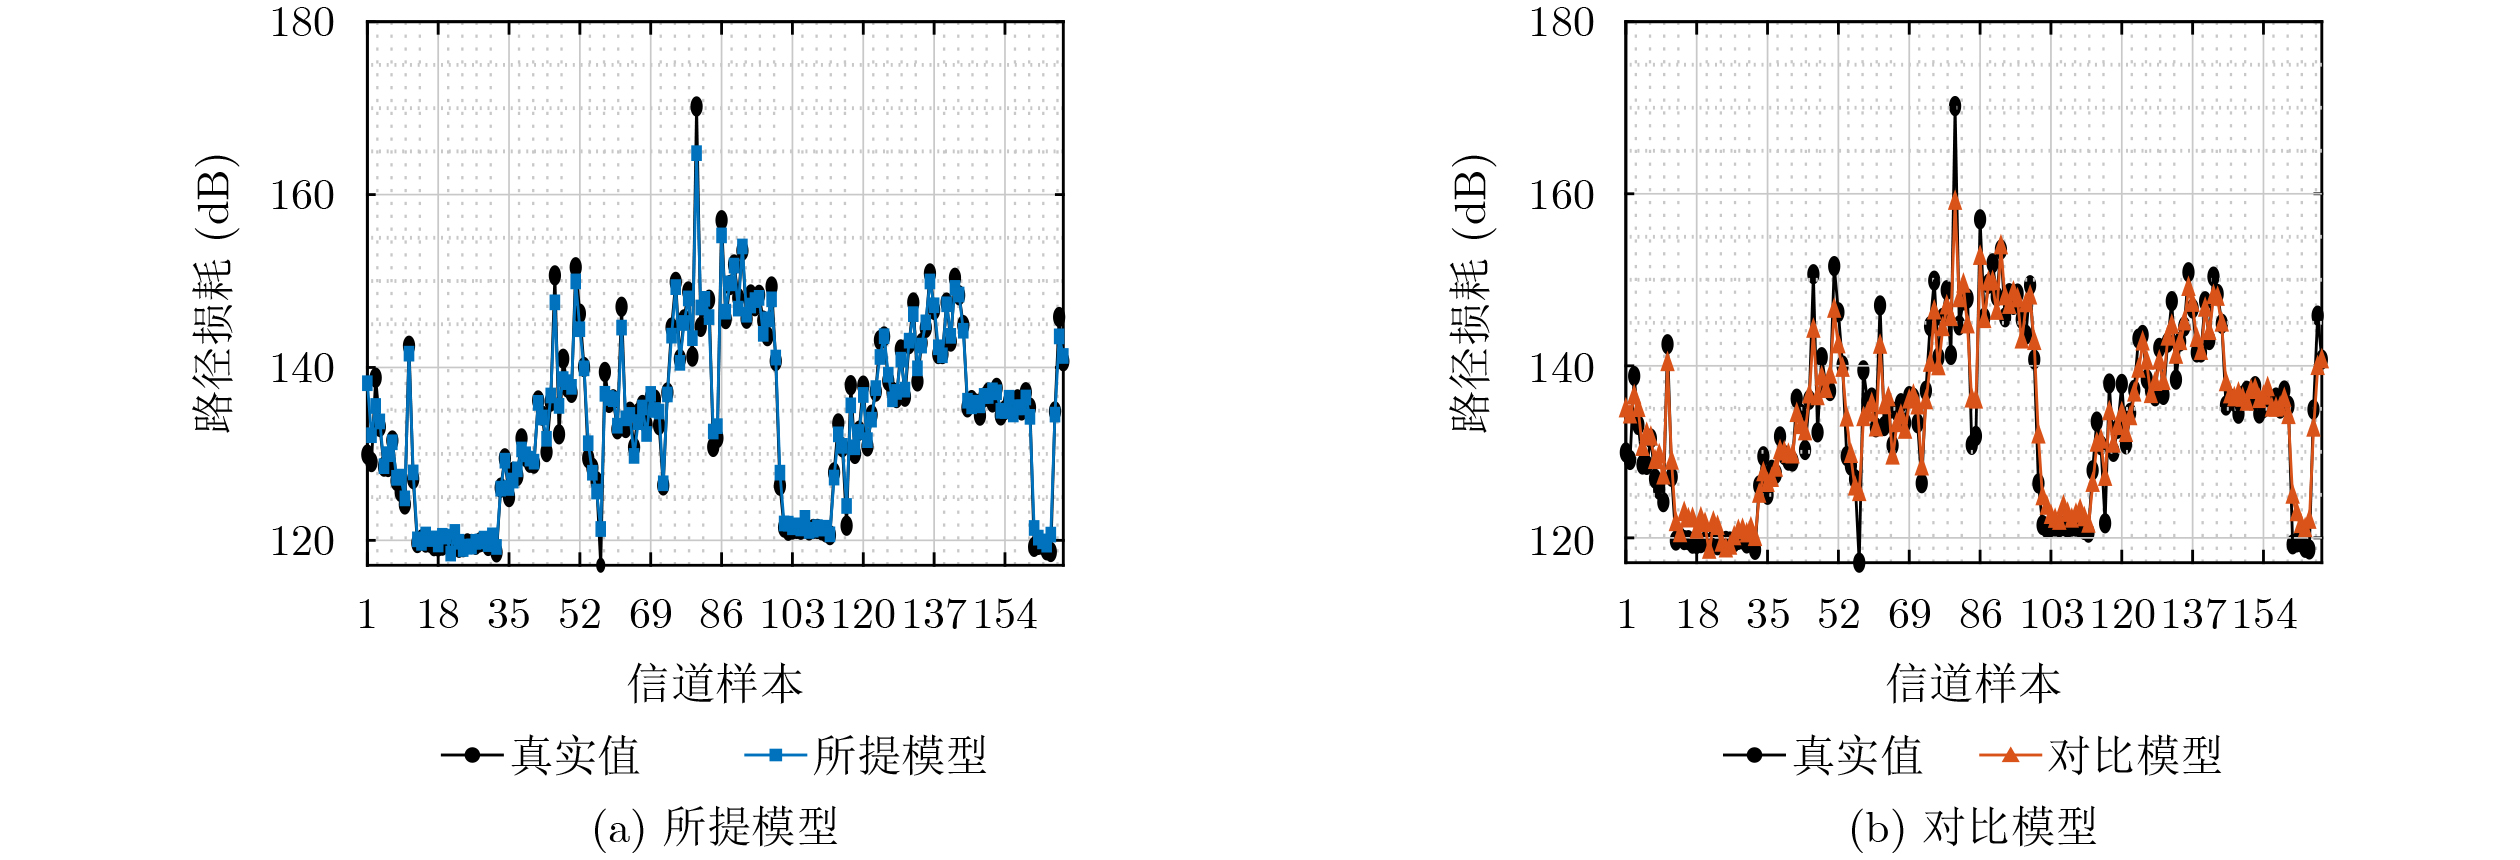
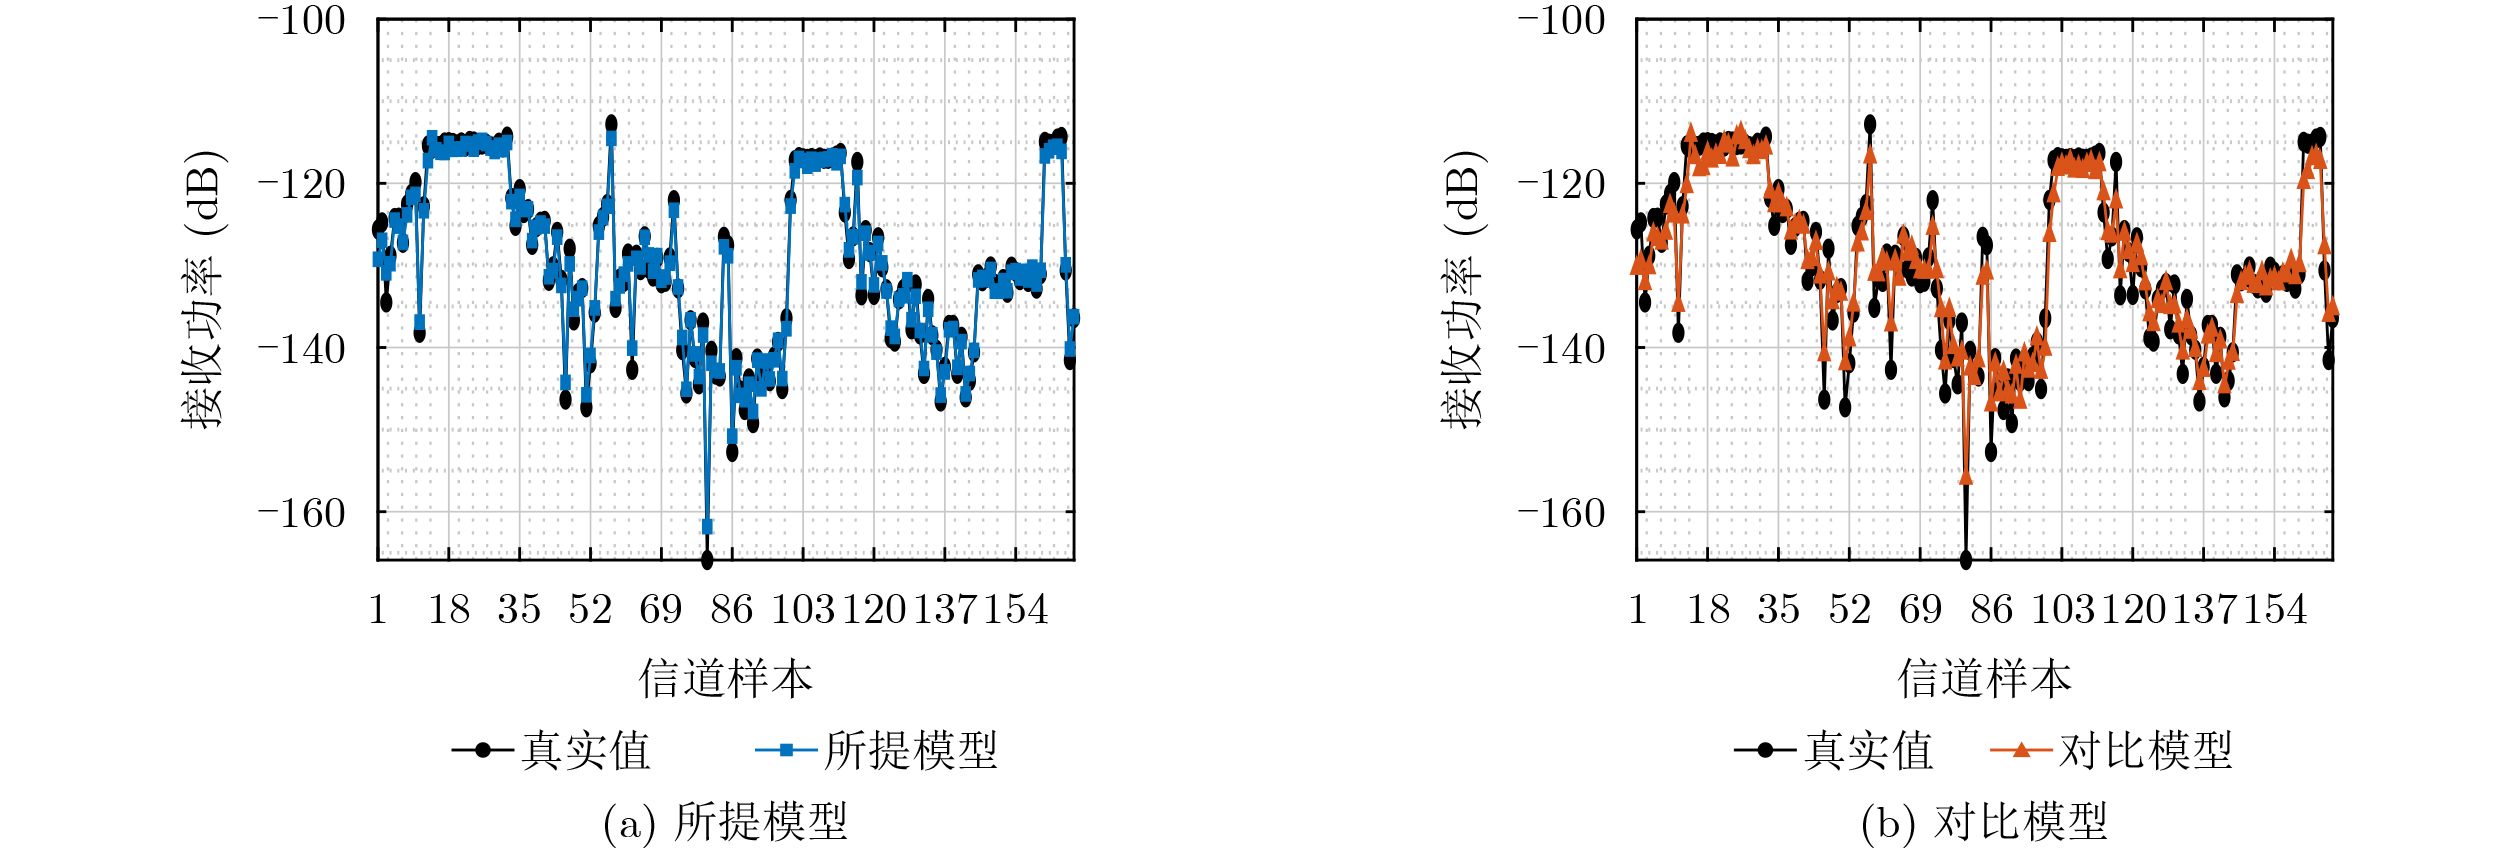
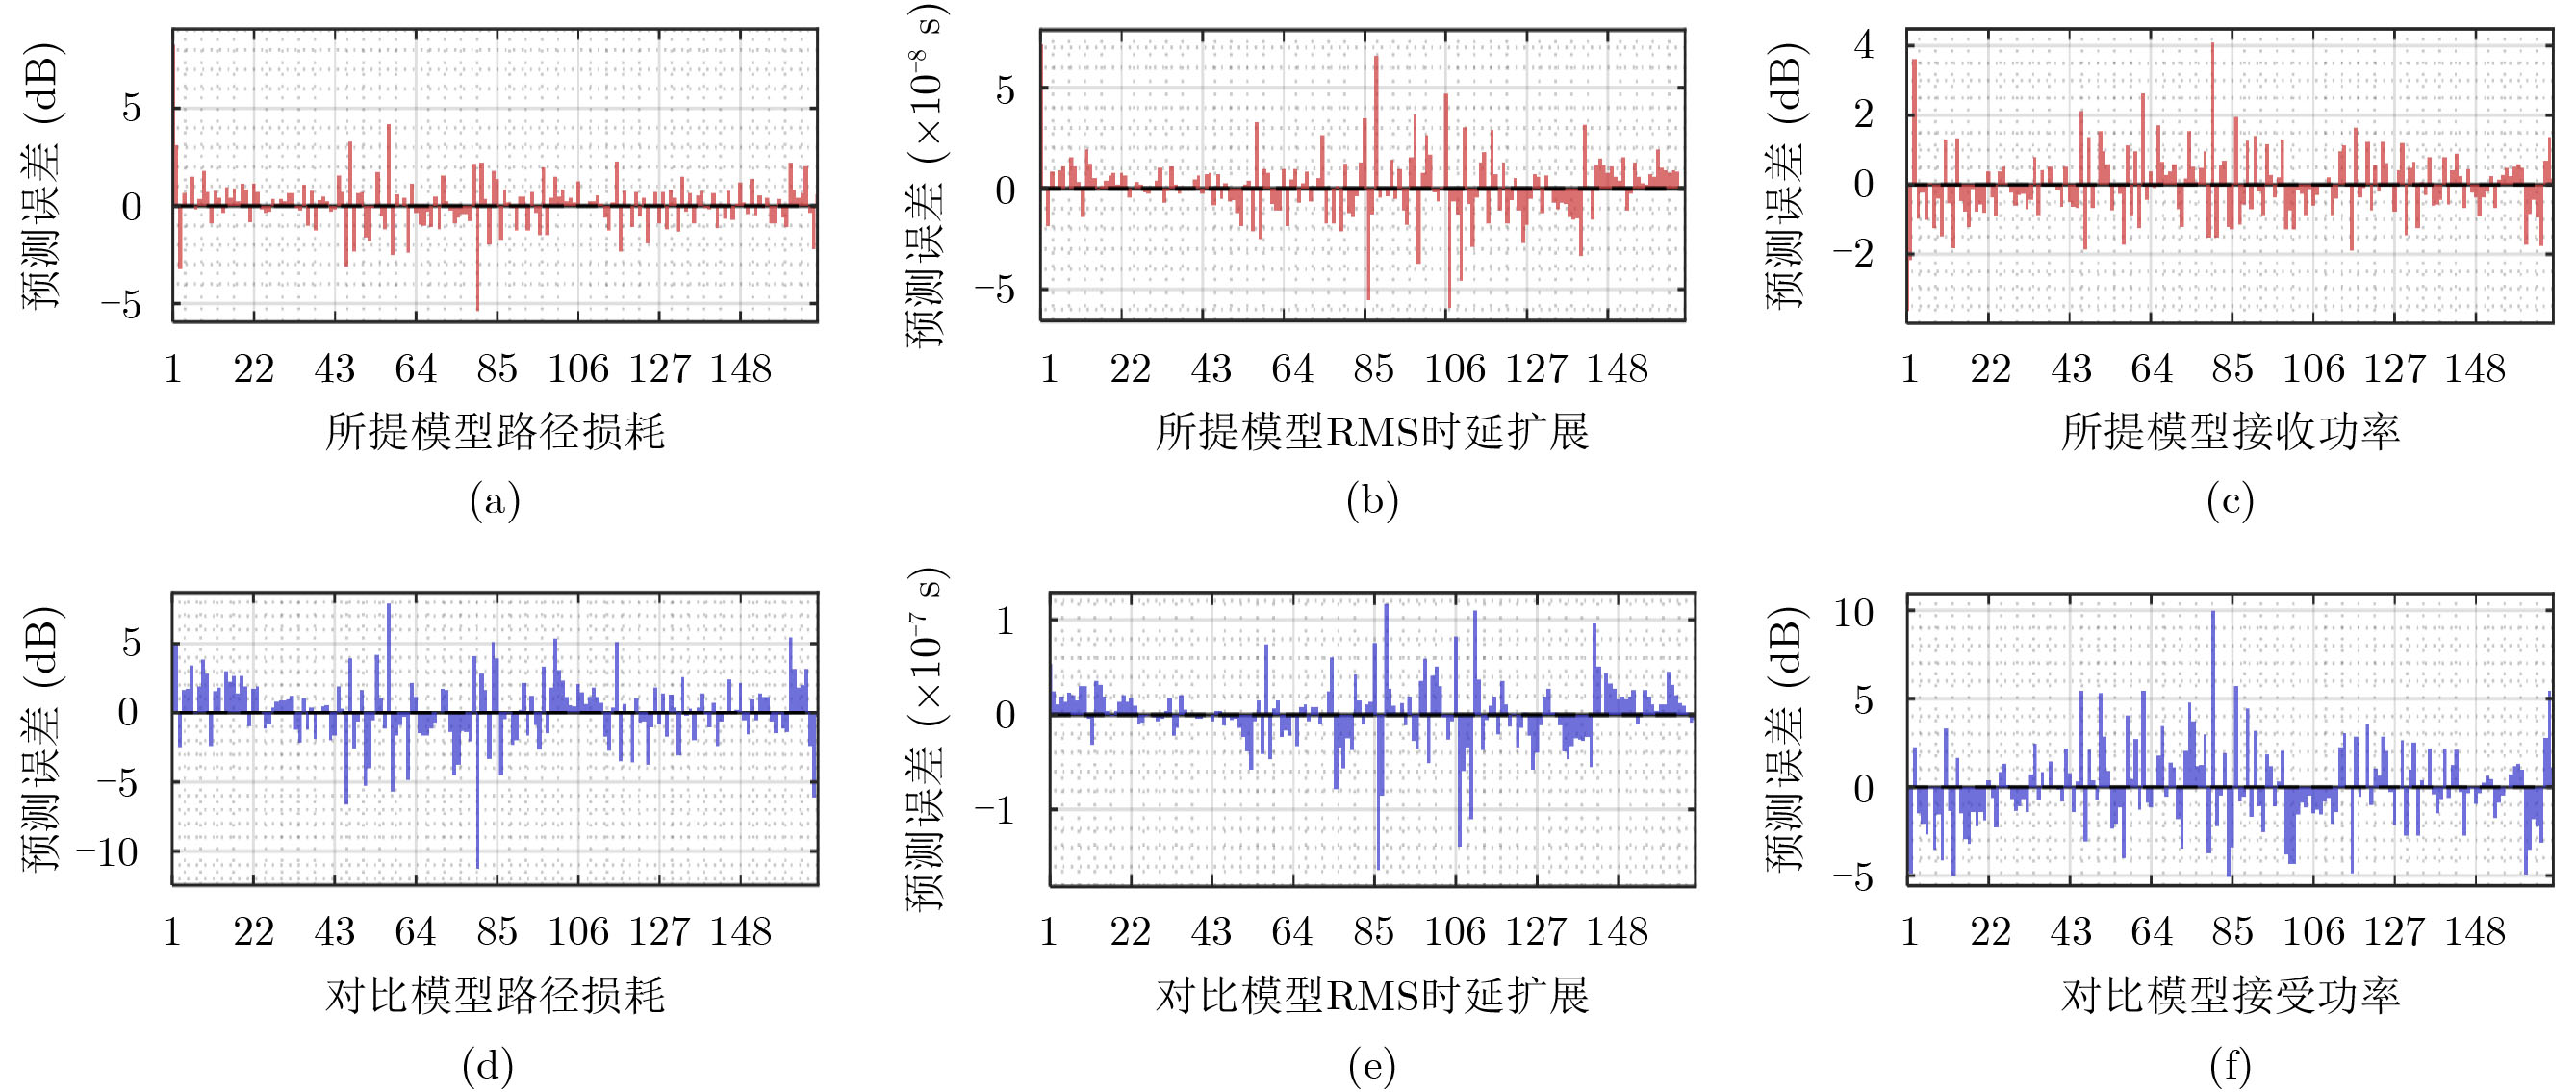
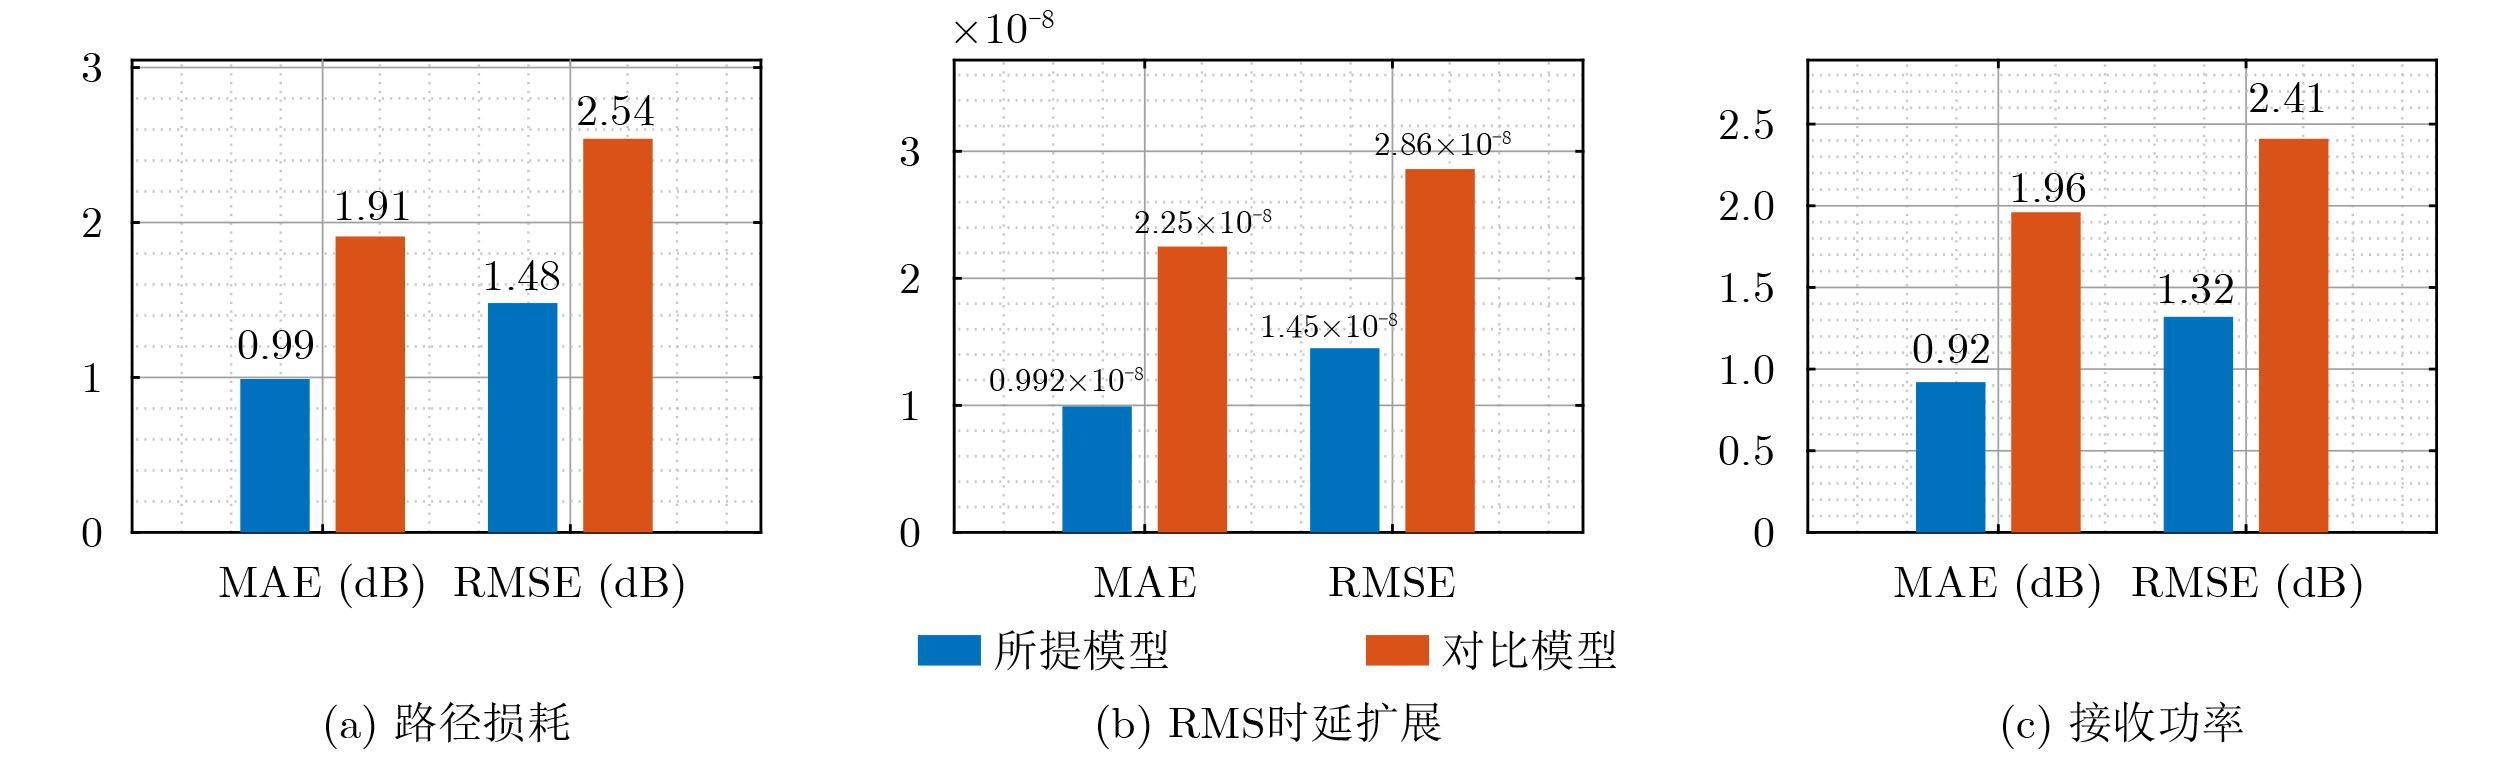
  •   Objective  Accurate prediction of Air-to-Ground (A2G) channel parameters is essential for adaptive transmission and resource optimization in Unmanned Aerial Vehicle (UAV) communications. In urban Millimeter-Wave (mmWave) scenarios, A2G links are highly sensitive to blockage, reflection, scattering, and rapidly changing geometry among the transmitter, receiver, and surrounding buildings. The channel therefore shows strong spatial and temporal nonstationarity. Conventional pilot- or feedback-based methods can become ineffective because channel estimates are rapidly outdated. Recent data-driven approaches have shown potential. However, many rely heavily on historical channel observations or directly use raw images as network inputs, which may introduce redundant visual information and reduce physical interpretability. To address these limitations, this paper proposes a vision-assisted mmWave A2G channel prediction method. Low-dimensional geometric features are extracted from the propagation environment instead of using raw visual data directly. The method preserves key structural information governing channel evolution, reduces irrelevant redundancy, and improves the accuracy of channel prediction.  Methods  An Integrated Sensing and Communication (ISAC) dataset with strict spatial and temporal alignment is established for mmWave UAV A2G channel prediction. On the sensing side, a high-fidelity Three-Dimensional (3D) urban scenario containing 23 buildings, roads, and intersections is constructed in Unreal Engine 4.27. Synchronized RGB and depth images are collected in AirSim using a multirotor UAV equipped with RGB and depth cameras. The UAV flies along 10 preset trajectories at a height of 55 m with a spatial sampling interval of 1 m, yielding 2 160 valid visual samples (Fig. 1, Fig. 2). On the communication side, the same scene is reconstructed in Wireless InSite. The transmitter-receiver positions are updated synchronously along the same trajectories to ensure frame-level alignment between visual and channel data (Fig. 3). A cross-modal spatial feature extraction scheme is developed to obtain compact and physically meaningful environmental representations. Buildings are first detected from RGB images using YOLOv8 (Fig. 4). The detected regions are then registered with depth images to reconstruct 3D point clouds. After Euclidean clustering and axis-aligned bounding-box fitting, key geometric attributes are extracted, including planar position, height, and volume. These features are combined with the transmitter-receiver distance to form the spatial feature vector for each frame. Their relevance to path loss, received power, and Root Mean Square (RMS) delay spread is evaluated through cosine-similarity-based correlation analysis (Fig. 6). Based on the extracted features, a hybrid Transformer-Multilayer Perceptron (MLP) network is designed for channel prediction (Fig. 5). Building features are first projected into a latent space. A stacked Transformer encoder is then used to capture global interactions among buildings through masked multi-head self-attention. Masked average pooling aggregates building-level representations into a scene-level environmental descriptor. This descriptor is concatenated with the link-distance feature and fed into an MLP regressor to predict the three target channel parameters.  Results and Discussions  The results confirm the effectiveness of the proposed spatial feature representation. Correlation analysis shows that the extracted geometric features are consistently related to path loss, received power, and RMS delay spread under different aggregation strategies (Fig. 6). This result indicates that compact building descriptors can effectively characterize the propagation environment. Among these descriptors, building height shows the strongest correlation with all three channel parameters. This finding confirms the key role of building height in blockage, attenuation, and multipath propagation in urban mmWave A2G channels. In prediction experiments, the proposed method accurately tracks the variation trends of all three targets. It remains effective in deep-fading and sharp-fluctuation regions for path loss prediction (Fig. 7), achieves high consistency with the ground truth for RMS delay spread (Fig. 8), and follows rapid local fluctuations in received power with high fidelity (Fig. 9). By contrast, the benchmark model captures only the overall trend and shows larger deviations at peaks, valleys, and abrupt-change intervals. Residual analysis further demonstrates the superiority of the proposed method. Across all three tasks, its errors are more concentrated around zero and fluctuate within narrower ranges than those of the benchmark model (Fig. 10). Quantitatively, both Mean Absolute Error (MAE) and Root Mean Square Error (RMSE) are reduced (Fig. 11). Compared with the benchmark model, the proposed method improves MAE by 48.2%, 55.9%, and 53.1% for path loss, RMS delay spread, and received power, respectively. The corresponding RMSE improvements are 41.7%, 49.3%, and 45.2% (Table 3). The model also maintains acceptable complexity, with about 5.5 M parameters and a single-frame inference delay of about 3.4 ms. These results indicate its potential for real-time deployment.  Conclusions  A vision-assisted mmWave A2G channel prediction method is proposed for UAV communications. A strictly aligned ISAC dataset is constructed, and low-dimensional spatial features with clear physical meaning are extracted from RGB-depth visual data. The method establishes an effective mapping from environmental geometry to channel parameters. The proposed Transformer-MLP framework accurately predicts path loss, received power, and RMS delay spread. It also provides better interpretability, robustness, and efficiency than the benchmark model.
  • loading
  • [1]
    陶静, 侯萌, 彭薇, 等. 伪三维卷积注意力网络的多步信道预测[J]. 电子与信息学报, 2026, 48(1): 394–403. doi: 10.11999/JEIT251090.

    TAO Jing, HOU Meng, PENG Wei, et al. A Multi-step channel prediction method based on pseudo-3D convolutional neural network with attention mechanism[J]. Journal of Electronics & Information Technology, 2026, 48(1): 394–403. doi: 10.11999/JEIT251090.
    [2]
    CUI Yanpeng, FENG Zhiyong, ZHANG Qixun, et al. Toward trusted and swift UAV communication: ISAC-enabled dual identity mapping[J]. IEEE Wireless Communications, 2023, 30(1): 58–66. doi: 10.1109/MWC.003.2200207.
    [3]
    LIU Lihong, FENG Hui, YANG Tao, et al. MIMO-OFDM wireless channel prediction by exploiting spatial-temporal correlation[J]. IEEE Transactions on Wireless Communications, 2014, 13(1): 310–319. doi: 10.1109/TWC.2013.112613.130455.
    [4]
    ZENG Fanhui, ZHANG Rongqing, CHENG Xiang, et al. Channel prediction based scheduling for data dissemination in VANETs[J]. IEEE Communications Letters, 2017, 21(6): 1409–1412. doi: 10.1109/LCOMM.2017.2676766.
    [5]
    游雨欣, 姜兴龙, 刘会杰, 等. TDD OTFS低轨卫星通信系统的LLM信道预测方法[J]. 电子与信息学报, 2025, 47(8): 2535–2548. doi: 10.11999/JEIT250105.

    YOU Yuxin, JIANG Xinglong, LIU Huijie, et al. LLM channel prediction method for TDD OTFS low-earth-orbit satellite communication systems[J]. Journal of Electronics & Information Technology, 2025, 47(8): 2535–2548. doi: 10.11999/JEIT250105.
    [6]
    STENHAMMAR O, FODOR G, and FISCHIONE C. A comparison of neural networks for wireless channel prediction[J]. IEEE Wireless Communications, 2024, 31(3): 235–241. doi: 10.1109/MWC.006.2300140.
    [7]
    MELIHA M, CHARGÉ P, WANG Yide, et al. Deep learning-based channel prediction with path extraction[J]. IEEE Wireless Communications Letters, 2025, 14(3): 891–895. doi: 10.1109/LWC.2025.3527345.
    [8]
    WANG Jun, GONG Shenyi, XIAO Jian, et al. A lightweight channel prediction network for UAV-LEO satellite communications[J]. IEEE Wireless Communications Letters, 2025, 14(1): 113–117. doi: 10.1109/LWC.2024.3489677.
    [9]
    廖勇, 尹子松, 田肖懿. 车联网V2I场景下基于GNN的SC-FDMA智能信道估计[J]. 电子学报, 2024, 52(3): 772–782. doi: 10.12263/DZXB.20220545.

    LIAO Yong, YIN Zisong, and TIAN Xiaoyi. Intelligent channel estimation of SC-FDMA based on GNN for V2I scenarios in internet of vehicles[J]. Acta Electronica Sinica, 2024, 52(3): 772–782. doi: 10.12263/DZXB.20220545.
    [10]
    赵川斌, 许伟华, 林博, 等. 融合视觉的多模态通信感知一体化关键技术及原型验证[J]. 电子与信息学报, 2026, 48(2): 487–498. doi: 10.11999/JEIT250685.

    ZHAO Chuanbin, XU Weihua, LIN Bo, et al. Vision enabled multimodal integrated sensing and communications: Key technologies and prototype validation[J]. Journal of Electronics & Information Technology, 2026, 48(2): 487–498. doi: 10.11999/JEIT250685.
    [11]
    SUN Mingran, BAI Lu, HUANG Ziwei, et al. Multi-modal sensing data-based real-time path loss prediction for 6G UAV-to-ground communications[J]. IEEE Wireless Communications Letters, 2024, 13(9): 2462–2466. doi: 10.1109/LWC.2024.3419245.
    [12]
    ZHANG Xuejian, HE Ruisi, YANG Mi, et al. Vision aided channel prediction for vehicular communications: A case study of received power prediction using RGB Images[J]. IEEE Transactions on Vehicular Technology, 2025, 74(11): 17531–17544. doi: 10.1109/TVT.2025.3579333.
    [13]
    GUPTA A, DU Jinfeng, CHIZHIK D, et al. Machine learning-based urban canyon path loss prediction using 28 GHz Manhattan measurements[J]. IEEE Transactions on Antennas and Propagation, 2022, 70(6): 4096–4111. doi: 10.1109/TAP.2022.3152776.
    [14]
    NISHIO T, OKAMOTO H, NAKASHIMA K, et al. Proactive received power prediction using machine learning and depth images for mmWave networks[J]. IEEE Journal on Selected Areas in Communications, 2019, 37(11): 2413–2427. doi: 10.1109/JSAC.2019.2933763.
    [15]
    AHMADIEN O, ATES H F, BAYKAS T, et al. Predicting path loss distribution of an area from satellite images using deep learning[J]. IEEE Access, 2020, 8: 64982–64991. doi: 10.1109/ACCESS.2020.2985929.
    [16]
    YIN Hongpei, LIU P X, and ZHENG Minhua. Stereo visual-inertial odometry with online initialization and extrinsic self-calibration[J]. IEEE Transactions on Instrumentation and Measurement, 2023, 72: 9508210. doi: 10.1109/TIM.2023.3282674.
    [17]
    YUAN Xingyu, WANG Shuting, XIE Yuanlong, et al. Object-based semantic fusion algorithm of Lidar and camera via inverse projection[J]. IEEE Transactions on Instrumentation and Measurement, 2025, 74: 9513215. doi: 10.1109/TIM.2025.3548241.
    [18]
    GENG Maosi, LI Junyi, XIA Yingji, et al. A physics-informed transformer model for vehicle trajectory prediction on highways[J]. Transportation Research Part C: Emerging Technologies, 2023, 154: 104272. doi: 10.1016/j.trc.2023.104272.
    [19]
    TALAAT F M and ZAINELDIN H. An improved fire detection approach based on YOLO-v8 for smart cities[J]. Neural Computing and Applications, 2023, 35(28): 20939–20954. doi: 10.1007/s00521-023-08809-1.
  • 加载中

Catalog

    通讯作者: 陈斌, bchen63@163.com
    • 1. 

      沈阳化工大学材料科学与工程学院 沈阳 110142

    1. 本站搜索
    2. 百度学术搜索
    3. 万方数据库搜索
    4. CNKI搜索

    Figures(11)  / Tables(3)

    Article Metrics

    Article views (565) PDF downloads(35) Cited by()
    Proportional views
    Related

    /

    DownLoad:  Full-Size Img  PowerPoint
    Return
    Return