Advanced Search
Turn off MathJax
Article Contents
ZHU Hongbo, ZHANG Yunkai. Distributed Resilient Invariant Extended Kalman Fusion Filter Method for Target Tracking[J]. Journal of Electronics & Information Technology. doi: 10.11999/JEIT260273
Citation: ZHU Hongbo, ZHANG Yunkai. Distributed Resilient Invariant Extended Kalman Fusion Filter Method for Target Tracking[J]. Journal of Electronics & Information Technology. doi: 10.11999/JEIT260273

Distributed Resilient Invariant Extended Kalman Fusion Filter Method for Target Tracking

doi: 10.11999/JEIT260273 cstr: 32379.14.JEIT260273
Funds:  The National Nature Science Foundation of China (62003001), Anhui Provincial Natural Science Foundation (2508085MF169), The Natural Science Research Project of Anhui Educational Committee (2023AH040157), Anhui University of Science and Technology Graduate Innovation Fundation (2023cx2093)
  • Received Date: 2026-03-16
  • Accepted Date: 2026-10-10
  • Rev Recd Date: 2026-10-10
  • Available Online: 2026-10-17
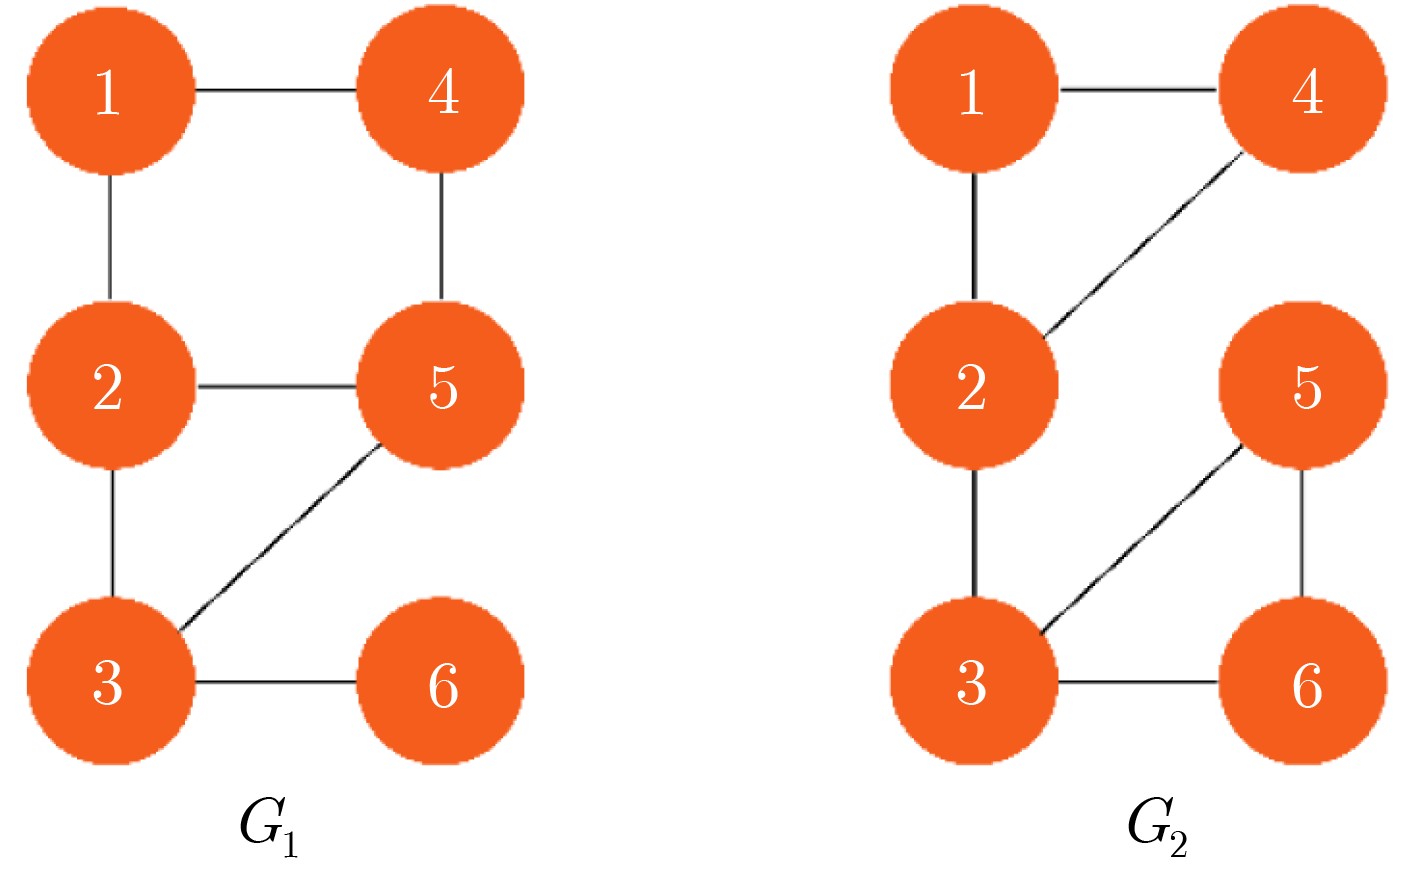
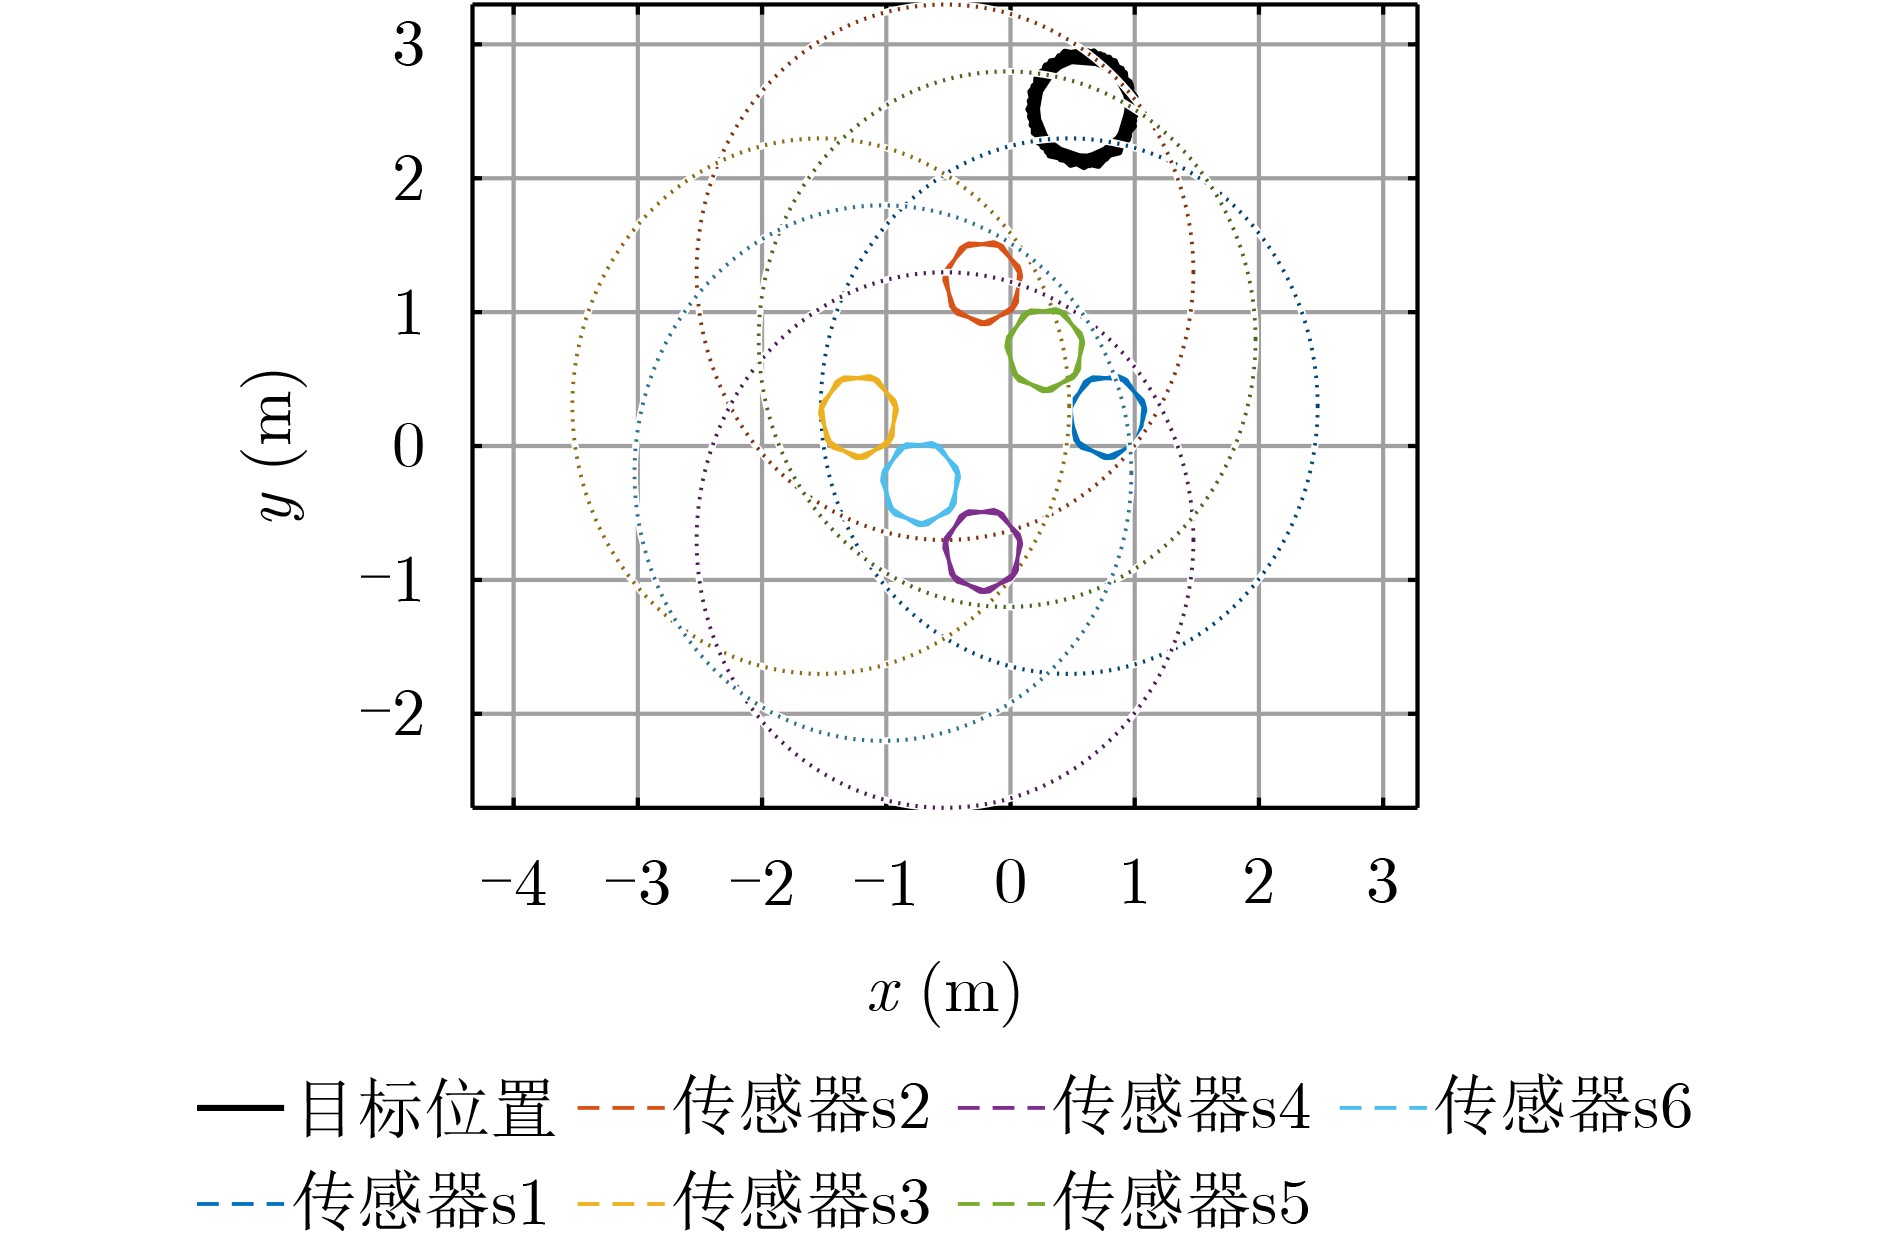
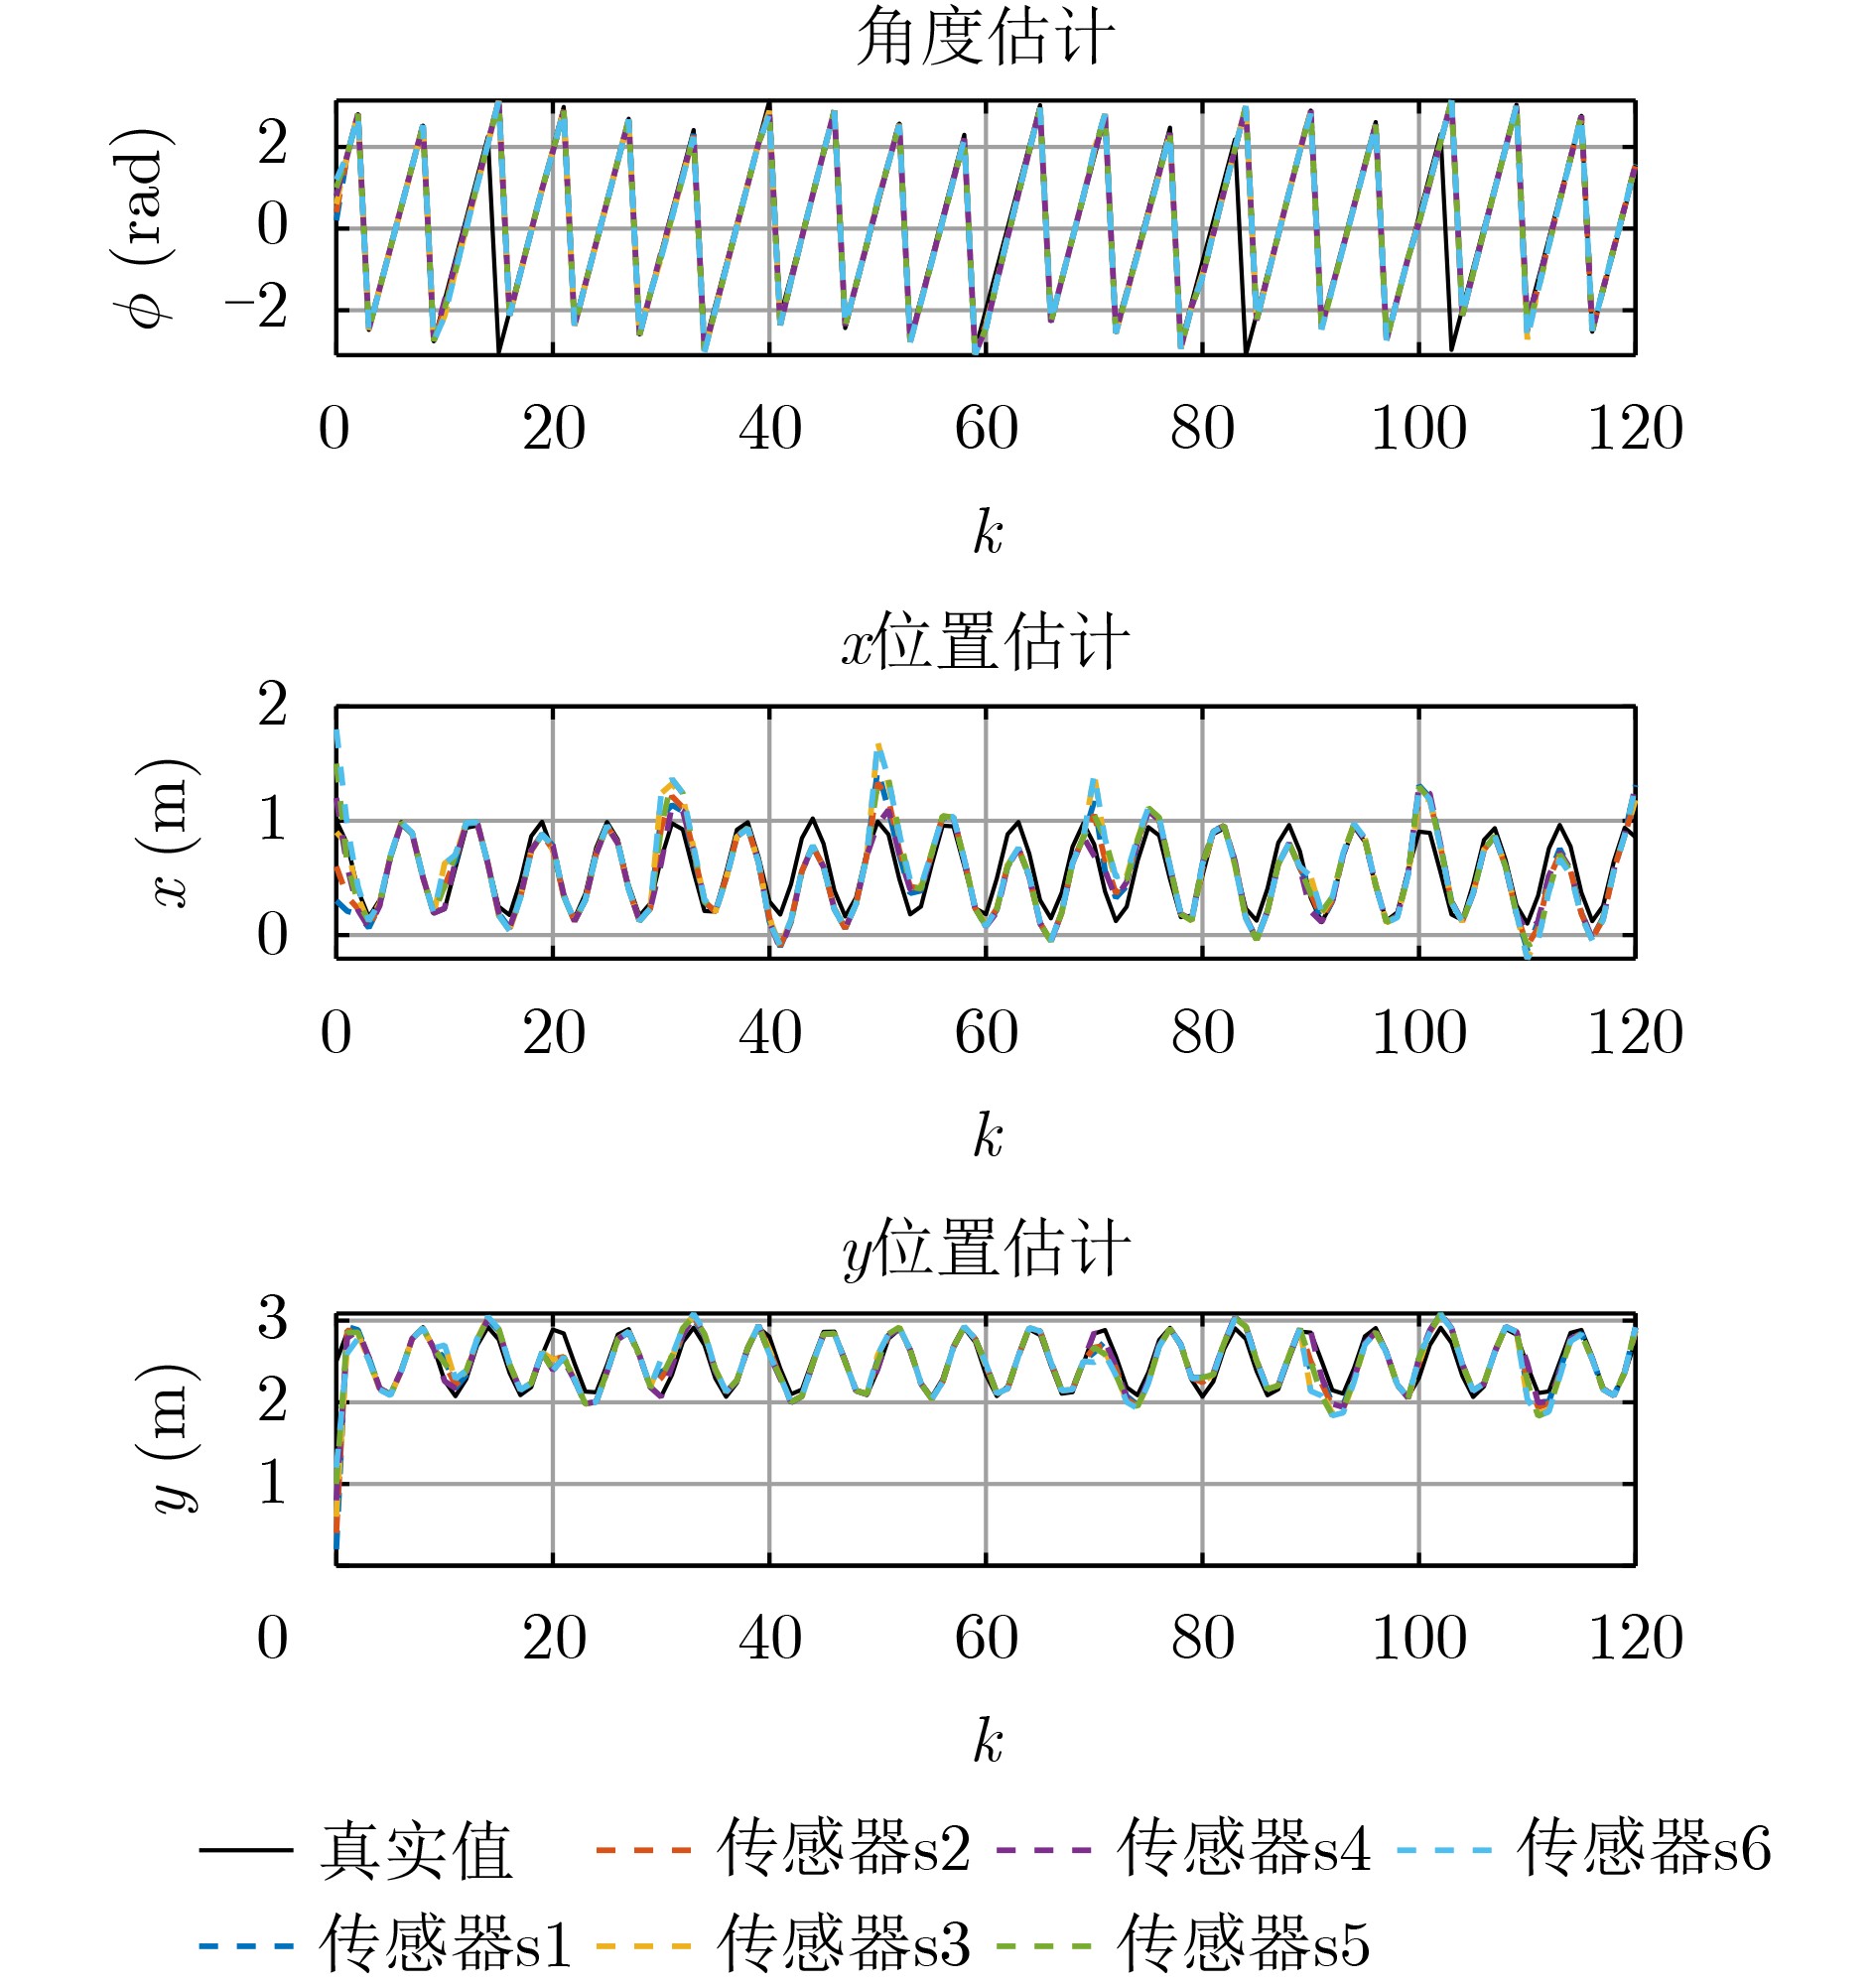
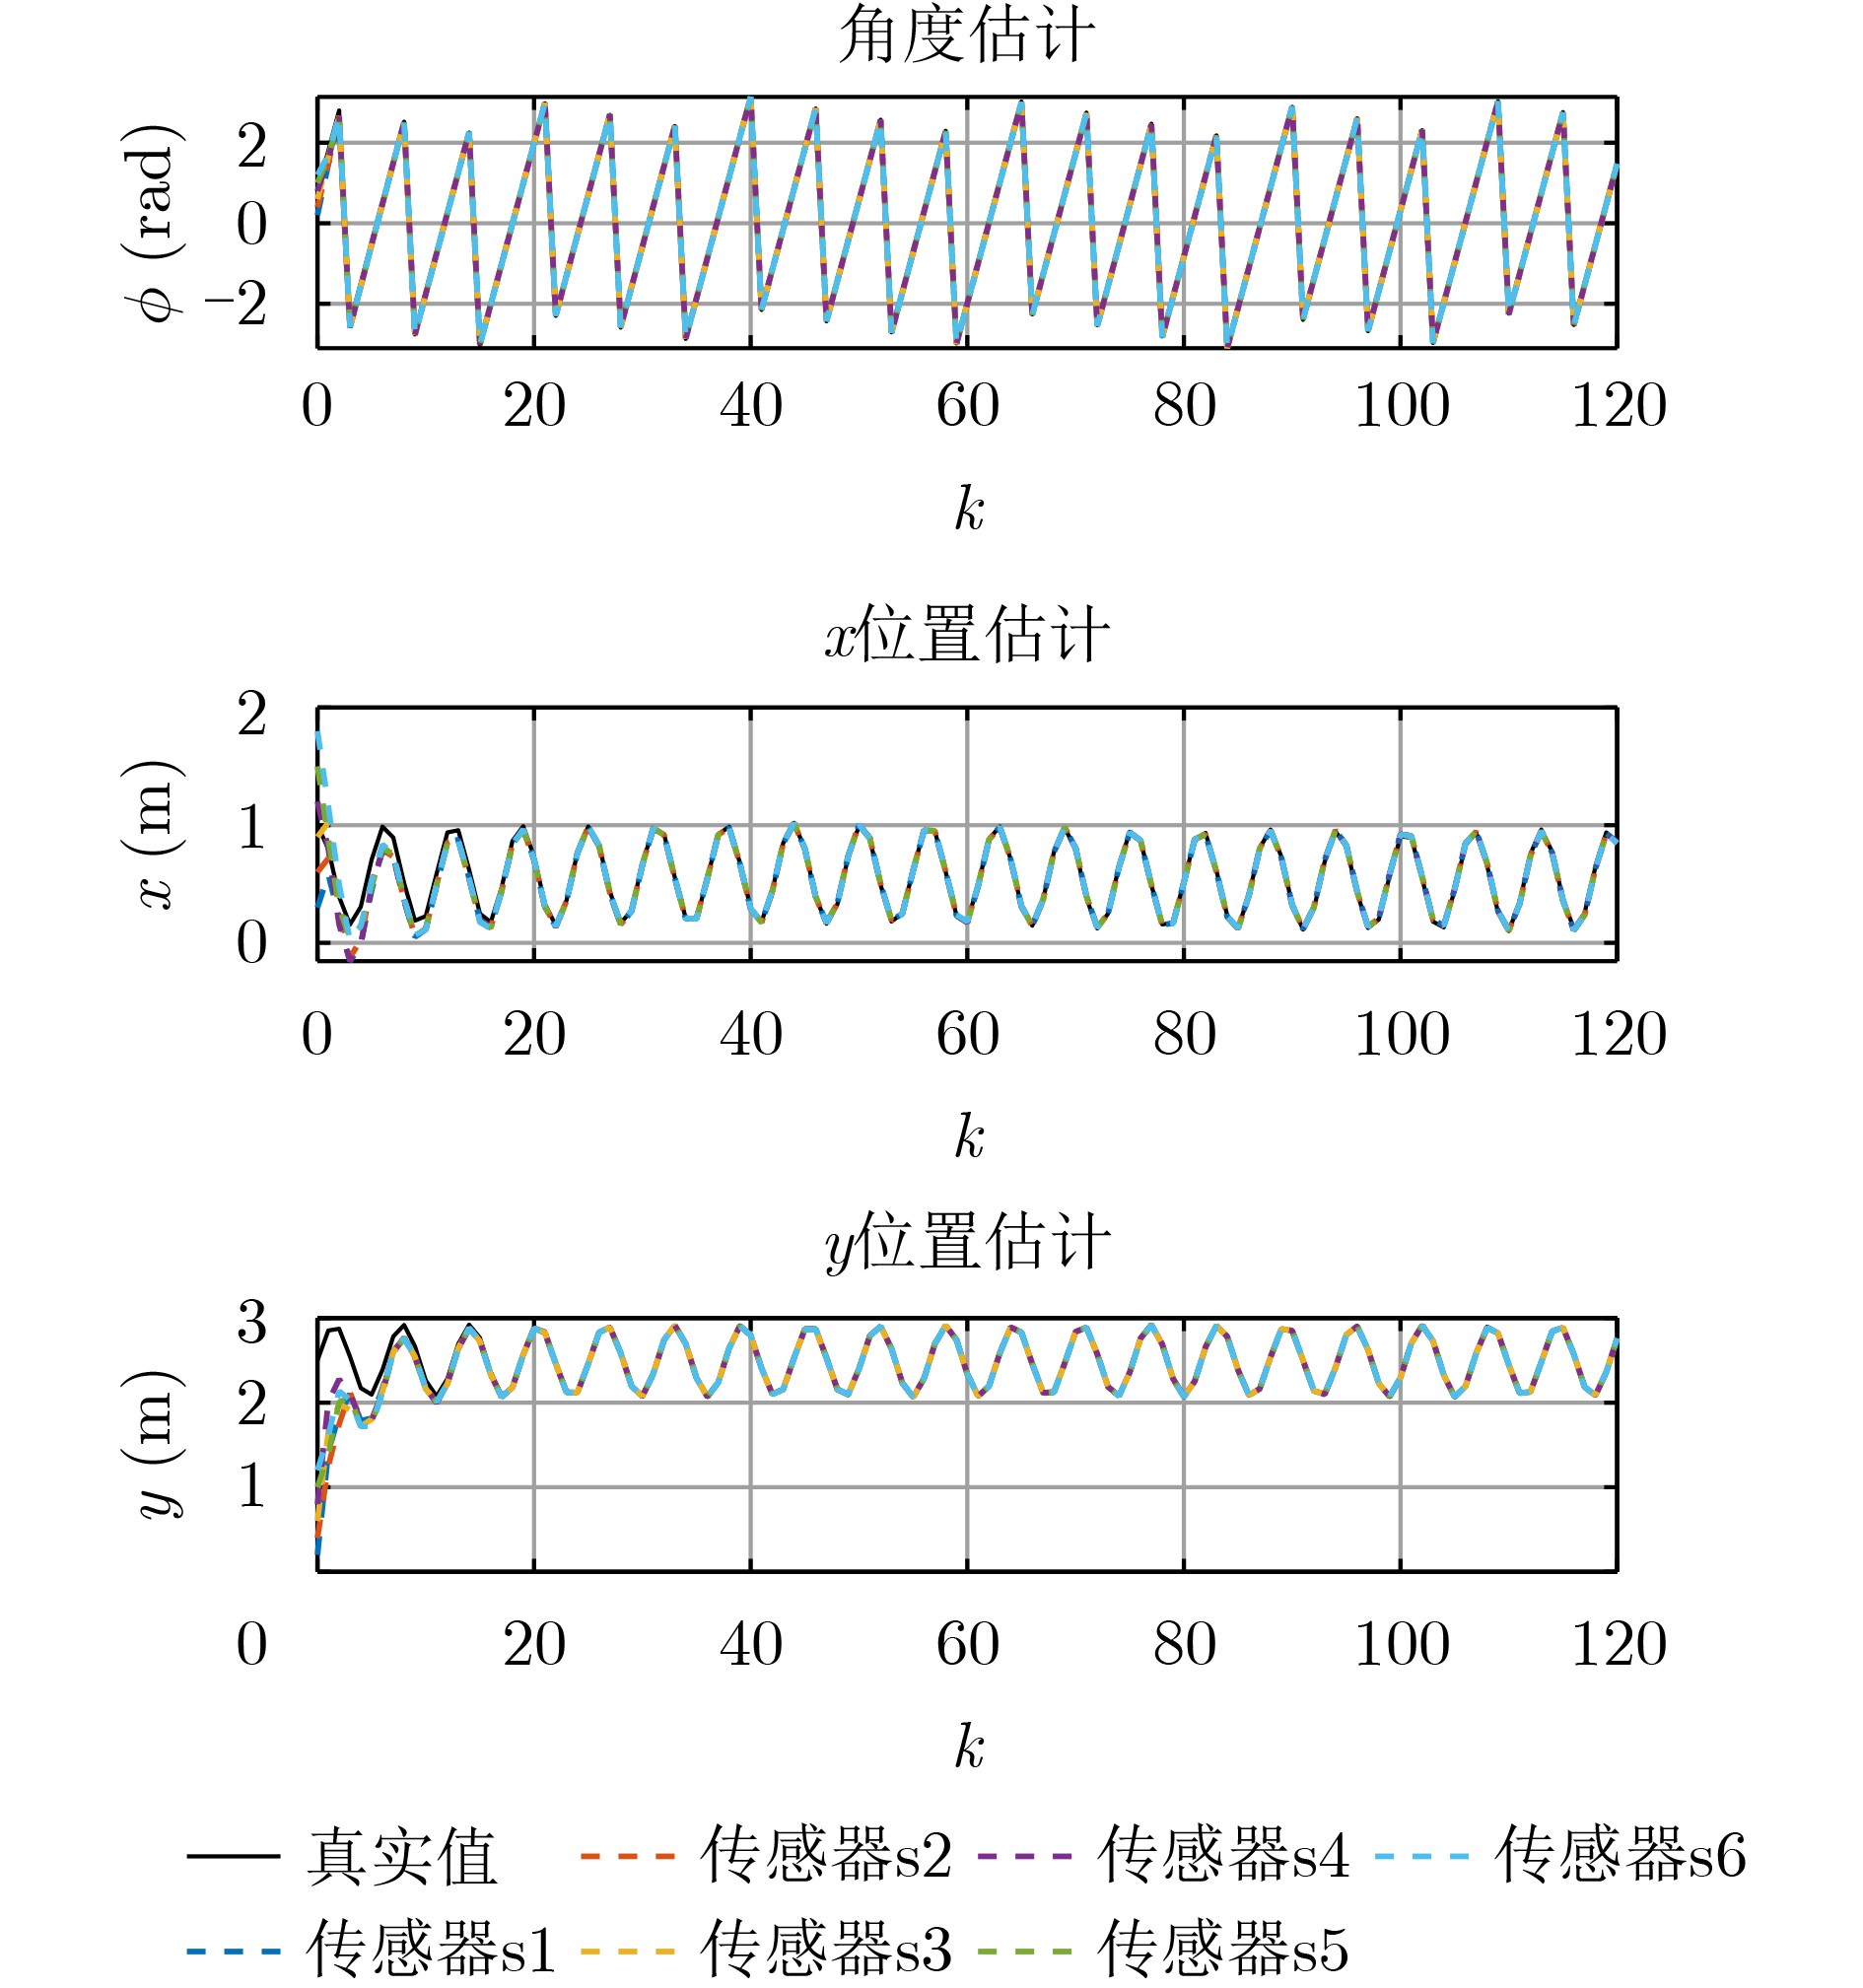
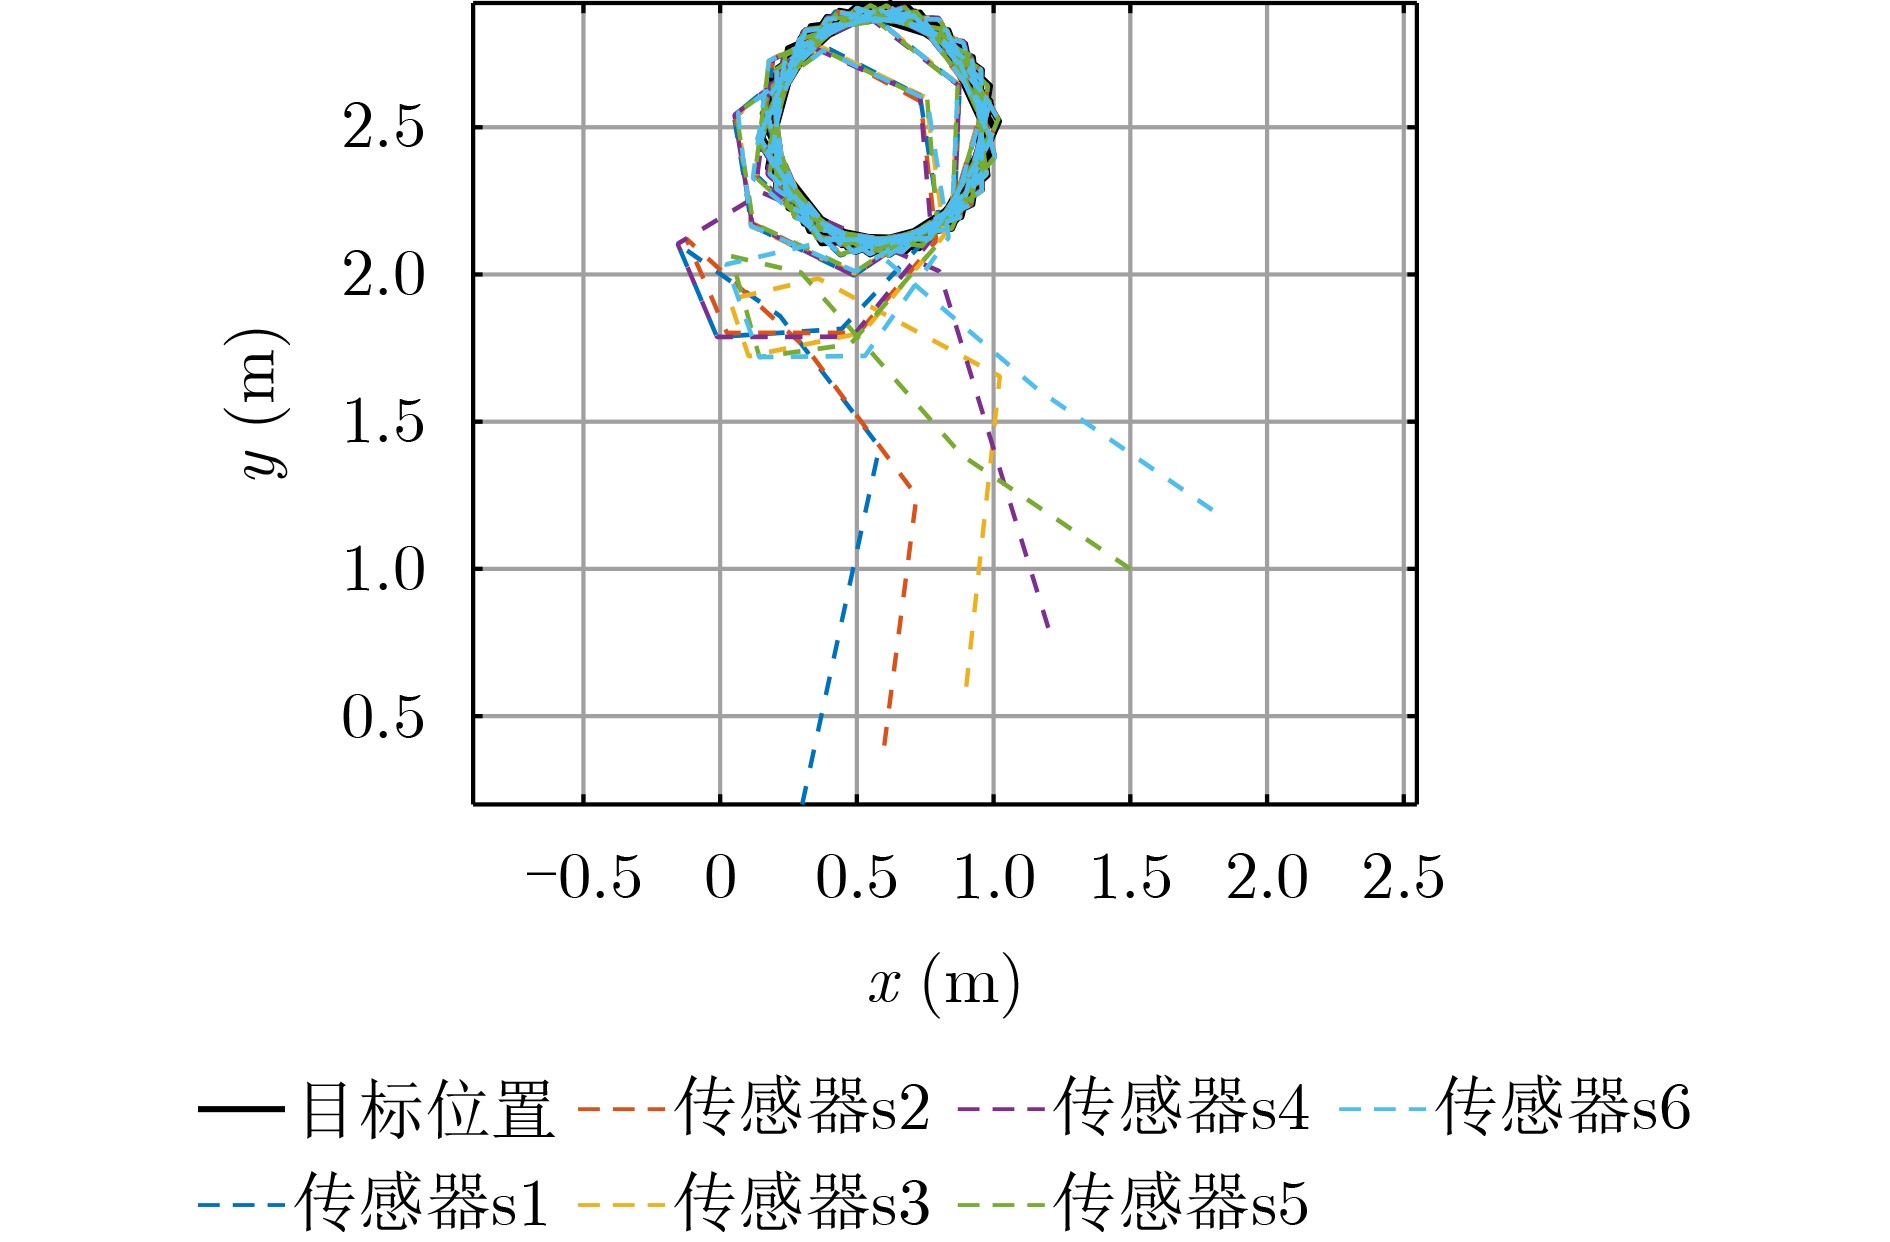
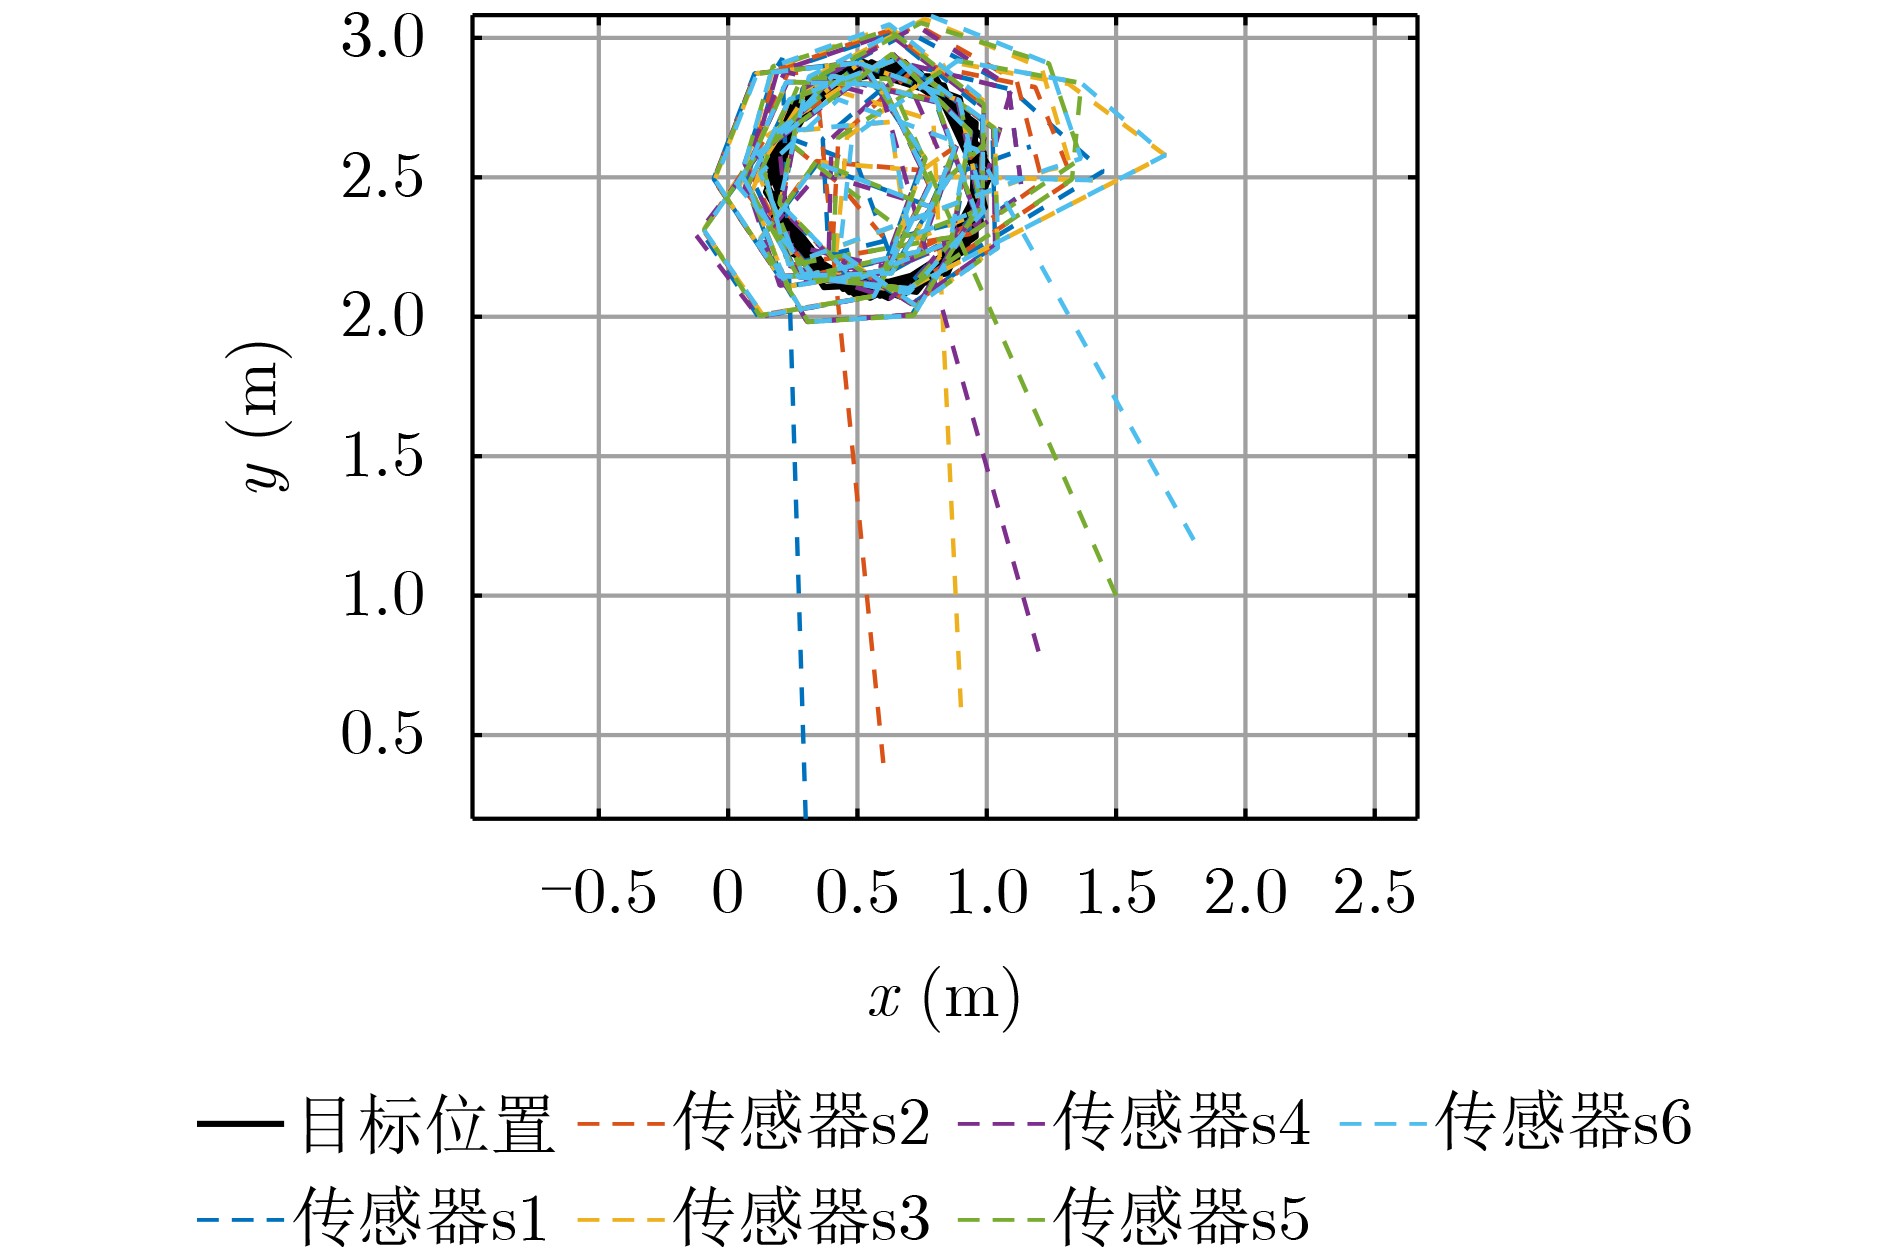
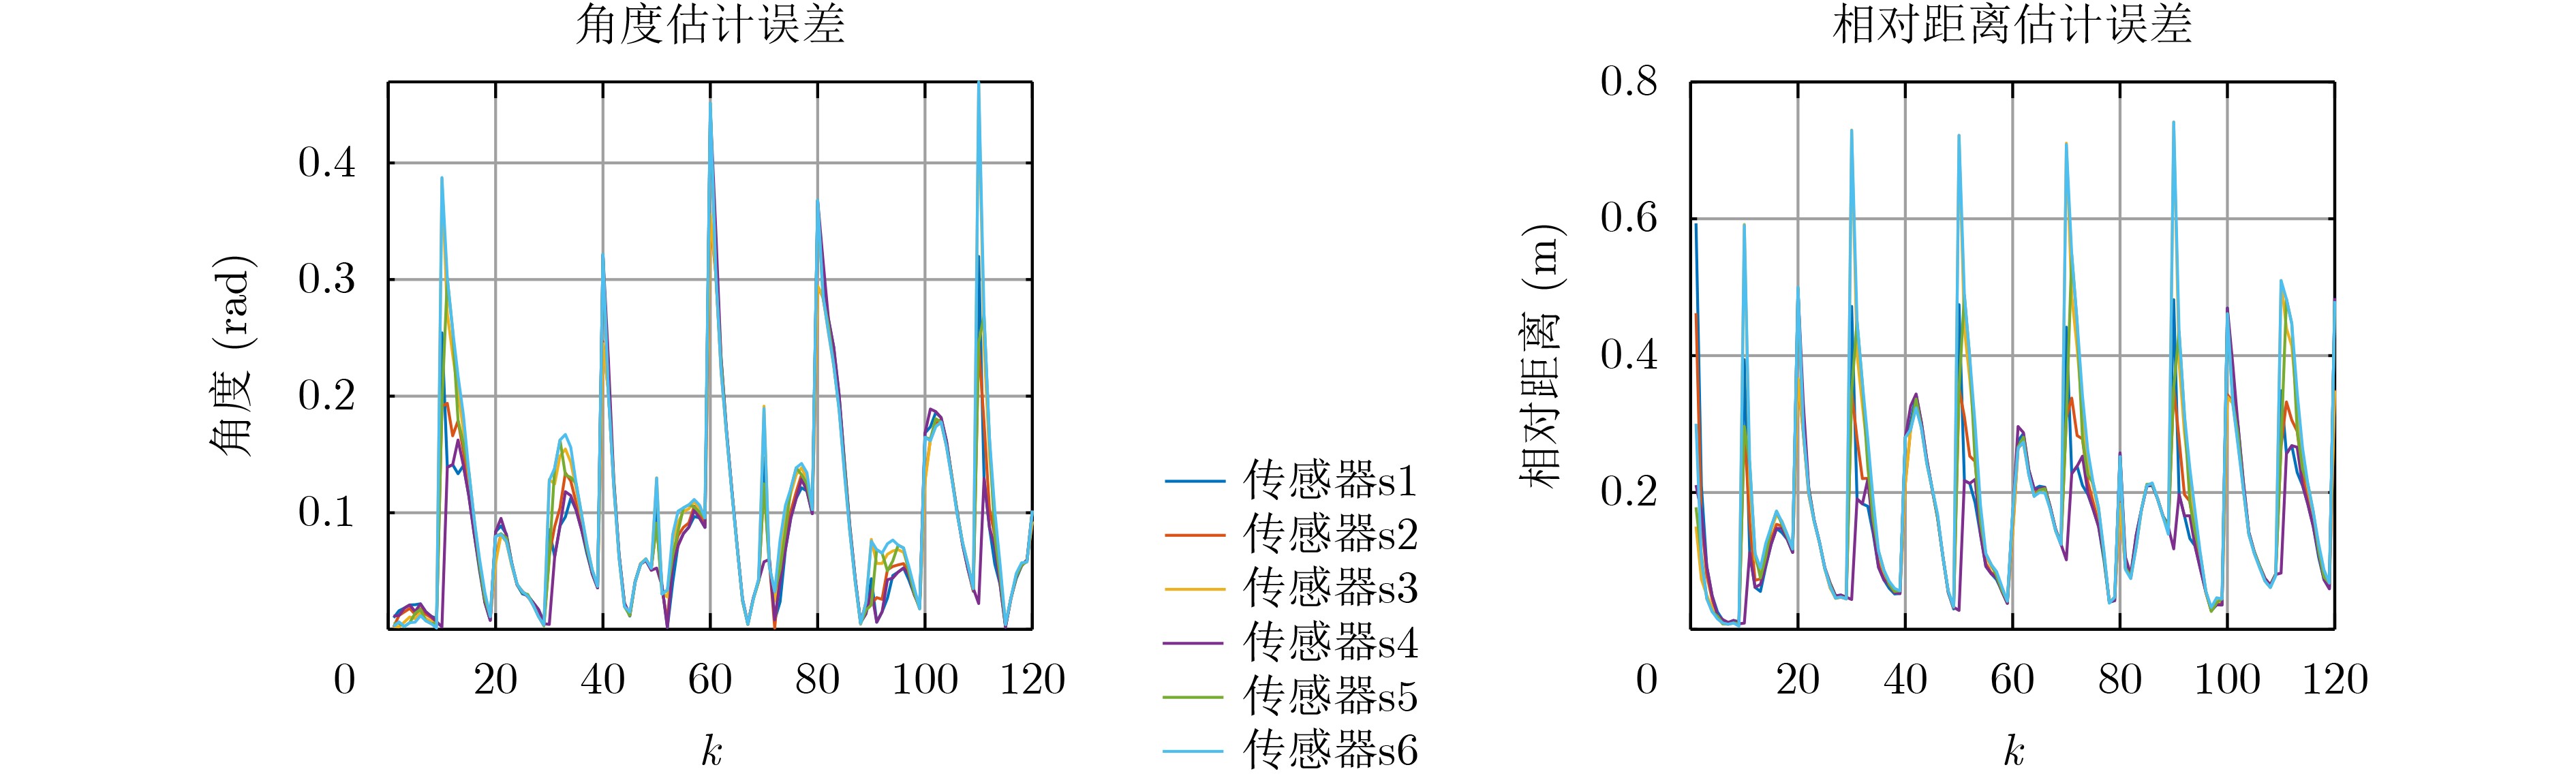
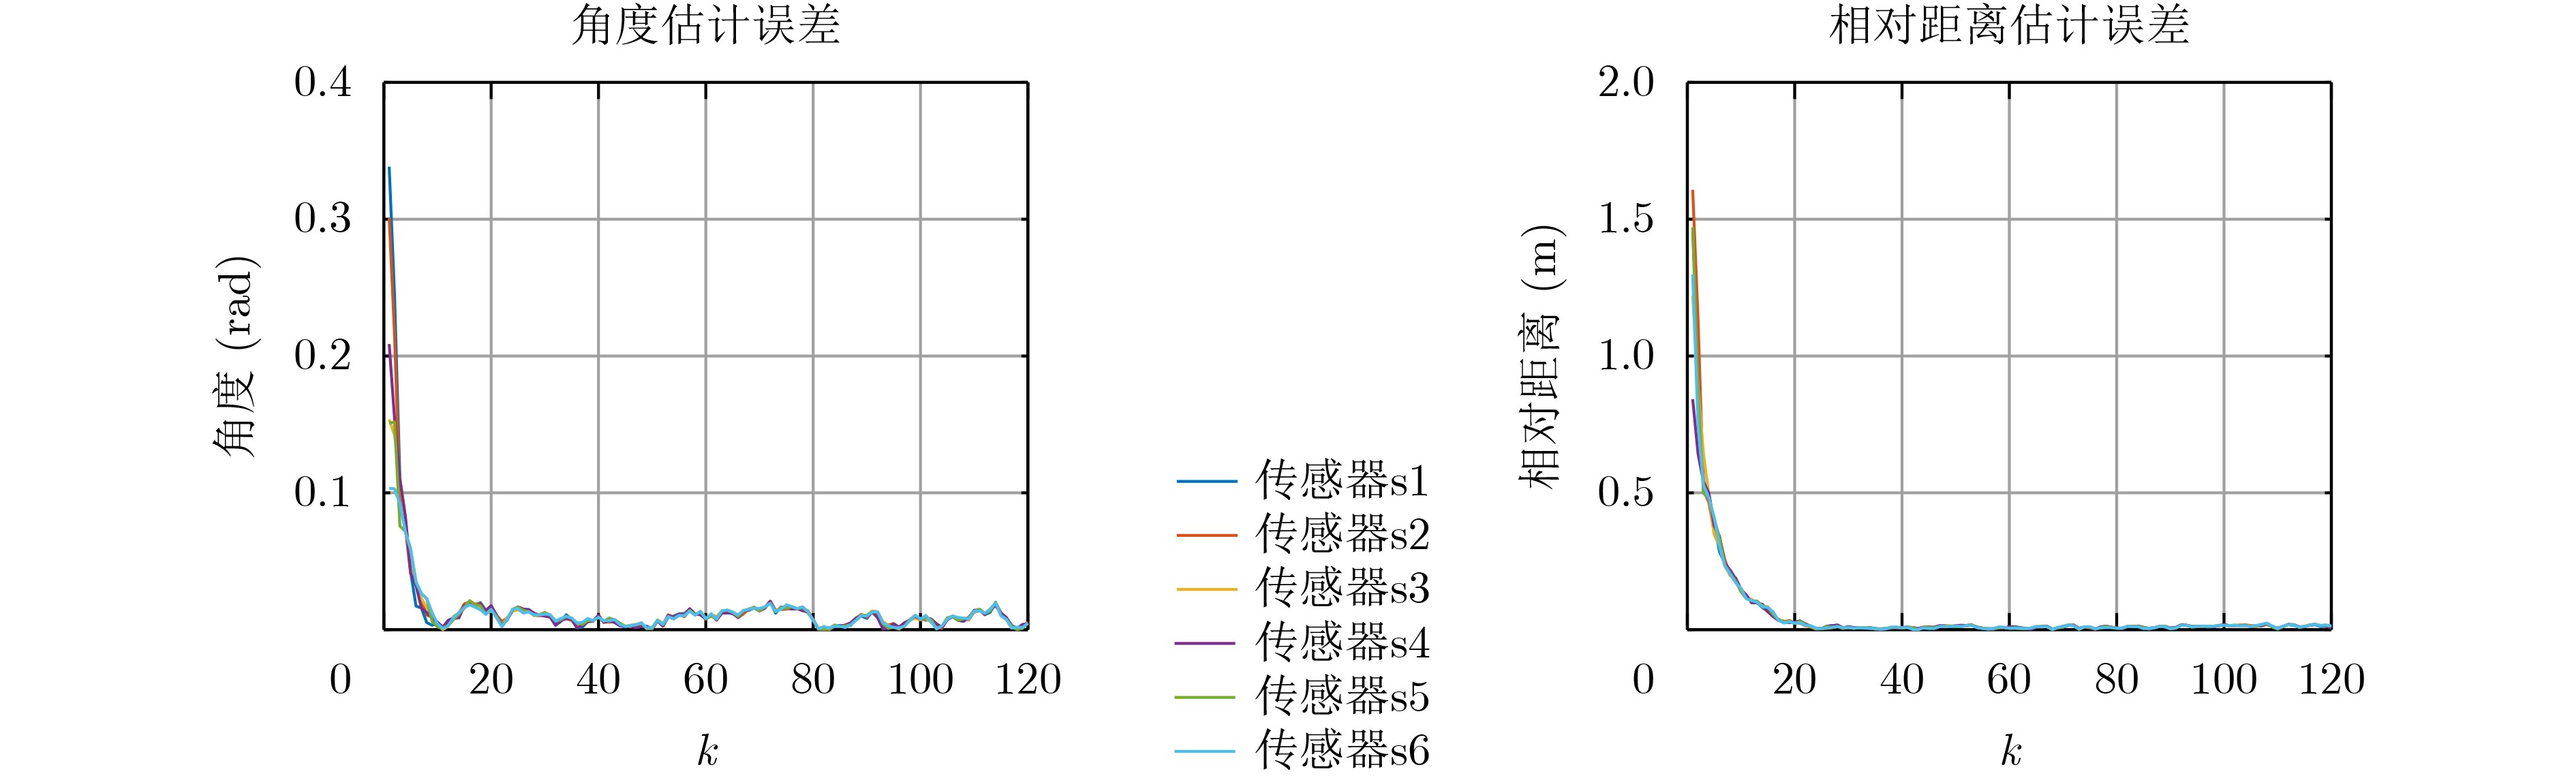
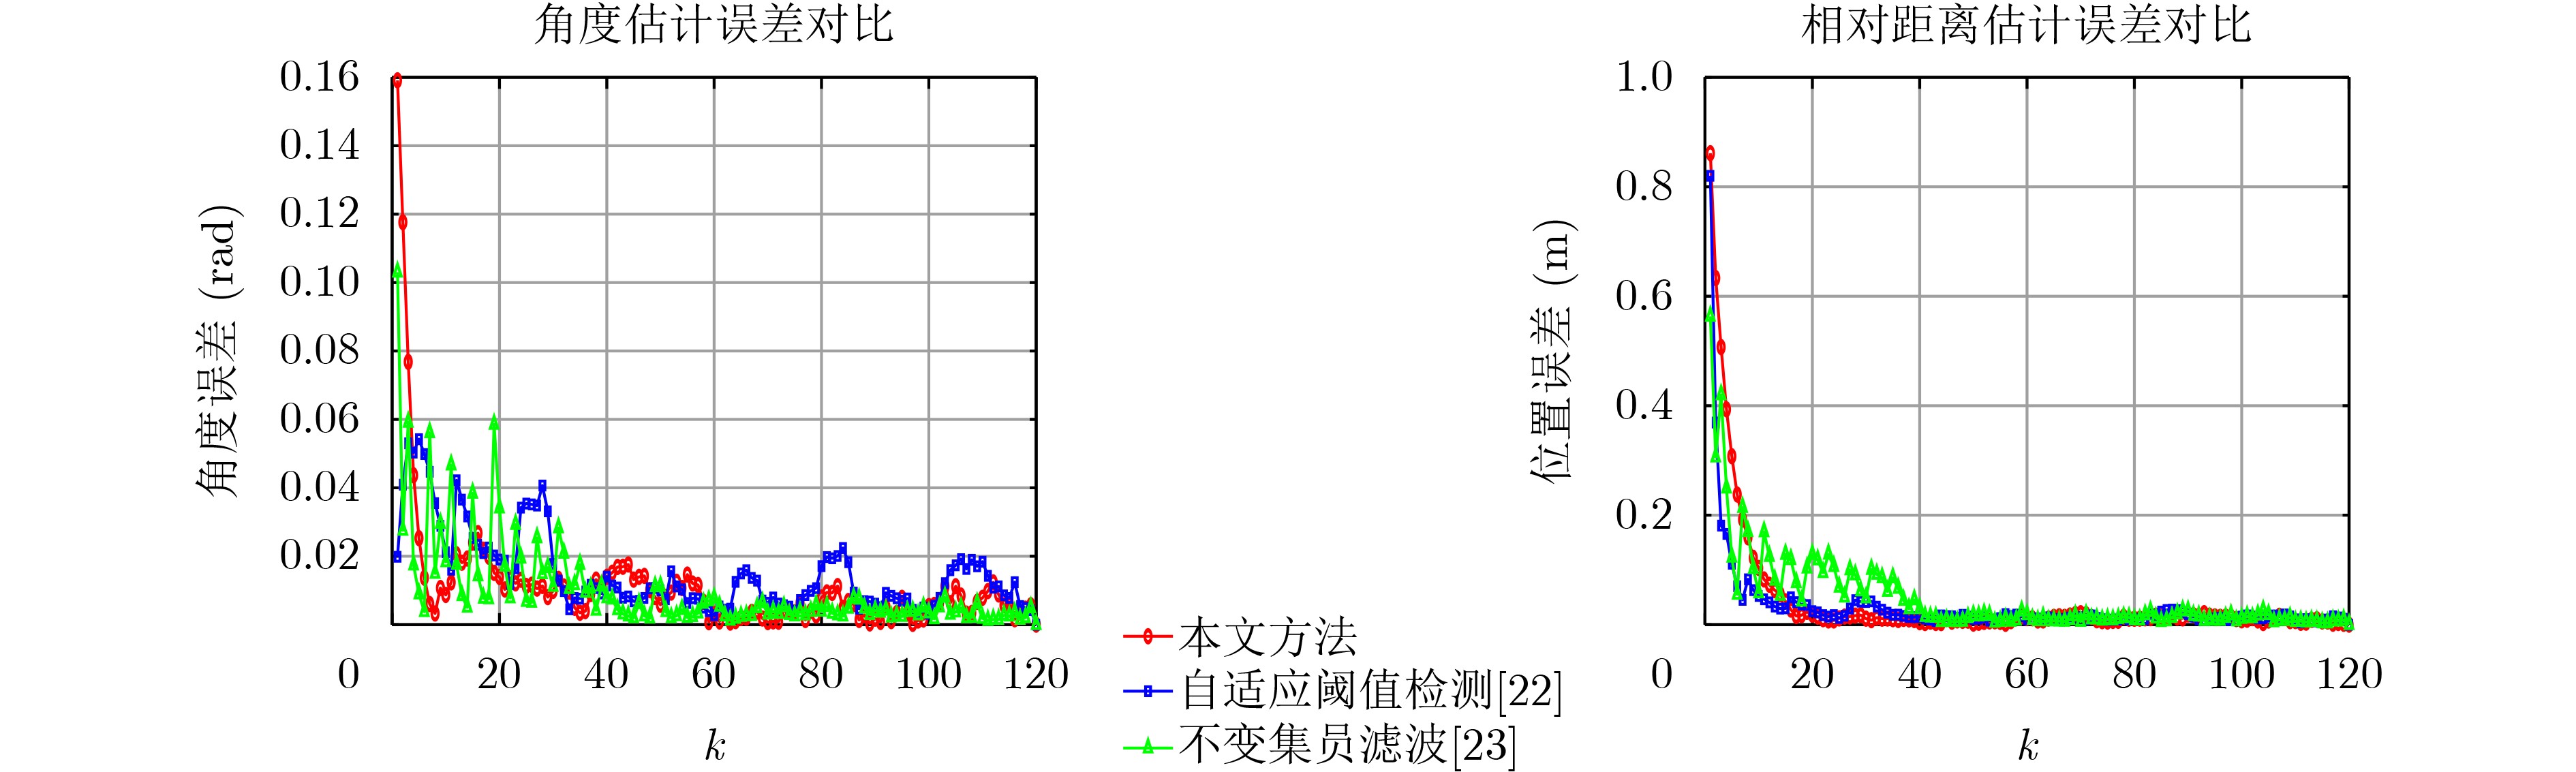
  •   Objective  Mobile Sensor Networks (MSNs) provide flexible deployment, dynamic sensing coverage, and cooperative observation capabilities for target tracking. However, nonlinear target motion, time-varying wireless communication topologies, intermittent measurements, and malicious attacks jointly complicate target tracking in MSNs. In open wireless communication environments, false data injection, denial-of-service, and replay attacks may corrupt measurement information and cause abnormal state estimates to propagate among neighboring nodes, thereby degrading estimation accuracy and potentially compromising filter consistency and stability. In addition, the target state considered in this study comprises orientation and position variables, whose evolution has an intrinsic non-Euclidean geometric structure. Conventional Extended Kalman Filter (EKF) methods generally linearize the system directly in Euclidean coordinates, which can introduce approximation errors and violate the orthogonality of the rotation matrix. Existing resilient distributed estimation methods also commonly rely on static sensor networks or restrictive linear-motion assumptions, limiting their applicability to nonlinear target tracking under dynamically switching network topologies. Therefore, reliable target tracking in MSNs requires a distributed state estimation method that accounts for geometric consistency, attack resilience, and dynamic network connectivity.  Methods  A distributed resilient invariant extended Kalman fusion filtering method is developed for nonlinear target tracking under network attacks. First, a Lie group-Lie algebra mapping is introduced into the EKF framework to construct an Invariant Extended Kalman Filter (IEKF). The target pose is represented on the two-dimensional Special Euclidean group (SE(2)), and the estimation error is defined through group multiplication. The error is then mapped to the corresponding Lie algebra, where linearization is performed. This geometric error representation preserves the structural properties of the rotation matrix during state propagation and avoids the loss of orthogonality caused by direct Taylor-expansion linearization. Prediction and measurement updates are formulated using the invariant error representation to obtain prior and posterior state estimates and their covariance matrices. Second, a dimensionality-reduced k-means attack detection mechanism is designed to assess local node credibility. For each neighboring node, the deviation between its posterior estimate and the local node’s fused prior estimate is reduced from a high-dimensional state difference to a scalar dissimilarity measure. These scalar dissimilarity measures are then clustered into two groups using k-means, and the cluster with the smaller centroid value is classified as the normal-node group. This mechanism identifies compromised or untrusted nodes without prior knowledge of the attack model and reduces the computational cost of clustering high-dimensional state deviations. The posterior estimates of identified compromised nodes are excluded from the trusted information set. Third, a covariance-intersection-based consensus fusion strategy is developed for time-varying network topologies. At each time step, a sensor node combines its own posterior estimate with the posterior estimates of trusted neighbors identified by k-means and the prior estimates of untrusted neighbors. The fusion weights are determined by the current network topology and node connectivity. Therefore, each node requires only local neighborhood information, and no global network information is needed. The resulting four-stage procedure consists of prediction, measurement update, attack detection, and consensus fusion.  Results and Discussions  MATLAB simulations are conducted to evaluate the estimation accuracy, stability, computational efficiency, and attack resilience of the proposed method. A mobile sensor network with six sensors is used to track a nonlinear moving target. The communication topology switches every two time steps, as shown in Fig. 1, and the target and sensor trajectories are presented in Fig. 2. Each sensor obtains a valid measurement only when the target is within its sensing range. The method is first evaluated in two cases: without attack detection and with the proposed attack detection mechanism. The corresponding state estimates are shown in Figs. 3 and 4. Without attack detection, malicious measurements cause the state estimates of several sensors to deviate markedly from the true target state. With the proposed detection mechanism enabled, corrupted measurements are screened out, and the state estimates from all six sensors gradually converge to the true target state, indicating improved estimation stability and tracking accuracy. A grouped false data injection attack is then simulated. Every 10 time steps, sensors 1 and 5 are attacked simultaneously, as are sensors 2 and 6, while the remaining sensors operate normally. Figs. 5 and 6 show the tracking trajectories without and with attack detection, respectively. The results indicate that the proposed detection mechanism identifies compromised nodes and prevents their abnormal measurements from dominating the distributed fusion process. Figs. 7 and 8 show the corresponding angular and relative-position estimation errors. Without attack detection, the estimation errors fluctuate significantly when attacks occur. When attack detection is combined with resilient fusion, the errors remain bounded and become more stable, indicating that the proposed method suppresses the propagation of malicious information under dynamic topology switching. For a quantitative comparison, the Root Mean Squared Error (RMSE) values for the angular and position estimates are compared among the proposed method, an adaptive-threshold detection method, and an invariant set-membership filtering method. All three methods are evaluated under the same target motion, network topology, noise, and attack conditions. As shown in Fig. 9, the proposed method maintains lower estimation errors and converges faster than both comparison methods. This improvement is attributable to two complementary components: the Lie group-Lie algebra-based IEKF, which preserves the geometric structure of the state representation, and the combined attack detection and covariance-intersection-based consensus fusion strategy, which limits the influence of abnormal information. Computational efficiency is also evaluated by running each method independently 100 times under identical conditions. As reported in Table 1, the average running time of the proposed method is 0.0340 s, compared with 0.0809 s for the adaptive-threshold detection method, 0.0816 s for the invariant set-membership filtering method, and 0.0357 s for the high-dimensional k-means method. The corresponding computation-time reductions are approximately 57.9%, 58.3%, and 4.7%, respectively. These results show that reducing high-dimensional state deviations to scalar dissimilarity measures lowers the computational cost of attack detection while preserving information about deviations caused by malicious measurements.  Conclusions  A distributed resilient invariant extended Kalman fusion filtering method is proposed for target tracking in MSNs subject to nonlinear target motion, time-varying communication topologies, and malicious measurement attacks. The Lie group-Lie algebra representation aligns the error definition and linearization with the system’s geometric structure, helping preserve consistency in nonlinear state estimation. The dimensionality-reduced k-means mechanism converts high-dimensional estimation deviations into scalar dissimilarity measures, enabling attack identification without a predefined attack model while reducing the computational burden. The covariance-intersection-based consensus fusion strategy combines each node’s own posterior estimate and trusted neighbors’ posterior estimates with untrusted neighbors’ prior estimates according to the current local topology, thereby limiting the influence of compromised nodes while preserving distributed operation. Simulation results show that the proposed method achieves lower estimation errors, more stable tracking performance, and lower computational cost than the comparison methods under the tested attack and dynamic-topology conditions. The proposed framework therefore provides an effective distributed solution for resilient target state estimation in attack-prone MSNs.
  • loading
  • [1]
    YOKOYAMA T, NARIEDA S, and NARUSE H. Optimization of sensor node placement for CO2 concentration monitoring based on wireless sensor networks in an indoor environment[J]. IEEE Sensors Letters, 2024, 8(4): 7001904. doi: 10.1109/LSENS.2024.3373369.
    [2]
    王恩良, 章祯, 孙知信. 复杂约束下应急救援无人机路径的熵增强量子涟漪协同算法[J]. 电子与信息学报, 2026, 48(4): 1708–1718. doi: 10.11999/JEIT250694.

    WANG Enliang, ZHANG Zhen, and SUN Zhixin. Entropy-enhanced quantum ripple synergy planning method for emergency path of unmanned aerial vehicles driven by survival probability[J]. Journal of Electronics & Information Technology, 2026, 48(4): 1708–1718. doi: 10.11999/JEIT250694.
    [3]
    陈喜群, 朱奕璋, 谢宁珂, 等. 基于异构多智能体自注意力网络的路网信号协调顺序优化方法[J]. 交通运输系统工程与信息, 2024, 24(3): 114–126. doi: 10.16097/j.cnki.1009-6744.2024.03.012.

    CHEN Xiqun, ZHU Yizhang, XIE Ningke, et al. Coordinated sequential optimization for network-wide traffic signal control based on heterogeneous multi-agent transformer[J]. Journal of Transportation Systems Engineering and Information Technology, 2024, 24(3): 114–126. doi: 10.16097/j.cnki.1009-6744.2024.03.012.
    [4]
    王文博, 苏琳惠, 程振乾, 等. 无线传感器技术在战场环境的应用及发展趋势[J]. 环境技术, 2025, 43(6): 86–89. doi: 10.3969/j.issn.1004-7204.2025.06.015.

    WANG Wenbo, SU Linhui, CHENG Zhenqian, et al. The application and development trends of wireless sensor technology in the battlefield environment[J]. Environmental Technology, 2025, 43(6): 86–89. doi: 10.3969/j.issn.1004-7204.2025.06.015.
    [5]
    韩乔妮, 马建国, 李鹏, 等. 混合网络攻击下车辆队列的无模型自适应弹性控制[J]. 电子与信息学报, 2026, 48(5): 2066–2076. doi: 10.11999/JEIT251135.

    HAN Qiaoni, MA Jianguo, LI Peng, et al. Model-free adaptive resilient control of vehicle platoons against hybrid cyberattacks[J]. Journal of Electronics & Information Technology, 2026, 48(5): 2066–2076. doi: 10.11999/JEIT251135.
    [6]
    孙同晶, 朱庆煜, 王治撰. 基于主动波导不变量分布的改进扩展卡尔曼滤波跟踪方法[J]. 电子与信息学报, 2025, 47(1): 167–177. doi: 10.11999/JEIT240595.

    SUN Tongjing, ZHU Qingyu, and WANG Zhizhuan. Improved extended Kalman filter tracking method based on active waveguide invariant distribution[J]. Journal of Electronics & Information Technology, 2025, 47(1): 167–177. doi: 10.11999/JEIT240595.
    [7]
    PENG Hua, WANG Yongxin, CHEN Zhiyong, et al. Dynamic sensor speed measurement algorithm and influencing factors of traffic safety with wireless sensor network nodes and RFID[J]. IEEE Sensors Journal, 2021, 21(14): 15679–15686. doi: 10.1109/JSEN.2020.3020643.
    [8]
    CHEN Wei, WANG Zidong, DING Derui, et al. Distributed state estimation over wireless sensor networks with energy harvesting sensors[J]. IEEE Transactions on Cybernetics, 2023, 53(5): 3311–3324. doi: 10.1109/TCYB.2022.3179280.
    [9]
    AGARWAL A and JAGANNATHAM A K. Distributed estimation in homogenous Poisson wireless sensor networks[J]. IEEE Wireless Communications Letters, 2014, 3(1): 90–93. doi: 10.1109/WCL.2013.112313.130696.
    [10]
    BASIT A, TUFAIL A, and REHAN M. Event-triggered distributed state estimation under unknown parameters and sensor saturations over wireless sensor networks[J]. IEEE Transactions on Circuits and Systems II: Express Briefs, 2022, 69(3): 1772–1776. doi: 10.1109/TCSII.2021.3109884.
    [11]
    LIANG Chaoyang, HE Defeng, and CHEN Yun. Improving distributed moving horizon estimation over wireless sensor networks with application to mobile robot localization[J]. IEEE Sensors Journal, 2025, 25(13): 26032–26041. doi: 10.1109/JSEN.2025.3573283.
    [12]
    YU Yingrong, REN Jie, DONG Xiwang, et al. Distributed state estimation for heterogeneous mobile sensor networks with varying nodes[C]. 2020 39th Chinese Control Conference (CCC), Shenyang, China, 2020: 3129–3134. doi: 10.23919/CCC50068.2020.9189451.
    [13]
    周雪, 张皓, 王祝萍. 扩展卡尔曼滤波在受到恶意攻击系统中的状态估计[J]. 自动化学报, 2020, 46(1): 38–46. doi: 10.16383/j.aas.c170609.

    ZHOU Xue, ZHANG Hao, and WANG Zhuping. Extended Kalman filtering in state estimation systems with malicious attacks[J]. Acta Automatica Sinica, 2020, 46(1): 38–46. doi: 10.16383/j.aas.c170609.
    [14]
    LA H M, SHENG Weihua, and CHEN Jiming. Cooperative and active sensing in mobile sensor networks for scalar field mapping[J]. IEEE Transactions on Systems, Man, and Cybernetics: Systems, 2015, 45(1): 1–12. doi: 10.1109/TSMC.2014.2318282.
    [15]
    YANG Feng, SHI Lihong, and ZHENG Litao. Event-triggered globally sequential fusion estimation for clustered wireless sensor networks with variational Bayesian[J]. IEEE Sensors Journal, 2021, 21(18): 20273–20282. doi: 10.1109/JSEN.2021.3092888.
    [16]
    GAO Ming, NIU Yichun, and SHENG Li. Distributed fault-tolerant state estimation for a class of nonlinear systems over sensor networks with sensor faults and random link failures[J]. IEEE Systems Journal, 2022, 16(4): 6328–6337. doi: 10.1109/JSYST.2022.3142183.
    [17]
    MUSTAFA A, MAZOUCHI M, and MODARES H. Secure event-triggered distributed Kalman filters for state estimation over wireless sensor networks[J]. IEEE Transactions on Systems, Man, and Cybernetics: Systems, 2023, 53(2): 1268–1283. doi: 10.1109/TSMC.2022.3195121.
    [18]
    MA Yinping, LI Yinya, WANG Ning, et al. Covariance intersection-based Kalman consensus filtering with sequential replay attack detection over sensor networks[J]. IEEE Sensors Journal, 2024, 24(15): 24880–24891. doi: 10.1109/JSEN.2024.3417511.
    [19]
    ZHU Hongbo, AMURI M J V, SHEN Jinzhong, et al. Mean-shift-based robust distributed set-membership fusion filtering for sensor network systems with outliers[J]. Automatica, 2025, 177: 112345. doi: 10.1016/j.automatica.2025.112345.
    [20]
    ZHU Hongbo, AMURI M J V, LI Xueyang, et al. Mean-shift-based outliers-robust distributed Kalman filter for wireless sensor network systems[J]. IEEE Transactions on Instrumentation and Measurement, 2025, 74: 9500312. doi: 10.1109/TIM.2024.3497172.
    [21]
    ZHU Hongbo, LUO Jingxian, LUO Minzhou, et al. A recursive robust set-membership estimator for WSN-assisted moving targets tracking with UBB anchor location uncertainty[J]. IEEE Transactions on Vehicular Technology, 2023, 72(5): 6547–6557. doi: 10.1109/TVT.2022.3231598.
    [22]
    ZHANG Cong, QIN Jiahu, YAN Chengzhen, et al. Towards invariant extended Kalman filter-based resilient distributed state estimation for moving robots over mobile sensor networks under deception attacks[J]. Automatica, 2024, 159: 111408. doi: 10.1016/j.automatica.2023.111408.
    [23]
    朱洪波, 朱旭. 双通道欺骗攻击下分布式弹性不变集员融合滤波的目标跟踪[J/OL]. 控制与决策, https://doi.org/10.13195/j.kzyjc.2026.0124, 2026.

    ZHU Hongbo and ZHU Xu. Distributed resilient invariant set-membership fusion filtering for target tracking under dual-channel deception attacks[J/OL]. Control and Decision, https://doi.org/10.13195/j.kzyjc.2026.0124, 2026. doi: 10.13195/j.kzyjc.2026.0124,2026.
  • 加载中

Catalog

    通讯作者: 陈斌, bchen63@163.com
    • 1. 

      沈阳化工大学材料科学与工程学院 沈阳 110142

    1. 本站搜索
    2. 百度学术搜索
    3. 万方数据库搜索
    4. CNKI搜索

    Figures(9)  / Tables(1)

    Article Metrics

    Article views (130) PDF downloads(36) Cited by()
    Proportional views
    Related

    /

    DownLoad:  Full-Size Img  PowerPoint
    Return
    Return