

Intelligent Secure Transmission for UAV-Assisted Mobile Edge Computing under Malicious Flight Jamming
-
摘要: 无人机辅助移动边缘计算凭借其高机动性,显著提升了网络覆盖能力与服务灵活性。然而,这种机动性也使其可能成为动态的恶意干扰源,对计算安全构成严重威胁。为了克服这一挑战,该文考虑恶意飞行干扰下无人机辅助边缘计算安全传输系统,提出一种基于双延迟深度确定性策略梯度的智能轨迹与资源协作安全传输方案。该方案通过联合优化无人机飞行轨迹、传输功率及计算任务分配,以最大化系统的安全计算容量。由于该问题涉及多类耦合变量,呈现高维非凸特性,难以直接解决。该文设计双延迟深度确定性策略梯度算法,借助智能体与环境的持续交互,实现对通信与计算资源的高效调度及无人机轨迹的自主规划。仿真结果表明,所提方案能够有效适应存在恶意干扰的动态环境,并在收敛性与系统稳定性方面优于基准方案,显著提升了系统的安全计算容量,从而为高动态环境下无人机辅助边缘计算面临的恶意飞行干扰问题提供了可行的解决途径。Abstract:
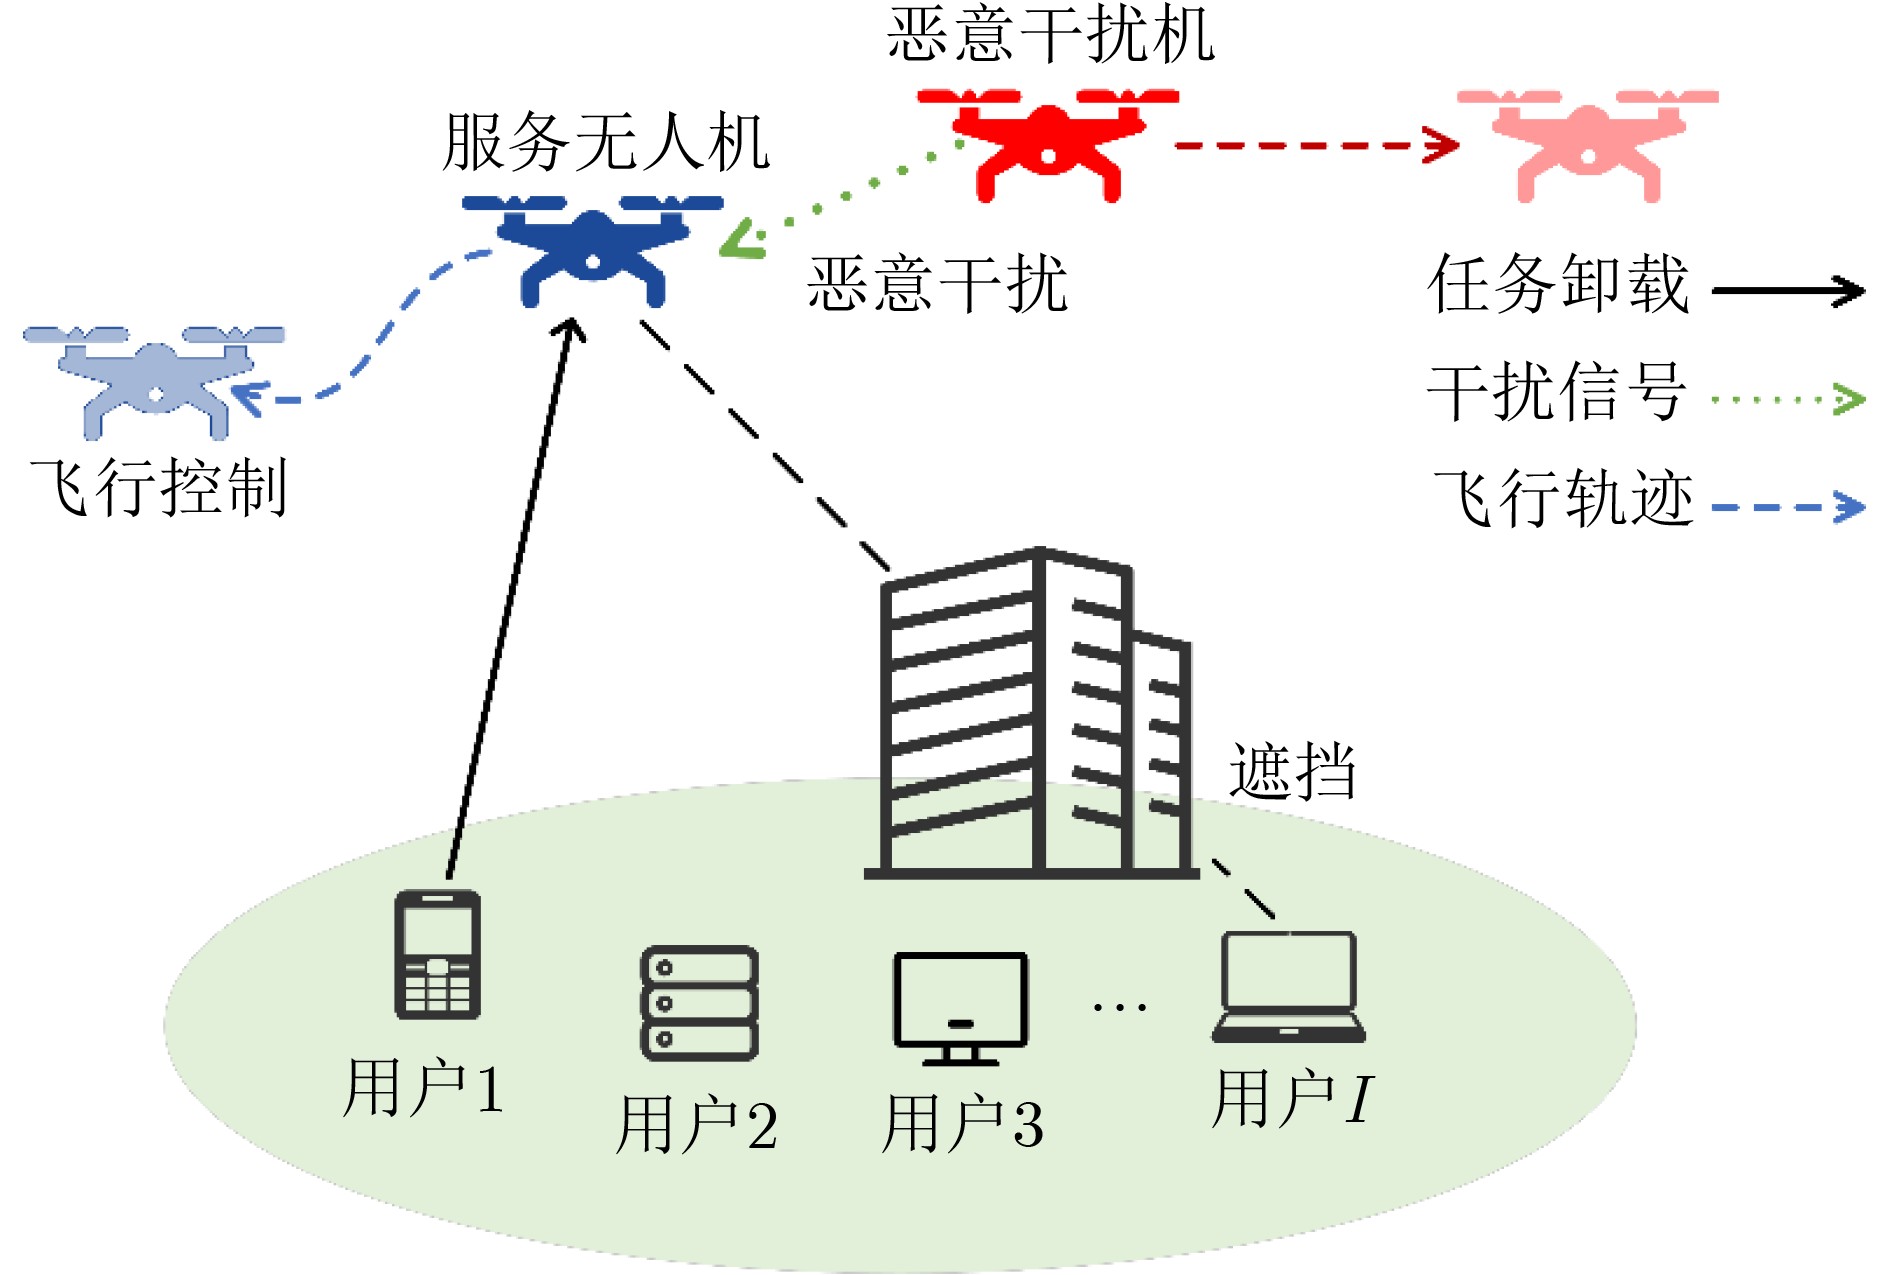
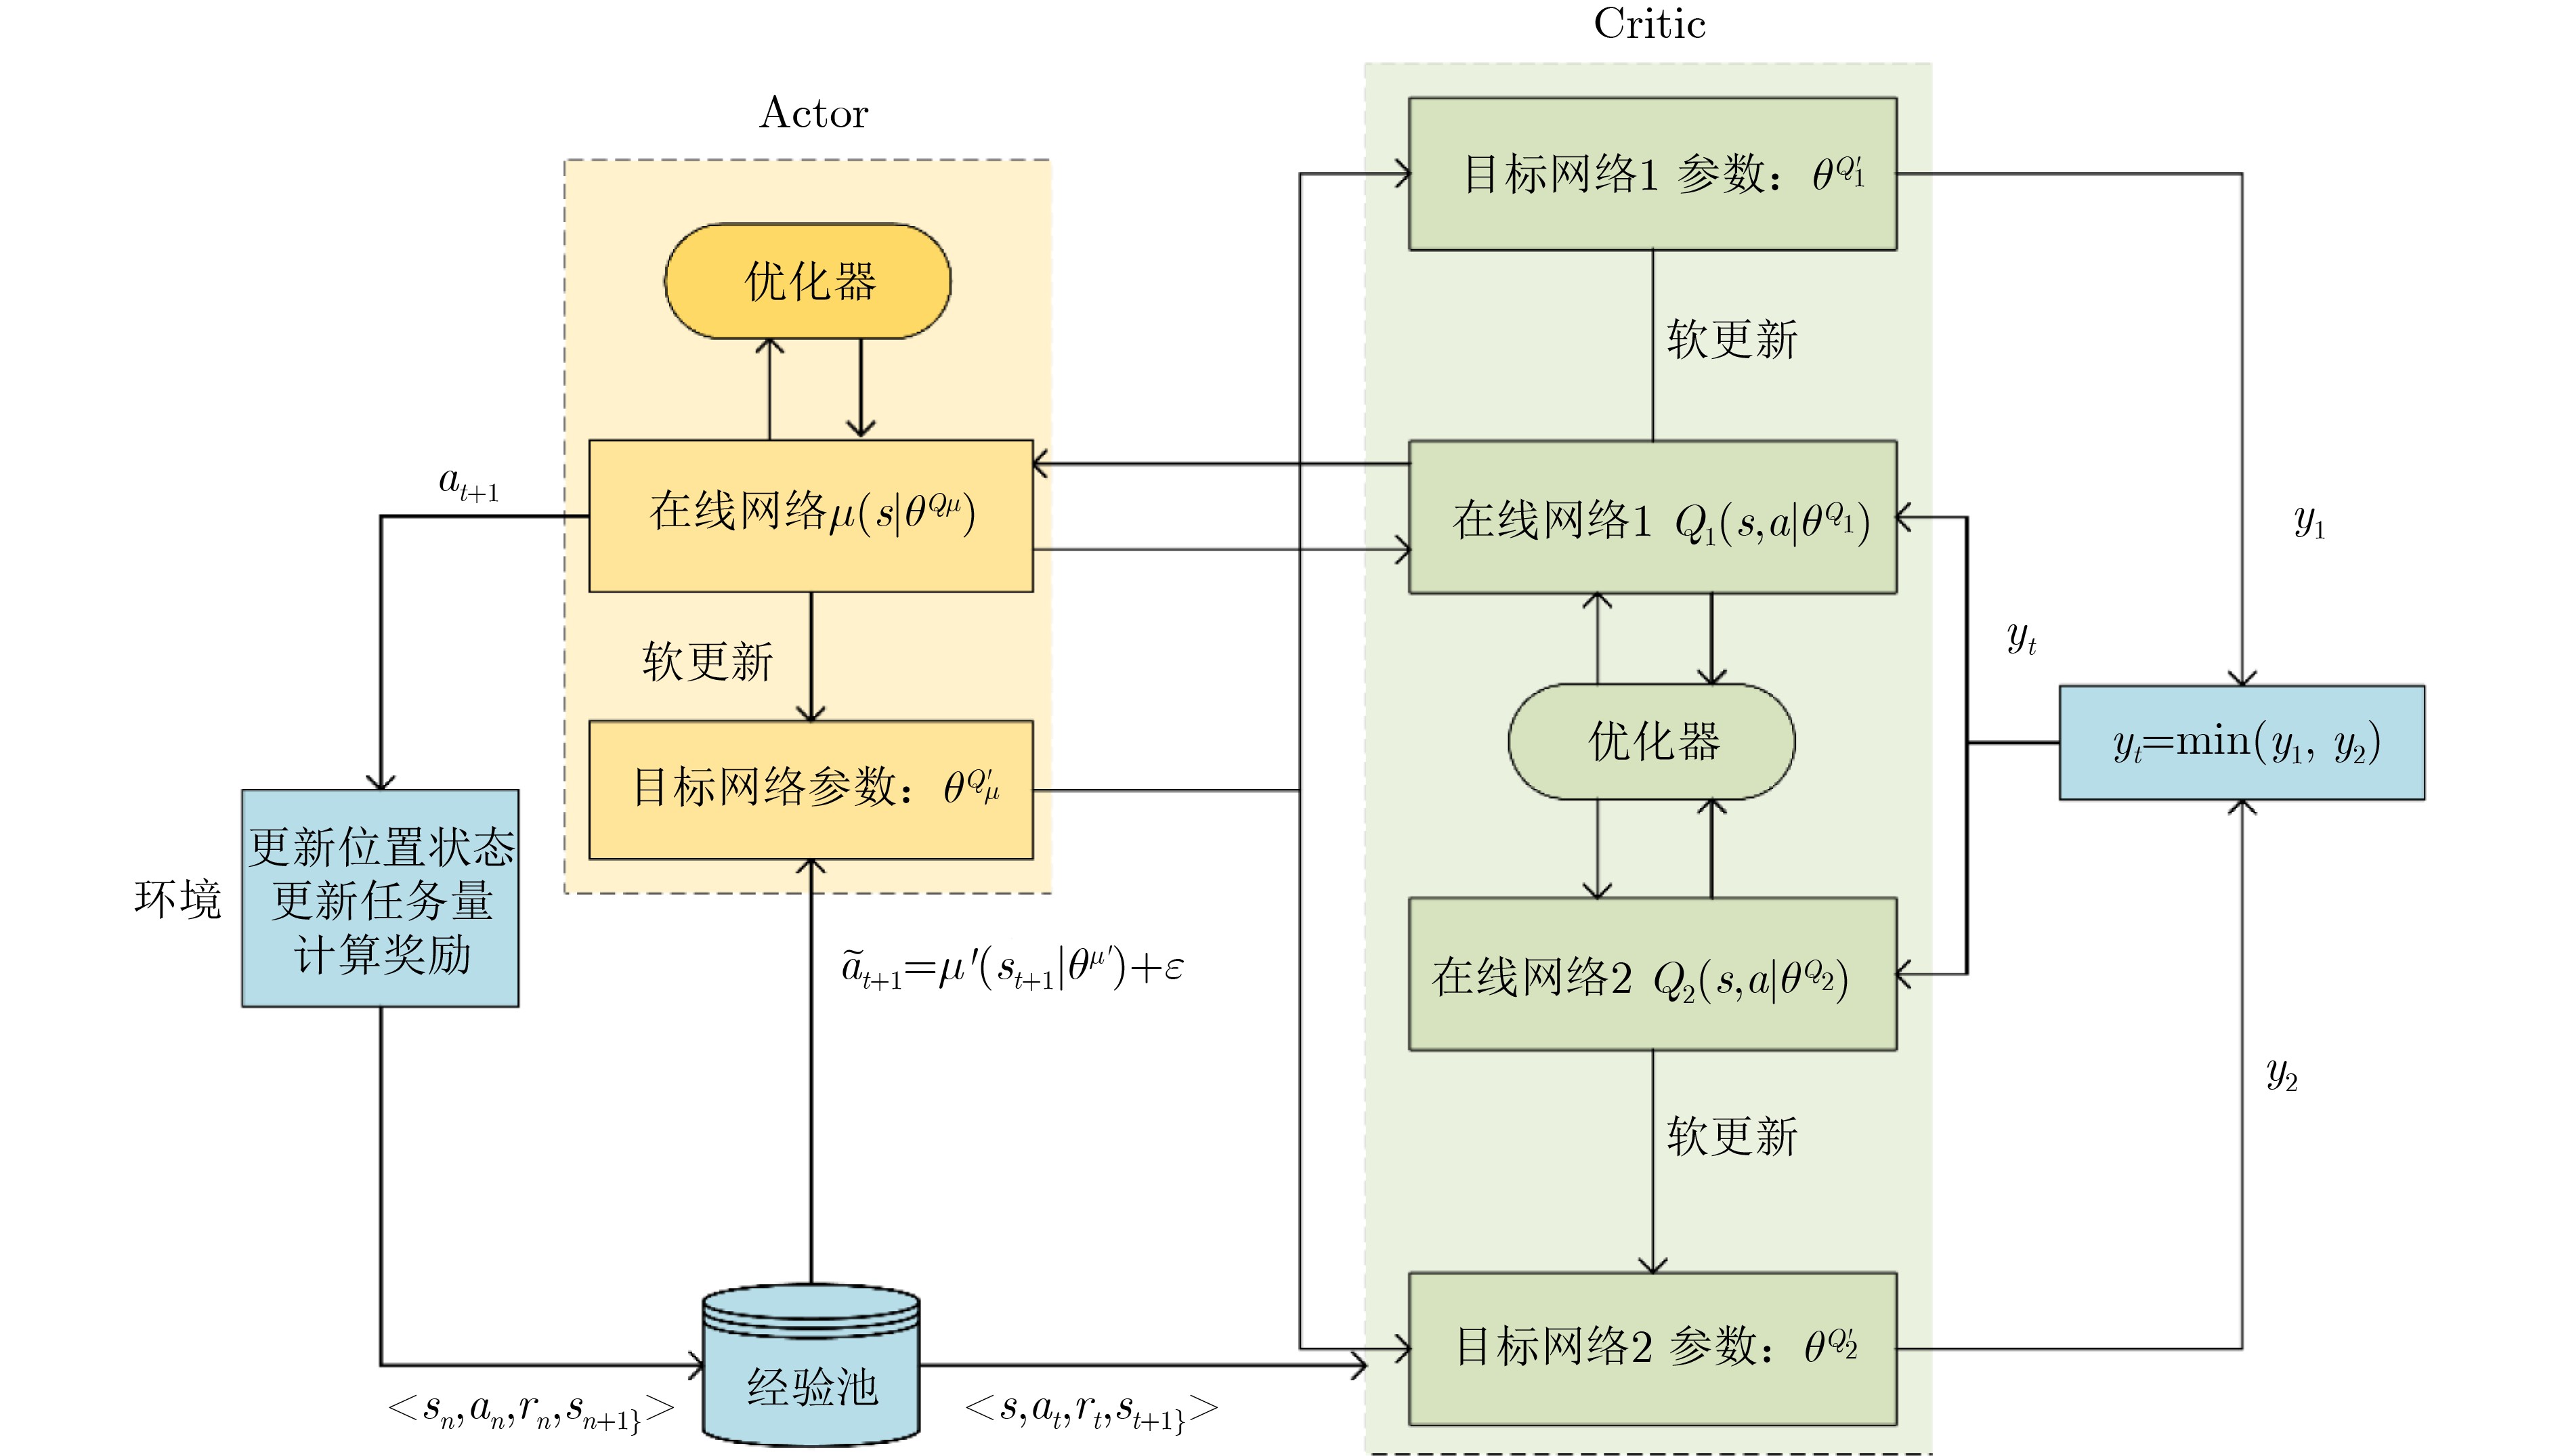
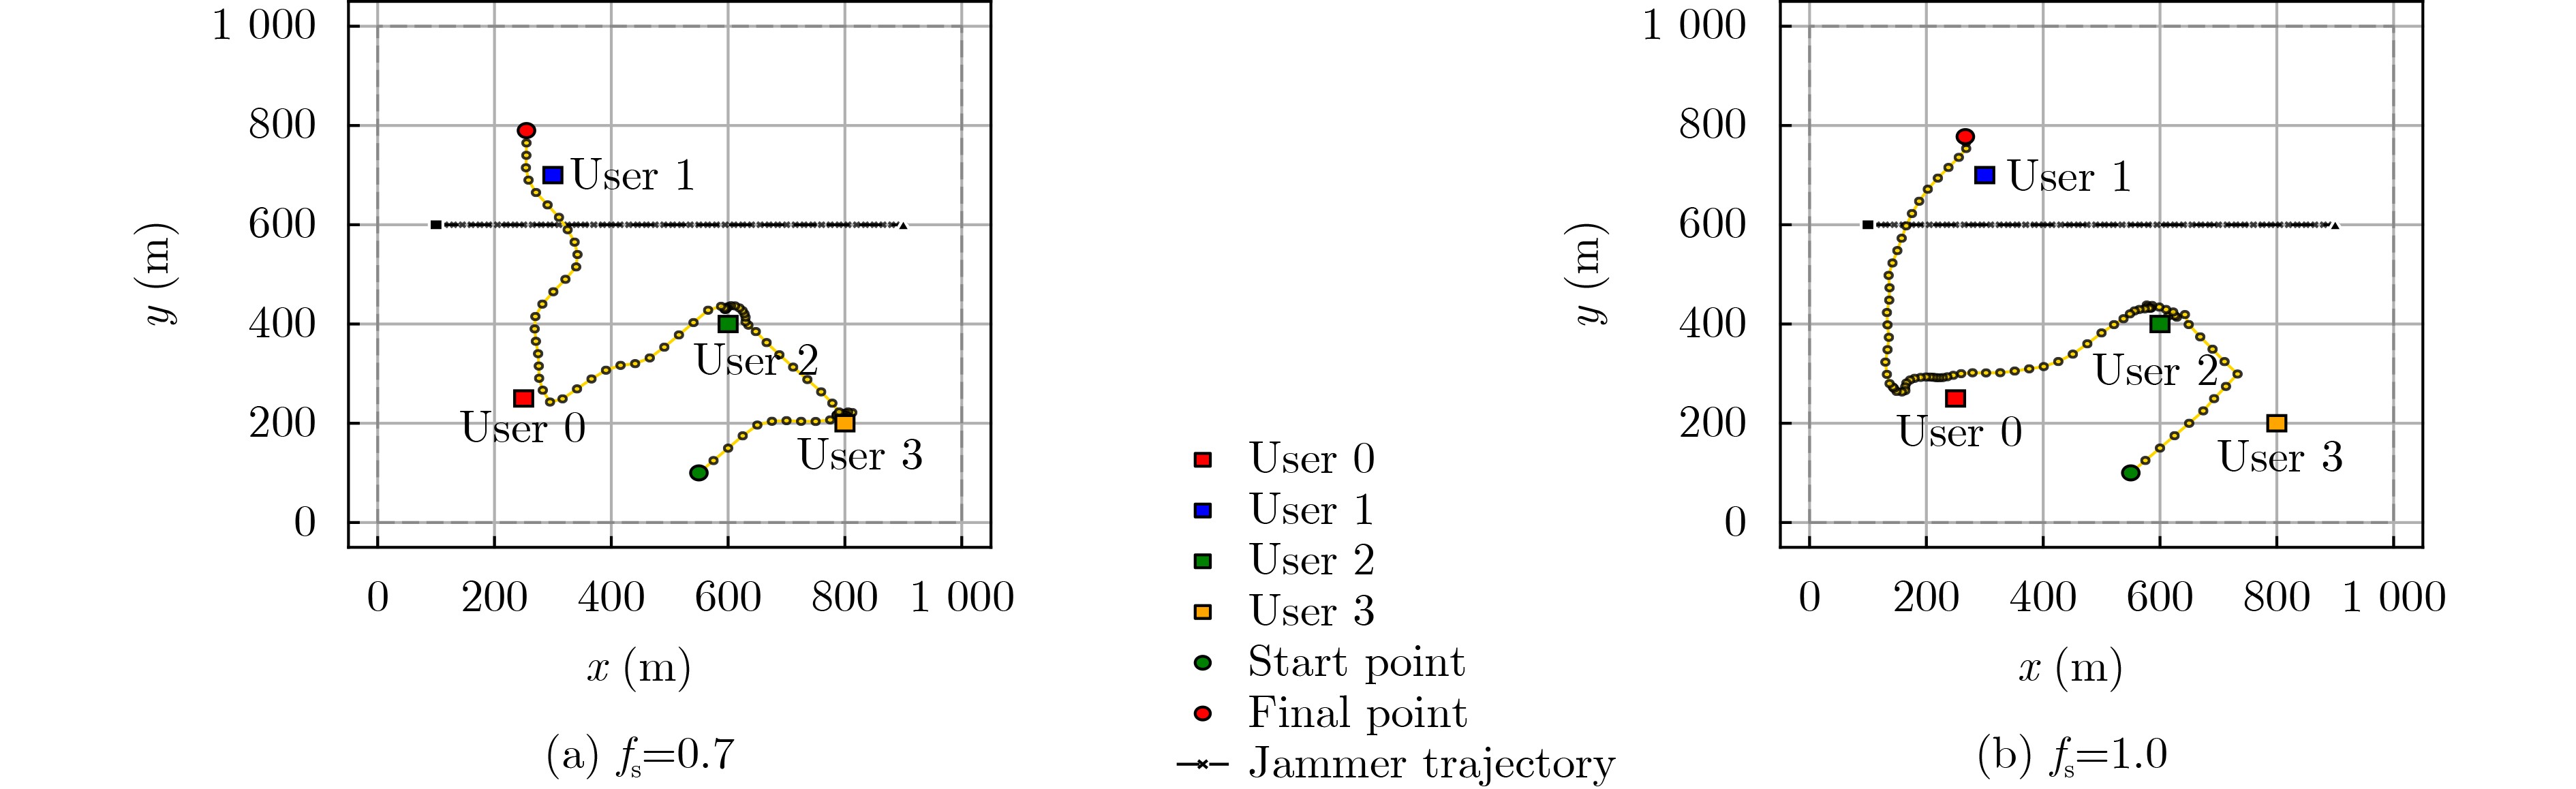
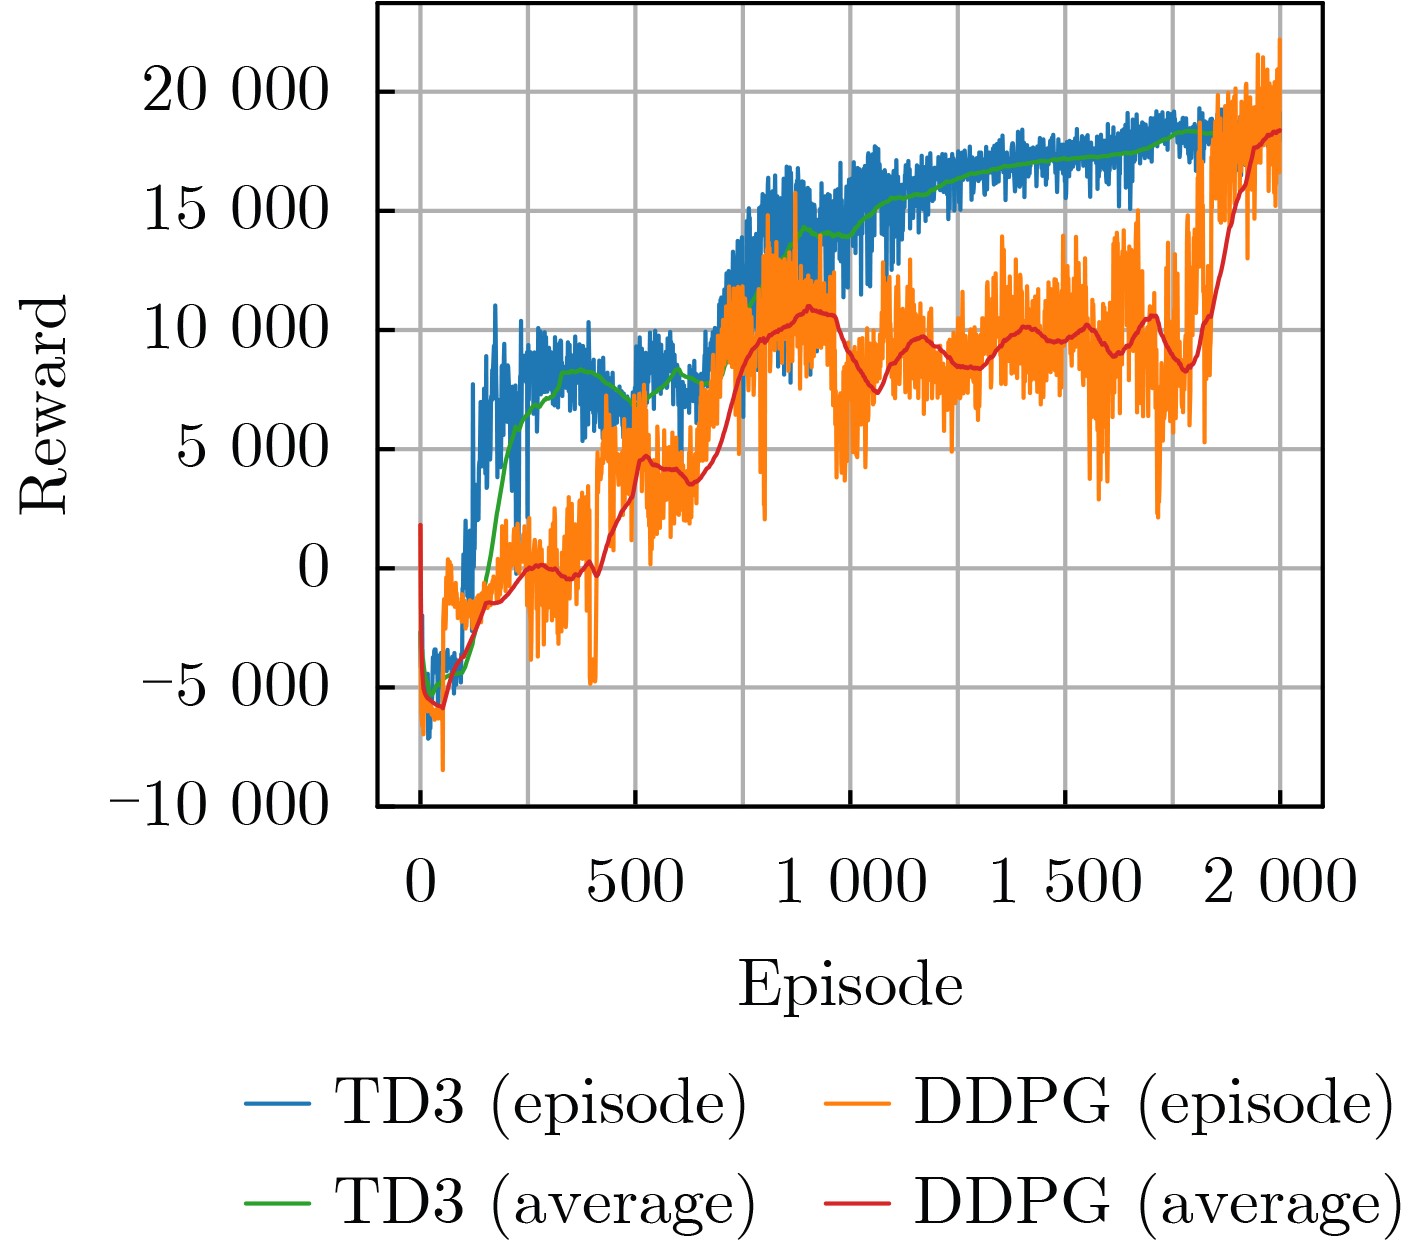
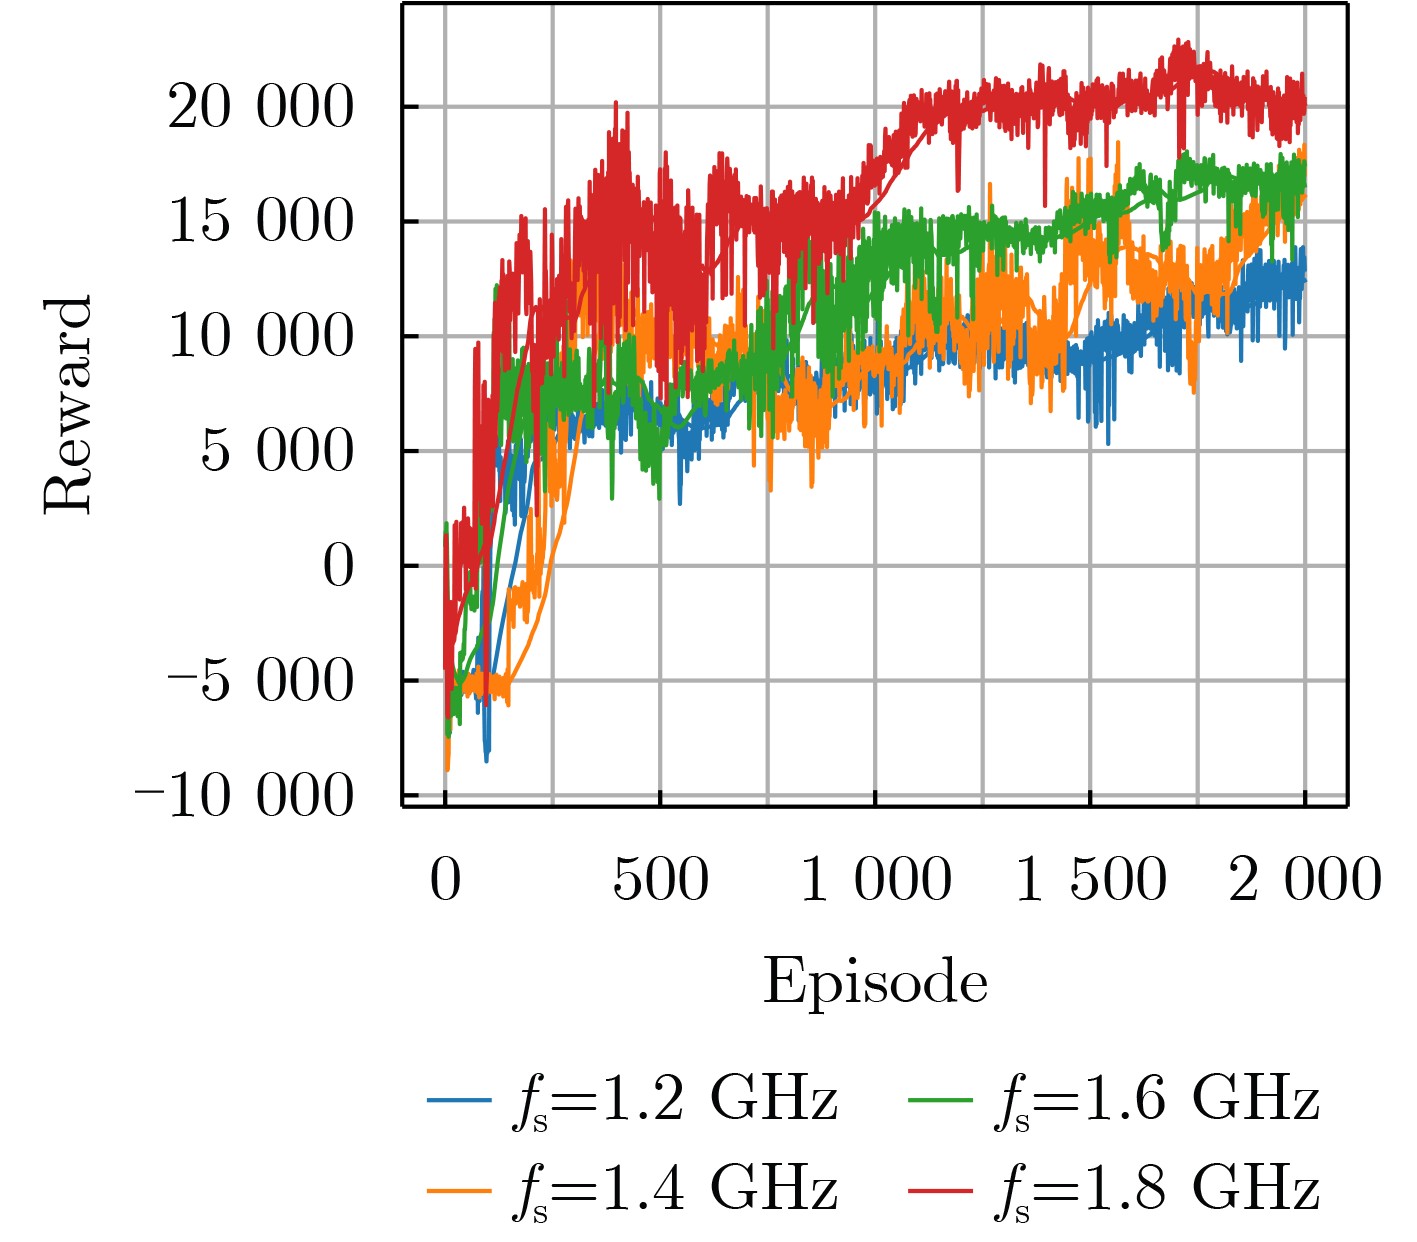
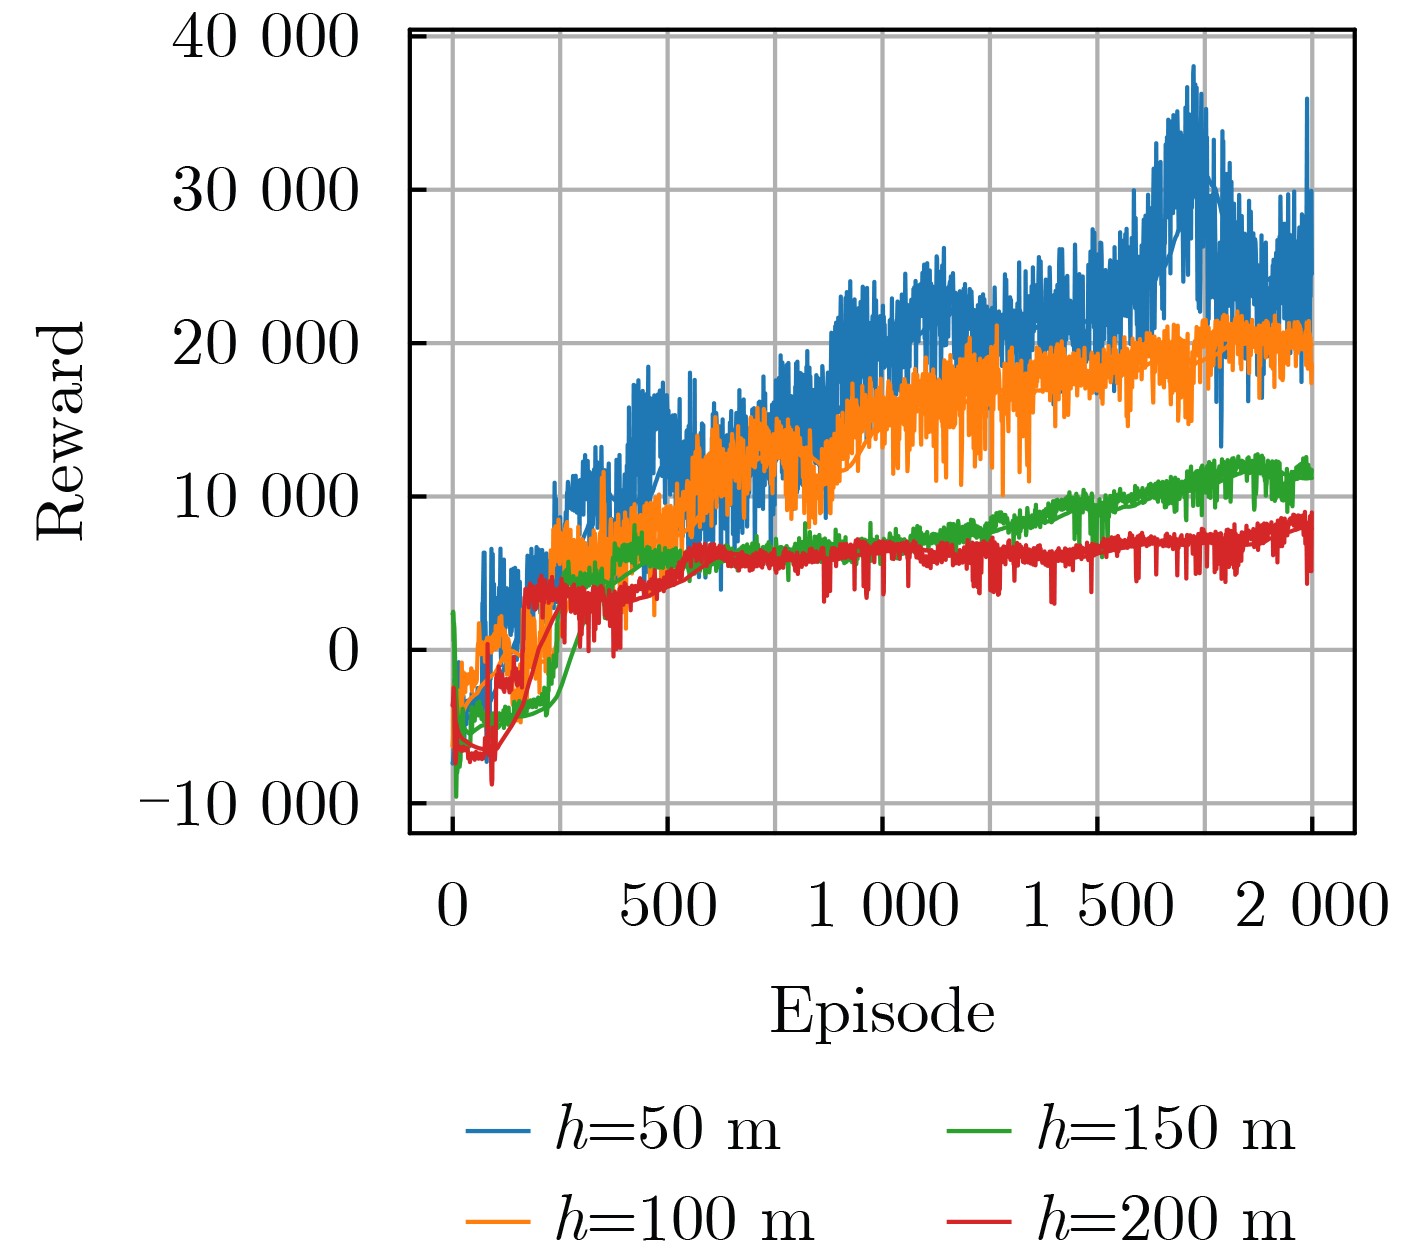
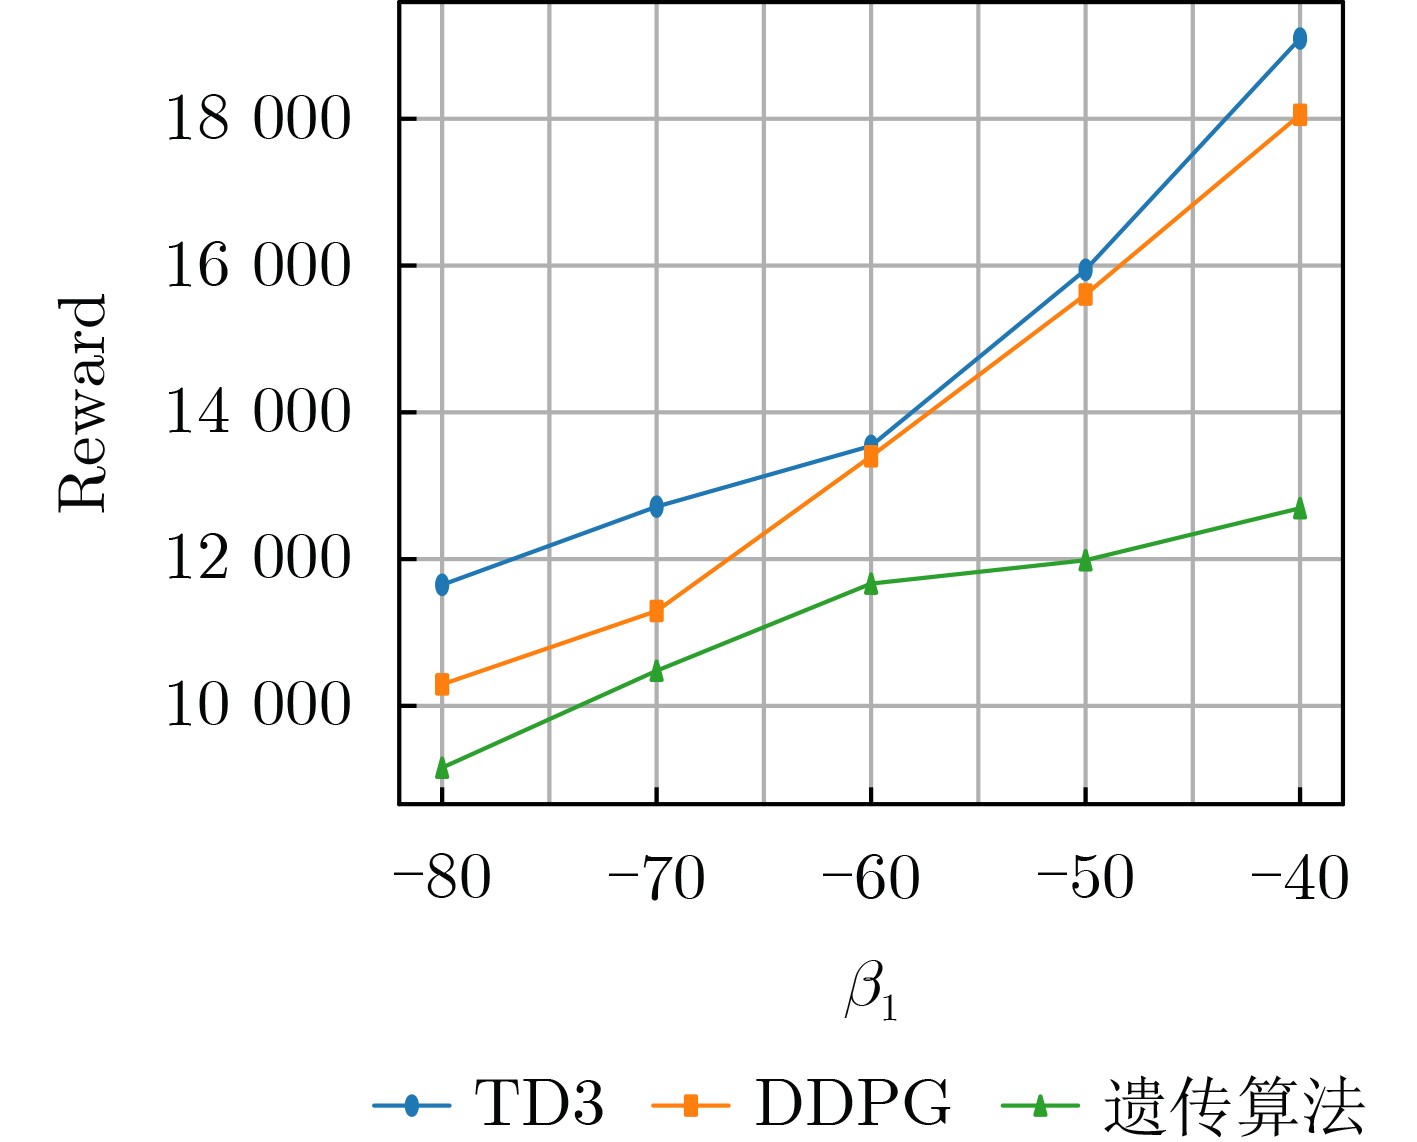
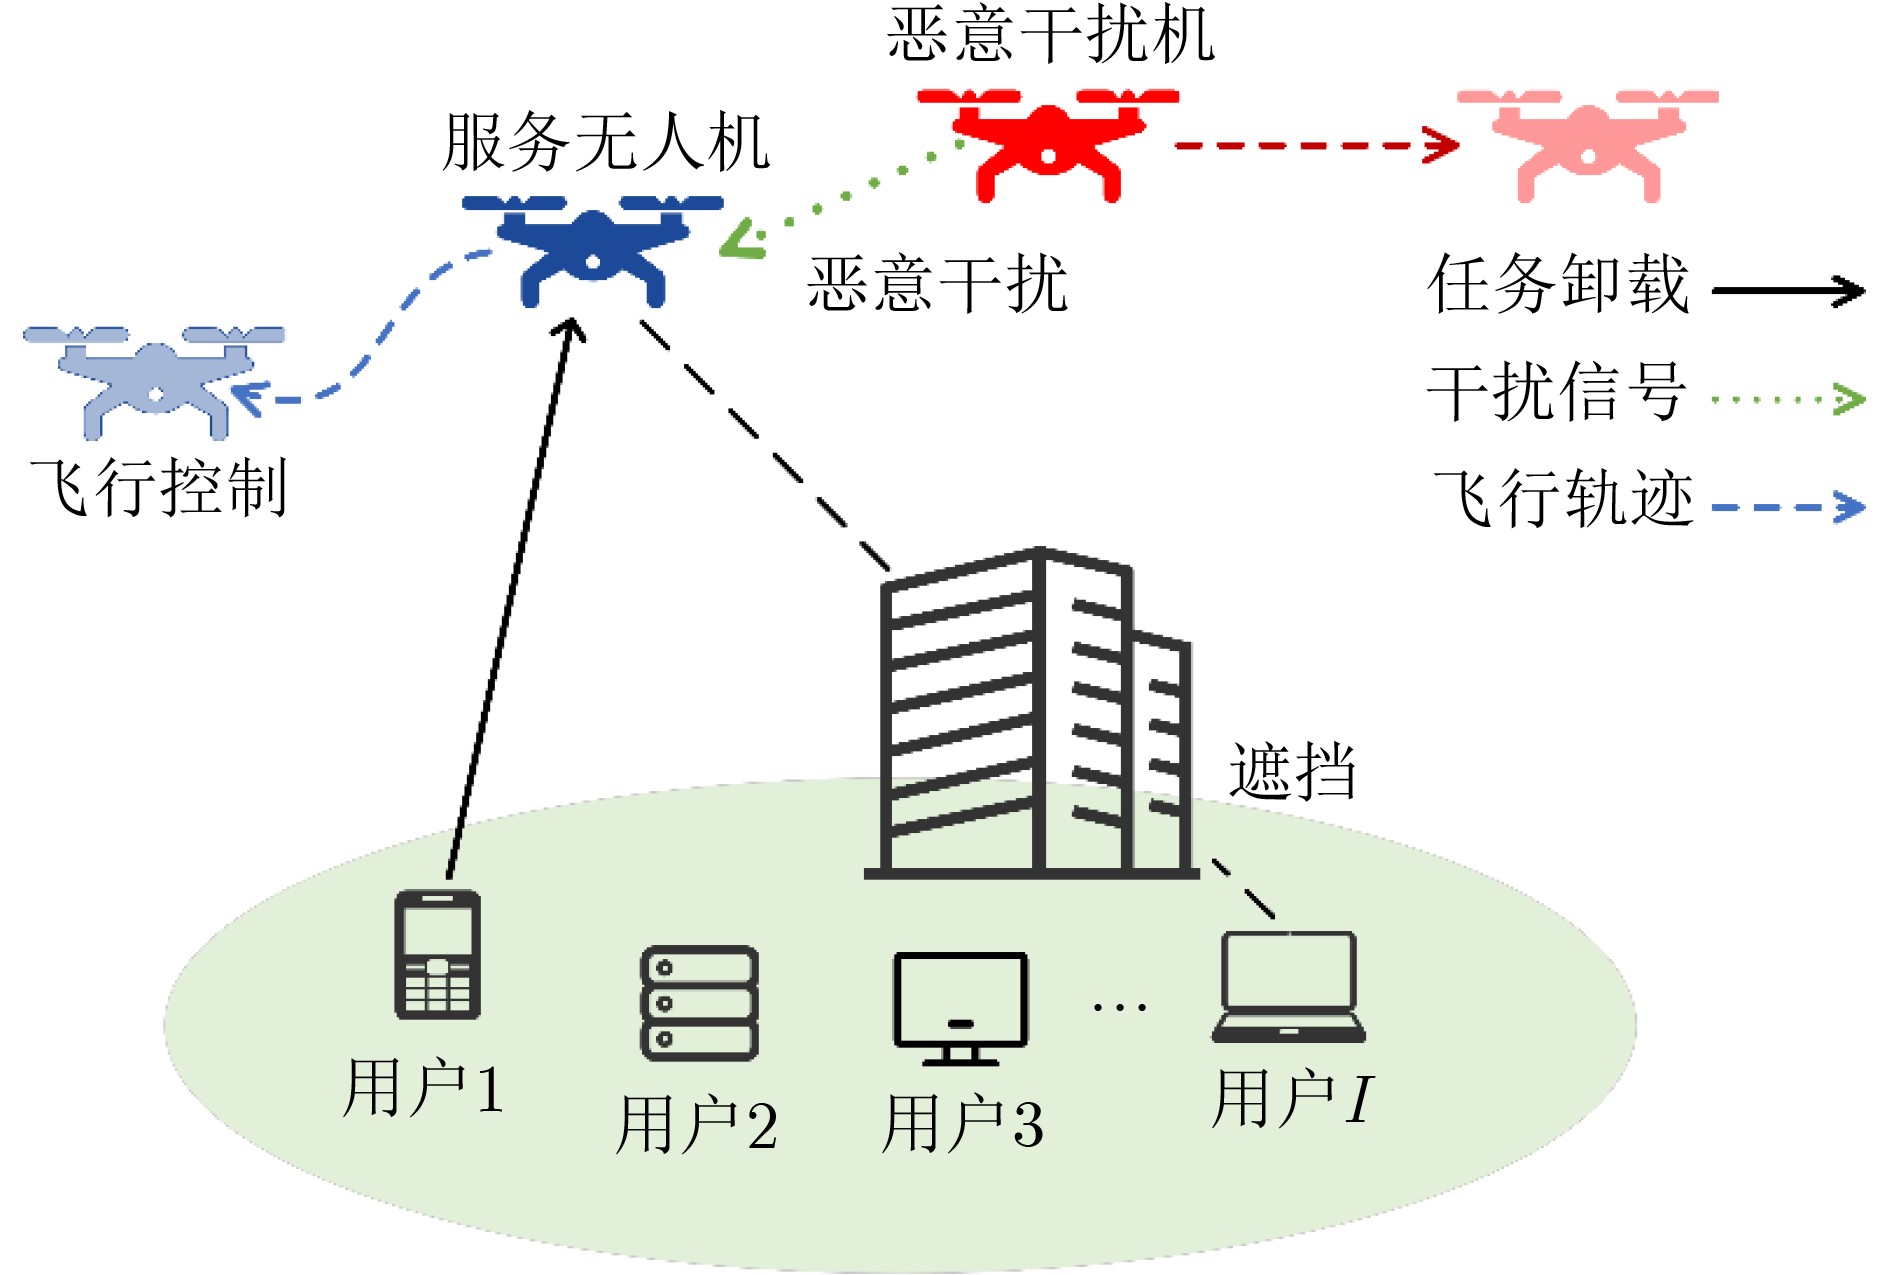
Objective Unmanned Aerial Vehicle (UAV)-assisted Mobile Edge Computing (MEC) extends network coverage and improves service flexibility by exploiting the high mobility and rapid deployment capabilities of UAV platforms. However, this mobility also allows an adversary to use a malicious UAV as a dynamic jammer, continuously degrading the reliability and security of computation-offloading links. Existing optimization-based methods typically rely on convex approximation, block-coordinate iteration, or staged decomposition, limiting their ability to respond efficiently to rapidly moving jammers when communication, computation, and mobility variables are tightly coupled. To address this challenge, a secure transmission system for UAV-assisted MEC under malicious flight jamming is investigated. The objective is to maximize the system’s secure computing capacity by jointly optimizing the service UAV’s trajectory, user transmit power, and computation-task allocation, thereby improving the robustness of task offloading and processing in highly dynamic adversarial environments. Methods A system comprising one MEC-enabled service UAV, one malicious UAV jammer, and multiple ground users is established ( Fig. 1 ). The service period is divided into equal time slots, with at most one user served in each slot. Line-of-sight air-to-ground and air-to-air channels are adopted, while obstacle blockage, jammer interference power, receiver noise, and path loss are incorporated into the achievable transmission-rate model. A partial-offloading mechanism allows each user to divide its workload between local execution and UAV-assisted computation. Transmission delay, edge-computing delay, local-computing delay, UAV computing energy, propulsion energy, and user transmission energy are jointly modeled. The resulting optimization problem maximizes the total amount of computation completed locally and through UAV-assisted offloading, subject to constraints on user association, blockage states, task delays, flight regions, maximum speed, transmit power, UAV energy consumption, and minimum secure computing capacity. Because the problem is high-dimensional, nonconvex, and strongly coupled, it is reformulated as a Markov Decision Process (MDP). The state comprises the service UAV’s position and residual energy, the jammer’s position, user locations, remaining workloads, and blockage states. The action comprises user transmit power, UAV velocity, and computation-task allocation decisions. A Twin Delayed Deep Deterministic Policy Gradient (TD3) algorithm is developed within an actor–critic framework (Fig. 2 ). Two critic networks are employed to reduce value overestimation, delayed actor updates improve policy stability, and soft target-network updates promote stable convergence. Simulations are conducted using Python 3.8 and PyTorch, with the main parameters listed in Table 1. The proposed method is compared with Deep Deterministic Policy Gradient (DDPG) and a genetic algorithm.Results and Discussions The learned trajectories show that the service UAV identifies the spatial threat posed by the moving jammer and adaptively detours when approaching the interference region, while still visiting users and completing offloading tasks ( Fig. 3 ). This behavior demonstrates that trajectory planning and resource allocation are coordinated rather than optimized independently. The convergence comparison shows that the DDPG baseline exhibits greater fluctuations and converges to a lower secure computing capacity, whereas the TD3-based scheme converges faster and more smoothly (Fig. 4 ). This improvement is primarily attributable to the twin-critic structure and delayed actor updates, which suppress value overestimation and reduce unstable policy drift. The results further show that greater UAV computing capability increases secure computing capacity by reducing the processing time per offloaded bit, thereby encouraging users to offload more tasks (Fig. 5). A lower flight altitude also improves performance by reducing the distance between the service UAV and users and improving channel conditions, thereby increasing the amount of data that can be securely transmitted and processed within each time slot (Fig. 6 ). Under different interference-channel gains, the proposed scheme consistently achieves the highest secure computing capacity, while the genetic algorithm exhibits greater performance fluctuations and adapts less effectively to time-varying channel conditions (Fig. 7 ). These findings demonstrate the effectiveness of the proposed method under variations in UAV computing capability, flight altitude, and interference-channel gain.Conclusions A TD3-based scheme for intelligent trajectory planning and coordinated resource allocation is developed for secure transmission in UAV-assisted MEC systems under malicious flight jamming. By formulating the coupled trajectory, transmit-power, and computation-task allocation problem as an MDP, the scheme enables autonomous trajectory planning and dynamic scheduling of communication and computing resources. Simulation results demonstrate that the proposed method achieves faster convergence, greater stability, and higher secure computing capacity than the DDPG and genetic-algorithm baselines. The proposed method provides a practical approach to secure UAV-assisted edge computing in dynamic and adversarial environments. -
表 1 仿真参数设置
参数 值 参数 值 L(m) 1000 $ {\sigma }^{2} $(dBm) –110 $ {\beta }_{0} $(dB) –50 B(MHz) 1 $ {\beta }_{1} $(dB) –60 $ {t}_{{\mathrm{f}}} $(s) 1 $ {f}_{\text{loc}} $(GHz) 0.8 $ h $(m) 100 $ {f}_{{\mathrm{s}}} $(GHz) 1.2 c 1000 $ {P}_{{\mathrm{J}}} $(W) 0.1 $ \xi $ 0.1  下载: 导出CSV
-
[1] TAN Zhenjie, QU Hua, ZHAO Jihong, et al. UAV-aided edge/fog computing in smart IoT community for social augmented reality[J]. IEEE Internet of Things Journal, 2020, 7(6): 4872–4884. doi: 10.1109/JIOT.2020.2971325. [2] 王侃, 曹铁林, 李旭杰, 等. 无人机辅助边缘计算网络轨迹规划与资源分配研究综述[J]. 电子与信息学报, 2025, 47(5): 1266–1281. doi: 10.11999/JEIT241071.WANG Kan, CAO Tielin, LI Xujie, et al. A survey on trajectory planning and resource allocation in unmanned aerial vehicle-assisted edge computing networks[J]. Journal of Electronics & Information Technology, 2025, 47(5): 1266–1281. doi: 10.11999/JEIT241071. [3] ZHAN Cheng, HU Han, SUI Xiufeng, et al. Completion time and energy optimization in the UAV-enabled mobile-edge computing system[J]. IEEE Internet of Things Journal, 2020, 7(8): 7808–7822. doi: 10.1109/JIOT.2020.2993260. [4] XU Yu, ZHANG Tiankui, LOO J, et al. Completion time minimization for UAV-assisted mobile-edge computing systems[J]. IEEE Transactions on Vehicular Technology, 2021, 70(11): 12253–12259. doi: 10.1109/TVT.2021.3112853. [5] HU Zhenzhen, ZENG Fanzi, XIAO Zhu, et al. Computation efficiency maximization and QoE-provisioning in UAV-enabled MEC communication systems[J]. IEEE Transactions on Network Science and Engineering, 2021, 8(2): 1630–1645. doi: 10.1109/TNSE.2021.3068123. [6] WANG Maoli, ZHANG Lu, GAO Peng, et al. Stackelberg-game-based intelligent offloading incentive mechanism for a multi-UAV-assisted mobile-edge computing system[J]. IEEE Internet of Things Journal, 2023, 10(17): 15679–15689. doi: 10.1109/JIOT.2023.3265432. [7] LIU Yuan, XIONG Ke, NI Qiang, et al. UAV-assisted wireless powered cooperative mobile edge computing: Joint offloading, CPU control, and trajectory optimization[J]. IEEE Internet of Things Journal, 2020, 7(4): 2777–2790. doi: 10.1109/JIOT.2019.2958975. [8] DAI Xingxia, XIAO Zhu, JIANG Hongbo, et al. UAV-assisted task offloading in vehicular edge computing networks[J]. IEEE Transactions on Mobile Computing, 2024, 23(4): 2520–2534. doi: 10.1109/TMC.2023.3259394. [9] YU Xueyong, NIU Wenjin, ZHU Ye, et al. UAV-assisted cooperative offloading energy efficiency system for mobile edge computing[J]. Digital Communications and Networks, 2024, 10(1): 16–24. doi: 10.1016/j.dcan.2022.03.005. [10] WANG Tong and YOU Chuanchuan. Distributed user association and computation offloading in UAV-assisted mobile edge computing systems[J]. IEEE Access, 2024, 12: 63548–63567. doi: 10.1109/ACCESS.2024.3396471. [11] WANG Hui, KE Hongchang, and SUN Weijia. Unmanned-aerial-vehicle-assisted computation offloading for mobile edge computing based on deep reinforcement learning[J]. IEEE Access, 2020, 8: 180784–180798. doi: 10.1109/ACCESS.2020.3028553. [12] ZHAO Nan, YE Zhiyang, PEI Yiyang, et al. Multi-agent deep reinforcement learning for task offloading in UAV-assisted mobile edge computing[J]. IEEE Transactions on Wireless Communications, 2022, 21(9): 6949–6960. doi: 10.1109/TWC.2022.3153316. [13] QIAN Liping, ZHANG Hongsen, WANG Qian, et al. Joint multi-domain resource allocation and trajectory optimization in UAV-assisted maritime IoT networks[J]. IEEE Internet of Things Journal, 2023, 10(1): 539–552. doi: 10.1109/JIOT.2022.3201017. [14] SEID A M, BOATENG G O, ANOKYE S, et al. Collaborative computation offloading and resource allocation in multi-UAV-assisted IoT networks: A deep reinforcement learning approach[J]. IEEE Internet of Things Journal, 2021, 8(15): 12203–12218. doi: 10.1109/JIOT.2021.3063188. [15] DING Yu, CHEN Xin, HAN Huimei, et al. Security-driven joint trajectory and resource orchestration for fluid antenna enhanced UAV-assisted MEC systems[J]. IEEE Transactions on Vehicular Technology, 2026. doi: 10.1109/TVT.2026.3731379. [16] 陆音, 刘金志, 张珉. 一种模型辅助的联邦强化学习多无人机路径规划方法[J]. 电子与信息学报, 2025, 47(5): 1368–1380. doi: 10.11999/JEIT241055.LU Yin, LIU Jinzhi, and ZHANG Min. A model-assisted federated reinforcement learning method for multi-UAV path planning[J]. Journal of Electronics & Information Technology, 2025, 47(5): 1368–1380. doi: 10.11999/JEIT241055. [17] DING Yu, HAN Huimei, LU Weidang, et al. DDQN-based trajectory and resource optimization for UAV-aided MEC secure communications[J]. IEEE Transactions on Vehicular Technology, 2024, 73(4): 6006–6011. doi: 10.1109/TVT.2023.3335210. [18] 王义君, 王雅出, SHAHD B, 等. 无人机辅助动态权重边缘计算卸载策略研究[J]. 电子与信息学报, 2026, 48(7): 3071–3083. doi: 10.11999/JEIT260054.WANG Yijun, WANG Yachu, SHAHD B, et al. Research on UAV-assisted dynamic-weight edge computing offloading strategy[J]. Journal of Electronics & Information Technology, 2026, 48(7): 3071–3083. doi: 10.11999/JEIT260054. -

 下载:

图(7) / 表(1)
计量
- 文章访问数: 116
- HTML全文浏览量: 30
- PDF下载量: 12
- 被引次数: 0
