

Space-Time Joint Clutter Suppression Technology for ISAC Sensing Echo Signals
-
摘要: 针对通感一体化感知信号处理中强静态杂波易掩盖“低慢小”目标,以及传统动目标显示(MTI)方法在低速场景下易损伤目标回波和微多普勒特征的问题,该文提出一种空-时联合杂波抑制方法。该方法利用杂波角度图(CLAM)构建空域投影算子,实现强静态杂波抑制;针对目标与杂波角度接近时空域抑制易将目标一并压制的问题, 进一步结合候选角度遍历与Taubin拟合,对慢时域残余直流偏置进行估计和消除。仿真结果表明,所提方法相比传统MTI方法,在低速目标场景下具有更低的角度估计误差,并能较好地保留目标微多普勒特征。Abstract:
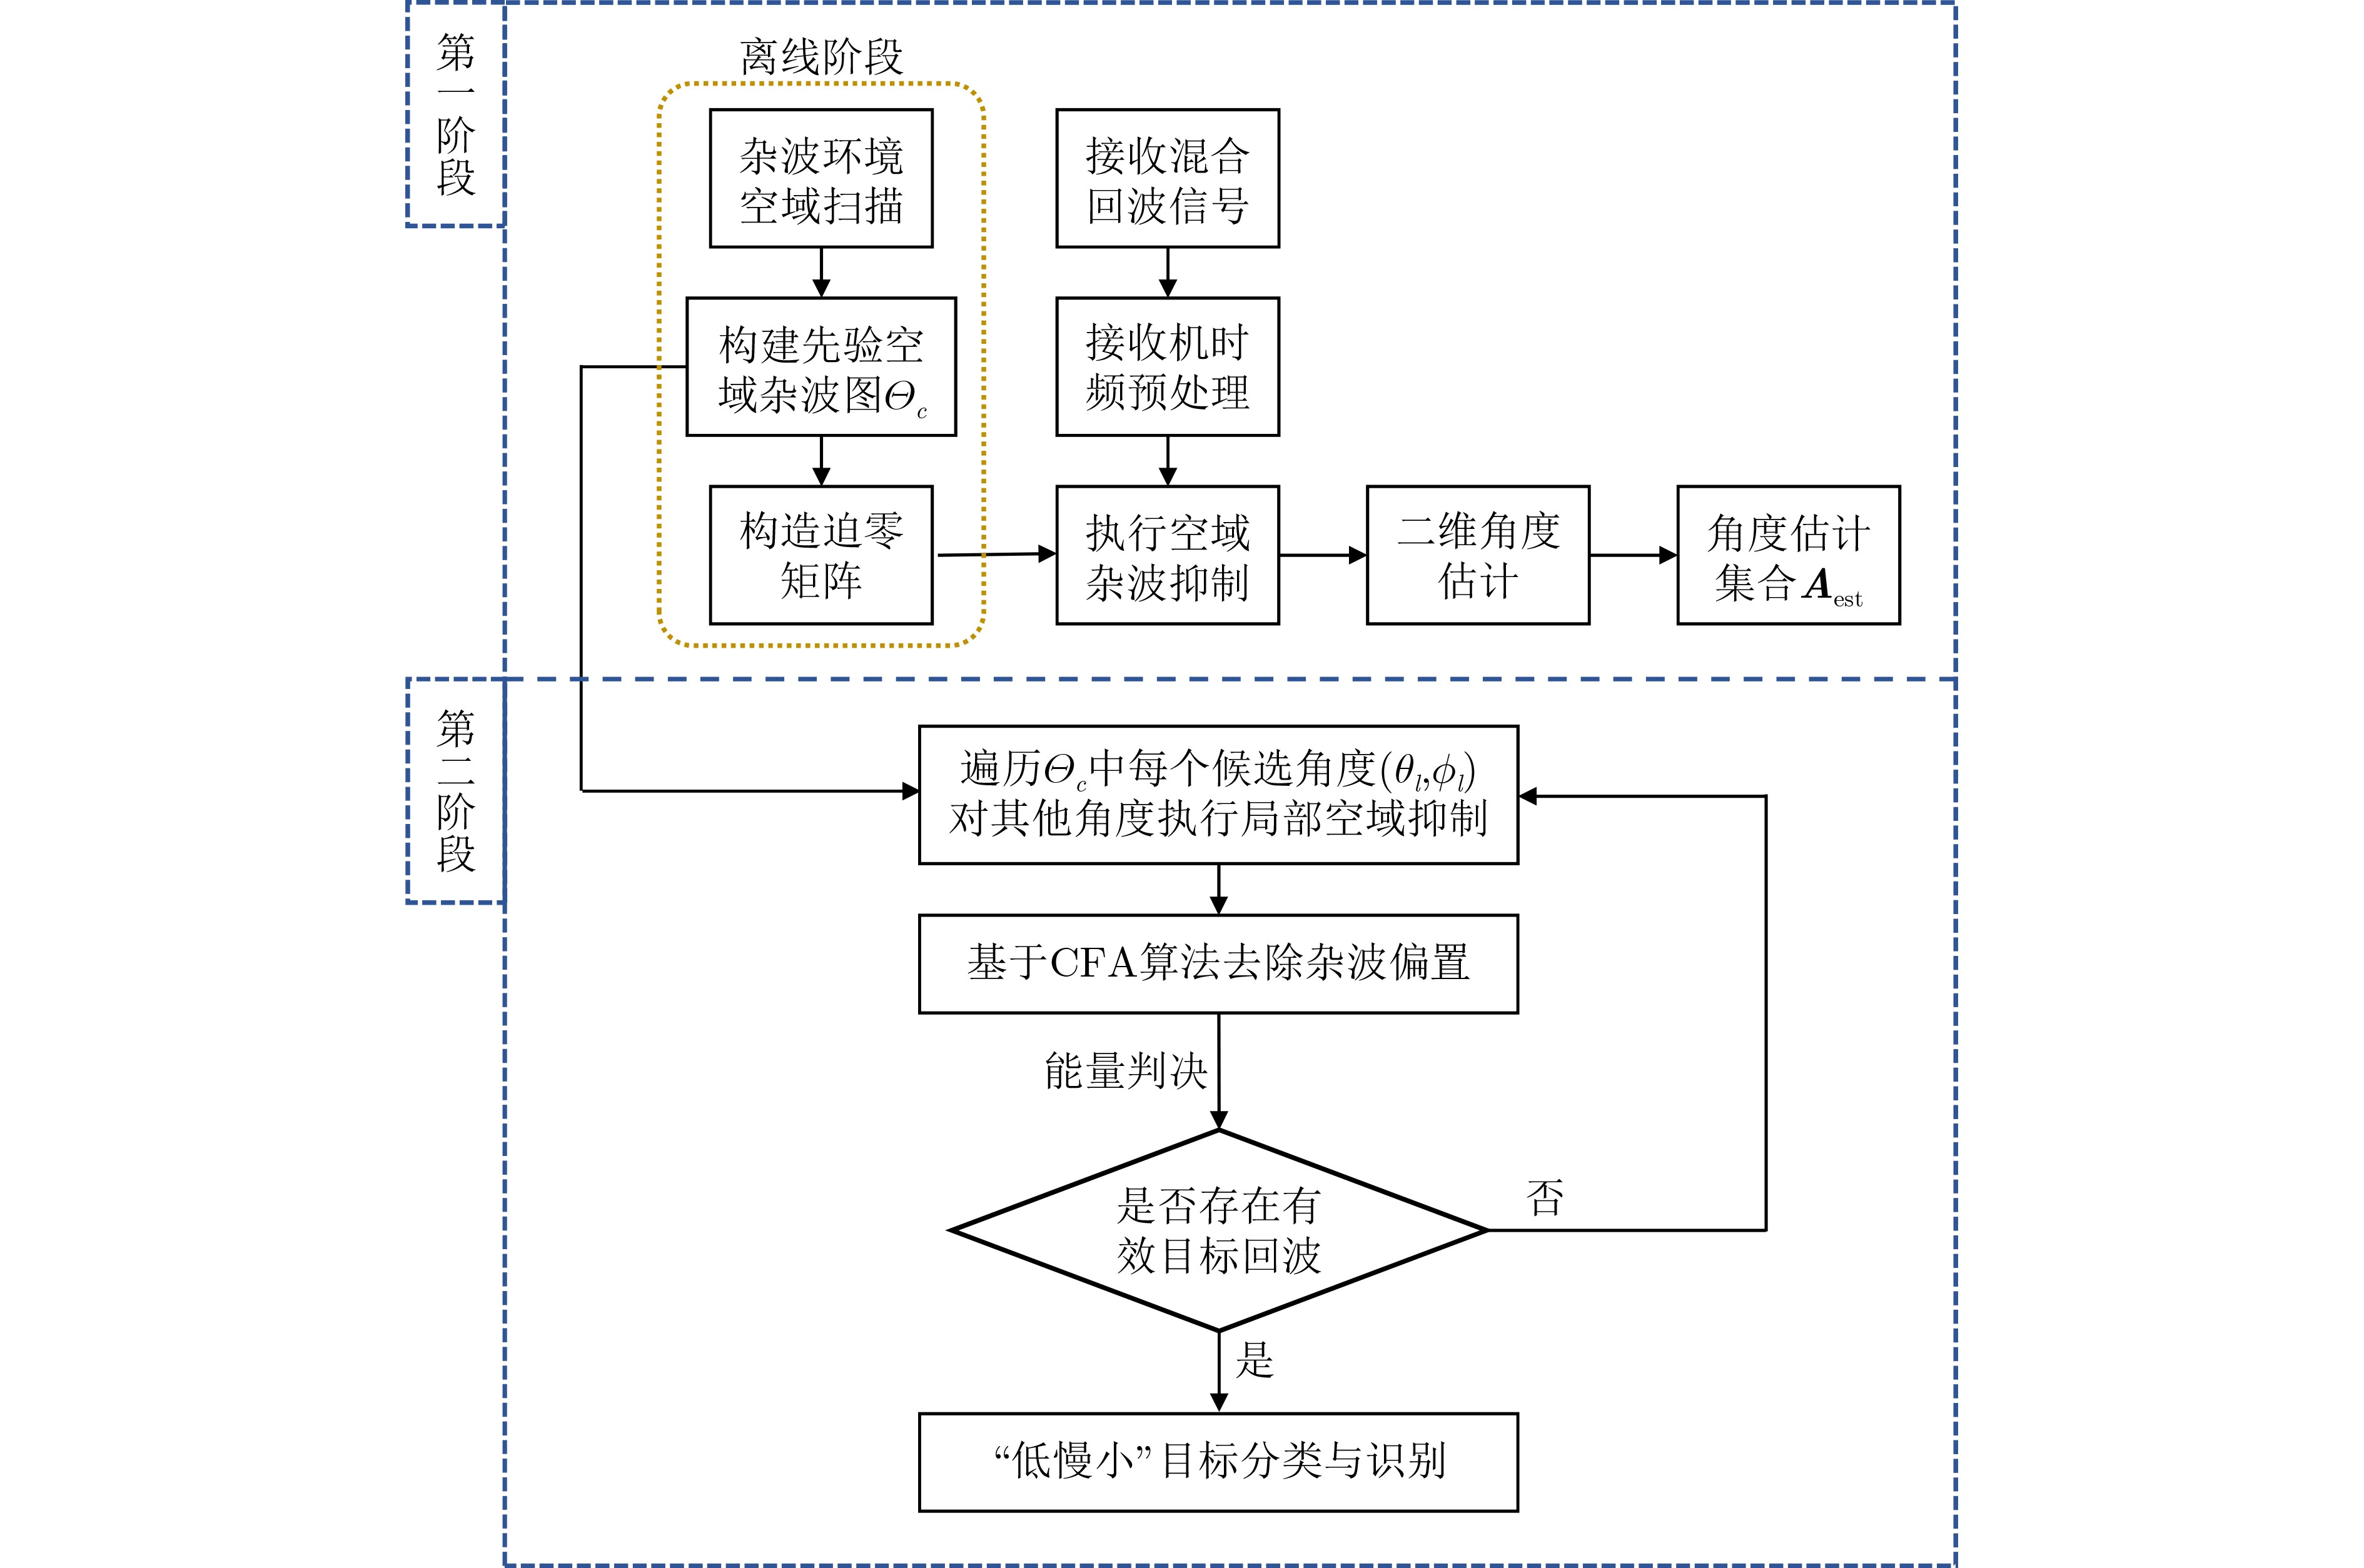
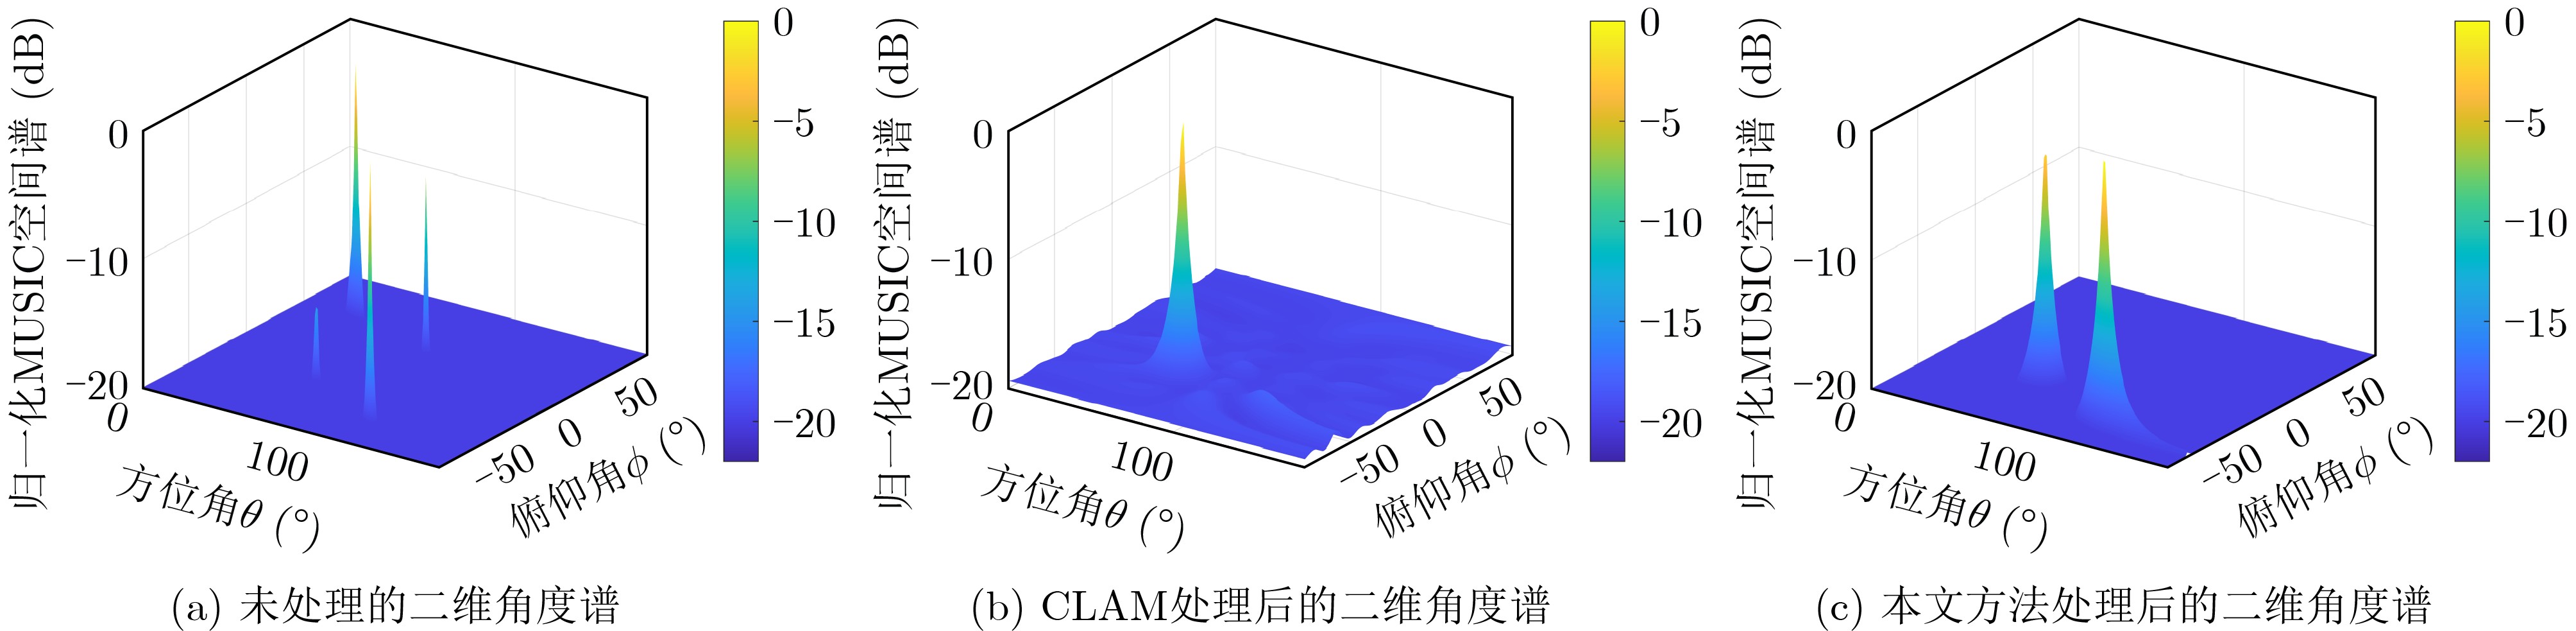
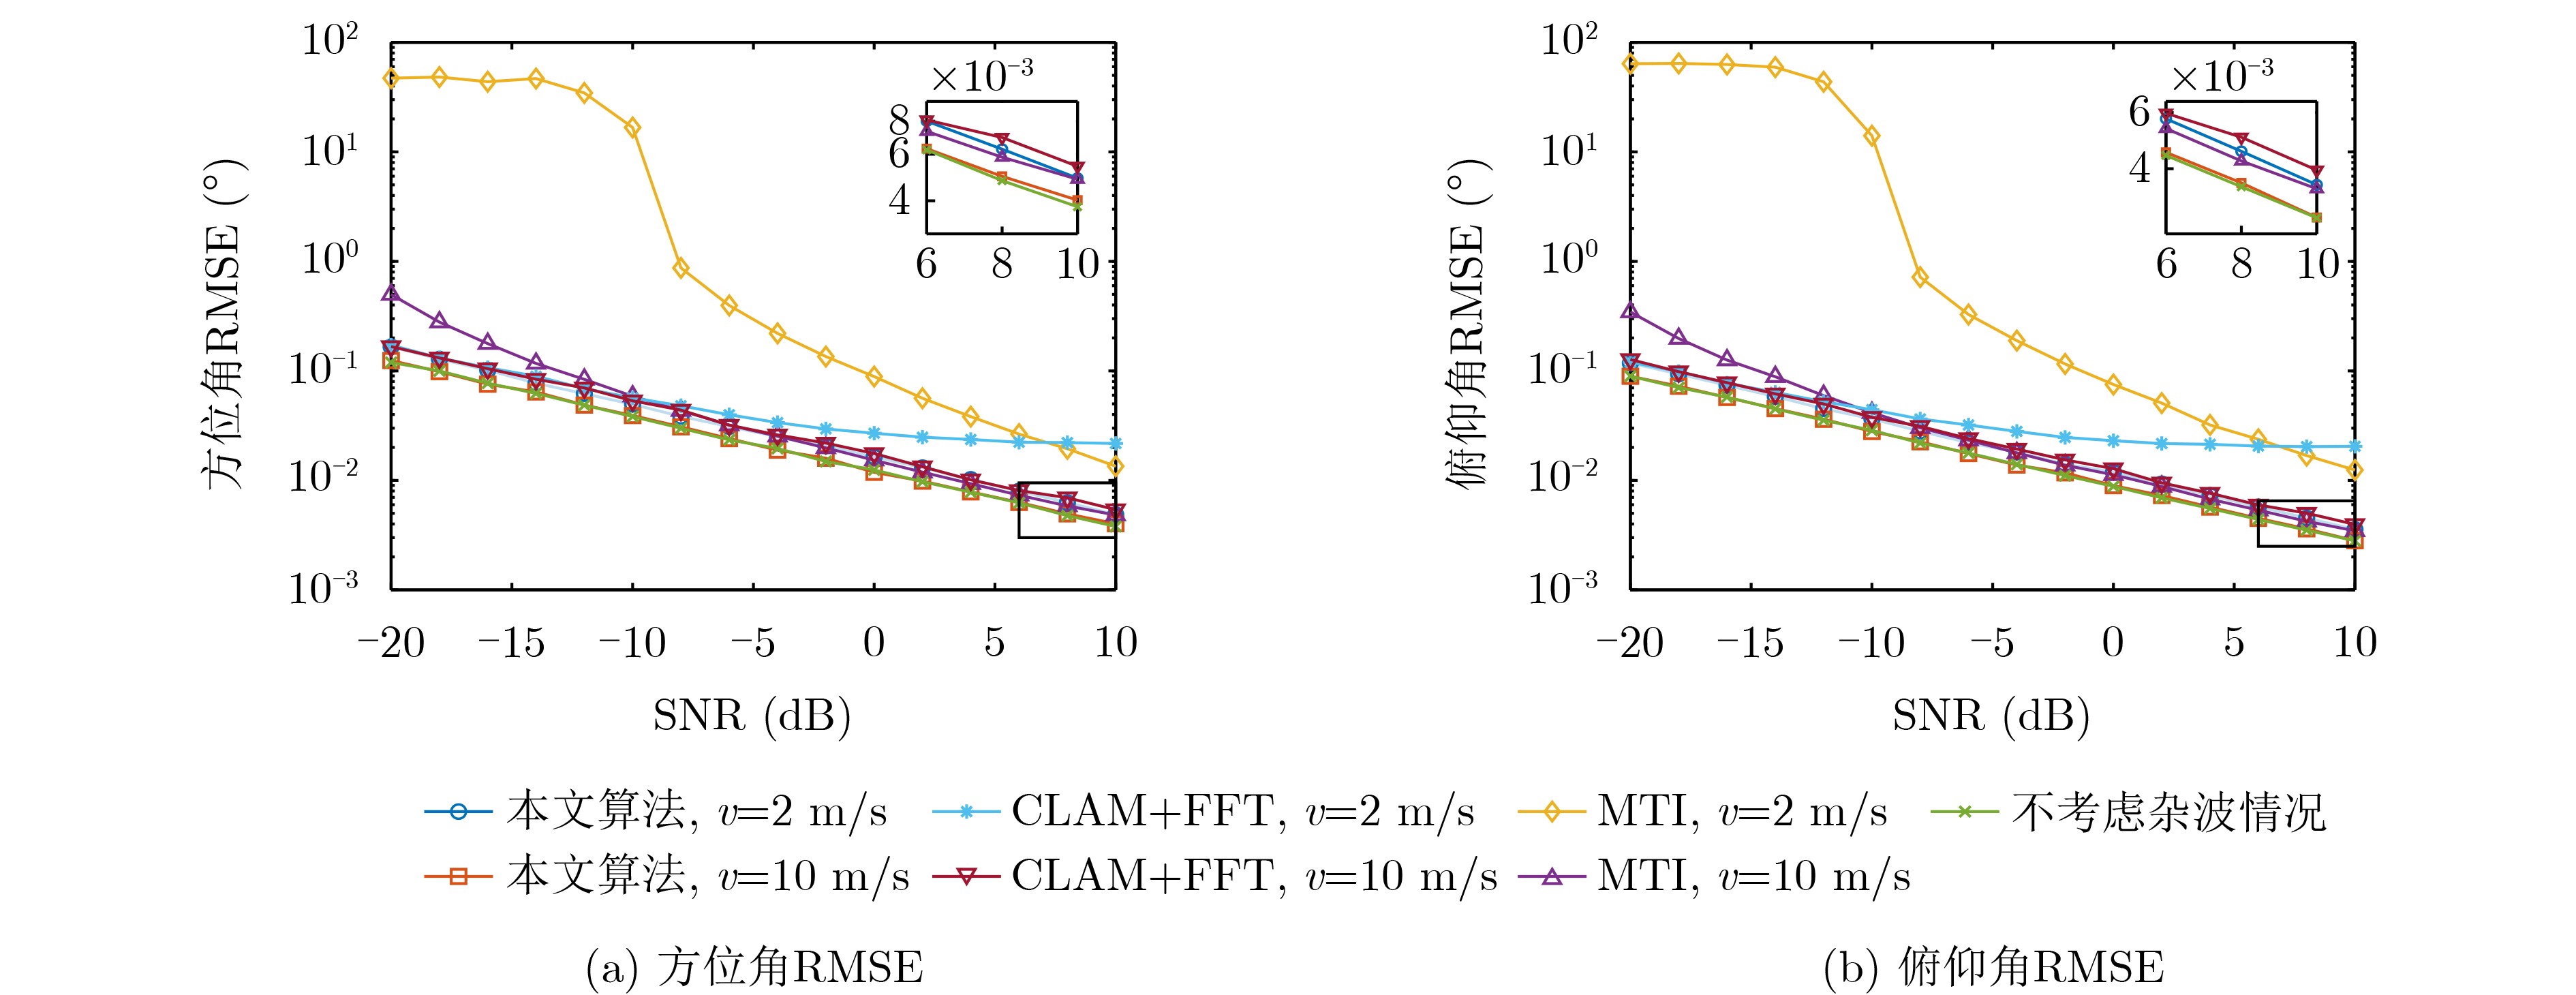
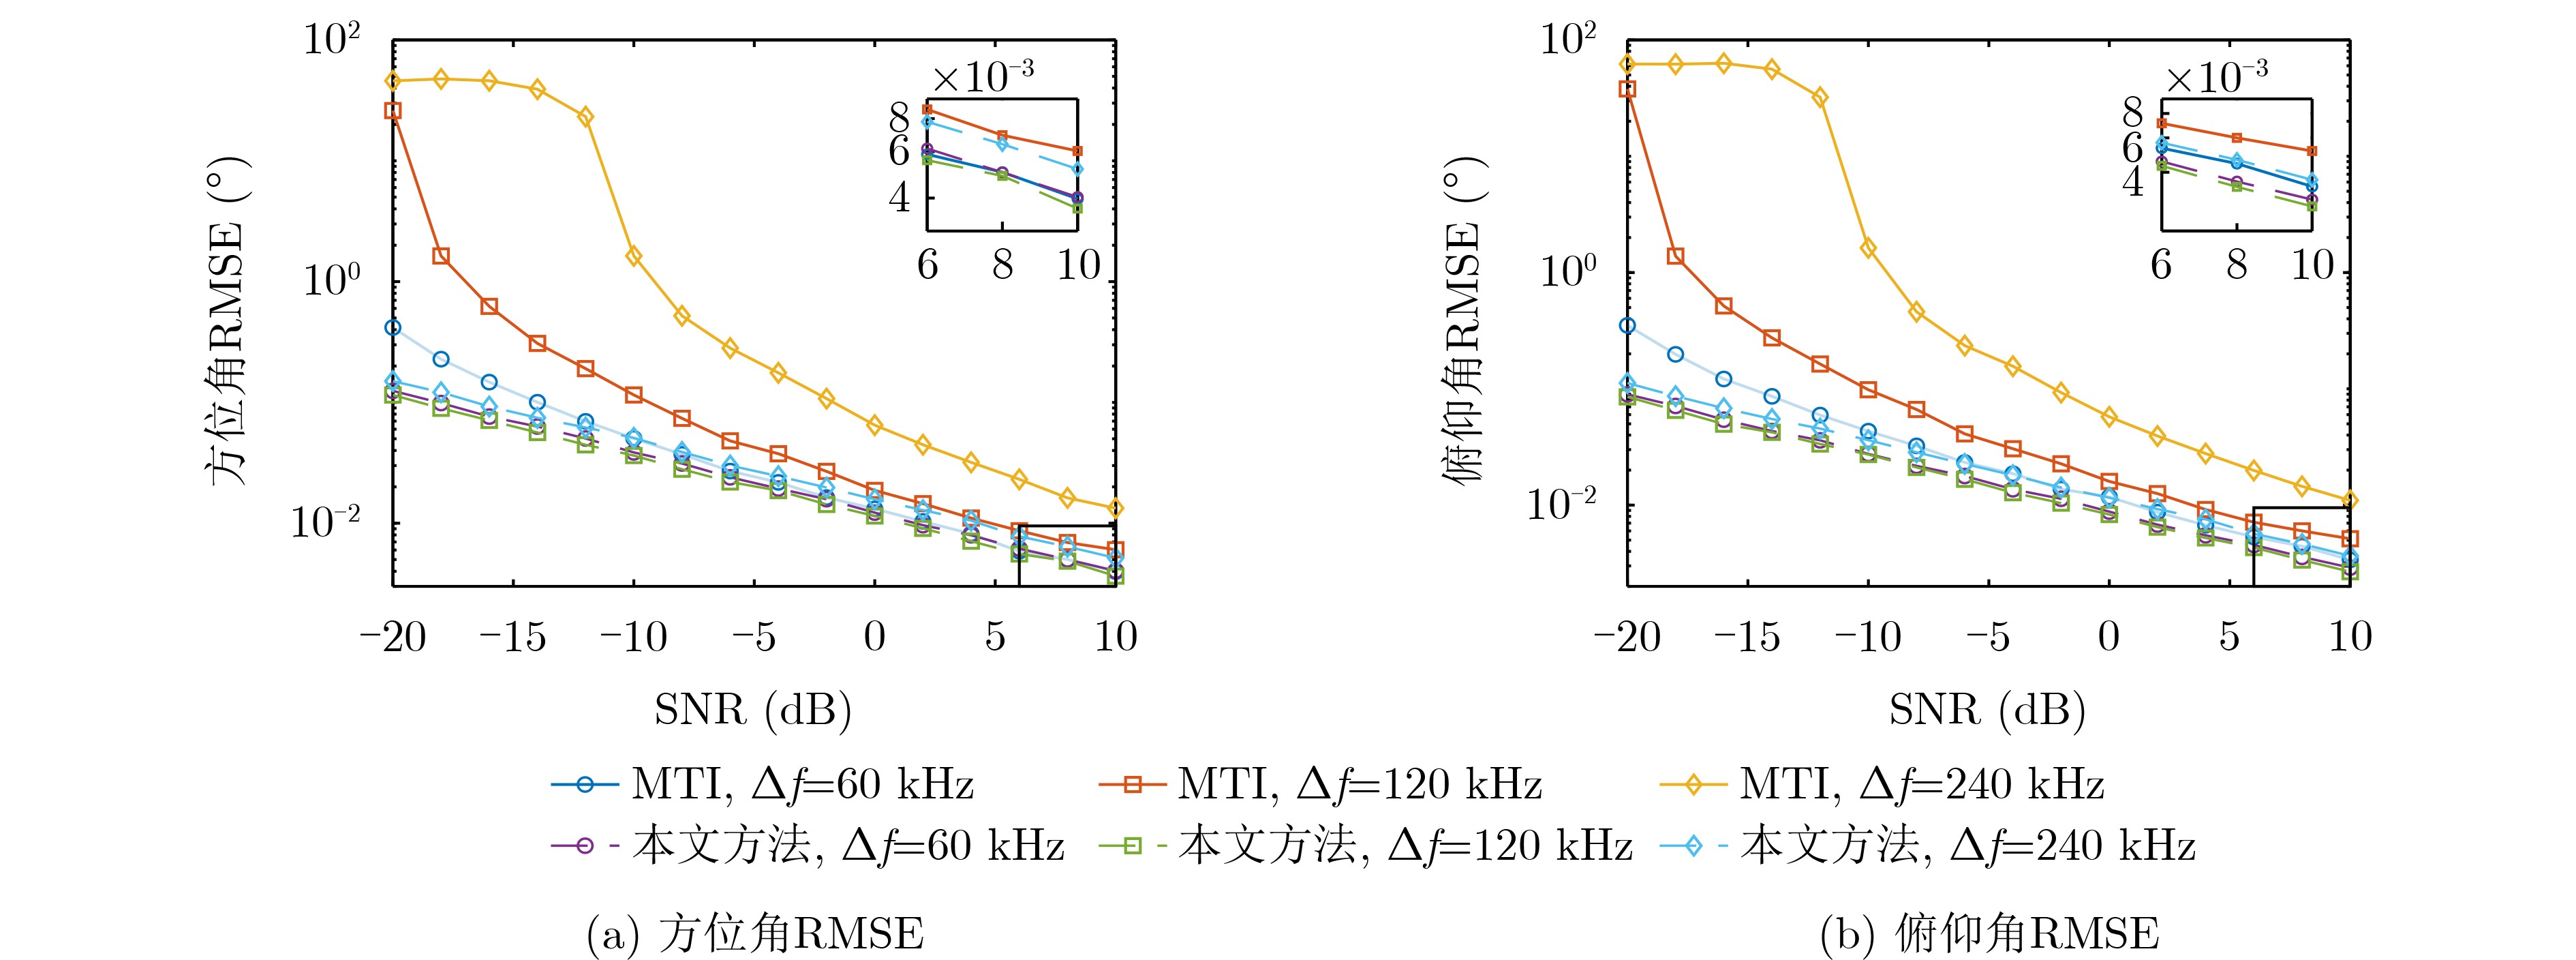
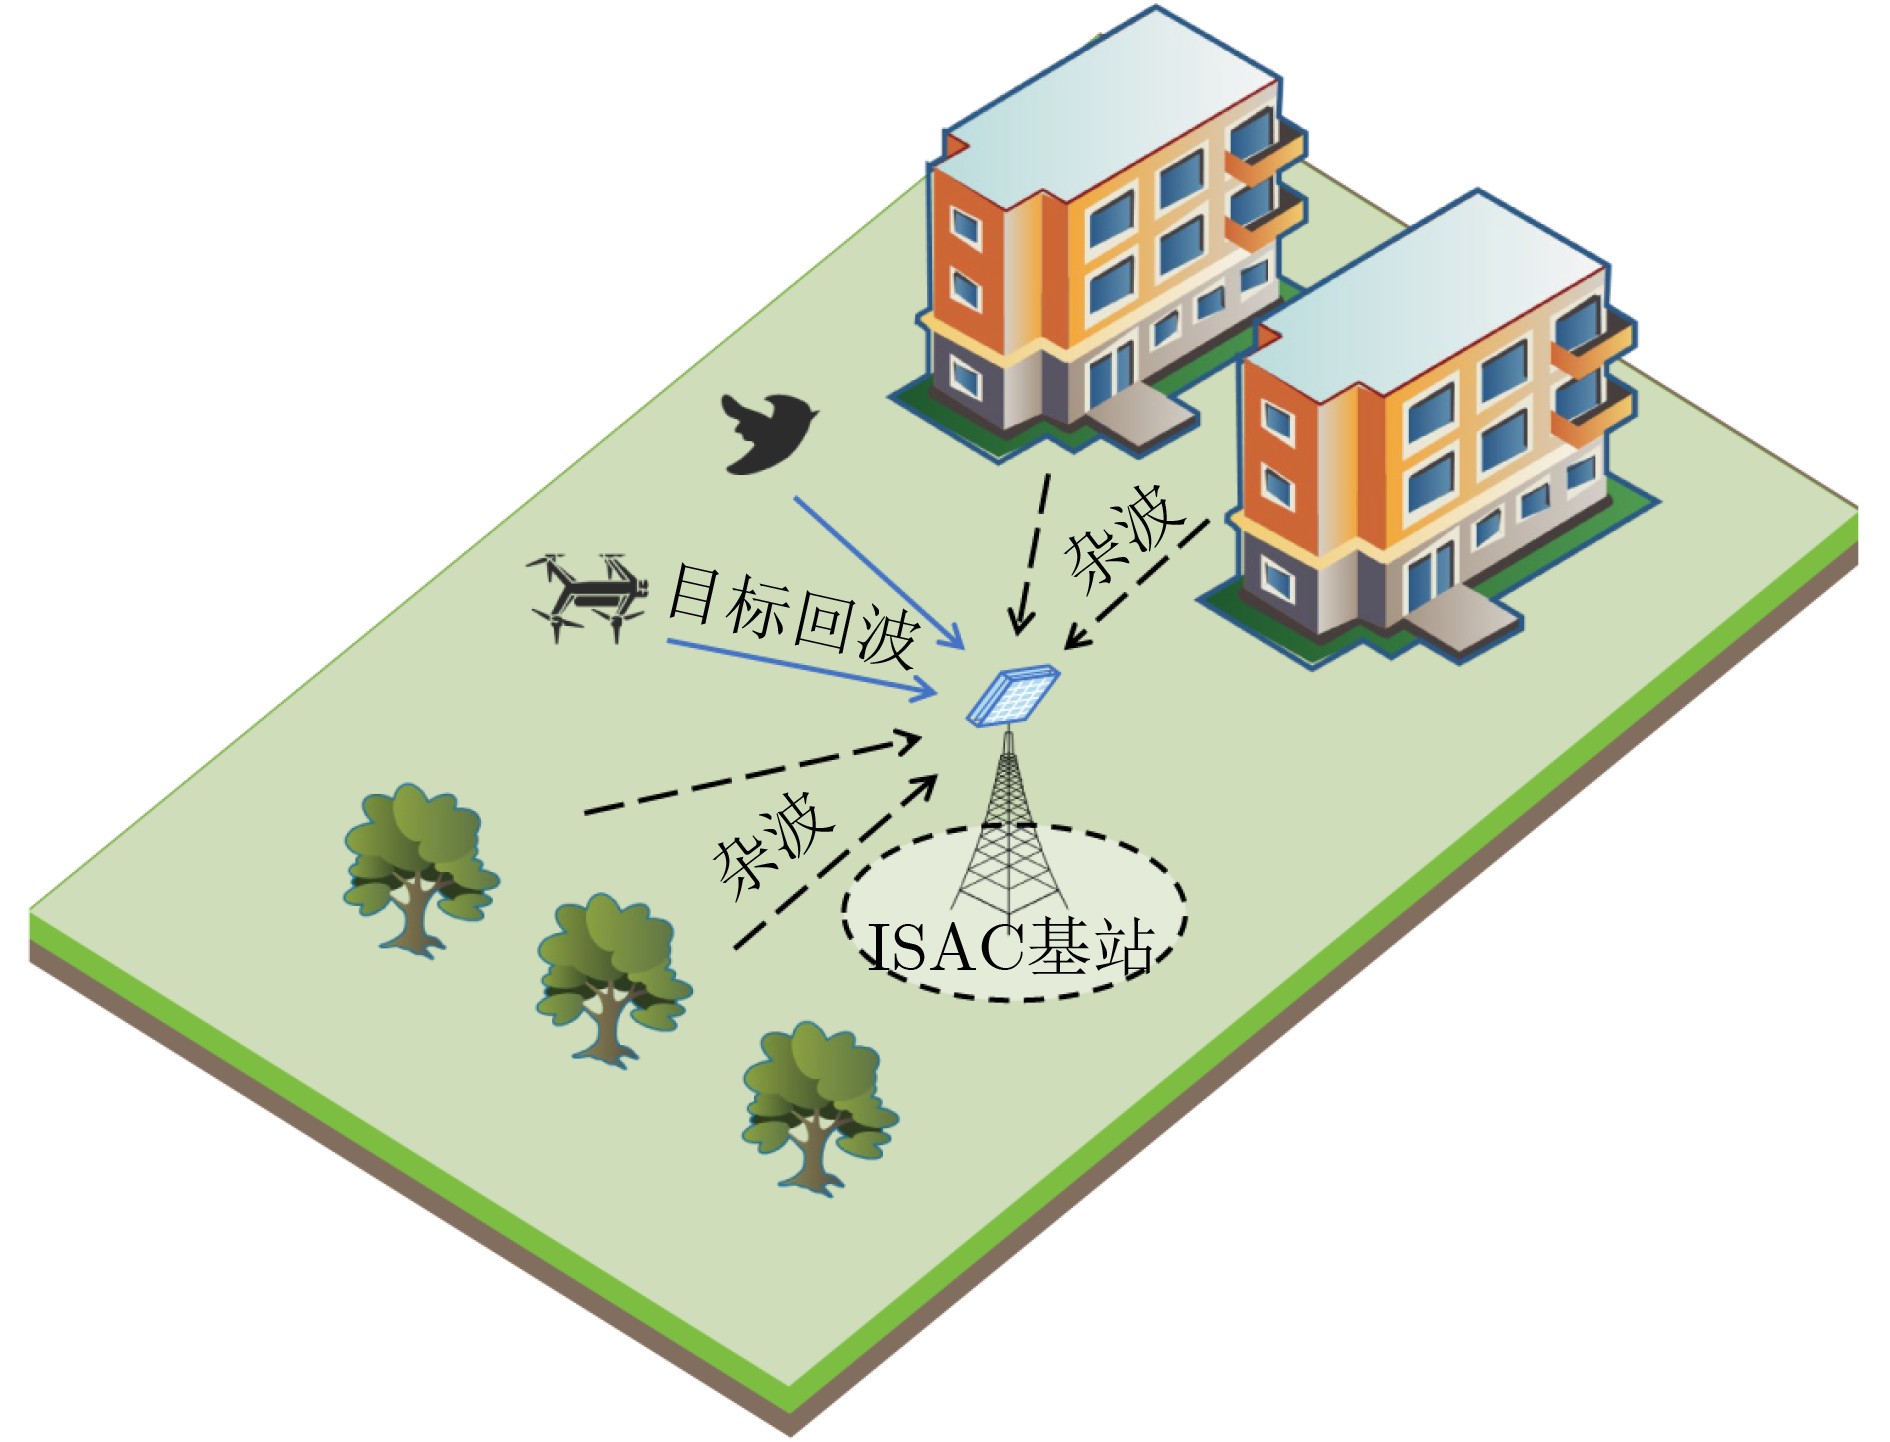
Objective The rapid development of low-altitude logistics, urban air mobility, and security monitoring requires Integrated Sensing And Communication (ISAC) systems to detect weak uncooperative “Low, Slow, and Small” (LSS) targets while reusing communication waveforms and hardware. In practical low-altitude environments, echoes from buildings, towers, and ground facilities can be much stronger than target echoes and may mask targets during range, angle, and Doppler processing. Static clutter exhibits stable directions of arrival and near-zero-Doppler slow-time components. Conventional Moving Target Indication (MTI) suppresses zero-frequency clutter by exploiting Doppler differences, but this strategy may attenuate low-speed targets whose Doppler components overlap with the clutter region and distort micro-Doppler modulation. Spatial nulling based on clutter-angle information preserves low-Doppler components, but it may simultaneously suppress targets when target and clutter directions are closely aligned. Neither approach alone can simultaneously achieve strong clutter suppression, low-speed target preservation, and robustness to angular overlap. Therefore, this study proposes a joint spatial–slow-time clutter suppression method that exploits environmental angular prior information while preserving weak low-speed target signatures. Methods After reception of the MIMO-OFDM sensing echo, down-conversion, digitization, cyclic-prefix removal, and FFT processing are performed. Element-wise division by transmitted communication symbols removes data modulation, and measurements over array elements, subcarriers, and slow-time symbols are stacked into a three-dimensional sensing data matrix. The proposed method consists of offline clutter angle map construction and online two-stage suppression. During the offline stage, inverse FFT along the subcarrier dimension separates range cells from pure clutter measurements. Strong clutter cells are selected, and the corresponding slow-time snapshots are used to construct spatial covariance matrices, from which two-dimensional MUSIC estimates the azimuth and elevation angles of dominant static scatterers. These estimated angles are stored in a CLutter Angle Map (CLAM), which serves as reusable environmental prior information for subsequent clutter suppression. During online sensing, steering vectors associated with the stored angles form a clutter spatial manifold matrix, from which an orthogonal projection operator is derived to remove spatially separable static clutter. To maintain model consistency, steering vectors for subsequent angle estimation are projected using the same operator. When a target direction overlaps or approaches a stored clutter direction, each CLAM angle is individually examined. For each candidate direction, the remaining CLAM directions are treated as interference and suppressed using a normalized local orthogonal projection, while the current direction is retained. This traversal avoids prematurely suppressing an angularly overlapped target and provides candidate slow-time sequences for further discrimination. The residual sequence of each subcarrier is mapped onto the complex I/Q plane, where residual static clutter appears as an approximately fixed DC offset and moving targets form circular arcs due to slow-time phase evolution. Because low target speeds and finite observation intervals may produce only short arcs with limited geometric constraints, Taubin circle fitting estimates the circle center through a normalized generalized eigenvalue problem. The estimated center represents the residual clutter bias and is subtracted from the complex slow-time samples. Thus, CLAM-guided global projection removes spatially separable clutter, while local angular traversal and circle fitting address angular overlap and residual slow-time clutter without modifying the target phase trajectory. Results and Discussions MIMO-OFDM simulations under the ISAC architecture verify the proposed method in several representative scenarios. When target and clutter angles are separated, the proposed method preserves distinct target peaks in the two-dimensional angular spectrum, and the Root Mean Square Error (RMSE) of azimuth and elevation estimation is substantially lower than that of conventional MTI ( Fig. 4 ). When target and clutter angles are close, spatial filtering alone may suppress the target together with the clutter and cause missed detection (Fig. 5 ). The proposed local traversal and circle-fitting stages effectively mitigate this limitation. At a low target speed of 2 m/s, the proposed method reduces the angle-estimation RMSE to a level close to the ideal clutter-free result, outperforming both MTI and CLAM+FFT (Fig. 6 ). It also exhibits lower sensitivity to changes in subcarrier spacing than MTI, indicating improved robustness under different communication-system bandwidth settings (Fig. 7 ). Time-frequency results further show that MTI causes nonlinear distortion and energy loss in target echoes, whereas the proposed method retains the principal translational component and periodic rotor-induced micro-Doppler structures required for fine-grained target characterization (Fig. 8 ).Conclusions The proposed joint spatial–slow-time method provides a target-preserving clutter suppression strategy for ISAC low-altitude sensing by combining environmental angular priors with slow-time bias estimation. It achieves accurate angle estimation in both angularly separated and closely spaced target–clutter scenarios, with a clear advantage for low-speed targets. By estimating and removing residual DC bias through circle fitting instead of Doppler-domain high-pass filtering, it avoids unnecessary target-energy attenuation and preserves micro-Doppler structures required for subsequent classification and recognition. Therefore, the proposed method provides high-fidelity echoes for subsequent low-altitude target perception. Future work will investigate dynamic clutter broadening in measured environments and intelligent target classification using real-world echo data. -
表 1 仿真参数设置
参数名称 数值 载波中心频率$ {f}_{{\mathrm{c}}} $ 28 GHz 系统总带宽$ B $ 30.72 MHz 子载波间隔$ \Delta f $ 60 kHz 子载波数$ K $ 512 符号数$ M $ 64 循环前缀周期$ {T}_{{\mathrm{cp}}} $ 4.167 μs 发射天线数$ {N}_{{\mathrm{t}}} $ 64 接收天线数$ {N}_{{\mathrm{r}}} $ 64  下载: 导出CSV
表 2 杂波参数设置
杂波 距离(m) 信杂比(dB) 方位角(°) 俯仰角(°) 杂波1 50 –40 88.3 29.7 杂波2 100 –40 32.7 48.8 杂波3 150 –40 115.8 –58.2
下载: 导出CSV
表 3 低空目标参数设置
低空目标 距离(m) 方位角(°) 俯仰角(°) 目标1 75 64.4 –31.3 目标2 125 82.8 –47.6 目标3 125 117.8 –56.2
下载: 导出CSV
-
[1] LIU Fan, MASOUROS C, PETROPULU A P, et al. Joint radar and communication design: Applications, state-of-the-art, and the road ahead[J]. IEEE Transactions on Communications, 2020, 68(6): 3834–3862. doi: 10.1109/TCOMM.2020.2973976. [2] 胡杨林, 张天魁, 李博, 等. 无人机使能的通信感知一体化组网与技术研究综述[J]. 电子与信息学报, 2025, 47(4): 859–875. doi: 10.11999/JEIT241116.HU Yanglin, ZHANG Tiankui, LI Bo, et al. A survey on UAV-enabled integrated sensing and communication networking and technologies[J]. Journal of Electronics & Information Technology, 2025, 47(4): 859–875. doi: 10.11999/JEIT241116. [3] 卓浩泽, 张驰, 李泰霖, 等. 面向电力作业无人机的位姿估计与目标感知方法[J]. 南方电网技术, 2025, 19(7): 140–149. doi: 10.13648/j.cnki.issn1674-0629.2025.07.012.ZHUO Haoze, ZHANG Chi, LI Tailin, et al. Pose Estimation and Target Perception Methods for Electric Power Operation Unmanned Aerial Vehicles[J]. Southern Power System Technology, 2025, 19(7): 140–149. doi: 10.13648/j.cnki.issn1674-0629.2025.07.012. [4] 叶采萍, 陈炯, 马显龙, 等. 改进YOLOv5的变电站反无人机目标检测算法[J]. 南方电网技术, 2024, 18(2): 89–97. doi: 10.13648/j.cnki.issn1674-0629.2024.02.010.YE Caiping, CHEN Jiong, MA Xianlong, et al. Anti UAV Target Detection Algorithm for Substation Based on Improved YOLOv5[J]. Southern Power System Technology, 2024, 18(2): 89–97. doi: 10.13648/j.cnki.issn1674-0629.2024.02.010. [5] ZHANG Hao, WEI Shunjun, MIN Rui, et al. Robust FMCW radar clutter suppression for UAV detection via learning physics-informed priors[J]. IEEE Transactions on Aerospace and Electronic Systems, 2026, 62: 6180–6195. doi: 10.1109/TAES.2026.3664357. [6] HOU Huiling, YANG Zhiliang, and PANG Cunsuo. Rotor UAV’s micro-Doppler signal detection and parameter estimation based on FRFT-FSST[J]. Sensors, 2021, 21(21): 7314. doi: 10.3390/s21217314. [7] CHEN V C, LI Fayin, HO S S, et al. Micro-Doppler effect in radar: Phenomenon, model, and simulation study[J]. IEEE Transactions on Aerospace and Electronic Systems, 2006, 42(1): 2–21. doi: 10.1109/TAES.2006.1603402. [8] 陈小龙, 陈唯实, 饶云华, 等. 飞鸟与无人机目标雷达探测与识别技术进展与展望[J]. 雷达学报, 2020, 9(5): 803–827. doi: 10.12000/JR20068.CHEN Xiaolong, CHEN Weishi, RAO Yunhua, et al. Progress and prospects of radar target detection and recognition technology for flying birds and unmanned aerial vehicles[J]. Journal of Radars, 2020, 9(5): 803–827. doi: 10.12000/JR20068. [9] ZHANG Ruihang, XUE Jiayin, and ZHANG Tingting. Reliable clutter suppression for slow-moving weak target radar detection[C]. The 2025 IEEE International Conference on Communications Workshops (ICC Workshops), Montreal, Canada, 2025: 354–359. doi: 10.1109/ICCWorkshops67674.2025.11162253. [10] GUO Yifan, LIAO Guisheng, LI Jun, et al. A clutter suppression method based on NSS-RPCA in heterogeneous environments for SAR-GMTI[J]. IEEE Transactions on Geoscience and Remote Sensing, 2020, 58(8): 5880–5891. doi: 10.1109/TGRS.2020.2972060. [11] LIU Qi, SONG Meng, YU Jinghan, et al. A circular fitting clutter suppression algorithm based on ISAC for low altitude UAVs[J]. Sensors, 2025, 25(20): 6285. doi: 10.3390/s25206285. [12] 张杰, 朱宇, 王洋. 微多普勒辅助的城市环境无人机编队检测方法[J]. 电子与信息学报, 2024, 46(9): 3583–3591. doi: 10.11999/JEIT240203.ZHANG Jie, ZHU Yu, and WANG Yang. Micro-Doppler-assisted unmanned aerial vehicle formation detection method in urban environments[J]. Journal of Electronics & Information Technology, 2024, 46(9): 3583–3591. doi: 10.11999/JEIT240203. [13] LIU Fan, MASOUROS C, LI Ang, et al. MU-MIMO communications with MIMO radar: From co-existence to joint transmission[J]. IEEE Transactions on Wireless Communications, 2018, 17(4): 2755–2770. doi: 10.1109/TWC.2018.2803045. [14] 刘昆, 贺雄鹏, 廖桂生, 等. 面向复杂场景的多通道慢速动目标稳健检测算法[J]. 电子与信息学报, 2024, 46(5): 2018–2027. doi: 10.11999/JEIT230958.LIU Kun, HE Xiongpeng, LIAO Guisheng, et al. A robust multi-channel moving target detection algorithm for complex scenes[J]. Journal of Electronics & Information Technology, 2024, 46(5): 2018–2027. doi: 10.11999/JEIT230958. [15] LEE N, PARK H, KIM H, et al. ISAC-STAP: Space-time adaptive processing for ISAC systems[C]. The 2024 IEEE Globecom Workshops (GC Wkshps), Cape Town, South Africa, 2024: 1–5. doi: 10.1109/GCWkshp64532.2024.11101537. [16] ZENG Yong and XU Xiaoli. Toward environment-aware 6G communications via channel knowledge map[J]. IEEE Wireless Communications, 2021, 28(3): 84–91. doi: 10.1109/MWC.001.2000327. [17] XU Zihan, ZHOU Zhiwen, WU Di, et al. Channel knowledge map-enhanced clutter suppression for integrated sensing and communication[C]. The 2024 IEEE/CIC International Conference on Communications in China (ICCC Workshops), Hangzhou, China, 2024: 90–95. doi: 10.1109/ICCCWorkshops62562.2024.10693799. [18] XU Zihan, ZHOU Zhiwen, WU Di, et al. CKM-enabled joint spatial--Doppler domain clutter suppression for low-altitude UAV ISAC[J]. IEEE Internet of Things Journal, 2026, 13(14): 31752–31767. doi: 10.1109/JIOT.2026.3689485. -

 下载:



图(8) / 表(3)
计量
- 文章访问数: 182
- HTML全文浏览量: 46
- PDF下载量: 4
- 被引次数: 0
