



A State Prediction Method for Long-Endurance Fixed-Wing UAV Propulsion Systems
-
摘要: 面向长航时固定翼无人机推进系统关键状态预测的工程应用需求,该文优化设计出一种融合多尺度嵌入与分组通道注意力的时序卷积模型(Grouped Squeeze-and-Excitation Multi-Scale Temporal Convolutional Networks, GEMS-TCN)。该模型采用多尺度嵌入层自适应提取短期波动与长期趋势的混合时序表征,通过分组通道注意力实现变量内与跨变量特征的层次化加权。基于实飞数据集的实验结果表明,GEMS-TCN在推进系统16维关键状态的单步预测精度优越,测试集中平均绝对误差(Mean Absolute Error, MAE)、均方误差(Mean Squared Error, MSE)分别达到0.171, 0.069,且在不同特征及昼夜工况下均保持一致的精度优势,为固定翼无人机推进系统多维状态预测提供了切实可行且性能优异的实现方案。Abstract:
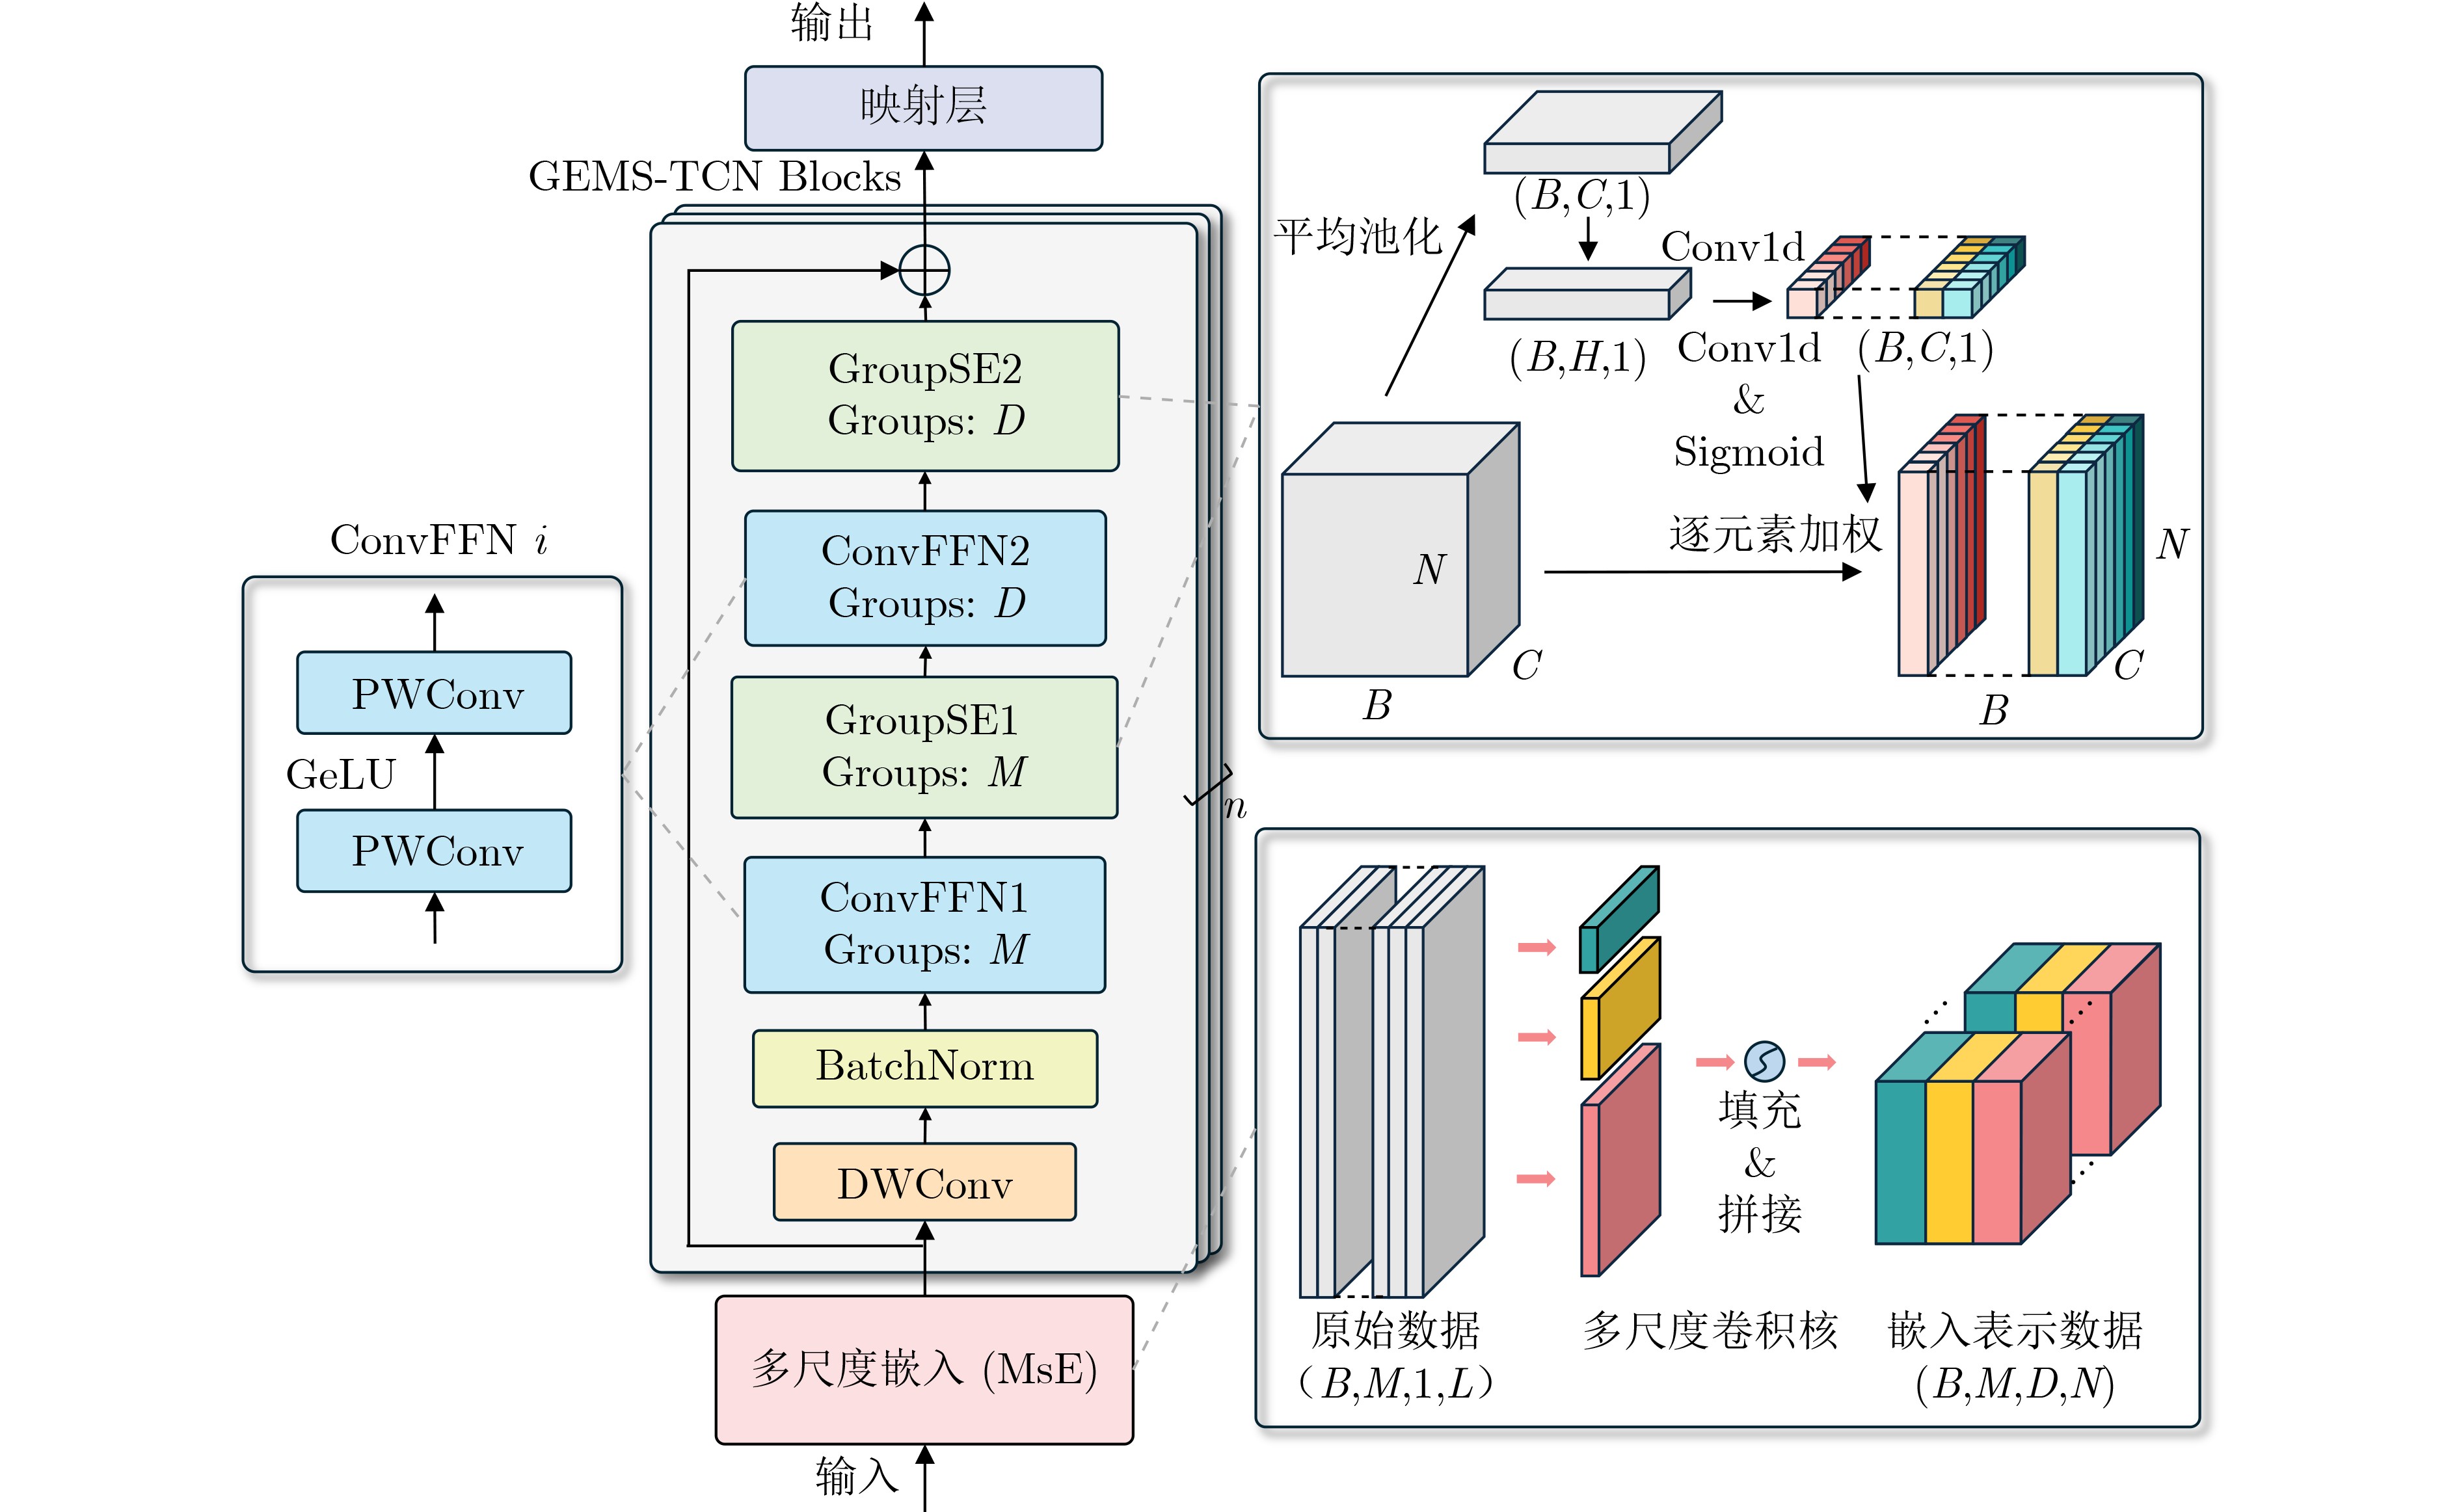
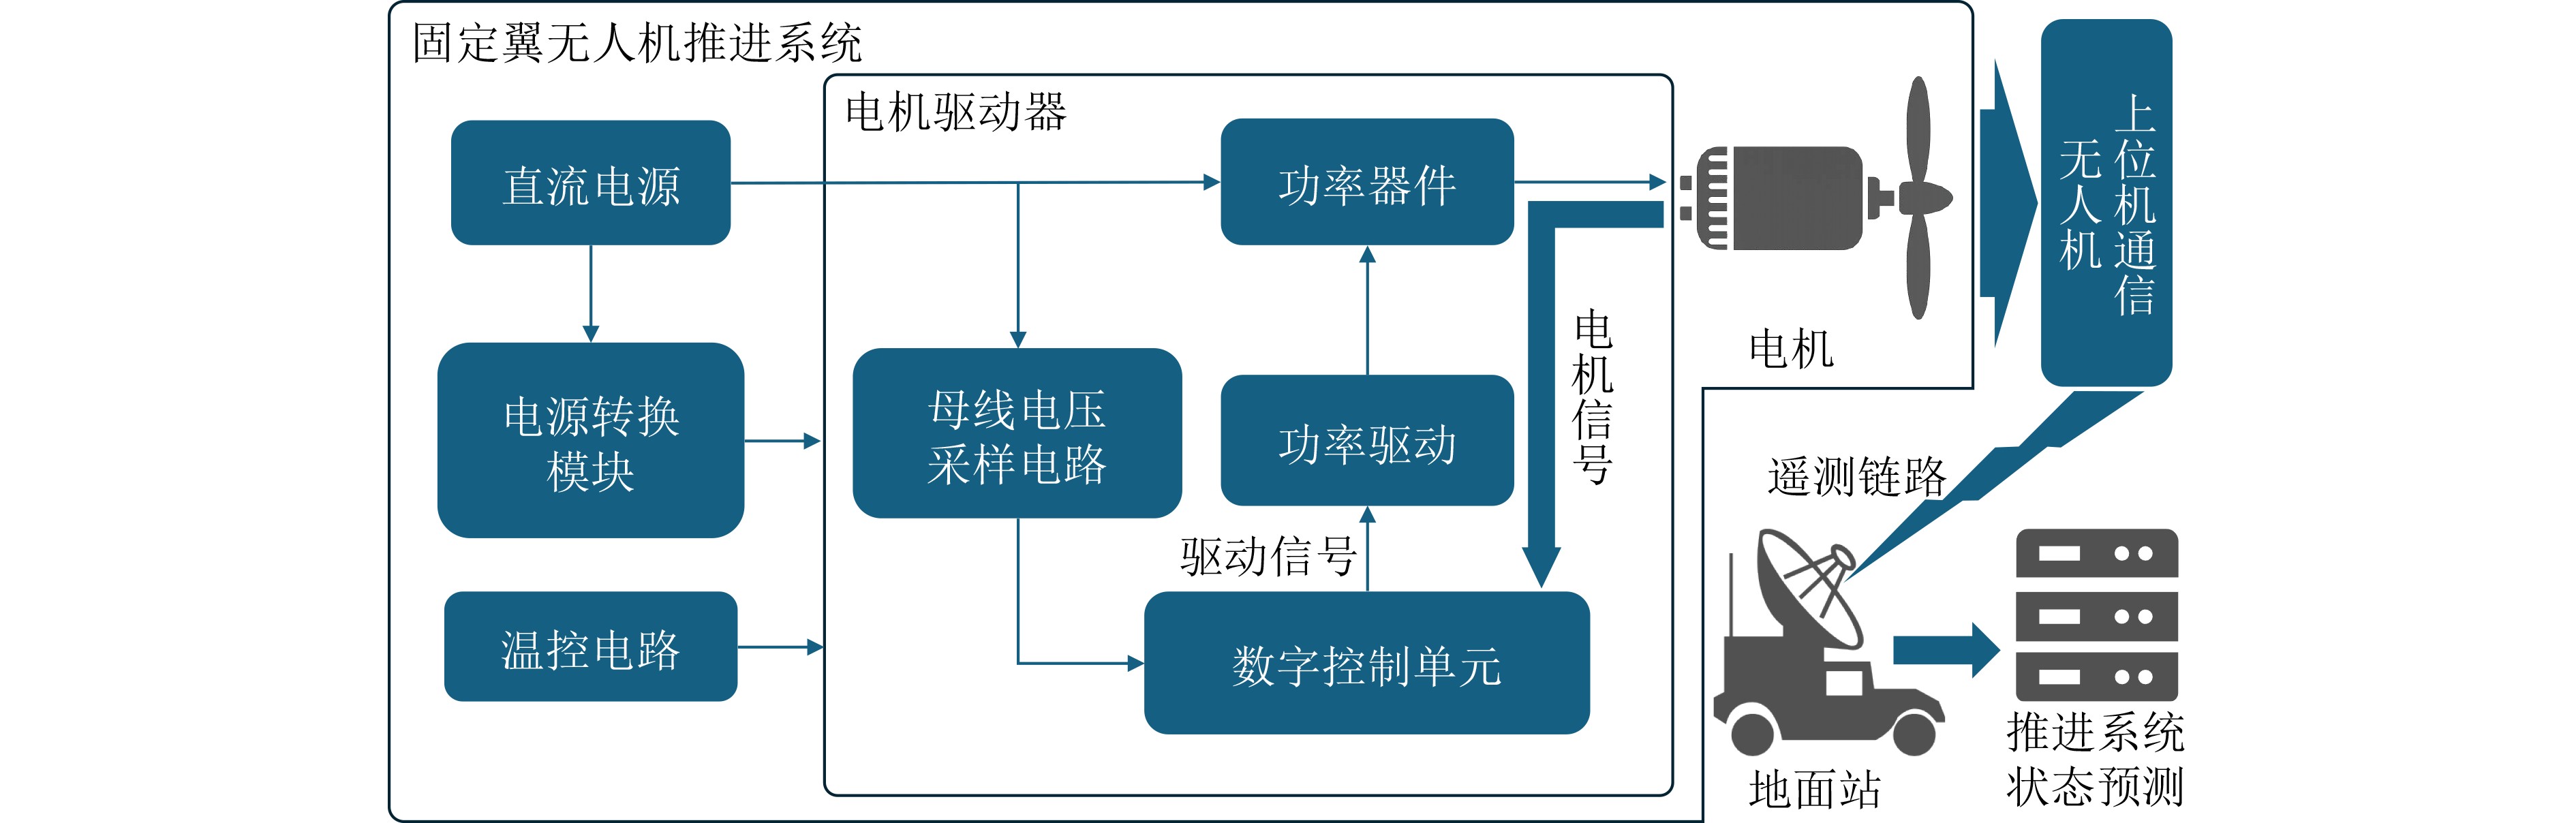
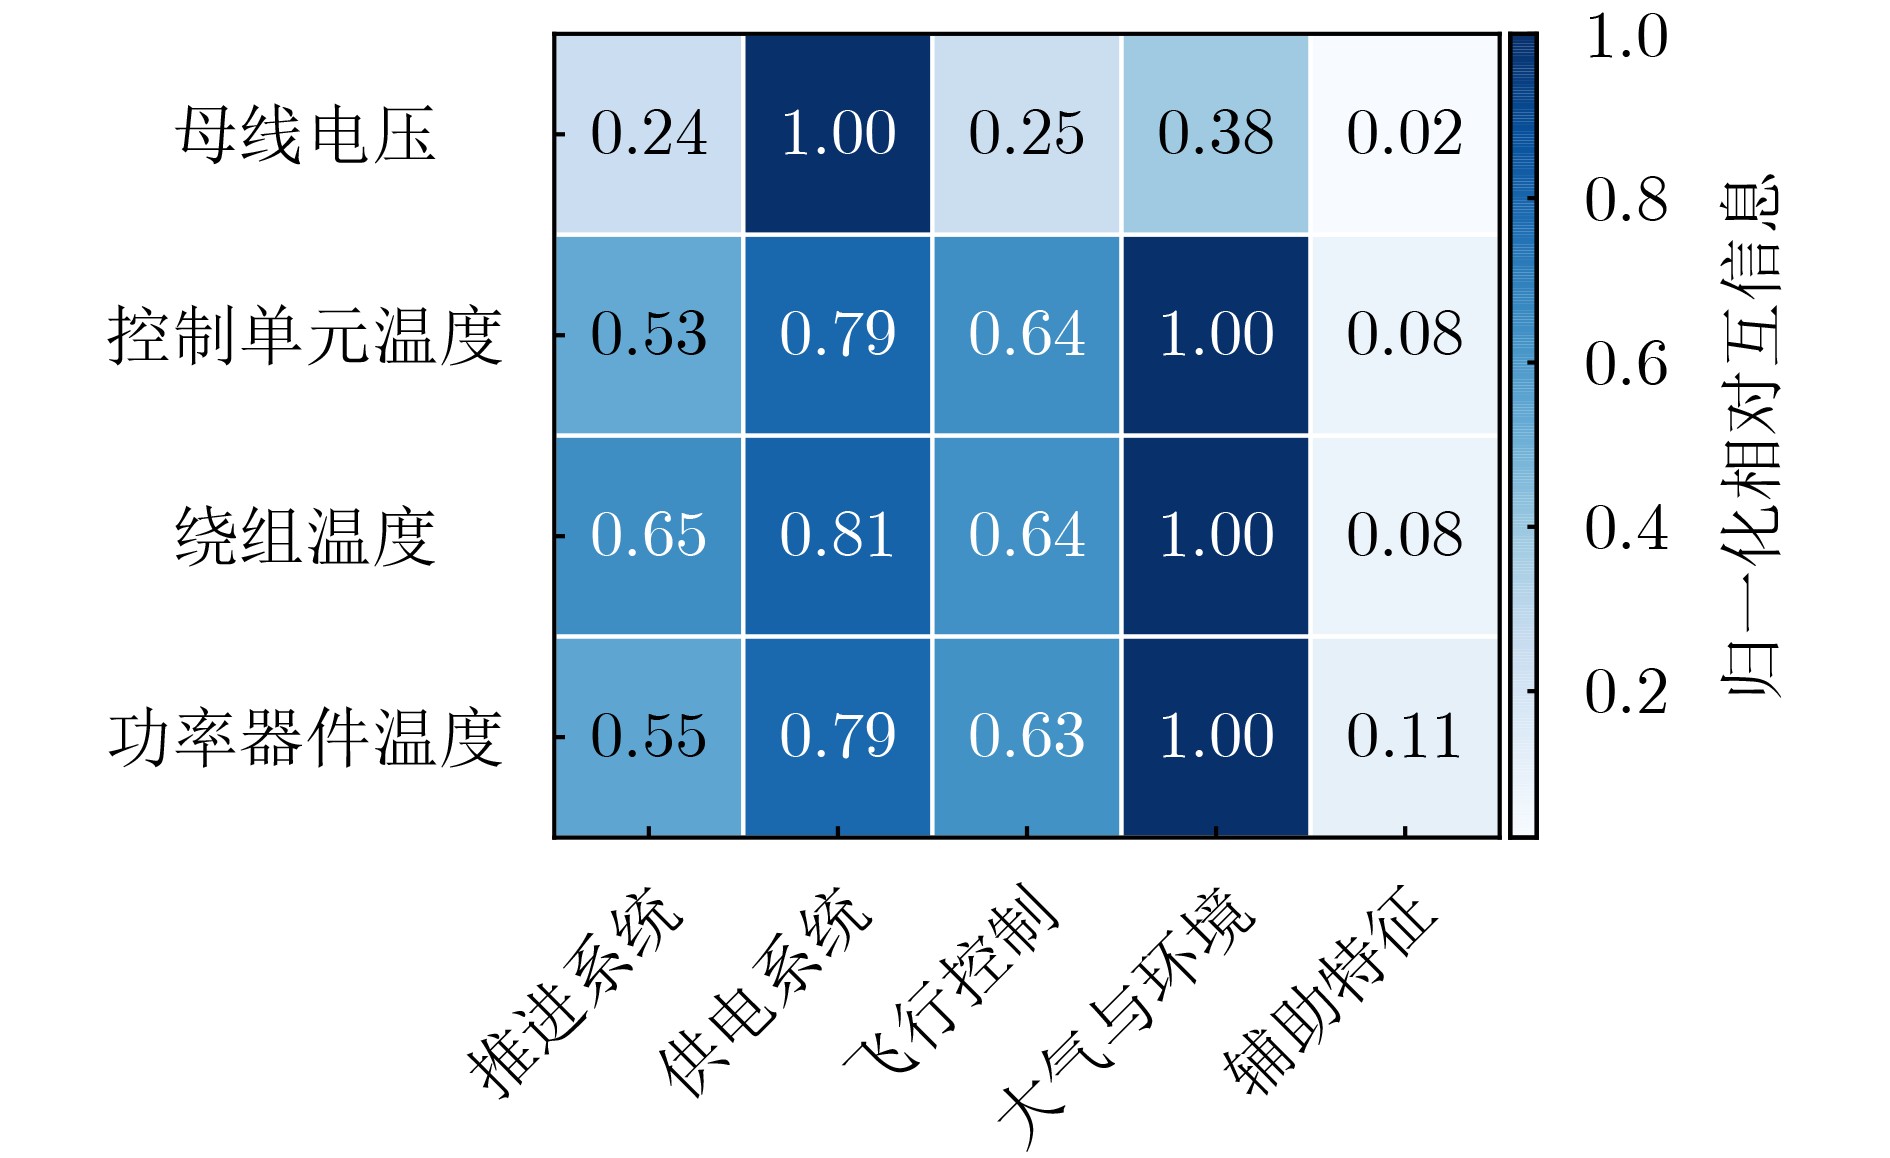
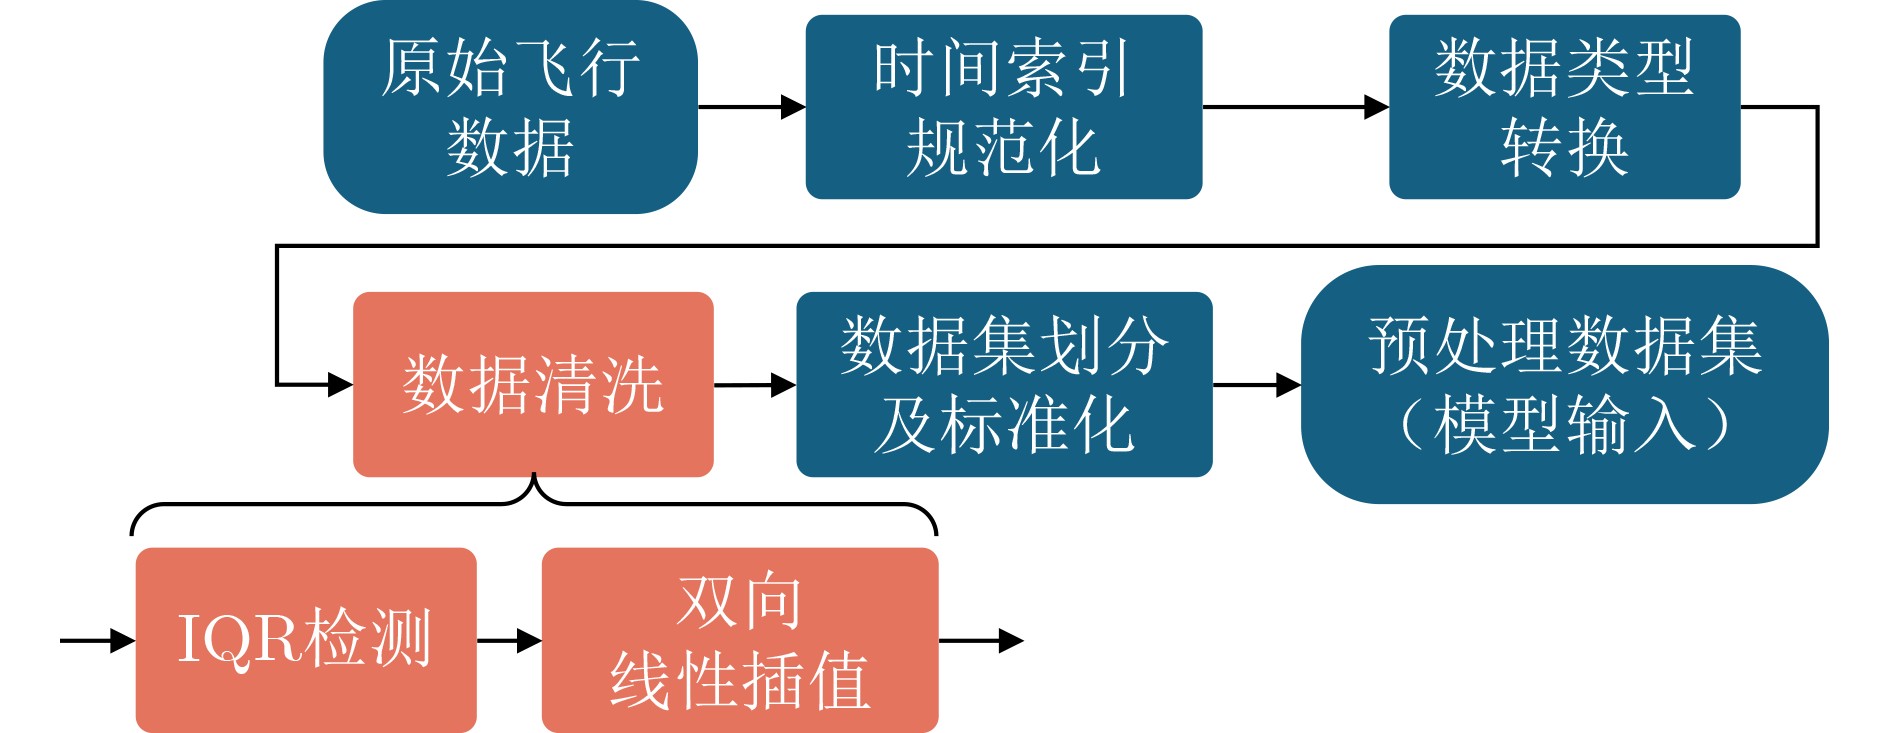
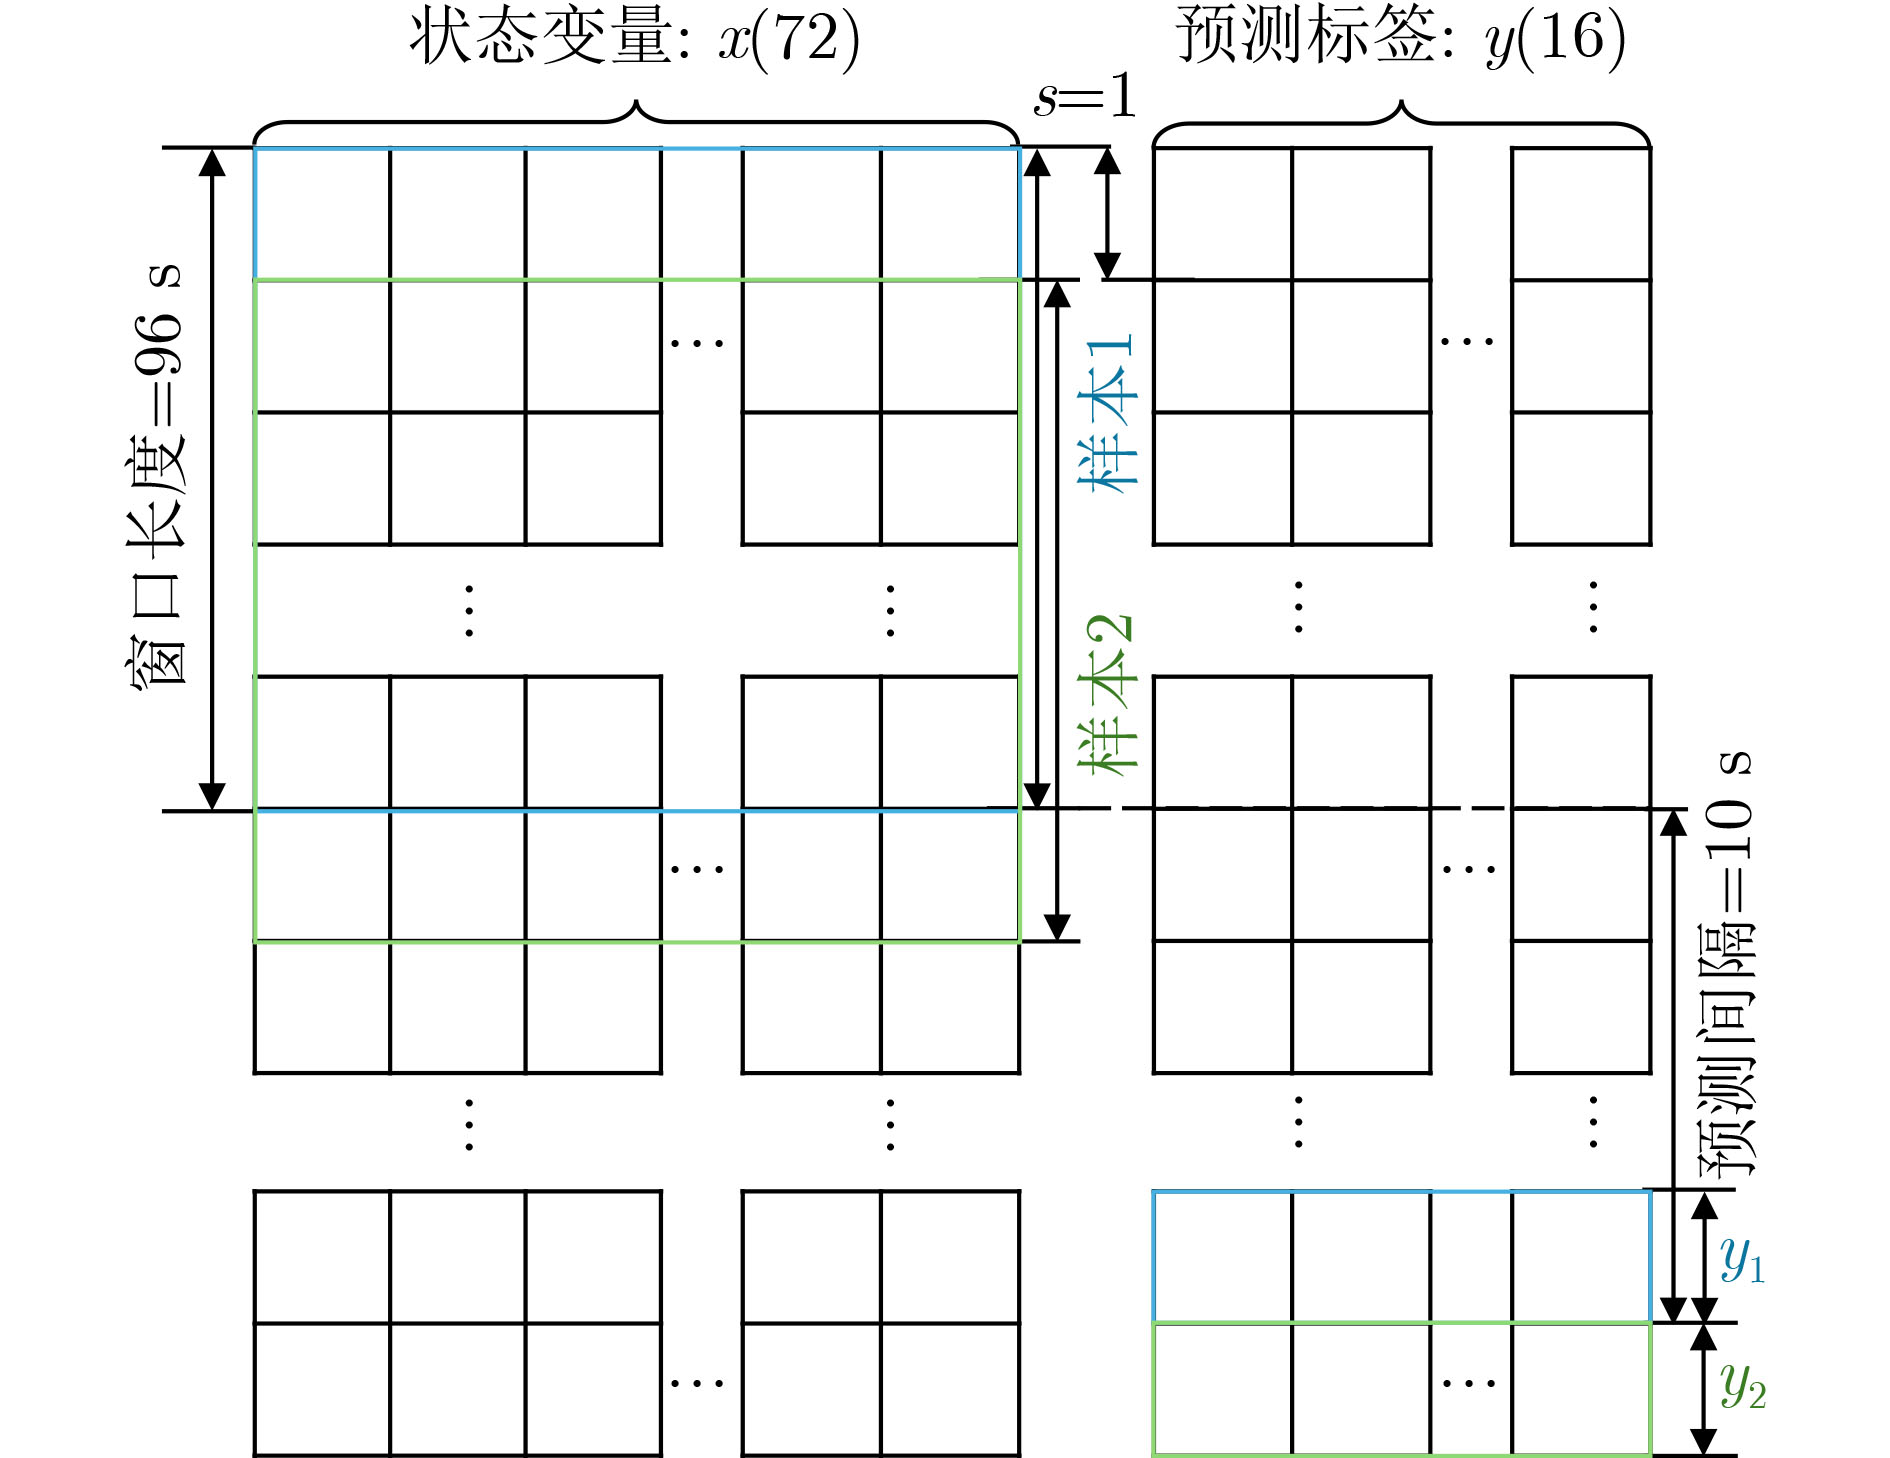
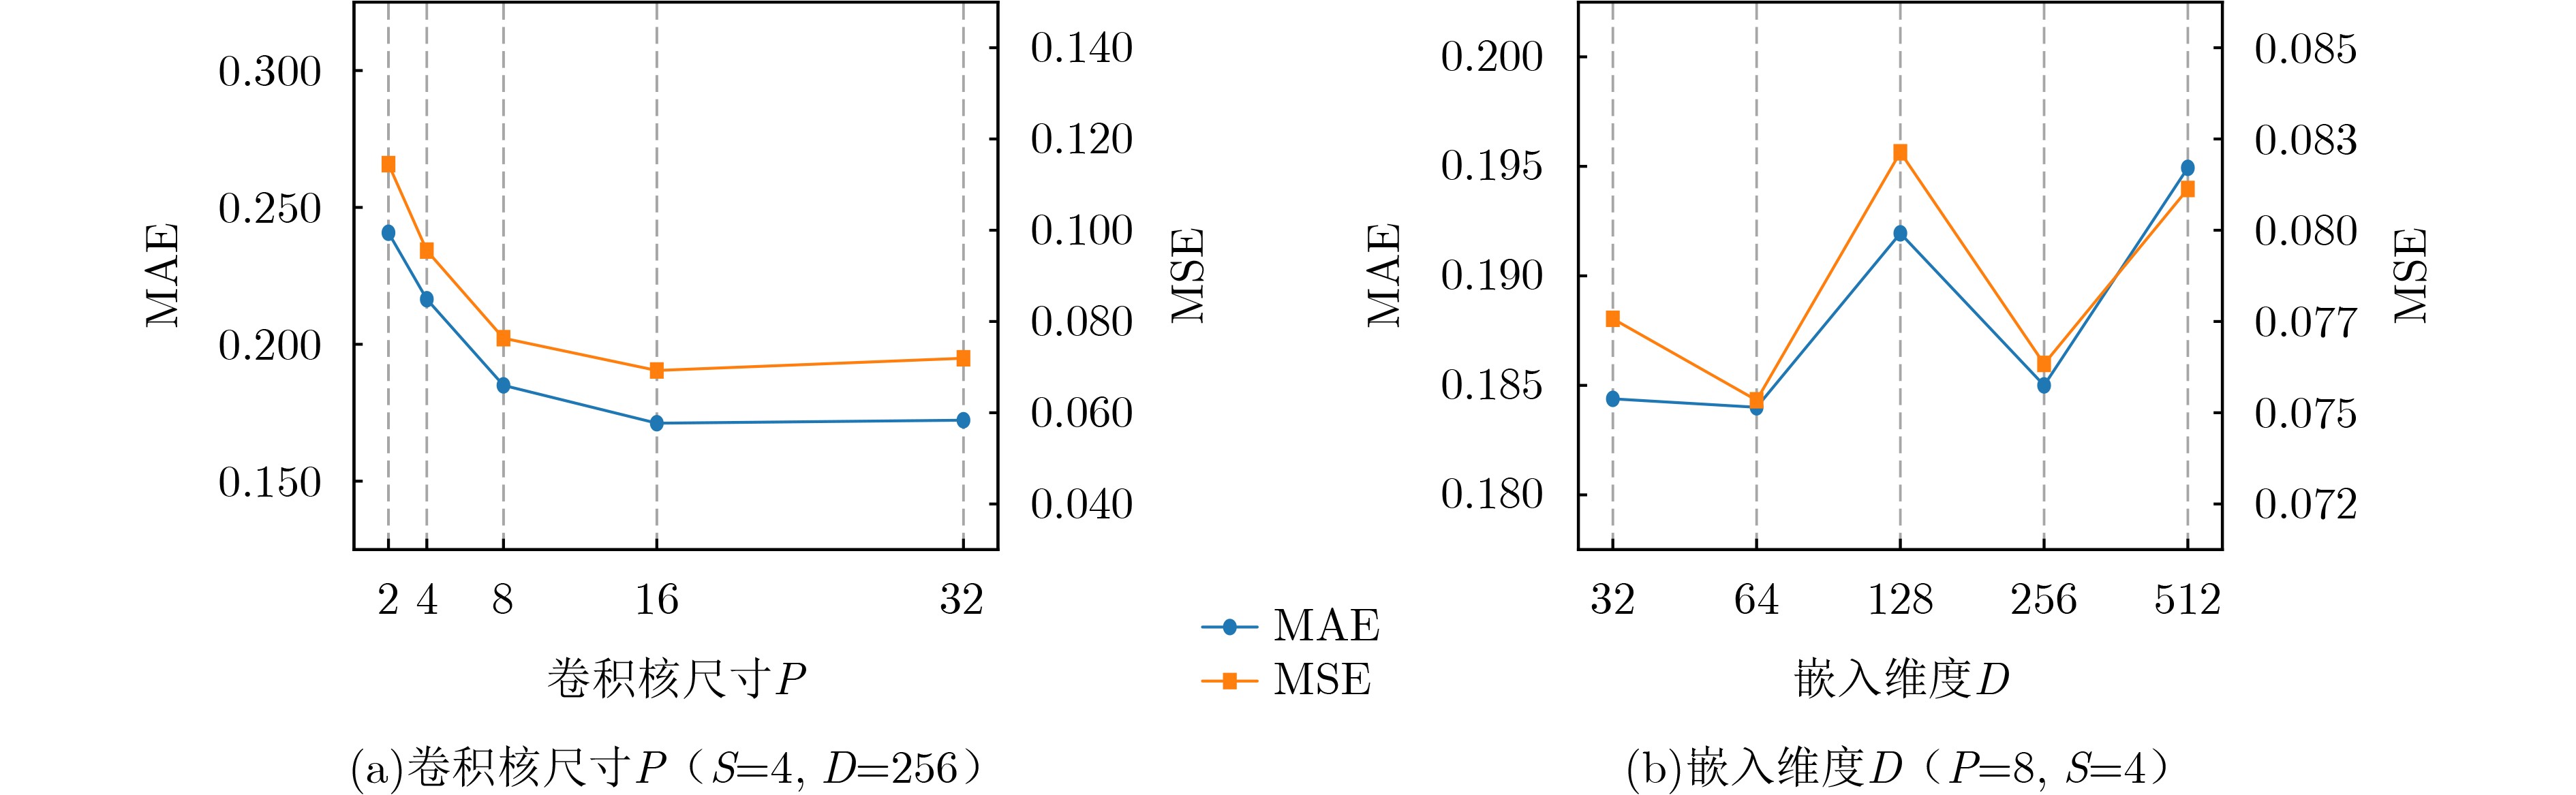
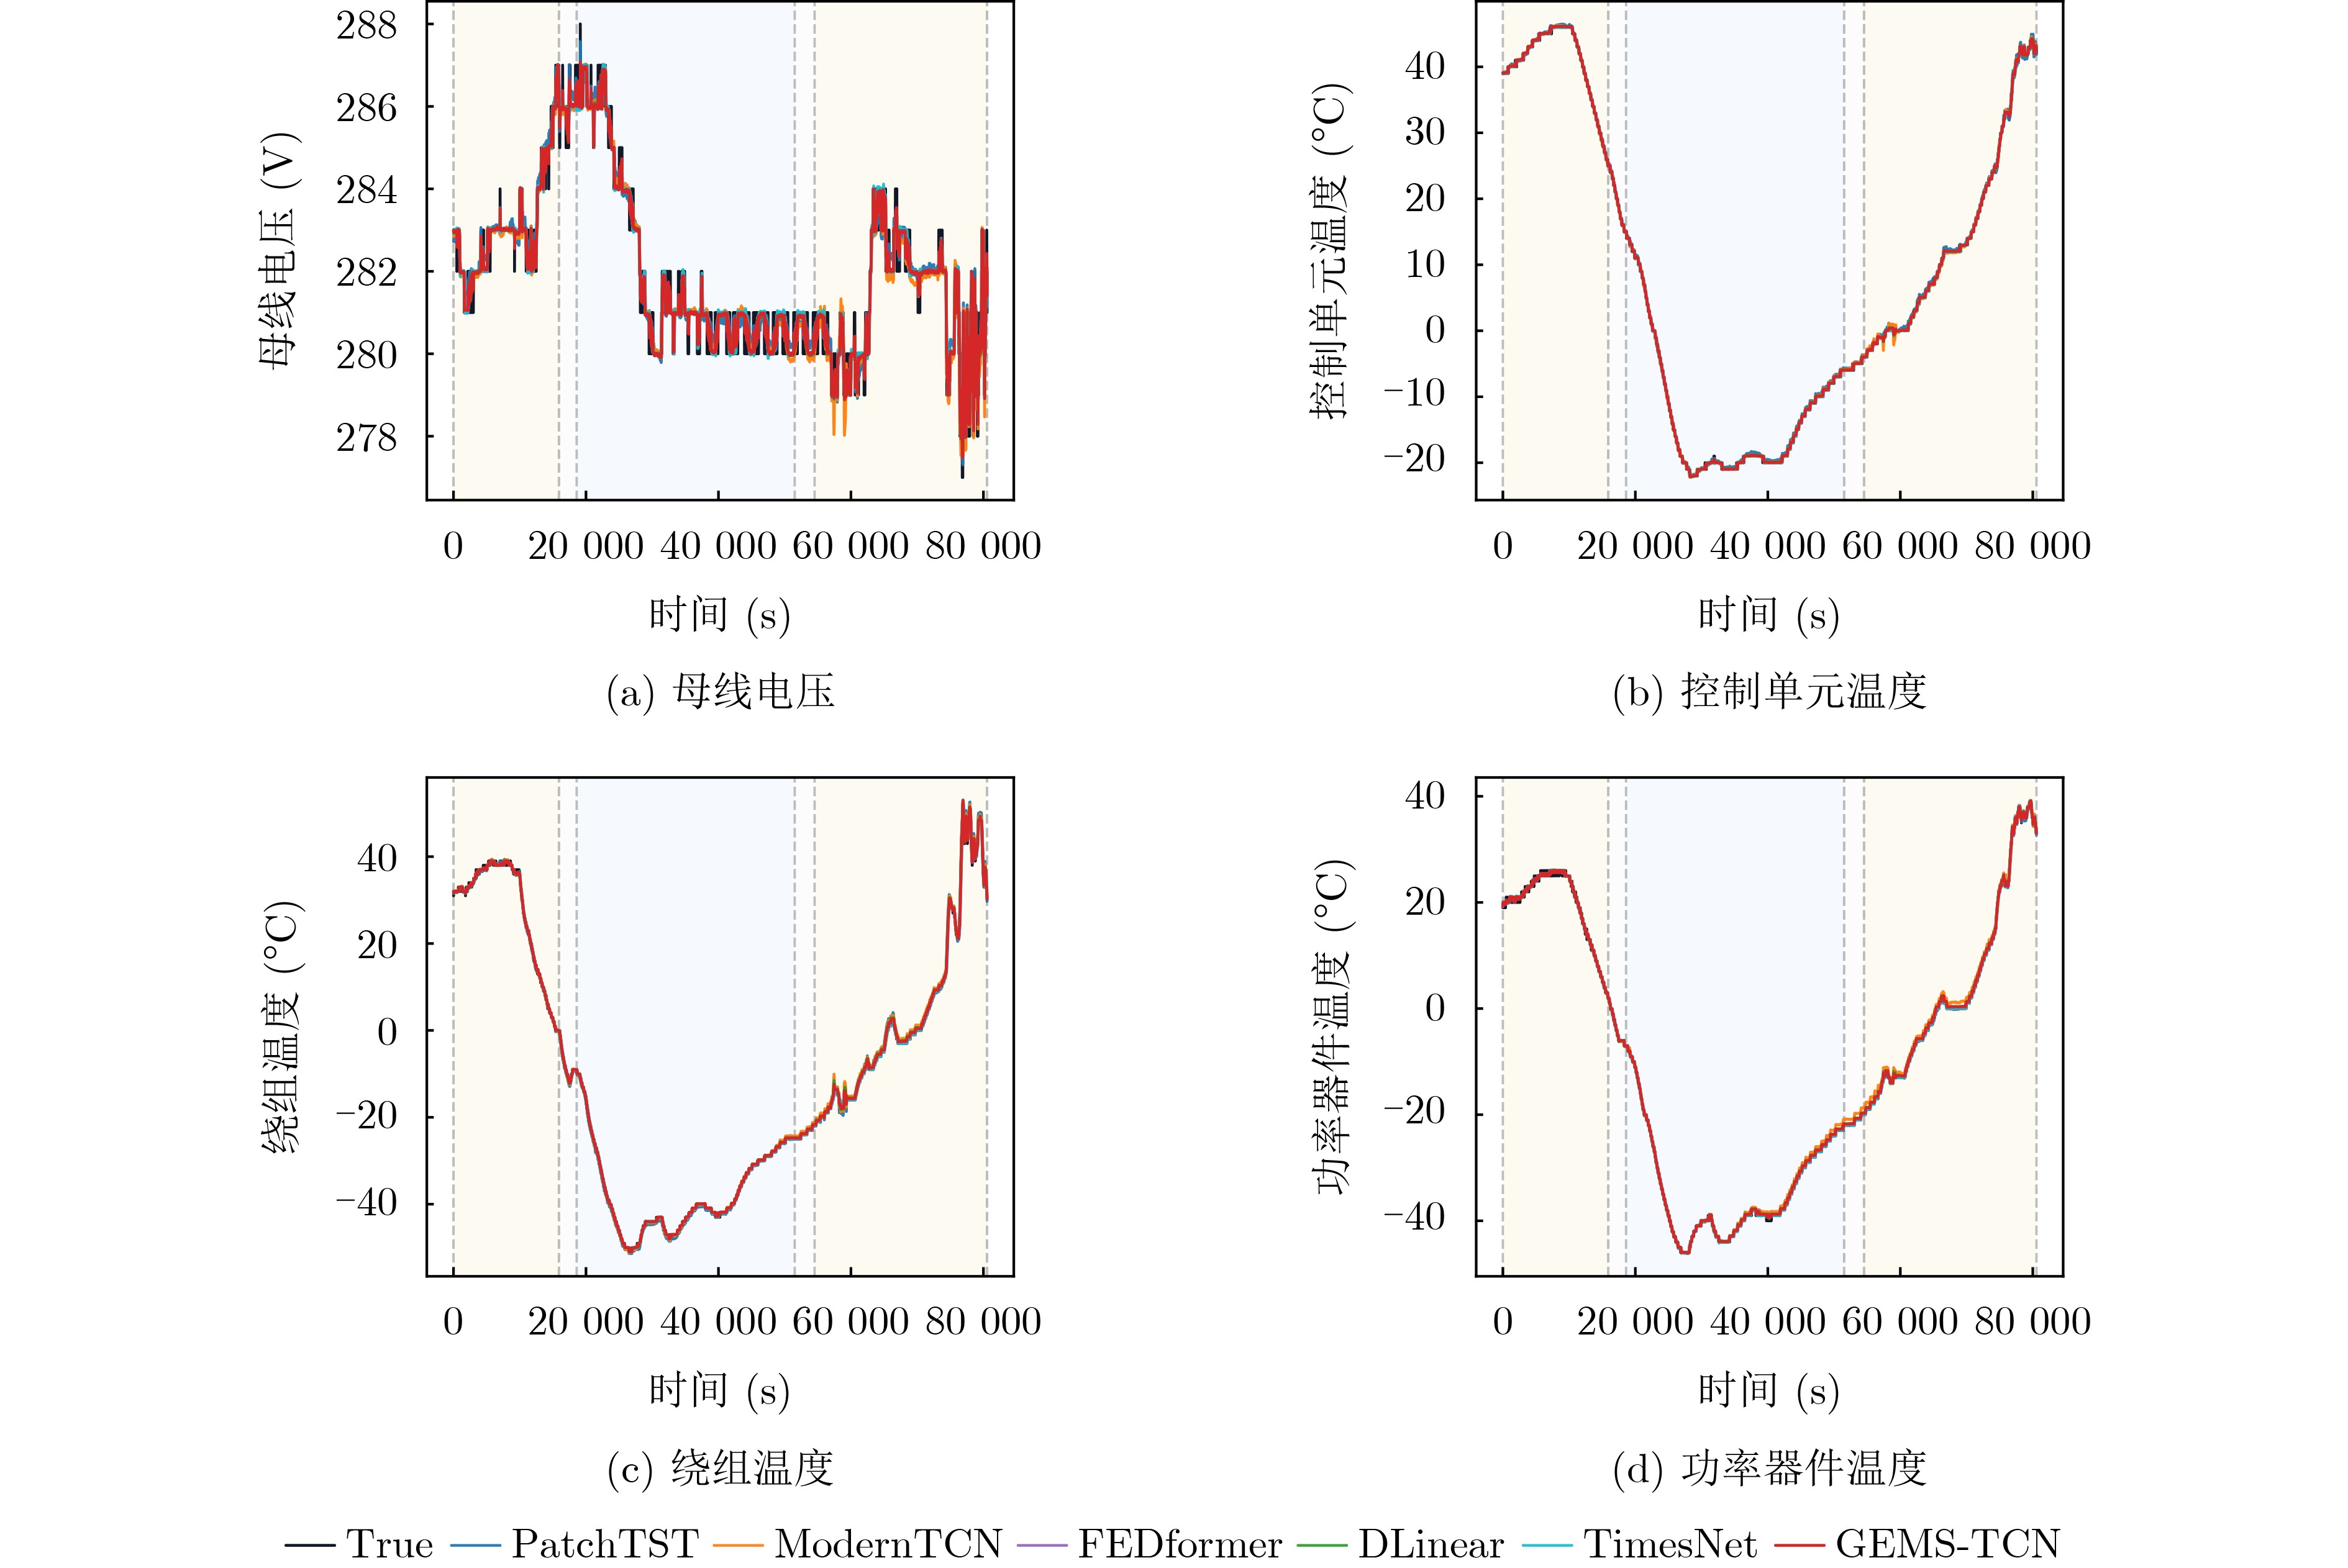
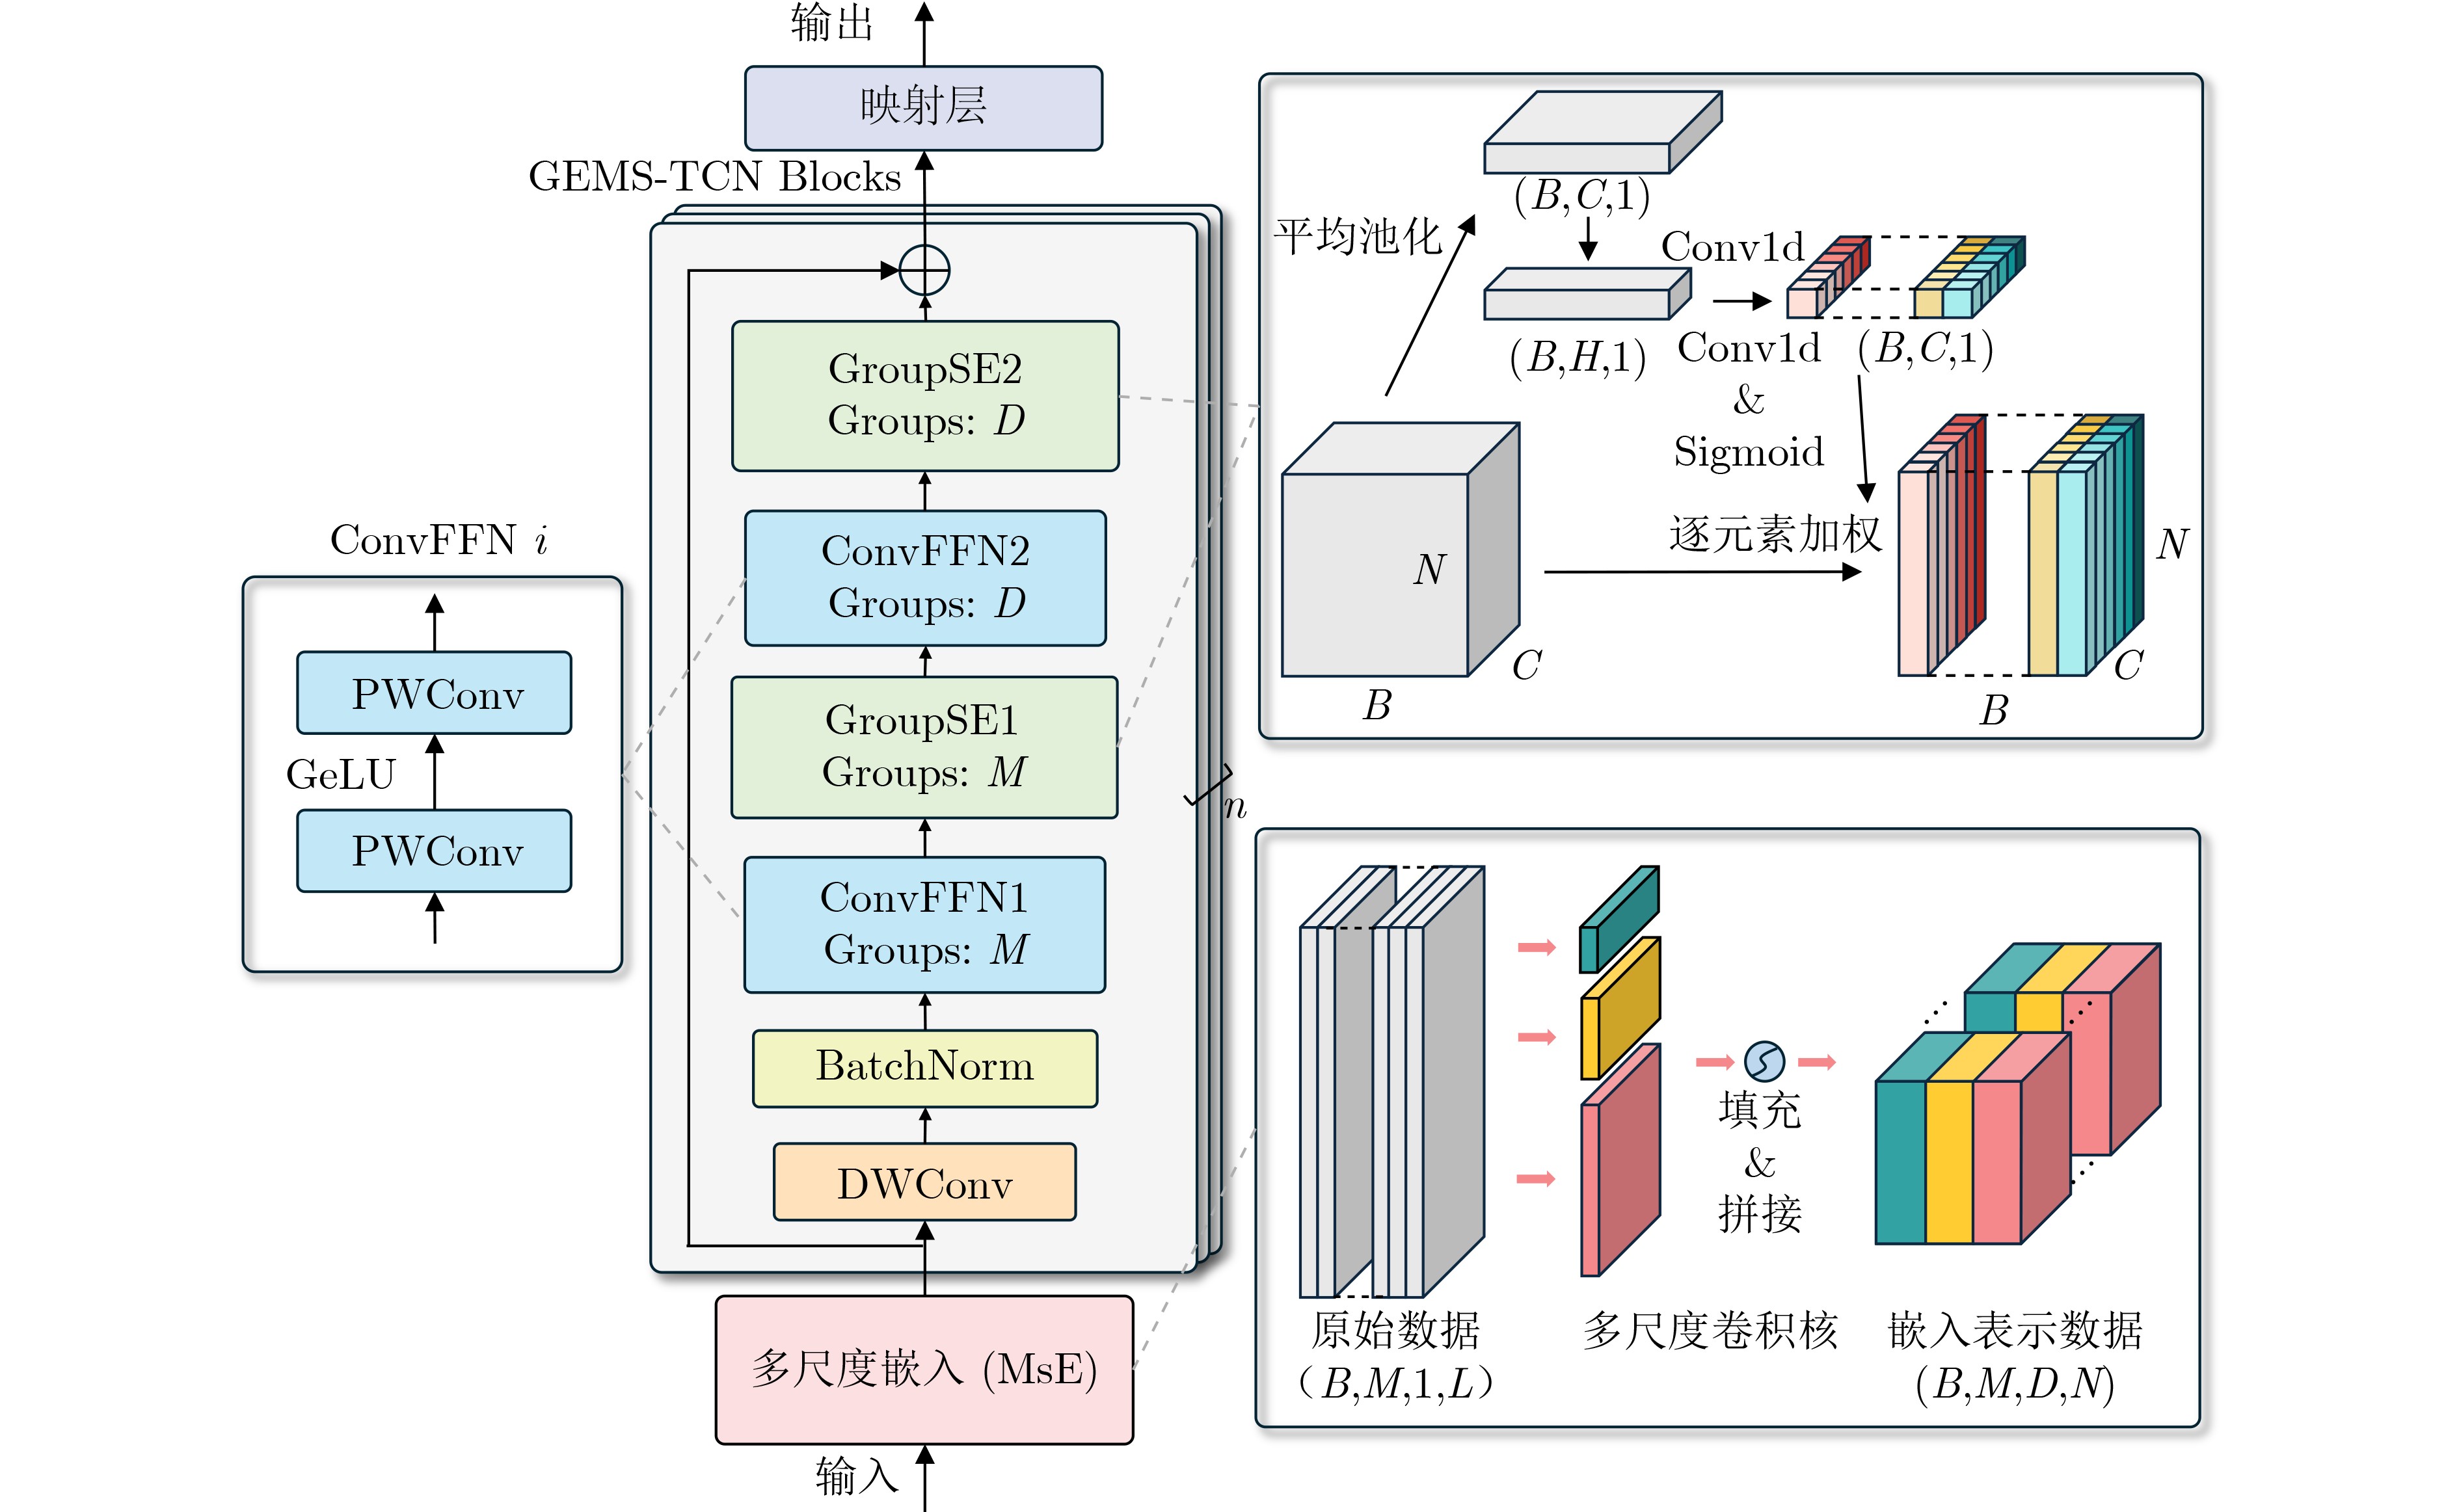
Objective Accurate single-step prediction of key propulsion-system states is essential for early fault warning and autonomous health management of long-endurance fixed-wing Unmanned Aerial Vehicles (UAVs). During high-altitude missions exceeding 24 h, electrical and thermal variables in the propulsion system exhibit strong coupling, multi-time-constant dynamics, and pronounced day-night operating-condition changes. These characteristics cause short-term fluctuations and long-term trends to coexist, making adaptive feature weighting difficult under time-varying variable sensitivities. Therefore, general-purpose time-series forecasting models often fail to satisfy the accuracy and robustness requirements of multivariate propulsion-system state prediction. To address these challenges, a Grouped Squeeze-and-Excitation Multi-scale Temporal Convolutional Network (GEMS-TCN) is proposed by enhancing a modern convolution-based forecasting backbone with Multi-scale Embedding (MsE) and Grouped Channel Attention. The proposed model performs accurate 10 s-ahead single-step prediction of 16 key propulsion-system states from 72-dimensional flight telemetry while satisfying the real-time inference requirement of the 1 Hz telemetry cycle. Methods Real-flight telemetry collected from a representative long-endurance fixed-wing UAV is used for model development and evaluation. The dataset is sampled at 1 Hz over nine consecutive days and contains 806 629 time steps and 72 variables ( Fig. 2 ). Sixteen propulsion-system states, including the bus voltage, control-unit temperature, winding temperature, and power-device temperature of four motors, are selected as prediction targets, whereas all 72 variables are used as model inputs (Table 1 ). The raw data are processed through time indexing, interquartile range (IQR)-based anomaly detection, and interpolation, and are then chronologically divided into training, validation, and test sets at a ratio of 8:1:1 to prevent information leakage (Figs. 4 and5 ). GEMS-TCN employs an MsE layer with parallel one-dimensional convolutions to extract temporal features at multiple receptive-field scales. Stacked GEMS-TCN blocks integrate Depthwise Convolution (DWConv), Convolutional Feed-Forward Networks (ConvFFNs), and Grouped Squeeze-and-Excitation (GroupSE) modules to hierarchically recalibrate intra-variable and cross-variable channel responses (Fig. 1 ). The models are trained using the Adam optimizer with the Mean Squared Error (MSE) loss function. Performance is evaluated using the Mean Absolute Error (MAE), MSE, and Symmetric Mean Absolute Percentage Error (SMAPE). PatchTST, ModernTCN, FEDformer, DLinear, and TimesNet are used as benchmark models. Ablation and robustness experiments are conducted for further validation.Results and Discussions On the complete 16-dimensional prediction task, GEMS-TCN achieves a test-set MAE of 0.171 and an MSE of 0.069 ( Table 4 ). Compared with TimesNet, the strongest baseline for trend tracking, GEMS-TCN reduces the MSE by 28.1% while maintaining comparable MAE and SMAPE, demonstrating improved suppression of large prediction errors (Table 4 ). Stable prediction accuracy is maintained under both daytime and nighttime operating conditions, with MAE/MSE values of 0.189/0.085 and 0.150/0.051, respectively, demonstrating robustness to operating-condition changes (Table 4 ). The predicted trajectories exhibit more accurate alignment at thrust-transition points, reduced overshoot, and fewer spurious spikes, while maintaining low-bias tracking of slowly varying nighttime temperature profiles (Fig. 7 ). Ablation experiments show that MsE and GroupSE each improve prediction performance, and their combination achieves the best overall performance, confirming that the two modules provide complementary benefits (Table 6 ). Under 1% and 5% random data dropouts and 60 s continuous data loss, the MSE remains below 0.07, demonstrating robustness to practical data-loss scenarios (Table 5 ). Furthermore, GEMS-TCN contains 27.88 M parameters and achieves an inference latency of 0.90 ms per sample, which is substantially shorter than the 1 s telemetry sampling interval.Conclusions GEMS-TCN provides an effective convolution-based framework for multivariate propulsion-system state prediction in long-endurance fixed-wing UAVs. By integrating MsE with hierarchical channel recalibration implemented through GroupSE, the proposed method simultaneously represents rapid fluctuations and slow temporal evolution, thereby improving the representation of multi-time-constant dynamics and multivariate coupling in propulsion-system telemetry. Real-flight experiments demonstrate stable prediction performance across daytime and nighttime operating conditions, different state categories, and data-loss scenarios. Ablation experiments further verify the effectiveness and complementarity of MsE and GroupSE. These results indicate that the proposed structure-aware modeling strategy provides effective support for propulsion-system health monitoring, early fault warning, and autonomous health management of long-endurance fixed-wing UAVs. -
表 1 16维待预测关键特征与故障预警任务关系表
1#~4#电机特征组 单位 物理含义 与故障预警任务的关系 母线电压 V 电机驱动侧直流供电水平以及负载扰动下的
母线稳定性异常下降或波动表征电池接近截止放电阈值、剩余航时下降及供电链路异常,是续航预测与任务级预警的重要先兆[26] 控制单元温度 ℃ 电机控制电子单元的热负荷水平与散热状态 异常升高常对应故障、开关异常或散热退化,
可用于推进系统早期告警与故障隔离[3]绕组温度 ℃ 电机定子绕组的热积累程度和绝缘系统受热水平 持续升高通常意味着过流、绕组绝缘退化或退化向电机侧传递,可作为电机热失效与性能衰退的关键预警量[27] 功率器件温度 ℃ 电机驱动器功率半导体器件的热应力水平 异常升高直接指向功率器件退化、开关频率异常与效率下降,严重时可导致失推,是驱动级健康管理的重要监测量[3]  下载: 导出CSV
表 2 数据集72维特征分组表
序号 特征组 数据项 1 推进系统 1#~4#电机实际转速、指令转速、母线电压、母线电流、D/Q轴电流、解算力矩、转子位置、
控制单元温度、绕组温度、功率器件温度2 供电系统 1#~8#单体电池电压 3 飞行控制 指示空速、真空速、地速 4 大气与环境 气压高度、海拔、左右两侧大气静温 5 辅助特征 帧计数器;1#~4#电机序号、电机系统状态、通信状态字
下载: 导出CSV
表 3 实验环境配置
硬件 配置 软件 配置 CPU Intel Xeon Gold 6330 操作系统 Ubuntu 22.04 GPU NVIDIA A100 PCIe 40 GB 编程框架 PyTorch 2.0.0
下载: 导出CSV
表 4 模型预测精度对比
方法 特征 MAE MSE SMAPE 白天 夜晚 全天 白天 夜晚 全天 白天 夜晚 全天 PatchTST A 0.406 0.322 0.371 0.303 0.174 0.249 0.115 0.025 0.078 B 0.269 0.261 0.265 0.128 0.105 0.117 0.001 0.001 0.001 C 0.546 0.417 0.494 0.476 0.264 0.389 0.188 0.065 0.131 W 0.482 0.352 0.427 0.435 0.211 0.338 0.144 0.012 0.093 P 0.326 0.256 0.298 0.175 0.117 0.153 0.127 0.023 0.086 ModernTCN A 0.330 0.260 0.303 0.230 0.130 0.190 0.110 0.019 0.071 B 0.278 0.218 0.253 0.152 0.091 0.126 0.001 0.001 0.001 C 0.221 0.198 0.211 0.092 0.068 0.082 0.148 0.043 0.097 W 0.491 0.320 0.425 0.453 0.189 0.349 0.159 0.012 0.100 P 0.331 0.306 0.323 0.221 0.170 0.204 0.133 0.022 0.087 FEDformer A 0.224 0.142 0.186 0.226 0.091 0.162 0.088 0.016 0.058 B 0.204 0.157 0.182 0.153 0.083 0.120 0.001 0.001 0.001 C 0.140 0.116 0.130 0.092 0.076 0.085 0.133 0.040 0.087 W 0.355 0.153 0.263 0.517 0.106 0.324 0.109 0.006 0.072 P 0.196 0.144 0.170 0.141 0.097 0.119 0.109 0.016 0.072 DLinear A 0.247 0.194 0.224 0.128 0.071 0.103 0.100 0.017 0.065 B 0.184 0.175 0.179 0.095 0.071 0.084 0.001 0.001 0.001 C 0.215 0.188 0.204 0.081 0.059 0.072 0.149 0.043 0.098 W 0.358 0.214 0.296 0.243 0.087 0.174 0.132 0.008 0.083 P 0.231 0.198 0.216 0.093 0.067 0.081 0.119 0.017 0.077 TimesNet A 0.178 0.122 0.152 0.126 0.061 0.096 0.085 0.014 0.055 B 0.173 0.153 0.163 0.108 0.079 0.094 0.001 0.001 0.001 C 0.126 0.098 0.114 0.068 0.050 0.060 0.133 0.036 0.085 W 0.263 0.126 0.200 0.257 0.066 0.167 0.102 0.005 0.067 P 0.148 0.111 0.130 0.071 0.050 0.061 0.104 0.014 0.068 GEMS-TCN (本文方法) A 0.189 0.150 0.171 0.085 0.051 0.069 0.092 0.015 0.059 B 0.155 0.151 0.153 0.081 0.066 0.073 0.001 0.001 0.001 C 0.153 0.125 0.141 0.053 0.036 0.045 0.139 0.037 0.089 W 0.254 0.174 0.220 0.133 0.055 0.097 0.114 0.006 0.072 P 0.191 0.149 0.171 0.074 0.047 0.061 0.113 0.015 0.073 注:特征列中A代表1#~4#电机完整16维特征,而B, C, W, P分别代表1#~4#电机的母线电压、控制单元温度、绕组温度以及功率器件温度。
下载: 导出CSV
表 5 模型鲁棒性对比(MSE)
模型 无扰动 数据掉点(1%) 数据掉点(5%) 高斯噪声(0.05) 高斯噪声(0.10) 连续缺失(60 s) PatchTST 0.2493 0.2493 0.2496 2.4646 9.1779 0.2493 ModernTCN 0.1903 0.1903 0.1904 2.1375 8.0099 0.1903 FEDformer 0.1623 0.1623 0.1622 2.0433 7.7212 0.1623 DLinear 0.1026 0.1026 0.1028 2.0310 7.8473 0.1026 TimesNet 0.0956 0.0956 0.0956 2.0407 7.8970 0.0956 GEMS-TCN(本文方法) 0.0693 0.0694 0.0697 2.2460 8.8151 0.0693 注:加粗数值为指标最优值。
下载: 导出CSV
表 6 不同模块对预测精度的影响
模型 Multi-Scale Embedding GroupSE MAE MSE ModernTCN × × 0.303 0.190 Model1 √ × 0.199 0.085 Model2 × √ 0.219 0.098 Model3 √ √ 0.171 0.069
下载: 导出CSV
-
[1] PAL O K, SHOVON M S H, MRIDHA M F, et al. In-depth review of AI-enabled unmanned aerial vehicles: Trends, vision, and challenges[J]. Discover Artificial Intelligence, 2024, 4(1): 97. doi: 10.1007/s44163-024-00209-1. [2] RAI S, RAWAT A, and KUMAR A. Design and performance analysis of high-altitude UAVs: Trends, challenges, and innovations[J]. Discover Applied Sciences, 2025, 7(8): 833. doi: 10.1007/s42452-025-07357-8. [3] TANG Liang, SAXENA A, and YOUNSI K. Prognostics and health management for electrified aircraft propulsion: State of the art and challenges[J]. Journal of Engineering for Gas Turbines and Power, 2025, 147(4): 041018. doi: 10.1115/1.4066598. [4] ADAIKA Z, AL-HADDAD L A, GIERNACKI W, et al. Fault detection and diagnosis methodologies for unmanned aerial vehicles: State-of-the-art[J]. Journal of Intelligent & Robotic Systems, 2025, 111(2): 63. doi: 10.1007/s10846-025-02267-8. [5] GONG Wenquan, LI Bo, AHN C K, et al. Prescribed-time extended state observer and prescribed performance control of quadrotor UAVs against actuator faults[J]. Aerospace Science and Technology, 2023, 138: 108322. doi: 10.1016/j.ast.2023.108322. [6] ZHOU Laihong, JIN Hong, CHEN Ping, et al. Actuator fault detection method of quadrotor UAV based on dual channel inertial sensors[J]. Discover Applied Sciences, 2025, 7(7): 736. doi: 10.1007/s42452-025-07403-5. [7] LIANG Shaojun, ZHANG Shirong, HUANG Yuping, et al. Data-driven fault diagnosis of FW-UAVs with consideration of multiple operation conditions[J]. ISA Transactions, 2022, 126: 472–485. doi: 10.1016/j.isatra.2021.07.043. [8] ZHANG Yizong, LI Shaobo, ZHANG Ansi, et al. FW-UAV fault diagnosis based on knowledge complementary network under small sample[J]. Mechanical Systems and Signal Processing, 2024, 215: 111418. doi: 10.1016/j.ymssp.2024.111418. [9] GUO Kai, WANG Na, LIU Datong, et al. Uncertainty-aware LSTM based dynamic flight fault detection for UAV actuator[J]. IEEE Transactions on Instrumentation and Measurement, 2023, 72: 3502113. doi: 10.1109/TIM.2022.3225040. [10] CHU Xiaoyan, ZHOU Xu, BU Qixuan, et al. Sensor fault detection for UAVs using improved self-attention LSTM network with similarity space mapping[J]. IEEE Transactions on Instrumentation and Measurement, 2024, 73: 3528612. doi: 10.1109/TIM.2024.3450064. [11] WANG Shengdong, JIA Zhen, LIU Zhenbao, et al. Self-supervised contrast learning based UAV fault detection and interpretation with spatial-temporal information of multivariate flight data[J]. Expert Systems with Applications, 2025, 267: 126156. doi: 10.1016/j.eswa.2024.126156. [12] FANG Jie, LI Shaobo, ZHANG Yizong, et al. Fault diagnosis of UAV sensors based on multi-auxiliary task learning with few samples[J]. Journal of Computational Design and Engineering, 2025, 12(12): 142–160. doi: 10.1093/jcde/qwaf117. [13] 张景森, 侯彪, 李志杰, 等. 结合姿态不变性特征和半监督复兴稠密生成对抗分类网络模型的飞控系统故障诊断方法[J]. 电子与信息学报, 2026, 48(1): 264–276. doi: 10.11999/JEIT250964.ZHANG Jingsen, HOU Biao, LI Zhijie, et al. A fault diagnosis method for flight control systems combining pose-invariant features and a semi-supervised RDC-GAN model[J]. Journal of Electronics & Information Technology, 2026, 48(1): 264–276. doi: 10.11999/JEIT250964. [14] 潘金伟, 王乙乔, 钟博, 等. 基于统计特征搜索的多元时间序列预测方法[J]. 电子与信息学报, 2024, 46(8): 3276–3284. doi: 10.11999/JEIT231264.PAN Jinwei, WANG Yiqiao, ZHONG Bo, et al. Statistical feature-based search for multivariate time series forecasting[J]. Journal of Electronics & Information Technology, 2024, 46(8): 3276–3284. doi: 10.11999/JEIT231264. [15] 杨真真, 徐奕, 万成业, 等. 融合多尺度频域适配器和双路注意力的时序预测[J]. 电子与信息学报, 2026, 48(4): 1795–1805. doi: 10.11999/JEIT251188.YANG Zhenzhen, XU Yi, WAN Chengye, et al. Multi-scale frequency adapter and dual-path attention for time series forecasting[J]. Journal of Electronics & Information Technology, 2026, 48(4): 1795–1805. doi: 10.11999/JEIT251188. [16] NIE Yuqi, NGUYEN N H, SINTHONG P, et al. A time series is worth 64 words: Long-term forecasting with transformers[C]. The Eleventh International Conference on Learning Representations, Kigali, Rwanda, 2023. [17] WU Haixu, HU Tengge, LIU Yong, et al. TimesNet: Temporal 2D-variation modeling for general time series analysis[C]. The Eleventh International Conference on Learning Representations, Kigali, Rwanda, 2023. [18] ZENG Ailing, CHEN Muxi, ZHANG Lei, et al. Are transformers effective for time series forecasting?[C]. The 37th AAAI Conference on Artificial Intelligence, Washington, USA, 2023: 11121–11128. doi: 10.1609/aaai.v37i9.26317. [19] LUO Donghao and WANG Xue. ModernTCN: A modern pure convolution structure for general time series analysis[C]. The Twelfth International Conference on Learning Representations, Vienna, Austria, 2024: 1–43. [20] SZEGEDY C, LIU Wei, JIA Yangqing, et al. Going deeper with convolutions[C]. 2015 IEEE Conference on Computer Vision and Pattern Recognition (CVPR), Boston, USA, 2015: 1–9. doi: 10.1109/CVPR.2015.7298594. [21] HU Jie, SHEN Li, and SUN Gang. Squeeze-and-excitation networks[C]. 2018 IEEE/CVF Conference on Computer Vision and Pattern Recognition, Salt Lake City, USA, 2018: 7132–7141. doi: 10.1109/CVPR.2018.00745. [22] HOWARD A G, ZHU Menglong, CHEN Bo, et al. MobileNets: Efficient convolutional neural networks for mobile vision applications[EB/OL]. https://arxiv.org/abs/1704.04861, 2017. doi: 10.48550/arXiv.1704.04861. [23] HE Kaiming, ZHANG Xiangyu, REN Shaoqing, et al. Deep residual learning for image recognition[C]. 2016 IEEE Conference on Computer Vision and Pattern Recognition (CVPR), Las Vegas, USA, 2016: 770–778. doi: 10.1109/CVPR.2016.90. [24] IOFFE S and SZEGEDY C. Batch normalization: Accelerating deep network training by reducing internal covariate shift[C]. The 32nd International Conference on Machine Learning, Lille, France, 2015: 448–456. [25] LUO Wenjie, LI Yujia, URTASUN R, et al. Understanding the effective receptive field in deep convolutional neural networks[C]. The 30th International Conference on Neural Information Processing Systems, Barcelona, Spain, 2016: 4905–4913. [26] ALCIBAR J, AIZPURUA J I, ZUGASTI E, et al. A hybrid probabilistic battery health management approach for robust inspection drone operations[J]. Engineering Applications of Artificial Intelligence, 2025, 146: 110246. doi: 10.1016/j.engappai.2025.110246. [27] YANG Mengchen and PHUNG B T. Motor winding insulation degradation under repetitive voltage pulses[J]. IEEE Access, 2024, 12: 77658–77674. doi: 10.1109/ACCESS.2024.3406490. [28] ZHOU Tian, MA Ziqing, WEN Qingsong, et al. FEDformer: Frequency enhanced decomposed transformer for long-term series forecasting[C]. The 39th International Conference on Machine Learning, Baltimore, USA, 2022: 27268–27286. [29] WANG Yuxuan, WU Haixu, DONG Jiaxiang, et al. Deep time series models: A comprehensive survey and benchmark[J]. IEEE Transactions on Pattern Analysis and Machine Intelligence, 2026: 1–20. doi: 10.1109/TPAMI.2026.3690845. [30] KINGMA D and BA J. Adam: A method for stochastic optimization[C]. 3rd International Conference on Learning Representations, San Diego, USA, 2015. [31] SWEENEY A J and FU Qiang. Diurnal cycles of synthetic microwave sounding Lower-stratospheric temperatures from radio occultation observations, reanalysis, and model simulations[J]. Journal of Atmospheric and Oceanic Technology, 2021, 38(12): 2045–2059. doi: 10.1175/JTECH-D-21-0071.1. -

 下载:

图(7) / 表(6)
计量
- 文章访问数: 618
- HTML全文浏览量: 189
- PDF下载量: 33
- 被引次数: 0
